
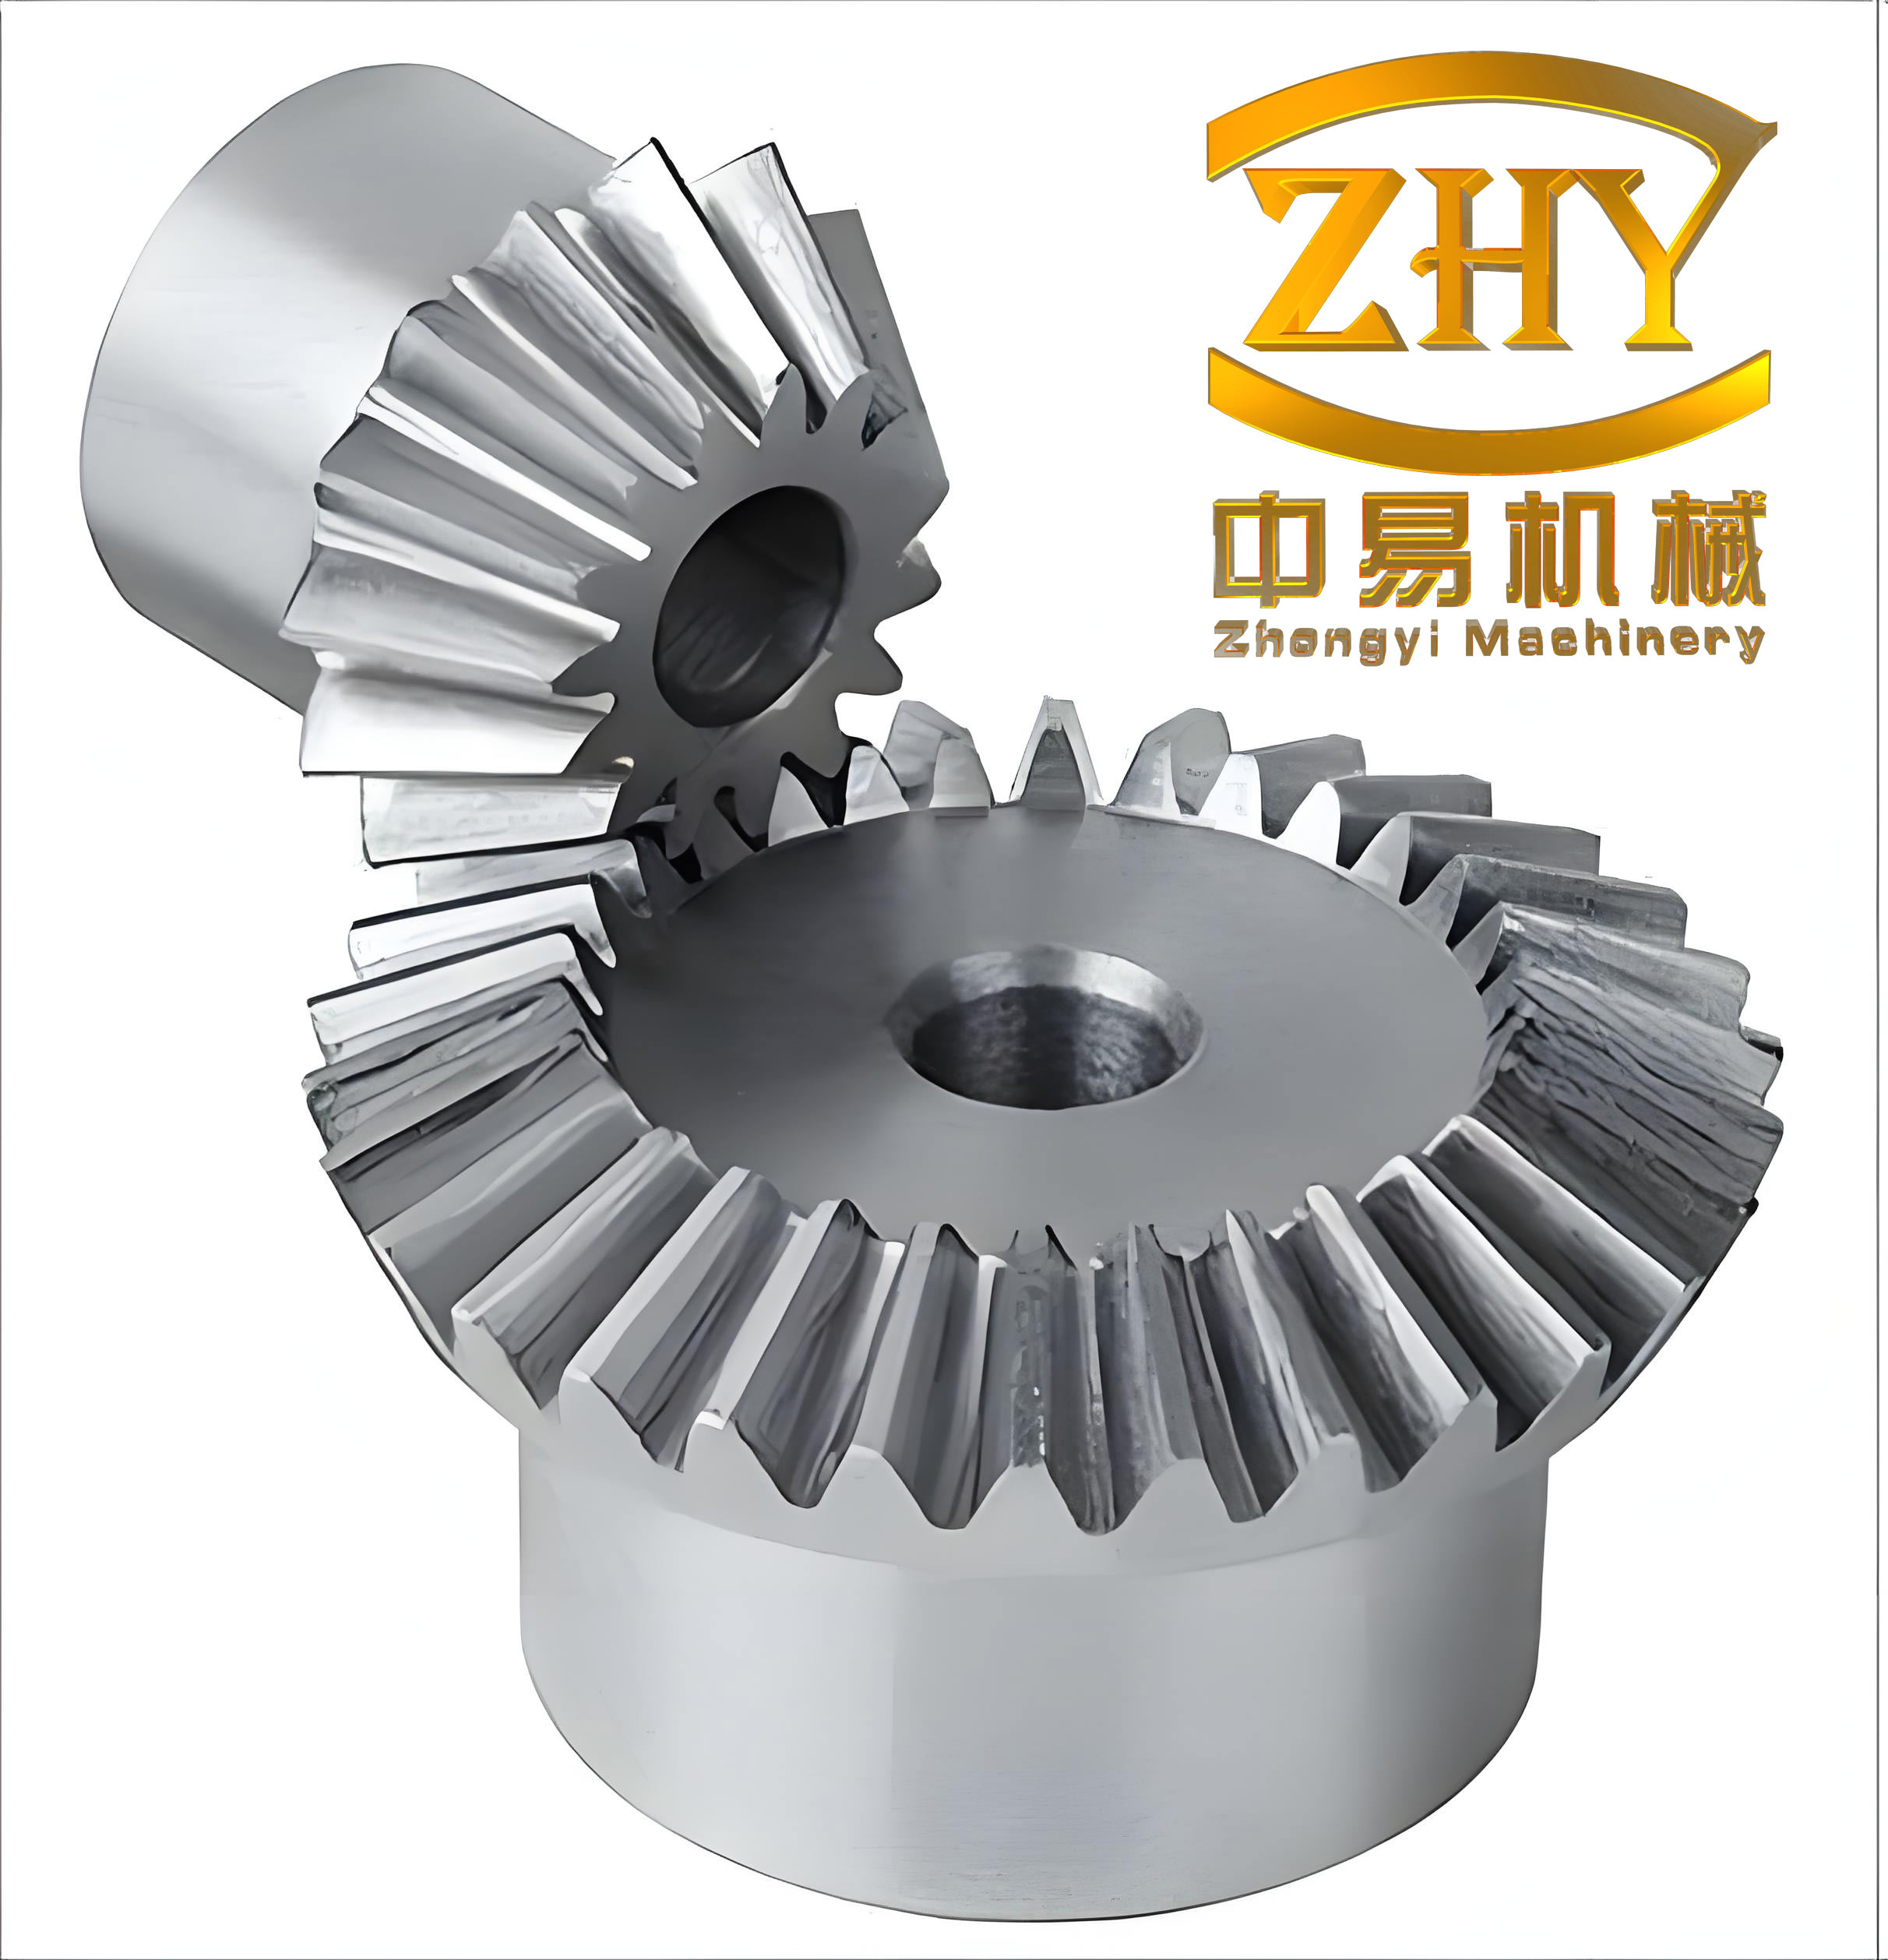
I have focused on the problem of low machining efficiency for small-module straight bevel gears. In many industrial fields, including automotive, aerospace, and defense applications, the straight bevel gear remains a critical transmission element because it can transfer motion between intersecting axes with a compact structure, high transmission efficiency, accurate motion, and long service life. However, compared with spiral bevel gears and hypoid gears, the manufacturing equipment and processing technology for straight bevel gears have developed more slowly. Many existing machines for straight bevel gear production are mechanical types that rely on complex kinematic chains. These machines require tedious adjustments, and their productivity and accuracy are often limited. Therefore, I developed a high-speed hobbing-milling method for small-module straight bevel gears based on a six-axis CNC spiral bevel gear milling machine. The method uses a carbide-tipped single-position hob and continuous indexing, and it is verified through virtual simulation and practical cutting tests.
In my work, the straight bevel gear is not produced by a traditional planing process or by a double-cutter disk process. Instead, I use a forming method with a special hob. The straight bevel gear tooth profile is generated by the cutting edge shape of the hob, and the workpiece rotates continuously with a fixed ratio relative to the cutter. This continuous indexing eliminates the retracting, indexing, and re-entering motions that are unavoidable in single-indexing methods. As a result, the machining time is drastically reduced. For the same workpiece, the hobbing-milling time on the CNC machine is only about 10% to 13.3% of the time required by a conventional mechanical planing machine. This improvement is especially important for small-module straight bevel gears, where batch sizes can be large and production cost is sensitive to cycle time.
Fundamental Geometry of a Straight Bevel Gear
Before describing the machining process, I summarize the basic geometry of a straight bevel gear. The pitch cone angles are determined by the numbers of teeth. For a pair of straight bevel gears with shaft angle \( \Sigma = 90^\circ \), the pitch cone angles \( \delta_1 \) and \( \delta_2 \) satisfy
$$ \tan\delta_1 = \frac{z_1}{z_2}, \qquad \tan\delta_2 = \frac{z_2}{z_1}, \qquad \delta_1 + \delta_2 = 90^\circ. $$
Here \( z_1 \) and \( z_2 \) are the tooth numbers of the pinion and the gear, respectively. The outer cone distance \( R \) is related to the module and the pitch cone angle by
$$ R = \frac{m_t z}{2 \sin\delta}, $$
where \( m_t \) is the transverse module and \( z \) is the number of teeth. The face width \( b \) should be limited to a fraction of the cone distance. For small-module straight bevel gears, a common recommendation is
$$ b \le 0.25 R \quad \text{or sometimes} \quad b \le 0.30 R. $$
When the face width is kept below about 25% of the outer cone distance, the deviation of the actual tooth profile from the theoretical involute at the small end has only a minor influence on the meshing performance. This is the geometric basis that makes the single-position hob method acceptable for small-module straight bevel gears.
The equivalent virtual tooth number is another important parameter. It is given by
$$ z_v = \frac{z}{\cos\delta}. $$
This equivalent tooth number is used to select the hob and to evaluate the tooth profile approximation. The profile of the straight bevel gear is usually defined on the back cone. When the back cone is developed into a plane, the tooth profile becomes an involute. For a small-module straight bevel gear, the hob cutting edge is designed according to this back-cone involute at the large end. The small end will be slightly thicker at the addendum than the theoretical involute, but for small modules and narrow face widths this deviation is acceptable.
Form-Milling Principle with a Single-Position Hob
The core of my method is the use of a single-position hob. This hob is also called a fixed-position hob or a special straight bevel gear hob. Its cutting teeth are arranged along a helical thread, but only about one turn of the basic worm thread is retained to avoid interference. The cutting edges are designed according to the large-end tooth profile of the straight bevel gear. In the axial direction, the teeth are often arranged in a staggered manner. Two teeth that are 180 degrees apart form a group, and they cut the left and right flanks of the gear tooth respectively. The axial offset between adjacent teeth is half of the hob thread pitch. The number of cutting teeth is typically 5 or 7 for a single-start hob. Because the hob is made of carbide and coated, it can run at high speed, which further increases productivity.
The hob tooth profile can be determined by two main methods. The first is the approximate circular-arc method, in which one or two arcs replace the theoretical involute. The second is the exact method, in which the cutting edge is designed and manufactured according to the conjugate profile on the back-cone development. The exact method is more precise, but it is complex to calculate and difficult to dress on the grinding wheel during tooth relieving. In engineering practice, the circular-arc approximation is often used for small-module gears because it provides a good balance between accuracy and manufacturability. I adopted this practical approach in my tool design.
The basic worm thread of the hob has a lead angle \( \lambda \). The axial pitch \( p_x \) and the normal pitch \( p_n \) are related by
$$ p_x = \frac{p_n}{\cos\lambda}. $$
The hob rotates at a high speed \( n_c \), and the workpiece rotates at a speed \( n_w \) such that the ratio is exactly the number of teeth:
$$ n_w = \frac{n_c}{z}. $$
This relationship ensures that the hob passes through each tooth slot continuously. There is no need to stop the cutting process for indexing. The workpiece is fed relative to the hob along a path that consists of two linear segments. The first segment is perpendicular to the pitch cone generatrix and cuts to the full tooth depth at the large end. The second segment is along the pitch cone generatrix and completes the full face width. This two-stage feed strategy is simple, rigid, and efficient.
Machine Tool Configuration
The machine I used is a six-axis CNC spiral bevel gear milling machine. It has three linear axes \( X \), \( Y \), and \( Z \), and three rotary axes \( A \), \( B \), and \( C \). The \( A \) axis is the workpiece spindle, which carries the straight bevel gear blank. The \( C \) axis is the cutter spindle, which carries the hob. The \( B \) axis adjusts the angle between the workpiece axis and the cutter axis. This configuration allows the machine to produce spiral bevel gears, hypoid gears, high-reduction hypoid gears, and straight bevel gears. The machine is especially designed for small-module applications, and its main specifications are listed in Table 1.
| Parameter category | Parameter name | Value |
|---|---|---|
| Workpiece parameters | Maximum gear outer diameter | 120 mm |
| Maximum module | 4 mm | |
| Maximum face width | 30 mm | |
| Maximum full tooth depth | 10 mm | |
| Number of teeth range | 1 to 200 | |
| Maximum transmission ratio | 100:1 | |
| Cutter parameters | Maximum cutter diameter | 101.6 mm |
| Minimum cutter diameter | 25.4 mm | |
| Linear travel | \( X \) axis | \( -210 \) to \( +210 \) mm |
| \( Y \) axis | \( -100 \) to \( +45 \) mm | |
| \( Z \) axis | \( -25 \) to \( +240 \) mm | |
| \( B \) axis | \( -95^\circ \) to \( +95^\circ \) | |
| Spindle speed | \( A \) axis | 0 to 200 rpm |
| \( C \) axis | 0 to 3500 rpm |
The machine uses a CNC controller that can be programmed for the special kinematics of straight bevel gear hobbing. I developed a dedicated NC program generator. The operator inputs the cutter parameters, the basic geometric parameters of the straight bevel gear, and the fixture parameters. The software then automatically generates the NC program. The program controls the coordinated motion of all axes so that the hob and the workpiece perform the required continuous indexing and feed motions.
Tool Design and Cutting Parameters
The hob I used has a diameter of 25.4 mm and a lead angle of 1 degree. The material is coated carbide. The cutting speed is determined by the hob diameter and the spindle speed:
$$ v_c = \frac{\pi D_c n_c}{1000}, $$
where \( D_c \) is the hob diameter in mm and \( n_c \) is the cutter speed in rpm. With \( D_c = 25.4 \) mm and \( n_c = 1500 \) rpm, the cutting speed is approximately
$$ v_c = \frac{\pi \times 25.4 \times 1500}{1000} \approx 119.7 \ \text{m/min}. $$
This is a high cutting speed for a small-module straight bevel gear, and it is possible because the hob is made of carbide and the machine has a high-speed spindle. The feed per workpiece revolution \( f_z \) and the number of teeth \( z \) determine the feed speed along the workpiece:
$$ v_f = f_z z n_w. $$
The machining time for one straight bevel gear can be approximated by
$$ T = \frac{L}{v_f} + T_a, $$
where \( L \) is the total feed length and \( T_a \) is the auxiliary time for loading, unloading, and rapid motions. In my process, the total feed length is the sum of the radial infeed length and the axial feed length along the pitch cone generatrix. Because the continuous indexing eliminates the indexing time, the auxiliary time is small. The actual machining time is dominated by the two linear feed segments.
Table 2 lists the main process parameters for the straight bevel gear pair used in my tests. The pinion has 37 teeth, the gear has 74 teeth, the transverse module is 0.5 mm, the pressure angle is 20 degrees, and the face width is 5 mm. These parameters represent a typical small-module straight bevel gear pair.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth \( z \) | 37 | 74 |
| Transverse module \( m_t \) | 0.5 mm | 0.5 mm |
| Pressure angle \( \alpha \) | 20° | 20° |
| Face width \( b \) | 5 mm | 5 mm |
| Pitch cone angle \( \delta \) | \( \arctan(37/74) = 26.565^\circ \) | \( \arctan(74/37) = 63.435^\circ \) |
| Outer cone distance \( R \) | \( \frac{0.5 \times 37}{2 \sin 26.565^\circ} \approx 20.64 \) mm | \( \frac{0.5 \times 74}{2 \sin 63.435^\circ} \approx 20.64 \) mm |
| Face width ratio \( b/R \) | 0.242 | 0.242 |
| Equivalent tooth number \( z_v \) | \( 37 / \cos 26.565^\circ \approx 41.4 \) | \( 74 / \cos 63.435^\circ \approx 165.5 \) |
Vericut Simulation Environment
I used Vericut to build a virtual machining environment before the actual cutting test. The simulation flow is as follows. First, I established the machine model. Because the standard Vericut library did not contain the exact model of my six-axis CNC spiral bevel gear milling machine, I created the three-dimensional models of the machine components and the hob in a CAD system. Then I imported these models into Vericut and defined the topological relationships among the motion axes. The machine model includes the linear axes \( X \), \( Y \), and \( Z \), the rotary axes \( A \), \( B \), and \( C \), and the fixture. The cutter model includes the hob, the holder, and the extension rod. I set the tool reference point and the tool length according to the actual setup.
Second, I imported the CNC program generated by my dedicated software into Vericut. The program includes the tool parameters, the workpiece parameters, and the fixture parameters. Third, I created the workpiece blank model and the theoretical straight bevel gear model. Fourth, I ran the simulation. During the simulation, I could observe whether any collision or interference occurred between the machine components, the cutter, and the workpiece. This reduced the risk of costly mistakes in the real machining process.
Table 3 summarizes the steps of the virtual machining workflow.
| Step | Action | Purpose |
|---|---|---|
| 1 | Build 3D models of machine and hob | Create accurate geometry for simulation |
| 2 | Import models into Vericut | Establish the virtual machine environment |
| 3 | Define axis topology and tool library | Represent the real kinematic chain |
| 4 | Input straight bevel gear parameters | Generate the workpiece blank and target gear |
| 5 | Load NC program | Drive the virtual machine |
| 6 | Run simulation | Check interference and program correctness |
| 7 | Analyze simulated tooth surface | Compare with theoretical straight bevel gear |
The simulation confirmed that the NC program was correct and that the machine axes moved without collision. It also allowed me to visualize the material removal process and to verify the two-stage feed path. The virtual straight bevel gear tooth surface was compared with the theoretical surface, and the deviation was within the expected range for this forming method.
Machining Strategy and NC Program Generation
The machining strategy for the straight bevel gear consists of the following steps. The workpiece is clamped on the \( A \) axis. The hob is mounted on the \( C \) axis. The \( B \) axis is set to the required angle between the workpiece axis and the cutter axis. The hob rotates at \( n_c \). The workpiece rotates at \( n_w = n_c / z \). The relative feed motion is divided into two linear segments. The first segment is perpendicular to the pitch cone generatrix, and it moves from point 1 to point 2. At point 2, the full tooth depth is reached at the large end. The second segment moves from point 2 to point 3 along the pitch cone generatrix, and it completes the full face width. After point 3 is reached, the hob and the workpiece continue to rotate, and the next tooth slot is cut automatically because of the continuous indexing.
The coordinates of the feed path can be expressed in the machine coordinate system. Let the large end of the straight bevel gear be at the cone distance \( R \). The radial infeed \( h_r \) and the axial feed \( h_a \) are related to the tooth depth \( H \) and the pitch cone angle \( \delta \) by
$$ h_r = H \cos\delta, \qquad h_a = H \sin\delta. $$
In my process, the full tooth depth \( H \) is determined by the module and the addendum and dedendum coefficients. For a standard straight bevel gear,
$$ H = (h_a^* + h_f^*) m_t, $$
where \( h_a^* \) is the addendum coefficient and \( h_f^* \) is the dedendum coefficient. For the test gear pair, \( m_t = 0.5 \) mm, and with standard coefficients \( h_a^* = 1 \) and \( h_f^* = 1.25 \), the full tooth depth is
$$ H = (1 + 1.25) \times 0.5 = 1.125 \ \text{mm}. $$
The radial infeed and axial feed for the pinion are
$$ h_r = 1.125 \cos 26.565^\circ \approx 1.006 \ \text{mm}, \qquad h_a = 1.125 \sin 26.565^\circ \approx 0.503 \ \text{mm}. $$
For the gear,
$$ h_r = 1.125 \cos 63.435^\circ \approx 0.503 \ \text{mm}, \qquad h_a = 1.125 \sin 63.435^\circ \approx 1.006 \ \text{mm}. $$
These values are used in the NC program to define the two feed segments. The program also includes the rapid approach, the tool retraction, and the safe positions. Because the continuous indexing is synchronized with the spindle rotation, the program must maintain a strict electronic gear ratio between the \( A \) axis and the \( C \) axis. The ratio is
$$ \frac{n_A}{n_C} = \frac{1}{z}. $$
Any error in this ratio would cause tooth spacing errors. Therefore, the CNC system must have high synchronization accuracy. The six-axis machine I used has this capability.
Simulation Verification of the Straight Bevel Gear
I performed the simulation with the actual gear pair parameters. The pinion has 37 teeth and the gear has 74 teeth. The module is 0.5 mm, the pressure angle is 20 degrees, and the face width is 5 mm. The hob diameter is 25.4 mm, the lead angle is 1 degree, and the cutter speed is 1500 rpm. The simulation showed that the hob cut the straight bevel gear tooth slots correctly. The left and right flanks were formed by the staggered cutting teeth. The continuous indexing produced uniform tooth spacing. No interference was observed between the hob and the workpiece, and no collision occurred between the machine components.
I also compared the simulated tooth surface with the theoretical straight bevel gear surface. The maximum deviation in the simulation was small, and it was mainly caused by the circular-arc approximation of the hob profile and by the small-end profile deviation inherent in the forming method. This result confirmed the feasibility of the CNC machining process and the correctness of the NC program. It also gave me confidence to proceed to actual cutting tests.
Practical Cutting and Inspection
After the simulation, I conducted practical cutting experiments on the six-axis CNC machine. The same hob and the same process parameters were used. The straight bevel gear blanks were clamped on the workpiece spindle. The machine ran the NC program automatically. The pinion and the gear were machined separately. The cutting process was stable, and the chip evacuation was good. The carbide hob showed no significant wear after the test. The machining time for the gear was 6 minutes, and the machining time for the pinion was also 6 minutes. In contrast, a conventional mechanical planing machine required 60 minutes for the gear and 45 minutes for the pinion. The comparison is shown in Table 4.
| Machine | Gear machining time (min) | Pinion machining time (min) | Relative time for gear | Relative time for pinion |
|---|---|---|---|---|
| Six-axis CNC hobbing-milling machine | 6 | 6 | 10.0% | 13.3% |
| Conventional mechanical planing machine | 60 | 45 | 100% | 100% |
The machined straight bevel gears were inspected on a gear measuring center. I measured the pitch accuracy and the tooth profile error. The pitch accuracy was evaluated by the single pitch deviation \( f_p \) and the total cumulative pitch deviation \( F_p \). The tooth profile error was evaluated by comparing the actual tooth surface with the theoretical surface. The theoretical surface was defined according to the spatial meshing principle of straight bevel gears. The measurement results are summarized in Table 5.
| Inspection item | Pinion | Gear | DIN grade |
|---|---|---|---|
| Single pitch deviation \( f_p \) | Within DIN 4 | Within DIN 4 | 4 |
| Total cumulative pitch deviation \( F_p \) | Within DIN 4 | Within DIN 4 | 4 |
| Maximum tooth profile error | 7.4 μm | -5.4 μm | — |
The single pitch deviation \( f_p \) is defined as the algebraic difference between the actual pitch and the theoretical pitch:
$$ f_p = p_{\text{actual}} – p_{\text{theoretical}}. $$
The total cumulative pitch deviation \( F_p \) is the maximum difference between the cumulative pitch deviations over all teeth:
$$ F_p = \max_{i} \left( \sum_{j=1}^{i} f_{p,j} \right) – \min_{i} \left( \sum_{j=1}^{i} f_{p,j} \right). $$
The tooth profile error \( \Delta_f \) is defined as the maximum absolute deviation between the actual profile and the theoretical profile along the normal direction:
$$ \Delta_f = \max \left| y_{\text{actual}}(x) – y_{\text{theory}}(x) \right|. $$
For the pinion, the maximum tooth profile error was 7.4 μm. For the gear, the maximum tooth profile error was -5.4 μm. Both values are very small for a small-module straight bevel gear. The pitch accuracy reached DIN 4. After assembly and testing by the user, the gear pair met the application requirements completely. This confirmed that the forming method with the single-position hob is suitable for small-module straight bevel gears when the face width is limited to about 25% of the outer cone distance.
Error Sources and Accuracy Analysis
The accuracy of the straight bevel gear produced by my method depends on several factors. The most important are the hob profile accuracy, the synchronization accuracy between the \( A \) and \( C \) axes, the machine geometric accuracy, the workpiece clamping accuracy, and the thermal deformation during cutting. Table 6 lists the main error sources and their approximate contributions.
| Error source | Type | Effect on straight bevel gear | Control method |
|---|---|---|---|
| Hob profile approximation | Systematic | Tooth profile deviation | Accurate tool design and grinding |
| Hob manufacturing error | Random and systematic | Profile and pitch deviation | Precision tool inspection |
| Axis synchronization error | Dynamic | Pitch deviation and tooth spacing error | High-bandwidth CNC synchronization |
| Machine geometric error | Systematic | Profile and lead deviation | Machine calibration and compensation |
| Workpiece clamping error | Random | Runout and pitch deviation | Precise fixture and dial indicator |
| Thermal deformation | Time-dependent | Profile and pitch drift | Coolant and thermal stability |
| Tool wear | Progressive | Profile change and surface roughness | Tool life monitoring and replacement |
The hob profile approximation is the largest systematic error source. Because the cutting edge is designed on the back-cone involute at the large end, the small end of the straight bevel gear has a slightly different profile. The deviation increases with the face width and with the cone angle. For the test gear pair, the face width ratio was 0.242, which is below the recommended limit of 0.25. Therefore, the small-end deviation was acceptable. If the face width were larger, the deviation would become significant, and the straight bevel gear might not mesh correctly. This is the main limitation of the single-position hob method.
The synchronization error between the \( A \) and \( C \) axes directly affects the pitch accuracy. If the ratio \( n_A / n_C \) deviates from \( 1/z \) by \( \Delta r \), the pitch deviation over one tooth is approximately
$$ \Delta p \approx \frac{\pi m_t z}{z} \Delta r = \pi m_t \Delta r. $$
For \( m_t = 0.5 \) mm and a synchronization error of \( 10^{-4} \), the pitch deviation would be about \( 0.157 \) μm, which is negligible. However, if the synchronization error is \( 10^{-3} \), the pitch deviation would be about \( 1.57 \) μm, which could affect the DIN grade. Therefore, the CNC system must maintain a synchronization error well below \( 10^{-3} \). The machine I used achieved this level.
Comparison with Conventional Planing
The conventional planing process for straight bevel gears uses a single-indexing method. The cutter or the workpiece must retract, index, and re-enter for each tooth slot. This consumes a large amount of non-cutting time. In addition, the planing process usually requires a mechanical machine with a complex kinematic chain. The setup is time-consuming, and the cutting speed is limited by the tool material and the machine rigidity. My hobbing-milling method uses continuous indexing and a carbide hob. The cutting speed is much higher, and the non-cutting time is almost eliminated. Table 7 compares the two processes for the same straight bevel gear.
| Comparison item | Conventional planing | My hobbing-milling method |
|---|---|---|
| Indexing method | Single indexing | Continuous indexing |
| Cutting tool | Planer tool or double cutter disk | Carbide single-position hob |
| Machine type | Mechanical planing machine | Six-axis CNC milling machine |
| Cutting speed | Low to moderate | High |
| Non-cutting time | Large | Very small |
| Setup flexibility | Low | High |
| Machining time for gear | 60 min | 6 min |
| Machining time for pinion | 45 min | 6 min |
| Relative productivity | 1 | 7.5 to 10 |
| Accuracy capability | DIN 6 to 7 typical | DIN 4 achieved |
The productivity improvement is dramatic. For the gear, the machining time is reduced from 60 minutes to 6 minutes, which is a factor of 10. For the pinion, the machining time is reduced from 45 minutes to 6 minutes, which is a factor of 7.5. In terms of percentage, the hobbing-milling time is only 10% of the planing time for the gear and 13.3% for the pinion. This is a significant improvement for small-module straight bevel gear production. The accuracy is also better. The pitch accuracy reaches DIN 4, and the profile error is less than 7.4 μm in magnitude. The conventional planing process typically achieves DIN 6 or 7 for small-module straight bevel gears. Therefore, my method is superior in both efficiency and accuracy.
Material Removal Rate and Cutting Forces
I also analyzed the material removal rate and the cutting forces. The material removal rate \( Q \) can be estimated by
$$ Q = A_c v_c, $$
where \( A_c \) is the chip cross-sectional area and \( v_c \) is the cutting speed. For a small-module straight bevel gear, the chip cross section is small, but the cutting speed is high. Therefore, the material removal rate is still reasonable. The cutting force per tooth \( F_c \) can be approximated by
$$ F_c = K_c A_c, $$
where \( K_c \) is the specific cutting force. For the carbide hob and the small-module straight bevel gear, the specific cutting force is moderate because the chip thickness is small. The total cutting force is distributed over several teeth because the hob has multiple cutting edges in contact. This reduces the load on each tooth and improves the stability of the process. The high spindle speed of the \( C \) axis, up to 3500 rpm, allows the use of a small-diameter hob with a high cutting speed. This is advantageous for small-module straight bevel gears because the tool can be rigid and the chip evacuation is good.
The feed per tooth \( f_z \) has a strong influence on the cutting force and the surface finish. If \( f_z \) is too large, the cutting force increases, and the tooth surface roughness becomes worse. If \( f_z \) is too small, the cutting edge rubs instead of cutting, and the tool wear increases. I selected the feed per tooth based on the module, the workpiece material, and the tool coating. For the test gear pair, the feed per tooth was set to a moderate value that balanced productivity and surface quality. The resulting tooth surface had no visible chatter marks, and the profile error was small.
Thermal Behavior and Cooling
High-speed machining generates heat. In my process, the cutting speed was about 120 m/min, which is high for a small-module straight bevel gear. The heat is generated mainly at the cutting edge and in the chip. If the heat is not controlled, the workpiece can expand, and the tooth profile can deviate from the theoretical shape. The hob can also wear rapidly. I used a flood coolant to remove the heat and to flush the chips. The coolant was directed at the cutting zone. The thermal expansion of the workpiece was estimated by
$$ \Delta L = \alpha L \Delta T, $$
where \( \alpha \) is the coefficient of thermal expansion, \( L \) is the characteristic length, and \( \Delta T \) is the temperature rise. For steel, \( \alpha \approx 11 \times 10^{-6} \ \text{K}^{-1} \). If the temperature rise is \( 10 \) K and the characteristic length is 20 mm, the expansion is about
$$ \Delta L = 11 \times 10^{-6} \times 20 \times 10 = 2.2 \ \mu\text{m}. $$
This is small but not negligible for a DIN 4 straight bevel gear. Therefore, I allowed the workpiece to cool before the final measurement. The measurement was performed at room temperature. The thermal error was thus minimized. In production, the coolant and the machine thermal stability must be controlled to ensure consistent accuracy.
Tool Wear and Tool Life
The carbide hob is the most critical tool in my process. Its wear behavior determines the tool life and the consistency of the straight bevel gear accuracy. The main wear mechanisms are abrasive wear, adhesive wear, and diffusion wear. Because the cutting speed is high, the temperature at the cutting edge is high, and diffusion wear can become significant. The coating on the carbide hob reduces the wear rate. In my tests, the hob showed no significant wear after machining the gear pair. This indicates that the tool life is sufficient for small-batch and medium-batch production. For large-batch production, the hob should be inspected periodically, and the cutting parameters should be optimized to maximize tool life. Table 8 lists the recommended tool life management strategy.
| Item | Recommendation |
|---|---|
| Tool material | Coated carbide |
| Cutting speed | 100 to 150 m/min for small-module straight bevel gears |
| Feed per tooth | Optimized for chip thickness and surface finish |
| Coolant | Flood coolant or high-pressure coolant |
| Wear inspection | After every 50 to 100 workpieces |
| Replacement criterion | Flank wear \( VB > 0.1 \) mm or profile error exceeds limit |
| Regrinding | Possible with profile control |
Practical Implementation and Programming Details
The NC program for the straight bevel gear is generated by a dedicated software module. The operator enters the following data: the number of teeth of the pinion and the gear, the module, the pressure angle, the face width, the pitch cone angles, the outer cone distance, the tooth depth, the hob diameter, the hob lead angle, the cutting speed, the feed per tooth, and the safe positions. The software calculates the machine coordinates for the two feed segments and the synchronization ratio. It then outputs the NC code in the machine controller format. The program includes the following blocks:
| Block type | Function | Example |
|---|---|---|
| Initialization | Set units, absolute mode, spindle speed | G21 G90 G97 S1500 M03 |
| Tool change | Select the hob and set the tool offset | T01 M06 |
| Workpiece clamping | Close the fixture | M10 |
| Rapid approach | Move to the safe start point | G00 X… Y… Z… |
| Synchronization | Start the electronic gear between \( A \) and \( C \) | G… |
| First feed segment | Radial infeed to full depth | G01 X… Y… Z… F… |
| Second feed segment | Axial feed along the pitch cone generatrix | G01 X… Y… Z… F… |
| Retraction | Move away from the workpiece | G00 X… Y… Z… |
| Stop | Stop the spindle and the synchronization | M05 M30 |
The electronic gear ratio is defined by the controller. For a straight bevel gear with \( z \) teeth, the ratio is \( 1:z \) between the workpiece axis and the cutter axis. The controller must maintain this ratio during the entire cutting cycle. If the ratio is lost, the tooth spacing will be incorrect. The six-axis CNC machine has a high-performance motion controller that can maintain the ratio even at high spindle speeds. I verified this by measuring the pitch accuracy of the machined straight bevel gears. The results reached DIN 4, which confirms the synchronization accuracy.
Verification of the Straight Bevel Gear Meshing
After machining, I assembled the pinion and the gear and checked the meshing. The contact pattern was observed by applying a marking compound to the tooth surfaces. The contact pattern was centered on the tooth flank and extended over a reasonable area. There was no edge contact, and the backlash was within the specified range. The gear pair ran smoothly with low noise. This confirmed that the straight bevel gear tooth surfaces produced by my method are conjugate enough for practical use. The small-end profile deviation did not cause a harmful contact pattern because the face width was limited and the load was distributed over the central region of the tooth.
The meshing test also showed that the tooth contact pattern was sensitive to the mounting distance. This is normal for straight bevel gears. The correct mounting distance must be maintained in the application. In my process, the mounting distance is controlled by the machine setup and the workpiece clamping. The gear measuring center can measure the mounting distance and the tooth contact pattern. I used this feedback to adjust the machine parameters when necessary.
Discussion of the Forming Method
The forming method with a single-position hob is not a generating method. The tooth profile is determined by the cutting edge shape. Therefore, the method is inherently less flexible than generating methods. For each tooth number, a different hob may be required in theory. However, in practice, a set of hobs can cover a range of tooth numbers. For example, a set of 25 hobs with the same module can machine straight bevel gears with equivalent tooth numbers from 16 to 120. This is similar to the grouping method used for bevel gear milling cutters. By grouping the tooth numbers, the number of required hobs is reduced, and the tool management becomes practical. The accuracy loss due to the grouping is small for small-module straight bevel gears. Table 9 shows a typical grouping scheme for a single module.
| Hob number | Equivalent tooth number range | Typical application |
|---|---|---|
| 1 | 16 to 17 | Very small pinions |
| 2 | 18 to 19 | Small pinions |
| 3 | 20 to 21 | Small pinions |
| 4 | 22 to 23 | Small pinions |
| 5 | 24 to 25 | Small pinions |
| 6 | 26 to 29 | Medium pinions |
| 7 | 30 to 34 | Medium pinions |
| 8 | 35 to 41 | Medium pinions |
| 9 | 42 to 49 | Large pinions and small gears |
| 10 | 50 to 59 | Gears |
| 11 | 60 to 74 | Gears |
| 12 | 75 to 99 | Large gears |
| 13 | 100 to 120 | Very large gears |
In my test, the pinion had an equivalent tooth number of about 41.4, and the gear had an equivalent tooth number of about 165.5. The pinion could be covered by the 35 to 41 group, and the gear required a separate hob or a larger grouping range. In practice, the gear with 74 teeth and a cone angle of 63.435 degrees has a large equivalent tooth number. The hob for the gear must be designed accordingly. The pinion and the gear use different hobs because their tooth profiles are different. This is normal for straight bevel gear production. The hobs are designed as a pair to ensure proper meshing.
Economic and Production Benefits
The economic benefits of my method are clear. The machining time is reduced by a factor of 7.5 to 10. The accuracy is improved to DIN 4. The machine is a CNC machine, so the setup is flexible and the program can be reused. The tool is a carbide hob, which has a long life and can be reground. The process is suitable for small-module straight bevel gears in batches of various sizes. For large batches, the high productivity reduces the cost per piece. For small batches, the flexible CNC programming reduces the setup time. Table 10 summarizes the economic comparison.
| Factor | Conventional planing | My hobbing-milling method |
|---|---|---|
| Machine cost | Lower initial cost | Higher initial cost |
| Setup time | Long | Short |
| Tool cost | Moderate | Moderate to high |
| Tool life | Short | Long |
| Labor intensity | High | Low |
| Cycle time | Long | Very short |
| Accuracy | DIN 6 to 7 | DIN 4 |
| Flexibility | Low | High |
| Best application | Low-volume, low-accuracy | Medium- to high-volume, high-accuracy |
The higher initial cost of the CNC machine is offset by the shorter cycle time and the higher accuracy. For a production run of thousands of straight bevel gears, the savings in machining time alone can justify the investment. In addition, the CNC machine can produce other types of bevel gears, such as spiral bevel gears and hypoid gears, so the machine utilization is high. This makes the investment even more attractive.
Limitations and Future Work
My method has some limitations. The most important is the small-end profile deviation. The method is suitable for straight bevel gears with a face width less than about 25% of the outer cone distance. If the face width is larger, the deviation becomes significant, and the tooth profile may not meet the accuracy requirement. Another limitation is the need for a special hob for each tooth number group. Although the grouping reduces the number of hobs, a complete set is still required for a wide range of tooth numbers. The hob design and manufacturing cost is therefore a consideration. Finally, the method is a forming method, so it cannot correct the tooth profile by a generating motion. The accuracy depends on the hob profile and the machine synchronization.
In the future, I plan to investigate the following topics. First, I will optimize the hob profile approximation to reduce the small-end deviation. A more accurate circular-arc or involute approximation could extend the allowable face width ratio. Second, I will study the thermal behavior in more detail and develop a thermal compensation model for the machine. Third, I will test different coatings and cutting parameters to further increase the tool life and the cutting speed. Fourth, I will apply the method to other small-module bevel gears, such as those with a shaft angle other than 90 degrees. Fifth, I will integrate the simulation and the NC program generation into a single software platform to improve the workflow. These developments will make the high-speed hobbing-milling method even more powerful for small-module straight bevel gears.
Conclusions
I have developed a high-speed hobbing-milling process for small-module straight bevel gears based on a six-axis CNC spiral bevel gear milling machine. The process uses a carbide single-position hob and continuous indexing. The main conclusions are as follows.
1. The continuous indexing method eliminates the retracting and indexing time of conventional planing. For the same straight bevel gear, the hobbing-milling time is only 10% to 13.3% of the planing time. This is a major productivity improvement.
2. The process uses a forming method with a single-position hob. The hob cutting edge is designed according to the large-end back-cone involute of the straight bevel gear. The small-end profile deviation is acceptable when the face width is less than about 25% of the outer cone distance.
3. I established a Vericut simulation environment for the six-axis CNC machine and the hob. The simulation verified the feasibility of the CNC machining process and the correctness of the NC program. It also helped to avoid collision and interference.
4. I conducted practical cutting tests. The pitch accuracy of the machined straight bevel gears reached DIN 4. The maximum tooth profile error was 7.4 μm for the pinion and -5.4 μm for the gear. The gear pair met the application requirements.
5. The method is suitable for small-module straight bevel gears with a module less than 4 mm. It is especially effective when the face width is limited and the production volume is medium to high. The combination of high speed, high accuracy, and high flexibility makes it a strong alternative to conventional planing.
6. The economic analysis shows that the higher initial cost of the CNC machine is offset by the shorter cycle time and the higher accuracy. The machine can also produce other bevel gear types, which increases its utilization.
Overall, the high-speed hobbing-milling method I developed provides a practical and efficient solution for small-module straight bevel gear manufacturing. It addresses the low efficiency of existing processes and achieves both high productivity and high accuracy. I believe that this method will be useful in automotive, aerospace, defense, and other industries where small-module straight bevel gears are required in large quantities.