
I have studied the precision forging behavior of the driving pinion of a hypoid bevel gear set because hypoid bevel gears are widely used in automotive drive axles, aerospace transmissions, marine systems, machine tools, and heavy engineering equipment. A hypoid bevel gear is a special type of spiral bevel gear in which the axis of the driving pinion is offset from the axis of the driven gear. This offset changes the geometry, the meshing behavior, and the manufacturing requirements. Compared with ordinary spiral bevel gears, hypoid bevel gears provide a larger contact ratio, smoother meshing, higher load capacity, more compact packaging, lower noise, and greater design freedom in vehicle layout. At the same time, the tooth surfaces of the pinion are asymmetric, the two flanks usually have different curvatures and pressure angles, and the sliding motion between the mating surfaces is more severe. These features make hypoid bevel gears difficult to design, difficult to cut, and difficult to forge near net shape.
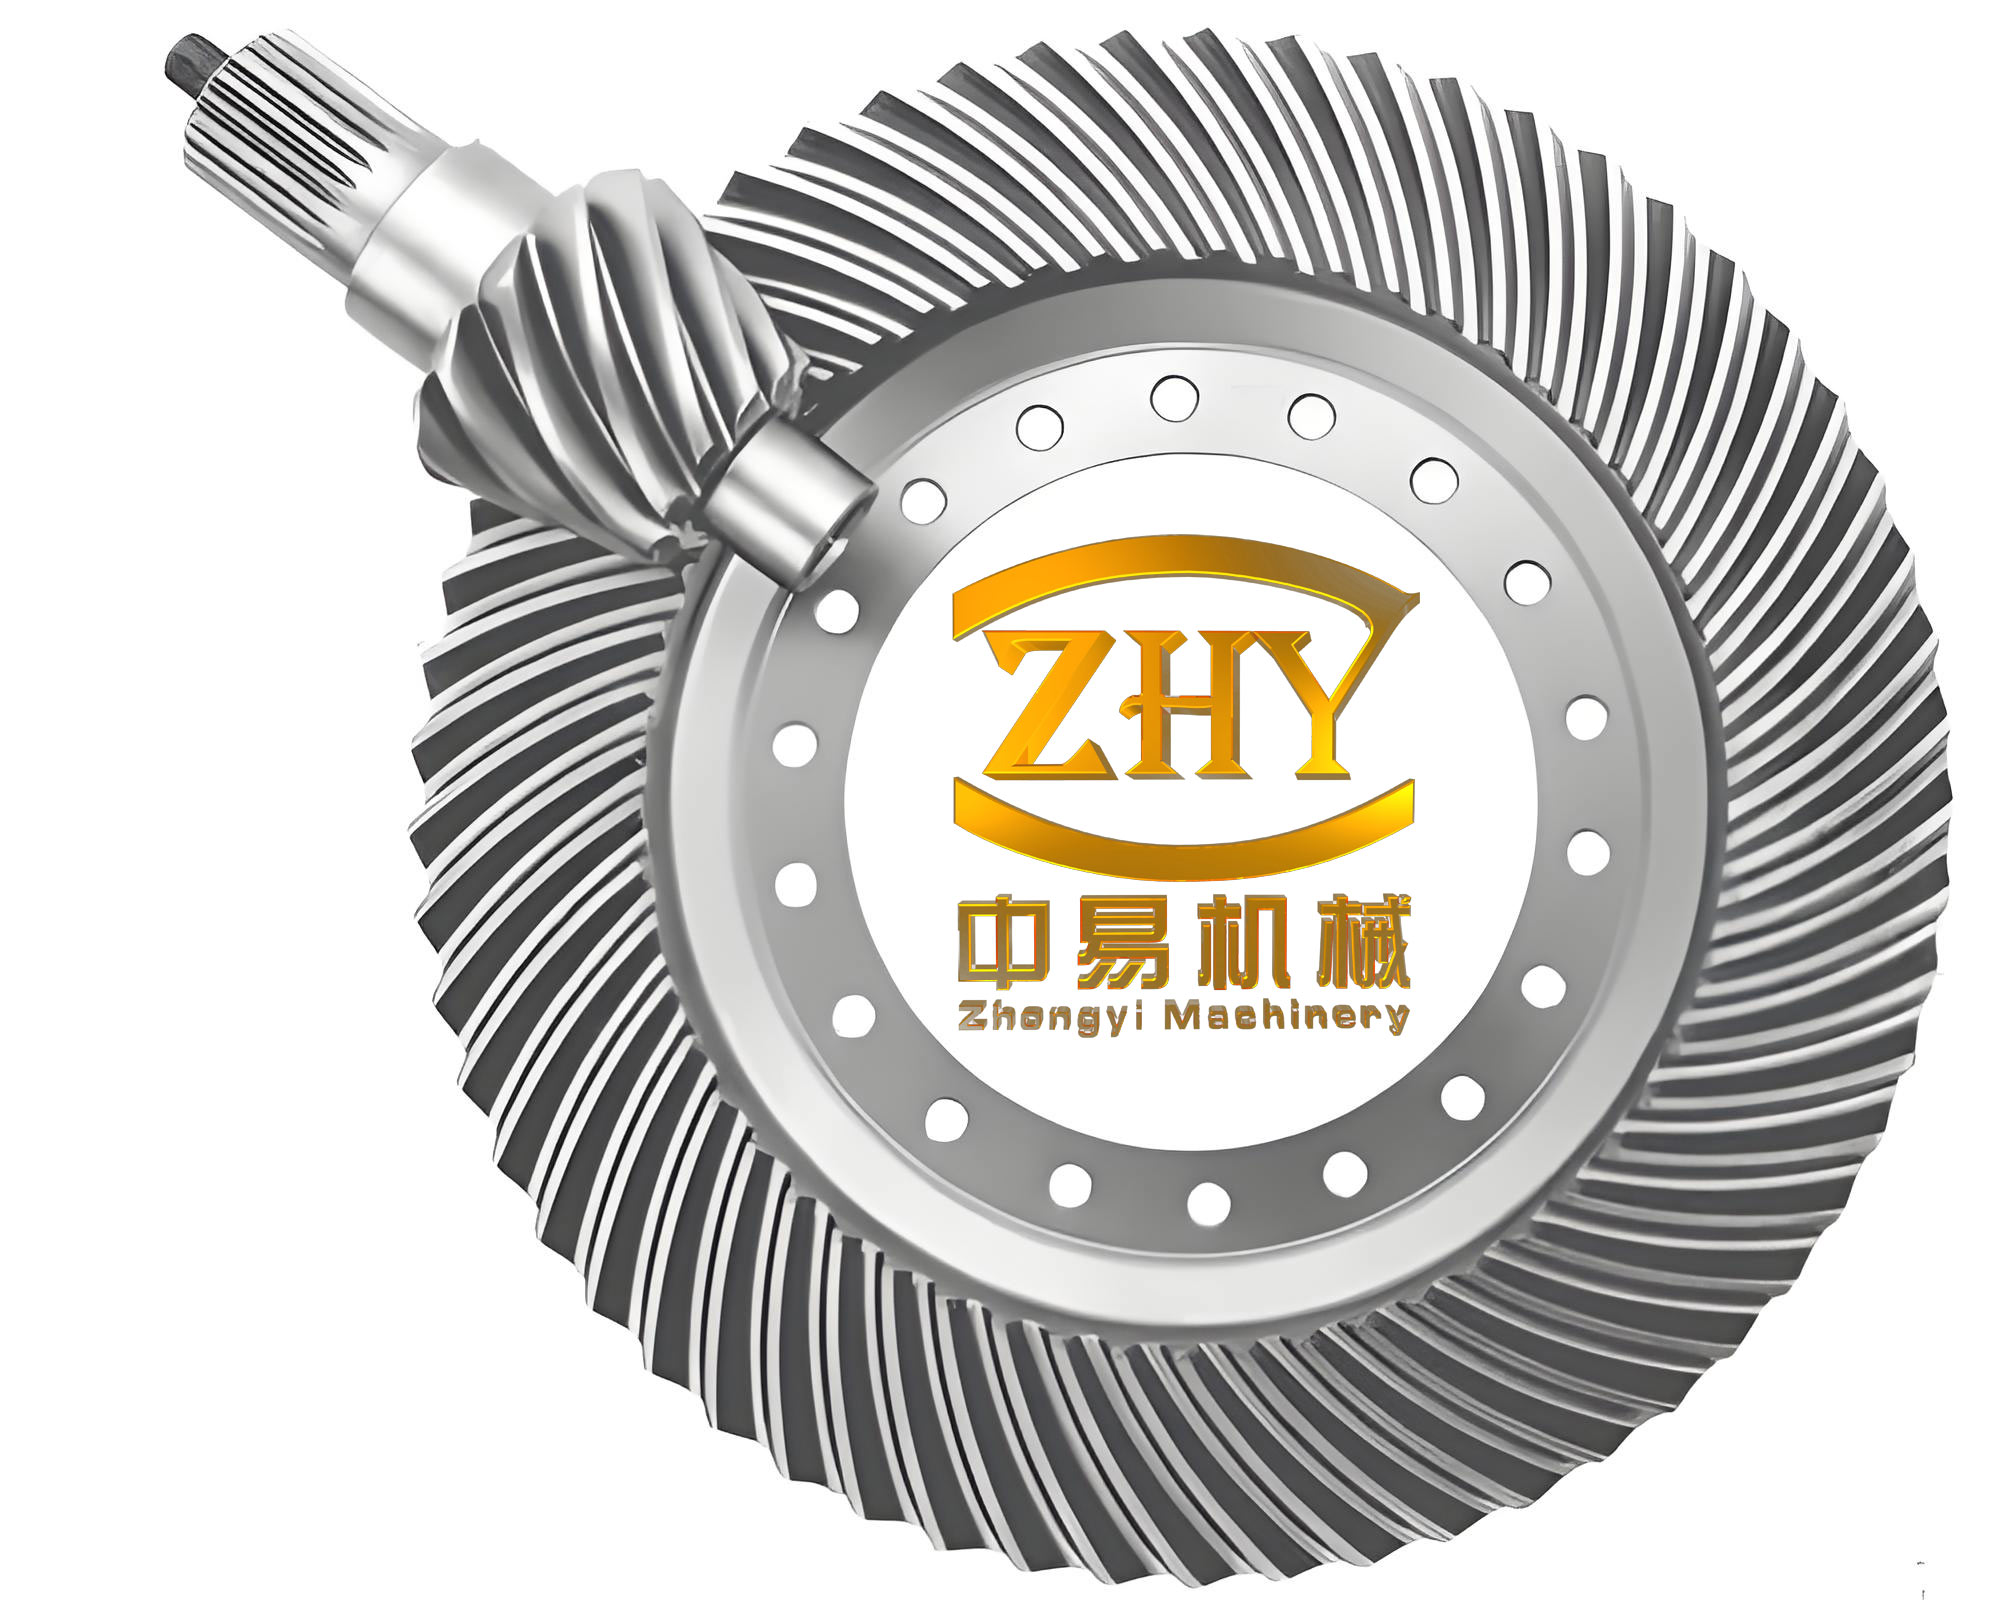
In my research, I focused on the precision forging of the driving pinion, which is the smaller and more complex member of a hypoid bevel gear pair. I used finite element simulation as the main tool to evaluate material flow, cavity filling, stress, strain, velocity, temperature, and forming load. I also selected process parameters, designed the forging drawing, proposed several blank shapes and forming schemes, optimized the schemes, and analyzed the influence of friction and forging temperature. The objective was to establish a reliable numerical basis for the near-net-shape forging of hypoid bevel gears and to support later experimental tooling and production trials.
1. Characteristics and Manufacturing Challenges of Hypoid Bevel Gears
I began with a process-oriented review of hypoid bevel gears. The offset between the pinion axis and the gear axis causes the pitch surfaces to be hyperboloids rather than simple cones. In practical design, these hyperboloids are approximated by pitch cones, and the resulting gear pair is called a hypoid bevel gear pair. The pinion usually has a larger spiral angle than the gear, which increases the overlap ratio and improves transmission smoothness. The offset also permits the drive shaft to be placed lower or higher, which is important in passenger cars and commercial vehicles because it affects floor height, center of gravity, and suspension layout.
I summarized the main advantages and difficulties of hypoid bevel gears in Table 1.
| Item | Hypoid bevel gear behavior | Effect on precision forging |
|---|---|---|
| Axis relation | Pinion axis is offset from gear axis | Asymmetric pinion tooth geometry and complicated die cavity |
| Contact ratio | Higher than ordinary spiral bevel gears | Better transmission, but tighter tooth accuracy is needed |
| Pinion spiral angle | Usually larger than gear spiral angle | Strong tangential flow during forging |
| Flank symmetry | Pinion flanks are not symmetric | Unequal flow resistance and difficult corner filling |
| Surface motion | Combined rolling and sliding | High contact pressure and strict surface quality requirements |
| Load capacity | High because of larger pinion diameter and stiffness | Attractive for forging if fiber continuity is preserved |
| Cutting process | Material utilization is low and fiber lines are cut | Fatigue strength and service life are reduced |
Conventional manufacturing of hypoid bevel gears is dominated by cutting methods. I found that cutting can achieve high accuracy, but it has several disadvantages: low material utilization, high tool cost, long production time, and interruption of metal fiber flow. The interrupted fiber flow reduces bending fatigue strength at the tooth root and contact fatigue strength on the tooth surface. Precision forging, by contrast, can produce continuous fiber lines along the tooth profile, refine the microstructure, reduce internal defects, and improve impact toughness, bending fatigue resistance, wear resistance, and corrosion resistance. For these reasons, I treated precision forging as a promising alternative for hypoid bevel gears.
2. Finite Element Basis for My Simulation
Because hypoid bevel gear forging involves large plastic deformation, high temperature, contact friction, and strong thermal coupling, I used a rigid-viscoplastic finite element formulation. I neglected elastic deformation of the workpiece, treated the material as homogeneous and isotropic, assumed incompressibility, and used the Levy-Mises constitutive relation. The governing equations I used are summarized below.
The equilibrium equation is
$$\sigma_{ij,j}=0$$
The strain-rate and velocity relation is
$$\dot{\varepsilon}_{ij}=\frac{1}{2}\left(u_{i,j}+u_{j,i}\right)$$
The Levy-Mises constitutive equation is
$$\sigma’_{ij}=\frac{2\bar{\sigma}}{3\dot{\bar{\varepsilon}}}\dot{\varepsilon}_{ij}$$
where the equivalent stress and equivalent strain rate are
$$\bar{\sigma}=\sqrt{\frac{3}{2}\sigma’_{ij}\sigma’_{ij}},\qquad
\dot{\bar{\varepsilon}}=\sqrt{\frac{2}{3}\dot{\varepsilon}_{ij}\dot{\varepsilon}_{ij}}$$
The Mises yield criterion is
$$\sigma’_{ij}\sigma’_{ij}=2k^2$$
and the incompressibility condition is
$$\dot{\varepsilon}_{V}=\dot{\varepsilon}_{ij}\delta_{ij}=0$$
For rigid-viscoplastic material, the flow stress depends on strain, strain rate, and temperature:
$$Y=Y\left(\bar{\varepsilon},\dot{\bar{\varepsilon}},T\right)$$
I used a variational formulation with a Lagrange multiplier or penalty term to impose volume constancy. A general form of the functional is
$$\Pi=\int_V \bar{\sigma}\dot{\bar{\varepsilon}}\,dV-\int_{S_p}p_i u_i\,dS+\int_V \lambda \dot{\varepsilon}_{V}\,dV$$
For thermal coupling, I solved the heat balance equation together with the plastic deformation problem. The heat conduction equation is
$$\rho c\frac{\partial T}{\partial t}=\lambda\nabla^2 T+\dot{q}$$
where \(\rho\) is density, \(c\) is specific heat, \(\lambda\) is thermal conductivity, \(T\) is temperature, and \(\dot{q}\) is the internal heat generation rate from plastic work and friction. I assumed that about ninety percent of plastic deformation work was converted into heat. The coupling procedure updated the velocity field, temperature field, flow stress, and contact conditions iteratively until convergence.
I used DEFORM-3D as the simulation platform. I chose tetrahedral elements, automatic remeshing, volume compensation, rigid dies, and a plastic workpiece. The software allowed me to visualize the filling process, equivalent stress, equivalent strain, velocity, temperature, and load-stroke curves. This was essential because the hypoid bevel gear pinion has a complicated tooth surface and the forging process cannot be evaluated reliably from simple hand calculations alone.
3. Material, Die, Lubrication, and Equipment Selection
For the hypoid bevel gear pinion, I selected a low-carbon alloy carburizing steel, 20CrMnTi, because it is commonly used for automotive drive axle gears. After carburizing and quenching, the surface obtains high hardness and wear resistance, while the core retains toughness and strength. The mechanical properties I used are listed in Table 2.
| Property | Value |
|---|---|
| Tensile strength | 1080 MPa |
| Yield strength | 835 MPa |
| Elongation | 10% |
| Reduction of area | 45% |
| Impact energy | 55 J |
| Hardness | 217 HB |
I selected the forging temperature range carefully. For 20CrMnTi, the brittle zones are approximately 600–975 °C and above about 1350 °C. In the range of 1000–1350 °C, dynamic recrystallization occurs and the reduction of area can exceed 75%, which is much better than at room temperature. Therefore, I chose a hot precision forging route with a recommended forging temperature of 1000–1200 °C. To avoid oxidation, I assumed that a low-oxidation or protective heating method would be used. A higher temperature within the safe range reduces flow stress and improves cavity filling.
For the die material, I selected a hot-work die steel equivalent to H13, designated 4Cr5MoSiV1. It has good high-temperature strength, toughness, wear resistance, and thermal fatigue resistance. I set the die preheating temperature to about 350 °C. Preheating reduces the temperature difference between the workpiece and the die, lowers the flow stress, and decreases the risk of thermal fatigue cracking. The allowed stress of this die material is about 1500 MPa, which is sufficient if the forging load is controlled properly.
For lubrication, I selected water-based graphite, which is common in hot die forging. It provides good high-temperature lubrication, release behavior, and cooling. In finite element analysis, I used the shear friction model:
$$\tau_f=mK$$
where \(m\) is the friction factor, \(K\) is the shear yield strength, and \(\tau_f\) is the friction shear stress. For hot forging with good lubrication, the friction factor can be varied around 0.1–0.3. The maximum friction condition corresponds to \(m=1\). In my simulations, I studied friction factors of 0.1, 0.2, and 0.3 to understand their influence on filling and load.
For equipment, I considered friction presses, crank presses, hydraulic presses, and hammers. I selected a friction press because it has a long stroke, no fixed bottom dead center, good process adaptability, and a built-in ejector. These features are helpful for the hypoid bevel gear pinion because the tooth cavity is deep and demolding is difficult. I estimated the required forging force using two common formulas. The first is
$$P=\left(2+\alpha\frac{V}{F}\right)\sigma_b F$$
where \(\alpha\) is a die-type coefficient, \(F\) is the projected area including flash, \(V\) is the forging volume, and \(\sigma_b\) is the flow stress at the final forging temperature. The second is
$$F=KA$$
where \(A\) is the projected area and \(K\) is an empirical coefficient. I also used the press tonnage relation
$$F’=\frac{F}{q}$$
where \(q\) is a deformation coefficient. From the calculations and later simulation results, I concluded that the required press capacity should be at least about 800 t, and an 800 t friction press is a reasonable preliminary choice.
4. Forging Drawing and Blank Design
I designed the precision forging drawing according to the geometry of the hypoid bevel gear pinion. The parting line was placed at the largest horizontal projection, which is near the large end of the tooth form. This position allows the punch to move from the small end toward the large end, and it also helps with demolding. I left a small machining allowance on the tooth surface because hot precision forging alone cannot reach the final tooth accuracy of cutting. I assumed that the forged pinion would be later finished by precision cutting or cold sizing. I also included shrinkage compensation using
$$L=(1+\delta)l$$
where \(L\) is the hot forging dimension, \(l\) is the cold forging dimension, and \(\delta\) is the thermal shrinkage coefficient. For steel, I used approximately 1.2–1.5%, and I selected 1.5% for the simulation models. I designed fillets at the intersections of the face cone, back cone, and front cone to avoid sharp corners. These fillets reduce stress concentration, improve metal flow, and prevent incomplete filling. The internal fillet radius \(R\) and external fillet radius \(r\) were chosen according to
$$r=e+a,\qquad R=(2\sim3)r$$
where \(e\) is the single-side machining allowance and \(a\) is the corresponding part fillet radius or chamfer.
I then designed the blank. For a fully enclosed die forging process, the blank must be positioned easily, must allow the die halves to close before the punch squeezes the material, and must force metal to flow into the tooth cavity along the shortest path. I established a geometric constraint: the tooth-forming portion of the blank must be contained within the body bounded by the root cone and the two cylindrical surfaces defined by the small-end and large-end root circles. This constraint ensures that the tooth cavity is filled by radial flow generated from axial compression, rather than by uncontrolled flash formation or long-distance reverse flow.
I considered seven candidate blank shapes and combined them into five forming schemes. Table 3 summarizes the blank design logic.
| Blank feature | Design reason | Constraint or result |
|---|---|---|
| Small-end punch | Shortest flow path into the tooth cavity | Best filling behavior in my simulations |
| Large-end punch | Easy to use the shank as a punch | Longer flow path and risk of folding |
| Cylindrical tooth body | Easy positioning and stable compression | Diameter must be controlled carefully |
| Conical tooth body | Matches the root cone envelope | Must remain within root cone boundary |
| Step at large end | Reduces later machining of shank | Causes reverse flow and folding |
| Double punch | Balanced axial compression | Complicated tooling and possible defects |
| Height-to-diameter ratio | Avoid buckling and instability | Should be about 0.5–3 for the tooth body |
I proposed five forming schemes. Scheme 1 used a single punch acting from the small end. Scheme 2 used a single punch from the large end with a blank whose diameter was close to the large-end root circle. Scheme 3 used a single punch from the large end with a different blank profile. Scheme 4 used a single punch from the large end with a smaller-diameter large-end step. Scheme 5 used double punches from both ends. I built finite element models for all five schemes and compared their filling behavior, stress, strain, and load-stroke curves.
5. Simulation Setup and Optimization Criteria
For the simulation models, I used a tetrahedral mesh with about 80,000 elements for the workpiece and dies. I measured the minimum element edge length and selected a step size no larger than one third of that length. For the detailed model, the minimum edge length was about 1.95 mm, so I used a step size of 0.6 mm. I saved results every ten steps. The workpiece was plastic, the dies were rigid, and heat transfer between the workpiece and dies was included. I used a shear friction factor of 0.3 for the main scheme comparison, a workpiece temperature of 1100 °C, a die preheating temperature of 350 °C, an environment temperature of 20 °C, and a heat transfer coefficient of 11 between workpiece and die. I set the punch velocity to 200 mm/s for single-punch schemes. For the double-punch scheme, I set the large-end punch velocity to 200 mm/s and the small-end punch velocity to 225 mm/s so that the two ends could reach their intended reductions at approximately the same time.
I evaluated the schemes using four main criteria. The first was tooth cavity filling. I looked for complete filling of the working tooth profile, clear tooth edges, and minimal unfilled corner regions. The second was equivalent stress. Lower stress means lower deformation resistance and easier filling. The third was equivalent strain. Higher strain indicates more accumulated deformation and better filling, provided that no defects appear. The fourth was the load-stroke curve. A lower final load and a smoother load increase indicate better process feasibility, lower press capacity, and longer die life.
6. Comparison of Forming Schemes
The differences among the five schemes were significant. In Scheme 1, the punch acts from the small end. Metal first enters the tooth cavity at the small end, then flows progressively toward the large end. The flow path is short, continuous, and stable. The tooth working profile fills completely, and the final unfilled region is limited to a small corner at the large end. This corner can be solved by designing a suitable fillet at the intersection of the face cone and back cone. The fiber flow is smooth, and there is no folding or flow reversal.
In Schemes 2 and 3, the punch acts from the large end. The initial deformation resembles upsetting. The blank bulges in the middle, then the tooth cavity fills first near the large end or the middle, and finally the small end fills. The flow path is longer, deformation is less uniform, and the final filling of both ends becomes difficult. The large-end corner is especially difficult to fill. These schemes also show severe corner voids.
In Schemes 4 and 5, the blank has a step or uses double punches. Although the final tooth profile appears mostly filled, I observed folding defects near the large end. The diameter change at the large end creates a step, and metal flows axially and radially at the same time. This produces a reverse flow zone and folds. Even if the corner is rounded, the fundamental mismatch between the blank diameter and the large-end root circle remains. Therefore, these schemes are not robust for the hypoid bevel gear pinion.
Table 4 summarizes the comparison of the five schemes.
| Scheme | Punch direction | Filling quality | Main defect | Maximum stress | Maximum strain | Maximum load |
|---|---|---|---|---|---|---|
| 1 | Small end | Good, clear profile | Small corner at large end | 377 MPa | 8.54 | 198 t |
| 2 | Large end | Poor at both ends | Corner voids | 4880 MPa | 4.62 | Higher than Scheme 1 |
| 3 | Large end | Poor at both ends | Corner voids | 4300 MPa | 3.49 | Higher than Scheme 1 |
| 4 | Large end | Partial but defective | Folding at large end | 2140 MPa | 8.53 | Higher than Scheme 1 |
| 5 | Double punch | Partial but defective | Folding at large end | 1140 MPa | 4.95 | Higher than Scheme 1 |
Based on these results, I selected Scheme 1 as the best forming scheme for the hypoid bevel gear pinion. Scheme 1 gives the best combination of complete filling, low stress, high accumulated strain, smooth flow, and low forming load. It also avoids the folding and reverse flow defects observed in the other schemes.
7. Influence of Friction Coefficient
I studied the influence of the friction coefficient under a constant forging temperature of 1050 °C and a constant die temperature of 350 °C. I used friction factors of 0.1, 0.2, and 0.3. The results are summarized in Table 5.
| Friction factor \(m\) | Maximum equivalent stress | Stress distribution | Load-stroke behavior |
|---|---|---|---|
| 0.1 | 366 MPa | Uniform | Lowest load |
| 0.2 | 428 MPa | Reasonably uniform | Moderate load |
| 0.3 | 441 MPa | Less uniform | Highest load |
I found that increasing the friction factor increases the maximum equivalent stress and reduces stress uniformity. This happens because higher friction restricts metal flow, increases deformation resistance, and raises the load required to fill the tooth cavity. The load-stroke curves also shift upward as friction increases. In practical forging of hypoid bevel gears, I concluded that good lubrication is essential. A lower friction factor reduces forming load, lowers press capacity requirements, reduces die wear, and improves die life. Therefore, friction must be treated as an important process variable in the precision forging of hypoid bevel gears.
8. Influence of Forging Temperature
I also studied the influence of forging temperature under a constant friction factor of 0.3. I used temperatures of 1000 °C, 1050 °C, and 1100 °C. The results are summarized in Table 6.
| Forging temperature | Maximum equivalent stress | Flow stress trend | Load-stroke behavior |
|---|---|---|---|
| 1000 °C | 446 MPa | High flow stress | Highest load |
| 1050 °C | 441 MPa | Moderate flow stress | Moderate load |
| 1100 °C | 377 MPa | Low flow stress | Lowest load |
I observed that higher forging temperature reduces the maximum equivalent stress and improves stress uniformity. It also lowers the forming load. The reason is that higher temperature promotes dynamic recovery and recrystallization, increases atomic mobility, activates more slip systems, improves grain boundary sliding and diffusion creep, and reduces deformation resistance. Within the safe forging range of 20CrMnTi, a higher temperature is therefore beneficial for filling the hypoid bevel gear tooth cavity. However, excessive temperature must be avoided because of oxidation, grain growth, and die wear. I concluded that the forging temperature should be controlled within 1000–1200 °C, preferably toward the upper part of that range when the heating atmosphere and die life allow it.
9. Detailed Forming Behavior of the Optimized Scheme
After selecting Scheme 1, I performed a detailed numerical simulation of the hypoid bevel gear pinion precision forging process. I analyzed mesh evolution, equivalent stress, equivalent strain, velocity, temperature, and load-stroke behavior. The results revealed a clear and repeatable forming sequence.
9.1 Mesh evolution
At the beginning, the blank mesh was uniform. As the punch moved down, the metal at the small end first entered the tooth cavity. The surface mesh became denser than the interior mesh because the surface metal contacted the die cavity, deformed severely, and was remeshed. As forging continued, the densified region extended from the small end toward the large end. At the end of filling, the tooth region had a much denser mesh than the interior of the blank. This confirmed that the tooth cavity was filled progressively from the small end to the large end.
9.2 Equivalent stress
The equivalent stress increased gradually throughout the process because of work hardening and because the remaining unfilled area became smaller. The first stress concentration appeared near the small-end root region. This region experienced the earliest contact with the die and the most severe deformation. As the small end filled, the tooth root region showed higher stress than the tooth tip region. When filling moved toward the large end, a new stress concentration appeared near the large-end root and the step between the tooth body and the shank. The maximum stress at the final stage occurred at the corner regions, which are the last areas to fill. The maximum equivalent stress in the detailed simulation was about 279 MPa at the final stage, and the stress distribution was smooth and gradual. This indicated good material flow and no severe stress concentration that would cause internal cracking.
9.3 Equivalent strain
The equivalent strain also increased continuously. The first strained region was near the small-end root. The strain value was higher at the root than at the tip. As filling progressed from the small end to the large end, the accumulated strain decreased from the small end toward the large end. The maximum equivalent strain occurred near the small-end root and reached about 4.58 in the detailed model. The interior of the tooth body had lower strain than the surface, and the shank had almost zero strain because it did not participate in tooth forming. This strain pattern is consistent with the observed flow sequence.
9.4 Velocity field
The velocity field showed that the cylindrical part of the blank moved axially downward at the beginning. As metal entered the tooth cavity, the flow became radial and tangential because of the spiral tooth shape. The metal first filled the small end and then flowed toward the large end along the root and tip regions. The maximum and minimum velocities did not change sharply, and there was no significant backflow or velocity crossing. This supported the conclusion that Scheme 1 provides stable filling without folding. Because the pinion flanks are asymmetric, the tangential component became stronger near the tooth tip. This is why the large-end face-cone and back-cone intersection must be provided with a suitable fillet to avoid incomplete filling.
9.5 Temperature field
The temperature field showed that the outer surface of the blank cooled gradually because of contact with the die. The interior remained hotter. At the beginning, the tooth region was not in full contact with the die, so heat loss was limited and the temperature remained above 1000 °C. As filling progressed, the small-end root contacted the die early, but deformation work and friction work compensated part of the heat loss. The large-end root also remained around 950–1000 °C. The tooth tips remained hotter because they contacted the die later. At the end of filling, most of the tooth region remained between 900 °C and 1000 °C, and the maximum temperature occurred near the large-end tooth tip. The overall temperature difference was less than about 200 °C, which is acceptable for 20CrMnTi hot forging. This reduces residual thermal stress and helps maintain die life.
Table 7 summarizes the temperature behavior in different regions.
| Region | Contact condition | Main heat effect | Typical temperature |
|---|---|---|---|
| Small-end root | Early contact | Heat loss compensated by deformation and friction | 950–1050 °C |
| Small-end tip | Later contact | Heat loss with little compensation | 800–950 °C near final stage |
| Large-end root | Moderate contact | Heat loss partly compensated | 950–1000 °C |
| Large-end tip | Late contact | High temperature retained | 1050–1100 °C |
| Interior | No direct die contact | Low heat loss | Above 1000 °C |
9.6 Load-stroke behavior
The load-stroke curve of the optimized scheme has three distinct stages. In the initial stage, the blank is compressed like upsetting before the surface contacts the small-end cavity. The load rises almost linearly. In the filling stage, metal flows into the tooth cavity from the small end toward the large end. This stage lasts the longest. The load increases steadily, and the curve slope gradually increases, showing that deformation becomes more difficult as the cavity fills. In the final stage, only small corner regions remain unfilled. The free surface area is very small, and the metal must overcome the hydrostatic pressure of the already filled material. Therefore, the load rises sharply and reaches its maximum. In the detailed simulation, the maximum punch load was about 153 t, while the lower die load reached about 702 t because it carried both the clamping force and the punch force. This supports the selection of an 800 t friction press.
Table 8 summarizes the load stages.
| Stage | Approximate step range | Deformation mode | Load behavior |
|---|---|---|---|
| Initial | Start to about step 10 | Upsetting before cavity contact | Linear rise |
| Filling | Step 10 to about step 175 | Progressive tooth cavity filling | Steady rise with increasing slope |
| Final | Step 175 to end | Corner filling under high constraint | Sharp rise to maximum |
10. Forming Characteristics of Hypoid Bevel Gear Pinion Precision Forging
From the detailed numerical results, I identified the following forming characteristics for the hypoid bevel gear pinion:
First, the metal enters the tooth cavity mainly by axial compression from the small end. The flow path is short, and the tooth cavity fills from the small end toward the large end. This is the key reason why Scheme 1 avoids folding and produces a clear tooth profile.
Second, the surface mesh becomes denser than the interior mesh because the surface metal experiences severe shear and contact friction. The interior metal undergoes less deformation. This gradient is acceptable for hot forging because it produces a dense surface layer and a tougher core after heat treatment.
Third, the equivalent stress and strain are highest near the small-end root. This region is the first to contact the die and the first to deform. The stress and strain decrease toward the large end and toward the tooth tip. The root region is therefore the most critical region for die wear and forging defect control.
Fourth, the velocity field contains radial, axial, and tangential components. The tangential component is especially important because of the spiral tooth shape and the asymmetric pinion flanks. This component can cause incomplete filling near the large-end face cone and back cone. A proper fillet design is necessary.
Fifth, the temperature field remains within a reasonable range for 20CrMnTi. The highest temperature occurs at the large-end tooth tip, and the lowest temperature occurs at the small-end tip near the final stage. The temperature difference is small enough to avoid severe residual thermal stress.
Sixth, the load-stroke curve confirms that the final corner filling stage requires a sharp increase in load. Therefore, the press capacity must be selected based on the lower die load, not only the punch load. In my analysis, the lower die load reached about 702 t, so an 800 t press is appropriate.
11. Process Window and Practical Implications
Based on my simulations, I established a practical process window for the precision forging of hypoid bevel gears. The workpiece temperature should be controlled between 1000 °C and 1200 °C, with a preference for about 1100 °C when oxidation can be controlled. The die preheating temperature should be about 350 °C. The friction factor should be kept as low as possible, preferably around 0.1–0.2, by using water-based graphite or an equivalent high-temperature lubricant. The punch should act from the small end. The blank diameter should be slightly smaller than the small-end and large-end root circle diameters, and the blank must remain within the root cone envelope. The forging drawing should include fillets at the large-end face-cone and back-cone intersection, and a small machining allowance should be left on the tooth surface for later finishing.
I also note that the flow stress of 20CrMnTi is strongly temperature and strain-rate dependent. The strain rate can be estimated from
$$\dot{\varepsilon}=\frac{1}{L_0}\frac{dL}{dt}$$
For a punch velocity of 200 mm/s and a deformation length of about 131 mm over about 2 s, the average strain rate is approximately 0.3 s⁻¹. This lies within the range of 0.1–1 s⁻¹, which is consistent with the material data used in my simulations. This confirms that the selected punch velocity is reasonable for a friction press.
12. Preliminary Experimental Context
Before my detailed numerical study, preliminary trials of the hypoid bevel gear pinion forging were attempted with a fully enclosed die forging setup. Those trials showed two major problems: the die bearing was damaged, and the die structure could not release the forged pinion. As a result, a complete pinion was not produced. My numerical simulations helped explain these difficulties. The lower die carries both the clamping force and the punch force, so the total load is much higher than the punch load alone. The deep and asymmetric tooth cavity also makes demolding difficult. The simulation results indicated that the lower die load could reach about 702 t, which means an 800 t press is required and the die structure must be robust. The results also showed that the large-end corner is the last region to fill, so the die corner and forging fillet must be designed carefully. These findings provide a basis for redesigning the die structure and selecting a press with sufficient capacity.
13. Summary of Numerical Results
I summarize the main numerical results in Table 9.
| Quantity | Result | Interpretation |
|---|---|---|
| Best forming scheme | Single punch from small end | Shortest flow path and best filling |
| Blank constraint | Inside root cone and root-circle cylinders | Ensures radial filling from axial compression |
| Maximum punch load | About 153 t | Punch load alone |
| Maximum lower die load | About 702 t | Clamping plus punch load |
| Recommended press | 800 t friction press | Matches calculation and simulation |
| Maximum equivalent stress in detailed model | About 279 MPa at final corners | Filling difficulty increases near the end |
| Maximum equivalent strain | About 4.58 near small-end root | Severe deformation at small-end root |
| Temperature range | Mostly 900–1100 °C | Within safe forging window |
| Main defect risk | Large-end corner underfill and folding | Controlled by scheme, fillet, and lubrication |
14. Conclusions
I have completed a numerical simulation study of the precision forging of a hypoid bevel gear pinion. The study combined rigid-viscoplastic finite element theory, thermal coupling, process parameter selection, forging drawing design, blank design, and multi-scheme optimization. The following conclusions can be drawn.
First, hypoid bevel gears have asymmetric pinion tooth surfaces and complex meshing behavior, which makes precision forging more difficult than ordinary spiral bevel gears. The driving pinion requires careful control of metal flow, cavity filling, and demolding.
Second, the blank for the pinion tooth body must be contained within the root cone and the small-end and large-end root-circle cylinders. The best forming scheme uses a single punch acting from the small end. The blank should have a diameter slightly smaller than the root circle diameters at both ends. This scheme produces a short flow path, continuous fiber lines, complete tooth filling, low stress, high accumulated strain, and low forming load.
Third, friction has a strong influence on the process. Increasing the friction factor increases equivalent stress and forming load and reduces stress uniformity. Good lubrication with water-based graphite or an equivalent lubricant is necessary to keep the friction factor low and improve die life.
Fourth, forging temperature has a strong influence on flow stress and load. Within the safe range of 20CrMnTi, higher temperature reduces equivalent stress and forming load. The recommended forging temperature is 1000–1200 °C, preferably around 1100 °C when oxidation is controlled.
Fifth, the optimized forging process fills the hypoid bevel gear pinion tooth cavity from the small end toward the large end. The small-end root experiences the highest strain and the earliest stress concentration. The velocity field contains radial, axial, and tangential components because of the spiral and asymmetric tooth geometry. The large-end face-cone and back-cone intersection is the most difficult region to fill and should be provided with a suitable fillet.
Sixth, the load-stroke curve has three stages: initial upsetting, steady filling, and final sharp load increase. The final corner filling stage dominates the press capacity requirement. The lower die load reaches about 702 t, so an 800 t friction press is a reasonable and safe choice.
Seventh, the temperature field remains within a suitable range for hot forging, and the temperature difference across the tooth body is moderate. This supports good forgeability, reduces residual thermal stress, and helps maintain die life.
Overall, my numerical simulation shows that precision forging of the hypoid bevel gear pinion is feasible when the forming scheme, blank shape, friction condition, forging temperature, die design, and press capacity are properly controlled. The results provide a quantitative basis for further die design, process optimization, and experimental validation of hypoid bevel gear precision forging.