
In my research, I focused on the geometric modeling and measurement of a miter gear, which in this work I treat as a double-helical herringbone gear formed by two opposite-handed helical gear sections. A miter gear of this type is important because it combines the smooth meshing action of a helical gear with the ability to cancel axial forces internally. I began from the involute cylindrical gear generation principle, built a spatial coordinate system, derived the tooth surface equations, and then studied the measurement of profile deviation, helix deviation, and pitch deviation. I also designed software for tooth surface calculation and error evaluation, and I used a coordinate measuring machine to verify the theoretical model. Throughout this article, I use the term miter gear repeatedly because the main object of my study is the miter gear tooth surface and its measurement behavior.
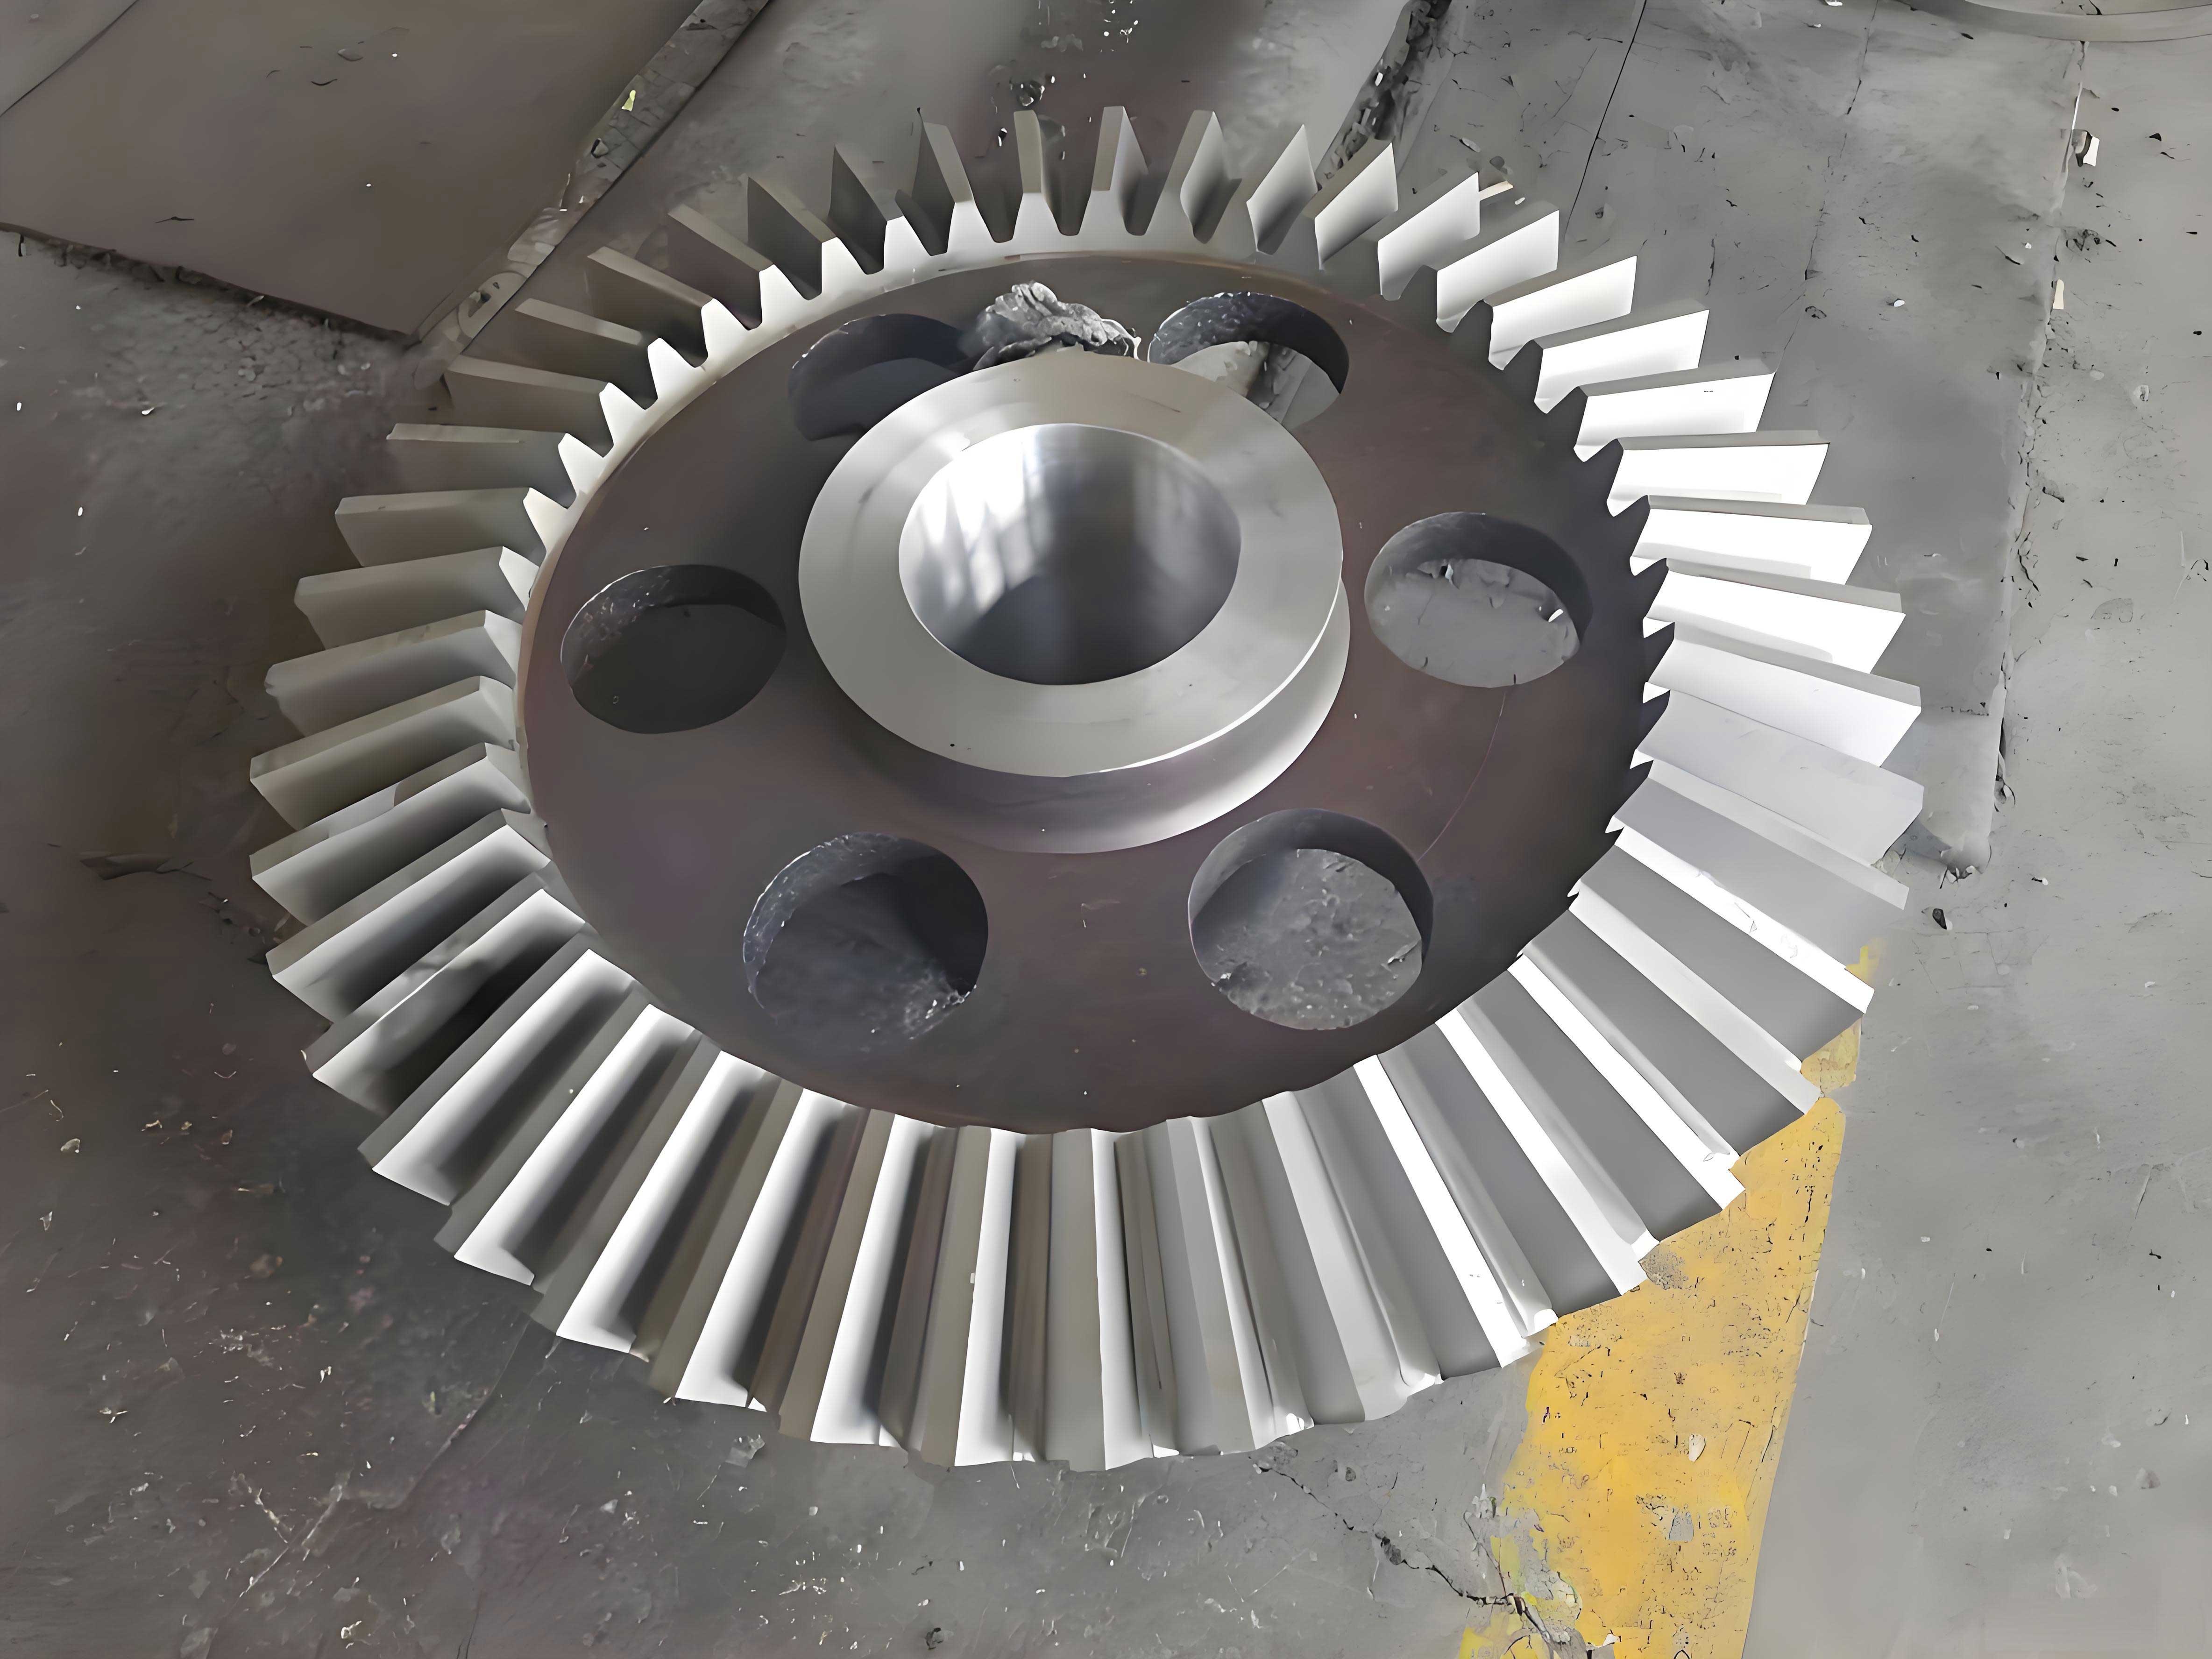
A miter gear is widely used in high-speed and heavy-load transmission systems because it can self-balance the axial force generated during meshing. The miter gear consists of two helical gear halves with the same helix angle but opposite directions. Therefore, the miter gear inherits the advantages of a helical gear, such as high load capacity, stable transmission, and large overlap ratio. At the same time, the miter gear avoids the large axial thrust that a single helical gear would produce. For this reason, I consider the miter gear to be a key transmission component in aircraft, marine, and large industrial systems. However, the miter gear has a more complex structure than a simple spur gear or helical gear, so accurate mathematical modeling and suitable measurement methods are necessary. My work addresses both the theoretical tooth surface of the miter gear and the practical evaluation of its deviations.
I started by reviewing the basic parameters of the miter gear. Since the miter gear can be regarded as two helical gears joined back-to-back, most of its parameters follow the standard helical gear definitions. The normal module, number of teeth, addendum coefficient, clearance coefficient, helix angle, pressure angle, and face width are the essential inputs. I list the basic parameter relations in the following table, which I used repeatedly in my derivations.
| Parameter | Symbol | Formula or value |
|---|---|---|
| Normal module | \(m_n\) | Standard value |
| Transverse module | \(m_t\) | \(m_t = m_n / \cos\beta\) |
| Normal pressure angle | \(\alpha_n\) | \(20^\circ\) or specified value |
| Transverse pressure angle | \(\alpha_t\) | \(\sin\alpha_t = \sin\alpha_n / \cos\beta\) |
| Pitch diameter | \(d\) | \(d = m_t z\) |
| Base diameter | \(d_b\) | \(d_b = d \cos\alpha_t\) |
| Helix angle | \(\beta\) | Usually \(8^\circ\) to \(20^\circ\) |
| Base helix angle | \(\beta_b\) | \(\tan\beta_b = \tan\beta \cos\alpha_t\) |
| Addendum | \(h_a\) | \(h_a = h_{an}^* m_n\) |
| Dedendum | \(h_f\) | \(h_f = (h_{an}^* + c_n^*) m_n\) |
| Addendum diameter | \(d_a\) | \(d_a = d + 2h_a\) |
| Dedendum diameter | \(d_f\) | \(d_f = d – 2h_f\) |
| Transverse pitch | \(p_t\) | \(p_t = \pi m_t\) |
| Normal pitch | \(p_n\) | \(p_n = \pi m_n\) |
The involute curve is the foundation of the miter gear tooth profile. I derived the involute equations from the rolling motion of a straight line on a base circle. Let the base radius be \(r_b\), and let \(K\) be an arbitrary point on the involute. The pressure angle at \(K\) is \(\alpha_k\), and the radius is \(r_k\). The fundamental relations are:
$$ r_k = \frac{r_b}{\cos\alpha_k} $$
$$ \theta_k = \tan\alpha_k – \alpha_k = \mathrm{inv}\,\alpha_k $$
$$ \begin{cases} r_k = \dfrac{r_b}{\cos\alpha_k} \\ \theta_k = \tan\alpha_k – \alpha_k \end{cases} $$
In a Cartesian coordinate system, I wrote the involute as:
$$ \begin{cases} x_k = r_b(\cos\phi_k + \phi_k \sin\phi_k) \\ y_k = r_b(\sin\phi_k – \phi_k \cos\phi_k) \end{cases} $$
where \(\phi_k = \theta_k + \alpha_k\) is the roll angle of the generating line. These equations allowed me to generate the transverse profile of the miter gear. I then extended the profile along the helix direction to obtain the three-dimensional tooth surface.
For a helical gear, the tooth surface is generated when a plane rolls on a base cylinder. The contact line between the plane and the base cylinder is inclined at the base helix angle \(\beta_b\). The trajectory of a point on this line forms an involute, and the collection of such involutes forms the involute helicoid. I used this idea to derive the right and left tooth surfaces of the miter gear. I first derived the right tooth surface of the first tooth, and then I obtained the left tooth surface by a mirror transformation.
For the first tooth right surface, I used the following parameter equations:
$$ \begin{cases} X_{R1j} = r_b \left[ \cos(\phi_{1j} + \theta_z)\cos\phi_{1j} – \sin(\phi_{1j} + \theta_z)\sin\phi_{1j} \right] \\ Y_{R1j} = r_b \left[ \sin(\phi_{1j} + \theta_z)\cos\phi_{1j} + \cos(\phi_{1j} + \theta_z)\sin\phi_{1j} \right] \\ Z_{R1j} = r_b \theta_z \cot\beta_b \end{cases} $$
Here, \(\phi_{1j}\) is the roll angle of the involute at point \(j\) on the first tooth right surface, and \(\theta_z\) is the rotation angle of the transverse involute along the axial direction. The term \(\theta_z\) is positive for one half of the miter gear and negative for the other half. This sign change is exactly what creates the herringbone shape of the miter gear.
To obtain the right surface of the \(i\)-th tooth, I rotated the first tooth right surface about the \(Z\)-axis. If \(P_{R1jz}\) is a point on the first tooth right surface, then the corresponding point on the \(i\)-th tooth right surface is:
$$ P_{Rijz} = A_z(\theta_i) P_{R1jz} $$
$$ P_{Rijz} = A_z(\theta_i) P_{R1jz} $$
where the rotation angle is:
$$ \theta_i = \frac{2\pi (i-1)}{Z_0} $$
and \(Z_0\) is the number of teeth. The rotation matrix about the \(Z\)-axis is:
$$ A_z(\theta_i) = \begin{bmatrix} \cos\theta_i & -\sin\theta_i & 0 \\ \sin\theta_i & \cos\theta_i & 0 \\ 0 & 0 & 1 \end{bmatrix} $$
After establishing the right tooth surface, I derived the left tooth surface. The left and right profiles are symmetric about a line \(c\) in the transverse plane. I defined the line \(c\) as \(Y = kX\), and the condition for symmetry gave the mirror transformation matrix \(V\):
$$ V = \begin{bmatrix} \dfrac{1-k^2}{1+k^2} & \dfrac{2k}{1+k^2} & 0 \\ \dfrac{2k}{1+k^2} & \dfrac{k^2-1}{1+k^2} & 0 \\ 0 & 0 & 1 \end{bmatrix} $$
Then the first tooth left surface point is related to the first tooth right surface point by:
$$ P_{L1jz} = V P_{R1jz} $$
For the \(i\)-th tooth left surface, I applied the same rotation operation:
$$ P_{Lijz} = A_z(\theta_i) P_{L1jz} = A_z(\theta_i) V P_{R1jz} $$
Since the miter gear is composed of two opposite-handed helical gear halves, I treated the axial coordinate \(Z\) as positive on one side and negative on the other. The complete miter gear tooth surface equation therefore becomes:
$$ \begin{cases} X_{R1j} = r_b \left[ \cos(\phi_{1j} + \theta_z)\cos\phi_{1j} – \sin(\phi_{1j} + \theta_z)\sin\phi_{1j} \right] \\ Y_{R1j} = r_b \left[ \sin(\phi_{1j} + \theta_z)\cos\phi_{1j} + \cos(\phi_{1j} + \theta_z)\sin\phi_{1j} \right] \\ Z_{R1j} = \pm r_b \theta_z \cot\beta_b \end{cases} $$
The positive sign applies to one half of the miter gear, and the negative sign applies to the other half. This sign convention is the mathematical expression of the herringbone geometry of the miter gear. I then used the same rotation and mirror operations to obtain all teeth of the miter gear.
To verify the derived equations, I used a numerical example. I selected a miter gear with the following basic parameters:
| Parameter | Symbol | Value |
|---|---|---|
| Normal module | \(m_n\) | 3.456811 mm |
| Number of teeth | \(Z\) | 19 |
| Addendum coefficient | \(h_a^*\) | 1 |
| Clearance coefficient | \(c^*\) | 0.25 |
| Helix angle | \(\beta\) | \(16.6772^\circ\) |
| Pressure angle | \(\alpha\) | \(22.5^\circ\) |
| Face width | \(b\) | 30 mm or 60 mm depending on test |
I programmed the equations in MATLAB. I first calculated the transverse module, transverse pressure angle, pitch diameter, base diameter, addendum diameter, and dedendum diameter. I then determined the range of the involute roll angle from the base circle to the addendum circle. Next, I determined the range of the axial rotation angle \(\theta_z\) from the face width. Finally, I calculated the coordinates of the miter gear tooth surface point by point. The resulting three-dimensional surface was smooth and continuous, and the left and right halves met exactly at the mid-plane. This simulation confirmed that my miter gear tooth surface model was correct.
I also developed a graphical interface for tooth surface calculation and simulation. I used a graphical programming environment because it allows rapid construction of interactive engineering software. In my miter gear software, the user can input the basic parameters, and the program calculates the remaining parameters automatically. The software displays the coordinate values in a spreadsheet and generates either a single-tooth or full-gear three-dimensional simulation. I called the mathematical engine from a script, and the graphical interface handled the input and output. This made the miter gear modeling process much more efficient than manual calculation.
After establishing the miter gear tooth surface model, I analyzed the deviations that affect miter gear transmission quality. Gear accuracy is directly related to transmission performance. In my study, I focused on three essential deviation items: profile deviation, helix deviation, and pitch deviation. These three items are fundamental because they influence transmission smoothness, load distribution, and motion accuracy. I summarize the standard gear error groups in the following table.
| Group | Error item | Main influence |
|---|---|---|
| Group I | Tangential composite total deviation | Motion accuracy |
| Group I | Radial composite total deviation | Motion accuracy |
| Group I | Total cumulative pitch deviation | Motion accuracy |
| Group I | Cumulative pitch deviation | Motion accuracy |
| Group I | Radial runout | Motion accuracy |
| Group II | Single pitch deviation | Transmission smoothness |
| Group II | Profile total deviation | Transmission smoothness |
| Group II | Base pitch deviation | Transmission smoothness |
| Group III | Helix total deviation | Load distribution |
| Group III | Contact line total deviation | Load distribution |
| Group III | Axial pitch deviation | Load distribution |
For the miter gear, profile deviation is the amount by which the actual profile deviates from the design profile. This deviation is measured in the transverse plane and perpendicular to the involute profile. I defined the total profile deviation \(f_\alpha\) as the normal distance between two design profiles that just contain the actual profile within the evaluation range. I also considered profile form deviation and profile slope deviation, but the total profile deviation is the mandatory item. If a miter gear has profile deviation, the instantaneous transmission ratio is no longer constant, and vibration and noise increase. Therefore, accurate profile deviation measurement is essential for a high-quality miter gear.
I calculated the profile deviation from measured coordinate points. For a point \(P_i(x_i, y_i)\) on the right profile of a miter gear tooth, the radius and pressure angle are:
$$ r_i = \sqrt{x_i^2 + y_i^2} $$
$$ \alpha_i = \arccos\left(\frac{r_b}{r_i}\right) $$
The polar angle is:
$$ \phi_i = \arctan\left(\frac{y_i}{x_i}\right) $$
The involute function value at this point is:
$$ \theta_i = \tan\alpha_i – \alpha_i $$
I defined the auxiliary quantity:
$$ \omega_i = \phi_i – \theta_i $$
For a single profile, the difference between any two measured points is related to the profile deviation. If the maximum and minimum values of \(\omega_i\) occur at points 1 and 2, the total profile deviation of the miter gear is:
$$ f_\alpha = r_b \cos\beta_b \left[ (\phi_1 – \theta_1) – (\phi_2 – \theta_2) \right] $$
Expanding the terms gives:
$$ f_\alpha = r_b \cos\beta_b \left[ \arctan\frac{y_1}{x_1} – \arccos\frac{r_b}{r_1} + \tan\left(\arccos\frac{r_b}{r_1}\right) – \arctan\frac{y_2}{x_2} + \arccos\frac{r_b}{r_2} – \tan\left(\arccos\frac{r_b}{r_2}\right) \right] $$
For the left profile, the sign of the polar angle is treated differently, and I used:
$$ \omega_i = \phi_i + \theta_i $$
If I measured \(m\) teeth, the total profile deviation of the whole miter gear was the maximum among all measured teeth:
$$ F_\alpha = \max(f_{\alpha 1}, f_{\alpha 2}, \ldots, f_{\alpha m}) $$
Helix deviation is another important item for the miter gear. It reflects the accuracy of the tooth trace along the face width. For a miter gear, the helix deviation controls the contact pattern and load distribution. I defined the total helix deviation \(f_\beta\) as the distance between two design helix traces that contain the actual helix trace within the evaluation range. The helix deviation includes helix form deviation and helix slope deviation, but the total helix deviation is the mandatory item. If the helix deviation is too large, the miter gear will have edge contact and poor load sharing. Therefore, I measured the helix deviation along the pitch cylinder.
I calculated the helix deviation from measured points on the pitch helix. For two adjacent measured points, the rotation angle difference is:
$$ \Delta\theta_i = \theta_i – \theta_{i-1} $$
The corresponding arc length on the pitch cylinder is:
$$ \Delta W_i = r \Delta\theta_i $$
The theoretical arc length difference for the same axial increment is:
$$ \Delta W_{ti} = \Delta Z \tan\beta $$
The helix deviation between two adjacent points is:
$$ \Delta f_i = \cos\beta \left( \Delta W_i – \Delta W_{ti} \right) $$
If the \(\Delta f_i\) values have different signs, the total helix deviation of one tooth trace is:
$$ f_\beta = \max(\Delta f_i) – \min(\Delta f_i) $$
If all \(\Delta f_i\) values have the same sign, then:
$$ f_\beta = \max|\Delta f_i| $$
For the whole miter gear, I took the maximum among all measured teeth:
$$ F_\beta = \max(f_{\beta 1}, f_{\beta 2}, \ldots, f_{\beta m}) $$
Pitch deviation is the third key item. The single pitch deviation \(f_{pt}\) is the difference between the actual pitch and the theoretical pitch on the pitch circle. The cumulative pitch deviation \(F_{pk}\) is the algebraic difference between the actual arc length and the theoretical arc length over \(k\) pitches. The total cumulative pitch deviation \(F_p\) is the maximum difference between any two cumulative pitch deviations on the same side of the miter gear teeth. I computed these deviations from coordinate measurement data.
For two adjacent teeth, I measured points \(P_1(x_1, y_1)\) and \(P_2(x_2, y_2)\) on the same side of the profiles. The radius and pressure angle at each point are:
$$ r_1 = \sqrt{x_1^2 + y_1^2}, \qquad r_2 = \sqrt{x_2^2 + y_2^2} $$
$$ \alpha_1 = \arccos\left(\frac{r_b}{r_1}\right), \qquad \alpha_2 = \arccos\left(\frac{r_b}{r_2}\right) $$
The polar angles are:
$$ \phi_1 = \arccos\left(\frac{x_1}{r_1}\right), \qquad \phi_2 = \arccos\left(\frac{x_2}{r_2}\right) $$
The involute intersection angle with the pitch circle is:
$$ \phi_f = \phi_i + \mathrm{inv}\,\alpha_i – \mathrm{inv}\,\alpha $$
where \(\alpha\) is the pitch pressure angle. The angle between the two adjacent tooth profiles on the pitch circle is:
$$ \Delta\phi = \phi_{f2} – \phi_{f1} $$
The actual pitch is:
$$ P_t’ = r \Delta\phi $$
The theoretical pitch is:
$$ P_t = \pi m $$
Therefore, the single pitch deviation is:
$$ f_{pt} = P_t’ – P_t $$
After calculating all single pitch deviations, the total cumulative pitch deviation is:
$$ F_p = \max(f_{pt}) – \min(f_{pt}) $$
I also considered the cumulative pitch deviation over \(k\) pitches:
$$ F_{pk} = \sum_{i=1}^{k} f_{pt,i} $$
These formulas provided a complete set of calculation methods for the miter gear deviation evaluation.
I implemented the miter gear tooth surface calculation and error evaluation in a graphical programming environment. The software consisted of a front panel, a block diagram, and a connector panel. The front panel allowed the user to input the basic parameters of the miter gear. The block diagram contained the mathematical operations and the calls to the numerical engine. I designed separate modules for profile deviation, helix deviation, and pitch deviation. The profile deviation module read the measured profile coordinates, calculated the deviation for each measured tooth, and displayed the total profile deviation. The helix deviation module read the measured helix coordinates, calculated the deviation for each helix trace, and displayed the total helix deviation. The pitch deviation module read the measured pitch coordinates, calculated the single pitch deviation for each tooth, and displayed the cumulative pitch deviation.
I paid special attention to the human-computer interaction design. The main interface allowed the user to select the deviation type. Once a deviation type was selected, the corresponding module opened and displayed the relevant input fields and result tables. I used spreadsheet controls for coordinate data and result data, and I used waveform charts for single pitch deviation curves. This made the miter gear evaluation process clear and efficient. The software also allowed the user to save and load data files, which is important for repeated miter gear measurements.
For the experimental verification, I used a coordinate measuring machine. The coordinate measuring machine created a three-dimensional Cartesian coordinate system using three orthogonal axes. The probe touched the miter gear surface, and the measuring system recorded the coordinates of the probe center. The software compensated for the probe radius automatically. I fixed the miter gear on the worktable and established a part coordinate system. I took three points on the top face to define the \(XY\) plane. I took three points on the inner bore to define the \(Z\)-axis. I took two points on opposite profiles of one tooth to define the \(X\)-axis. Then I measured the profile, helix, and pitch according to the predefined measurement paths.
For profile measurement, I measured four teeth evenly distributed around the miter gear. On each tooth, I measured the left and right profiles from near the base circle to near the addendum circle. I kept the \(Z\) coordinate constant. The probe touched the surface along the normal direction. The measured points were stored in a text file. I then used the profile deviation formula to process the data. The following table shows a portion of the raw profile measurement data for the miter gear.
| Tooth | Point | \(X\) (mm) | \(Y\) (mm) |
|---|---|---|---|
| 1 left | 1 | 32.1436 | 3.0128 |
| 1 left | 2 | 33.3346 | 2.7680 |
| 1 left | 3 | 34.5112 | 2.3989 |
| 1 left | 4 | 35.6879 | 1.9035 |
| 1 left | 5 | 36.8559 | 1.2953 |
| 1 right | 1 | 31.9313 | -4.7107 |
| 1 right | 2 | 33.1312 | -4.5197 |
| 1 right | 3 | 34.3294 | -4.2110 |
| 1 right | 4 | 35.5334 | -3.7736 |
| 1 right | 5 | 36.7355 | -3.2377 |
After processing the profile data, I obtained the following profile deviation results. The total profile deviation of the miter gear was \(F_\alpha = 0.0174\) mm. This value was within the expected range for the tested miter gear, and it confirmed that the theoretical profile model was consistent with the actual measured profile.
| Tooth | Point | \(\phi_i\) (rad) | \(\omega_i\) (rad) | \(\Delta f\) (mm) |
|---|---|---|---|---|
| 1 left | 1 | 1.4773 | 1.4734 | 0.0139 |
| 1 left | 2 | 1.4879 | 1.4734 | |
| 1 left | 3 | 1.5014 | 1.4731 | |
| 1 left | 4 | 1.5175 | 1.4730 | |
| 1 left | 5 | 1.5357 | 1.4731 | |
| 1 right | 1 | -1.4243 | -1.4205 | 0.0157 |
| 1 right | 2 | -1.4352 | -1.4208 | |
| 1 right | 3 | -1.4487 | -1.4205 | |
| 1 right | 4 | -1.4650 | -1.4205 | |
| 1 right | 5 | -1.4829 | -1.4203 |
For helix measurement, I measured the left and right helix traces of four teeth. The probe moved along the pitch helix from one end of the face width to the other. The measured points were spaced uniformly along the \(Z\)-axis. The following table shows a portion of the raw helix measurement data.
| Tooth | Point | \(X\) (mm) | \(Y\) (mm) | \(Z\) (mm) |
|---|---|---|---|---|
| 1 right | 1 | 34.4913 | 0.6245 | -1.5005 |
| 1 right | 2 | 34.4754 | 1.3504 | -3.9027 |
| 1 right | 3 | 34.4401 | 2.0770 | -6.3024 |
| 1 right | 4 | 34.3877 | 2.8002 | -8.7026 |
| 1 right | 5 | 34.2921 | 3.5119 | -11.1013 |
| 1 left | 1 | 33.9568 | -6.0122 | -1.5009 |
| 1 left | 2 | 34.0888 | -5.3099 | -3.9042 |
| 1 left | 3 | 34.1901 | -4.5981 | -6.3011 |
| 1 left | 4 | 34.2786 | -3.8708 | -8.7024 |
| 1 left | 5 | 34.3640 | -3.1484 | -11.1017 |
After processing the helix data, I obtained the helix deviation results. The total helix deviation of the miter gear was \(F_\beta = 0.0180\) mm. This result indicated that the helix trace was close to the design helix, and the miter gear had good axial contact characteristics.
| Tooth | Point | \(\theta_i\) (rad) | \(\Delta W_i\) (mm) | \(\Delta f_i\) (mm) |
|---|---|---|---|---|
| 1 right | 1 | 0.0181 | 0 | 0 |
| 1 right | 2 | 0.0392 | 0.7215 | 0.0024 |
| 1 right | 3 | 0.0602 | 0.7228 | 0.0037 |
| 1 right | 4 | 0.0813 | 0.7205 | 0.0014 |
| 1 right | 5 | 0.1021 | 0.7132 | -0.0055 |
| 1 left | 1 | -0.1752 | 0 | 0 |
| 1 left | 2 | -0.1545 | 0.7101 | -0.0085 |
| 1 left | 3 | -0.1337 | 0.7145 | -0.0043 |
| 1 left | 4 | -0.1125 | 0.7292 | 0.0087 |
| 1 left | 5 | -0.0914 | 0.7216 | 0.0036 |
For pitch measurement, I measured the left and right profiles of every tooth in the same transverse plane. I kept the \(Z\) coordinate constant and alternated between left and right profiles. The following table shows a portion of the raw pitch measurement data.
| Tooth side | Tooth number | \(X\) (mm) | \(Y\) (mm) |
|---|---|---|---|
| Left | 1 | -26.8138 | -21.7197 |
| Left | 2 | -32.3976 | -11.8390 |
| Left | 3 | -34.4902 | -0.6886 |
| Left | 4 | -32.8544 | 10.5486 |
| Left | 5 | -27.6472 | 20.6407 |
| Right | 1 | -23.6017 | -25.1792 |
| Right | 2 | -30.4838 | -16.1471 |
| Right | 3 | -34.0615 | -5.3844 |
| Right | 4 | -33.9658 | 5.9590 |
| Right | 5 | -30.1933 | 16.6553 |
After processing the pitch data, I obtained the single pitch deviation for each tooth. The following table shows a portion of the processed pitch deviation results. The left and right sides were evaluated separately. The total cumulative pitch deviation of the miter gear was \(F_p = 0.0263\) mm.
| Tooth side | Tooth number | \(\phi_i\) (rad) | \(\Delta\phi\) (rad) | \(P_t’\) (mm) | \(f_{pt}\) (mm) |
|---|---|---|---|---|---|
| Left | 1 | 0.6808 | 0 | 0 | 0 |
| Left | 2 | 0.3504 | 0.3305 | 11.3290 | -0.0078 |
| Left | 3 | 0.0120 | 0.3304 | 11.3263 | -0.0104 |
| Left | 4 | -0.3107 | 0.3306 | 11.3348 | -0.0020 |
| Left | 5 | -0.6413 | 0.3306 | 11.3346 | -0.0022 |
| Right | 1 | 0.8177 | 0 | 0 | 0 |
| Right | 2 | 0.4871 | 0.3306 | 11.3337 | -0.0031 |
| Right | 3 | 0.1568 | 0.3303 | 11.3245 | -0.0122 |
| Right | 4 | -0.1737 | 0.3305 | 11.3285 | -0.0082 |
| Right | 5 | -0.5041 | 0.3304 | 11.3271 | -0.0096 |
I summarized the total deviations of the miter gear in the following table. These values provided a complete accuracy assessment of the tested miter gear.
| Deviation item | Symbol | Result (mm) |
|---|---|---|
| Total profile deviation | \(F_\alpha\) | 0.0174 |
| Total helix deviation | \(F_\beta\) | 0.0180 |
| Total cumulative pitch deviation | \(F_p\) | 0.0263 |
I also validated the error evaluation software by importing the measured data into the software modules. The profile deviation module produced the same total profile deviation as the manual calculation. The helix deviation module produced the same total helix deviation. The pitch deviation module produced the same single pitch deviations and total cumulative pitch deviation. This agreement confirmed that the software implementation was correct and that the miter gear evaluation workflow was reliable.
In my study, I found that the miter gear tooth surface model derived from the involute helicoid principle is accurate and practical. The model can be used to generate the theoretical coordinates of any point on the miter gear tooth surface. The model also provides a basis for measurement path planning. By comparing measured coordinates with theoretical coordinates, I could calculate profile deviation, helix deviation, and pitch deviation with high confidence. The miter gear measurement process was efficient because the coordinate measuring machine could capture all necessary points in a single setup.
I also observed that the axial force cancellation of the miter gear is directly related to the symmetry of the two helical halves. If the two halves are not perfectly symmetric, the axial forces will not cancel completely. Therefore, the helix deviation of the miter gear is especially important. A small helix deviation can cause an unbalanced axial force and a poor contact pattern. For this reason, I recommend that miter gear inspection always include both left and right helix traces. The total helix deviation should be evaluated on both sides of the miter gear.
Similarly, the profile deviation of the miter gear affects the smoothness of meshing. Because the miter gear often operates at high speed, a profile deviation can produce significant vibration. The profile deviation should be measured on multiple teeth around the circumference. The maximum profile deviation among the measured teeth should be used as the total profile deviation of the miter gear. This approach is consistent with the standard definition and with practical miter gear quality control.
The pitch deviation of the miter gear affects the motion accuracy. If the single pitch deviation is large, the miter gear will not rotate uniformly. The cumulative pitch deviation will cause angular transmission error. I calculated both the single pitch deviation and the total cumulative pitch deviation. The single pitch deviation curve was useful for identifying local pitch errors, while the total cumulative pitch deviation was useful for evaluating the overall motion accuracy of the miter gear.
In terms of software design, I found that a graphical programming environment is very suitable for miter gear measurement and evaluation. The user can input parameters, load measurement data, and view results without writing code. The modular design allows the user to evaluate profile deviation, helix deviation, and pitch deviation separately. The software can also be extended to include other deviation items, such as base pitch deviation and radial runout. This flexibility is important for future miter gear research.
For future work, I plan to extend the miter gear model to a full solid model in a three-dimensional CAD environment. I will import the calculated tooth surface points into a CAD system and create a precise solid model of the miter gear. Then I will perform virtual assembly and motion simulation. I also plan to study non-contact measurement methods for small-module miter gears, because contact measurement may be difficult when the tooth space is very small. Optical measurement and image-based measurement could be useful alternatives. These extensions will make the miter gear modeling and measurement system more complete.
In conclusion, I successfully established a mathematical model for the miter gear tooth surface, derived the equations for the right and left tooth surfaces, and generated the complete miter gear geometry. I analyzed the profile deviation, helix deviation, and pitch deviation of the miter gear, and I developed calculation methods and software for each deviation. I measured a miter gear using a coordinate measuring machine and verified the theoretical model with experimental data. The total profile deviation was \(F_\alpha = 0.0174\) mm, the total helix deviation was \(F_\beta = 0.0180\) mm, and the total cumulative pitch deviation was \(F_p = 0.0263\) mm. These results demonstrated that my miter gear model and measurement methods are correct and practical. The miter gear remains an important transmission component, and accurate modeling and measurement are essential for improving its performance in high-speed and heavy-load applications.