
I began this study from the observation that a miter gear transmission in a marine drivetrain must simultaneously carry high torque, remain compact, and radiate as little vibration and noise as possible. In the configuration I examined, the miter gear is arranged as a double-helical miter gear pair with opposite hand helical sides, so the axial forces generated by the two sides can be balanced within the miter gear itself. This balance is one reason the miter gear remains attractive for high-speed and heavy-load applications. However, the miter gear still receives internal excitations from time-varying mesh stiffness and meshing impact, and these excitations travel through bearings and housing feet as vibration. My objective was therefore to design a triangular end relief for the miter gear, to realize that relief by a practical form-grinding method, and to verify the vibration reduction by dynamic analysis and experiments.
I treated the miter gear tooth surface as a pair of mirrored helical surfaces. I first generated one hand of the miter gear by a virtual generating rack, then obtained the opposite hand by a symmetric mapping about the central plane of the relief groove. This allowed me to describe the miter gear standard tooth surface, the triangular end relief surface, the contact behavior of the miter gear pair, the loaded transmission error, the meshing impact force, and the dynamic response of the miter gear system with a consistent geometric model. The triangular end relief I used is a diagonal relief: material is removed only near the tooth tip and tooth root, while the middle working region remains nearly unmodified. This is important for a miter gear because the effective contact area remains large, the contact ratio is not severely reduced, and the loaded transmission error fluctuation can be decreased.
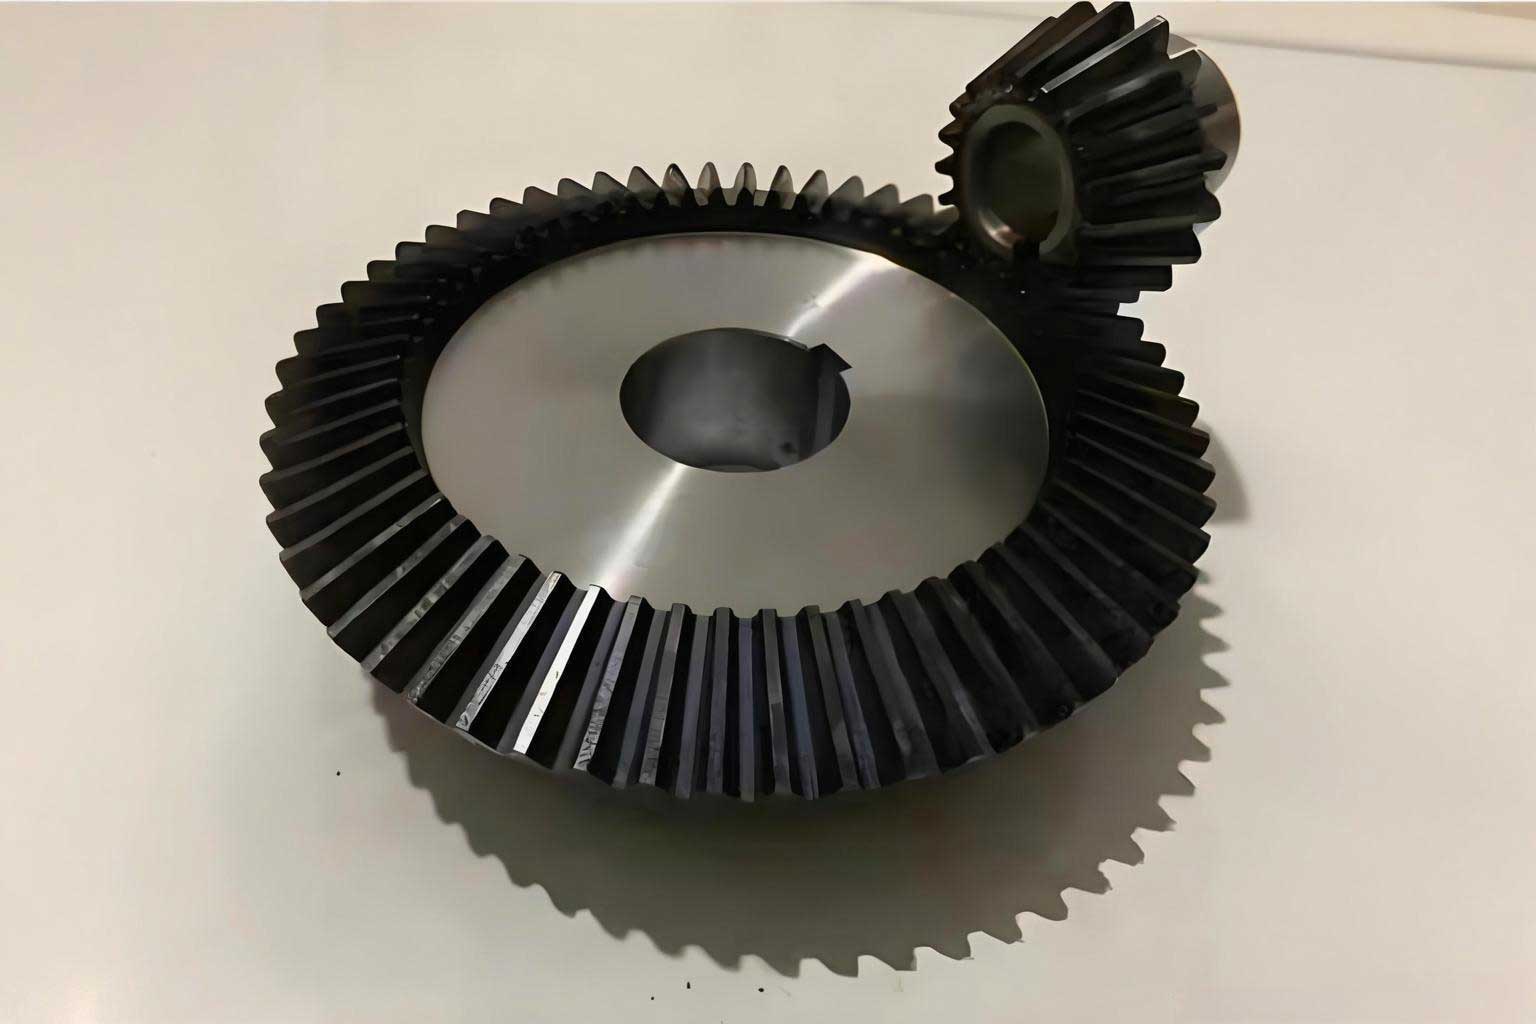
For the geometric foundation, I used a rack cutter coordinate system and transformed it to the miter gear workpiece coordinate system. The standard involute miter gear tooth surface can be expressed in parametric form. Let the rack cutter position vector and unit normal be given in the cutter system, and let the transformation matrix from the cutter system to the miter gear workpiece system be \(\mathbf M_{i,ti}\). Then the miter gear tooth surface position and normal are
$$
\mathbf r_{ti}(u_i,l_i,\theta_i)=\mathbf M_{i,ti}\mathbf r_{ti},\qquad
\mathbf n_{ti}(u_i,l_i,\theta_i)=\mathbf L_{i,ti}\mathbf n_{ti}
$$
and the meshing equation is
$$
f_i(u_i,l_i,\theta_i)=\mathbf n_{ti}\cdot\frac{\partial \mathbf r_{ti}}{\partial \theta_i}=0
$$
Here \(u_i\) and \(l_i\) are surface parameters, and \(\theta_i\) is the miter gear rotation angle. The subscript \(i=1,2\) denotes the pinion and the gear of the miter gear pair. For the root fillet of the miter gear, I used a rack tip transition arc with radius \(r_{wi}=0.25m_n/(1-\sin\alpha_n)\). The fillet surface and its meshing condition follow the same transformation logic, so the complete miter gear tooth flank, including the working involute and the root fillet, can be generated in a unified way. For the opposite hand of the miter gear, I applied a symmetric mapping; thus the full double-helical miter gear geometry is available without an independent derivation for the second side.
The most important design decision in triangular end relief is where to start the relief and how much material to remove. I defined the tip relief height \(L_{Ea}\), the maximum tip relief amount \(C_{Ea}\), the root relief height \(L_{Ef}\), and the maximum root relief amount \(C_{Ef}\). The starting lines of the tip and root relief are spatial helices on the miter gear tooth surface. I computed their helix angles on the rotation projection plane and then approximated the instantaneous contact lines by straight lines in the projection. If \(P\) is an arbitrary point in the relief region, \(l_p\) is its distance to the relief starting line, and \(l_a\) or \(l_f\) is the corresponding total relief length, the relief amount for a linear triangular end relief is
$$
\delta(z,x’)=C_{Ea}\frac{l_p}{l_a}\quad \text{for }P\in ABC
$$
$$
\delta(z,x’)=C_{Ef}\frac{l_p}{l_f}\quad \text{for }P\in DEF
$$
$$
\delta(z,x’)=0\quad \text{otherwise}
$$
For a quadratic parabolic triangular end relief, I used
$$
\delta(z,x’)=C_{Ea}\left(\frac{l_p}{l_a}\right)^2\quad \text{for }P\in ABC
$$
$$
\delta(z,x’)=C_{Ef}\left(\frac{l_p}{l_f}\right)^2\quad \text{for }P\in DEF
$$
$$
\delta(z,x’)=0\quad \text{otherwise}
$$
The modified miter gear tooth surface is then obtained by superimposing the relief amount along the normal direction of the standard miter gear surface:
$$
\mathbf r_{1m}(u_1,l_1,\theta_1)=\mathbf r_1(u_1,l_1,\theta_1)+\delta(z,x’)\mathbf n_1(u_1,l_1,\theta_1)
$$
$$
\mathbf n_{1m}(u_1,l_1,\theta_1)=\mathbf n_1(u_1,l_1,\theta_1)+\delta(z,x’)\left(\frac{\partial \mathbf n_1}{\partial u_1}+\frac{\partial \mathbf n_1}{\partial l_1}\right)
$$
I used the normal-direction superposition because triangular end relief is a normal modification rather than a simple profile shift or lead crowning. In this way, the relief remains attached to the miter gear tooth surface and follows the local contact-line direction. The starting line of the relief is found by solving the nonlinear geometric constraints that relate the tooth surface radius and the axial coordinate to the desired relief boundary. For the root end, I also ensured that the active involute length was not reduced below the required minimum meshing length.
To evaluate the miter gear pair after triangular end relief, I used tooth contact analysis and loaded tooth contact analysis. The geometric contact condition for the two sides of the miter gear pair can be written in a fixed coordinate system as
$$
\mathbf r_f^{(1)}(u_1,l_1,\varepsilon,\theta_1)=\mathbf r_f^{(2)}(u_2,l_2,\theta_2)
$$
$$
\mathbf n_f^{(1)}(u_1,l_1,\varepsilon,\theta_1)=\mathbf n_f^{(2)}(u_2,l_2,\theta_2)
$$
where \(\varepsilon\) is the axial floating displacement of the miter gear pinion. Because the miter gear pinion is allowed to float axially, the left and right sides of the miter gear pair can share the load and balance the axial force. For the loaded contact analysis, I generated a finite-element mesh of the miter gear tooth, obtained the normal flexibility matrix, and combined it with the initial gap from the geometric contact analysis. The loaded contact model can be written as a complementarity problem:
$$
\mathbf F\mathbf p+\mathbf Z+\mathbf w=\mathbf d
$$
$$
\mathbf e^T\mathbf p=P_0
$$
$$
p_j\ge 0,\qquad d_j\ge 0,\qquad p_jd_j=0
$$
Here \(\mathbf p\) is the discrete normal load vector, \(\mathbf Z\) is the normal displacement, \(\mathbf w\) is the initial gap, \(\mathbf d\) is the final gap, and \(P_0\) is the total normal load. For the miter gear pair, I also imposed the axial force balance condition:
$$
\sum_{j=1}^{n}p_j^{(I)}\cos\eta+\sum_{j=1}^{n}p_j^{(II)}\cos\eta
=
\sum_{j=1}^{n}p_j^{(III)}\cos\eta+\sum_{j=1}^{n}p_j^{(IV)}\cos\eta
$$
where the four groups represent the left and right contact pairs of the miter gear. After solving the loaded contact problem, the load sharing factor at a contact position is
$$
L_k=\frac{\sum_{j=1}^{n}p_{jk}}{P_0}
$$
and the loaded transmission error of the miter gear pair is
$$
T_e=\frac{3600\times 180}{\pi}\frac{Z}{r_b\cos\beta}
$$
The fluctuation of the loaded transmission error is the key excitation for miter gear vibration:
$$
\Delta T_e=\max(T_e)-\min(T_e)
$$
I found that the triangular end relief can significantly reduce this fluctuation because the relief is arranged along the instantaneous contact line and therefore compensates for the loaded deformation more effectively than a conventional profile or lead modification. The middle part of the miter gear tooth remains almost unchanged, so the miter gear pair keeps a large effective contact area.
The second major excitation is the meshing impact force. In an ideal miter gear pair, the teeth enter and leave contact smoothly. In practice, manufacturing error, installation error, and tooth deflection cause the actual meshing point to deviate from the theoretical point. The driven miter gear tooth tip may contact the driving miter gear flank ahead of the theoretical line of action, producing a corner contact and an impact. I calculated the actual impact position by reversing the driven miter gear through a small angle until contact occurred. If the loaded transmission error is \(T_e\), the center distance is \(a\), the gear ratio is \(i\), and the pressure angle is \(\alpha\), the geometric relation for the actual impact point can be solved from the following equations:
$$
O_1D^2=a^2+r_{a2}^2-2ar_{a2}\cos(\angle PO_2D)
$$
$$
\angle PO_2D=\gamma_2+T_e+\Delta\varphi_{k2}
$$
$$
\gamma_2=\frac{\pi}{2}-\alpha-\angle PEO_2
$$
$$
\angle PEO_2=\arcsin\left(\frac{r_{p2}\sin(\alpha+\pi/2)}{r_{a2}}\right)
$$
$$
O_1E^2=a^2+r_{a2}^2-2ar_{a2}\cos\gamma_2
$$
The offset angle \(\Delta\varphi_{k2}\) and the actual impact point \(D\) are obtained by solving these equations together with the involute function relation
$$
\operatorname{inv}\lambda=\tan\lambda-\lambda
$$
Once the actual impact point is known, the relative velocity along the line of action is
$$
\mathbf v_{12}^{(f)}=\left(\mathbf w^{(1)}-\mathbf w^{(2)}\right)\times \mathbf r^{(1)}-\mathbf E_f\times \mathbf w^{(2)}
$$
where \(\mathbf w^{(1)}\) and \(\mathbf w^{(2)}\) are the angular velocity vectors of the pinion and gear in the fixed coordinate system. The impact kinetic energy of the miter gear pair is
$$
E_k=\frac{1}{2}\left(\frac{J_1J_2}{J_1r_{b2}^2+J_2r_{b1}^2}\right)\left(v_{12}^{(f)}\right)^2
$$
Using energy conservation between the impact kinetic energy and the elastic strain energy of the miter gear teeth, the maximum meshing impact force is
$$
F_s=v_{12}^{(f)}\sqrt{k_s\frac{J_1J_2}{J_1r_{b2}^2+J_2r_{b1}^2}}
$$
Here \(k_s\) is the meshing stiffness at the actual impact point. This impact force is a major source of miter gear noise, especially at low load and high speed. The triangular end relief reduces the impact force because it removes the interfering material near the tooth tip and root, allowing the miter gear pair to enter contact more gradually.
I formulated the triangular end relief design as a multi-objective optimization problem. The objectives were the minimum loaded transmission error fluctuation and the minimum meshing impact force of the miter gear pair. The design variables were the maximum relief amounts and the relief heights at the tip and root. The optimization model can be written as
$$
\min Q(y_1,y_2,y_3,y_4)
=
w_1\frac{\Delta T_e(y_1,y_2,y_3,y_4)}{\Delta T_{e0}}
+
w_2\frac{F_s(y_1,y_2,y_3,y_4)}{F_{s0}}
$$
$$
\Delta T_e(y_1,y_2,y_3,y_4)=\max T_e-\min T_e
$$
$$
Q_{\min}\le y_1\le Q_{\max}
$$
$$
h_{a\min}\le y_2\le h_{a\max}
$$
$$
Q_{\min}\le y_3\le Q_{\max}
$$
$$
h_{f\min}\le y_4\le h_{f\max}
$$
where \(w_1\) and \(w_2\) are weighting factors. I set both weights to \(0.5\). \(\Delta T_{e0}\) and \(F_{s0}\) are the corresponding values of the standard miter gear pair. I used the NSGA-II genetic algorithm because the objective functions are obtained through repeated tooth contact analysis and loaded tooth contact analysis, so no simple analytical gradient is available. The population size was 100 to 200, and the generation number was 100 to 400. The algorithm produced a set of non-dominated solutions, and I selected the compromise solution with balanced reduction of loaded transmission error fluctuation and impact force.
The basic parameters of the miter gear pair I studied are listed in the following table. The miter gear pinion has 30 teeth, the gear has 72 teeth, the normal module is 5 mm, the pressure angle is 20 degrees, and the helix angle is 33.273 degrees. The miter gear pair uses a relief groove between the two helical sides. The pinion speed for the dynamic test was 2500 r/min, and the rated torque on the gear was 3000 N m.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth | 30 | 72 |
| Normal module (mm) | 5 | 5 |
| Pressure angle (degree) | 20 | 20 |
| Helix angle (degree) | 33.273 | 33.273 |
| Hand | left and right | right and left |
| Face width (mm) | 44 each side | 40 each side |
| Relief groove width (mm) | 46 | 50 |
| Speed (r/min) | 2500 | not applicable |
| Rated torque (N m) | not applicable | 3000 |
For the standard miter gear tooth surface, the geometric transmission error is zero, but the loaded transmission error fluctuates because of tooth deflection. At the rated torque, the standard miter gear pair had a loaded transmission error fluctuation of \(0.8102\) arc seconds, and the meshing impact force was \(2983\) N. The load sharing factor reached a maximum of \(0.3378\). The contact pattern showed edge contact near the entering and leaving regions, which is one reason the miter gear pair generated impact and vibration.
After I optimized the linear triangular end relief for the miter gear pinion, the maximum tip relief amount was \(16.10\ \mu\text{m}\), the tip relief height was \(2.72\ \text{mm}\), the maximum root relief amount was \(9.31\ \mu\text{m}\), and the root relief height was \(2.81\ \text{mm}\). The optimization objective converged after about 43 generations, and the minimum objective value was \(0.15\). At the rated torque, the loaded transmission error fluctuation decreased to \(0.1973\) arc seconds, which is a reduction of \(75.55\) percent compared with the standard miter gear pair. The meshing impact force decreased to \(191\) N, a reduction of \(93.60\) percent. The load sharing factor in the relief region became smaller than that of the standard miter gear, and the maximum load sharing factor moved toward the middle of the tooth. The multi-load curves showed that the loaded transmission error fluctuation first decreased and then increased with increasing load, reaching a minimum near the rated load.
For the quadratic parabolic triangular end relief, the optimized maximum tip relief amount was \(16.53\ \mu\text{m}\), the tip relief height was \(4.52\ \text{mm}\), the maximum root relief amount was \(11.63\ \mu\text{m}\), and the root relief height was \(2.44\ \text{mm}\). The objective converged after about 50 generations, and the minimum objective value was \(0.11\). At the rated torque, the loaded transmission error fluctuation decreased to \(0.1319\) arc seconds, which is a reduction of \(83.7\) percent. The meshing impact force decreased to \(168\) N, a reduction of \(94.37\) percent. The quadratic parabolic miter gear relief produced a smoother entry into contact than the linear relief and therefore gave a better dynamic result. The following table summarizes the optimized triangular end relief parameters for the miter gear pinion.
| Relief type | Tip maximum relief | Tip relief height | Root maximum relief | Root relief height |
|---|---|---|---|---|
| Linear | 16.10 micrometers | 2.72 mm | 9.31 micrometers | 2.81 mm |
| Quadratic parabolic | 16.53 micrometers | 4.52 mm | 11.63 micrometers | 2.44 mm |
I then addressed how to manufacture the triangular end relief on the miter gear by form grinding. The miter gear pinion was ground on a five-axis CNC form grinding machine. The machine has two linear axes and three rotary axes. The grinding wheel spindle provides the main cutting motion, the wheel head moves radially relative to the workpiece, the workpiece spindle indexes the miter gear, the workpiece table moves axially, and the wheel swivel sets the helix angle. I derived the coordinate transformation from the workpiece to the wheel and then to the machine axes. The transformation from the workpiece coordinate system to the wheel coordinate system is
$$
\mathbf r_t=\mathbf M_{t1}(\gamma_m,E_t,L_t)\mathbf r_1
$$
$$
\mathbf n_t=\mathbf L_{t1}(\gamma_m,E_t,L_t)\mathbf n_1
$$
where \(\gamma_m\) is the wheel setting angle, \(E_t\) is the center distance, and \(L_t\) is the axial travel of the wheel. Because the wheel is a surface of revolution, the normal at every wheel surface point must intersect or be parallel to the wheel axis. The contact condition is therefore
$$
f_t(u_1,l_1,\theta_1)=\mathbf n_t\cdot(\mathbf z_t\times\mathbf r_t)=0
$$
Solving this equation gives the contact line between the wheel and the miter gear tooth surface. Rotating the contact points into the wheel axial plane gives the wheel profile. The machine axis parameters are related to the virtual generating parameters by
$$
\psi_a=\theta_1
$$
$$
\psi_b=\gamma_m
$$
$$
C_x=-L_t
$$
$$
C_y=E_t
$$
For the miter gear pinion, I selected a wheel diameter of 100 mm. The axial travel was \(C_x=-136.7044\theta_1\), the radial position was \(C_y=139.7058\) mm, the workpiece rotation was \(\psi_a=\theta_1\), and the wheel swivel was \(\psi_b=0.5807\) rad. These values were used to control the actual grinding process.
To realize the triangular end relief efficiently, I proposed a three-section grinding wheel form-grinding method. The idea is that a linear triangular end relief on the miter gear can be approximated by three helical surfaces with different basic parameters. The middle section is the standard miter gear helical surface. The tip section has a different pressure angle, module, or helix angle so that it removes extra material near the tooth tip. The root section has another set of parameters so that it removes extra material near the tooth root. The three sections are combined on one grinding wheel, and the wheel is dressed to the three corresponding profiles. The miter gear is first ground with the standard section, then with the root section, and finally with the tip section. In this way, the triangular end relief is produced without a complex special cutter.
For the linear triangular end relief, I selected the normal module \(m_n\), normal pressure angle \(\alpha_n\), and helix angle \(\beta\) as the design variables for the tip and root sections. For the quadratic parabolic triangular end relief, I added the profile relief height \(h\) and the profile relief amount \(\zeta\) as additional design variables. The optimization objective was the minimum square sum of the normal deviation between the actual three-section ground miter gear surface and the target triangular end relief surface. If the target surface points and normals are \(\mathbf p_{i,j}^{*}\) and \(\mathbf n_{i,j}^{*}\), and the actual surface points and normals are \(\mathbf p_{i,j}\) and \(\mathbf n_{i,j}\), the normal deviation is
$$
h_{i,j}=\left(\mathbf p_{i,j}^{*}-\mathbf p_{i,j}\right)\cdot\mathbf n_{i,j}
$$
and the objective for the tip or root section is
$$
\min f_j(\mathbf d)=\mathbf H_j^T(\mathbf d)\mathbf H_j(\mathbf d)
$$
$$
\mathbf H_j(\mathbf d)=
\begin{bmatrix}
h_{1,j} & h_{2,j} & \cdots & h_{k,j}
\end{bmatrix}^T
$$
For the linear triangular end relief, the optimized tip parameters were a module of \(5.00053\) mm, a pressure angle of \(20.5342\) degrees, and a helix angle of \(33.4012\) degrees. The optimized root parameters were a module of \(5.00383\) mm, a pressure angle of \(19.9219\) degrees, and a helix angle of \(33.2534\) degrees. The maximum theoretical deviation between the ground miter gear surface and the target surface was less than \(1\ \mu\text{m}\). For the quadratic parabolic triangular end relief, the optimized tip parameters were a module of \(4.9995\) mm, a pressure angle of \(20.0423\) degrees, a helix angle of \(33.3354\) degrees, a profile relief height of \(6.44\) mm, and a profile relief amount of \(16.25\ \mu\text{m}\). The optimized root parameters were a module of \(5.00432\) mm, a pressure angle of \(19.9641\) degrees, a helix angle of \(33.2498\) degrees, a profile relief height of \(3.89\) mm, and a profile relief amount of \(3.50\ \mu\text{m}\). The maximum deviation was less than \(3\ \mu\text{m}\). The following table gives the optimized three-section wheel parameters.
| Section | Module (mm) | Pressure angle (degree) | Helix angle (degree) | Profile relief height (mm) | Profile relief amount (micrometers) | Maximum deviation |
|---|---|---|---|---|---|---|
| Linear tip | 5.00053 | 20.5342 | 33.4012 | not applicable | not applicable | less than 1 micrometer |
| Linear root | 5.00383 | 19.9219 | 33.2534 | not applicable | not applicable | less than 1 micrometer |
| Quadratic tip | 4.9995 | 20.0423 | 33.3354 | 6.44 | 16.25 | less than 3 micrometers |
| Quadratic root | 5.00432 | 19.9641 | 33.2498 | 3.89 | 3.50 | less than 3 micrometers |
I then ground a linear triangular end relief miter gear pinion and inspected it. The miter gear pair was designed to grade 4 accuracy. The measured profile total deviation, helix total deviation, single pitch deviation, and total cumulative pitch deviation were compared with the grade 4 limits. The measured profile and helix deviations were mostly inside the grade 4 tolerance band, and the single pitch and cumulative pitch deviations were also inside the limits. A small area near the tip of one hand exceeded the profile tolerance band by about \(2\ \mu\text{m}\), and a similar small excess appeared in the helix direction. The main causes were machine motion error, thermal drift, pressure-angle and helix-angle setting error, and repeated positioning error when the standard, tip, and root wheel sections were aligned. After several trial grinding and adjustment cycles, most indicators reached grade 4, and some were between grade 4 and grade 5. A rolling contact check of the miter gear pair showed that the triangular end relief region was bright and free of red lead, which confirmed that the relief had been generated in the intended region.
For the dynamic analysis, I built a twelve-degree-of-freedom bending-torsional-axial coupled model of the miter gear transmission. The model includes the transverse displacement, axial displacement, and torsional displacement of both sides of the miter gear pinion and gear. I assumed that the miter gear pinion floats axially, so the axial force from the left and right helical sides can be balanced. The generalized displacement vector is
$$
\mathbf q=
\begin{bmatrix}
y_{p1} & z_{p1} & \theta_{p1} & y_{g1} & z_{g1} & \theta_{g1} &
y_{p2} & z_{p2} & \theta_{p2} & y_{g2} & z_{g2} & \theta_{g2}
\end{bmatrix}^T
$$
The dynamic equations for the left side of the miter gear pinion can be written as
$$
m_{p1}\ddot y_{p1}+c_{p1y}\dot y_{p1}+k_{p1y}y_{p1}=-F_1
$$
$$
m_{p1}\ddot z_{p1}+c_{p1z}(\dot z_{p1}-\dot z_{p2})+k_{p1z}(z_{p1}-z_{p2})=-F_{1z}
$$
$$
I_{p1}\ddot\theta_{p1}=F_1R_{bp}+T_{p1}-F_{s1}R_{bp}
$$
and the equations for the right side are
$$
m_{p2}\ddot y_{p2}+c_{p2y}\dot y_{p2}+k_{p2y}y_{p2}=-F_2
$$
$$
m_{p2}\ddot z_{p2}+c_{p2z}(\dot z_{p2}-\dot z_{p1})+k_{p2z}(z_{p2}-z_{p1})=-F_{2z}
$$
$$
I_{p2}\ddot\theta_{p2}=F_2R_{bp}+T_{p2}-F_{s2}R_{bp}
$$
The gear side equations have the same structure with the sign of the mesh force reversed and with the gear inertia and base radius. The normal dynamic mesh force on one side of the miter gear is
$$
F_n=c_m\left(\dot y_p-\dot y_g+R_{bp}\dot\theta_p-R_{bg}\dot\theta_g+\dot z_p-\dot z_g\right)\cos\beta
+
k_m\left(y_p-y_g+R_{bp}\theta_p-R_{bg}\theta_g+z_p-z_g\right)\cos\beta
$$
and the axial and transverse components are
$$
F_y=F_n\cos\beta
$$
$$
F_z=F_n\sin\beta
$$
The mesh damping is calculated from the average mesh stiffness and the equivalent inertias:
$$
c_m=2\zeta\sqrt{\frac{k_{m0}I_pI_g}{I_pR_{bg}^2+I_gR_{bp}^2}}
$$
where \(\zeta\) is the relative damping ratio. I used \(\zeta=0.1\). The time-varying mesh stiffness of the miter gear is obtained from the loaded tooth contact analysis:
$$
K_m=\frac{F_n}{Z_k}
$$
I fitted the discrete stiffness values with Hermite interpolation and then expanded them into a Fourier series for the dynamic solution. The meshing impact force was also fitted as a periodic function by a Fourier series after its time history was obtained from the impact calculation. The impact duration is
$$
\Delta T=T_0-t_0
$$
where \(t_0\) is the meshing time at the actual impact point and \(T_0\) is the meshing time at the theoretical entering point. This impact force was applied as an internal excitation to the miter gear dynamic model.
For the sliding bearings that support the miter gear rotor, I used a linear oil-film force model. The Reynolds equation for the bearing oil film is
$$
\frac{\partial}{\partial\phi}\left(H^3\frac{\partial p}{\partial\phi}\right)
+
\left(\frac{D}{L}\right)^2
\frac{\partial}{\partial\lambda}\left(H^3\frac{\partial p}{\partial\lambda}\right)
=
6\left(\cos\phi\frac{\partial H}{\partial\phi}+2\frac{\partial H}{\partial\tau}\right)
$$
where \(H=h/c\) is the dimensionless film thickness, \(D\) is the bearing diameter, \(L\) is the bearing width, \(\phi\) is the circumferential coordinate, \(\lambda\) is the axial coordinate, and \(\tau\) is dimensionless time. After solving the pressure field, the oil-film stiffness and damping coefficients are obtained from the derivatives of the oil-film force with respect to displacement and velocity:
$$
k_{xx}=\frac{\partial F_x}{\partial x},\qquad
k_{xy}=\frac{\partial F_x}{\partial y},\qquad
k_{yx}=\frac{\partial F_y}{\partial x},\qquad
k_{yy}=\frac{\partial F_y}{\partial y}
$$
$$
c_{xx}=\frac{\partial F_x}{\partial \dot x},\qquad
c_{xy}=\frac{\partial F_x}{\partial \dot y},\qquad
c_{yx}=\frac{\partial F_y}{\partial \dot x},\qquad
c_{yy}=\frac{\partial F_y}{\partial \dot y}
$$
These coefficients were introduced into the miter gear dynamic model. The dynamic parameters of the miter gear system are summarized in the following table.
| Parameter | Pinion | Gear |
|---|---|---|
| Input speed (r/min) | 2500 | not applicable |
| Load torque (N m) | not applicable | 3000 |
| Material | 20CrMnTi | 20CrMnTi |
| Density (g/cm3) | 7.8 | 7.8 |
| Elastic modulus (GPa) | 207 | 207 |
| Relative damping ratio | 0.1 | 0.1 |
With the dynamic model, I compared the standard miter gear pair, the linear triangular end relief miter gear pair, and the quadratic parabolic triangular end relief miter gear pair. For the standard miter gear, the comprehensive time-varying mesh stiffness fluctuation was \(1.16\times10^8\) N/m. The maximum meshing impact force was \(2983\) N. The root-mean-square vibration acceleration along the line of action was \(70.24\) m/s2. The dominant frequency component was at the third mesh harmonic and reached \(47.97\) m/s2. The dynamic load fluctuation along the line of action was \(624\) N. As the load increased, the vibration acceleration increased steadily.
For the linear triangular end relief miter gear pair, the single-tooth mesh stiffness in the relief region decreased, while the unmodified middle region remained almost unchanged. The comprehensive time-varying mesh stiffness fluctuation was \(2.4\times10^7\) N/m, a reduction of \(79.31\) percent. The maximum meshing impact force was \(191\) N. The root-mean-square vibration acceleration along the line of action was \(11.83\) m/s2, a reduction of \(83.15\) percent. The dominant frequency component moved to the first mesh harmonic and had an amplitude of \(11.15\) m/s2. The dynamic load fluctuation was \(206\) N, a reduction of \(66.98\) percent. Under multiple loads, the vibration acceleration first decreased and then increased, which is consistent with the trend of the loaded transmission error fluctuation.
For the quadratic parabolic triangular end relief miter gear pair, the comprehensive time-varying mesh stiffness fluctuation was \(1.6\times10^7\) N/m, a reduction of \(86.20\) percent. The maximum meshing impact force was \(168\) N. The root-mean-square vibration acceleration along the line of action was \(8.43\) m/s2, a reduction of \(88\) percent. The dominant frequency component was at the third mesh harmonic and had an amplitude of \(7.3\) m/s2. The dynamic load fluctuation was \(161\) N, a reduction of \(74.2\) percent. The quadratic parabolic relief gave the best dynamic performance among the three miter gear cases. The following table summarizes the dynamic comparison.
| Case | Stiffness fluctuation (N/m) | Impact force (N) | Line-of-action acceleration RMS (m/s2) | Dynamic load fluctuation (N) |
|---|---|---|---|---|
| Standard miter gear | \(1.16\times10^8\) | 2983 | 70.24 | 624 |
| Linear triangular end relief | \(2.4\times10^7\) | 191 | 11.83 | 206 |
| Quadratic parabolic triangular end relief | \(1.6\times10^7\) | 168 | 8.43 | 161 |
I also designed experiments to verify the triangular end relief of the miter gear. The test objects were a standard miter gear pair and a miter gear pair with a linear triangular end relief pinion and a standard gear. The miter gear parameters were the same as those used in the simulation. The loaded transmission error test was performed at a very low pinion speed, \(4.18\) r/min, with gear torques of \(1000\), \(1500\), \(2000\), \(2500\), \(3000\), \(3500\), and \(4000\) N m. The vibration test was performed at a pinion speed of \(2500\) r/min with gear torques of \(1000\), \(2000\), \(3000\), and \(4000\) N m. For the loaded transmission error test, I used a pair of high-precision rotary encoders, a synchronized data acquisition system, and a processing program. The measurement accuracy was calibrated to \(\pm0.05\) arc seconds. The tooth-frequency transmission error was separated from the shaft-frequency cumulative pitch error by median filtering. For the vibration test, I used a mechanical closed-loop test rig with sliding bearings, and I measured the vertical vibration acceleration at the housing foot with a three-axis accelerometer. The sampling frequency was \(51200\) Hz, and the vibration signal was averaged over 100 mesh cycles.
The measured loaded transmission error fluctuations for the standard miter gear pair and the linear triangular end relief miter gear pair are compared in the following table. At the design torque of \(3000\) N m, the measured loaded transmission error fluctuation of the relieved miter gear pair was \(0.76\) arc seconds, while that of the standard miter gear pair was \(1.16\) arc seconds. The reduction was about \(34\) percent in the test. The simulated values were \(0.20\) and \(0.81\) arc seconds, respectively, giving a simulated reduction of about \(75\) percent. The test values were higher than the simulated values because of manufacturing error, assembly error, and housing deformation. The error between simulation and test was about \(30\) percent for the standard miter gear pair and about \(60\) percent for the relieved miter gear pair. The larger discrepancy for the relieved miter gear pair is reasonable because the three-section form-grinding process was still in an exploratory stage and the tooth surface deviation was more difficult to control than for the standard miter gear.
| Torque (N m) | Standard test (arc seconds) | Standard simulation (arc seconds) | Relieved test (arc seconds) | Relieved simulation (arc seconds) |
|---|---|---|---|---|
| 1000 | 0.73 | 0.26 | 0.91 | 0.48 |
| 1500 | 0.80 | 0.39 | 0.85 | 0.45 |
| 2000 | 0.86 | 0.53 | 0.74 | 0.36 |
| 2500 | 1.02 | 0.67 | 0.69 | 0.27 |
| 3000 | 1.16 | 0.81 | 0.76 | 0.20 |
| 3500 | 1.25 | 0.95 | 0.86 | 0.26 |
| 4000 | 1.33 | 1.09 | 1.01 | 0.36 |
The vibration test results showed the same general trend. At \(3000\) N m, the housing-foot vibration acceleration of the relieved miter gear pair was \(3.36\) m/s2, while that of the standard miter gear pair was \(4.22\) m/s2. The test reduction was about \(20\) percent. The simulated line-of-action vibration acceleration was \(11.83\) m/s2 for the relieved miter gear pair and \(70.24\) m/s2 for the standard miter gear pair, a reduction of about \(83\) percent. The housing-foot vibration was much smaller than the line-of-action acceleration because the sliding bearings and the housing damp and attenuate the vibration before it reaches the foot. The measured housing-foot vibration followed the same load trend as the measured loaded transmission error fluctuation: a larger loaded transmission error fluctuation produced a larger housing-foot vibration. The simulation and test both showed that the linear triangular end relief reduced the vibration of the miter gear pair, especially after \(1500\) N m. The following table compares the vibration results.
| Torque (N m) | Standard test (m/s2) | Standard simulation (m/s2) | Relieved test (m/s2) | Relieved simulation (m/s2) |
|---|---|---|---|---|
| 1000 | 3.34 | 22.72 | 2.93 | 26.87 |
| 2000 | 3.51 | 44.55 | 2.33 | 20.21 |
| 3000 | 4.22 | 70.24 | 3.36 | 11.83 |
| 3600 | 4.76 | 80.12 | 4.07 | 14.86 |
From the experimental and simulation results, I concluded that the triangular end relief of the miter gear is effective for reducing loaded transmission error fluctuation and meshing impact. The quadratic parabolic relief gave a better theoretical result than the linear relief, but the linear relief was easier to manufacture with the three-section form-grinding method and was therefore selected for the experimental miter gear. The three-section form-grinding method successfully produced the linear triangular end relief on the miter gear pinion. After repeated grinding, adjustment, and inspection, most tooth surface deviations reached grade 4 accuracy. The measured loaded transmission error and housing vibration were reduced under multiple loads, and the trends agreed with the simulation. The main source of the remaining error was the machine tool error and the repeated positioning error when the three wheel sections were aligned.
In my view, the triangular end relief of a miter gear should be designed together with the manufacturing method, because the geometric relief, the grinding wheel profile, and the dynamic response are strongly coupled. A miter gear with a well-designed triangular end relief keeps a large effective contact area, reduces the impact at entry, smooths the loaded transmission error, and lowers the vibration transmitted to the housing. The three-section form-grinding method provides a practical way to realize this relief on a miter gear with acceptable accuracy. Future work can extend the method to polynomial relief curves, include manufacturing error in the optimization, and build a full finite-element model of the miter gear, sliding bearings, and housing so that the housing-foot vibration can be predicted directly rather than represented by the line-of-action acceleration of the miter gear pair.