
In this study, I investigate the symmetrical deviation of miter gears and herringbone gears used in high-speed and heavy-duty transmissions. Miter gears are widely employed where motion and torque must be transferred with compact layouts, while herringbone gears are preferred when high load capacity and axial-force cancellation are required. In both miter gears and herringbone gears, geometric symmetry is essential for uniform load sharing. When symmetry is lost, the load shifts toward one side of the tooth system, the maximum contact stress rises, and the transmission may develop axial vibration, noise, and premature failure. My work therefore treats the symmetry problem as a measurable geometric deviation problem. I transform the symmetry condition into a comparison between two corresponding tooth flanks after mirroring about the symmetry midplane. I then decompose the deviation into circumferential distance, radial distance, helix angular deviation, and profile angular deviation. I design a coordinate measuring machine based feature-line measurement procedure, develop data-processing algorithms, perform experiments on an aviation herringbone gear, and analyze the influence of each deviation component on meshing behavior through finite element contact analysis. The same logic can be adapted to miter gears when their tooth flanks are inspected for mirror symmetry and load balance.
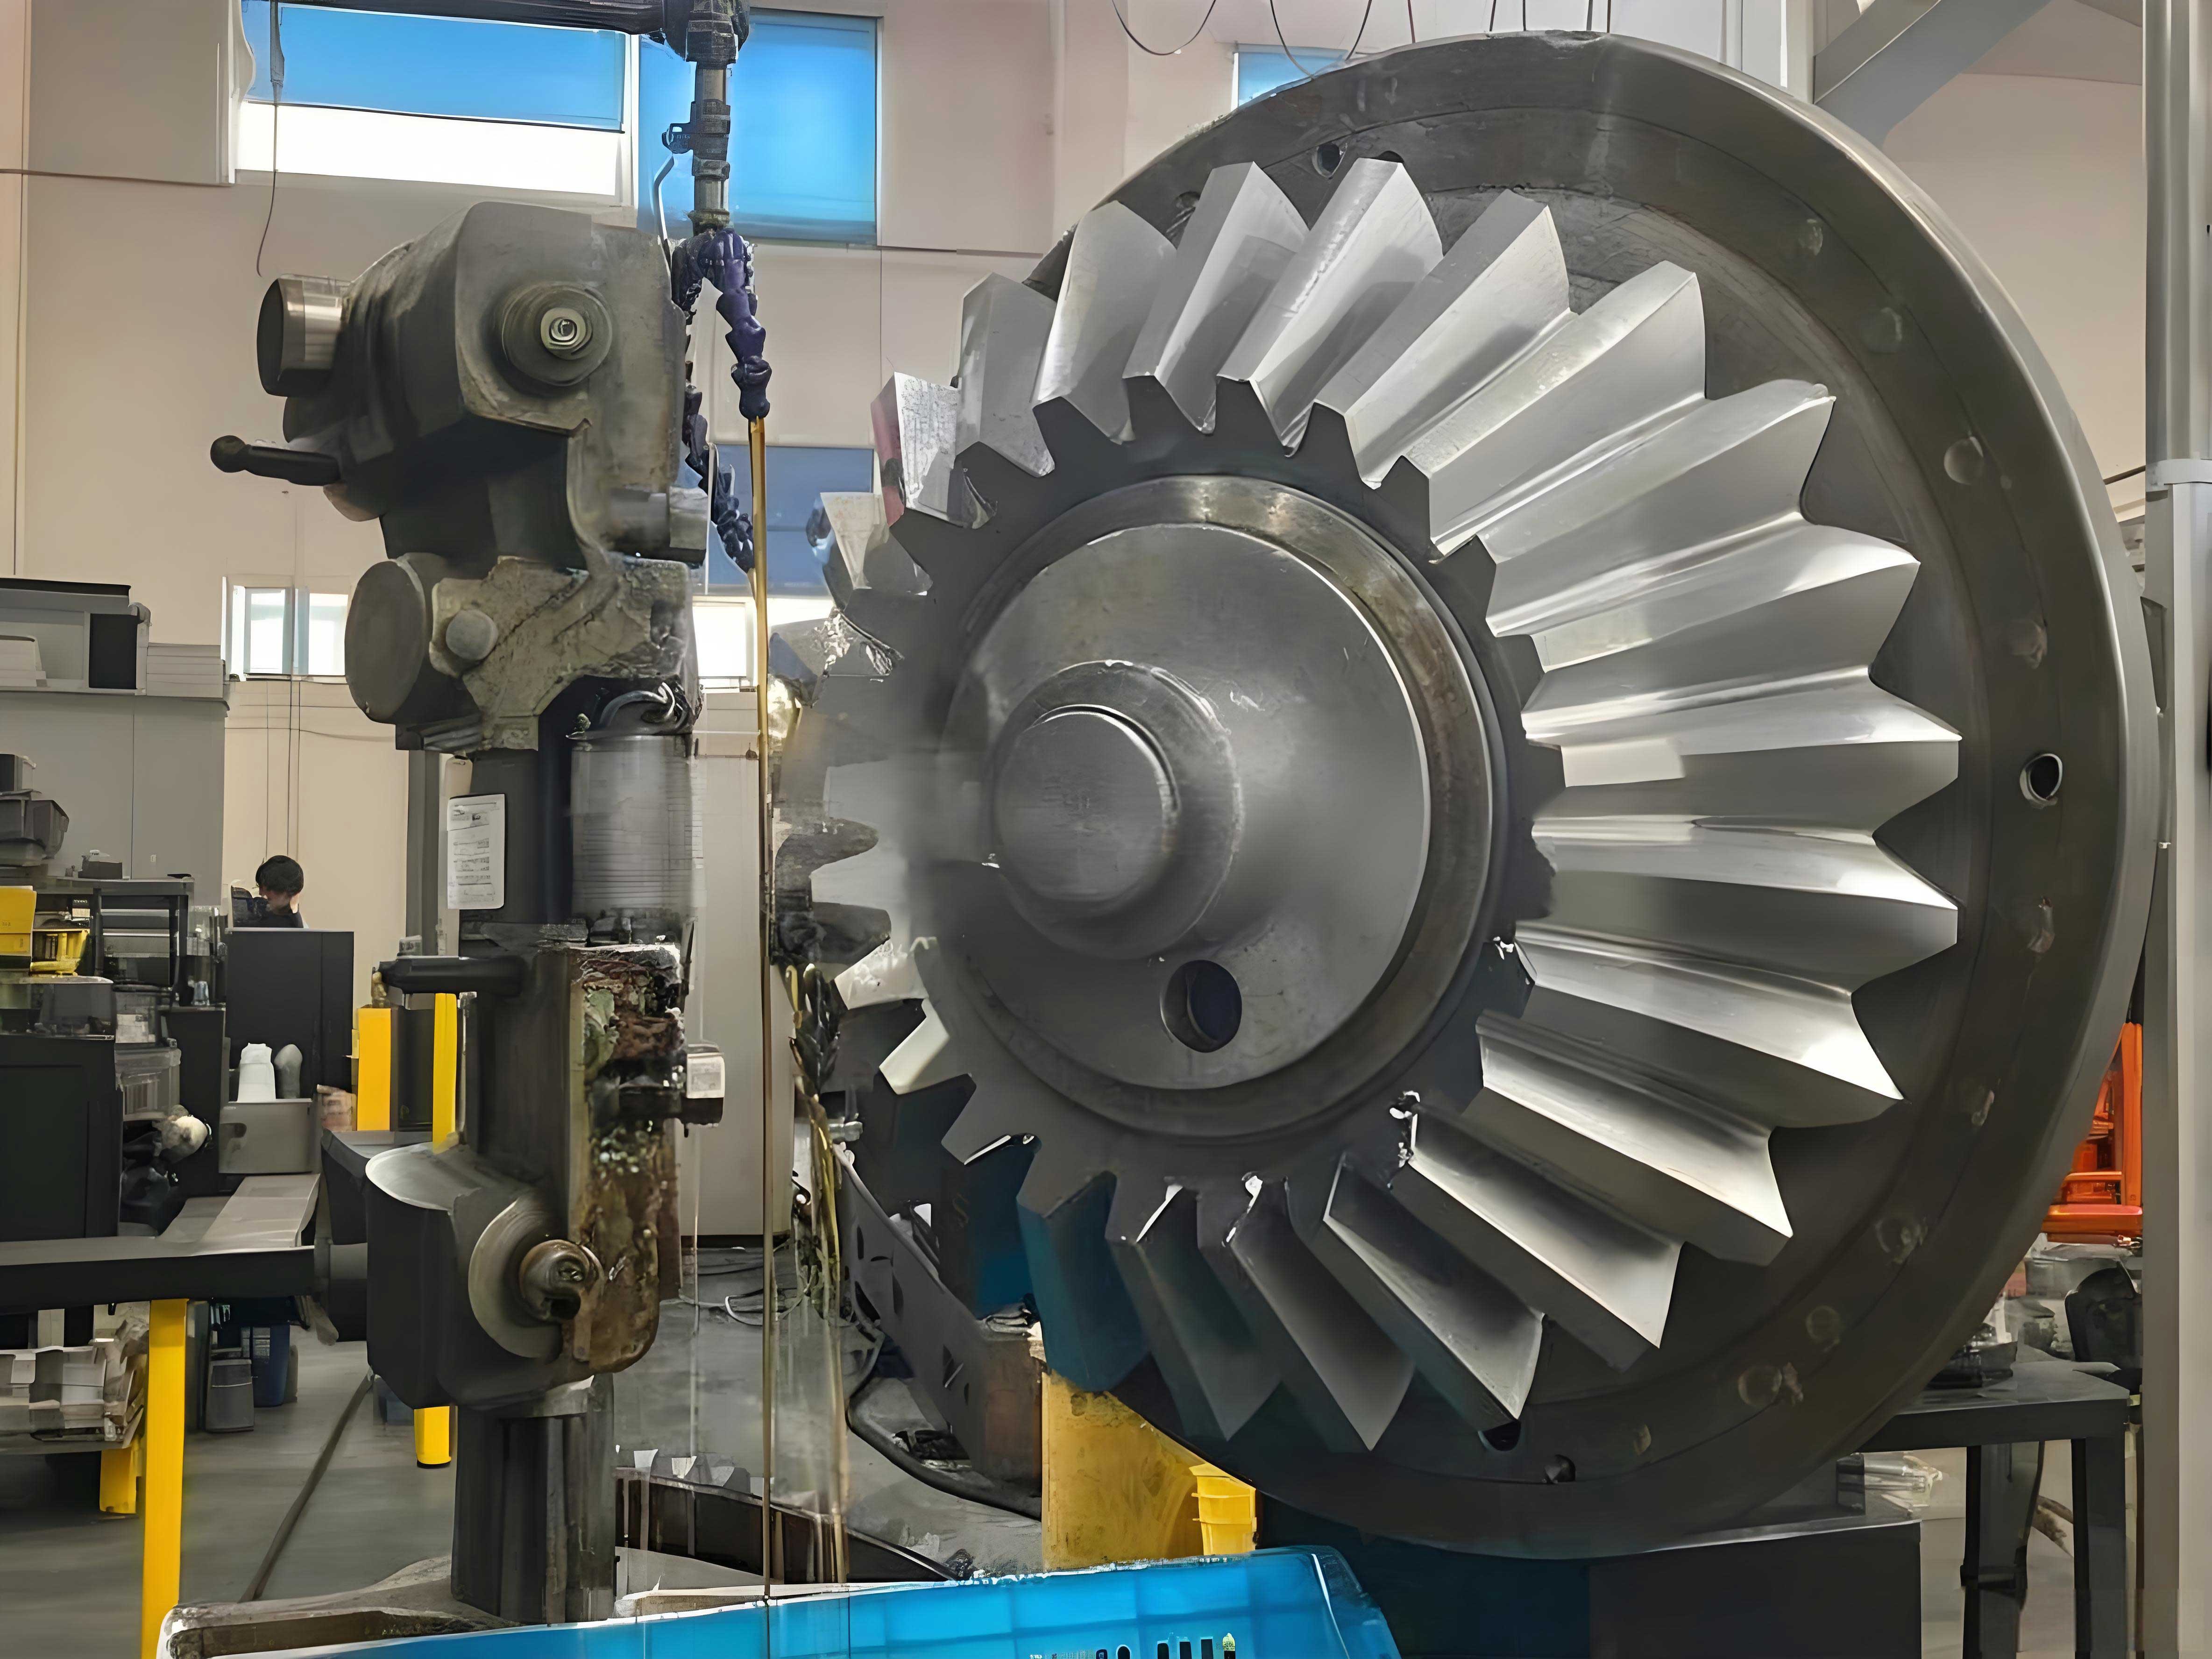
1. Research Motivation and Scope
Miter gears and herringbone gears are both sensitive to manufacturing and assembly errors, but the symmetry problem is especially severe in herringbone gears because two opposite helical sides must work together. If the two sides are not perfectly symmetric about the midplane, the axial components no longer cancel each other, and the load distribution becomes uneven. In high-speed aviation transmissions, this asymmetry can be amplified by dynamic effects. For miter gears, the same general requirement exists: the left and right sides of the tooth system must be geometrically consistent so that contact pressure and transmission error remain controlled. Although national and international standards define profile deviation, helix deviation, pitch deviation, and runout for cylindrical gears, there is still no unified evaluation standard specifically for the symmetry deviation of miter gears or herringbone gears. This lack of standardization restricts design verification and quality inspection.
My research addresses this gap by developing a complete chain from characterization to measurement to data processing to meshing analysis. The main objectives are:
1. To convert the symmetry condition into a mirror-comparison problem between corresponding tooth flanks.
2. To decompose the symmetry deviation into concrete distance and angle components.
3. To establish calculation formulas for each component.
4. To design a coordinate measuring machine measurement strategy using helix and profile feature lines.
5. To implement data extraction and processing programs.
6. To verify the method experimentally on an aviation herringbone gear.
7. To evaluate how each symmetry deviation component affects contact stress and load distribution.
8. To discuss how the method can be extended to miter gears.
2. Nomenclature and Coordinate Definition
I define the coordinate system so that the gear rotational axis is the \(Z\)-axis and the symmetry midplane is the \(XY\)-plane. For a point on the upper helical side, its mirror point about the symmetry midplane is obtained by changing the sign of the \(Z\)-coordinate. The same convention can be applied to miter gears after establishing the appropriate reference plane. The following symbols are used throughout my analysis.
| Symbol | Meaning |
|---|---|
| \(Z\) | Tooth number |
| \(m_n\) | Normal module |
| \(\alpha_n\) | Normal pressure angle |
| \(\beta\) | Helix angle |
| \(r_b\) | Base circle radius |
| \(r_p\) | Pitch circle radius |
| \(B\) | Face width or evaluation width |
| \(L_s\) | Circumferential distance deviation |
| \(L_R\) | Radial distance deviation |
| \(L_\alpha\) | Helix angular deviation expressed as length |
| \(L_\beta\) | Profile angular deviation expressed as length |
| \(F_\alpha\) | Total profile deviation |
| \(f_{H\alpha}\) | Profile slope deviation |
| \(f_{f\alpha}\) | Profile form deviation |
| \(F_\beta\) | Total helix deviation |
| \(f_{H\beta}\) | Helix slope deviation |
| \(f_{f\beta}\) | Helix form deviation |
3. Problem Transformation for Miter Gears and Herringbone Gears
For a perfectly symmetric herringbone gear, the left-hand helical part and the right-hand helical part coincide after one part is mirrored about the symmetry midplane. For miter gears, a similar mirror relation can be defined about the reference plane that separates the two corresponding tooth-flank groups. In my method, I treat one flank as the reference and the other flank as the measured object. The symmetry deviation is then the geometric difference between the measured flank and the mirrored reference flank. This transformation is powerful because it converts a global symmetry problem into a local tooth-flank comparison problem, which can be handled by gear error theory.
Let a point on the reference flank be
$$
P_1=(x_1,y_1,z_1).
$$
Its mirror point about the symmetry midplane \(z=0\) is
$$
P_1’=(x_1,y_1,-z_1).
$$
Let the corresponding point on the compared flank be
$$
P_2=(x_2,y_2,z_2).
$$
The local symmetry deviation vector is defined as
$$
\mathbf{e}=P_2-P_1′.
$$
This vector can be projected onto three physically meaningful directions:
$$
\mathbf{e}=d\,\mathbf{n}+\theta_\alpha\,\mathbf{t}_\alpha+\theta_\beta\,\mathbf{t}_\beta,
$$
where \(\mathbf{n}\) is the normal direction of the tooth surface, \(\mathbf{t}_\alpha\) is the tangent direction along the helix, and \(\mathbf{t}_\beta\) is the tangent direction along the profile. The scalar \(d\) represents a distance deviation, while \(\theta_\alpha\) and \(\theta_\beta\) represent angular deviations. In the plane perpendicular to the gear axis, the distance deviation can be further separated into circumferential and radial components. This decomposition forms the basis of my symmetry deviation characterization for both miter gears and herringbone gears.
| Deviation Type | Physical Meaning | Main Effect on Miter Gears and Herringbone Gears |
|---|---|---|
| Circumferential distance \(L_s\) | Phase shift between corresponding flanks | Unequal load sharing, axial force imbalance |
| Radial distance \(L_R\) | Offset in the radial direction | Change in effective base radius, contact position shift |
| Helix angular deviation \(L_\alpha\) | Angular tilt along the helix direction | Helix slope mismatch, edge contact |
| Profile angular deviation \(L_\beta\) | Angular tilt along the profile direction | Profile mismatch, contact stress concentration |
4. Gear Error Concepts Used in the Characterization
To describe the mirrored-flank difference properly, I use the standard concepts of profile deviation and helix deviation. These concepts are well established for cylindrical gears and can also be applied to miter gears when the inspection coordinate system is defined correctly.
The total profile deviation \(F_\alpha\) is the distance between two design profile traces that enclose the actual profile trace within the evaluation range. The profile form deviation \(f_{f\alpha}\) is the distance between two curves that are parallel to the mean profile trace and enclose the actual trace. The profile slope deviation \(f_{H\alpha}\) is the distance between two design profile traces that intersect the mean profile trace at the end points of the evaluation range.
Similarly, the total helix deviation \(F_\beta\) is the distance between two design helix traces that enclose the actual helix trace. The helix form deviation \(f_{f\beta}\) is the distance between two curves parallel to the mean helix trace, and the helix slope deviation \(f_{H\beta}\) is the distance between two design helix traces that intersect the mean helix trace at the ends of the evaluation range.
For an involute profile, the radius and the roll angle are related by
$$
r_k=\frac{r_b}{\cos\alpha_k},
$$
and the involute angle is
$$
\theta_k=\tan\alpha_k-\alpha_k.
$$
The coordinates of a point on the involute in the transverse plane can be written as
$$
\begin{cases}
x_k=r_b(\cos\phi_k+\phi_k\sin\phi_k),\\
y_k=r_b(\sin\phi_k-\phi_k\cos\phi_k),
\end{cases}
$$
where \(\phi_k\) is the involute roll angle. For a helical tooth surface, the profile is swept along the helix. If \(v\) is the helix parameter and \(\beta\) is the helix angle, a standard helical tooth surface can be expressed as
$$
\mathbf{r}(u,v)=
\begin{bmatrix}
r_b[(\cos u+u\sin u)\cos v-(\sin u-u\cos u)\sin v]\\
r_b[(\cos u+u\sin u)\sin v+(\sin u-u\cos u)\cos v]\\
r_b v\cot\beta
\end{bmatrix}.
$$
This equation is the foundation for introducing symmetry deviation into the tooth surface model. For miter gears, the same mathematical idea can be used with the appropriate cone or reference geometry.
5. Decomposition of Symmetry Deviation
I decompose the symmetry deviation into four practical components. These components are derived from the mean helix and mean profile traces of the two corresponding flanks. The method is general and can be applied to miter gears when corresponding flank traces are available.
5.1 Circumferential and Radial Distance Deviations
For the helix feature, I fit the measured points of the upper and lower flanks to obtain two mean helices. I extend these mean helices to the symmetry midplane. Ideally, the two intersection points should coincide after mirroring. In reality, they are separated. Let the two intersection points be \(A_1=(x_1,y_1,z_1)\) and \(A_2=(x_2,y_2,z_2)\). Their polar coordinates are
$$
R_1=\sqrt{x_1^2+y_1^2},\qquad
\theta_1=\operatorname{atan2}(y_1,x_1),
$$
$$
R_2=\sqrt{x_2^2+y_2^2},\qquad
\theta_2=\operatorname{atan2}(y_2,x_2).
$$
The radial distance deviation is
$$
L_R=R_1-R_2.
$$
The angular phase difference is
$$
\Delta\phi=\theta_1-\theta_2.
$$
The circumferential distance deviation is obtained by multiplying the angular phase difference by a reference radius. I use the pitch radius \(r_p\) for stable comparison:
$$
L_s=r_p\Delta\phi.
$$
If the base radius is preferred for a particular inspection, the same equation can be written with \(r_b\).
5.2 Helix Angular Deviation
The mean helix angles of the two flanks are fitted as \(\beta_1\) and \(\beta_2\). The helix angular deviation is
$$
\Delta\beta=\beta_1-\beta_2.
$$
Because this angle must be compared with distance-based gear tolerances, I convert it into a length over the evaluation width \(\Delta Z\):
$$
L_\alpha=\frac{\Delta Z}{\sin(\Delta\beta)}.
$$
In a small-angle approximation, this becomes
$$
L_\alpha\approx \frac{\Delta Z}{\Delta\beta}.
$$
This component describes the angular mismatch along the helix direction. For miter gears, an analogous helix-direction mismatch can be defined along the corresponding tooth trace.
5.3 Profile Angular Deviation
For the profile feature, I fit the measured points of the upper and lower flanks to obtain mean profile traces. I then shift the lower mean profile trace until its starting point coincides with that of the upper mean profile trace. The residual angular difference at the evaluation end point is \(\Delta\theta_k\). I convert this angle into a length using the larger of the two radii:
$$
L_\beta=\max(r_{k1},r_{k2})\,\Delta\theta_k.
$$
This component describes the angular mismatch along the profile direction. In my experiments, this component has the strongest influence on the maximum contact stress of the herringbone gear, and I expect a similar sensitivity trend for miter gears with comparable profile contact conditions.
| Component | Formula | Measured Feature |
|---|---|---|
| Radial distance deviation | \(L_R=R_1-R_2\) | Helix intersection with midplane |
| Circumferential distance deviation | \(L_s=r_p(\theta_1-\theta_2)\) | Helix intersection with midplane |
| Helix angular deviation | \(L_\alpha=\Delta Z/\sin(\beta_1-\beta_2)\) | Mean helix slope |
| Profile angular deviation | \(L_\beta=\max(r_{k1},r_{k2})(\theta_{k1}-\theta_{k2})\) | Mean profile slope |
6. Measurement Method Using a Coordinate Measuring Machine
I selected a coordinate measuring machine because it can inspect complex tooth surfaces and can also be used for general geometric verification. For miter gears, coordinate measurement is attractive because the tooth geometry may be complex and not easily inspected by a conventional gear measuring center. For herringbone gears, the coordinate measuring machine provides sufficient flexibility for extracting helix and profile feature lines.
There are three common strategies for tooth-surface point extraction: feature point measurement, feature line measurement, and full tooth-surface measurement. I compared these strategies for symmetry deviation evaluation.
| Strategy | Advantages | Limitations | Suitability for Symmetry Deviation |
|---|---|---|---|
| Feature point measurement | Fast, simple, low data volume | Highly sensitive to local errors and probe positioning | Not ideal; insufficient information |
| Feature line measurement | Balanced data volume, captures profile and helix trends | Requires careful datum and point planning | Selected in this study |
| Full tooth-surface measurement | Most complete geometric information | Time-consuming, complex processing, high data volume | Useful for advanced analysis but not necessary for routine inspection |
I use feature line measurement because it provides enough information to compute profile deviation, helix deviation, and symmetry deviation while remaining practical. The feature lines are the helix and the profile.
6.1 Helix Feature Line Extraction
For helix measurement, I select a mean helix near the pitch cylinder. The points are sampled at equal intervals along the \(Z\)-direction. If the \(Z\)-increment between two neighboring points is \(\Delta Z\), the angular increment is
$$
\Delta\theta_i=\theta_{i+1}-\theta_i.
$$
The corresponding arc length on the reference cylinder is
$$
w_i=r_b\Delta\theta_i.
$$
The theoretical arc length for a helix with angle \(\beta\) is
$$
w_{\text{theory}}=\Delta Z\tan\beta.
$$
The helix deviation in the normal direction is approximately
$$
f_i=(w_{\text{theory}}-w_i)\cos\beta.
$$
By evaluating \(f_i\) over the full evaluation length, I obtain \(F_\beta\), \(f_{H\beta}\), and \(f_{f\beta}\). The same measured points are also used to fit the mean helix for symmetry deviation calculation.
6.2 Profile Feature Line Extraction
For profile measurement, I select a transverse section near the middle of the face width. I sample points along the involute within the evaluation range. Three equal-distance sampling schemes can be used:
1. Equal angular increment about the gear center.
2. Equal radial increment.
3. Equal involute length increment.
I use the equal angular increment scheme because it is simple to program on a coordinate measuring machine and is stable for data processing. The measured profile points are fitted to a mean profile trace. The distance from each measured point to the mean profile trace is calculated. The envelope of these distances provides the profile deviation values. The mean profile trace is then used for the profile angular deviation \(L_\beta\).
7. Datum and Symmetry Midplane Establishment
For symmetry deviation measurement, the symmetry midplane is the most important reference. In a real gear, this plane is not a physical surface. I therefore establish it from manufacturing or inspection datums. For a shaft-integrated herringbone gear, I use the cylindrical bearing surfaces to define the \(Z\)-axis and the shoulder surfaces to define the axial datum. If the gear has two symmetric shoulders, I measure both shoulder planes and set the symmetry midplane at their midpoint. If the gear has a central groove, I measure the two groove side faces and use their midpoint. For miter gears, the reference plane should be chosen according to the design and assembly datum.
The coordinate system is established as follows:
1. Measure a cylindrical datum surface and fit its axis to the \(Z\)-axis.
2. Measure a shoulder plane or a set of symmetric planes to define the axial origin.
3. Set the \(XY\)-plane at the symmetry midplane.
4. Measure the helix and profile feature lines on both corresponding flanks.
5. Transform all measured points into this coordinate system.
This procedure ensures that the symmetry evaluation is referenced to the same axis and midplane for all measured points.
8. Data Processing Program
I designed a data-processing program that reads the coordinate data, fits the mean helix and mean profile, computes gear deviations, and calculates the four symmetry deviation components. The program can be implemented in a numerical computing environment. The main steps are:
1. Import the measured point coordinates.
2. Convert Cartesian coordinates into polar coordinates.
3. Fit the helix points using the helix parametric equation.
4. Fit the profile points using the involute equation.
5. Mirror one flank about the symmetry midplane.
6. Compute the intersection points of the mean helices with the midplane.
7. Calculate \(L_R\), \(L_s\), \(L_\alpha\), and \(L_\beta\).
8. Calculate \(F_\alpha\), \(f_{H\alpha}\), \(f_{f\alpha}\), \(F_\beta\), \(f_{H\beta}\), and \(f_{f\beta}\) for comparison with the gear measurement module.
The helix fitting equation is
$$
\begin{cases}
x=r_p\cos\theta,\\
y=r_p\sin\theta,\\
z=b\theta,
\end{cases}
$$
where \(b\) is related to the helix angle by
$$
b=\frac{r_p}{\tan\beta}.
$$
The profile fitting equation is based on the involute equation. After fitting, I calculate the differences between the measured points and the fitted curves. The mean curve is used as the reference for angular deviation calculation. This processing method is also applicable to miter gears when the corresponding flank curves are known.
9. Experimental Setup
I performed measurements on an aviation herringbone gear. The gear is integrated with a shaft, and the two sides have opposite helix directions. The basic parameters are listed in Table 5. The coordinate measuring machine parameters are listed in Table 6. The probe is a ruby sphere with a small diameter, which is suitable for the narrow tooth space.
| Parameter | Value |
|---|---|
| Number of teeth \(Z\) | 27 |
| Normal module \(m_n\) | 3.8788 mm |
| Normal pressure angle \(\alpha_n\) | 22.5° |
| Helix angle \(\beta\) | 30° |
| Tip diameter \(d_a\) | 130.62 mm |
| Root diameter \(d_f\) | 108.51 mm |
| Face width \(b\) | 47 mm |
| Technical Parameter | Value |
|---|---|
| X-axis travel | 800 mm |
| Y-axis travel | 1000 mm |
| Z-axis travel | 600 mm |
| Maximum load | 500 kg |
| Measurement accuracy | 3.0 + L/300 µm |
| Encoder resolution | 0.078 µm |
| Temperature | 20 ± 2 °C |
| Humidity | 45%–75% |
Before measurement, I calibrated the coordinate measuring machine using gauge blocks in seven directions. The calibration results showed that the maximum errors were within the allowable limits. This step is essential for miter gears and herringbone gears because small positioning errors can be confused with symmetry deviation.
| Calibration Direction | Nominal Length | Maximum Error | Allowable Error | Result |
|---|---|---|---|---|
| X-axis | 400 mm | 2.18 µm | 3.62 µm | Pass |
| Y-axis | 400 mm | 1.48 µm | 3.62 µm | Pass |
| Z-axis | 400 mm | 0.78 µm | 3.62 µm | Pass |
| Space diagonal 1 | 400 mm | 0.48 µm | 3.62 µm | Pass |
| Space diagonal 2 | 400 mm | 1.22 µm | 3.62 µm | Pass |
| Space diagonal 3 | 400 mm | 2.08 µm | 3.62 µm | Pass |
10. Experimental Results
I measured three groups of tooth flanks. Each group included the left-hand and right-hand helical sides. The helix and profile data were imported into the data-processing program. The mean helix and mean profile were fitted, and the symmetry deviation components were calculated.
| Group | \(L_s\) (µm) | \(L_R\) (µm) | \(L_\alpha\) (µm) | \(L_\beta\) (µm) |
|---|---|---|---|---|
| 1 | 15.3 | 10.2 | 5.3 | 6.3 |
| 2 | 13.6 | 8.5 | 6.5 | 5.9 |
| 3 | 17.8 | 11.7 | 7.2 | 8.4 |
The measured circumferential distance is below 20 µm for all groups, which satisfies the design requirement used for this gear. The radial distance and angular deviations also varied from group to group. This confirms that a single scalar value cannot describe the full symmetry state of miter gears or herringbone gears. A multi-component representation is necessary.
I also calculated the helix deviation from the same measured points and compared it with the result obtained from the gear measurement module. The values were close, which verifies the correctness of my data extraction and processing procedure.
| Error Item | My Coordinate Measuring Method | Gear Measurement Module |
|---|---|---|
| Total helix deviation \(F_\beta\) | 23.2 µm | 20.1 µm |
| Helix slope deviation \(f_{H\beta}\) | 2.9 µm | 2.5 µm |
| Helix form deviation \(f_{f\beta}\) | 21.9 µm | 21.2 µm |
The differences are small compared with the tolerance level, and the main trend is consistent. This gives confidence that my method can be used for symmetry deviation evaluation. For miter gears, a similar validation can be performed by comparing coordinate measuring machine results with a dedicated gear inspection module.
11. Error Sources and Compensation
Three main error sources affect the measurement: probe radius error, machine geometric error, and datum establishment error. I analyzed each source.
The probe radius error occurs because the measured point is the center of the probe sphere, not the contact point on the tooth surface. If the probe radius is \(R_c\), the contact point can be compensated using the local normal direction. A simplified compensation in the transverse plane is
$$
\begin{cases}
x_0=x_1+R_c\cos(\alpha_a+\theta_a),\\
y_0=y_1+R_c\sin(\alpha_a+\theta_a),
\end{cases}
$$
where \(\alpha_a\) is the pressure angle at the contact point and \(\theta_a\) is the involute roll angle. After compensation, the profile deviation changed only slightly. This indicates that probe radius compensation does not change the essential shape of the profile trace and has limited influence on symmetry deviation components.
Machine geometric errors include guideway straightness, squareness, scale error, and dynamic positioning error. These errors appear as systematic deviations in the measured coordinates. I compensated the positioning error by using the theoretical tooth surface equation. Because the measured point must lie on the actual tooth surface, I projected the measured point onto the theoretical surface along the normal direction. This reduced the average distance from the measured points to the theoretical points.
| Condition | Average Distance to Theoretical Point | Amplitude of Scatter |
|---|---|---|
| Before compensation | 2.84 µm | 2.59 µm |
| After compensation | 1.83 µm | 0.95 µm |
After compensation, the circumferential and radial distance deviations decreased by about 1–2 µm, while the angular deviations changed little. This suggests that machine positioning error mainly affects the absolute position of the fitted curves, whereas the angular components are more stable.
| Group | \(L_s\) Before (µm) | \(L_s\) After (µm) | \(L_R\) Before (µm) | \(L_R\) After (µm) | \(L_\alpha\) Before (µm) | \(L_\alpha\) After (µm) | \(L_\beta\) Before (µm) | \(L_\beta\) After (µm) |
|---|---|---|---|---|---|---|---|---|
| 1 | 15.3 | 11.5 | 10.2 | 8.3 | 5.3 | 5.1 | 6.3 | 5.8 |
| 2 | 13.6 | 10.7 | 8.5 | 8.0 | 6.5 | 6.3 | 5.9 | 5.6 |
| 3 | 17.8 | 15.3 | 11.7 | 9.4 | 7.2 | 6.9 | 8.4 | 8.1 |
12. Influence of Symmetry Deviation on Meshing Behavior
To study how symmetry deviation affects meshing, I introduced the four components into the tooth surface equation. I then built finite element models with different deviation values. This analysis is important for miter gears and herringbone gears because both rely on balanced contact across corresponding flanks.
The base radius with radial deviation is
$$
r_b^*=r_b+L_R.
$$
The helix angle with helix angular deviation is
$$
\beta^*=\arctan\left(\frac{B\tan\beta+L_\alpha}{B}\right).
$$
The profile starting angle with profile angular deviation is
$$
\alpha^*=\alpha+\frac{L_\beta}{L},
$$
where \(L\) is the evaluation length. The circumferential deviation is introduced as a rotation about the gear axis:
$$
R_z(\gamma_s)=
\begin{bmatrix}
\cos\gamma_s & -\sin\gamma_s & 0\\
\sin\gamma_s & \cos\gamma_s & 0\\
0 & 0 & 1
\end{bmatrix},
$$
$$
\gamma_s=\frac{L_s}{r_p}.
$$
Using these relations, the tooth surface with symmetry deviation can be written as
$$
\mathbf{r}^*(u,v)=R_z(\gamma_s)
\begin{bmatrix}
r_b^*[(\cos u+u\sin u)\cos v-(\sin u-u\cos u)\sin v]\\
r_b^*[(\cos u+u\sin u)\sin v+(\sin u-u\cos u)\cos v]\\
r_b^* v\cot\beta^*
\end{bmatrix}.
$$
I used the measured deviations as the baseline and then increased each component by 50% to compare its influence. The values used in the finite element models are listed in Table 11.
| Case | \(L_s\) (µm) | \(L_R\) (µm) | \(L_\alpha\) (µm) | \(L_\beta\) (µm) |
|---|---|---|---|---|
| Measured value | 17.8 | 11.7 | 7.2 | 8.4 |
| Increased by 50% | 26.7 | 17.6 | 10.8 | 12.6 |
The finite element model used a pair of gears with 44 and 41 teeth. The normal module was 3.5 mm, the normal pressure angle was 22.5°, the helix angle was 30°, the groove width was 20 mm, and the face width was 30 mm. The material properties are listed in Table 12. The mesh contained approximately 300,000 elements, with local refinement near the contact region.
| Material | Elastic Modulus | Poisson Ratio | Density |
|---|---|---|---|
| 45 steel | 210 GPa | 0.3 | 7.8 × 10³ kg/m³ |
A standard model without symmetry deviation showed symmetric load distribution about the midplane. The maximum contact stress was about 16621 N/m². When symmetry deviation was introduced, the load shifted toward one side. The stress peaks for different cases are summarized in Table 13.
| Deviation Case | Value | Maximum Stress on Heavily Loaded Side (N/m²) | Increase Relative to Standard |
|---|---|---|---|
| Standard | 0 | 16621 | — |
| Circumferential distance \(L_s\) | 17.8 µm | 16883 | 1.58% |
| Circumferential distance \(L_s\) | 26.7 µm | 17284 | 3.99% |
| Radial distance \(L_R\) | 11.7 µm | 17564 | 5.67% |
| Radial distance \(L_R\) | 17.6 µm | 17972 | 8.12% |
| Profile angular deviation \(L_\beta\) | 8.4 µm | 18986 | 14.2% |
| Profile angular deviation \(L_\beta\) | 12.6 µm | 20697 | 24.5% |
| Helix angular deviation \(L_\alpha\) | 7.2 µm | 17640 | 6.13% |
| Helix angular deviation \(L_\alpha\) | 10.8 µm | 17808 | 7.14% |
The results show that all four components increase the maximum contact stress and cause load concentration on one side. Among them, the profile angular deviation \(L_\beta\) has the strongest influence for the tested herringbone gear. The radial distance deviation also has a noticeable effect. The circumferential distance and helix angular deviations have smaller but still non-negligible effects. For miter gears, the ranking may depend on the specific tooth geometry, but the general principle remains: angular profile mismatch and radial offset are critical for load concentration.
| Rank | Component | Influence on Maximum Stress |
|---|---|---|
| 1 | Profile angular deviation \(L_\beta\) | Strongest |
| 2 | Radial distance deviation \(L_R\) | Strong |
| 3 | Helix angular deviation \(L_\alpha\) | Moderate |
| 4 | Circumferential distance deviation \(L_s\) | Moderate to weak |
13. Discussion
My results show that symmetry deviation in miter gears and herringbone gears should not be represented by a single scalar quantity. A single value may indicate that a phase shift exists, but it cannot explain whether the load concentration is caused by a radial offset, a helix tilt, or a profile tilt. The four-component representation gives a clearer physical picture and supports targeted manufacturing control.
For miter gears, the same measurement logic can be applied after the reference plane and corresponding flank traces are defined. The coordinate measuring machine method is flexible enough to handle complex tooth forms. The feature line strategy is a practical compromise between measurement time and information content. The data-processing program can be adapted by replacing the helix and profile equations with the corresponding miter gear tooth equations.
The experiment also shows that datum selection is critical. If the symmetry midplane is incorrectly established, all four deviation components will be biased. Therefore, I recommend measuring the cylindrical datum and the axial datum carefully before tooth-flank inspection. For miter gears, the assembly datum and the mounting surfaces should be measured first.
The finite element analysis indicates that the profile angular deviation is the most influential component in the tested case. This means that during manufacturing and quality control of miter gears and herringbone gears, the profile slope and profile form should be controlled tightly. Radial distance deviation should also be monitored because it changes the effective base radius and shifts the contact pattern. Circumferential distance deviation is important for axial force balance, but its effect on maximum contact stress is smaller than that of the profile angular deviation in this study.
14. Conclusions
I developed a complete method for characterizing, measuring, and analyzing the symmetry deviation of miter gears and herringbone gears. The main conclusions are as follows.
1. The symmetry condition of miter gears and herringbone gears can be transformed into a mirror comparison between two corresponding tooth flanks. This transformation converts a global symmetry problem into a measurable tooth-flank deviation problem.
2. The symmetry deviation can be decomposed into four components: circumferential distance deviation \(L_s\), radial distance deviation \(L_R\), helix angular deviation \(L_\alpha\), and profile angular deviation \(L_\beta\). These components describe both distance and angle mismatches.
3. I established calculation formulas for all four components using mean helix and mean profile traces. The formulas are suitable for coordinate measuring machine data and can be extended to miter gears.
4. I designed a feature-line measurement strategy using helix and profile lines. This strategy provides sufficient information for symmetry evaluation without the long measurement time required by full tooth-surface scanning.
5. I developed data extraction and processing procedures that can calculate profile deviation, helix deviation, and the four symmetry deviation components from measured points.
6. I performed experiments on an aviation herringbone gear. The measured circumferential distance was below the design limit, and the helix deviation calculated from my data was close to the result from a gear measurement module. This verifies the feasibility of my method.
7. I analyzed probe radius error, machine geometric error, and datum error. Probe radius compensation had little effect on the symmetry deviation components. Machine positioning error compensation reduced the average point-to-surface distance and improved data stability.
8. I introduced the four symmetry deviation components into the tooth surface equation and performed finite element contact analysis. All four components caused uneven load distribution and increased the maximum contact stress. The profile angular deviation had the strongest influence in the tested case, followed by the radial distance deviation.
9. The proposed method provides a foundation for standardizing symmetry deviation evaluation for miter gears and herringbone gears. It can support high-precision design, manufacturing compensation, and dynamic performance analysis.
15. Future Work
Future work can proceed in several directions. First, I plan to simplify the measurement procedure so that symmetry deviation can be estimated from a small number of feature points. This would make routine inspection of miter gears and herringbone gears faster. Second, I intend to extend the method to full tooth-surface scanning and integrate it with overall gear error evaluation. Third, I will study the dynamic behavior of miter gears and herringbone gears with symmetry deviation, including axial vibration, transmission error, and mesh stiffness variation. Fourth, I will investigate how each symmetry deviation component affects contact fatigue life and noise radiation. Finally, I will work toward a unified evaluation specification that can be used for both miter gears and herringbone gears in high-speed and heavy-duty applications.
In summary, my study shows that symmetry deviation in miter gears and herringbone gears is a multi-dimensional geometric error. By decomposing it into four measurable components, by using coordinate measuring machine feature-line inspection, and by linking the components to finite element contact results, I provide a practical and extensible framework for design, manufacturing, and quality control. The method is especially valuable for miter gears and herringbone gears in aviation, marine, and other high-speed heavy-load transmission systems, where even a small asymmetry can cause a large change in load distribution and service life.