
In the realm of industrial robotics, the precision and performance of joint actuators are paramount. Among these, the RV reducer stands out as a critical component, directly influencing the operational stability, positioning accuracy, and longevity of robotic arms. Its complex two-stage transmission system, combining a planetary gear train with a cycloidal pin gear mechanism, presents significant challenges for dynamic analysis. This work details my comprehensive approach to constructing and validating a high-fidelity multi-body dynamics model of an RV reducer, leveraging CAD software and Adams, with a particular focus on the accurate derivation and application of key dynamic parameters such as meshing stiffness and damping.
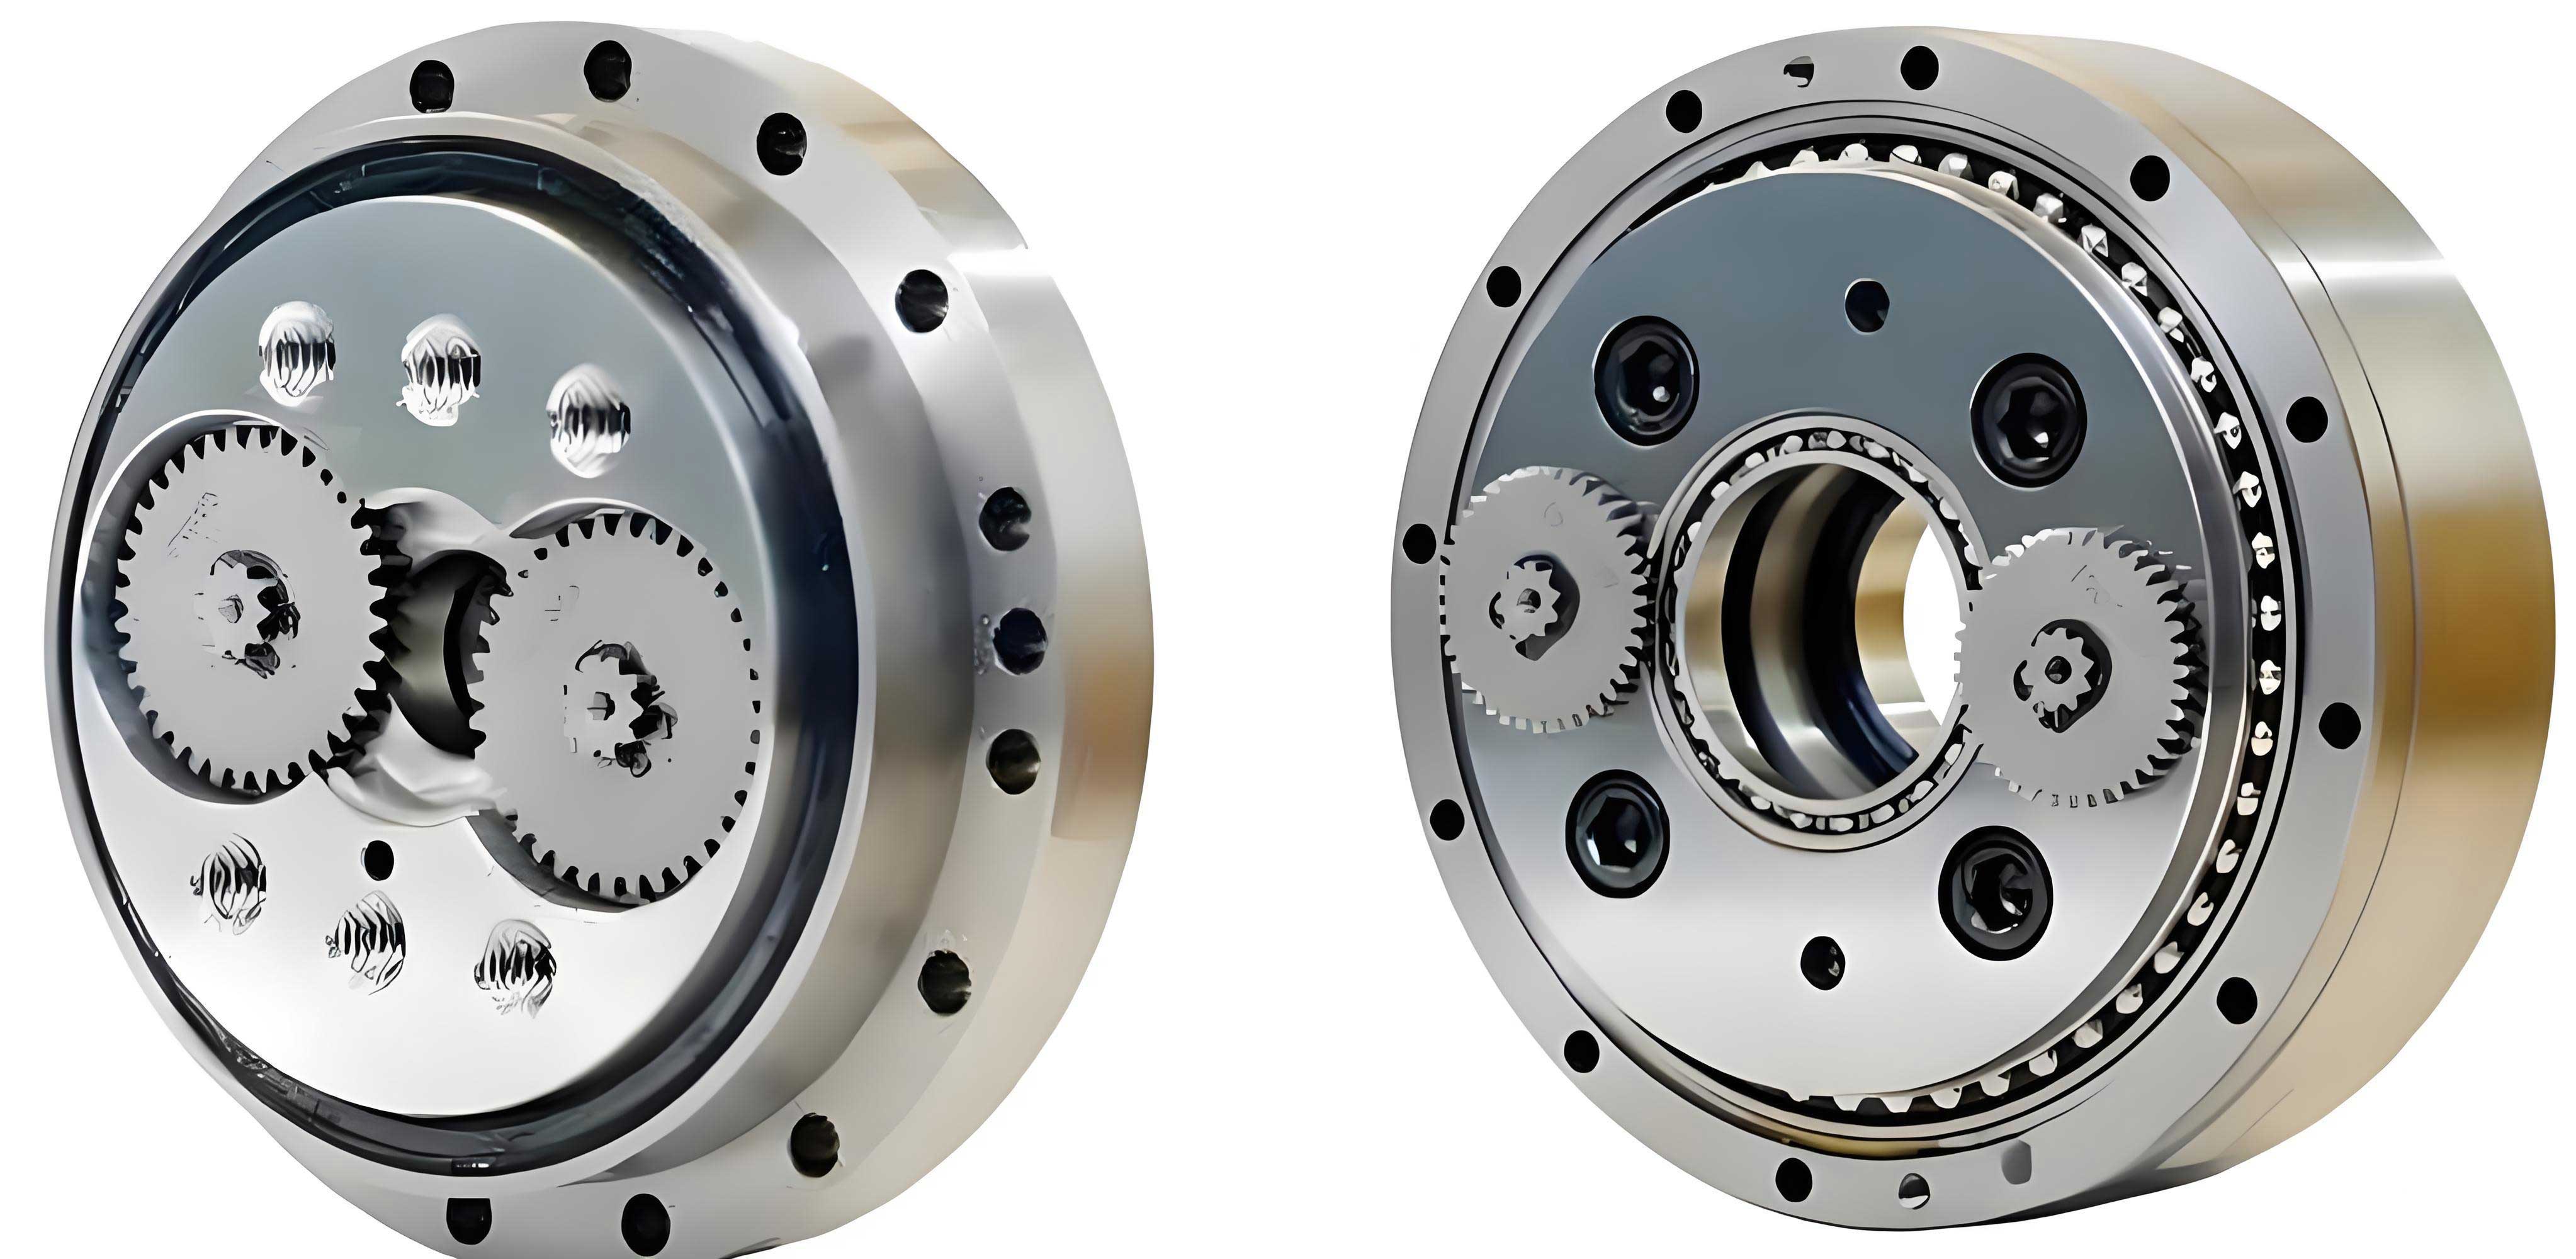
The foundation of any accurate dynamics simulation lies in the precise acquisition of modeling parameters. My process began with a detailed physical measurement and metallographic analysis of a disassembled RV reducer. This hands-on investigation provided the essential structural dimensions and material properties required for geometric modeling. The core structural parameters of the RV reducer are summarized in the table below.
| Parameter | Symbol | Value | Unit |
|---|---|---|---|
| Pin Center Circle Radius | $r_z$ | 64 | mm |
| Pin Radius | $r_{rp}$ | 3 | mm |
| Eccentricity | $e$ | 1.3 | mm |
| Number of Pin Teeth | $z_p$ | 40 | – |
| Number of Cycloidal Teeth | $z_c$ | 39 | – |
| Sun Gear Teeth | $z_1$ | 10 | – |
| Planet Gear Teeth | $z_2$ | 26 | – |
| Module | $m$ | 2 | mm |
| Pressure Angle | $\alpha$ | 20 | deg |
| Transmission Ratio | $i$ | 105 | – |
The material properties for each major component, determined through analysis, are crucial for calculating mass and inertia properties. These are listed in the following table.
| Component | Material | Young’s Modulus, $E$ (GPa) | Poisson’s Ratio, $\nu$ | Density, $\rho$ (kg/m³) |
|---|---|---|---|---|
| Crankshaft, Gears | 20CrMnMo | 207 | 0.254 | 7870 |
| Housing | QT500-7 | 168 | 0.240 | 7250 |
| Output Shaft, Flange | ZG65Mn | 198 | 0.230 | 7850 |
| Needle Pins | GCr15 | 208 | 0.300 | 7800 |
Using these material properties and the precise geometry, I calculated the mass and moment of inertia tensors for each part within the CAD software, which were then exported for use in the dynamics model. The most critical and challenging parameters to define for a realistic RV reducer simulation are the meshing stiffness and damping coefficients for both the involute spur gear stage and the cycloidal drive stage. These parameters govern the force-deflection relationship and energy dissipation at the gear contacts, fundamentally affecting vibration and dynamic transmission error.
For the first-stage spur gear pair (sun-planet), I adopted the ISO 6336 methodology to calculate the mesh stiffness. The single tooth stiffness $c’$ is derived from the unit load deflection $q$:
$$ c’ = \frac{1}{q} $$
Where $q$ is computed based on the number of teeth and profile shift coefficients. The effective mesh stiffness $c_r$, accounting for the contact ratio $\varepsilon_{\alpha}$, is:
$$ c_r = (0.75 \varepsilon_{\alpha} + 0.25) c’ $$
$$ \varepsilon_{\alpha} = \frac{1}{2\pi} \left[ z_1 (\tan \alpha_{a1} – \tan \alpha) + z_2 (\tan \alpha_{a2} – \tan \alpha) \right] $$
Finally, the total meshing stiffness $k_{12}$ for the gear pair with face width $b$ is:
$$ k_{12} = c_r \cdot b \times 10^6 $$
The corresponding meshing damping coefficient $c_{12}$ for the spur gears is calculated using a simplified formula based on the stiffness and inertia properties:
$$ c_{12} = 2 \xi_{12} \sqrt{ k_{12} \frac{r_1^2 r_2^2 J_1 J_2}{r_1^2 J_1 + r_2^2 J_2} } $$
where $\xi_{12}$ is the damping ratio (taken as 0.05), and $J_1$, $J_2$ are the mass moments of inertia of the sun and planet gears, respectively.
For the second-stage cycloidal-pin mesh, the calculation is more complex due to the multi-tooth contact nature. The stiffness of a single contact between the cycloidal disk and the $i$-th pin, $k_{ni}$, depends on the instantaneous curvature radii $\rho_r$ and $\rho_c$:
$$ k_{ni} = \frac{\pi b E \rho_{r} \rho_{c}}{4(1-\mu^2)(\rho_{r}+\rho_{c})\rho_i} $$
The variable radius of curvature $\rho_r$ for the cycloid profile is a function of the gear geometry and the instantaneous rotation angle $\phi_i$. The effective total torsional mesh stiffness $k_{36}$ reflected to the crankshaft axis is obtained by summing the contribution of all simultaneously engaged tooth pairs, considering their lever arm $l_i$:
$$ k_{36} = \sum_{i=n}^{m} k_{ni} l_i^2 $$
$$ l_i = r’_c \frac{\sin \phi_i}{\sqrt{1 + k^2 – 2k \cos \phi_i}} $$
Here, $k$ is the shortening coefficient, and $r’_c$ is the cycloid generating circle radius. Similarly, the meshing damping for the cycloidal stage $c_{36}$ is aggregated from individual contact damping $c_{ni}$:
$$ c_{ni} = 2 \xi_{36} \sqrt{ k_{ni} \frac{{r’_c}^2 r_{rp}^2 J_3 J_{rp}}{{r’_c}^2 J_3 + r_{rp}^2 J_{rp}} } $$
$$ c_{36} = \sum_{i=n}^{m} c_{ni} $$
All calculated dynamic parameters for the RV reducer model are consolidated below.
| Parameter Description | Symbol | Calculated Value | Unit |
|---|---|---|---|
| Spur Gear Mesh Stiffness | $k_{12}$ | $1.648 \times 10^8$ | N/m |
| Spur Gear Mesh Damping | $c_{12}$ | $2.14 \times 10^{-2}$ | N·s/m |
| Cycloidal-Pin Mesh Stiffness | $k_{36}$ | $1.511 \times 10^7$ | N·m/rad |
| Cycloidal-Pin Mesh Damping | $c_{36}$ | $4.899 \times 10^{-4}$ | N·s·m/rad |
With parameters defined, I constructed a detailed 3D geometric model using CAD software. A crucial pre-simulation step was performing a comprehensive interference check on the full RV reducer assembly to ensure all mating relationships were correct, eliminating potential rigid-body conflicts before dynamics analysis. The verified model was then translated into a format compatible with Adams. To balance model fidelity with computational efficiency and solver stability, I implemented several judicious simplifications in the Adams model: the sun gear was integrated with the input shaft, each crankshaft was integrated with its planet gear, and the output planet carrier was modeled with its support pins as a single rigid body. Bearings and bushings were simplified as ideal revolute or fixed joints.
In Adams, I defined the model by assigning the calculated mass properties, creating appropriate kinematic joints (fixed, revolute), and applying force elements. The spur gear meshes were modeled using Adams’ built-in geared coupler constraints, which enforce the correct kinematic relationship. The contacts between the two cycloidal disks and the 40 needle pins were modeled using impact force functions. These functions utilized the derived nonlinear stiffness $k_{36}$ and damping $c_{36}$ parameters, along with a reasonable contact stiffness based on material properties, to simulate the elastodynamic forces. A step-function-driven rotational motion was applied to the input shaft, and a constant load torque of 30 N·m was applied to the output carrier to simulate operational conditions. The simulation was run using the GSTIFF SI2 integrator for robustness.
The simulation results were analyzed to validate the RV reducer model. The kinematic output confirmed the correct transmission ratio. With an input speed of 3000 deg/s (~523.6 rpm), the output carrier speed stabilized at approximately 28 deg/s (~5 rpm), yielding the designed ratio of 105:1. The angular accelerations of the intermediate and output components showed expected transient behavior during startup, followed by low-amplitude oscillations due to meshing dynamics, confirming a stable transmission without unrealistic shocks.
The force analysis revealed characteristic behaviors of the RV reducer. The forces on the needle pins from the two cycloidal disks were phase-shifted, corresponding to their opposite motion phases. The resultant force from the two crankshafts acting on a single cycloidal disk directly represented the total meshing force between that disk and the pin ring. Analysis confirmed that at any given instant, precisely half of the needle pins (20 out of 40) were in load-bearing contact with each cycloidal disk, a key feature ensuring high torsional stiffness and smooth torque transmission in the RV reducer. The motion trajectories of the crankshaft and cycloidal disk centers showed the expected compound motion: a primary rotation (revolution) superimposed with a small eccentric oscillation (self-rotation defined by the eccentricity $e$).
A critical performance metric for a precision RV reducer is its transmission error. I calculated this by comparing the simulated output carrier angle with the theoretical output angle (input angle divided by 105). The results demonstrated a high level of modeling accuracy. The transmission error exhibited a periodic pattern with an amplitude of less than 0.8 arcminutes. This error stems from the discrete modeling of gear contacts, numerical integration tolerances, and the simplified representation of compliance and damping. Nevertheless, this magnitude of error validates that the model’s dynamic parameters—especially the meshing stiffness and damping values—are physically reasonable and that the overall modeling approach is sound. This accurate model establishes a solid foundation for further in-depth dynamic characteristic studies of the RV reducer, such as parametric studies on damping, nonlinear vibration analysis, or investigations into the effects of manufacturing tolerances.
In conclusion, this work successfully demonstrates a systematic methodology for building and validating a dynamic simulation model of a complex RV reducer. The process underscored the paramount importance of accurately determining key dynamic parameters like meshing stiffness and damping through theoretical or empirical means. The simplified yet physically accurate Adams model correctly replicated the kinematics, force distribution, and high transmission precision characteristic of the RV reducer. The model’s output, showing minimal transmission error and stable dynamic behavior, confirms the validity of the applied parameters and the modeling strategy. This reliable virtual prototype of the RV reducer now serves as a powerful tool for conducting virtual experiments, optimizing design parameters, and predicting dynamic performance, thereby contributing to the advancement of high-precision reduction technology for robotic applications.