
In my experience working with drivetrain systems, I have observed a significant shift in the automotive industry toward adopting hyperboloid gears, also known as hypoid gears, in single-reduction axles for medium and heavy-duty trucks. Historically, hyperboloid gears were predominantly used in passenger cars and light vehicles due to their superior performance characteristics. However, with advancements in manufacturing processes and the increased availability of specialized lubricants like hyperboloid gear oil, these gears are now extensively implemented in commercial vehicle drive axles. Despite their advantages, hyperboloid gears are prone to specific failure modes under demanding operating conditions. This article delves into a comprehensive analysis of hyperboloid gear damage, drawing from practical insights and engineering principles to elucidate the underlying causes and mitigation strategies.
The unique geometry of hyperboloid gears involves an offset between the pinion and ring gear axes, which allows for larger pinion diameters and improved strength compared to conventional spiral bevel gears. This design enhances torque capacity and reduces drivetrain noise, but it also introduces higher sliding velocities and complex contact patterns. Consequently, hyperboloid gears demand meticulous attention to lubrication, material properties, and operational parameters. Through this analysis, I aim to highlight the critical factors contributing to hyperboloid gear failures and provide actionable recommendations for enhancing durability in heavy-duty applications.
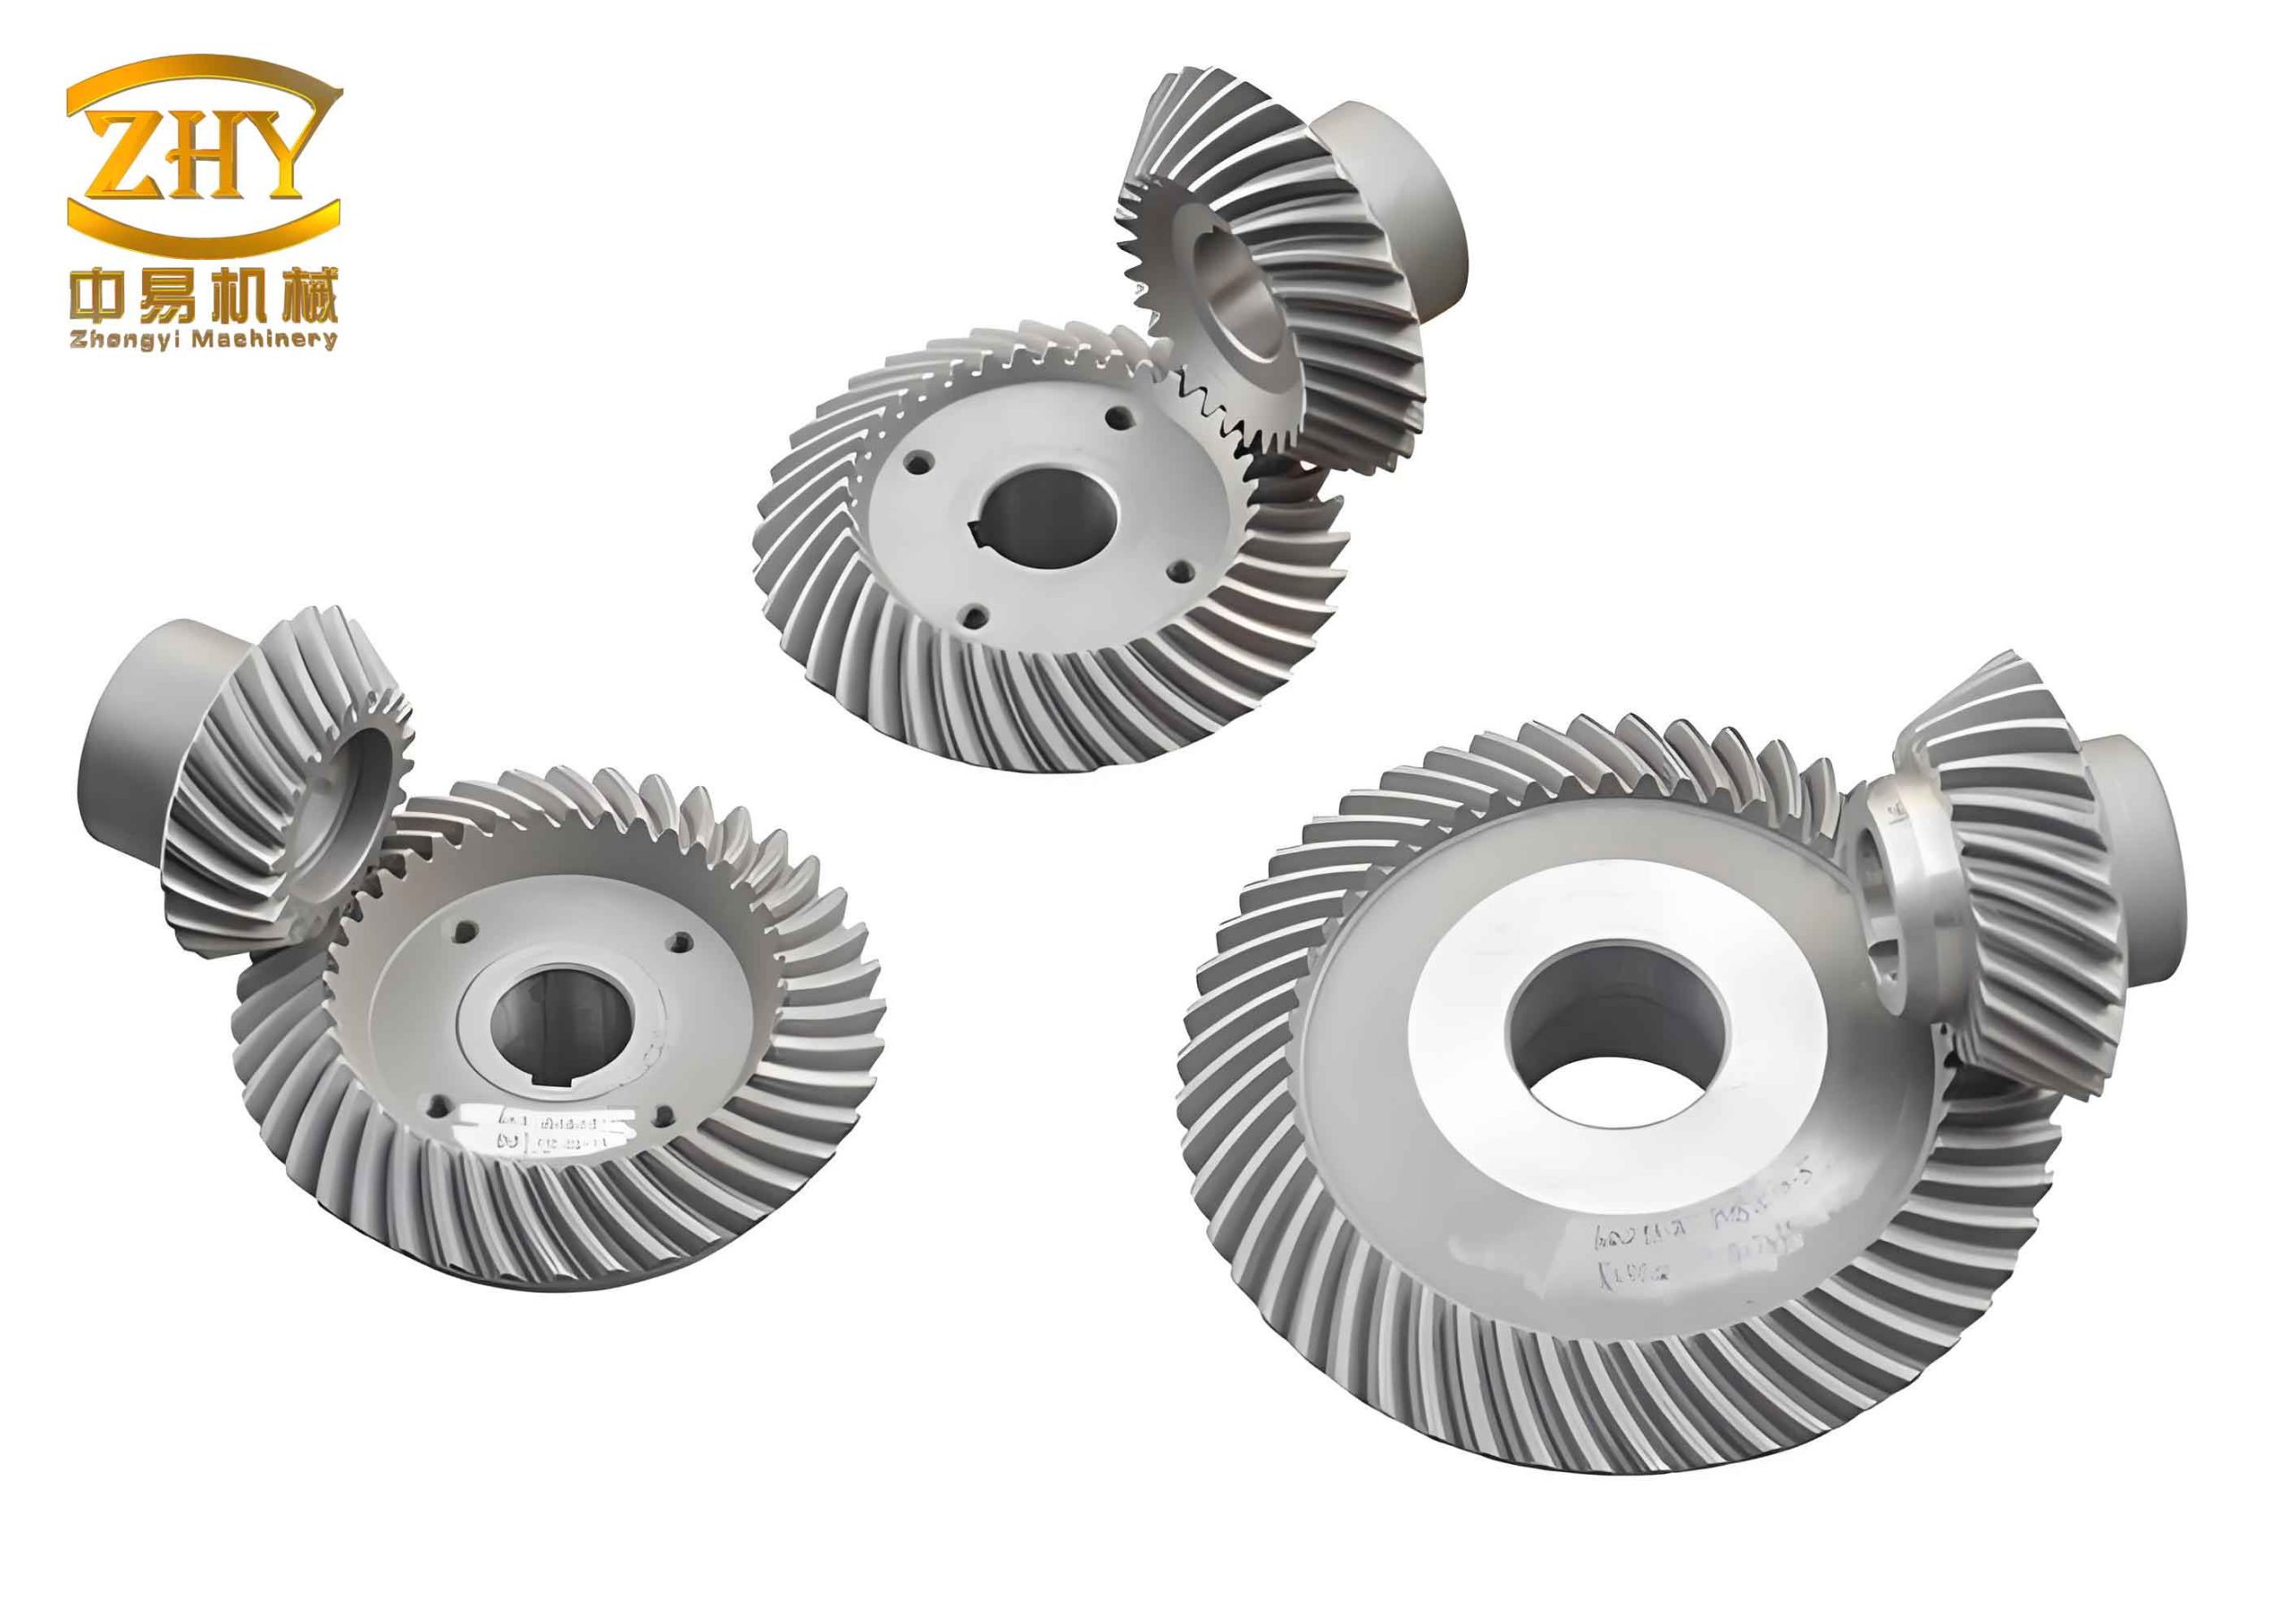
To understand the failure mechanisms of hyperboloid gears, it is essential first to contrast their properties with those of spiral bevel gears. The table below summarizes key characteristics, emphasizing why hyperboloid gears are favored in modern axles despite their sensitivity to certain conditions.
| Characteristic | Hyperboloid Gear | Spiral Bevel Gear |
|---|---|---|
| Operational Smoothness | Excellent | Good |
| Bending Strength | Increased by approximately 30% | Relatively Lower |
| Resistance to Scuffing | High | High |
| Contact Strength | High | Moderate to Low |
| Transmission Efficiency | About 98% | Approximately 97% |
| Sensitivity to Misalignment | Depends on Bearing Stiffness and Cutter Diameter | Depends on Bearing Stiffness and Cutter Diameter |
| Bearing Load | Higher Axial Force on Pinion | Lower Axial Force on Pinion |
| Lubricant Requirement | Specialty Oil with Anti-Scuff Additives | Conventional Gear Oil |
From this comparison, it is evident that hyperboloid gears offer superior strength and efficiency, but they impose greater demands on lubrication systems due to elevated sliding velocities. The axial forces in hyperboloid gears necessitate robust bearing support, and any compromise in alignment can exacerbate wear. In my analysis, I have categorized gear damage into several interrelated aspects, each influenced by operational, material, and maintenance factors.
Relationship Between Hyperboloid Gear Damage and Operational Parameters
Hyperboloid gear performance is intrinsically linked to vehicle speed and torque profiles. Based on field data and failure analyses, I have identified distinct damage patterns associated with specific driving conditions.
Firstly, during aggressive driving cycles involving frequent rapid acceleration and deceleration, hyperboloid gears experience cyclic shock loads. This leads to scuffing or adhesive wear on both the drive and coast sides of the gear teeth. The sliding velocity, denoted as \( v_s \), can be expressed for hyperboloid gears as:
$$ v_s = \sqrt{v_{t1}^2 + v_{t2}^2 – 2 v_{t1} v_{t2} \cos \phi} $$
where \( v_{t1} \) and \( v_{t2} \) are the tangential velocities at the pinion and gear, respectively, and \( \phi \) is the shaft angle. Under abrupt torque changes, the instantaneous sliding velocity spikes, compromising the lubricant film and causing metal-to-metal contact. This is particularly detrimental for hyperboloid gears due to their high contact pressures, often exceeding 2,000 MPa.
Secondly, prolonged operation in high-speed gears, such as overdrive modes, results in sustained high sliding velocities. This can cause thermal degradation of the lubricant and lead to scoring or polishing wear on the tooth surfaces. The temperature rise in hyperboloid gears can be approximated by:
$$ \Delta T = \frac{P_{loss}}{\rho c Q} $$
where \( P_{loss} \) is the power loss due to friction, \( \rho \) is the lubricant density, \( c \) is the specific heat, and \( Q \) is the flow rate. Elevated temperatures reduce oil viscosity, diminishing the elastohydrodynamic lubrication (EHL) film thickness, which is critical for hyperboloid gear protection.
Thirdly, overload conditions with low-speed, high-torque applications, such as climbing steep grades or hauling excessive payloads, induce extreme Hertzian contact stresses. This can manifest as high-pressure ridges, rippling, or pitting on the gear teeth. The contact stress \( \sigma_H \) for hyperboloid gears is given by the refined AGMA formula:
$$ \sigma_H = Z_E \sqrt{ \frac{F_t}{b d_1} \cdot \frac{u+1}{u} \cdot \frac{Z_R Z_I}{K_A K_V K_{H\beta} K_{H\alpha}} } $$
Here, \( Z_E \) is the elasticity factor, \( F_t \) is the tangential load, \( b \) is the face width, \( d_1 \) is the pinion pitch diameter, \( u \) is the gear ratio, \( Z_R \) and \( Z_I \) are geometry factors, and \( K \) terms account for application, dynamic, and load distribution factors. Exceeding the material’s endurance limit under such stresses accelerates fatigue failures like spalling.
To quantify the impact, consider the following table summarizing damage modes versus operational regimes for hyperboloid gears:
| Operational Regime | Primary Damage Mode | Key Contributing Factors |
|---|---|---|
| Aggressive Cycling (Rapid Acceleration/Deceleration) | Scuffing and Adhesive Wear | High Instantaneous Sliding Velocity, Lubricant Film Breakdown |
| Sustained High-Speed Operation | Scoring and Noise Generation | Elevated Temperatures, Reduced Film Thickness |
| Low-Speed, High-Torque Overload | Pitting, Rippling, and Spalling | Excessive Hertzian Stress, Material Fatigue |
Influence of Gear Hardness on Hyperboloid Gear Damage
Hyperboloid gears are typically manufactured from case-hardened alloy steels, such as AISI 8620 or similar grades, to achieve a hard surface layer with a tough core. This configuration provides excellent wear resistance and compressive strength, but improper heat treatment or material selection can precipitate failures.
The core hardness of hyperboloid gears is usually in the range of 30-40 HRC, while the case hardness exceeds 58 HRC, with a effective case depth of 0.8-1.2 mm. The gradient in hardness is crucial; a steep transition can cause subsurface cracking under heavy loads. The bending stress \( \sigma_b \) at the tooth root of a hyperboloid gear can be calculated using:
$$ \sigma_b = \frac{F_t}{b m_n} Y_F Y_S Y_\beta Y_B $$
where \( m_n \) is the normal module, \( Y_F \) is the form factor, \( Y_S \) is the stress correction factor, \( Y_\beta \) is the helix angle factor, and \( Y_B \) is the rim thickness factor. If the core lacks sufficient toughness, plastic deformation may occur, leading to tooth bending fatigue.
Moreover, differential carbon concentration between the case and core can induce residual stresses. If the carbon gradient is too abrupt, it promotes case crushing or spalling. The diffusion process during carburizing is governed by Fick’s second law:
$$ \frac{\partial C}{\partial t} = D \frac{\partial^2 C}{\partial x^2} $$
where \( C \) is carbon concentration, \( t \) is time, \( D \) is the diffusion coefficient, and \( x \) is depth. Optimizing this process is vital for hyperboloid gear durability.
Additionally, the hardness mismatch between the oxide film formed during lubrication and the base metal affects wear resistance. A smaller hardness difference enhances adhesion, reducing oxidative wear. The wear rate \( W \) can be modeled by Archard’s equation:
$$ W = k \frac{F_n L}{H} $$
where \( k \) is the wear coefficient, \( F_n \) is the normal load, \( L \) is the sliding distance, and \( H \) is the hardness. For hyperboloid gears, maintaining high surface hardness minimizes plastic deformation and wear.
Common hardness-related failures in hyperboloid gears include:
- Plastic deformation under overload, causing tooth flank wear.
- Case spalling due to inadequate core support.
- Micro-pitting from insufficient hardness depth.
Role of Gear Oil Quality in Hyperboloid Gear and Bearing Damage
Hyperboloid gears operate under extreme pressure (EP) conditions, with contact stresses often surpassing 2,500 MPa and sliding velocities exceeding 8 m/s. Consequently, lubricant performance is paramount. In my assessments, I have found that gear oil formulation directly influences the longevity of hyperboloid gears and associated bearings.
Specialized hyperboloid gear oils contain EP additives, such as sulfur-phosphorus compounds, which form protective tribofilms under high temperatures. The film thickness \( h \) in EHL regimes can be estimated using the Hamrock-Dowson equation:
$$ h = 2.69 R’ U^{0.67} G^{0.53} W^{-0.067} (1 – 0.61 e^{-0.73k}) $$
where \( R’ \) is the reduced radius of curvature, \( U \) is the speed parameter, \( G \) is the material parameter, \( W \) is the load parameter, and \( k \) is the ellipticity parameter. Inadequate film formation due to oil degradation leads to boundary lubrication, increasing friction and wear.
High operating temperatures, which can reach 150-160°C in heavy-duty applications, accelerate oil oxidation. This depletes additives and increases viscosity, impairing flow. The oxidation rate follows an Arrhenius relationship:
$$ r = A e^{-E_a / (RT)} $$
where \( r \) is the reaction rate, \( A \) is the pre-exponential factor, \( E_a \) is the activation energy, \( R \) is the gas constant, and \( T \) is the absolute temperature. Oxidized oil forms sludge, which can block oil passages and starve hyperboloid gears of lubrication.
Furthermore, bearing failures like pitting and spalling are exacerbated by contaminated or aged oil. The fatigue life \( L_{10} \) of rolling bearings is given by:
$$ L_{10} = \left( \frac{C}{P} \right)^p $$
where \( C \) is the dynamic load rating, \( P \) is the equivalent dynamic load, and \( p \) is the exponent (3 for ball bearings, 10/3 for roller bearings). Poor lubrication reduces \( L_{10} \) significantly.
Based on field trials, I recommend using API GL-5 or higher grade oils with viscosity grades like 75W-90 or 80W-140 for hyperboloid gears in heavy trucks. In cold climates, 75W-90 oils offer better low-temperature fluidity. The table below outlines oil specifications for hyperboloid gear applications:
| Application | Recommended Oil Grade | Key Properties |
|---|---|---|
| General Heavy-Duty Use | API GL-5 75W-90 | High EP Performance, Thermal Stability |
| Extreme Cold Environments | API GL-5 75W-140 | Low Pour Point, Enhanced Flowability |
| High-Temperature Operations | API GL-5 80W-140 with Antioxidants | Oxidation Resistance, High Film Strength |
Impact of Oil Quantity and Change Intervals on Hyperboloid Gear Damage
Proper lubrication management is critical for hyperboloid gear systems. Both overfilling and underfilling can lead to premature failures, and neglecting oil change schedules compounds these issues.
Excessive oil volume increases churning losses, reducing transmission efficiency and generating excess heat. The churning torque \( T_c \) can be approximated as:
$$ T_c = C \rho \omega^2 D^5 $$
where \( C \) is a coefficient, \( \rho \) is oil density, \( \omega \) is angular velocity, and \( D \) is gear diameter. This heat raises oil temperature, accelerating degradation. Conversely, insufficient oil causes inadequate cooling and lubricant starvation, especially under high loads. The minimum oil level should ensure immersion of the lowest gear teeth during operation.
Oil change intervals are dictated by service conditions. As hyperboloid gears subject oil to severe shear and thermal stress, additives deplete over time. The remaining useful life (RUL) of gear oil can be modeled using:
$$ RUL = t_0 \left( \frac{V_i}{V_c} \right)^n $$
where \( t_0 \) is the baseline life, \( V_i \) is the initial additive concentration, \( V_c \) is the current concentration, and \( n \) is an empirical exponent. Regular oil analysis helps determine optimal change points.
Moreover, modern hyperboloid gear oils include dispersants to hold contaminants in suspension, but over time, abrasive particles accumulate, increasing wear rates. The contaminant-induced wear volume \( V_w \) is proportional to particle concentration \( C_p \):
$$ V_w = k_p C_p F_n L $$
where \( k_p \) is a proportionality constant. Hence, timely oil changes are essential to remove debris.
In practice, I advise checking oil levels weekly in severe service and changing oil every 50,000 to 100,000 kilometers, depending on the manufacturer’s guidelines and operational severity. Using synthetic hyperboloid gear oils can extend these intervals due to superior stability.
Advanced Considerations for Hyperboloid Gear Design and Maintenance
Beyond the factors discussed, hyperboloid gear performance is influenced by design nuances and proactive maintenance strategies. In my analysis, I have incorporated finite element analysis (FEA) and tribological simulations to predict failure modes.
The contact pattern on hyperboloid gears is elliptical, and its size and location affect stress distribution. The semi-major axis \( a \) and semi-minor axis \( b \) of the contact ellipse are given by Hertzian theory:
$$ a = \left( \frac{3 F_n R’}{2 E’} \right)^{1/3} \left( \frac{1}{1 + \kappa} \right)^{1/3}, \quad b = a \kappa $$
where \( E’ \) is the reduced modulus, and \( \kappa \) is the ellipticity ratio. Misalignment shifts this pattern, leading to edge loading and rapid wear. Proper shimming during assembly is crucial for hyperboloid gears.
Additionally, surface roughness plays a significant role. The lambda ratio \( \lambda \), defined as the ratio of film thickness to composite surface roughness, should exceed 2 for adequate protection:
$$ \lambda = \frac{h}{\sqrt{R_{q1}^2 + R_{q2}^2}} $$
where \( R_{q1} \) and \( R_{q2} \) are the root-mean-square roughness of the mating surfaces. For hyperboloid gears, superfinishing processes can improve \( \lambda \), reducing micropitting.
Noise and vibration analysis also provide early warnings of hyperboloid gear damage. The meshing frequency \( f_m \) is:
$$ f_m = \frac{N \omega}{60} $$
where \( N \) is the number of teeth and \( \omega \) is the rotational speed in RPM. Increases in vibration amplitudes at \( f_m \) or its harmonics indicate wear or misalignment.
To encapsulate, I have developed a holistic model for hyperboloid gear life prediction, integrating operational, material, and lubrication variables. The damage accumulation function \( D(t) \) can be expressed as:
$$ D(t) = \int_0^t \left( \frac{\sigma_H(t)}{\sigma_{H,\lim}} \right)^m + \left( \frac{\tau(t)}{\tau_{\lim}} \right)^n \, dt $$
where \( \sigma_H(t) \) and \( \tau(t) \) are time-varying contact and shear stresses, \( \sigma_{H,\lim} \) and \( \tau_{\lim} \) are endurance limits, and \( m, n \) are material exponents. This approach aids in scheduling maintenance for hyperboloid gear systems.
Conclusion and Recommendations
Through this extensive analysis, I have delineated the multifaceted nature of hyperboloid gear damage in medium and heavy-duty truck axles. The durability of hyperboloid gears hinges on a balance between robust design, high-quality materials, appropriate lubrication, and disciplined maintenance. Key takeaways include:
- Hyperboloid gears offer superior strength and efficiency but are sensitive to operational extremes.
- Material hardness gradients must be optimized to prevent subsurface failures.
- Specialized hyperboloid gear oils with EP additives are non-negotiable for preventing scuffing and wear.
- Regular oil monitoring and changes mitigate contaminant-induced damage.
- Advanced diagnostics, such as vibration analysis, can preempt catastrophic failures.
Looking forward, innovations in coating technologies, like diamond-like carbon (DLC) coatings, and the adoption of IoT-based condition monitoring systems promise to enhance hyperboloid gear reliability. By adhering to best practices and leveraging engineering insights, operators can maximize the service life of hyperboloid gear drives, ensuring economic and operational efficiency in heavy-duty transportation.
In summary, the integration of hyperboloid gears in truck axles represents a significant engineering advancement, but it demands commensurate attention to detail. My hope is that this analysis serves as a comprehensive guide for practitioners dealing with hyperboloid gear systems, fostering a deeper understanding of failure mechanisms and proactive mitigation strategies.