
In modern mechanical transmission systems, screw gears play a pivotal role due to their high load-bearing capacity, smooth operation, and efficiency in power transfer. These gears, characterized by their helical or worm-like tooth profiles, are extensively employed in heavy-duty applications such as automotive differentials, industrial machinery, and aerospace systems. However, the performance and longevity of screw gears are heavily influenced by dynamic interactions and lubrication conditions at the tooth contact interfaces. Specifically, the interplay between tribological behavior—encompassing friction and wear—and dynamic responses, such as time-varying stiffness and transmission errors, dictates the overall system reliability. This article delves into the elastohydrodynamic lubrication (EHL) analysis of screw gears by incorporating tribo-dynamics characteristics, aiming to provide a holistic understanding of how operational parameters affect gear performance.
The significance of this study stems from the need to optimize screw gear designs for enhanced durability and efficiency. Traditional lubrication models often assume smooth surfaces or neglect dynamic effects, leading to inaccuracies in predicting film thickness and pressure distributions. In reality, screw gears operate under mixed lubrication regimes where asperity contacts and fluid film coexist, especially under high loads or low speeds. By integrating tribo-dynamics—a field that merges tribology with dynamics—we can better simulate real-world conditions. This approach considers factors like variable mesh stiffness, friction coefficients of rough surfaces, and transient loads, which are critical for accurate EHL predictions. Through this analysis, we aim to derive insights that can guide the design of screw gears with improved lubrication performance and reduced friction-induced failures.
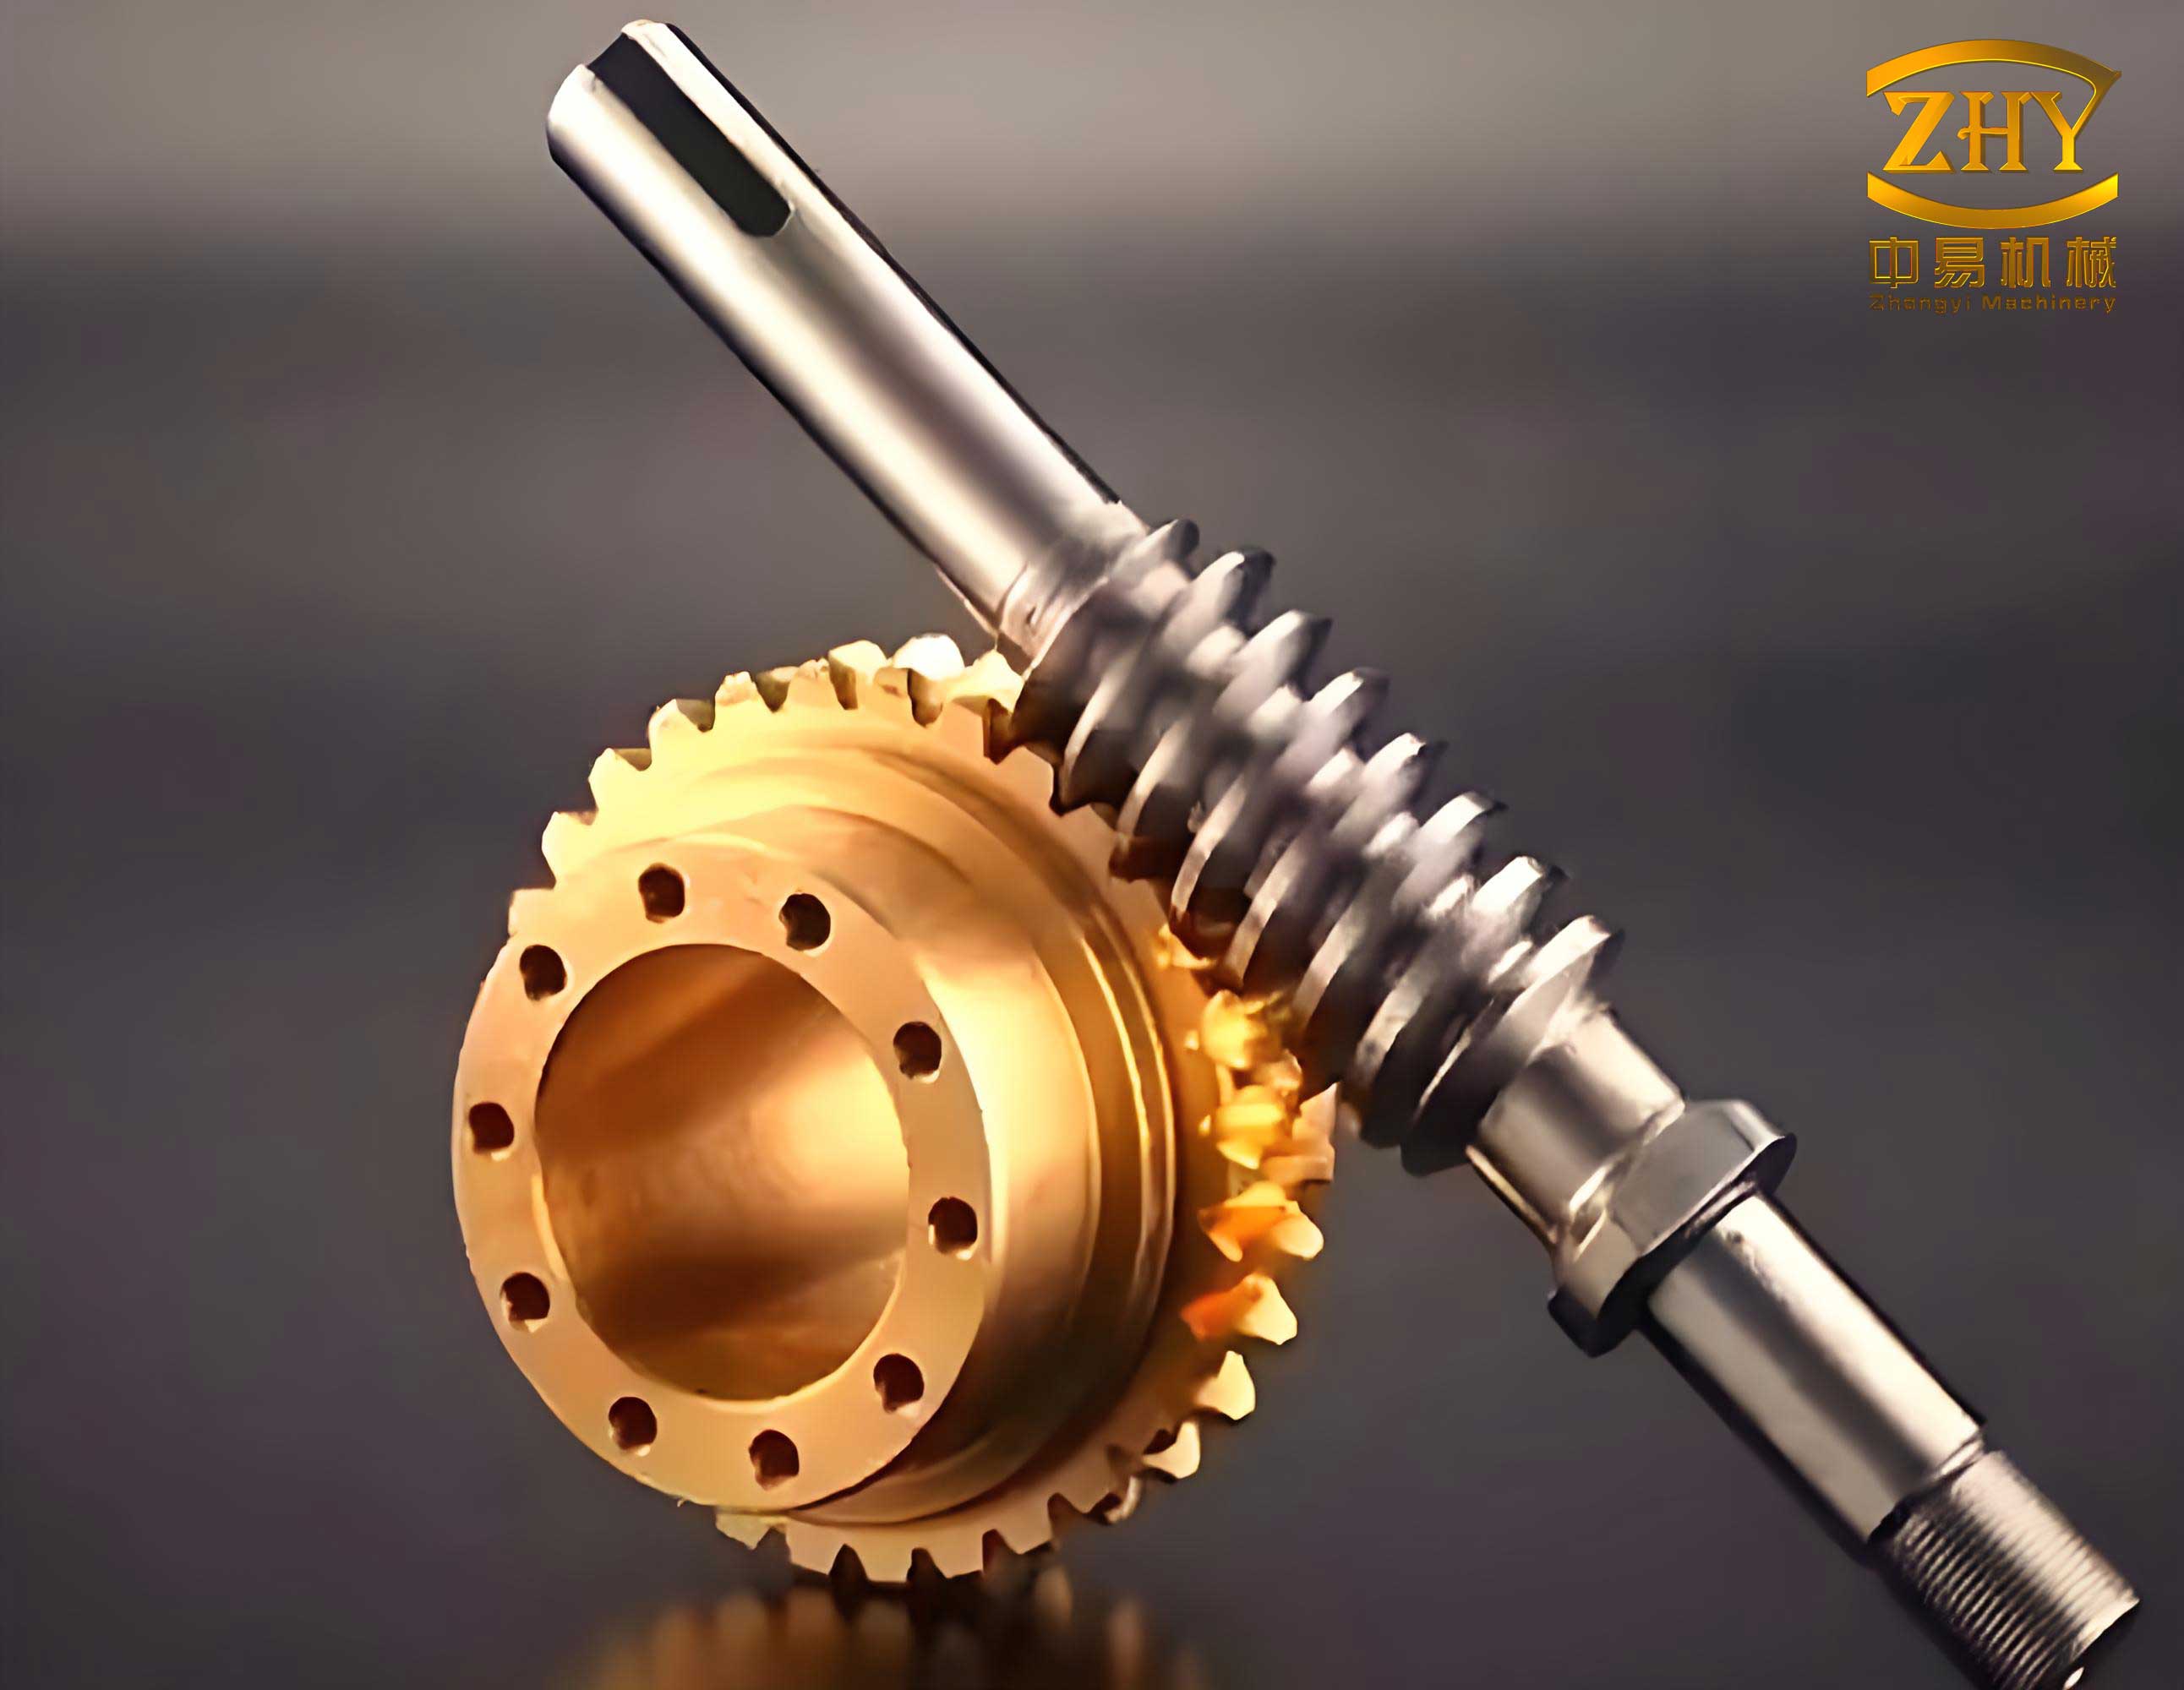
To model the tribo-dynamics of screw gears, we first establish a simplified dynamic representation based on lumped-parameter theory. The system comprises two main components: the driving screw gear (similar to a worm) and the driven gear (referred to as the wheel in screw gear pairs). We assume rigid shafts and bearings, focusing on the gear mesh dynamics. The equations of motion are derived using Newton’s second law, accounting for forces along the line of action. The dynamic transmission error, which quantifies deviations from ideal motion due to elastic deformations and manufacturing inaccuracies, is a key variable. It is expressed as:
$$ \delta(t) = r_{b1} \theta_1(t) – r_{b2} \theta_2(t) + x_1(t) – x_2(t) $$
where \( r_{b1} \) and \( r_{b2} \) are base circle radii of the screw gear and wheel, respectively; \( \theta_1(t) \) and \( \theta_2(t) \) are angular displacements; and \( x_1(t) \) and \( x_2(t) \) represent translational displacements due to bearing compliance. The static transmission error \( e(t) \) is modeled as a Fourier series to capture periodic variations:
$$ e(t) = e_m + \sum_{j=1}^{\infty} e_j \left[ \cos(j \omega_e t) + \sin(j \omega_e t) \right] $$
with \( e_m \) as mean amplitude, \( e_j \) as harmonic amplitudes, and \( \omega_e \) as mesh frequency. The dynamic mesh force for the i-th tooth pair is then:
$$ F_{di}(t) = k_i(t) \zeta(t) + c_i(t) \dot{\Delta}(t) $$
where \( k_i(t) \) is time-varying mesh stiffness, \( c_i(t) \) is damping coefficient, and \( \zeta(t) \) is a displacement function accounting for backlash \( b_n \). For screw gears, the mesh stiffness varies cyclically due to changing contact conditions along the helical teeth. The friction force at the contact point is:
$$ F_{fi}(t) = \Lambda_i(t) \mu_i(t) F_{di}(t) $$
Here, \( \mu_i(t) \) is the friction coefficient, which depends on lubrication regime and surface roughness, and \( \Lambda_i(t) \) is a direction factor based on relative sliding velocities. The dynamic equations for the screw gear system are:
| Component | Equation of Motion |
|---|---|
| Screw Gear | $$ J_1 \ddot{\theta}_1(t) + r_{b1} \sum_{i=1}^{n_z} F_{di}(t) + \sum_{i=1}^{n_z} \Lambda_i \lambda_{1i} \mu_i F_{fi}(t) = T_1 $$ |
| Wheel | $$ J_2 \ddot{\theta}_2(t) – r_{b2} \sum_{i=1}^{n_z} F_{di}(t) + \sum_{i=1}^{n_z} \Lambda_i \lambda_{2i} \mu_i F_{fi}(t) = -T_2 $$ |
| Translational (x-direction) | $$ m_1 \ddot{x}_1(t) + c_{x1} \dot{x}_1(t) + k_{x1} x_1(t) + \sum_{i=1}^{n_z} F_{di}(t) = 0 $$ |
| Translational (y-direction) | $$ m_2 \ddot{y}_2(t) + c_{y2} \dot{y}_2(t) + k_{y2} y_2(t) – \sum_{i=1}^{n_z} F_{di}(t) = 0 $$ |
In these equations, \( J_1 \) and \( J_2 \) are moments of inertia; \( T_1 \) and \( T_2 \) are input and load torques; \( m_1 \) and \( m_2 \) are equivalent masses; \( k \) and \( c \) terms denote bearing stiffness and damping; and \( n_z \) is number of simultaneously engaged tooth pairs. The tribo-dynamics model for screw gears thus captures essential interactions between mechanical vibrations and frictional effects.
Next, we integrate the EHL theory to analyze lubrication performance. The contact between screw gear teeth is approximated as line contact between equivalent cylinders, valid due to high curvature ratios. The Reynolds equation for transient, thermal EHL in screw gears is:
$$ \frac{\partial}{\partial x} \left( \frac{\rho h^3}{\eta^*} \frac{\partial p}{\partial x} \right) = 12 u_e \frac{\partial (\rho h)}{\partial x} + 12 \frac{\partial (\rho h)}{\partial t} $$
where \( p \) is pressure, \( h \) is film thickness, \( \rho \) is density, \( \eta^* \) is equivalent viscosity, and \( u_e \) is entrainment velocity. For screw gears, the entrainment velocity depends on gear geometry and operating conditions. The film thickness equation incorporating surface roughness is:
$$ h(x,t) = h_0(t) + \frac{x^2}{2R} + v(x,t) + S_1(x,t) + S_2(x,t) $$
Here, \( h_0 \) is central film thickness, \( R \) is equivalent radius of curvature, \( v \) is elastic deformation, and \( S_1 \), \( S_2 \) are roughness profiles of screw gear and wheel teeth, modeled as cosine functions. The pressure-viscosity relationship uses the Barus equation:
$$ \eta = \eta_0 \exp(\alpha p) $$
with \( \eta_0 \) as ambient viscosity and \( \alpha \) as pressure coefficient. The density-pressure correlation is:
$$ \rho = \rho_0 \left( 1 + \frac{0.6 \times 10^{-9} p}{1 + 1.7 \times 10^{-9} p} \right) $$
To solve the coupled tribo-dynamics and EHL problem, we employ an iterative numerical scheme. The dynamic model provides time-varying loads and speeds, which feed into the EHL model to compute film thickness and pressure. These outputs then update the oil film stiffness and friction coefficients, iterating until convergence. The oil film stiffness for the i-th tooth pair is:
$$ k_{Hi}(t) = \frac{\partial F_{di}(t)}{\partial h_{ci}(t)} $$
where \( h_{ci} \) is central film thickness. The effective mesh stiffness of screw gears, considering both structural and lubricant effects, becomes:
$$ \frac{1}{k_i(t)} = \frac{1}{k_{Mi}(t)} + \frac{1}{k_{Hi}(t)} \Rightarrow k_i(t) = \frac{k_{Mi}(t) k_{Hi}(t)}{k_{Mi}(t) + k_{Hi}(t)} $$
with \( k_{Mi}(t) \) as mechanical mesh stiffness. This coupling is crucial for accurate prediction of screw gear behavior under lubricated conditions.
We now present results from simulations performed on typical screw gear configurations. The parameters used are summarized in the table below, which reflects common values for industrial screw gears.
| Parameter | Value | Unit |
|---|---|---|
| Number of teeth (screw gear/wheel) | 2/40 | – |
| Module | 5 | mm |
| Pressure angle | 20 | ° |
| Helix angle | 15 | ° |
| Center distance | 125 | mm |
| Gear width | 40 | mm |
| Young’s modulus (both gears) | 210 | GPa |
| Poisson’s ratio | 0.3 | – |
| Input speed range | 500-3000 | rpm |
| Load torque | 100 | Nm |
| Lubricant viscosity | 0.08 | Pa·s |
| Roughness friction coefficient | 0.05-0.15 | – |
The dynamic response of screw gears over a mesh cycle reveals significant trends. For instance, the mesh force variation with helix angle and speed is captured by:
$$ F_d(t) = \sum_{i=1}^{n_z} k_i(t) \zeta(t) + c_i(t) \dot{\Delta}(t) $$
Plots indicate that at lower speeds, mesh forces at the engagement point are higher due to increased dynamic effects, while higher speeds reduce these forces but may elevate friction. The friction force, derived from tribo-dynamics, shows:
$$ F_f(t) = \sum_{i=1}^{n_z} \Lambda_i(t) \mu_i(t) F_{di}(t) $$
As helix angle increases from 5° to 15°, both mesh and friction forces rise, but the maximum friction decreases, enhancing screw gear life. This is quantified in the following table summarizing force peaks over a cycle.
| Helix Angle (°) | Max Mesh Force (N) | Max Friction Force (N) | Speed (rpm) |
|---|---|---|---|
| 5 | 1200 | 180 | 1000 |
| 10 | 1350 | 190 | 1000 |
| 15 | 1500 | 170 | 1000 |
| 5 | 1100 | 160 | 3000 |
| 10 | 1250 | 170 | 3000 |
| 15 | 1400 | 150 | 3000 |
The EHL analysis provides insights into film pressure and thickness distributions. The dimensionless pressure \( P = p / p_h \) and film thickness \( H = h / R \) are solved using the Reynolds equation with boundary conditions \( P(X_{in}) = 0 \) and \( P(X_{out}) = dP/dX = 0 \). Results show that for screw gears, increasing mesh stiffness significantly boosts maximum pressure and film thickness, as per:
$$ P_{max} \propto k_M^{0.5}, \quad H_{min} \propto k_M^{0.3} $$
where \( k_M \) is mesh stiffness. Variations with roughness friction coefficient \( \mu_a \) are less pronounced, but higher \( \mu_a \) reduces film thickness slightly. These relationships are derived from curve-fitting simulation data. The central film thickness formula for screw gears under mixed lubrication is:
$$ H_c = \gamma_1^{S/2} \left[ H_{ri}^{7/3} + (\gamma_1)^{-14/15} H_{ei}^{7/3} \right]^{3S/7} + \gamma_1^{-S/2} \left( H_{rp}^{-7/2} + H_{ep}^{-7/2} \right)^{-2S/7} $$
where \( \gamma_1 \) is load-sharing ratio, and \( H_{ri} \), \( H_{ei} \) are dimensionless parameters related to rigid and elastic film thicknesses. The pressure distribution along the contact line is illustrated by:
$$ P(X) = \frac{3}{2} \left( 1 – X^2 \right)^{1/2} + \Delta P_{rough} $$
with \( \Delta P_{rough} \) accounting for roughness effects. A key finding is that screw gears with higher helix angles exhibit more stable EHL conditions, due to better load distribution and entrainment motion.
To further elucidate parameter sensitivities, we present analytical expressions derived from the models. The dynamic transmission error influences vibration levels, modeled as:
$$ \Delta(t) = x(t) + x_1(t) – x_2(t) – e(t) $$
The mesh stiffness for screw gears, considering helical tooth engagement, is approximated by:
$$ k_M(t) = k_{base} + \Delta k \sin(\omega_e t + \phi) $$
where \( k_{base} \) is average stiffness, \( \Delta k \) is amplitude, and \( \phi \) is phase angle. The friction coefficient in mixed lubrication for screw gears is:
$$ \mu(t) = \mu_a \frac{F_a}{F_d} + \mu_h \frac{F_h}{F_d} $$
with \( \mu_a \) and \( \mu_h \) as asperity and hydrodynamic friction coefficients, and \( F_a \), \( F_h \) as asperity and fluid load shares. The load-sharing ratio is:
$$ \gamma_1 = \frac{F_h}{F_d}, \quad \gamma_2 = \frac{F_a}{F_d} $$
These equations highlight the interdependence of dynamics and lubrication in screw gears.
In conclusion, this analysis underscores the importance of integrating tribo-dynamics into EHL studies for screw gears. We have developed a coupled model that captures time-varying stiffness, friction, and lubrication effects, providing a robust framework for performance prediction. Key takeaways include: (1) Higher helix angles in screw gears improve load capacity but require careful lubrication design; (2) Dynamic forces are more severe at low speeds, necessitating enhanced film thickness; (3) Mesh stiffness is a dominant factor affecting EHL outcomes, more so than friction coefficients; and (4) The iterative solution method ensures convergence for practical screw gear applications. Future work could explore thermal effects or non-Newtonian lubricants in screw gears. This research aids in designing more efficient and durable screw gear systems, leveraging advanced tribo-dynamics principles.