
In the realm of high-performance power transmission systems, particularly within aerospace applications, spiral bevel gears serve as critical components. Their ability to transmit motion and power between intersecting shafts, especially at a 90-degree angle, with high efficiency and smooth operation is paramount. The ongoing trend towards lightweight and heavily loaded designs in aviation places extreme demands on these gears, pushing their operational boundaries. A significant challenge arising from this push is the phenomenon of edge contact, where under high loads, manufacturing tolerances, or assembly errors, contact occurs at the very edge of the tooth flank—either at the tip or the root—rather than within the designed, central contact area. This condition can lead to elevated contact stresses, accelerated surface wear, increased noise, and vibrations, ultimately compromising the gear’s performance and longevity. Therefore, a precise understanding and quantitative analysis of edge contact in spiral bevel gears are essential for reliable design.
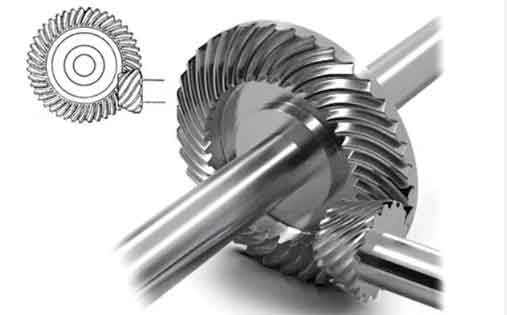
This article presents a detailed investigation into the edge contact behavior of spiral bevel gears using a systematic finite element method (FEM) approach. The core of the methodology involves leveraging the batch-processing capabilities of advanced FEM software to perform static contact analyses across the entire mesh cycle. By discretizing the engagement process from initial contact to recess into numerous sequential positions, a quasi-static simulation of the dynamic meshing event is achieved. This approach allows for the efficient and precise quantification of how edge contact initiates and evolves with increasing load, providing data on contact stress distribution, contact pattern morphology, and contact path trajectory. The results are compared and validated against classical analytical methods, namely Tooth Contact Analysis (TCA) and Loaded Tooth Contact Analysis (LTCA). The primary objective is to establish critical load thresholds for edge contact, identify its precise locations, and elucidate its impact on key performance parameters.
Theoretical Foundation and Contact Modeling
The complex geometry of spiral bevel gears is defined by a set of machine-tool settings during their generation process. For the purpose of contact analysis, two primary theoretical frameworks are employed: unloaded (Geometric) Tooth Contact Analysis (TCA) and Loaded Tooth Contact Analysis (LTCA).
TCA simulates the kinematic contact of perfectly rigid tooth flanks without considering elastic deformations. It determines the theoretical contact path, transmission error under no load, and the unloaded contact pattern. The fundamental condition for contact is the coincidence of position vectors and the alignment of surface normals at the potential contact point. This can be expressed by a system of equations derived from the gear geometry. For a pair of mating gear surfaces $Σ_g$ and $Σ_p$, the condition for contact is that their position vectors $r^{(g)}$ and $r^{(p)}$ and their unit normals $n^{(g)}$ and $n^{(p)}$ coincide at the contact point when the gears are in mesh. This leads to a set of scalar equations:
$$ r_x^{(g)}(θ_g, φ_g) – r_x^{(p)}(θ_p, φ_p) = 0 $$
$$ r_y^{(g)}(θ_g, φ_g) – r_y^{(p)}(θ_p, φ_p) = 0 $$
$$ r_z^{(g)}(θ_g, φ_g) – r_z^{(p)}(θ_p, φ_p) = 0 $$
$$ n_x^{(g)}(θ_g, φ_g) / n_y^{(g)}(θ_g, φ_g) – n_x^{(p)}(θ_p, φ_p) / n_y^{(p)}(θ_p, φ_p) = 0 $$
where $θ$ is the surface parameter and $φ$ is the angle of rotation of the gear. Solving this system yields the contact path on the tooth flank and the unloaded transmission error curve. However, standard TCA assumes contact remains within the boundaries of the active flank. Modified TCA algorithms are required to detect and model edge contact, where the contact point reaches the physical limit of the tooth edge.
LTCA extends this concept by incorporating the elastic deformations of the teeth under load. It solves for the actual load distribution among multiple pairs of teeth in contact and the resulting loaded transmission error. The compatibility condition requires that the sum of the elastic approach (contact deformation + tooth bending/deflection) at any potential contact point, plus the initial geometric separation (unloaded gap), equals a constant rigid-body approach. This is typically solved using influence coefficient methods. The compatibility and equilibrium equations for a discrete system can be summarized as:
Compatibility: $$ [δ_{ij}]{F_j} + {e_i} = {D} + {s_i} $$
Equilibrium: $$ \sum_{j=1}^{n} F_j = T / r_b $$
Here, $[δ_{ij}]$ is the flexibility/influence coefficient matrix, ${F_j}$ is the vector of discrete loads, ${e_i}$ is the initial unloaded gap vector, ${D}$ is the rigid-body approach vector, ${s_i}$ is the separation vector for non-contact points, $T$ is the input torque, and $r_b$ is the base radius. LTCA can predict edge contact by allowing the contact ellipse to intersect with the tooth edges, leading to a redistribution of load that often concentrates at the edge.
Finite Element Method and Batch Processing Technique
While TCA and LTCA provide powerful analytical insights, the Finite Element Method offers a highly detailed and visual means to study the contact mechanics of spiral bevel gears, including complex phenomena like stress concentration at edges. The challenge lies in efficiently modeling the transient meshing process. The strategy adopted here is a static, sequential batch analysis.
First, a high-fidelity, three-dimensional finite element model of a gear pair segment is constructed. To accurately capture load sharing and the effects of neighboring teeth, a model containing seven teeth on both the pinion and the gear is used, with the central tooth pair being the primary focus of analysis. The gears are modeled as elastic bodies with material properties typical of high-strength aerospace alloys. The contact between all potential tooth flanks is defined using a surface-to-surface contact formulation with a “hard” contact pressure-overclosure relationship in the normal direction and a frictionless tangential behavior for simplicity in this stress analysis.
The key to simulating the mesh cycle is the batch process. Based on the contact path obtained from TCA (both standard and edge-contact inclusive), the relative angular position of the gear pair from initial to final contact of the central tooth pair is divided into a series of discrete steps (e.g., 46 steps). For each step, a unique finite element input file is generated programmatically. This file represents the gear assembly “frozen” at that specific meshing position. The boundary conditions are applied as follows: the pinion shaft connection is fully constrained, while the gear shaft connection is coupled to a reference point that is free to rotate only about its axis. A static torque load is applied to this gear reference point.
These dozens of input files are then solved sequentially using the solver’s batch execution mode. Each solution provides a snapshot of the contact state—stress fields, contact pressures, and reaction forces—at that specific instant. By post-processing all results in sequence, one can construct a comprehensive view of the parameter evolution throughout the engagement. This static approach neglects dynamic inertial effects, making its results directly comparable to static LTCA solutions while offering the advantage of detailed stress visualization and the ability to handle severe edge contact geometries.
Case Study: Analysis of a Helicopter Transmission Spiral Bevel Gear Pair
A case study is performed on a pair of aerospace spiral bevel gears. The basic geometrical parameters are summarized in the table below.
| Parameter | Pinion | Gear | Common |
|---|---|---|---|
| Number of Teeth | 27 | 79 | – |
| Module (mm) | 3.15 | – | |
| Face Width (mm) | 30 | – | |
| Shaft Angle (°) | 90 | ||
| Spiral Angle (°) | 30 (at mid-face) | ||
| Pressure Angle (°) | 20 | ||
| Hand of Spiral | Left | Right | – |
The finite element analysis was conducted for five distinct load levels applied to the gear: 50 N·m, 500 N·m, 1500 N·m, 2500 N·m, and 3500 N·m. The post-processing focused on extracting three critical sets of data: the maximum contact stress on the central tooth pair versus mesh position, the shape and area of the contact pattern on the gear tooth flank, and the effective contact trajectory.
Contact Stress Evolution
The variation of maximum contact stress over the mesh cycle for different loads reveals the onset and severity of edge contact. At low loads (50, 500 N·m), the stress curve is relatively smooth and concave upward, typical of healthy contact moving from the dedendum to the addendum. A significant change occurs at 1500 N·m, where distinct stress peaks appear at the very beginning (entry, gear tooth tip contact) and end (recess, gear tooth root contact) of the mesh cycle. This signifies the initiation of edge contact. The stress at these edge peaks is approximately 20% higher than the central, nominal contact stress.
As the load increases further to 2500 N·m and 3500 N·m, these edge-contact peaks grow dramatically, both in magnitude and in the number of mesh positions affected. At 3500 N·m, the edge contact stress at recess is about 71% higher than the nominal stress in the middle of the mesh path. The recess edge contact consistently produces higher stress than the entry edge contact. The data is summarized below:
| Load (N·m) | Nominal Mid-Path Stress (GPa) | Peak Edge Stress (GPa) | Location of Peak | Stress Increase |
|---|---|---|---|---|
| 50 | ~0.35 | N/A | No edge contact | N/A |
| 500 | ~0.95 | N/A | No edge contact | N/A |
| 1500 | 1.185 | 1.439 | Recess | ~21.4% |
| 2500 | 1.385 | 2.226 | Recess | ~60.7% |
| 3500 | 1.608 | 2.754 | Recess | ~71.3% |
The relationship between applied torque $T$ and the resulting peak edge contact stress $\sigma_{edge}$ can be empirically described by a power-law function beyond the critical load $T_{crit}$:
$$ \sigma_{edge} = \sigma_{nominal} + k (T – T_{crit})^n $$
where $k$ is a proportionality constant and $n > 1$, indicating a super-linear growth of edge stress with load.
Contact Pattern and Area
The contact pattern, or the imprint of contact pressure on the tooth flank, undergoes significant transformation with load. At the lightest load (50 N·m), the pattern is a small, distinct ellipse located centrally along the theoretical path. As load increases, the ellipse elongates primarily along the lengthwise direction (from toe to heel) and expands slightly in the profile direction. Upon reaching the critical load for edge contact (1500 N·m), the pattern begins to intersect the tooth edges—the top edge at entry and the root edge at recess. At very high loads (3500 N·m), the contact area spreads dramatically, nearly covering the entire active flank from toe to heel and from root to tip at the extreme positions.
The contact area was approximated by calculating the convex hull of nodes with significant contact pressure. The growth of area $A$ with torque $T$ follows a nonlinear saturation trend, which can be modeled as:
$$ A(T) = A_{max} (1 – e^{-β T}) $$
where $A_{max}$ is a maximum asymptotic area and $β$ is a growth rate constant. The calculated areas are:
| Load (N·m) | Contact Area (mm²) | Notes |
|---|---|---|
| 50 | 21.4 | Central, elliptical |
| 500 | 70.0 | Elongated ellipse |
| 1500 | 100.7 | Initial edge intersection |
| 2500 | 108.7 | Pronounced edge contact |
| 3500 | 116.8 | Widespread, near-full flank |
A comparison between the FEM-predicted contact patterns (shown as von Mises stress contours) and the load distribution plots from LTCA shows excellent agreement in the location and shape of the contact zone. The key difference lies in the stress metric: FEM shows maximum stress concentration precisely at the sharp edge, while LTCA shows maximum load intensity at the center of the contact ellipse. This highlights that FEM is crucial for assessing the severe stress gradients caused by geometric discontinuities during edge contact.
Contact Path Trajectory
The TCA provides the theoretical, unloaded contact path. The finite element analysis, by identifying the centroids of high-pressure zones for each mesh position, constructs the loaded contact path. For loads below the edge-contact threshold, the FEM-derived path aligns almost perfectly with the TCA path. However, once edge contact occurs, the effective contact path extends beyond the theoretical boundaries. At the point of edge contact, the FEM path shows that contact is sustained at the extreme edge of the tooth, which the standard TCA does not account for. Thus, the finite element method effectively captures the lengthening of the actual contact path under severe load conditions, providing a more accurate picture of the true contact kinematics.
The length of the contact path $L$ can be related to the load and the occurrence of edge contact. Before edge contact, $L$ is relatively constant. After edge contact initiates, the path length increases, particularly at its extremities:
$$ L(T) = L_0 + ΔL_{entry}(T) + ΔL_{recess}(T) $$
where $L_0$ is the nominal path length, and $ΔL_{entry}$ and $ΔL_{recess}$ are the extensions due to edge contact at the entry and recess points, respectively, which are functions of the load $T$.
Discussion and Implications for Gear Design
The quantitative analysis clearly demonstrates that edge contact in spiral bevel gears is a load-dependent phenomenon with a distinct critical threshold. For the studied gear pair, this threshold lies between 500 N·m and 1500 N·m. Beyond this load, three key performance parameters degrade nonlinearly: 1) Peak Contact Stress increases super-linearly, posing a high risk for pitting and spalling failure initiation at the tooth edge. 2) Contact Pattern loses its controlled, elliptical shape, spreading uncontrollably and touching edges, which can lead to localized wear scars and increased mesh stiffness variation. 3) Contact Path effectively lengthens, altering the load distribution and potentially affecting the kinematic precision predicted by unloaded analysis.
The finite element batch processing method proves to be a robust tool for this investigation. Its static formulation allows for direct comparison with established LTCA results, validating its accuracy for contact zone prediction. More importantly, it surpasses analytical methods in its ability to visually and quantitatively depict the severe stress concentrations associated with edge contact, which are often idealized in influence coefficient methods. It is important to note that in real manufactured spiral bevel gears, tips and roots are usually chamfered or rounded (topped and rooted). This manufacturing practice significantly alleviates the extreme stress concentrations predicted by a sharp-edge model. Therefore, the finite element results presented here represent a “worst-case” scenario, highlighting the critical need for such edge relief in heavily loaded gear designs.
The findings underscore the importance of performing loaded contact analysis during the design phase of high-performance spiral bevel gears. Design optimization should aim not only for favorable unloaded kinematics but also to delay the onset of edge contact to well above the intended operational load range. This can be achieved through intentional flank topography modifications (e.g., flank relief or bias) and careful control of assembly conditions. The batch FEM technique serves as an excellent virtual test bench for evaluating these design modifications before physical prototyping.
Conclusion
This comprehensive study successfully implemented a finite element-based batch processing strategy to analyze the edge contact behavior in spiral bevel gears under progressively increasing loads. The method efficiently simulates the entire meshing process through a series of static analyses at discrete positions, providing detailed insights into stress, contact area, and path trajectory.
The key conclusions are as follows:
- Edge contact is initiated at a specific critical load. For the analyzed gear pair, significant edge contact stress peaks emerged at a load of 1500 N·m.
- Once initiated, the severity of edge contact, characterized by peak stress magnitude, increases at a rate greater than the increase in nominal load. The edge contact at the recess (gear tooth root) is more severe than at the entry.
- The contact pattern area grows nonlinearly with load, eventually spreading to the tooth edges and covering a large portion of the flank under extreme load, as predicted by both FEM and LTCA.
- The actual loaded contact path extends beyond the theoretical TCA path when edge contact occurs, a detail accurately captured by the finite element analysis.
- The FEM batch approach provides a reliable and detailed complement to traditional TCA and LTCA, capable of precisely identifying edge-contact onset loads, locations, and associated stress concentrations, which are vital for the durability design of aerospace spiral bevel gears.
Future work will focus on integrating realistic edge chamfers into the model, studying the impact of misalignments on edge contact, and exploring advanced flank modifications to optimize the load distribution and suppress edge contact under target operating conditions.