
I investigate the contact flash temperature of a miter gear transmission operating under high-speed and heavy-load conditions. In this work, the miter gear is treated as a symmetric double-helical gear pair whose left and right tooth flanks are mirror images of each other. This miter gear arrangement provides high load capacity, smooth meshing, and high transmission efficiency. However, the sliding friction between mating miter gear flanks generates a large amount of heat, which raises the tooth surface temperature, degrades lubricant performance, and may eventually cause scuffing. Therefore, I combine tooth surface contact analysis, loaded tooth contact analysis, thermal elastohydrodynamic lubrication, and a classical flash-temperature formulation to evaluate the miter gear contact temperature and scuffing risk.
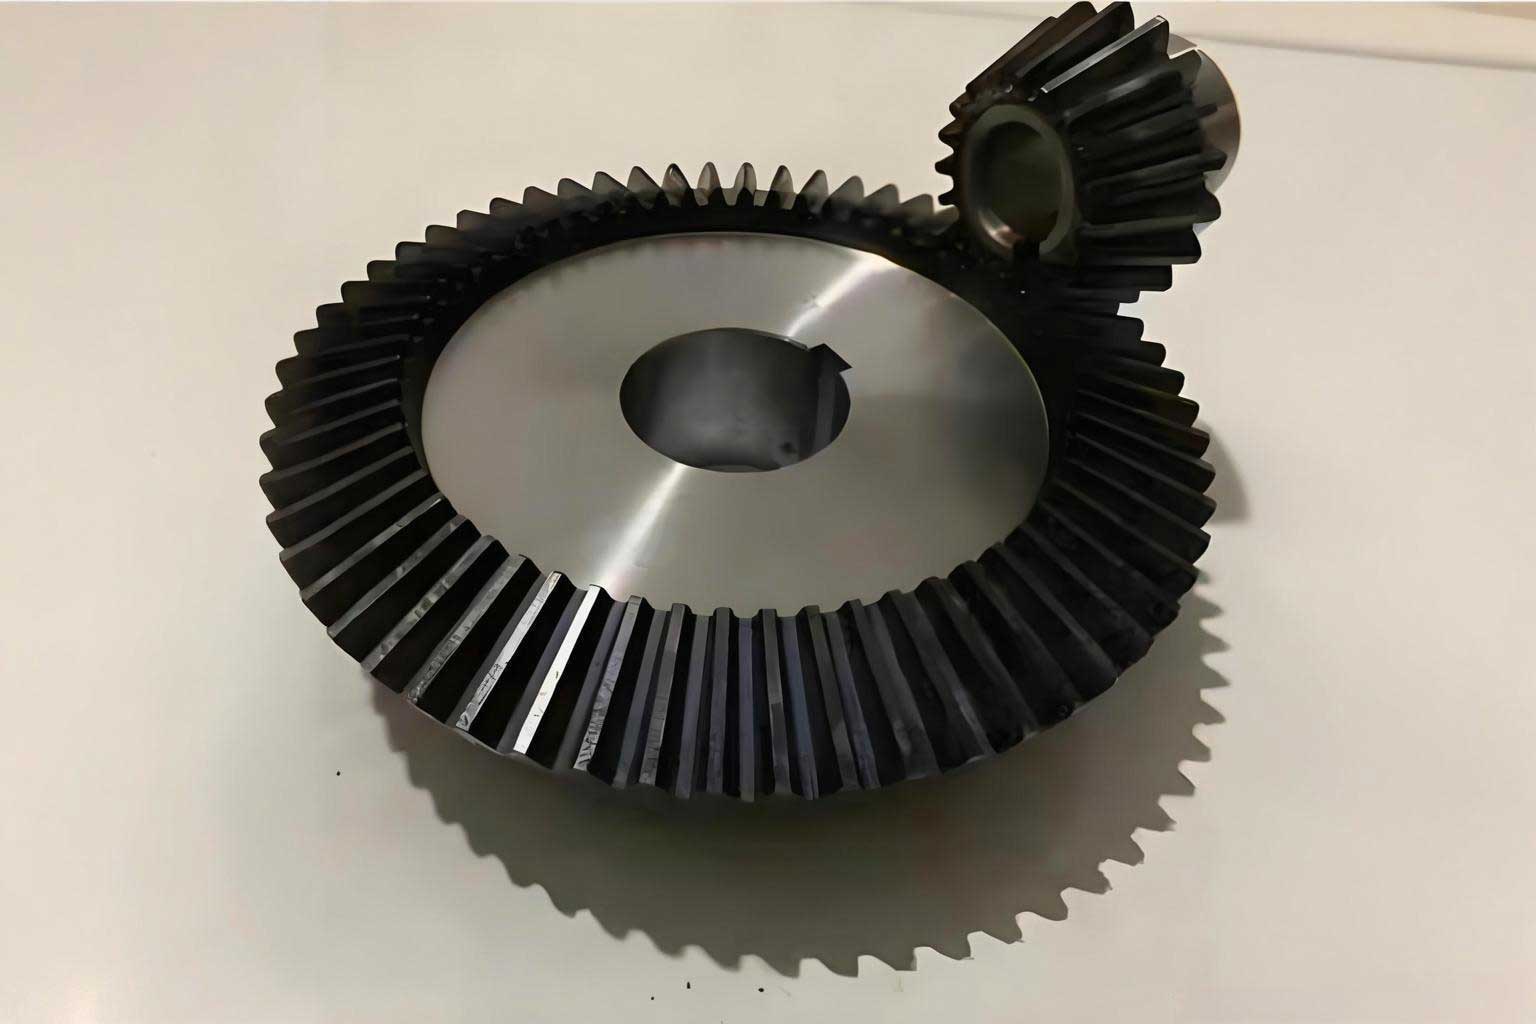
1. Study Scope and Miter Gear Configuration
I begin with a miter gear pair in which the driving miter gear has 21 teeth and the driven miter gear has 37 teeth. The normal module is 20 mm, the normal pressure angle is 20°, and the helix angle is 18°. The miter gear input speed is 1000 rpm, and the input torque is 5000 N·m. Because the miter gear consists of two symmetric helical sides, the left and right flanks must be analyzed simultaneously. The miter gear parameters used in my model are summarized below.
| Parameter | Driving Miter Gear | Driven Miter Gear |
|---|---|---|
| Number of teeth | 21 | 37 |
| Normal module | 20 mm | 20 mm |
| Normal pressure angle | 20° | 20° |
| Helix angle | 18° | 18° |
| Side arrangement | Left and right | Left and right |
| Input speed | 1000 rpm | — |
| Input torque | 5000 N·m | — |
For the miter gear, the transverse pressure angle is
$$ \alpha_t = \arctan\left(\frac{\tan \alpha_n}{\cos \beta}\right) $$
where \(\alpha_n\) is the normal pressure angle and \(\beta\) is the helix angle. The base pitch of the miter gear is
$$ P_b = \frac{\pi m_n \cos \alpha_t}{\cos \beta} $$
Using the miter gear parameters, I obtain a base pitch of approximately 46.7 mm. The end-face contact ratio and axial contact ratio are
$$ \varepsilon_\alpha = \frac{\overline{B_1B_2}}{P_b}, \qquad \varepsilon_\beta = \frac{b \sin \beta}{\pi m_n} $$
where \(\overline{B_1B_2}\) is the actual length of the line of action, and \(b\) is the face width of one side of the miter gear. The total contact ratio of one side of the miter gear is
$$ \varepsilon = \varepsilon_\alpha + \varepsilon_\beta $$
For my miter gear, the total contact ratio is 2.88. This means that at least two tooth pairs are in contact, and at some instants three tooth pairs participate in meshing. This high contact ratio is a principal reason why the miter gear can carry heavy loads, but it also means that the contact line length and load sharing change continuously.
| Quantity | Symbol | Value |
|---|---|---|
| Base pitch | \(P_b\) | 46.7 mm |
| Total contact ratio | \(\varepsilon\) | 2.88 |
| Minimum number of meshing pairs | — | 2 |
| Maximum number of meshing pairs | — | 3 |
| Maximum total contact line length | \(L_T\) | 0.31 m |
2. Meshing and Tooth Surface Contact of the Miter Gear
I describe the miter gear meshing process through a sequence of contact positions. For a single side of the miter gear, the position vector and unit normal vector of the tooth surface are expressed as
$$ \mathbf{r}_i = \mathbf{r}_i(u_i,\theta_i), \qquad \mathbf{n}_i = \frac{\frac{\partial \mathbf{r}_i}{\partial u_i}\times \frac{\partial \mathbf{r}_i}{\partial \theta_i}}{\left|\frac{\partial \mathbf{r}_i}{\partial u_i}\times \frac{\partial \mathbf{r}_i}{\partial \theta_i}\right|} $$
where \(i=1\) denotes the driving miter gear and \(i=2\) denotes the driven miter gear. When the two miter gear flanks are in contact, their position vectors and unit normal vectors must coincide in a common fixed reference frame. Thus,
$$ \mathbf{r}_{f1}(u_1,\theta_1,\phi_1)=\mathbf{r}_{f2}(u_2,\theta_2,\phi_2) $$
$$ \mathbf{n}_{f1}(u_1,\theta_1,\phi_1)=\mathbf{n}_{f2}(u_2,\theta_2,\phi_2) $$
where \(\phi_1\) and \(\phi_2\) are the rotation angles of the driving and driven miter gears. Because the normal vectors are unit vectors, the magnitude condition is
$$ \left|\mathbf{n}_{f1}(u_1,\theta_1,\phi_1)\right|=\left|\mathbf{n}_{f2}(u_2,\theta_2,\phi_2)\right|=1 $$
For edge contact of the miter gear, I add the following conditions:
$$ \mathbf{r}_{f1}(u_1,\theta_1,\phi_1)=\mathbf{r}_{f2}(u_2,\theta_2,\phi_2) $$
$$ \mathbf{n}_{f1}(u_1,\theta_1,\phi_1)=\mathbf{n}_{f2}(u_2,\theta_2,\phi_2) $$
$$ \mathbf{n}_{f1}\cdot \frac{\partial \mathbf{r}_{f1}}{\partial \theta_1}=0 $$
This formulation allows me to track the contact point along the miter gear meshing path and to obtain the geometric input required for the flash-temperature calculation.
3. Contact Line Length and Contact Ratio of the Miter Gear
For a single tooth of the miter gear, the contact line length passes through three stages. In the first stage, the contact begins as a point and grows into a line. In the second stage, both the front and rear portions of the tooth flank participate, and the contact line length remains constant. In the third stage, the contact line shortens and finally disappears. If \(L_x\) is the distance along the path of contact, then the contact line length in stage one is
$$ L_{T,1} = \frac{L_x}{\sin \beta_b} $$
where \(\beta_b\) is the base helix angle. In stage two, the contact line length is constant. In stage three, the contact line length is
$$ L_{T,3} = \frac{P_b \varepsilon_\beta – L_x}{\sin \beta_b} $$
For the miter gear, the total contact line length is the sum of the contact line lengths of all simultaneously meshing teeth. I calculate the total contact line length and find a periodic variation. The maximum total contact line length is approximately 0.31 m. Although each individual miter gear tooth has a changing contact line length, the sum over all meshing teeth becomes stable over certain intervals.
| Stage | Condition on \(L_x\) | Contact Line Length |
|---|---|---|
| Entry stage | \(0 \le L_x \le L_{b}\) | \(L_T = L_x / \sin \beta_b\) |
| Full contact stage | \(L_{b} < L_x \le L_{c}\) | \(L_T = \text{constant}\) |
| Exit stage | \(L_{c} < L_x \le L_{\max}\) | \(L_T = (P_b \varepsilon_\beta – L_x)/\sin \beta_b\) |
4. Local Contact Ellipse and Refined Grid of the Miter Gear
Under load, a point contact of the miter gear becomes a contact ellipse because of elastic deformation. I model the local contact region as an ellipse with major semi-axis \(a\) and minor semi-axis \(b\). According to Hertz contact theory,
$$ a = k_a \left[\frac{3F}{2E_c(A+B)}\right]^{1/3} $$
$$ b = k_b \left[\frac{3F}{2E_c(A+B)}\right]^{1/3} $$
where \(F\) is the normal load on the contact point, \(E_c\) is the equivalent elastic modulus, and \(A\) and \(B\) are curvature coefficients. The curvature coefficients satisfy
$$ A+B = C+D $$
$$ B-A = \sqrt{E^2+F^2+2EF\cos 2\gamma} $$
where \(C,D,E,F\) are combinations of the principal curvatures of the two miter gear flanks, and \(\gamma\) is the angle between the principal planes. The equivalent curvature radius at a contact point is
$$ \rho_M = \left(\frac{1}{\rho_{1M}}+\frac{1}{\rho_{2M}}\right)^{-1} $$
I divide the local contact ellipse into \(m \times n\) small rectangular cells. If \(dx=2a/m\) and \(dy=2b/n\), then the area of each cell is
$$ ds = dx\,dy $$
The load on each small cell is \(F_{ij}\), and the total load at the contact point is
$$ F_M = \sum_{i=1}^{m}\sum_{j=1}^{n} F_{ij} $$
| Grid Quantity | Expression | Description |
|---|---|---|
| Number of cells | \(m \times n\) | Discretization of local contact ellipse |
| Cell width | \(dx = 2a/m\) | Along major axis |
| Cell height | \(dy = 2b/n\) | Along minor axis |
| Cell area | \(ds = dx\,dy\) | Area of each small rectangle |
| Cell load | \(F_{ij}\) | Normal load on cell \((i,j)\) |
The relative sliding velocity of the miter gear at a contact point is obtained from the tangential velocities of the two flanks. The absolute velocity of the driving flank is
$$ \mathbf{v}_{1M} = \boldsymbol{\omega}_1 \times \mathbf{r}_{1M} $$
and the absolute velocity of the driven flank is
$$ \mathbf{v}_{2M} = \boldsymbol{\omega}_2 \times \mathbf{r}_{2M} $$
The tangential velocity components are
$$ \mathbf{v}_{t1M} = \mathbf{v}_{1M} – \left(\mathbf{v}_{1M}\cdot \mathbf{n}_M\right)\mathbf{n}_M $$
$$ \mathbf{v}_{t2M} = \mathbf{v}_{2M} – \left(\mathbf{v}_{2M}\cdot \mathbf{n}_M\right)\mathbf{n}_M $$
Thus, the relative sliding velocity of the miter gear is
$$ \mathbf{v}_c = \mathbf{v}_{t1M} – \mathbf{v}_{t2M} $$
I calculate the relative sliding velocity along the contact sequence and find that it first increases and then decreases. It is small near the pitch point and larger near the beginning and end of meshing.
5. Loaded Contact Analysis of the Miter Gear
For a loaded miter gear contact, the displacement compatibility condition at a discretized cell is
$$ u_{ij} + u’_{ij} + w_{ij} = u(x,y) + d_{ij} $$
where \(u_{ij}\) and \(u’_{ij}\) are the elastic deformations of the two mating flanks, \(w_{ij}\) is the initial gap before deformation, \(u(x,y)\) is the normal displacement, and \(d_{ij}\) is the residual gap after deformation. If the cell is in contact, then \(d_{ij}=0\) and \(F_{ij}>0\). If the cell is separated, then \(d_{ij}>0\) and \(F_{ij}=0\). The elastic deformation is
$$ u_{ij} = \sum_{i=1}^{m}\sum_{j=1}^{n} \eta_{ij} F_{ij} $$
$$ u’_{ij} = \sum_{i=1}^{m}\sum_{j=1}^{n} \eta’_{ij} F_{ij} $$
where \(\eta_{ij}\) and \(\eta’_{ij}\) are the bending-shear compliances of the driving and driven miter gear flanks. The total compliance is
$$ \lambda_{ij} = \eta_{ij} + \eta’_{ij} $$
For all contact cells of the miter gear, the compatibility equation can be assembled as
$$ [\lambda]_{\phi_1}[F]_{\phi_1} + [w]_{\phi_1} = [u]_{\phi_1} + [d]_{\phi_1} $$
For the left and right sides of the miter gear, the compatibility equations are
$$ [\lambda_L]_{\phi_1}[F_L]_{\phi_1} + [w_L]_{\phi_1} = [u_L]_{\phi_1} $$
$$ [\lambda_R]_{\phi_1}[F_R]_{\phi_1} + [w_R]_{\phi_1} = [u_R]_{\phi_1} $$
The load balance of the entire miter gear is
$$ \sum_{k=1}^{s} F_{ML}^{k} + \sum_{k=1}^{s} F_{MR}^{k} = F_n $$
where \(s\) is the number of meshing tooth pairs on one side, \(F_{ML}^{k}\) is the normal load on the left side, \(F_{MR}^{k}\) is the normal load on the right side, and \(F_n\) is the total normal load. The load distribution coefficient at a contact point is
$$ L_M^{k} = \frac{\sum_{i=1}^{m}\sum_{j=1}^{n} F_{ijL/R}^{k}}{F_n} $$
The load density at the center of a cell is
$$ w_{ij} = \frac{F_{ij}}{L_{i,j}} $$
where \(L_{i,j}\) is the length associated with the cell. These quantities are used directly in the flash-temperature calculation.
6. Support Deformation and Load Sharing of the Miter Gear
Support deformation and shaft misalignment can cause unequal load sharing between the left and right sides of the miter gear. The horizontal shaft angle error has the strongest influence on the miter gear contact state. When the left and right loads are unequal, an axial force difference appears:
$$ \Delta F_z = \sum_{k=1}^{s}\sum_{i=1}^{m}\sum_{j=1}^{n} F_{ijL}^{k}\cos\alpha_j – \sum_{k=1}^{s}\sum_{i=1}^{m}\sum_{j=1}^{n} F_{ijR}^{k}\cos\alpha_j $$
To avoid miter gear flank offset loading, I use an axially floating driving miter gear. The axial displacement is converted into a normal gap through
$$ w_{ijL/R}^{k} = w_{ijL/R}^{k} + \delta_n $$
where \(\delta_n\) is the normal component of the axial floating displacement. The iteration continues until
$$ \left|\frac{\Delta F_z}{F_n}\right| \le 0.01\% $$
When this condition is satisfied, the left and right miter gear flanks share the load evenly. The following table summarizes the load-sharing behavior under different alignment errors.
| Alignment Error | Left Load Coefficient | Right Load Coefficient | Axial Force Difference |
|---|---|---|---|
| 0° | Balanced | Balanced | ≈0 |
| 0.00094° | Slightly increased | Slightly decreased | Small |
| 0.00188° | Increased | Decreased | Moderate |
| 0.00376° | Strongly increased | Strongly decreased | Large |
| With floating driving miter gear | Nearly equal | Nearly equal | Within tolerance |
I compare the miter gear load distribution with the load distribution obtained by a standard method for a single helical gear. The results show that the miter gear left and right flank load coefficients are not always equal. Therefore, a single helical gear cannot be used as a direct equivalent of the miter gear when load sharing is important. The axially floating driving miter gear effectively suppresses offset loading and makes the left and right flash temperatures nearly identical.
7. Thermal Elastohydrodynamic Lubrication Model for the Miter Gear
I establish a point-contact thermal elastohydrodynamic lubrication model for the miter gear. The Reynolds equation for the miter gear contact is
$$ \frac{\partial}{\partial x}\left(\frac{\rho h^3}{12\eta}\frac{\partial p}{\partial x}\right) + \frac{\partial}{\partial y}\left(\frac{\rho h^3}{12\eta}\frac{\partial p}{\partial y}\right) = u_e \frac{\partial(\rho h)}{\partial x} + \frac{\partial(\rho h)}{\partial t} $$
where \(h\) is the film thickness, \(p\) is the pressure, \(\rho\) is the lubricant density, \(\eta\) is the lubricant viscosity, and \(u_e\) is the entrainment velocity. The film thickness equation is
$$ h = h_0 + \frac{x^2}{2R_x} + \frac{y^2}{2R_y} + V_e(x,y,t) $$
where \(h_0\) is the initial gap, \(R_x\) and \(R_y\) are the equivalent curvature radii, and \(V_e\) is the elastic deformation:
$$ V_e(x,y,t) = \frac{2}{\pi E’}\iint_\Omega \frac{p(\xi,\zeta)}{\sqrt{(x-\xi)^2+(y-\zeta)^2}}\,d\xi\,d\zeta $$
The density-pressure-temperature relation is
$$ \rho = \rho_0 \left[1 + \frac{0.6\times10^{-9}p}{1+1.7\times10^{-9}p} – 0.00065(T-T_0)\right] $$
The viscosity-pressure-temperature relation is
$$ \eta = \eta_0 \exp\left\{ (\ln\eta_0 + 9.67)\left[(1 + 5.1\times10^{-9}p)^{Z_0}\left(\frac{T-138}{T_0-138}\right)^{-S_0} – 1\right]\right\} $$
The load balance equation is
$$ w = \iint_\Omega p(x,y)\,dx\,dy $$
The energy equation for the lubricant film is
$$ \rho c_f \left(u\frac{\partial T}{\partial x} + v\frac{\partial T}{\partial y}\right) = k_f \frac{\partial^2 T}{\partial z^2} + \eta\left[\left(\frac{\partial u}{\partial z}\right)^2 + \left(\frac{\partial v}{\partial z}\right)^2\right] + \beta_T T\left(u\frac{\partial p}{\partial x} + v\frac{\partial p}{\partial y}\right) $$
where \(c_f\) is the specific heat of the lubricant, \(k_f\) is the thermal conductivity, and \(\beta_T\) is the thermal expansivity. The solid energy equations for the two miter gear flanks are
$$ \rho_1 c_1 \left(u_1\frac{\partial T_1}{\partial x} + v_1\frac{\partial T_1}{\partial y}\right) = k_1 \frac{\partial^2 T_1}{\partial z^2} $$
$$ \rho_2 c_2 \left(u_2\frac{\partial T_2}{\partial x} + v_2\frac{\partial T_2}{\partial y}\right) = k_2 \frac{\partial^2 T_2}{\partial z^2} $$
At the lubricant-solid interfaces, the heat flux continuity conditions are
$$ k_f \left.\frac{\partial T}{\partial z}\right|_{z=0} = k_1 \left.\frac{\partial T_1}{\partial z}\right|_{z=0} $$
$$ k_f \left.\frac{\partial T}{\partial z}\right|_{z=h} = k_2 \left.\frac{\partial T_2}{\partial z}\right|_{z=h} $$
I solve the thermal elastohydrodynamic lubrication equations for three representative positions of the miter gear: the inlet point, the pitch point, and the outlet point. The results are shown in the following table.
| Position | Pressure Behavior | Film Thickness Behavior | Temperature Behavior |
|---|---|---|---|
| Inlet point | Highest pressure peak | Smallest film thickness | Highest film temperature |
| Pitch point | Moderate pressure | Stable film thickness | Lowest temperature |
| Outlet point | Secondary pressure peak | Reduced film thickness | Temperature rises again |
The pressure distribution of the miter gear reaches its maximum near the contact ellipse center and forms a secondary peak near the outlet region. The film thickness decreases rapidly in the inlet region, remains stable in the Hertzian contact region, and slightly increases at the outlet. Because the left and right miter gear flanks share load almost equally in my axially floating design, their pressure and film thickness distributions are nearly identical.
8. Effects of Operating Conditions on Miter Gear Lubrication
I study the influence of torque and speed on the miter gear lubrication behavior. When the speed is fixed at 1000 rpm and the torque is increased, the film pressure increases, the film thickness decreases, and the central film temperature increases. The reason is that a higher torque increases the contact load and frictional heat generation. The following table summarizes the trend.
| Operating Variable | Film Pressure | Film Thickness | Central Film Temperature |
|---|---|---|---|
| Torque increases | Increases | Decreases | Increases |
| Speed increases at fixed torque | Almost unchanged | Slightly decreases | Increases |
| Surface roughness increases | Local fluctuations increase | Slightly decreases | Increases |
When the torque is fixed and the speed increases, the central pressure remains nearly unchanged. However, the secondary pressure peak moves toward the inlet region and becomes higher. Consequently, the film thickness decreases slightly, and the central film temperature rises. This trend indicates that the miter gear becomes more vulnerable to scuffing at higher speeds, especially when the load is also high.
9. Flash Temperature Model for the Miter Gear
The instantaneous contact temperature of the miter gear consists of the bulk temperature and the flash temperature. I calculate the flash temperature on the discretized contact ellipse. For each small cell, the flash temperature is
$$ T_{f,ij}^{k} = \frac{1.11 \mu_{mij}^{k} w_{ij}^{k} \left|V_{t1,ij}^{k} – V_{t2,ij}^{k}\right|}{\left(B_1\sqrt{V_{t1,ij}^{k}} + B_2\sqrt{V_{t2,ij}^{k}}\right)\sqrt{b_k}} $$
where \(\mu_{mij}^{k}\) is the local average friction coefficient, \(w_{ij}^{k}\) is the load density, \(V_{t1,ij}^{k}\) and \(V_{t2,ij}^{k}\) are the tangential velocities of the two miter gear flanks, and \(b_k\) is the contact half-width. The local friction coefficient is calculated from
$$ \mu_{mij}^{k} = 0.12 \left(w_{ij}^{k}\cos\alpha_n\right)^{0.25} \left(\frac{R_a}{a}\right)^{0.25} \left(\frac{\eta_a V_{\Sigma,ij}^{k}}{R_a}\right)^{0.25} $$
where \(R_a\) is the surface roughness, \(\eta_a\) is the lubricant dynamic viscosity at the bulk temperature, and \(V_{\Sigma,ij}^{k}\) is the sum of the tangential velocities. The thermal contact coefficients \(B_1\) and \(B_2\) are selected for surface-hardened miter gear flanks. I obtain the load density, tangential velocity, and contact half-width from the loaded contact analysis of the miter gear.
Using an input speed of 1000 rpm and an input torque of 5000 N·m, I calculate the miter gear flash temperature distribution. The left and right flank flash temperatures are nearly identical because the axially floating driving miter gear equalizes the load. The maximum flash temperature occurs at the beginning of meshing, where the equivalent curvature radius is small, the Hertzian contact stress is high, and the relative sliding velocity is large. At the pitch point, the flash temperature is small but not exactly zero because the miter gear flanks still deform under load. In my calculation, the pitch-point flash temperature is about 0.6°C. After the pitch point, the relative sliding velocity increases again, and the flash temperature rises again.
| Contact Position | Flash Temperature Behavior | Reason |
|---|---|---|
| Beginning of meshing | Maximum | Small curvature radius, high stress, large sliding velocity |
| Pitch point | Minimum but not zero | Sliding velocity near zero, but elastic deformation remains |
| End of meshing | Moderate | Curvature radius is larger, but sliding velocity increases again |
10. Validation of the Miter Gear Flash Temperature Calculation
To verify my miter gear flash-temperature method, I compare the result with a commercial transmission simulation, a thermal elastohydrodynamic lubrication solution, and a standard calculation method. The comparison is performed for the left flank of the miter gear under the same speed and torque. The results are listed below.
| Method | Inlet Temperature | Pitch-Point Temperature | Outlet Temperature |
|---|---|---|---|
| My miter gear flash-temperature model | 102°C | 0.6°C | 45°C |
| Commercial simulation | 96°C | 0°C | 43°C |
| Thermal elastohydrodynamic lubrication | 108°C | Not zero | 48°C |
| Standard calculation | 98°C | 0°C | 42°C |
The difference between my miter gear flash-temperature model and the thermal elastohydrodynamic lubrication result is about 6°C at the inlet and about 3°C at the outlet. The difference from the commercial simulation is about 6°C at the inlet and about 2°C at the outlet. The difference from the standard calculation is about 4°C at the inlet and about 3°C at the outlet. These differences are small. In addition, the pitch-point temperature in my miter gear model is close to that of the thermal elastohydrodynamic lubrication solution, and both are nonzero, while the standard calculation and the commercial simulation give zero at the pitch point. This is because the thermal elastohydrodynamic lubrication and my loaded contact model include squeezing and elastic deformation effects. Therefore, I consider the miter gear flash-temperature method to be reliable.
11. Parametric Study of Miter Gear Flash Temperature
I study the influence of torque, speed, and surface roughness on the miter gear flash temperature. First, with the speed fixed at 1000 rpm, I change the torque to 3000 N·m, 5000 N·m, and 10000 N·m. The maximum flash temperature increases from about 70°C to 102°C and then to 171°C. This shows that torque has a strong effect on the miter gear flash temperature because a higher torque increases the contact load density and friction coefficient.
Second, with the torque fixed at 5000 N·m, I change the speed to 1000 rpm, 2000 rpm, and 3000 rpm. The maximum flash temperature increases from about 102°C to 118°C and then to 131°C. Thus, speed also has an important influence on the miter gear flash temperature, although the effect is less dramatic than that of torque under the conditions I examined.
Third, I examine the effect of surface roughness. For surface roughness values of 0.3 μm, 0.5 μm, and 0.8 μm, the miter gear flash temperature increases as the surface roughness increases. A rougher surface increases the friction coefficient and the frictional heat generation. The increase is especially rapid near the beginning of meshing.
| Parameter | Values Studied | Maximum Flash Temperature Trend |
|---|---|---|
| Torque at 1000 rpm | 3000, 5000, 10000 N·m | 70°C → 102°C → 171°C |
| Speed at 5000 N·m | 1000, 2000, 3000 rpm | 102°C → 118°C → 131°C |
| Surface roughness | 0.3, 0.5, 0.8 μm | Increases with roughness |
12. Scuffing Check for the High-Speed Heavy-Load Miter Gear
I use the maximum contact temperature criterion to check the scuffing risk of the miter gear. The maximum contact temperature is
$$ T_{\max} = T_M + T_f \le T_S $$
where \(T_M\) is the bulk temperature of the miter gear, \(T_f\) is the flash temperature, and \(T_S\) is the critical scuffing temperature. The critical scuffing temperature can be estimated from the kinematic viscosity of the lubricant at 40°C:
$$ T_S = 26.2 \ln(v_{40}) $$
I select a lubricant with a kinematic viscosity of 327 mm²/s at 40°C. The calculated critical scuffing temperature is about 152°C. For the miter gear operating at 1000 rpm and 5000 N·m, the maximum contact temperature exceeds the critical value. The most dangerous location is the beginning of meshing, where the equivalent curvature radius is small, the contact pressure is high, and the relative sliding velocity is large. This location should be the focus of tooth flank modification and scuffing prevention.
| Case | Speed | Torque | Maximum Contact Temperature | Critical Temperature | Scuffing Risk |
|---|---|---|---|---|---|
| Case 1 | 1000 rpm | 3000 N·m | Below critical | 152°C | Low |
| Case 2 | 1000 rpm | 5000 N·m | Above critical | 152°C | High |
| Case 3 | 2000 rpm | 5000 N·m | Above critical | 152°C | High |
The scuffing check shows that the miter gear can approach the critical scuffing temperature under heavy load, even when the speed is moderate. The inlet region is the most critical because the flash temperature is highest there. Therefore, reducing the inlet flash temperature is essential for improving the scuffing resistance of the miter gear.
13. Conclusions from My Miter Gear Study
I have developed a coupled contact, lubrication, and flash-temperature model for a miter gear transmission. The main conclusions are as follows. First, the miter gear has a total contact ratio of 2.88, so at least two tooth pairs and sometimes three tooth pairs carry the load. The total contact line length varies periodically, with a maximum of about 0.31 m. Second, the local contact ellipse of the miter gear can be discretized into small cells. The load distribution coefficient and load density are obtained from the loaded contact analysis. Third, support deformation can cause uneven load sharing between the left and right sides of the miter gear. An axially floating driving miter gear equalizes the left and right loads and makes the flash temperatures nearly identical. Fourth, the thermal elastohydrodynamic lubrication results show that the inlet region has the highest pressure and the smallest film thickness. The film temperature increases with torque and speed. Fifth, the flash temperature of the miter gear is highest at the beginning of meshing. The calculated results agree well with a commercial simulation, a thermal elastohydrodynamic lubrication solution, and a standard calculation. Sixth, the miter gear flash temperature increases significantly with torque, speed, and surface roughness. The maximum contact temperature can exceed the critical scuffing temperature under high-speed and heavy-load conditions. Therefore, the inlet region of the miter gear should be prioritized in tooth flank modification and lubrication design.
In my future work, I will further study the miter gear flash temperature under transient dynamic loads, include three-dimensional thermal deformation, and optimize the miter gear tooth flank modification to reduce the maximum contact temperature. I will also perform experimental validation of the miter gear flash temperature and scuffing behavior. These extensions will help improve the reliability and service life of miter gear transmissions in high-speed and heavy-load applications.