
The manufacturing of precision gear shafts is a cornerstone of modern power transmission systems. The typical post-heat treatment finishing process for these components often involves multiple grinding operations on dedicated Computer Numerical Control (CNC) grinding machines. Historically, the loading and unloading of these gear shafts onto the machine tools have been manual tasks. This reliance on human labor introduces several critical inefficiencies: it is labor-intensive, prone to inconsistencies, and a significant source of work-in-process damage due to handling errors. In an era of increasing labor costs and heightened demands for quality and throughput, this operational model has become a bottleneck. This article explores the design and implementation of a fully automated grinding cell centered around an industrial robot, presenting a solution that enhances productivity, ensures consistent quality, and reduces operational costs for the finishing of gear shafts.
The core challenge addressed here is the automation of the material handling sequence between multiple machining centers. The proposed system architecture utilizes a single six-axis articulated industrial robot to service two CNC grinding machines and a centralized feeding station. This arrangement maximizes the return on investment for the robotic asset by keeping it utilized across multiple processes. The system integrates Programmable Logic Controllers (PLCs) for overarching coordination, Human-Machine Interface (HMI) panels for monitoring and control, and specialized end-of-arm tooling (EOAT) designed explicitly for handling gear shafts. The design philosophy prioritizes not only automation but also flexibility to accommodate different part families with minimal changeover time.
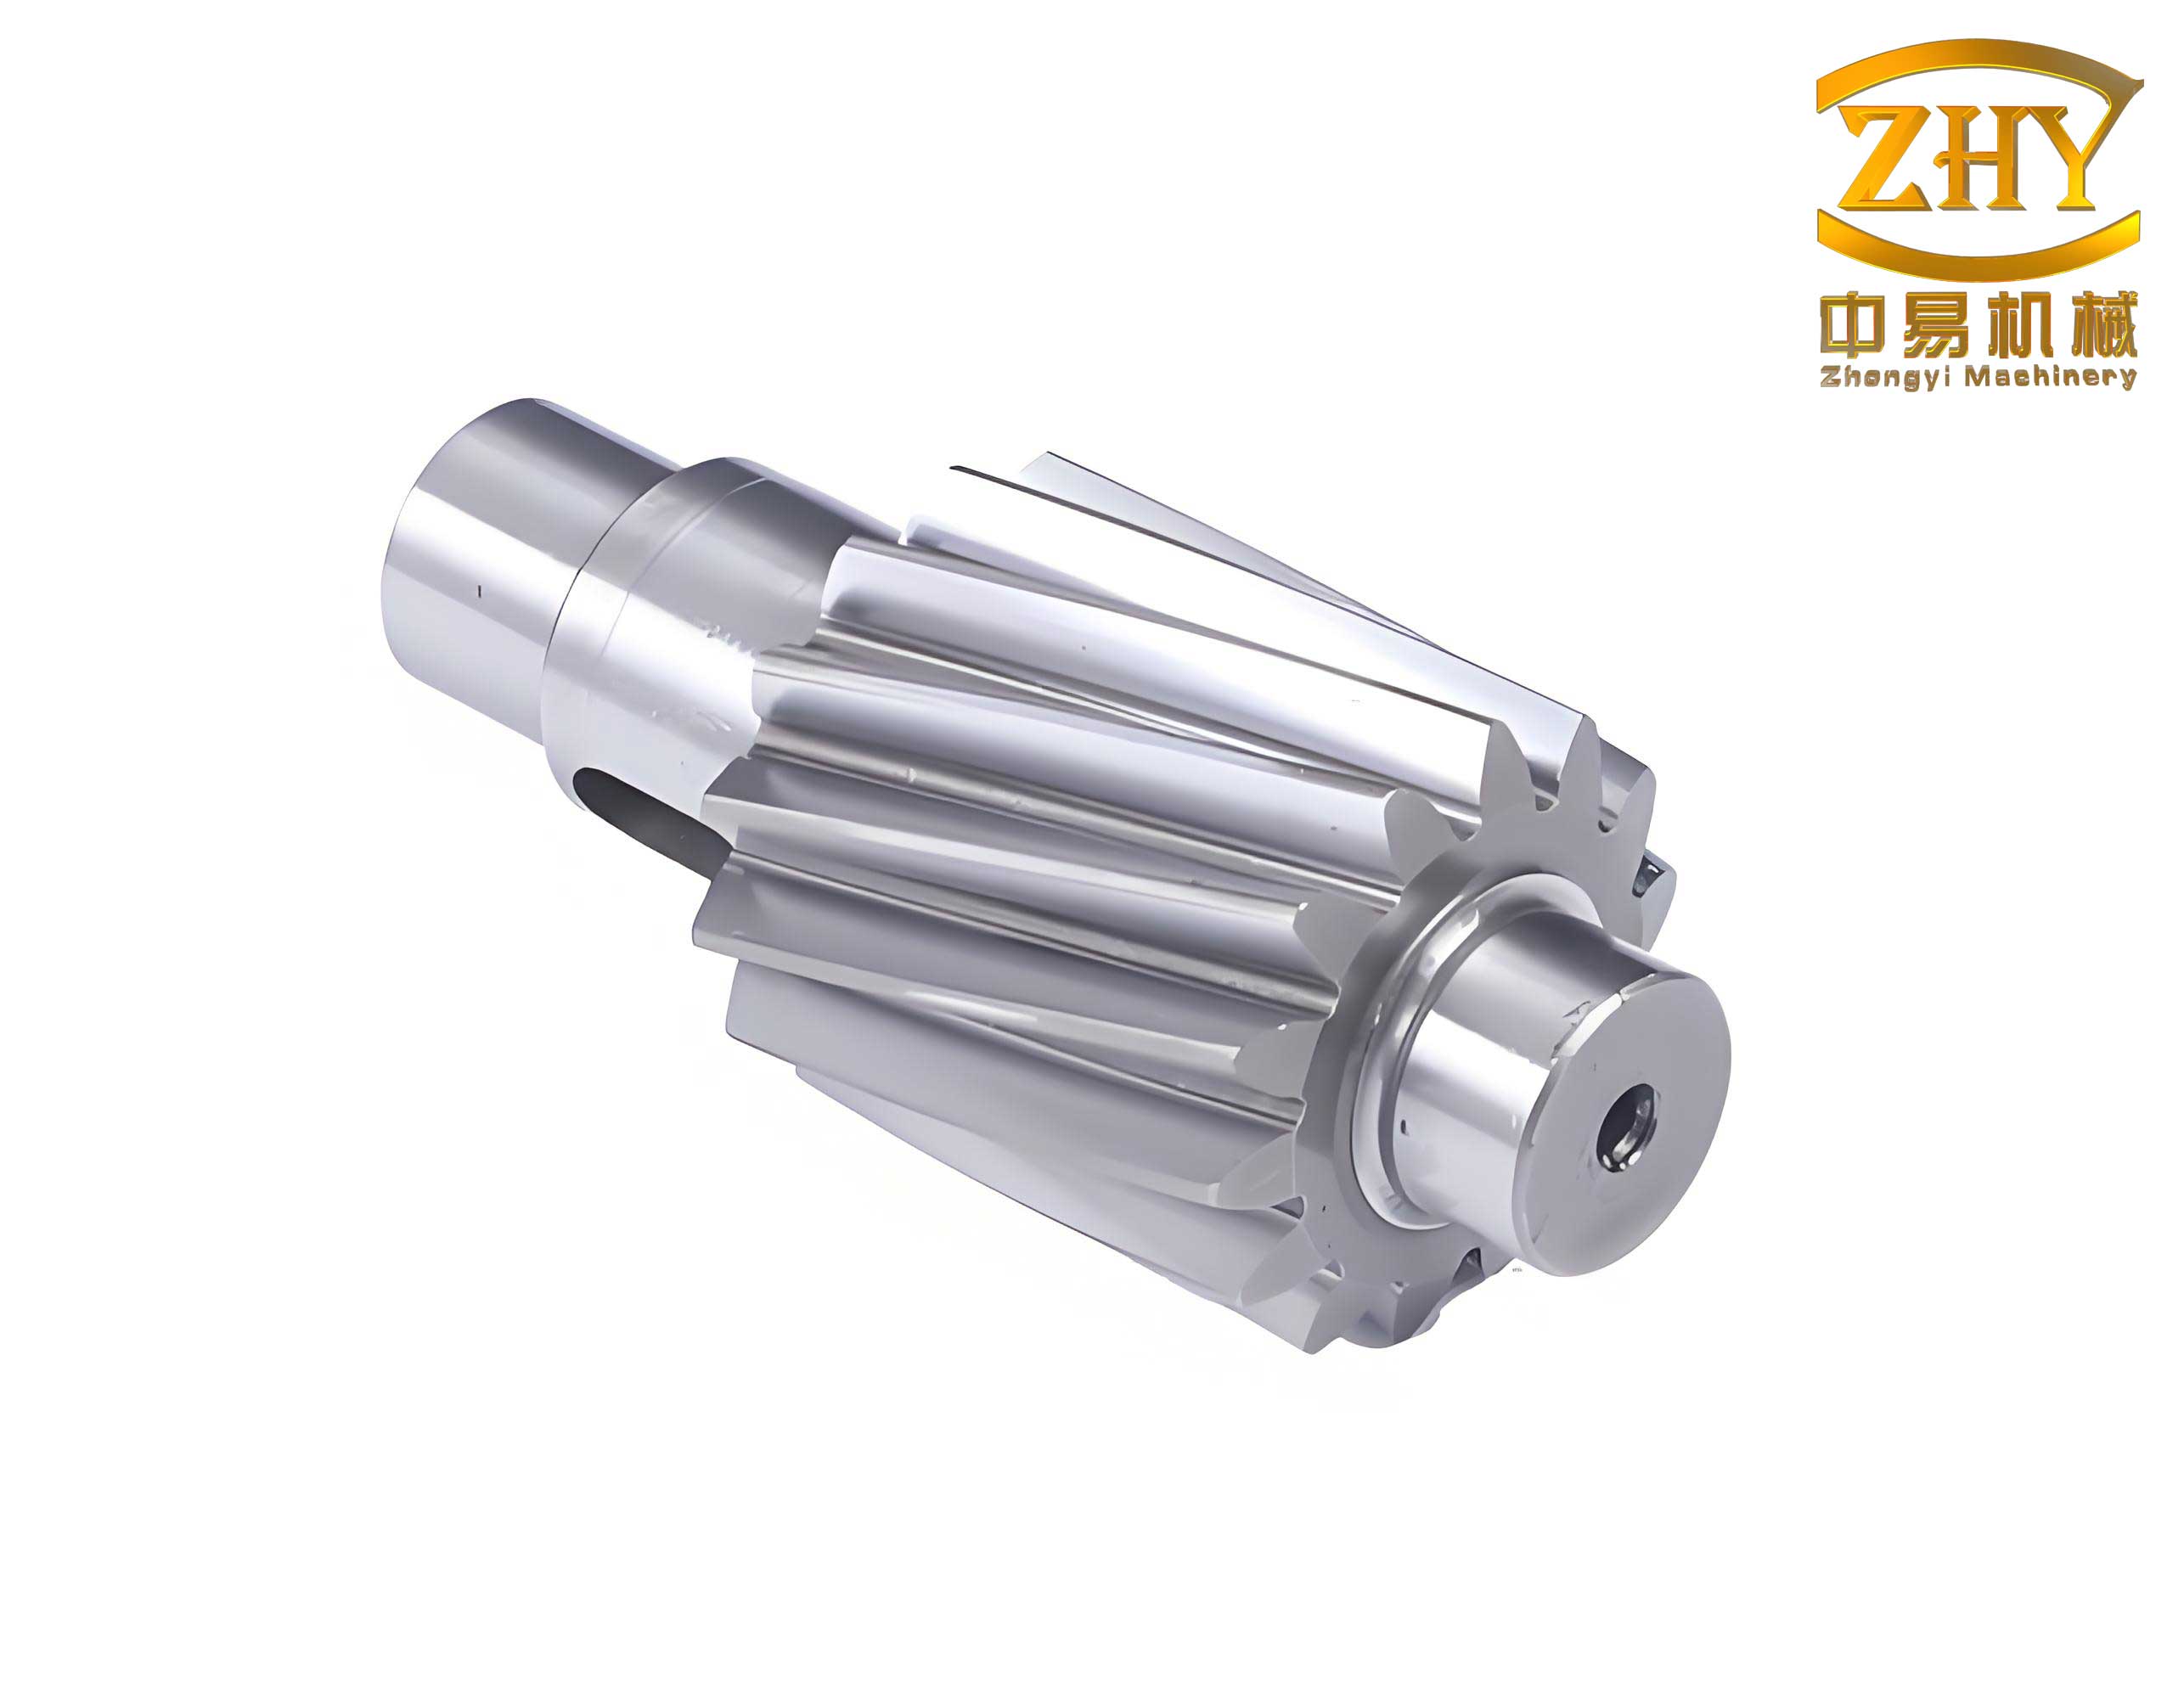
The grinding of gear shafts typically targets critical functional surfaces such as bearing journals, gear profiles, and thrust faces. Post-heat treatment, these components require high-precision grinding to achieve stringent tolerances for diameter, roundness, surface finish, and geometric relationships. Manual handling between operations not only limits the cycle time potential but also introduces risks of nicks, dents, and misalignment during loading, directly impacting the final product’s quality and reliability. Furthermore, the repetitive nature of the task makes it unsuitable for skilled labor, leading to high turnover and training costs. An automated robotic cell directly confronts these issues by performing highly repeatable pick-and-place motions with sub-millimeter accuracy, eliminating human variability and handling damage.
System Architecture and Layout Design
The automated grinding cell is designed as a closed, coordinated system. The physical layout is critical for optimizing the robot’s reach, minimizing cycle time, and ensuring safety. The two CNC grinding machines are positioned facing each other in a parallel arrangement. A multi-axis industrial robot is located centrally between them, within its operational work envelope. A dedicated feeding station, or “feeder,” equipped with programmable lifting and conveying mechanisms, is positioned at one end of the cell to manage the inflow of raw gear shafts and the outflow of finished ones. This “triangular” or “U-shaped” layout is space-efficient and allows the robot to pivot between stations with minimal wasted motion. Safety fencing with interlocked access gates encloses the entire cell, isolating the automated processes from human operators during normal production.
The control system hierarchy is architected for robustness and clear communication. A central PLC acts as the master controller, orchestrating the entire production sequence. It communicates via discrete I/O signals and industrial communication protocols (e.g., PROFINET, EtherNet/IP) with the subsystems:
- CNC Grinding Machines: The PLC receives signals indicating machine status (e.g., “cycle complete,” “door open,” “fixture ready”) and sends commands to start the grinding cycle or reset the machine.
- Industrial Robot: Communication is typically established via a fieldbus or TCP/IP socket. The PLC sends high-level commands (e.g., “Execute Program 1: Load Machine A”) and receives status updates (e.g., “Program completed,” “Gripper error”).
- Feeding Station: The PLC controls the conveyor belts, lift mechanisms, and part presence sensors to ensure a steady supply of gear shafts at the correct pickup location.
- Human-Machine Interface (HMI): A touchscreen panel connected to the PLC provides operators with system status, production counts, error messages, and manual control functions for maintenance and setup.
The workflow of the cell is a precisely choreographed sequence. A pallet or container holding multiple raw gear shafts is delivered to the feeder. The feeder presents them in a known, accessible orientation. The robot, equipped with a dual-gripper EOAT, initiates the following continuous loop:
- Pick a raw gear shaft from the feeder with Gripper 1.
- Load it into the fixture of Grinding Machine A.
- Pick another raw gear shaft from the feeder with Gripper 2.
- Wait for Machine A to complete its cycle.
- Unload the finished part from Machine A with the now-empty Gripper 1 while simultaneously loading the raw part from Gripper 2 into Machine A.
- Transport the finished part from Machine A to Grinding Machine B and load it.
- Return to the feeder to pick the next raw part, repeating the cycle. When Machine B finishes, the robot unloads the fully ground gear shaft and places it in an output pallet on the feeder.
This overlapping sequence minimizes machine idle time, as one machine is often being serviced while the other is cutting.
Robotic Component Specification and End-Effector Design
The selection of the industrial robot is governed by payload, reach, repeatability, and speed requirements. For handling typical gear shafts, a payload capacity of 7-10 kg is usually sufficient. The reach must encompass the pickup point at the feeder, the chucks/fixtures of both grinding machines, and any intermediate safe positions. High repeatability (e.g., ±0.05 mm) is essential for precise loading into machine fixtures. A six-axis articulated robot provides the necessary dexterity to orient the part correctly for loading. Based on these parameters, a robot like the Stäubli TX90 is an exemplary fit, with key specifications summarized below:
| Parameter | Specification |
|---|---|
| Maximum Payload | 20 kg |
| Nominal Payload (for this application) | 7 kg |
| Maximum Reach | 1000 mm |
| Number of Axes | 6 |
| Repeatability | ± 0.03 mm |
| Control System / Programming Language | VAL3 |
The end-effector is a custom-designed tool critical to the system’s efficiency. For handling gear shafts, a dual-gripper mechanism is optimal. This design features two independent, parallel-jaw grippers mounted on a common base plate attached to the robot’s wrist. The jaws are actuated by pneumatic cylinders with magnetic sensors to confirm “open” or “closed” states. The gripping surfaces are lined with a non-marring material like polyurethane or Vespel to protect the finely ground surfaces of the gear shafts. The key advantage of the dual-gripper is the ability to perform a “swap” operation at a machine: one gripper removes the finished part while the other holds the next raw part, ready for immediate insertion. This eliminates an entire robot trip to and from a buffer location, significantly reducing non-productive time. The kinematic transformation for positioning each gripper is handled within the robot’s controller, referencing a common tool center point (TCP). The position of Gripper 2 relative to Gripper 1 is defined by a fixed offset transform $T_{offset}$:
$$ TCP_{Gripper2} = TCP_{Gripper1} \cdot T_{offset} $$
where $T_{offset}$ contains the translational and rotational offsets between the two grippers.
Process Simulation and Cycle Time Optimization
To validate the design and predict throughput, discrete-event simulation and kinematic modeling are employed. The robot’s motion between all critical points—feeder pickup, Machine A load/unload, Machine B load/unload, and safe “via” points—is programmed and simulated. The goal is to minimize the total cycle time $T_{cycle}$, which is the time to complete one full sequence producing one finished gear shaft. $T_{cycle}$ is constrained by the slowest of three parallel processes: the robot’s material handling time $T_{robot}$, the grinding cycle time of Machine A $T_{grindA}$, and the grinding cycle time of Machine B $T_{grindB}$.
$$ T_{cycle} = \max(T_{robot}, T_{grindA}, T_{grindB}) $$
For the system to be balanced and efficient, the robot’s work should be completed before the machines finish their cycles. A detailed time-motion study breaks down $T_{robot}$:
| Robot Task Segment | Estimated Time (s) | Description |
|---|---|---|
| Move: Feeder to Machine A | 2.5 | Approach path for loading raw part. |
| Load/Unload Swap at Machine A | 4.0 | Complex coordinated move to exchange parts. |
| Move: Machine A to Machine B | 3.0 | Transport finished part from A to B. |
| Load Part into Machine B | 3.0 | Precise insertion into second fixture. |
| Move: Machine B to Feeder | 2.5 | Return to pickup next raw part. |
| Pick from Feeder | 2.0 | Acquire new raw gear shaft. |
| Total $T_{robot}$ (Estimated) | 17.0 | Sum of all handling segments. |
If $T_{grindA}$ and $T_{grindB}$ are each approximately 20 seconds, then $T_{cycle}$ is dominated by the grinding time at ~20 seconds, and the robot has ~3 seconds of idle time per cycle, indicating a well-balanced cell. The robot’s path is optimized by adjusting via points and velocities. Joint trajectories are planned to minimize acceleration-induced vibrations, which is crucial for final positioning accuracy when placing a gear shaft. The inverse kinematics solution for a 6-axis robot to reach a desired position and orientation $P_{desired}$ (in the world frame) is given by:
$$ \vec{\theta} = IK(T_{base}^{-1} \cdot P_{desired} \cdot T_{tool}^{-1}) $$
where $\vec{\theta}$ is the vector of joint angles, $T_{base}$ is the transformation from world to robot base, and $T_{tool}$ is the transformation from the robot flange to the TCP.
Error Budgeting and Quality Assurance Integration
A critical advantage of robotic automation is the dramatic improvement in consistency. However, potential error sources must be quantified. The final placement accuracy of a gear shaft in the machine fixture is a composite of several factors:
$$ E_{total} = \sqrt{E_{robot}^2 + E_{tooling}^2 + E_{part}^2 + E_{fixture}^2} $$
Where:
- $E_{robot}$: The robot’s repeatability (e.g., ±0.03 mm).
- $E_{tooling}$: Wear and deflection in the gripper jaws.
- $E_{part}$: Diameter tolerance of the raw gear shaft blank.
- $E_{fixture}$: Accuracy and clearance of the machine tool’s chuck or center.
By controlling these variables, the $E_{total}$ can be kept well within the permissible loading tolerance for grinding, often as tight as 0.02 mm. Furthermore, the system can be integrated with in-process or post-process gauging. A simple implementation involves a touch probe on the robot or a dedicated gauge in the cell. After loading a gear shaft, the robot can command a probe to check a critical dimension before initiating the grind, providing 100% inspection and preventing the machining of out-of-spec blanks.
Rapid Changeover for Different Gear Shaft Families
Manufacturing cells must handle product variety. The system is designed for rapid changeover between different families of gear shafts, which may vary in length, diameter, and shaft step configuration. This flexibility is achieved through:
- Quick-Change Tooling: The dual-gripper EOAT is mounted via a pneumatic or manual quick-change coupling on the robot flange. Different gripper sets for different part families can be swapped in minutes.
- Program Management: The robot controller stores separate programs for each part number. These programs contain the specific pickup points, approach angles, and gripper actuation commands.
- Feeder Adaptability: The feeding station uses adjustable fences and locators to accommodate different pallet or container sizes for various gear shafts.
- PLC Recipe System: The master PLC uses a recipe-based approach. An operator selects the part number on the HMI, and the PLC automatically calls the corresponding robot program, sets feeder parameters, and loads the correct CNC part programs to the grinding machines.
The changeover time $T_{changeover}$ can be modeled as:
$$ T_{changeover} = T_{mech} + T_{prog} + T_{verify} $$
where $T_{mech}$ is mechanical adjustment time, $T_{prog}$ is software/program loading time, and $T_{verify}$ is time for a first-part verification run.
Economic Justification and Performance Metrics
The implementation of an automated robotic grinding cell for gear shafts is justified by a clear return on investment (ROI) analysis. The primary cost drivers are the robot, EOAT, safety fencing, PLC control system, and system integration engineering. The savings and benefits are multifaceted:
| Cost/Saving Category | Impact |
|---|---|
| Labor Reduction | Eliminates 1-2 dedicated operators per shift. Direct savings on wages, benefits, and training. |
| Scrap & Rework Reduction | Near-elimination of handling damage (nicks, dents) reduces scrap rate significantly. |
| Productivity Increase | 24/7 operation capability and reduced machine idle time increase overall equipment effectiveness (OEE). |
| Quality Consistency | Reduced process variation leads to higher Cp/Cpk values, fewer customer returns. |
| Work-in-Process (WIP) Reduction | Tight coupling of operations reduces batch sizes and queue times. |
The annual savings $S_{annual}$ can be approximated as:
$$ S_{annual} = (N_{operators} \times C_{labor}) + (R_{scrap\_old} – R_{scrap\_new}) \times V_{part} \times Q + \Delta OEE \times V_{throughput} $$
where $C_{labor}$ is annual labor cost per operator, $R_{scrap}$ is scrap rate, $V_{part}$ is part value, $Q$ is annual quantity, and $\Delta OEE$ is the improvement in Overall Equipment Effectiveness.
A typical payback period for such a system, considering the aforementioned benefits, often falls between 12 to 24 months. Beyond the quantitative metrics, the strategic benefits of increased production flexibility, better data collection for traceability, and the ability to redeploy human workers to more value-added tasks like supervision, maintenance, and quality control are substantial.
Conclusion and System Evolution
The design and implementation of an automated robotic cell for grinding gear shafts represent a significant leap forward in manufacturing technology for this critical component. By integrating an industrial robot as the material handling core, synchronizing it with multiple CNC grinders and a smart feeder via a central PLC, a highly efficient, precise, and flexible manufacturing node is created. The system directly addresses the core challenges of labor dependency, quality inconsistency, and suboptimal equipment utilization prevalent in manual operations.
The success of such a system hinges on meticulous design in several areas: the ergonomic cell layout minimizing robot motion waste, the custom dual-gripper EOAT enabling efficient part swapping, the robust communication protocol ensuring seamless machine coordination, and the software architecture allowing for rapid changeover. The economic analysis confirms its viability, with a strong ROI driven primarily by labor savings and quality improvement.
Future evolution of such systems points towards even greater integration and intelligence. The next generation could incorporate machine vision for random bin picking of gear shafts, eliminating the need for precise feeder palletizing. Advanced force-torque sensing on the robot wrist could allow for compliant insertion and real-time quality checks during loading. Furthermore, integration with a factory-wide Manufacturing Execution System (MES) would enable dynamic production scheduling, predictive maintenance based on robot and machine performance data, and complete digital traceability for every gear shaft produced. The automated robotic grinding cell, therefore, is not merely a replacement for manual labor but a foundational step towards the data-driven, agile, and highly efficient smart factory of the future.