
In recent years, the demand for high-performance miter gear transmission systems has increased significantly in aerospace, large ships, and heavy machinery. A miter gear, also known as a double helical gear or herringbone gear, has a compact structure, large transmission torque, stable transmission ratio, and no additional axial force. These characteristics make the miter gear an excellent choice for high-load and high-speed applications. However, modern industrial development requires even higher transmission performance. To improve the meshing state and reduce vibration and noise, I investigate the modification design of the miter gear tooth surface. Gear statics is the foundation of gear transmission research. By applying appropriate modification measures, I can improve the static characteristics and applicability of the miter gear.
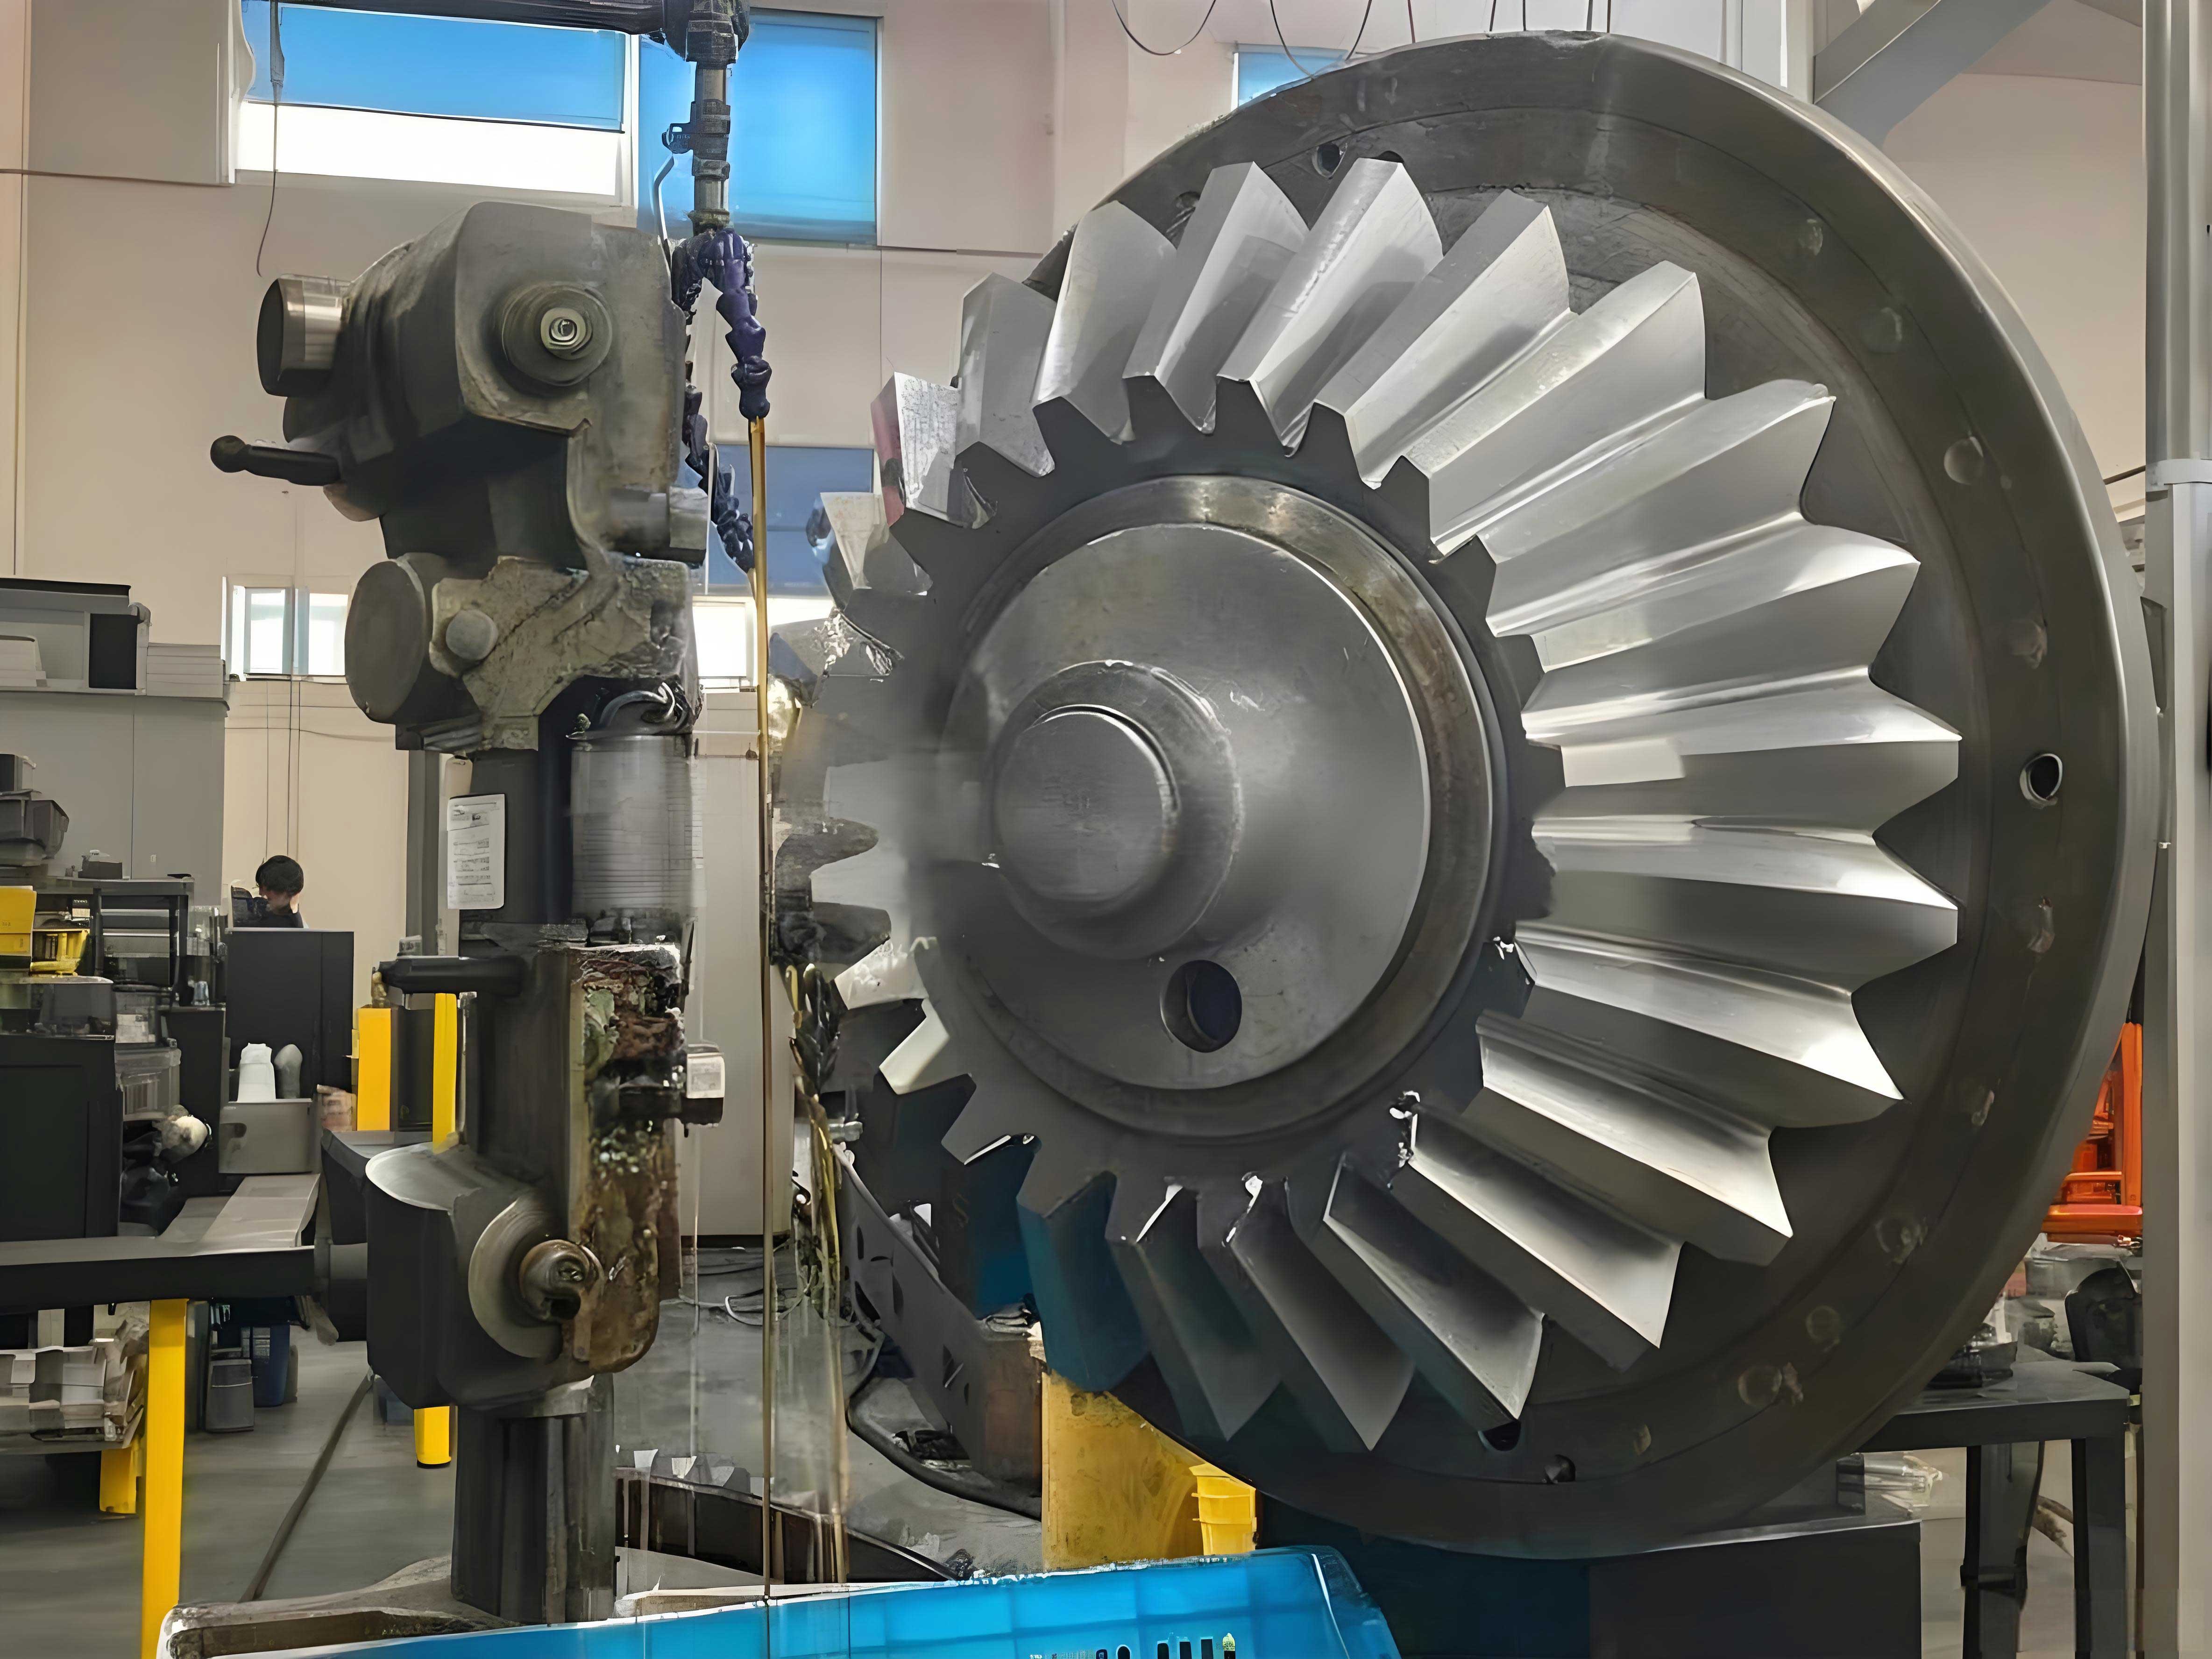
I base my research on modification theory and use ROMAX software to analyze the static characteristics and modification sensitivity of the miter gear. The main research contents are as follows. First, I determine the modification method as topological modification, the modification algorithms as the Monte Carlo method and the genetic algorithm, and the modification curve as a quadratic parabola. Second, because the studied miter gear is a combined gear with small tooth space width, large support stiffness, high installation accuracy, and high symmetry, the left and right tooth surfaces of the miter gear have symmetric load distribution. When modeling and loading this miter gear pair, I can build a corresponding helical gear model and apply half of the torque. I obtain stress bar charts, safety factor bar charts, transmission error curves, unit length normal load distribution diagrams, and contact stress distribution diagrams under various working conditions before and after modification. Third, I conduct sensitivity analysis on three groups of optimal profile modification data, three groups of optimal lead modification data, and one group of optimal topological modification data. Fourth, I measure the transmission error amplitude of the standard tooth surface using a built test rig and compare it with the transmission error amplitude calculated by ROMAX software.
The miter gear has been applied in many fields. In the automotive industry, the miter gear is used in gearboxes because of its smooth transmission and large torque capacity. In petroleum machinery, the miter gear is used in twin-screw pumps, which improves working reliability and efficiency. In defense industries, the miter gear is used in ship propulsion systems because of its high load capacity and reliability. In aircraft engines, the miter gear is used in planetary reduction mechanisms, replacing traditional dual-rotor turbofan engines and achieving energy saving, emission reduction, and noise reduction. However, the design and manufacture of the miter gear remain difficult, which directly restricts the development of national defense industries. The miter gear operates at very high speeds and carries heavy loads, so it generates large vibrations during transmission. These vibrations reduce the stability of the miter gear transmission and produce additional periodic alternating stresses, leading to gear failures such as scoring, tooth breakage, and plastic deformation. Moreover, the transmission error amplitude of the miter gear causes excessive noise, which greatly affects transmission stability and reliability.
Gear modification is an important method to improve the transmission performance of the miter gear. Therefore, reasonable modification of the miter gear can reduce vibration and noise, effectively control contact stress distribution, reduce transmission error variation, and decrease fatigue damage of the gear transmission system. My research aims to improve the tooth surface transmission performance and analyze the sensitivity of modification, thereby enhancing the reliability and applicability of miter gear modification.
Modification Theory for the Miter Gear
Gear modification is a method of removing tooth surface material to reduce interference during the meshing process and improve the meshing capability of the miter gear. Based on the modification direction, gear modification can be divided into profile modification, lead modification, and topological modification. Profile modification includes root relief and tip relief. Lead modification includes crowning and end relief. Topological modification is the simultaneous modification of both profile and lead directions. In this research, I choose topological modification for the miter gear because it combines the advantages of profile modification and lead modification.
The principle of profile modification is as follows. In the profile direction, the load distribution on the meshing tooth surface changes during the meshing process. In the double-tooth meshing region, the load is relatively small, while in the single-tooth meshing region, the load is large. When the miter gear enters and exits meshing, the load changes, producing vibration and noise. Profile modification removes material from the interference region to reduce the elastic deformation of the meshing teeth and improve the stability of the transmission system. Therefore, I perform tip relief and root relief on the pinion of the miter gear.
The principle of lead modification is as follows. In the lead direction, a standard miter gear without deformation would have a completely uniform load distribution on the meshing tooth surface. In reality, however, deformation of the housing, deformation of the bearings, and changes in the shaft deflection cause the miter gear to deviate from the theoretical meshing position. This leads to interference during tooth surface contact, uneven load distribution, and insufficient contact. To reduce interference and improve tooth surface conformity, I apply lead modification to the miter gear.
The principle of topological modification is as follows. In both the profile and lead directions, a standard tooth surface miter gear simultaneously experiences meshing impact and uneven load distribution. Topological modification can reduce the dynamic load at meshing entry and exit and improve the uneven load distribution. Therefore, I use topological modification in my research.
The modification curve determines how the modification amount varies along the profile or lead direction. Common modification curves include straight lines, circular arcs, and quadratic parabolas. Straight line modification produces a large concentrated stress. Circular arc modification is smoother than straight line modification. Quadratic parabola modification can effectively reduce stress concentration and has good tolerance to installation errors, thereby reducing vibration and noise during miter gear operation. Because ROMAX software provides a quadratic parabola modification curve, I choose the quadratic parabola as the modification curve. The modification amount can be expressed as a function of the position coordinate. For a quadratic parabola, the modification amount $$e(x)$$ at position $$x$$ is given by
$$e(x) = a x^2 + b x + c$$
where $$a$$, $$b$$, and $$c$$ are coefficients determined by the modification amount and modification length. For profile modification, the position coordinate is along the involute profile. For lead modification, the position coordinate is along the tooth width direction.
Modification Algorithms
I use two algorithms in ROMAX Designer: the Monte Carlo method and the genetic algorithm. The Monte Carlo method determines the probability distribution of the modification parameters, performs a large number of random samplings, and calculates the objective value. The steps are as follows. First, I determine the probability distribution of the eight modification parameters. Second, I repeatedly sample the eight modification parameters under this probability distribution to obtain different modification parameter combinations. The number of repetitions is the population size. Third, I calculate the transmission error using each combination. Fourth, I select the combinations that satisfy the constraint condition, which is the transmission error peak-to-peak value. The genetic algorithm is based on the principle of survival of the fittest. It encodes the modification parameters into binary strings, evaluates the fitness of each individual, selects the best individuals, and performs crossover and mutation to generate new individuals. After many generations, the algorithm converges to the optimal modification parameters. The genetic algorithm has strong flexibility and good adaptability, and it can quickly find the global optimal solution. I compare the two algorithms and find that the genetic algorithm provides better modification results and a higher success rate.
Modeling of the Miter Gear Transmission System
The miter gear studied in this research is a combined gear with small tooth space width, large support stiffness, high installation accuracy, and high symmetry. The left and right tooth surfaces of the miter gear have symmetric load distribution. When the pinion of the miter gear is mounted with axial floating, the two helical gear pairs on the left and right sides carry equal torque, and their geometric transmission errors are identical. Therefore, I can simplify the miter gear to a corresponding helical gear model and apply half of the torque. The basic parameters of the standard miter gear pair are listed in Table 1.
| Parameter | Unit | Pinion | Large Gear |
|---|---|---|---|
| Number of teeth | — | 17 | 44 |
| Normal module | mm | 6 | 6 |
| Normal pressure angle | degree | 20 | 20 |
| Helix angle | degree | 24.43 | -24.43 |
| Hand of helix | — | left/right | right/left |
| Effective face width per side | mm | 55 | 55 |
In ROMAX Designer 17.0, I build the equivalent miter gear model. Because of the symmetry of the miter gear, I simplify the large and small miter gears to meshing helical gears, which are left-handed and right-handed respectively. The applied torque is half of the original miter gear torque. The other parameters are listed in Table 2.
| Transmission system parameter | Property or value |
|---|---|
| Gear material | Structural steel |
| Elastic modulus | 210 GPa |
| Poisson’s ratio | 0.3 |
| Addendum coefficient | 1 |
| Clearance coefficient | 0.25 |
| Input shaft bearing | SKF30209 |
| Output shaft bearing | SKF30216 |
| Lubricating oil | ISOVG150 |
| Pinion speed | 160 r/min |
The working conditions used in the static analysis are listed in Table 3. The input shaft torque increases from 70 N·m to 230 N·m.
| Working condition | Input shaft torque (N·m) |
|---|---|
| Condition 1 | 70 |
| Condition 2 | 110 |
| Condition 3 | 150 |
| Condition 4 | 190 |
| Condition 5 | 230 |
According to the literature, the installation error of a pair of meshing helical gears is set to 0.008 mm. Based on these data, I build the equivalent miter gear transmission system model. The model includes the shafts, bearings, and gears. I apply the torque at the input shaft and fix the output shaft. The static analysis is then performed.
Modification Parameters for the Miter Gear
I perform topological modification on the pinion of the miter gear. The modification parameters include profile modification parameters and lead modification parameters. For profile modification, I use a quadratic parabola for both tip relief and root relief. The modification amount boundaries and modification length boundaries are determined from the literature. The profile modification boundaries are listed in Table 4.
| Parameter | Upper bound | Lower bound |
|---|---|---|
| Tip relief amount | 0.015 m_n | 0.005 mm |
| Root relief amount | 0.010 m_n | 0.005 mm |
| Tip relief length | 0.8 m_n | 0.15 m_n |
| Root relief length | 0.6 m_n | 0.1 m_n |
where $$m_n$$ is the normal module of the miter gear. For lead modification, I use a quadratic parabola for both the bottom end relief and the top end relief. The lead modification boundaries are listed in Table 5.
| Parameter | Upper bound | Lower bound |
|---|---|---|
| Bottom end relief amount | 0.02 mm | 0.005 mm |
| Top end relief amount | 0.02 mm | 0.005 mm |
| Unmodified length | 0.5 B | 0 |
where $$B$$ is the face width of the miter gear. To determine the starting point of the parabolic profile modification, I use the involute function. The involute function at point $$k$$ is
$$inv \alpha_k = \tan \alpha_k – \alpha_k$$
where $$\alpha_k$$ is the pressure angle at point $$k$$ in radians. The rolling angle at point $$k$$ is
$$\theta_k = \frac{180}{\pi} \left( \tan \alpha_k – \alpha_k \right)$$
in degrees. The relationship between the diameter at point $$k$$ and the base diameter is
$$d_k = \frac{d_b}{\cos \alpha_k}$$
where $$d_b$$ is the base circle diameter. Using these formulas, I calculate the range of the rolling angle for the tip relief starting point and the root relief starting point. For the tip relief, the modification length ranges from 0.9 mm to 4.8 mm. The corresponding rolling angle range is from 31.142 degrees to 39.352 degrees. For the root relief, the modification length ranges from 0.6 mm to 3.6 mm. The corresponding rolling angle range is from 10.400 degrees to 22.449 degrees. The profile modification parameter settings for the Monte Carlo method are listed in Table 6.
| Profile modification parameter | Range |
|---|---|
| Tip relief amount (μm) | 5–90 |
| Root relief amount (μm) | 5–60 |
| Rolling angle to tip relief start (degree) | 31.142–39.352 |
| Rolling angle to root relief start (degree) | 10.400–22.449 |
For lead modification, I set the bottom end relief starting point from 5/18 to 8/18 of the face width and the top end relief starting point from 11/18 to 14/18 of the face width. The lead modification parameter settings for the Monte Carlo method are listed in Table 7.
| Lead modification parameter | Range |
|---|---|
| Bottom end relief amount (μm) | 5–20 |
| Top end relief amount (μm) | 5–20 |
| Bottom end relief start (mm) | 15.28–24.44 |
| Top end relief start (mm) | 36.61–42.78 |
The objective of the modification is to minimize the transmission error peak-to-peak value. I set the target transmission error peak-to-peak values for the five working conditions as listed in Table 8.
| Working condition | Target peak-to-peak transmission error (μm) |
|---|---|
| Condition 1 | 0–0.2 |
| Condition 2 | 0.1–0.3 |
| Condition 3 | 0.2–0.4 |
| Condition 4 | 0.3–0.5 |
| Condition 5 | 0.4–0.6 |
Monte Carlo Modification Results for the Miter Gear
Using the Monte Carlo method, I generate 40 successful modification schemes. The best scheme is applied to the standard miter gear. The optimal profile modification parameters obtained by the Monte Carlo method are listed in Table 9.
| Profile modification parameter | Value |
|---|---|
| Tip relief amount (μm) | 54.42 |
| Root relief amount (μm) | 45.30 |
| Rolling angle to tip relief start (degree) | 35.484 |
| Rolling angle to root relief start (degree) | 17.529 |
The optimal lead modification parameters obtained by the Monte Carlo method are listed in Table 10.
| Lead modification parameter | Value |
|---|---|
| Bottom end relief amount (μm) | 10.12 |
| Top end relief amount (μm) | 9.16 |
| Bottom end relief start (mm) | 23.396 |
| Top end relief start (mm) | 39.897 |
Combining the profile and lead modification parameters, I obtain the topological modification result for the miter gear.
Genetic Algorithm Modification Results for the Miter Gear
I also use the genetic algorithm in ROMAX to calculate the modification parameters. The genetic algorithm settings are as follows: number of generations is 10, population size is 50, mutation rate is 0.3, crossover rate is 0.2, and generation gap is 0.1. The algorithm generates 500 candidate schemes, and 204 schemes satisfy the target conditions. The success rate is 40.8%. The optimal profile modification parameters obtained by the genetic algorithm are listed in Table 11.
| Profile modification parameter | Value |
|---|---|
| Tip relief amount (μm) | 75.41 |
| Root relief amount (μm) | 53.73 |
| Rolling angle to tip relief start (degree) | 38.479 |
| Rolling angle to root relief start (degree) | 20.268 |
The optimal lead modification parameters obtained by the genetic algorithm are listed in Table 12.
| Lead modification parameter | Value |
|---|---|
| Bottom end relief amount (μm) | 5.24 |
| Top end relief amount (μm) | 17.80 |
| Bottom end relief start (mm) | 18.552 |
| Top end relief start (mm) | 38.230 |
The genetic algorithm provides a better modification effect and a higher success rate than the Monte Carlo method. Therefore, I conclude that the genetic algorithm is more suitable for the modification of the miter gear.
Static Analysis of the Miter Gear
After building the miter gear transmission system, I perform static analysis. The static analysis includes strength check, damage degree, static transmission error, contact stress, and unit length normal load. The strength check includes contact strength and bending strength. Under different working conditions, the miter gear may fail due to excessive alternating stress, inadequate lubrication, or periodic excitation. The main failure modes are tooth surface pitting and tooth breakage. The gear material must satisfy the requirement of a hard surface and a tough core. However, improving the gear strength further is difficult. The maximum stress cycle number is determined by the material properties and the load. If the stress cycle number exceeds the maximum stress cycle number, the miter gear may fail. To improve the maximum stress cycle number, better materials or processes are needed, which increases manufacturing cost. Adequate lubrication is necessary to ensure a good meshing state. Therefore, I must perform static analysis to reduce failures caused by excessive contact stress and bending stress.
In reality, the miter gear produces transmission error due to installation error, manufacturing error, and contact stiffness. The unit length normal load distribution and contact stress distribution reflect the meshing performance. If the load and stress are concentrated in the middle of the tooth surface, the meshing state is good. The transmission error variation, measured by the peak-to-peak value, generates excitation force, which further changes the load and stress distribution, leading to increased dynamic load. Therefore, I analyze the contact stress and transmission error to find the causes of poor meshing and improve transmission stability.
I calculate the contact stress, bending stress, and safety factor for the large gear and the pinion under the five working conditions. The contact stress and bending stress increase linearly with the torque. The safety factor decreases nonlinearly as the torque increases. The bending safety margin is large, while the contact safety factor is close to 1. Therefore, the tooth surface is most likely to suffer contact damage. When designing the miter gear, I should use the contact fatigue strength criterion as the design standard.
The Palmgren-Miner linear cumulative damage rule is used to calculate the damage degree. The mathematical expression is
$$\sum_{i=1}^{n} \frac{n_i}{N_i} = 1$$
where $$n$$ is the number of stress levels, $$n_i$$ is the number of stress cycles at the $$i$$-th stress level, and $$N_i$$ is the fatigue life at the $$i$$-th stress level. The Corten-Dolan damage theory is expressed as
$$N_g = \frac{N_1}{\sum_{i=1}^{n} a_i \left( \frac{\sigma_i}{\sigma_1} \right)^d}$$
where $$N_g$$ is the total fatigue life under multi-level stress, $$\sigma_1$$ is the maximum stress level, $$N_1$$ is the fatigue life at the maximum stress level, $$\sigma_i$$ is the $$i$$-th stress level, $$a_i$$ is the proportion of cycles at the $$i$$-th stress level, and $$d$$ is a constant determined by two-level tests. ROMAX Designer 17.0 uses the Palmgren-Miner rule to calculate the expected life and then calculates the damage degree. The damage degrees of the large gear and the pinion under the five working conditions are listed in Table 13 and Table 14.
| Working condition | Contact damage (left) | Contact damage (right) | Bending damage (left) | Bending damage (right) |
|---|---|---|---|---|
| Condition 1 | 0% | 0% | 0% | 0% |
| Condition 2 | 0% | 0% | 0% | 0% |
| Condition 3 | 0% | 0.36% | 0% | 0% |
| Condition 4 | 0% | 3.3% | 0% | 0% |
| Condition 5 | 0% | 0% | 0% | 0% |
| Working condition | Contact damage (left) | Contact damage (right) | Bending damage (left) | Bending damage (right) |
|---|---|---|---|---|
| Condition 1 | 0% | 0% | 0% | 0% |
| Condition 2 | 0% | 0% | 0% | 0% |
| Condition 3 | 0% | 0.94% | 0% | 0% |
| Condition 4 | 0% | 8.5% | 0% | 0% |
| Condition 5 | 0% | 54.9% | 0% | 0% |
At low torque, the miter gear has no damage. When the torque reaches condition 3, contact damage appears. As the torque increases linearly, the contact damage degree increases nonlinearly. This is because the tooth surface damage accelerates under large cyclic stress. At condition 5, the pinion contact surface suffers significant damage. Therefore, the miter gear should avoid operating under heavy load. The bending damage is zero for all working conditions because the bending stress does not reach the fatigue limit. The contact stress is the main factor affecting the life of the miter gear pair. The modification amount is in the micrometer range, which is very small compared to the tooth geometry. Therefore, the micro-modification does not change the static strength of the miter gear.
Transmission Error Analysis of the Miter Gear
In an ideal state, the meshing tooth profiles of the miter gear are perfectly conjugate, and there is no transmission error. In reality, manufacturing errors, installation errors, and deformation cause the actual output angle to lag behind the theoretical output angle, producing transmission error. Transmission error is the excitation source of vibration and noise, which accelerates fatigue damage and reduces service life. Transmission error can be expressed as angular displacement error or linear displacement error. The angular displacement error is
$$\Delta \theta = \left( \theta_2 – \theta_2^0 \right) – \frac{z_1}{z_2} \left( \theta_1 – \theta_1^0 \right)$$
where $$\theta_1$$ is the actual meshing angle of the pinion, $$\theta_2$$ is the actual meshing angle of the large gear, $$z_1$$ is the number of pinion teeth, $$z_2$$ is the number of large gear teeth, $$\theta_1^0$$ is the initial meshing angle of the pinion, and $$\theta_2^0$$ is the initial meshing angle of the large gear. The linear displacement error along the meshing line is
$$\Delta L = \left( r_{b2} \left( \theta_2 – \theta_2^0 \right) – r_{b1} \left( \theta_1 – \theta_1^0 \right) \right) \frac{\pi}{180}$$
where $$r_{b1}$$ is the base radius of the pinion and $$r_{b2}$$ is the base radius of the large gear. In ROMAX software, the transmission error is mainly expressed as linear displacement error along the meshing line, in micrometers. I calculate the transmission error for the five working conditions. The transmission error curves for the standard tooth surface, the Monte Carlo modified tooth surface, and the genetic algorithm modified tooth surface are compared. The transmission error peak-to-peak values and their reductions are listed in Table 15.
| Working condition | Standard tooth surface max (μm) | Standard peak-to-peak (μm) | Monte Carlo peak-to-peak (μm) | Monte Carlo reduction | Genetic algorithm peak-to-peak (μm) | Genetic algorithm reduction |
|---|---|---|---|---|---|---|
| Condition 1 | 1.29 | 0.255 | 0.094 | 63.14% | 0.078 | 69.41% |
| Condition 2 | 1.99 | 0.400 | 0.141 | 64.75% | 0.112 | 72.00% |
| Condition 3 | 2.69 | 0.545 | 0.290 | 46.79% | 0.239 | 56.15% |
| Condition 4 | 3.37 | 0.689 | 0.402 | 41.65% | 0.345 | 49.93% |
| Condition 5 | 4.05 | 0.832 | 0.445 | 46.51% | 0.421 | 49.40% |
The transmission error peak-to-peak value reflects the stability of the miter gear transmission system. A smaller peak-to-peak value means smaller vibration and more stable transmission. Both the Monte Carlo method and the genetic algorithm effectively reduce the transmission error peak-to-peak value. The genetic algorithm achieves a maximum reduction of 72.00% at condition 2 and a minimum reduction of 49.40% at condition 5. The Monte Carlo method achieves a maximum reduction of 64.75% at condition 2 and a minimum reduction of 41.65% at condition 4. The genetic algorithm provides a more significant modification effect. As the torque increases, the transmission error maximum and peak-to-peak value increase. The torque increase is approximately proportional to the transmission error increase. Under heavy load, the transmission error peak-to-peak value is large, and the transmission system vibration increases. Therefore, modification is necessary to reduce the transmission error peak-to-peak value.
Unit Length Normal Load Analysis of the Miter Gear
The unit length normal load on the tooth surface determines whether the meshing state is good. In an ideal case, the unit length normal load is concentrated in the middle of the tooth surface, and the load gradient is small. Because the meshing tooth surfaces of the pinion and the large gear have equal forces, I study the unit length normal load on the pinion. The maximum unit length normal loads for the standard tooth surface, the Monte Carlo modified tooth surface, and the genetic algorithm modified tooth surface are listed in Table 16.
| Working condition | Standard (N/mm) | Monte Carlo (N/mm) | Genetic algorithm (N/mm) |
|---|---|---|---|
| Condition 1 | 30.8 | 46.3 | 43.8 |
| Condition 2 | 49.1 | 65.7 | 63.0 |
| Condition 3 | 67.7 | 84.3 | 82.0 |
| Condition 4 | 86.5 | 100.8 | 100.0 |
| Condition 5 | 106.3 | 115.8 | 117.9 |
After modification, the maximum unit length normal load increases because the modification reduces the contact ratio and the load is concentrated on a smaller area. However, the genetic algorithm produces a smaller maximum unit length normal load than the Monte Carlo method. The standard tooth surface has the maximum unit length normal load concentrated at the tooth surface edge. The modified miter gear moves the maximum load to the interior of the tooth surface, effectively solving the edge load concentration problem.
Contact Stress Analysis of the Miter Gear
The contact stress on the meshing tooth surface is an important content of gear dynamic analysis. The contact stress magnitude and distribution indicate the meshing state and force condition at each point. Because of the interaction principle, the contact stresses on the pinion and the large gear are equal in magnitude and opposite in direction. I calculate the contact stress on the pinion. The maximum contact stresses for the standard tooth surface, the Monte Carlo modified tooth surface, and the genetic algorithm modified tooth surface are listed in Table 17.
| Working condition | Standard (MPa) | Monte Carlo (MPa) | Monte Carlo reduction | Genetic algorithm (MPa) | Genetic algorithm reduction |
|---|---|---|---|---|---|
| Condition 1 | 339 | 345 | -1.74% | 320 | 5.94% |
| Condition 2 | 428 | 410 | 4.39% | 382 | 12.04% |
| Condition 3 | 502 | 459 | 9.37% | 434 | 15.67% |
| Condition 4 | 567 | 500 | 13.40% | 479 | 18.37% |
| Condition 5 | 626 | 537 | 16.57% | 520 | 20.38% |
For the standard tooth surface, large contact stress exists at the tooth edge. After modification, the contact stress moves to the interior of the tooth surface, and the contact state improves. The maximum contact stress decreases after modification. Under the five working conditions, the Monte Carlo method reduces the maximum contact stress by up to 16.57% at condition 5. The genetic algorithm reduces the maximum contact stress by up to 20.38% at condition 5. Therefore, the genetic algorithm provides a better modification effect for the miter gear.
Sensitivity Analysis of Miter Gear Modification
In the transmission process, manufacturing errors and installation errors cause the actual modification result to differ from the optimal simulation result. This affects the transmission error and contact stress. The sensitivity analysis of the miter gear modification evaluates the stability of the transmission error and contact stress under manufacturing errors and installation errors. The sensitivity analysis improves the applicability of miter gear modification, which is important for gear design and manufacturing.
I perform sensitivity analysis on three groups of optimal profile modification data, three groups of optimal lead modification data, and one group of optimal topological modification data. For each group, I add a small variation to the optimal modification parameters and consider the center distance installation error. I analyze the transmission error, the maximum contact stress, and the sensitivity of the center distance installation error to the transmission error. I use the following variation ranges: for profile modification, the modification length is varied by ±0.7 mm, and the maximum modification amount is varied by ±2 μm. For lead modification, the modification length is varied by ±1 mm, and the maximum modification amount is varied by ±1 μm. For topological modification, both profile and lead variations are applied. The sensitivity analysis results are summarized in Table 18.
| Sensitivity analysis variable | Profile modification | Lead modification | Topological modification |
|---|---|---|---|
| Transmission error | Sensitive | Not sensitive | Sensitive |
| Maximum contact stress | Not sensitive | Not sensitive | Not sensitive |
| Center distance installation error to transmission error | Not sensitive | Sensitive | Not sensitive |
For profile modification, the variation in the optimal modification parameters has a large effect on the transmission error peak-to-peak value, so the profile modification is sensitive to transmission error. The variation has little effect on the transmission error average value, so the profile modification is not sensitive to the transmission error average. The variation has little effect on the maximum contact stress, so the profile modification is not sensitive to the maximum contact stress. When the center distance installation error changes, the transmission error remains almost unchanged because of the separability of involute gears. Therefore, the center distance installation error is not sensitive to the transmission error of the profile-modified miter gear.
For lead modification, the variation in the optimal modification parameters has little effect on both the transmission error peak-to-peak value and the transmission error average value. Therefore, the lead modification is not sensitive to transmission error. The variation has little effect on the maximum contact stress, so the lead modification is not sensitive to the maximum contact stress. When the center distance installation error changes, the transmission error changes significantly. Therefore, the center distance installation error is sensitive to the transmission error of the lead-modified miter gear. This is because the lead modification parameters are designed for a center distance error of 0.008 mm. When the center distance changes, the tooth surface deviates from the theoretical meshing position, and the transmission error changes greatly.
For topological modification, the variation in the optimal modification parameters has a large effect on the transmission error peak-to-peak value, so the topological modification is sensitive to transmission error. The variation has little effect on the maximum contact stress, so the topological modification is not sensitive to the maximum contact stress. When the center distance installation error changes, the transmission error remains almost unchanged. Therefore, the center distance installation error is not sensitive to the transmission error of the topological-modified miter gear. In this topological modification, the profile modification parameters are much larger than the lead modification parameters, so the profile modification is the dominant factor. Increasing the manufacturing accuracy and installation accuracy and using shafts and bearings with high support stiffness can reduce the sensitivity of the miter gear modification to transmission error.
Experimental Verification of the Miter Gear Transmission Error
After completing the static analysis of the miter gear, I verify the software calculation results with experiments. Due to the limitation of experimental conditions, I only verify the transmission error amplitude of the standard tooth surface. I build a closed power flow mechanical transmission test rig for the miter gear. I use German Heidenhain circular gratings to measure the input and output angular position data. I use an Altai acquisition card to collect the data and complete the data conversion. I develop a transmission error measurement software using MATLAB and Visual Basic 6.0. The software calculates the transmission error from the converted data. I compare the measured transmission error amplitude with the theoretical calculation result.
The closed power flow mechanical transmission test rig consists of a load motor, a drive motor, elastic couplings, a speed and torque meter, an elastic shaft loading coupling, a test gearbox, a companion gearbox, and high-precision circular gratings. The closed power flow uses the reversible principle of a DC motor. The electric power generated by the drive motor passes through the test piece and the mechanical device, and then the load motor converts it into DC power, which is fed back to the drive motor. This achieves energy recycling and greatly saves experimental energy. The test rig structure is shown in the figure. I use two pairs of circular gratings. The first pair includes a pinion grating ROD280 with 18,000 lines and an accuracy of ±5 arcseconds, and a large gear grating ROD280 with 18,000 lines and an accuracy of ±5 arcseconds. The second pair includes a pinion grating RON886 with 90,000 lines and an accuracy of ±1 arcsecond, and a large gear grating RPN886 with 90,000 lines and an accuracy of ±1 arcsecond. Both pairs of circular gratings have arcsecond-level accuracy. I install the two circular gratings at the ends of the two gear shafts. According to ISO8015, the eccentricity error should be within 0.2 mm for valid measurement data.
The data acquisition software is PCI6755_SetupV1.8.0. I set the sampling points and sampling frequency. The sampling frequency is calculated by
$$F = K \frac{N}{60} \times 120$$
where $$F$$ is the sampling frequency, $$N$$ is the pinion speed in r/min, and $$K$$ is the number of grating lines. The collected data must satisfy two conditions. First, each of the four channels must have data signals, ensuring good contact between the acquisition card and the sensor interface and normal operation of the acquisition software. Second, the data on each channel must be a sine wave with an amplitude fluctuating around the zero line, ensuring that the collected data are not distorted. After debugging the test rig and ensuring no errors in the acquisition software, I collect data for the test miter gear.
The transmission error measurement software includes a data input module, a data calculation module, and a data output module. The input includes the converted data files of the pinion and the large gear and the basic parameter file of the miter gear pair. The basic parameter file contains the number of teeth (17 and 44), the module (6 mm), the pressure angle (20 degrees), the helix angle (24.43 degrees), the number of grating lines per revolution (36,000 lines and 180,000 lines), and the given analysis amount for the large gear (1 revolution). The data calculation module uses MATLAB. The main program is For_CalTRE.m. The algorithm performs mean filtering on the converted data, extracts the complete sine wave signals of the pinion and the large gear, calculates the angular position from the amplitude and phase of the sine wave, and then calculates the angular transmission error using the transmission error formula. The output data include Rm.dat (pinion speed in r/min), ANGLE1.dat and ANGLE2.dat (pinion and large gear angular data), TRE.dat (transmission error data), and Acr.dat (relative vibration data). The executable MATLAB programs Plot_ANGLE1.m, Plot_ANGLE2.m, and LVBO_TRE_CP.m draw the angular curves and the transmission error curve, calculate the transmission error amplitude, and perform fast Fourier transform to convert the time-domain transmission error into a frequency spectrum. The Visual Basic program manages the file paths and basic parameter files.
I conduct experiments on the standard tooth surface miter gear under five working conditions. The pinion speed is 160 r/min. The working conditions are listed in Table 19.
| Working condition | Torque (N·m) |
|---|---|
| Condition 1 | 140 |
| Condition 2 | 220 |
| Condition 3 | 300 |
| Condition 4 | 380 |
| Condition 5 | 460 |
The measured transmission error amplitude for the standard tooth surface miter gear is compared with the theoretical calculation. Because ROMAX software calculates the linear transmission error, and the experiment measures the angular transmission error, I convert the linear transmission error to the angular transmission error. The relationship is
$$\Delta \theta = \frac{\Delta L}{r_{b2}} \times 412.5296$$
where $$\Delta \theta$$ is the angular transmission error in arcseconds, $$\Delta L$$ is the linear transmission error in micrometers, and $$r_{b2}$$ is the base radius of the large gear in millimeters. The comparison is listed in Table 20.
| Working condition | Theoretical calculation (μm, arcsec) | Experimental measurement (arcsec) |
|---|---|---|
| Condition 1 | 0.255, 0.391 | 2.34 |
| Condition 2 | 0.400, 0.613 | 5.02 |
| Condition 3 | 0.545, 0.835 | 7.22 |
| Condition 4 | 0.689, 1.056 | 9.02 |
| Condition 5 | 0.832, 1.275 | 11.94 |
The theoretical calculation shows that the transmission error amplitude increases linearly with the torque. The experimental measurement also shows an increasing trend, but the increase rate is larger than the theoretical rate. This is because the miter gear transmission system is affected not only by static factors such as manufacturing errors and installation errors but also by dynamic factors such as tooth surface friction, time-varying meshing damping, time-varying meshing stiffness, torque fluctuation, and shaft torsional and bending deformation. These dynamic factors affect the base pitch error of the involute profile, causing the experimental transmission error peak-to-peak value to increase excessively. The increase in transmission error peak-to-peak value further aggravates vibration, which in turn enhances these factors, such as tooth surface friction and torque fluctuation. Therefore, these factors become uncontrollable in the experiment. However, the variation trend of the transmission error amplitude with torque is consistent with the theoretical calculation.
Conclusion
In this research, I investigate the modification design of the miter gear tooth surface. I use the Monte Carlo method and the genetic algorithm to perform topological modification on the miter gear model. The modification effectively reduces the transmission error peak-to-peak value and the maximum contact stress, improving the stability of the miter gear transmission system. I compare the two algorithms and find that the genetic algorithm provides better modification results and a higher success rate. I also conduct sensitivity analysis on the modified miter gear. The profile modification is sensitive to transmission error, not sensitive to the maximum contact stress, and the center distance installation error is not sensitive to the transmission error of the profile-modified miter gear. The lead modification is not sensitive to transmission error, not sensitive to the maximum contact stress, and the center distance installation error is sensitive to the transmission error of the lead-modified miter gear. The topological modification is sensitive to transmission error, not sensitive to the maximum contact stress, and the center distance installation error is not sensitive to the transmission error of the topological-modified miter gear. Finally, I verify the transmission error of the standard tooth surface miter gear through experiments. The experimental results are consistent with the theoretical calculation trend. The research provides a reference for the design and manufacturing of the miter gear.
Future Work
There are still some areas to be improved in this research. Due to the limitation of experimental conditions, I only verify the transmission error of the standard tooth surface miter gear, and I do not verify the modified miter gear. In future work, I will conduct experimental verification on the modified miter gear. In addition, due to the limitation of the thesis length, I only analyze the sensitivity of the modified miter gear under center distance installation error. I do not analyze the sensitivity under shaft angle installation error. In future work, I will study the sensitivity of the miter gear modification under shaft angle installation error.