
In marine engineering, the anchoring system is a critical component for vessel safety during port arrival, berthing等待, or when facing adverse weather conditions. Traditional anchor handling equipment, such as electric, hydraulic, or electro-hydraulic windlasses, often struggles to maintain reliable braking under external forces like wind, waves, and currents. This can lead to unintended anchor chain release, increasing the risk of grounding, collision, or excessive vessel drift. To mitigate these issues, I propose a novel self-locking mechanism based on screw gears, commonly known as worm gears, which enhances braking reliability through improved design and automated control. This article details the design process, from analyzing traditional screw gears self-locking principles to developing an advanced device with dual screws and programmable logic controller (PLC) integration, aimed at providing robust and precise anchor chain management for marine applications.
The fundamental principle behind screw gears self-locking lies in the kinematic relationship between the screw (worm) and the gear (worm wheel). In traditional configurations, self-locking occurs when the lead angle of the screw is smaller than the friction angle at the gear contact interface. This condition can be expressed mathematically as:
$$ \phi < \rho $$
where \(\phi\) is the lead angle of the screw and \(\rho\) is the friction angle, which depends on the materials and lubrication. The friction angle is related to the coefficient of friction \(\mu\) by \(\rho = \arctan(\mu)\). For screw gears to exhibit self-locking, the lead angle must satisfy \(\phi < \arctan(\mu)\). However, this traditional approach faces several challenges. First, screw gears typically have high friction losses due to sliding contact, reducing transmission efficiency and potentially affecting self-locking performance. Second, lubrication状态 can alter the effective friction coefficient, causing the lead angle to exceed the friction angle under dynamic conditions. Third, environmental factors like vibration in marine settings can induce relative motion, transitioning from static to dynamic friction and compromising self-locking. The following table summarizes the relationship between friction coefficients and required lead angles for self-locking in typical screw gears setups:
| Friction Coefficient (μ) | Friction Angle (ρ) | Maximum Lead Angle for Self-locking (φ) |
|---|---|---|
| 0.6 | 30.96° | 3°29’11” |
| 0.7 | 35.00° | 4°03’57” |
| 0.8 | 38.66° | 4°38’39” |
These values highlight how self-locking sensitivity increases with friction variations. To address these limitations, I developed a novel marine screw gears self-locking device with enhanced features. The design requirements were derived from marine standards and practical needs: (1) utilize screw gears with a large transmission ratio for efficient anchor chain handling during retrieval; (2) incorporate a dual-screw structure to improve self-locking reliability; (3) integrate a PLC-based monitoring system for precise control of anchor chain length; and (4) ensure compatibility with standard anchor chains, such as those specified in GB/T 549-2017, which mandate tensile loads up to 476 kN. The device aims to provide reliable braking under dynamic marine conditions while reducing manual intervention.
The working principle of the novel screw gears self-locking device revolves around three interconnected subsystems: a lubrication system, a screw gears transmission mechanism, and a PLC-controlled self-locking mechanism. The lubrication system employs an active carbon canister to absorb excess oil vapor, maintaining optimal lubrication for the screw gears and minimizing friction variations. Oil level and condition are monitored via sensors, with feedback to the PLC for automated oil spray control. The screw gears transmission mechanism features dual screws engaging with a single gear, allowing for switchable operation modes. In reduction mode, the screws act as drivers to retract the anchor chain with high torque, while in self-locking mode, the gear becomes the driver, and the screws provide braking resistance. The PLC system coordinates these modes by processing signals from position, speed, and oil sensors, controlling actuators like electromagnetic clutches and synchronizers to adjust transmission ratios and engage/disengage power inputs. This integrated approach ensures precise anchor chain management, from deployment to secure locking.
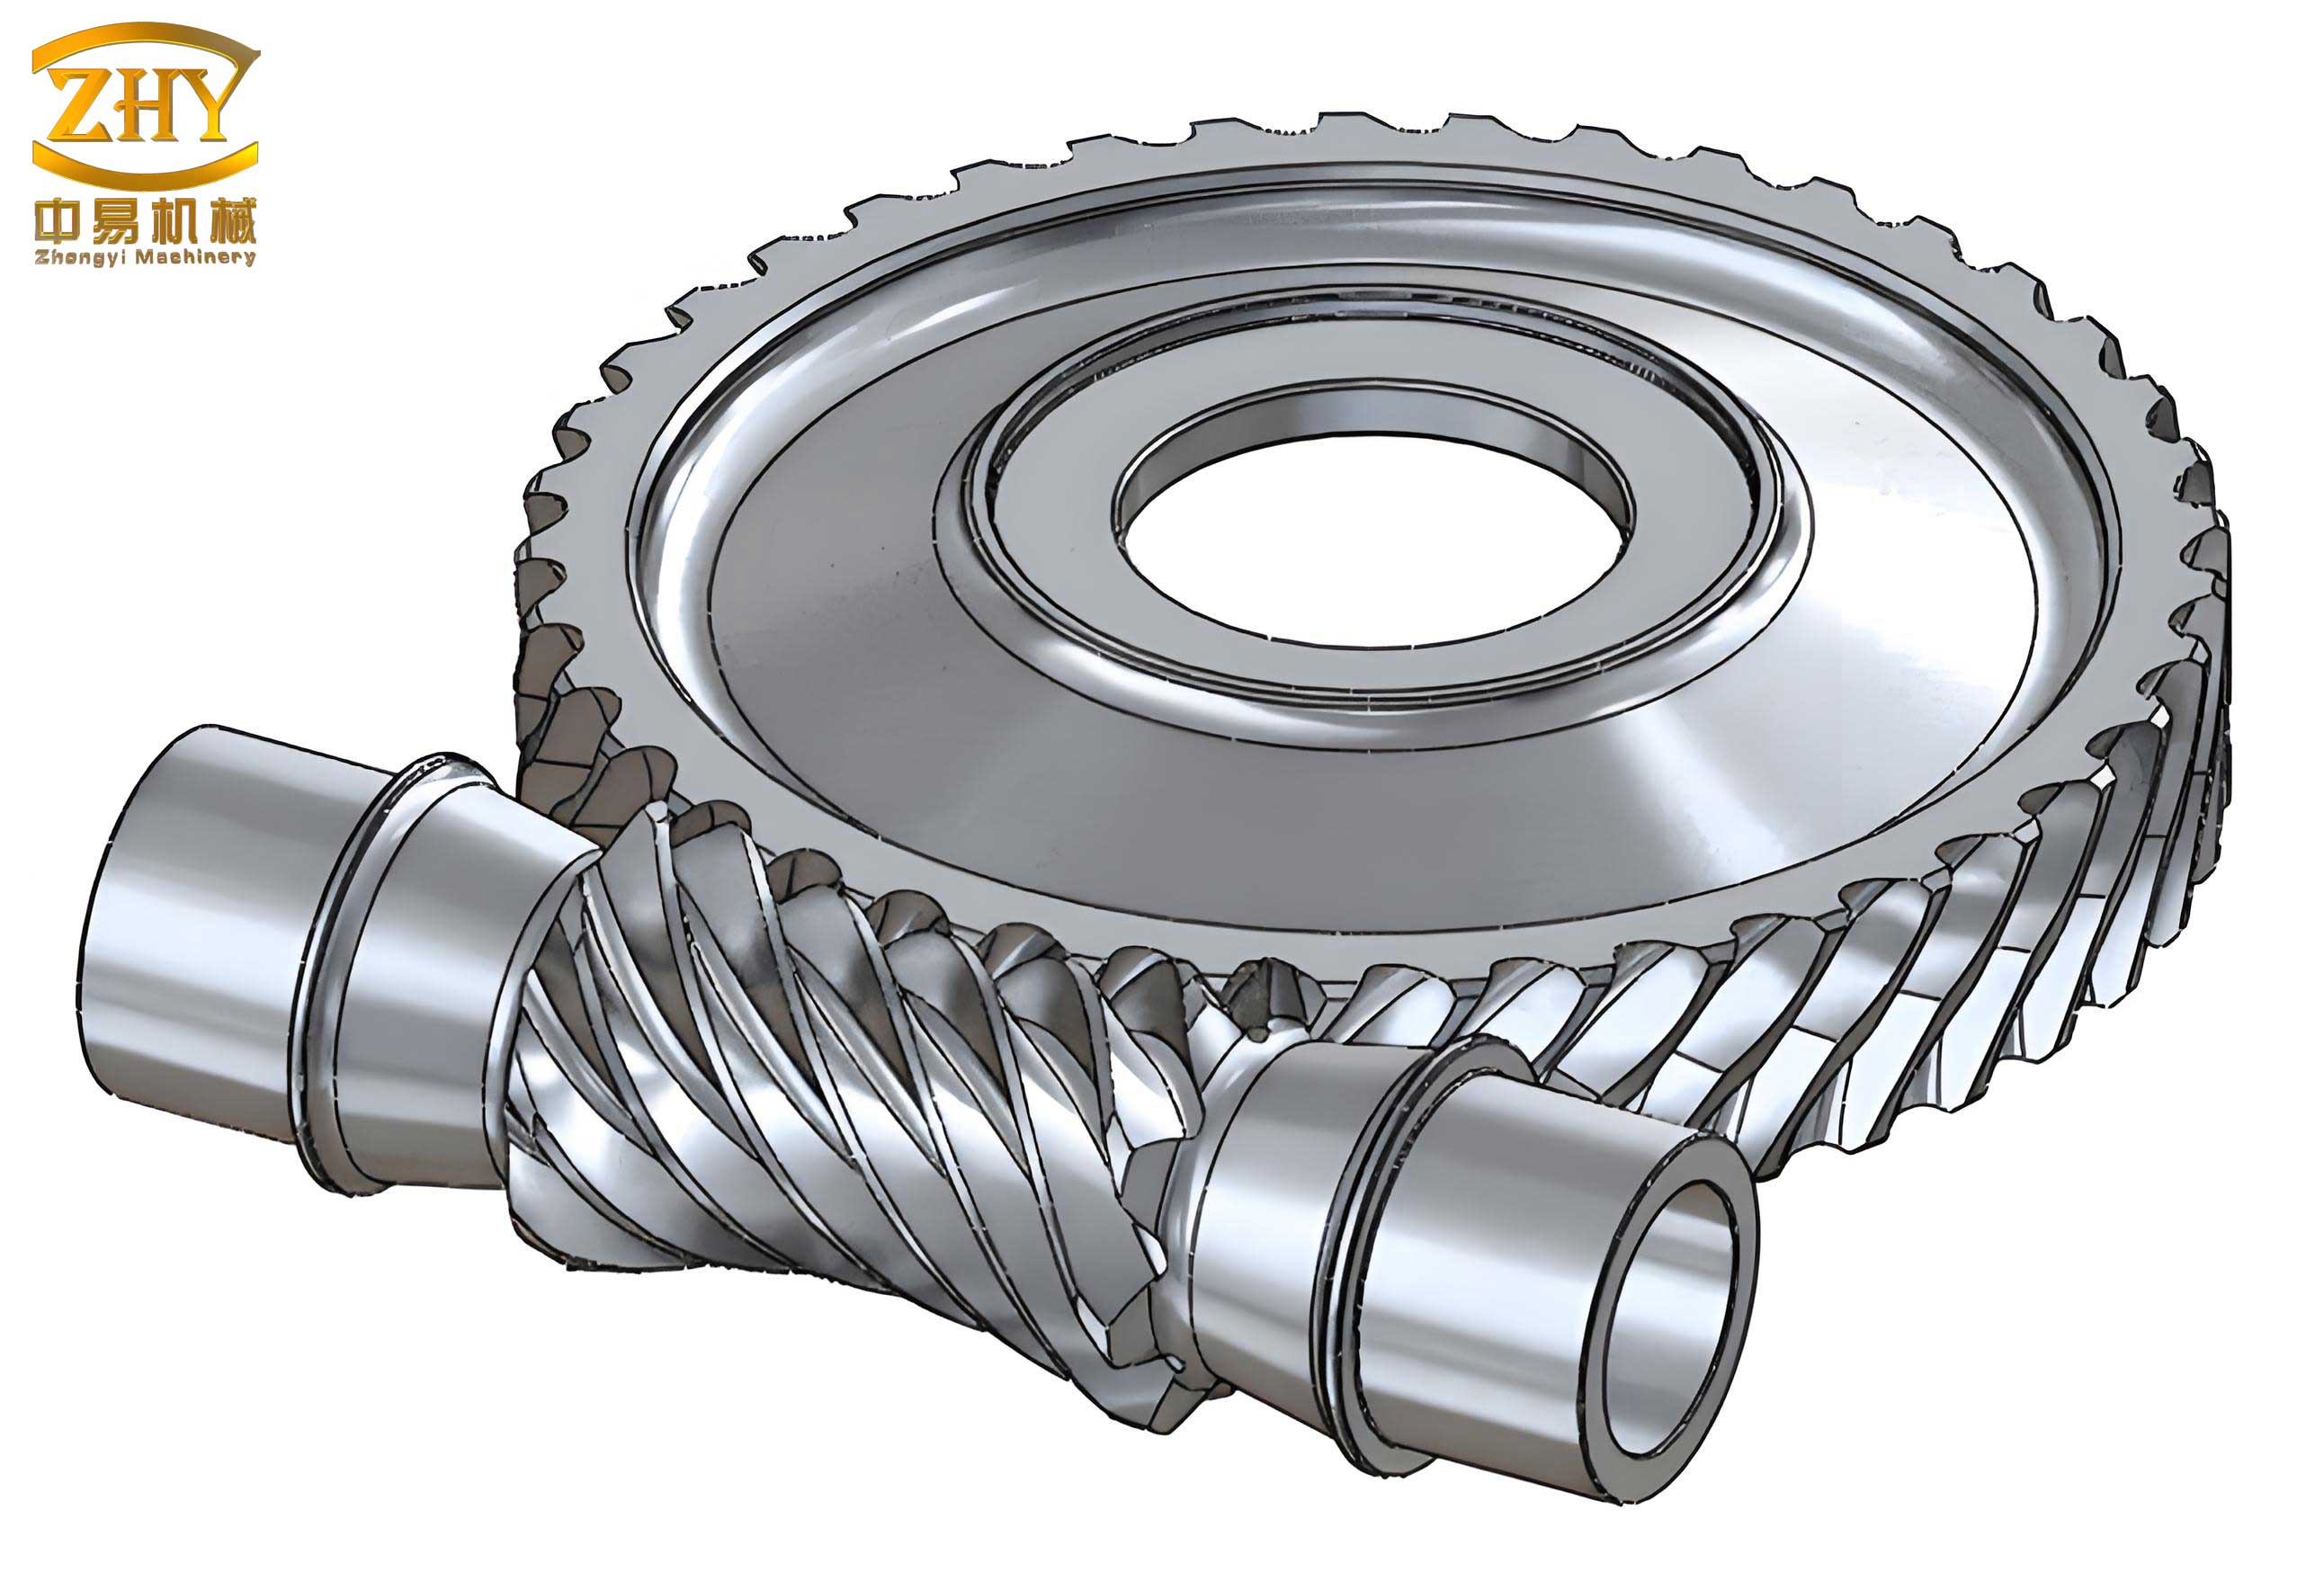
Key components of the screw gears self-locking device include the electromagnetic clutch, synchronizer, PLC control module, and various sensors. The electromagnetic clutch enables rapid switching between single-stage and multi-stage power inputs, facilitating transmission ratio changes for different operational phases. It operates based on magnetic fields to engage or disengage friction plates, responding to PLC commands within milliseconds. The synchronizer ensures smooth gear engagement during ratio adjustments, using inertial forces to match speeds between mating gears and prevent冲击. The PLC control module, built with a central processing unit and input/output modules, processes real-time data from sensors. For instance, position sensors track anchor chain movement, speed sensors monitor screw gears rotation, and oil sensors detect lubrication status. Outputs from the PLC drive actuators like the clutch and oil spray nozzles, enabling automated control. This componentization enhances reliability and allows for modular maintenance in harsh marine environments.
For the screw gears transmission design, selection calculations were performed to meet mechanical requirements. Based on the GB/T 549-2017 standard, an AM3-24 anchor chain was chosen with a tensile load of 332 kN and a mass per unit length of 12.61 kg/m. Considering a typical anchor chain length of 6 sections (27.5 m each) and anchor mass of 3.2 kg, the total force on the chain includes tensile and gravitational components. The torque \(T_1\) on the screw gear connection rod was calculated as 55,110 N·mm, derived from the chain force and mechanical advantage. To ensure durability, materials were selected: the screw made of 20Cr steel with surface hardening (58-63 HRC) and the gear made of tin bronze ZCuSn5Pb5Zn5 via sand casting. The design process involved determining geometric parameters through stress and deflection analyses. The center distance \(a\) was calculated using the formula for contact strength:
$$ a \geq \sqrt[3]{K_A \times T_2 \times \left( \frac{Z_E \times Z_\rho}{[\sigma_H]} \right)^2 } $$
where \(K_A = 1.4\) is the application factor, \(T_2\) is the torque on the gear, \(Z_E = 150 \, \text{MPa}^{1/2}\) is the elasticity coefficient for steel-bronze pairs, \(Z_\rho = 2.8\) is the contact coefficient, and \([\sigma_H] = 200 \, \text{MPa}\) is the allowable contact stress. With a transmission ratio \(i_{12} = 50\), screw threads \(z_1 = 1\), and gear teeth \(z_2 = 50\), the efficiency \(\eta\) was estimated as 0.65, leading to \(T_2 = T_1 \times \eta \times i_{12} = 55,110 \times 0.65 \times 50 = 1,791,075 \, \text{N·mm}\). Substituting values yielded \(a \geq 211.63 \, \text{mm}\), and after standardizing, parameters were finalized as shown in the table below:
| Parameter | Symbol | Value |
|---|---|---|
| Module | \(m\) | 8 mm |
| Screw Diameter Factor | \(q\) | 17.5 |
| Screw Lead Angle | \(\phi\) | 3.2705° |
| Center Distance | \(a\) | 270 mm |
| Gear Diameter | \(d_2\) | 400 mm |
| Screw Diameter | \(d_1\) | 140 mm |
The lead angle \(\phi = \arctan(z_1 / q) = \arctan(1 / 17.5) \approx 3.2705^\circ\) satisfies the self-locking condition \(\phi < \rho\) for typical friction angles. Bending stress was verified using:
$$ \sigma_F = \frac{1.53 \times K_A \times T_2}{d_1 \times d_2 \times m \times \cos \phi} \times Y_{Fa2} $$
where \(Y_{Fa2} = 2.35\) is the gear form factor for equivalent teeth \(z_v = z_2 / \cos^3 \phi \approx 50\). This gave \(\sigma_F \approx 17.2 \, \text{MPa}\), below the allowable bending stress \([\sigma_F] = 32 \, \text{MPa}\). Screw stiffness was checked by calculating deflection \(Y\) under tangential force \(F_{t1}\) and radial force \(F_{r1}\):
$$ F_{t1} = \frac{2 T_2}{d_2} \tan \alpha = \frac{2 \times 1,791,075}{400} \times \tan 20^\circ \approx 3,259.48 \, \text{N} $$
$$ F_{r1} = \frac{2 T_2}{d_2} = \frac{2 \times 1,791,075}{400} \approx 8,955.38 \, \text{N} $$
$$ Y = \sqrt{ \left( \frac{F_{t1} l^3}{48 E I} \right)^2 + \left( \frac{F_{r1} l^3}{48 E I} \right)^2 } $$
with length \(l = 0.9 d_2 = 360 \, \text{mm}\), elastic modulus \(E = 2.06 \times 10^5 \, \text{MPa}\), and inertia \(I = \pi d_1^4 / 64 \approx 18.86 \times 10^6 \, \text{mm}^4\). The result \(Y \approx 0.0023 \, \text{mm}\) was less than the allowable \([Y] = 0.14 \, \text{mm}\), confirming sufficient stiffness. These calculations ensure the screw gears can withstand operational loads while maintaining self-locking capability.
Motor selection for the screw gears device was based on power requirements. The minimum power \(P\) needed to drive the screw gears system is given by:
$$ P = \frac{n_1 \times T_1}{9550} $$
where \(n_1\) is the input speed in rpm. For an initial speed of 1000 rpm and torque \(T_1 = 55,110 \, \text{N·mm}\), \(P \approx 5.8 \, \text{kW}\). To account for losses and provide a safety margin, a Y160M-6 motor with 7.5 kW power and rated speed of 970 rpm was chosen. This motor aligns with marine standards and offers reliable performance for anchor handling. The integration of this motor with the screw gears transmission allows for efficient power delivery, whether for high-torque retrieval or precise braking during self-locking. The table below summarizes key motor and drive parameters:
| Parameter | Value |
|---|---|
| Motor Model | Y160M-6 |
| Rated Power | 7.5 kW |
| Rated Speed | 970 rpm |
| Transmission Ratio | 50 (reduction mode) |
| Self-locking Ratio | 30 (braking mode) |
The PLC system enhances control by automating operations based on sensor inputs. For example, position sensors detect anchor chain displacement, with each fathom (≈1.822 m) triggering a signal to the PLC. The PLC then adjusts the screw gears transmission via the synchronizer and electromagnetic clutch to maintain desired chain length. Oil sensors monitor lubrication levels, activating spray nozzles when needed to reduce friction and preserve self-locking性能. This automation reduces human error and improves response to dynamic sea conditions. The screw gears device’s dual-screw design doubles the braking force compared to single-screw systems, as torque is distributed across two contact interfaces. The self-locking condition can be expressed for dual screws as:
$$ \phi < \rho_{\text{eff}} $$
where \(\rho_{\text{eff}}\) is the effective friction angle considering dual contact. This design lowers the risk of slippage under high anchor chain tensions, such as those exceeding 400 kN in stormy weather.
In terms of application, the screw gears self-locking device is tailored for marine windlasses on various vessel types, from cargo ships to offshore platforms. Its modular design allows for customization based on anchor chain size and deck space. The use of screw gears provides inherent advantages like compactness and high torque transmission, but the novel additions—dual screws, PLC control, and automated lubrication—address traditional drawbacks. For instance, the PLC can log operational data, enabling predictive maintenance by tracking screw gears wear or lubrication cycles. This aligns with trends in smart shipping and Industry 4.0, where automation and data analytics enhance maritime safety.
To further elaborate on the screw gears design, consider the stress analysis under cyclic loading. Marine environments impose fatigue stresses on screw gears due to wave-induced vibrations. The contact stress \(\sigma_H\) can be modeled using Hertzian theory:
$$ \sigma_H = Z_E \sqrt{ \frac{F_n}{b} \cdot \frac{1}{\rho_{\text{rel}}} } $$
where \(F_n\) is the normal force, \(b\) is the face width, and \(\rho_{\text{rel}}\) is the relative curvature radius. For the screw gears pair, \(\rho_{\text{rel}} = \frac{d_1 \sin \phi}{2 \cos^2 \phi}\) for the screw and \(\rho_{\text{rel}} = \frac{d_2}{2}\) for the gear. Ensuring \(\sigma_H < [\sigma_H]\) over millions of cycles requires material endurance limits, which for tin bronze is approximately 150 MPa under marine conditions. The dual-screw configuration reduces stress concentration by sharing loads, as shown in the force distribution formula:
$$ F_{n,\text{total}} = F_{n1} + F_{n2} = \frac{T_2}{r_2} \left( \frac{1}{\cos \phi \cos \alpha} \right) $$
where \(F_{n1}\) and \(F_{n2}\) are normal forces on each screw, \(r_2 = d_2/2\) is the gear pitch radius, and \(\alpha = 20^\circ\) is the pressure angle. This distribution enhances durability and prolongs screw gears life.
Lubrication management is critical for maintaining screw gears self-locking performance. The PLC-controlled system uses an oil viscosity model to optimize spray intervals:
$$ \mu = \mu_0 e^{-\beta (T – T_0)} $$
where \(\mu\) is the dynamic viscosity, \(\mu_0\) is reference viscosity at temperature \(T_0\), \(\beta\) is a coefficient, and \(T\) is operating temperature. Sensors feed temperature data to the PLC, which adjusts oil flow to keep \(\mu\) within an optimal range (e.g., 0.05–0.1 Pa·s) for screw gears. This prevents excessive friction changes that could affect the self-locking condition \(\phi < \arctan(\mu)\). The active carbon canister also recovers oil mist, reducing waste and environmental impact—a key consideration in modern marine engineering.
Control algorithms in the PLC ensure precise screw gears operation. For anchor chain retrieval, the speed profile follows a trapezoidal pattern: acceleration, constant speed, and deceleration. The PLC calculates the required screw rotation speed \(n_s\) based on chain length \(L\):
$$ n_s = \frac{L}{p \cdot t} $$
where \(p\) is the screw lead (\(p = \pi m z_1 / \cos \phi\)) and \(t\) is time. During self-locking, the PLC monitors chain tension via load cells, engaging the dual screws when tension exceeds a threshold (e.g., 300 kN). The response time is under 0.1 seconds, thanks to high-speed PLC modules. This rapid control prevents chain overrun and enhances safety.
In conclusion, the novel marine screw gears self-locking device represents a significant advancement in anchor handling technology. By integrating dual screws, PLC automation, and smart lubrication, it addresses the limitations of traditional screw gears systems, such as friction sensitivity and poor dynamic response. The design calculations confirm mechanical robustness for standard marine loads, while the control system enables precise, automated operation. Future work could focus on optimizing screw gears geometry for higher efficiency, testing in full-scale marine trials, and integrating with digital twin platforms for real-time monitoring. This screw gears device not only improves vessel safety but also contributes to the evolution of intelligent maritime systems, where reliability and automation are paramount.