
In the field of mechanical transmissions, hyperboloid gears are critical components widely used in automotive drivetrains, industrial machinery, and aerospace applications due to their ability to transmit motion between non-parallel and non-intersecting shafts with high efficiency and compact design. The complex tooth geometry of hyperboloid gears, characterized by hyperboloidal surfaces, leads to localized contact patterns that significantly influence their operational performance, including lubrication conditions, vibration characteristics, and overall durability. Understanding the relationship between contact path strategies and running performance is essential for optimizing the design and manufacturing of hyperboloid gears. Previous theoretical studies, such as Tooth Contact Analysis (TCA), Loaded Tooth Contact Analysis (LTCA), and Lubrication and Loaded Tooth Contact Analysis (LLTCA), have provided insights into the meshing behavior of hyperboloid gears under various conditions. However, experimental validation through controlled bench tests remains crucial to corroborate these theoretical predictions and guide practical applications. This study aims to explore the impact of different contact path orientations on the running performance of hyperboloid gears using quantitative comparative testing methods, with a focus on steady-state oil temperature and vibration acceleration root mean square (RMS) values as key evaluation parameters.
The performance of hyperboloid gears is heavily influenced by the contact pattern formed between the pinion and gear teeth during operation. The contact path, which refers to the trajectory of the contact area on the tooth surface, can be classified into several typical orientations: along the tooth height, along the tooth length, inward diagonal, and outward diagonal. These orientations affect the load distribution, stress concentrations, and lubrication film formation, thereby impacting the gear’s operational stability and thermal behavior. Theoretical analyses, particularly through LLTCA simulations, suggest that contact paths along the tooth length or with significant inward diagonal tendencies may offer better running stability compared to those along the tooth height, contrary to conventional assumptions. To verify this, we conducted a series of bench tests on hyperboloid gears with controlled contact path strategies, measuring their performance under varying load and speed conditions. This article presents a comprehensive account of the experimental setup, methodology, results, and discussions, enriched with tables and mathematical formulations to elucidate the findings.
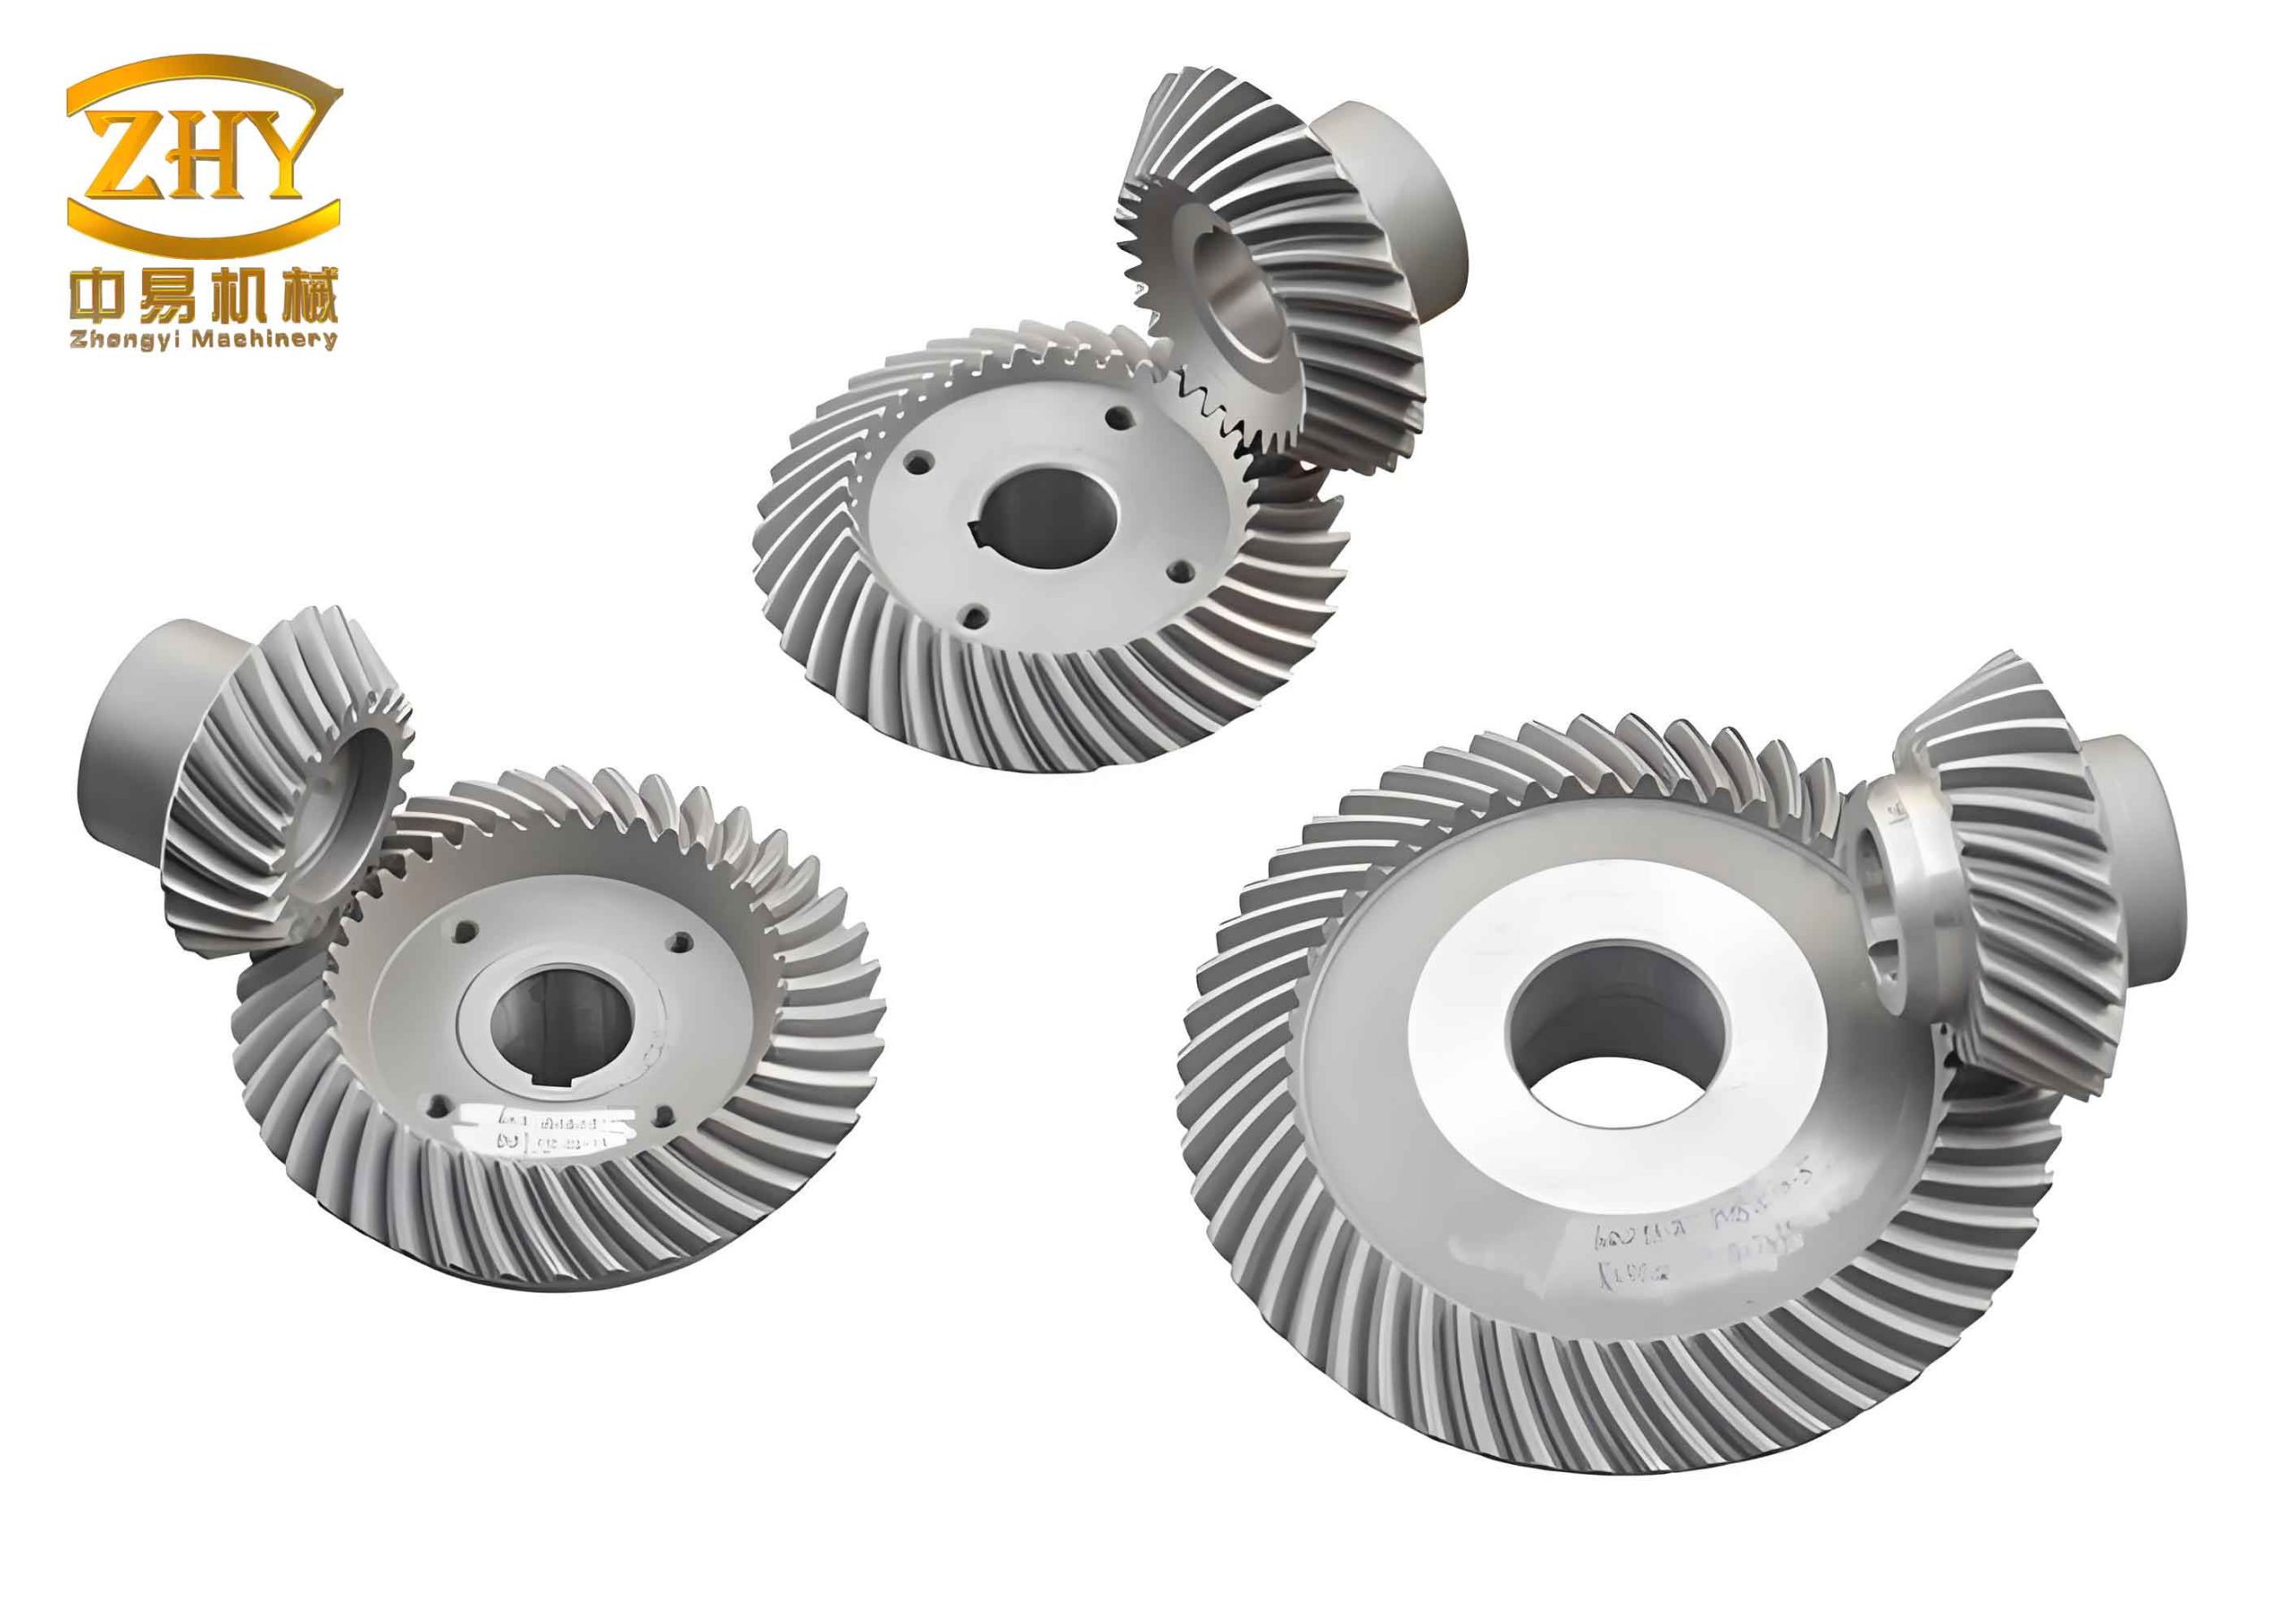
The geometry of hyperboloid gears involves complex mathematical representations that define their tooth profiles and meshing characteristics. The basic equations for a hyperboloidal surface can be expressed in parametric form, which is essential for understanding contact mechanics. For a hyperboloid gear pair, the pinion and gear surfaces are generated based on the principles of differential geometry and conjugate action. The position vector $\mathbf{r}(u, v)$ for a point on the tooth surface can be given by:
$$\mathbf{r}(u, v) = \begin{bmatrix} a \cosh(u) \cos(v) \\ a \cosh(u) \sin(v) \\ c \sinh(u) \end{bmatrix}$$
where $a$ and $c$ are constants related to the hyperboloid’s dimensions, $u$ is a hyperbolic parameter, and $v$ is an angular parameter. The contact between mating teeth is governed by the equation of meshing, which ensures continuous motion transmission. For hyperboloid gears, this can be derived from the condition that the relative velocity at the contact point is zero along the common normal. The meshing equation is:
$$ \mathbf{n} \cdot (\mathbf{v}_1 – \mathbf{v}_2) = 0 $$
where $\mathbf{n}$ is the unit normal vector at the contact point, and $\mathbf{v}_1$ and $\mathbf{v}_2$ are the velocities of the pinion and gear, respectively. The contact path orientation is determined by the solution of this equation under loaded conditions, which involves iterative numerical methods in practices like LLTCA. The performance metrics, such as oil temperature rise and vibration levels, are linked to the contact pressure distribution $p(x,y)$ and film thickness $h(x,y)$ in the elastohydrodynamic lubrication (EHL) regime. The Reynolds equation for lubricant flow in the contact zone is:
$$ \frac{\partial}{\partial x} \left( \frac{h^3}{\eta} \frac{\partial p}{\partial x} \right) + \frac{\partial}{\partial y} \left( \frac{h^3}{\eta} \frac{\partial p}{\partial y} \right) = 12 U \frac{\partial h}{\partial x} $$
where $\eta$ is the dynamic viscosity, $U$ is the entraining velocity, and $x$ and $y$ are coordinates along and perpendicular to the rolling direction. The solution of this equation, coupled with the elastic deformation of the teeth, provides insights into the lubrication performance of hyperboloid gears with different contact paths.
Our experimental investigation was conducted on a mechanically closed-loop gear testing rig, which simulates real-world operating conditions for hyperboloid gears while allowing precise control over load and speed parameters. The test rig consists of a DC motor drive system, a hydraulic loading unit, and a data acquisition system for monitoring temperature and vibration signals. The closed-loop configuration ensures energy efficiency and stable torque transmission, making it ideal for prolonged testing. The hyperboloid gear pairs used in this study were sourced from the rear axle drive of a minicab, with their key parameters summarized in Table 1. These hyperboloid gears were manufactured to exhibit four distinct contact path orientations: along the tooth height (Type A), along the tooth length (Type B), inward diagonal (Type C), and outward diagonal (Type D). Each orientation was represented by two gear pairs to ensure statistical reliability, and four pairs (one from each type) were selected for detailed bench testing. The gears were installed in a standard drive axle assembly, with the differential mechanism locked to accommodate the semi-axle closed testing scheme.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of Teeth | 7 | 35 |
| Spiral Angle | 50°11′ | 34°13′ |
| Tooth Height (mm) | 7.32 | 7.19 |
| Hand of Spiral | Left | Right |
| Module (mm) | 4.167 (face module) | |
The testing protocol involved subjecting each hyperboloid gear pair to a series of operational conditions defined by pinion torque $M$ and rotational speed $n$. Two load levels were selected: a medium load of 100 Nm and a heavier load of 175 Nm, each combined with three speed settings: 500 rpm, 1000 rpm, and 1400 rpm. This resulted in six distinct test conditions, denoted as K1 through K6, as detailed in Table 2. During each test, the gear assembly was run from startup until steady-state conditions were achieved, and data were recorded for oil temperature and vibration acceleration. The oil temperature was measured using a thermocouple immersed in the lubricant sump, reflecting the thermal equilibrium and lubrication efficiency. Vibration signals were acquired from two strategic locations on the drive axle housing: at the inner bearing seat of the pinion shaft (Channel A) and at the differential bearing seat on the gear side (Channel B). These signals were processed to compute the root mean square (RMS) value, a statistical measure of vibration intensity, using the formula:
$$ \text{RMS} = \sqrt{ \frac{1}{N} \sum_{i=1}^{N} a_i^2 } $$
where $a_i$ are the discrete acceleration samples and $N$ is the number of samples. This approach allows for a quantitative comparison of the running stability across different hyperboloid gear configurations.
| Condition (K) | Pinion Torque, M (Nm) | Pinion Speed, n (rpm) | Oil Temperature, T (°C) – Type A | Oil Temperature, T (°C) – Type B | Oil Temperature, T (°C) – Type C | Oil Temperature, T (°C) – Type D |
|---|---|---|---|---|---|---|
| 1 | 100 | 500 | 71.5 | 71.5 | 78.5 | 80.0 |
| 2 | 100 | 1000 | 85.5 | 88.0 | 98.0 | 101.0 |
| 3 | 100 | 1400 | 94.7 | 97.7 | 106.0 | 110.5 |
| 4 | 175 | 500 | 86.5 | 93.2 | 88.8 | 91.0 |
| 5 | 175 | 1000 | 103.7 | 109.0 | 108.5 | 109.0 |
| 6 | 175 | 1400 | 114.5 | 121.0 | 123.0 | 123.5 |
The steady-state oil temperatures recorded for the hyperboloid gear pairs under various conditions provide insights into their lubrication performance and thermal behavior. As shown in Table 2, at the medium load of 100 Nm, Type A and Type B hyperboloid gears exhibited similar oil temperatures, averaging around 70-90°C across speeds, while Type C and Type D gears showed higher temperatures, approximately 10°C greater on average. This indicates that hyperboloid gears with contact paths along the tooth height or length have better lubrication conditions under medium loads, likely due to more favorable load distribution and oil film formation. However, at the heavier load of 175 Nm, the temperature differences among the hyperboloid gear types diminished, with all types converging to similar values except for Type A at high speed, which remained slightly lower. This suggests that under high loads, the contact path orientation has a reduced impact on lubrication, possibly because all hyperboloid gears operate in a boundary lubrication regime where the oil film is thin and asperity contact dominates. The thermal power dissipation $P_{\text{loss}}$ in the gear mesh can be estimated using the equation:
$$ P_{\text{loss}} = \mu W v $$
where $\mu$ is the coefficient of friction, $W$ is the normal load, and $v$ is the sliding velocity. The oil temperature rise $\Delta T$ is proportional to $P_{\text{loss}}$ and inversely proportional to the heat dissipation capacity of the system. For hyperboloid gears, the friction coefficient $\mu$ is influenced by the contact path through its effect on pressure distribution and film thickness, explaining the observed temperature variations.
Vibration acceleration RMS values were computed from the signals captured at Channels A and B, offering a measure of the running stability of the hyperboloid gears. The results are summarized in Table 3, which reveals distinct patterns based on contact path orientation. At lower speeds (500 and 1000 rpm), Type B hyperboloid gears consistently demonstrated the lowest vibration levels, indicating superior running stability. At high speed (1400 rpm), Type B and Type C gears performed comparably well, while Type D gears exhibited the highest vibration magnitudes. This aligns with theoretical predictions from LLTCA simulations, which suggest that contact paths along the tooth length or with inward diagonal tendencies enhance meshing smoothness by optimizing the load-sharing among teeth. The vibration behavior can be modeled using a simplified dynamic equation for gear systems:
$$ m \ddot{x} + c \dot{x} + k x = F(t) $$
where $m$ is the equivalent mass, $c$ is the damping coefficient, $k$ is the stiffness, $x$ is the displacement, and $F(t)$ is the time-varying meshing force. For hyperboloid gears, $F(t)$ depends on the contact path orientation, as it affects the transmission error and impact forces during tooth engagement. The RMS value of acceleration $\ddot{x}$ provides a robust indicator of the dynamic response, with lower values corresponding to smoother operation.
| Measurement Channel | Condition (K) | Type A | Type B | Type C | Type D |
|---|---|---|---|---|---|
| Channel A (Pinion Bearing Seat) | 1 | 18.54 | 8.75 | 10.60 | – |
| 2 | 44.00 | 32.80 | 36.49 | 58.84 | |
| 3 | 139.20 | 83.46 | 76.86 | 291.80 | |
| 4 | 21.75 | 12.55 | 14.81 | 38.34 | |
| 5 | 55.87 | 30.24 | 29.30 | 100.20 | |
| 6 | 146.60 | 131.90 | 140.90 | 276.50 | |
| Channel B (Gear Bearing Seat) | 1 | 29.62 | 14.35 | 26.21 | – |
| 2 | 94.43 | 60.48 | 68.95 | 122.30 | |
| 3 | 319.00 | 350.00 | 215.30 | 398.90 | |
| 4 | 34.06 | 22.00 | 39.49 | 79.57 | |
| 5 | 85.56 | 58.49 | 82.03 | 191.60 | |
| 6 | 275.30 | 313.80 | 275.40 | 440.00 |
An intriguing finding from the bench tests is the non-monotonic relationship between running stability and load for hyperboloid gears. As illustrated in Figure 4 (described textually due to output constraints), the vibration RMS values for Type C hyperboloid gears were plotted against pinion torque at different speeds. The curves show that vibration levels do not consistently increase with load; instead, they exhibit a minimum around 100 Nm, indicating an optimal load for stable operation. This phenomenon was observed across multiple hyperboloid gear types, as seen in Figure 5 for Types B and C at 500 rpm, where both gears had the lowest vibration at 100 Nm. This suggests that the optimal load is largely independent of speed and contact path orientation, possibly dictated by the structural dynamics of the gearbox assembly. The optimal load $M_{\text{opt}}$ can be derived from a balance between meshing stiffness variations and damping effects, expressed as:
$$ M_{\text{opt}} = \arg \min_{M} \left( \int_{0}^{T} \ddot{x}^2(t) \, dt \right) $$
where $T$ is the time period of operation. This optimal point likely corresponds to a condition where the excitation forces from tooth meshing are minimized due to favorable phasing of contact transitions.
The discussion of these results emphasizes the practical implications for designing hyperboloid gears. The superior performance of Type B hyperboloid gears (contact path along the tooth length) in terms of both lubrication and vibration aligns with LLTCA predictions, validating the theoretical approach. However, under heavy loads, the advantages diminish, highlighting the need for load-specific design considerations. The inward diagonal contact path (Type C) also shows promise, especially at high speeds, offering a compromise between running stability and axial load management on the pinion shaft. For hyperboloid gears used in automotive applications, where loads vary widely, optimizing the contact path orientation can lead to enhanced durability and noise reduction. The experimental data also reinforce the importance of bench testing as a complement to computational models, as real-world factors like manufacturing tolerances and system compliance can alter performance.
In conclusion, this experimental investigation on hyperboloid gears demonstrates that contact path orientation significantly influences running performance, with contact along the tooth length providing the best combination of lubrication and stability under medium loads. Hyperboloid gears with this configuration exhibited lower oil temperatures and vibration levels, corroborating theoretical insights from advanced analysis methods. However, at heavier loads, the differences among contact path types become less pronounced, suggesting a shift in the dominant failure modes. Additionally, the running stability of hyperboloid gears is not a monotonic function of load, with an optimal load existing around 100 Nm for the tested gearbox, independent of speed and contact path. These findings have direct relevance for the design and application of hyperboloid gears in drivetrain systems, guiding manufacturers toward improved performance and reliability. Future work should extend these tests to include more gear geometries, lubricant types, and long-term durability assessments to further refine the understanding of hyperboloid gear behavior.
To further elaborate on the theoretical aspects, the contact mechanics of hyperboloid gears can be analyzed using stress and strain formulations. The Hertzian contact stress $\sigma_H$ for two curved surfaces in contact is given by:
$$ \sigma_H = \sqrt{ \frac{F E^*}{\pi R^*} } $$
where $F$ is the normal force, $E^*$ is the equivalent elastic modulus, and $R^*$ is the equivalent radius of curvature. For hyperboloid gears, $R^*$ varies along the contact path, influencing stress distribution and fatigue life. The film thickness $h$ in the EHL regime can be approximated by the Hamrock-Dowson equation:
$$ h = 2.69 R’ U^{0.67} G^{0.53} W^{-0.067} $$
where $R’$ is the reduced radius, $U$ is the speed parameter, $G$ is the material parameter, and $W$ is the load parameter. These equations highlight how contact path orientation affects $R’$ and $W$, thereby impacting lubrication performance. In our tests, the variation in oil temperature across hyperboloid gear types can be partially attributed to differences in these parameters, as computed from the gear geometry and operating conditions.
Moreover, the vibration characteristics of hyperboloid gears can be modeled using frequency domain analysis. The power spectral density (PSD) of the acceleration signal $S_a(f)$ reveals the dominant frequencies related to meshing harmonics and structural resonances. For a hyperboloid gear pair, the fundamental meshing frequency $f_m$ is:
$$ f_m = \frac{n Z}{60} $$
where $n$ is the rotational speed in rpm, and $Z$ is the number of teeth on the gear. Sidebands around $f_m$ indicate modulation due to load variations, which are influenced by contact path orientation. The overall vibration level can be integrated from the PSD:
$$ \text{RMS} = \sqrt{ \int_{0}^{f_{\text{max}}} S_a(f) \, df } $$
This frequency-based approach provides deeper insights into the noise and vibration sources in hyperboloid gears, complementing the time-domain RMS measurements from our bench tests.
In summary, the performance of hyperboloid gears is a multifaceted issue involving tribology, dynamics, and thermodynamics. Our experimental study, supported by mathematical models, underscores the critical role of contact path strategy in optimizing hyperboloid gear designs. By leveraging these findings, engineers can develop hyperboloid gears that offer enhanced efficiency, reduced noise, and longer service life, contributing to advancements in mechanical transmission technology. The continuous evolution of hyperboloid gear research, combining bench tests with computational tools, will undoubtedly lead to further innovations in this essential field.