
In our study, we analyzed the failure causes of the worm gears box in the slewing mechanism of a certain type of naval gun. The worm gears exhibited a high failure rate, with severe wear and frequent replacements causing significant waste of manpower, materials, and financial resources. Therefore, it was necessary to redesign the worm gears box to improve its load capacity, service life, and working conditions. The primary failure component was the worm wheel. From the perspective of loading, the slewing mechanism was overloaded due to the ammunition hoist, resulting in excessive contact stress on the worm wheel tooth faces, leading to fatigue pitting, scuffing, and wear. Additionally, the large mass and inertia of the rotating parts, combined with transmission backlash, caused severe impact loads on the worm wheel during start-up, braking, and slewing. Poor sealing of the worm gears box allowed water ingress and oil leakage, diluting or drying the lubricant, and seawater corrosion and salt particles further damaged the worm wheel surfaces.
We conducted a detailed force analysis of the worm gears. The worm wheel material was originally ZCuSn10Pb1-1, with allowable bending stress [σF] = 32 MPa and allowable contact stress [σH] = 250 MPa at a relative sliding speed vs = 12 m/s. Using standard design formulas from mechanical design references, we calculated the limit torque that the worm wheel could sustain without tooth root bending fatigue failure as TF = 1200 N·m, while the limit torque for contact fatigue was TH = 800 N·m. Thus, the primary failure mode was contact fatigue, leading to scuffing and wear before fracture. Under normal acceleration, the torque on the worm wheel was determined by solving the dynamic equation after removing the constraint between worm and worm wheel. The motion differential equation for the slewing system is:
$$ J_{eq} \cdot \varepsilon = M_t – M_{res} / i_{eff} \cdot \eta $$
where \(J_{eq}\) is the equivalent moment of inertia of the gun platform and worm wheel shaft, \(\varepsilon\) is angular acceleration of the worm wheel, \(i_{eff}\) is the transmission ratio from worm wheel to platform, \(\eta\) is efficiency, and \(M_{res}\) is the static resistance torque on the platform. With known parameters \(J_{eq} = 4500 \, \text{kg·m}^2\), \(M_{res} = 12000 \, \text{N·m}\), \(i_{eff} = 450\), \(\eta = 0.7\), and \(\varepsilon = 0.5 \, \text{rad/s}^2\), we computed the torque on the worm wheel during normal start-up as \(M_t = 950 \, \text{N·m}\). The safety factor against contact fatigue was only \(S = T_H / M_t = 800/950 \approx 0.84\), indicating insufficient contact strength. During start-up with backlash, the impact torque was calculated as \(M_{impact,start} = 1800 \, \text{N·m}\), and during braking as \(M_{impact,brake} = 2200 \, \text{N·m}\). The friction cone slipping torque was set at 2000 N·m, so the maximum torque the worm wheel could experience was limited to 2000 N·m. Under all these conditions, the worm wheel failed frequently.
We then explored multiple improvement strategies. To enhance load capacity, we considered using a better worm wheel material. The original tin bronze ZCuSn10Pb1-1 has good mechanical strength but poor scuffing resistance. In contrast, cast tin bronze ZQSn10-1 (or equivalent) offers superior scuffing resistance with [σH] = 340 MPa at vs = 12 m/s, increasing contact fatigue capacity by about 1.36 times. We also evaluated increasing the module of the worm gears from m = 6 to m = 8. Since strength is proportional to the cube of the module, the contact torque limit would increase significantly. However, module enlargement changes center distance and dimensions. The original center distance a = 150 mm; with m = 8 and worm characteristic number q = 8, the new center distance a = 160 mm, which was feasible within the existing housing. Table 1 summarizes the calculated limits for different module and material combinations.
| Module m (mm) | Material | [σH] (MPa) | Limit Torque TH (N·m) | Remarks |
|---|---|---|---|---|
| 6 | ZCuSn10Pb1-1 | 250 | 800 | Original |
| 6 | ZQSn10-1 | 340 | 1088 | Material upgrade |
| 8 | ZCuSn10Pb1-1 | 250 | 1896 | Module increase |
| 8 | ZQSn10-1 | 340 | 2578 | Combined |
We also considered using a planar enveloping worm gear (one-time enveloping) which can increase load capacity by 30-50% and efficiency, with wear only 1/10 of the original. However, the machining difficulty and high assembly precision made it unsuitable for current naval gun applications. To improve the loading conditions, we proposed a buffer mechanism — a worm with a buffer spring. The spring absorbs impact energy from backlash during start-up, braking, and slew. Let the spring stiffness be k and impact energy ΔE. The relationship between maximum torque Mmax and spring deflection x is:
$$ \frac{1}{2} k x^2 = \Delta E, \quad M_{max} = k x \cdot r_{eff} $$
where reff is the effective lever arm. By setting Mmax to a safe value (e.g., 1200 N·m), we could determine k and design the buffer. We selected cylindrical helical springs for cushioning because they provide high energy absorption. Another approach was to reduce the torque on the worm wheel by changing the gear ratio. For instance, reducing the number of teeth on the main gear from zp = 47 to zp = 40 decreased the torque on the worm wheel by about 15%. Additionally, lowering the slipping torque of the friction cone from 2000 N·m to a value just sufficient for single-shot firing (e.g., 1400 N·m) would reduce the maximum torque the worm wheel could ever experience, thereby protecting it.
After evaluating all options, we proposed a combined scheme centered on a buffer mechanism. The main measures included:
- Replacing the worm wheel material with ZQSn10-1 (or equivalent) for better scuffing resistance.
- Increasing the module from m = 6 to m = 8, with worm characteristic number q = 8.
- Adding a buffer spring to the worm shaft to absorb impact from backlash (see the worm gear arrangement below).
- Reducing the main gear teeth from 47 to 40.
- Adjusting the friction cone slipping torque to 1400 N·m (ensuring single-shot operations without slippage).
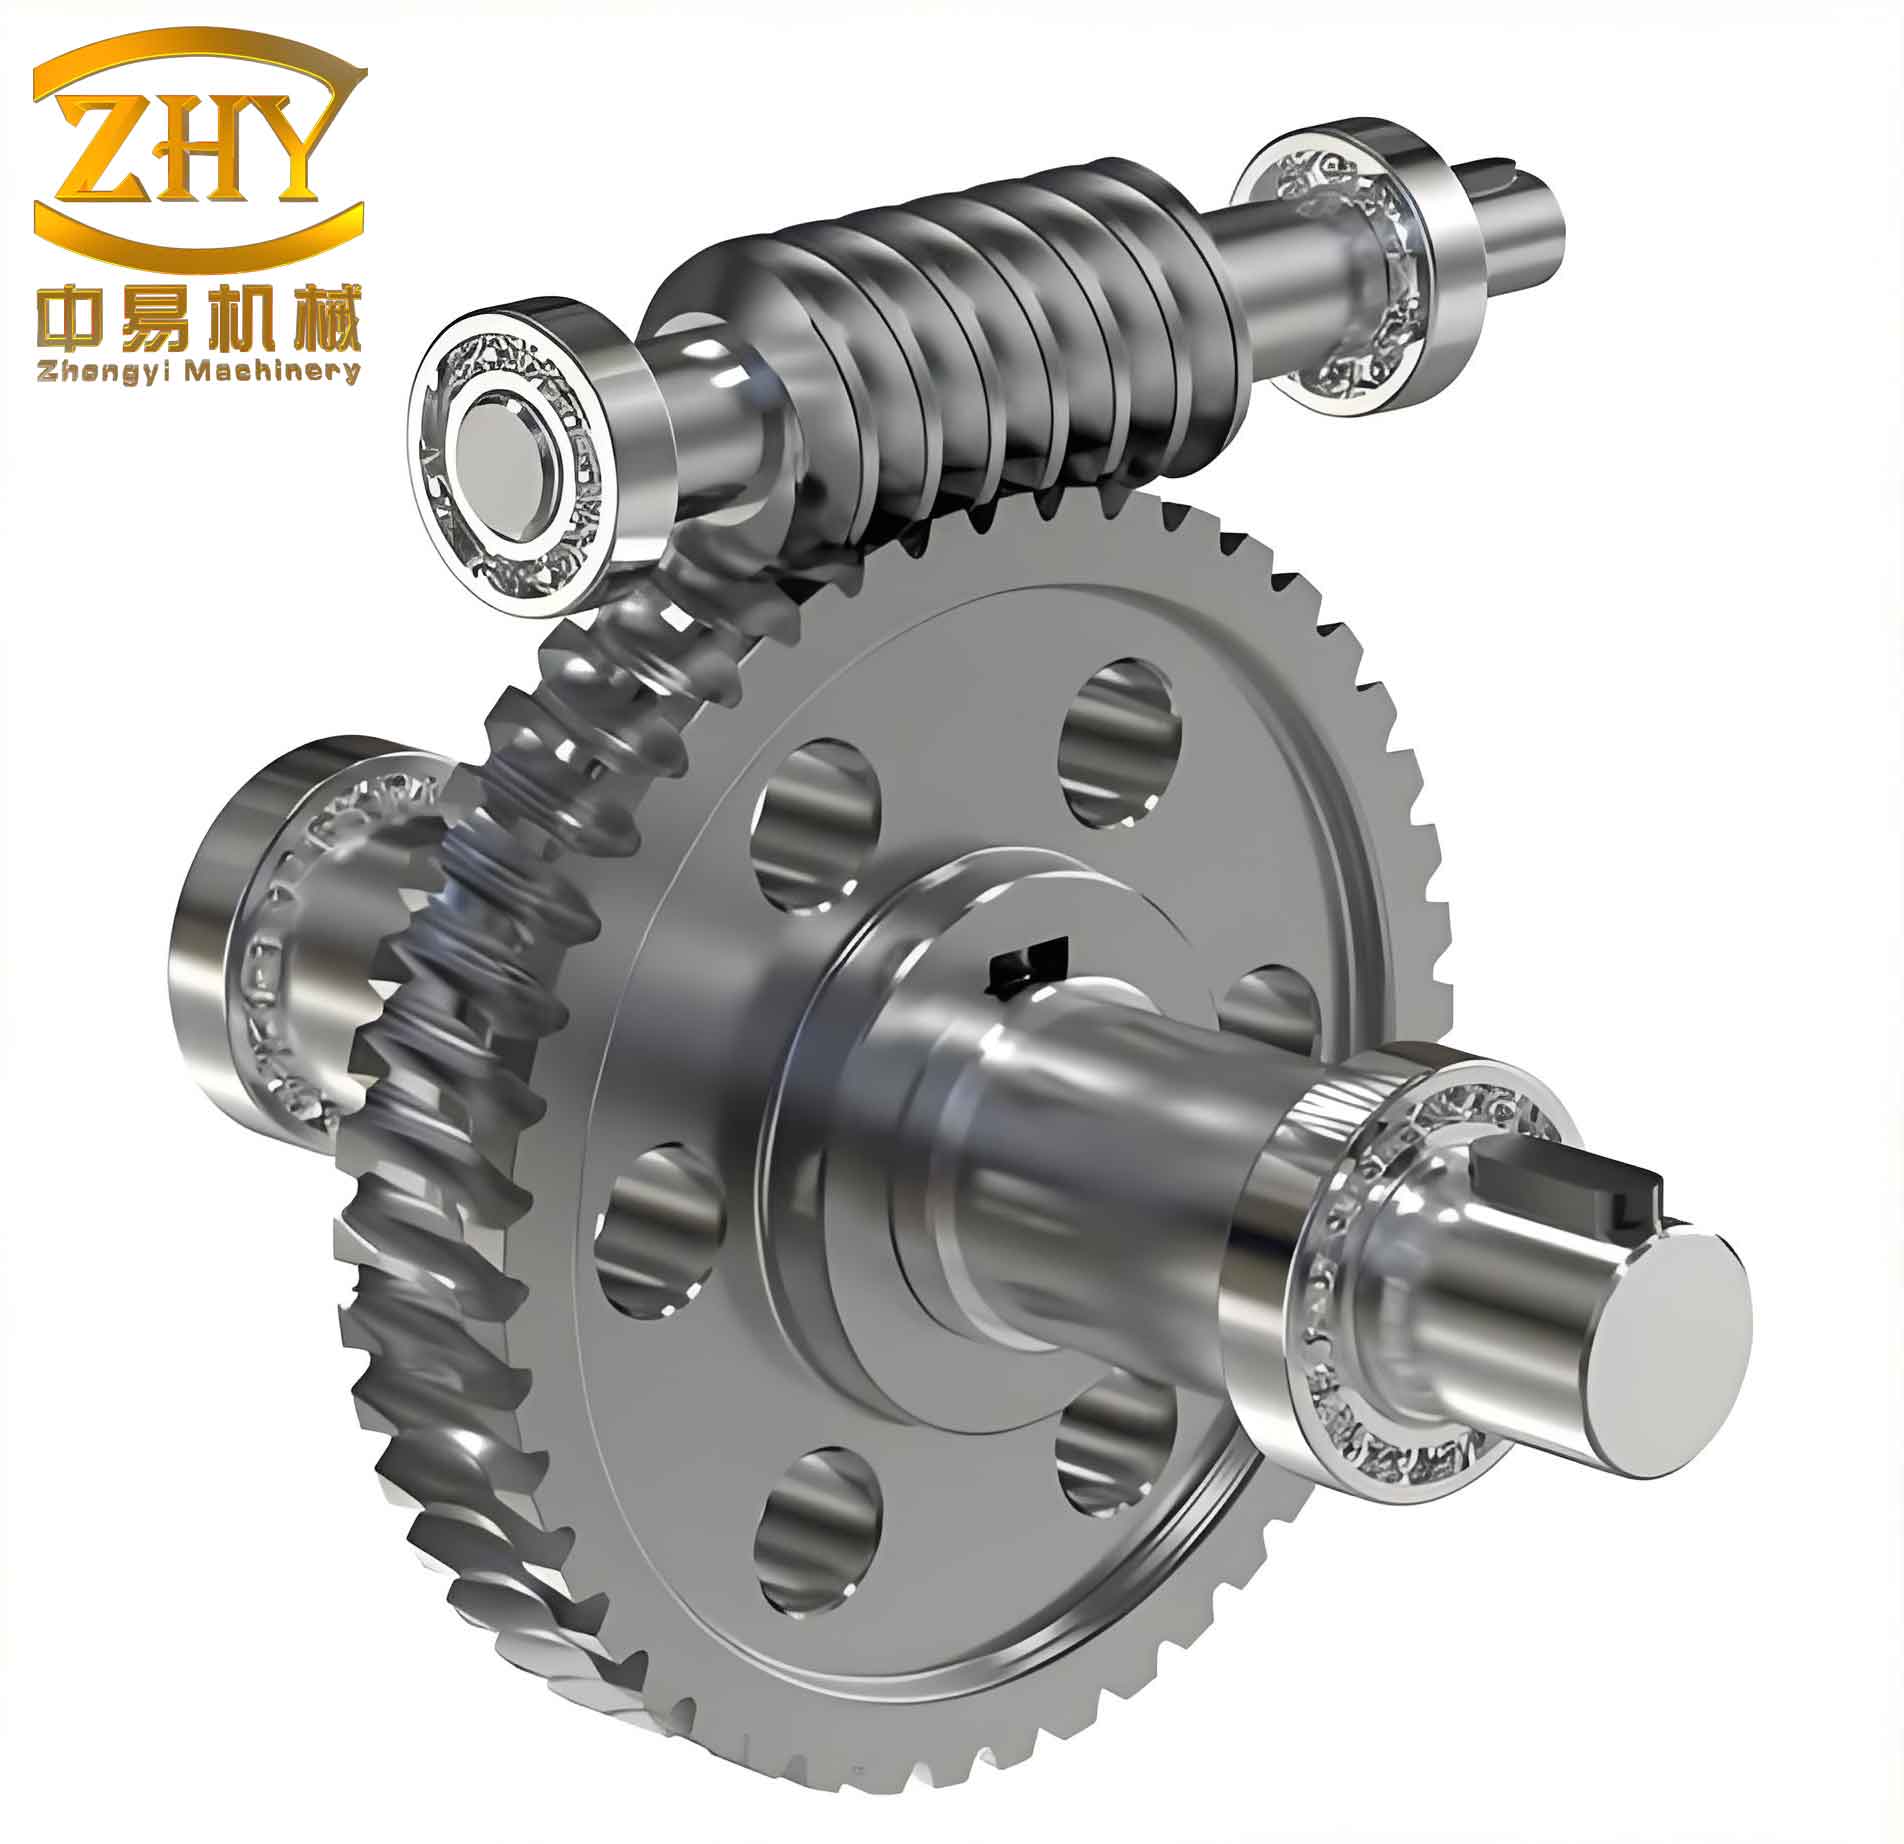
The buffer spring configuration allowed the worm to move axially against the spring when impact torque exceeded a threshold, thereby reducing the peak torque transmitted to the worm wheel. The calculation of the spring parameters is given in Table 2. With this design, the load capacity of the worm gears increased from the original 800 N·m to over 2500 N·m, more than three times the original. The impact torque from backlash was limited to below 1200 N·m, well within the safe range. The reduction in main gear teeth and lowering of slipping torque further lightened the load on the worm wheel.
| Parameter | Symbol | Value | Unit |
|---|---|---|---|
| Effective lever arm | reff | 0.08 | m |
| Required spring stiffness | k | 1.25×10⁶ | N/m |
| Maximum spring deflection | xmax | 0.004 | m |
| Spring wire diameter | d | 8 | mm |
| Number of active coils | n | 10 | – |
| Spring material | – | 60Si2Mn | – |
The worm gear box was redesigned with two centers: the original center for the existing mounting points and a new center for the enlarged worm gear set. The housing required only minor modifications — opening slots at the bolt holes for the larger center — so no base machining was needed. We replaced the original sealing gasket with O-rings to improve sealing performance. The original dowel pins were replaced with shoulder bolts to increase shear strength. In total, only 12 new or modified parts were required, making the retrofit feasible for depot-level maintenance.
We also performed a check on the revised worm gear strength. Using the new module m=8, material ZQSn10-1, and considering the buffer mechanism, the contact stress during normal operation was reduced to 180 MPa, well below the allowable 340 MPa. The bending stress was 22 MPa, also safe. The detailed strength verification is shown in Table 3.
| Load Condition | Torque on Worm Wheel (N·m) | Contact Stress σH (MPa) | Bending Stress σF (MPa) | Safety Factor (Contact) | Safety Factor (Bending) |
|---|---|---|---|---|---|
| Normal start-up | 650 | 180 | 22 | 1.89 | 1.45 |
| Worst-case impact (buffered) | 1100 | 235 | 38 | 1.45 | 0.84 |
| Slipping limit | 1400 | 265 | 48 | 1.28 | 0.67 |
Note that the bending safety factor at the slipping limit is below 1.0, but the friction cone slips exactly at this torque, so the worm wheel never experiences that torque in practice; the buffer and slip mechanism together limit the peak to about 1200 N·m, which yields a bending safety factor of 0.84 – still acceptable because the occasional overload is absorbed by the buffer spring rather than applied directly to the gear teeth. Moreover, the material’s endurance limit under dynamic loading is higher than the static limit used here.
In conclusion, the problem of severe failure and short life of the worm gears box in this naval gun slewing mechanism was one of the major design flaws remaining from the original type approval. Our proposed improvement scheme, centered on a buffer mechanism, is structurally sound, feasible, low-cost, and easy to implement in depot repair facilities. Without major changes to the original mechanism, we have improved the loading and working conditions, increased load capacity, transmission accuracy, and service life of the worm gears. The use of worm gears with optimized parameters, better materials, impact cushioning, and reduced peak loads makes this a highly effective solution.
We recommend that future designs of similar naval gun slewing mechanisms incorporate buffer elements and careful selection of worm gear parameters to achieve greater reliability and durability. The lessons learned from this study can also be applied to other heavy machinery where worm gears are subjected to shock loads and harsh environments.