
High-performance motion control systems, such as industrial robots and precision radar drives, impose stringent requirements for low vibration and high positional accuracy. The RV reducer is a critical component in these systems due to its compact size, high rigidity, and large reduction ratio, which is achieved through a two-stage compound planetary gear train. The first stage is a K-H type involute planetary gear train, and the second stage is a K-H-V type cycloidal pin gear planetary train. Understanding the dynamic behavior, particularly the torsional vibration characteristics, is paramount to mitigating chatter and ensuring smooth operation. While prior research has extensively covered transmission accuracy and established various dynamic models, significant gaps remain, such as the influence of the cycloid gear’s eccentric phase angle on system dynamics and a quantitative sensitivity analysis of system parameters. This work addresses these gaps by developing a refined torsional dynamic model that incorporates additional degrees of freedom and systematically analyzes the inherent characteristics and parametric sensitivities of the RV reducer.
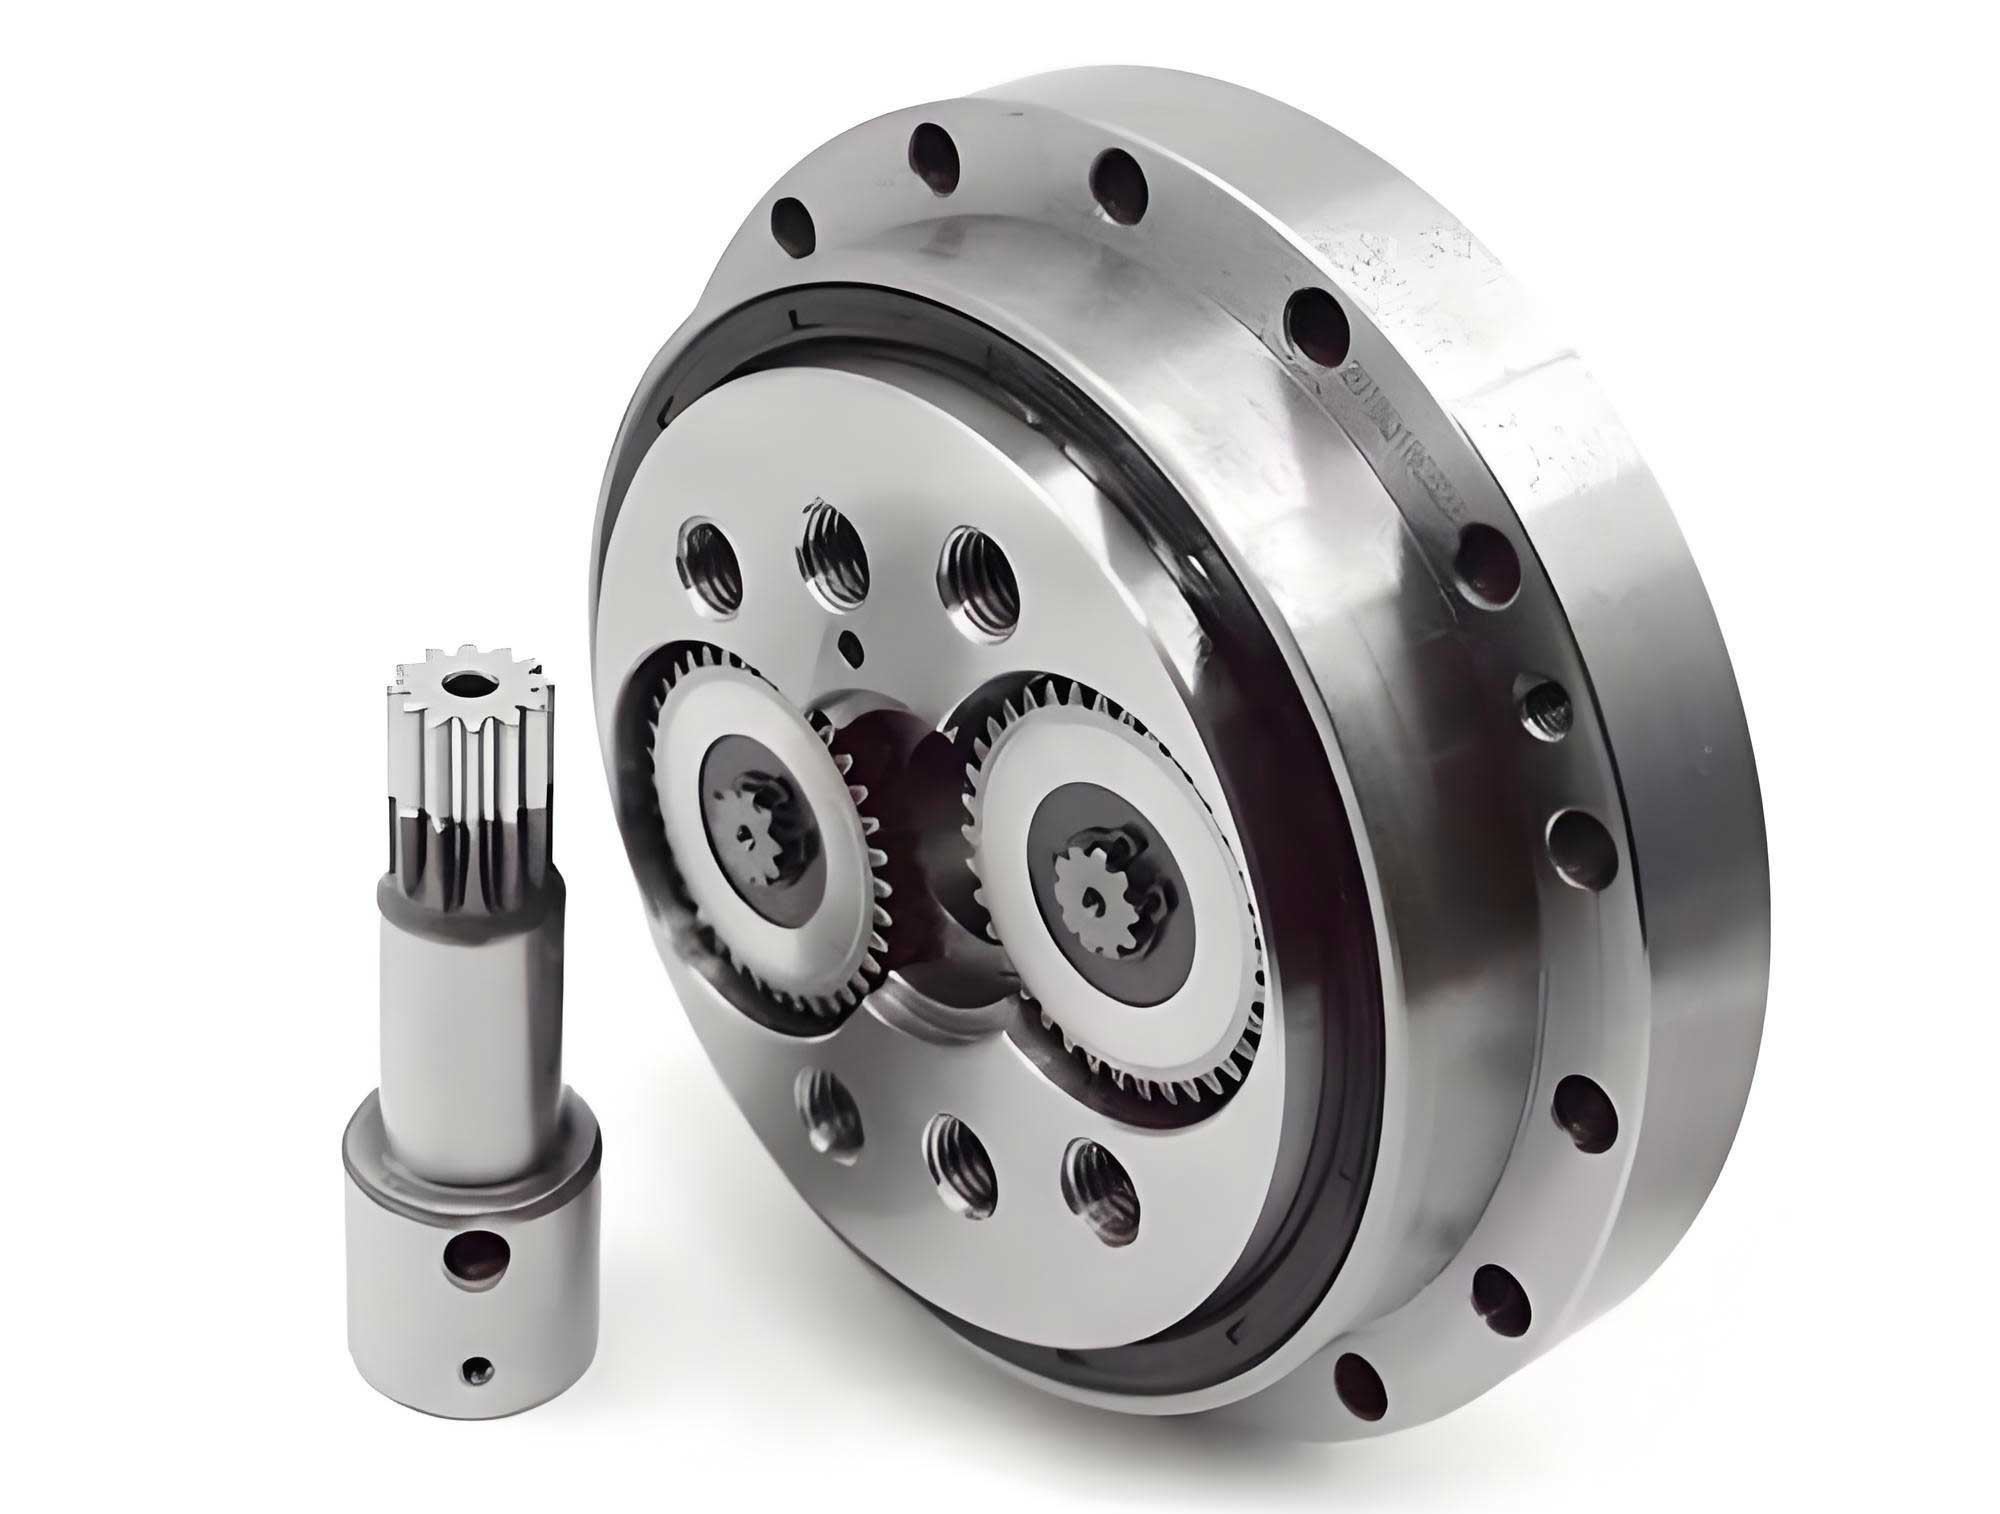
The structural composition of an RV reducer is key to its function. The input shaft drives a sun gear, which meshes with multiple (typically 2 or 3) planetary gears in the first stage. Each planetary gear is integrated with a crankshaft. The crankshafts, equally spaced on a common circle, each have an eccentric section. Two cycloid gears, mounted 180 degrees apart on these eccentric sections, engage with a stationary ring of pin gears. The crankshafts are also supported by bearings housed in the planet carrier (output carrier). As the crankshafts rotate, they cause the cycloid gears to undergo a compound epicyclic motion—a combination of revolution (eccentric wobble) and reverse rotation. This reverse rotation of the cycloid gears forces the crankshafts to revolve around the central axis, which in turn drives the planet carrier, providing the final low-speed, high-torque output.
To accurately capture the dynamics of this complex system, a 13-degree-of-freedom (13-DOF) modified torsional vibration model is established using the lumped-parameter method. This model advances upon traditional pure torsional models by incorporating the tangential translational motions of the crankshafts and cycloid gears during their revolution, and by accounting for the periodic variation in the interaction forces between the crankshafts and cycloid gears due to the changing eccentric angle \(\beta\). The model is based on several simplifying assumptions: geometric centers coincide with mass centers; stiffness values (bearings, gear meshes) are linearized averages; damping and friction are neglected; forces between the cycloid gear and pin gear are treated as concentrated; and crankshaft bending deformation is considered negligible compared to bearing compliance.
The model defines 13 generalized coordinates: 9 torsional angular displacements (converted to equivalent linear displacements \(u\)) for the input shaft, sun gear, two planetary gears, two crankshafts, two cycloid gears, and the planet carrier; plus 4 tangential translational displacements (\(x\)) for the two crankshafts and two cycloid gears. A coordinate system fixed to the rotating planet carrier is used, with the origin at the center of the pin gear ring. The eccentric angle \(\beta\) defines the instantaneous orientation of the line connecting the pin gear center to the theoretical center of the first cycloid gear relative to the carrier-fixed frame.
The interaction between a crankshaft \(i\) and a cycloid gear \(j\) is particularly critical. The relative displacement in the direction of the eccentric line (denoted \(\eta\)) for the pair (1,1), for example, is given by:
$$\delta \eta_{11} = u_{h1} – x_{h1}\cos\beta + u_{c1}\cos\beta – x_{c1}$$
The corresponding force is \(F_{h1c1} = k_{hc} \cdot \delta \eta_{11}\), where \(k_{hc}\) is the support stiffness of the crank bearing (arm bearing). The force component in the perpendicular tangential direction (\(x\)-direction) is derived similarly. This formulation explicitly includes the \(\cos\beta\) term, which introduces the parametric variation linked to the eccentric angle.
Applying Newton’s second law to all components yields the system’s matrix-form equation of motion for free vibration:
$$ \mathbf{M}\ddot{\mathbf{X}} + \mathbf{K}(\beta)\mathbf{X} = \mathbf{0} $$
where \(\mathbf{M}\) is the constant mass/inertia matrix, \(\mathbf{K}(\beta)\) is the stiffness matrix that is a periodic function of the eccentric angle \(\beta\), and \(\mathbf{X}\) is the vector of the 13 generalized coordinates. The specific expressions for the mass and stiffness matrices, derived from force balances, are omitted here for brevity but follow standard lumped-parameter modeling procedures for gear trains with the added translational coordinates.
The inherent dynamic characteristics are found by solving the associated eigenvalue problem from the free-vibration equation:
$$ \left( \mathbf{K}(\beta) – \omega_i^2 \mathbf{M} \right) \boldsymbol{\phi}_i = \mathbf{0} $$
Here, \(\omega_i\) is the \(i\)-th natural frequency (in rad/s) and \(\boldsymbol{\phi}_i\) is its corresponding mass-normalized mode shape vector. The periodic dependence of \(\mathbf{K}\) on \(\beta\) means the eigenvalues and eigenvectors also vary with \(\beta\).
A case study was performed on an RV reducer with the following key parameters:
| Parameter Group | Symbol | Value | Unit |
|---|---|---|---|
| Involute Stage | Sun Gear Teeth (\(Z_s\)) | 10 | – |
| Planet Gear Teeth (\(Z_p\)) | 34 | – | |
| Module (\(m\)) / Pressure Angle (\(\alpha\)) | 1 mm / 20° | – | |
| Cycloid Stage | Cycloid Gear Teeth (\(Z_c\)) | 29 | – |
| Pin Gear Teeth (\(Z_b\)) | 30 | – | |
| Short Width Coefficient (\(K\)) | 0.675 | – | |
| Eccentricity (\(a\)) | 0.9 | mm | |
| Stiffness (Calculated Mean Values) | \(k_{sp}, k_{cd}, k_{hc}, k_{oh}\) | Derived from geometry & Hertzian contact | N/m |
| Masses & Inertias | \(m_p, m_h, m_c, J_s, J_p, …\) | Obtained from 3D CAD model | kg, kg·m² |
The calculated first seven natural frequencies are shown below. A distinct pattern emerges related to the eccentric angle \(\beta\).
| Mode Order | Frequency (Hz) | Dependence on \(\beta\) |
|---|---|---|
| 1 | 121.4 | Constant (Independent) |
| 2 | ~245 – 260 | Periodic Variation |
| 3 | 587.8 | Constant (Independent) |
| 4 | ~1250 – 1320 | Periodic Variation |
| 5 | 1540.5 | Constant (Independent) |
| 6 | ~2100 – 2250 | Periodic Variation |
| 7 | 2875.1 | Constant (Independent) |
The results reveal a fundamental characteristic: the odd-numbered natural frequencies of the RV reducer system remain constant, unaffected by the periodic change in the cycloid gear’s eccentric angle \(\beta\). Their corresponding mode shapes are also constant. Furthermore, due to system symmetry, components like the two planetary gears, two crankshafts, and two cycloid gears exhibit mode shapes of identical magnitude and direction for these odd modes.
Conversely, the even-numbered natural frequencies exhibit a clear, periodic variation with \(\beta\), following a near-triangular wave pattern. Their associated mode shapes display a “planet vibration mode.” In these modes, central components (input shaft, sun gear, planet carrier) have negligible vibration (near-zero modal displacement), while the planetary components (planet gears, crankshafts, cycloid gears) vibrate. The two planets, two crankshafts, and two cycloids vibrate with the same magnitude but in opposite directions (out of phase). This phenomenon can be explained by planetary gear phasing theory: the internal meshing forces act as harmonic excitations. For even-order harmonics, the force contributions on central components from symmetrically arranged planets cancel out, leaving them stationary. However, the forces on individual planetary components do not cancel, resulting in the observed anti-phase vibrations.
The validity of the model was checked by comparing the calculated first natural frequency (121.4 Hz) with an experimental measurement obtained via impact testing (126.9 Hz). The close agreement supports the model’s accuracy. Importantly, the fundamental frequency is well above the typical input rotational frequency (e.g., 50 Hz for 3000 rpm), indicating a low risk of resonance under normal operating conditions.
Sensitivity analysis is crucial for efficient design and optimization, identifying parameters that most influence dynamic performance. The partial derivative method is employed here for its clarity. For a non-damped system with a symmetric mass matrix \(\mathbf{M}\) and stiffness matrix \(\mathbf{K}\), the sensitivity of the i-th natural frequency \(\omega_i\) to a system parameter \(p_j\) (e.g., an inertia or stiffness) is given by:
$$ \frac{\partial \omega_i}{\partial p_j} = \frac{1}{2\omega_i} \boldsymbol{\phi}_i^T \left( \frac{\partial \mathbf{K}}{\partial p_j} – \omega_i^2 \frac{\partial \mathbf{M}}{\partial p_j} \right) \boldsymbol{\phi}_i $$
A normalized (dimensionless) sensitivity index \(S_{p_j}^{\omega_i}\) is often more informative:
$$ S_{p_j}^{\omega_i} = \frac{p_j}{2\omega_i^2} \boldsymbol{\phi}_i^T \left( \frac{\partial \mathbf{K}}{\partial p_j} – \omega_i^2 \frac{\partial \mathbf{M}}{\partial p_j} \right) \boldsymbol{\phi}_i $$
This index represents the fractional change in frequency per fractional change in parameter.
The analysis focuses on the first four natural frequencies (at \(\beta=0\)) due to their dominant influence on system response. The normalized sensitivities with respect to key inertia parameters are summarized below:
| Component Inertia | Sensitivity (Mode 1) | Sensitivity (Mode 2) | Sensitivity (Mode 3) | Sensitivity (Mode 4) |
|---|---|---|---|---|
| Planet Carrier (\(J_o\)) | -0.42 | ~0 | -0.08 | ~0 |
| Crankshaft (\(J_h\)) | -0.25 | -0.31 | -0.15 | -0.12 |
| Sun Gear (\(J_s\)) | -0.18 | ~0 | -0.22 | ~0 |
| Cycloid Gear (\(J_c\)) | -0.05 | -0.11 | -0.01 | -0.28 |
| Planet Gear (\(J_p\)) | -0.04 | -0.05 | -0.10 | -0.04 |
The normalized sensitivities with respect to key stiffness parameters are:
| Stiffness Parameter | Sensitivity (Mode 1) | Sensitivity (Mode 2) | Sensitivity (Mode 3) | Sensitivity (Mode 4) |
|---|---|---|---|---|
| Support Bearing (\(k_{oh}\)) | +0.38 | ~0 | +0.10 | ~0 |
| Arm/Crank Bearing (\(k_{hc}\)) | +0.22 | +0.29 | +0.18 | +0.15 |
| Involute Mesh (\(k_{sp}\)) | +0.15 | ~0 | +0.25 | ~0 |
| Cycloid-Pin Mesh (\(k_{cd}\)) | +0.03 | +0.08 | +0.02 | +0.32 |
| Shaft Torsion (\(k_{as}, k_{ph}\)) | <+0.01 | <+0.01 | <+0.01 | <+0.01 |
The sensitivity results lead to several key insights for the RV reducer:
- Critical Inertias: The natural frequencies, particularly the fundamental mode, are most sensitive to the inertia of the planet carrier (\(J_o\)) and the crankshafts (\(J_h\)). Modifying these inertias offers the most effective way to tune the low-frequency dynamic behavior.
- Critical Stiffnesses: Bearing stiffnesses—specifically the output support bearing stiffness (\(k_{oh}\)) and the crank arm bearing stiffness (\(k_{hc}\))—are the dominant stiffness factors affecting natural frequencies. Their sensitivity indices are consistently high across multiple modes. In contrast, gear mesh stiffnesses and shaft torsional stiffnesses show lower influence.
- Mode-Specific Patterns: For odd modes (1, 3), central component parameters (carrier inertia, sun gear inertia, support bearing stiffness, involute mesh stiffness) show significant sensitivity. For even modes (2, 4), planet-class component parameters (crankshaft inertia, cycloid gear inertia, arm bearing stiffness, cycloid mesh stiffness) are more influential, consistent with their planet-mode vibration shapes.
The paramount importance of bearing stiffness has direct practical implications for the RV reducer. These bearings operate under high loads due to the large transmission ratio. Fatigue, wear, or improper preload can degrade their effective stiffness over time. To investigate this risk, the first natural frequency was recalculated as a function of reduced bearing stiffness. The results show a pronounced, non-linear decrease in the fundamental frequency as bearing stiffness degrades. If stiffness falls sufficiently, the natural frequency could approach the operating frequency range, dramatically increasing the risk of resonance and severe vibration. This underscores that bearing selection, lubrication, and life management are critical not just for mechanical integrity but also for maintaining stable dynamic performance over the life of the RV reducer.
In conclusion, this analysis provides a comprehensive investigation into the torsional vibration dynamics of the RV reducer. The developed 13-DOF modified model, which incorporates the tangential translation of crankshafts and cycloid gears and the effect of the cycloid eccentric angle, offers a more refined representation of the system physics. The key findings are:
- The periodic variation of the cycloid gear’s eccentric angle induces a corresponding periodic modulation in the system’s even-order natural frequencies and their associated planet-type mode shapes, while odd-order frequencies remain constant.
- Sensitivity analysis quantitatively identifies the planet carrier inertia, crankshaft inertia, support bearing stiffness, and crank arm bearing stiffness as the most influential parameters on the system’s natural frequencies.
- Bearing stiffness is the single most critical design factor for dynamic stability. Its potential degradation during service is a primary risk factor for shifting natural frequencies into problematic ranges, highlighting the need for robust bearing design and maintenance in high-performance RV reducer applications.
This work establishes a framework for dynamic analysis and provides clear guidance for the design optimization of RV reducers aimed at achieving superior vibration performance and operational reliability.