
In the field of mechanical power transmission, gear systems play a pivotal role, with screw gears being among the most critical components for motion conversion between non-parallel shafts. Traditional screw gear systems, particularly worm drives, are renowned for their high load capacity and compact design. However, they suffer from significant drawbacks, primarily excessive sliding friction, which leads to low transmission efficiency, severe wear, heat generation, and potential seizure. These limitations have driven extensive research into alternative screw gear configurations that mitigate sliding contact. One promising avenue is the adoption of rolling elements to replace sliding contacts, effectively transforming friction mechanisms. This paper presents a comprehensive meshing theory analysis of a novel screw gear system: the modified roller enveloping hourglass worm drive. This system evolves from the single-roller enveloping toroidal meshing worm drive by incorporating a parabolic modification to the roller profile. The primary objective is to establish a rigorous mathematical model based on spatial meshing theory, derive key performance parameters, and evaluate the meshing characteristics to demonstrate its superior performance. I will delve into the fundamental principles, coordinate system constructions, mathematical derivations, and parametric analyses, all while emphasizing the relevance to advanced screw gear technology.
The core innovation lies in substituting the conventional cylindrical or conical roller in enveloping worm drives with a parabolic-modified roller. This modification aims to enhance lubrication retention and prevent thermal expansion-induced jamming by reducing the roller tip radius. The basic operational principle involves an hourglass-shaped worm that meshes with a worm wheel equipped with multiple parabolic rollers. These rollers can rotate about their own axes, converting the typical sliding friction in traditional screw gears into rolling friction. The drive is designed for unilateral contact to avoid locking, with deliberate clearance on the non-working flanks. This configuration inherently increases the number of contacting tooth pairs, thereby boosting load capacity and transmission efficiency, hallmarks of improved screw gear performance. The parabolic profile, compared to linear generatrices, offers better conditions for forming elastohydrodynamic lubrication films, a crucial aspect for durable screw gear operation.
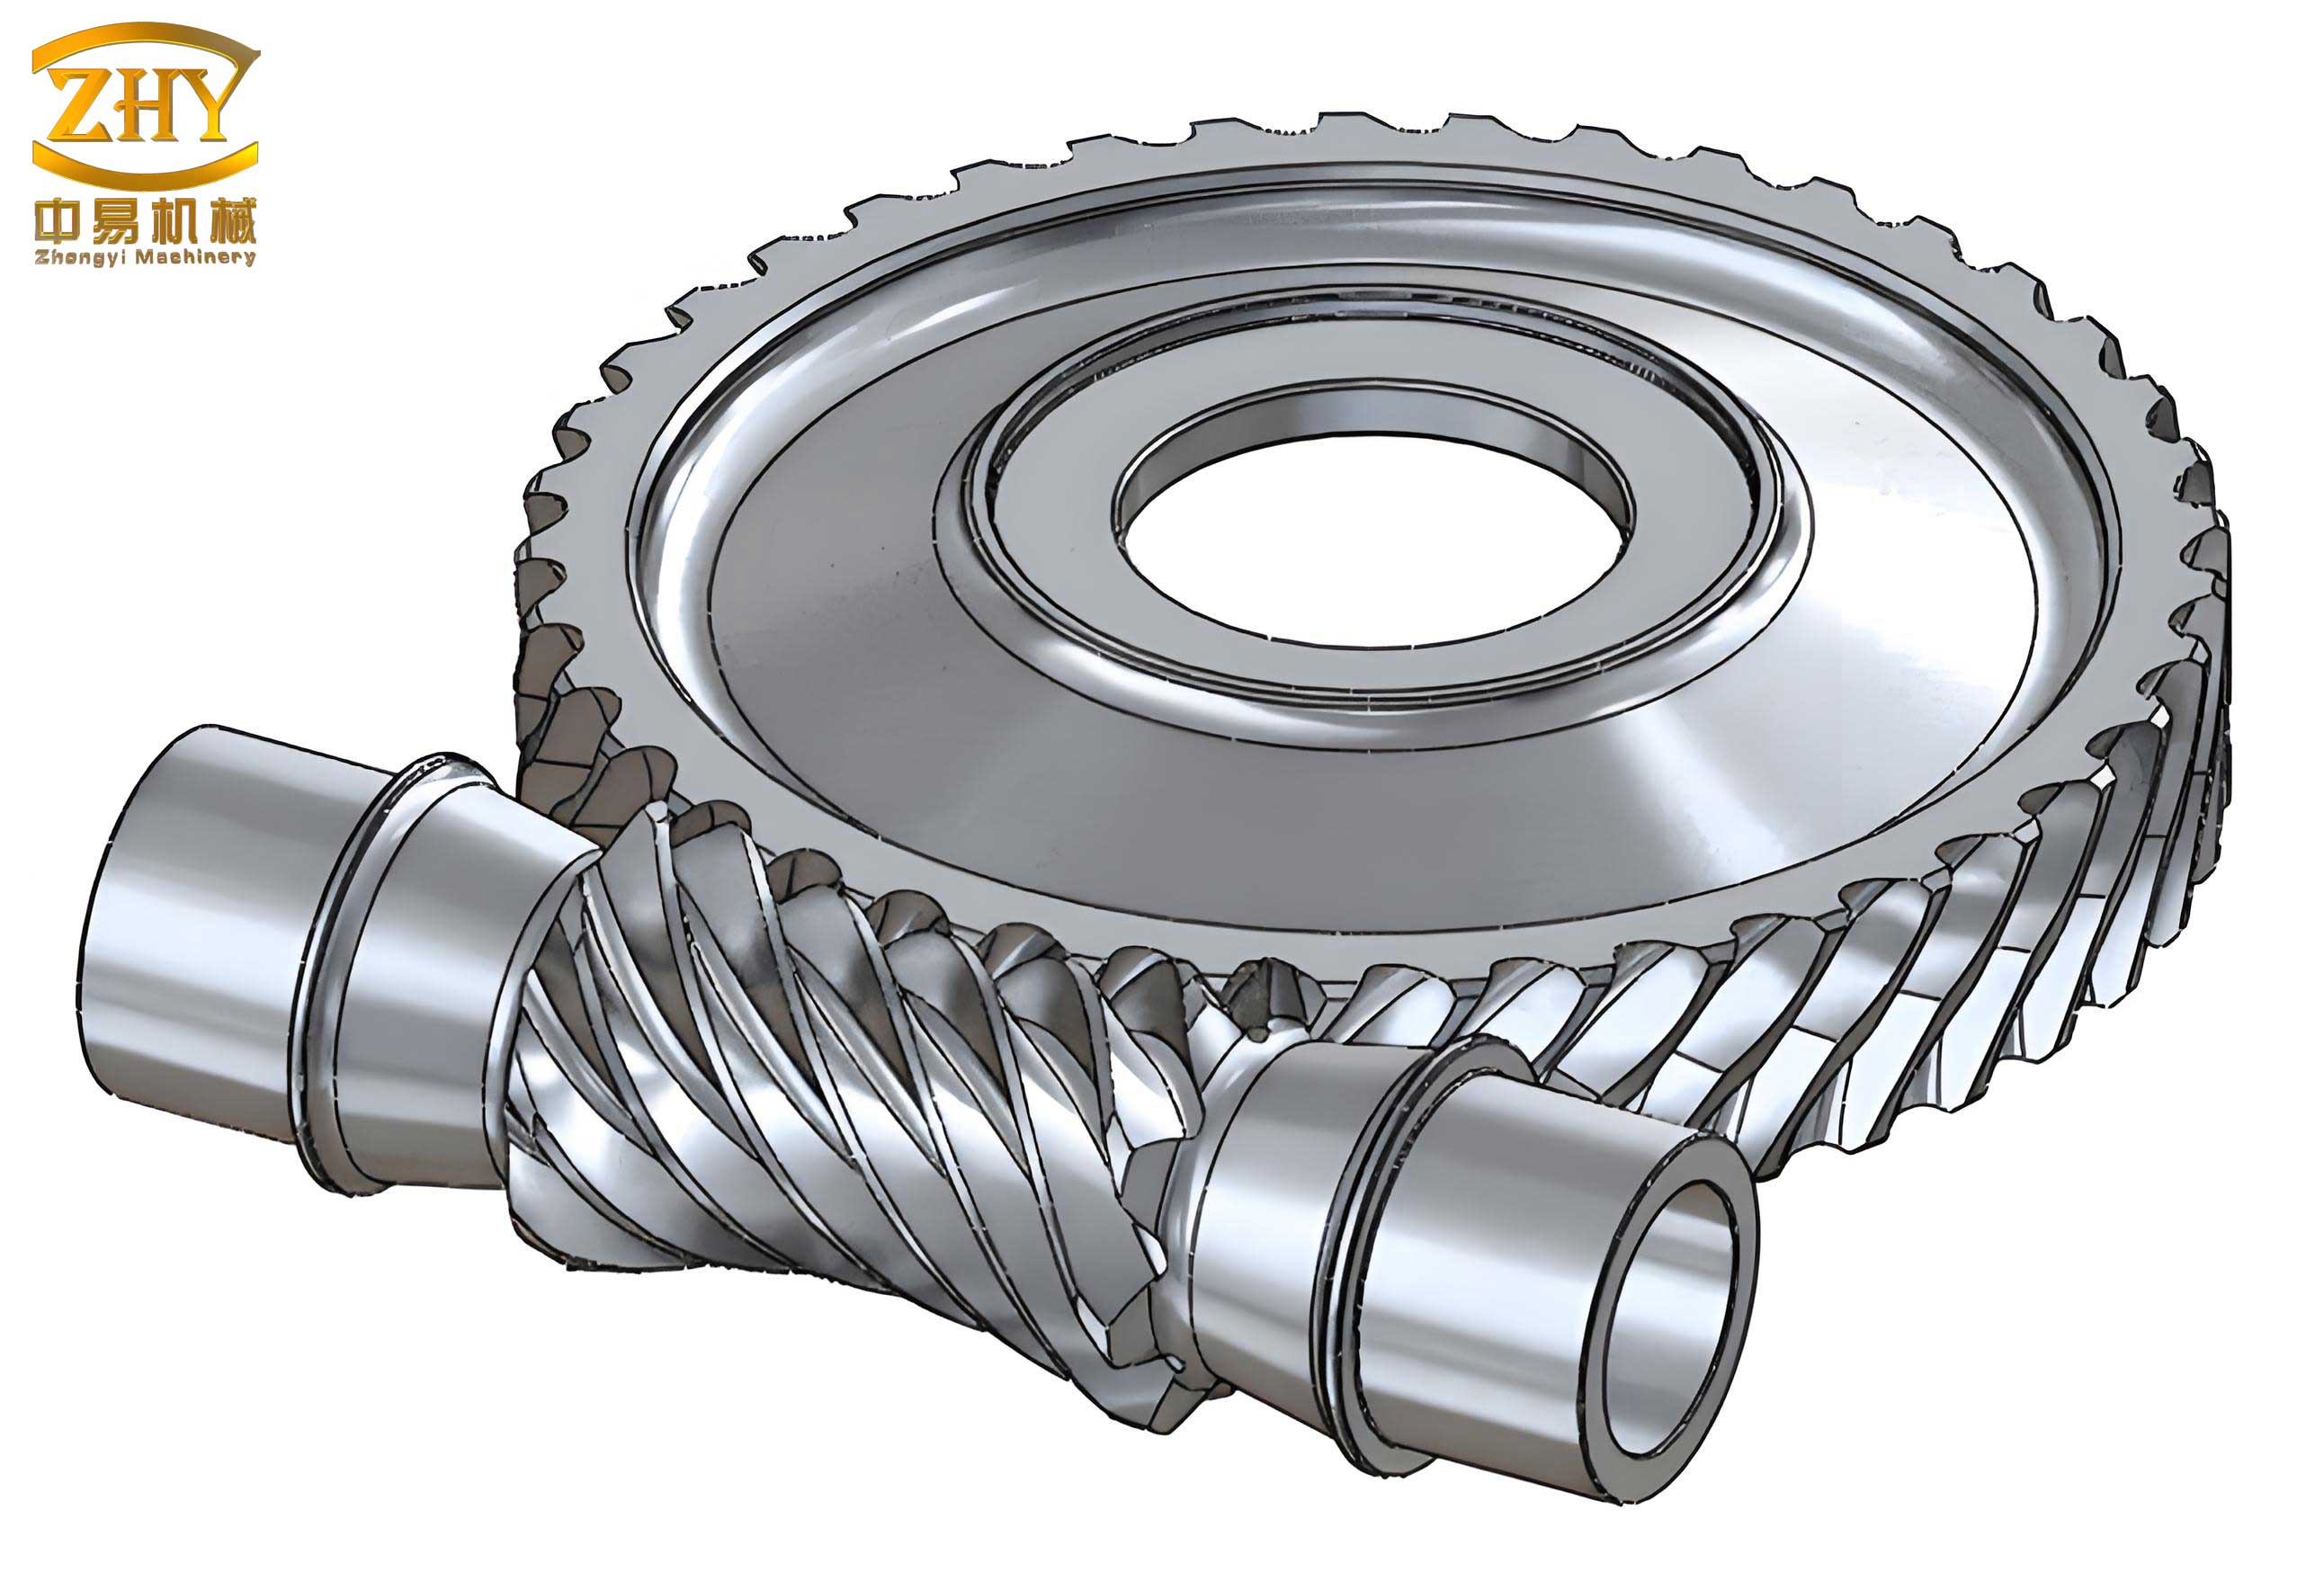
To analyze this complex screw gear system, a robust mathematical framework is essential. The first step involves defining a series of coordinate systems to describe the spatial relationship between the worm and the worm wheel. Let’s establish the following reference frames: a fixed coordinate system $S_1′(O_1′; \mathbf{i}_1′, \mathbf{j}_1′, \mathbf{k}_1′)$ attached to the worm housing, and a moving coordinate system $S_1(O_1; \mathbf{i}_1, \mathbf{j}_1, \mathbf{k}_1)$ that rotates with the worm. Similarly, for the worm wheel, we have $S_2′(O_2′; \mathbf{i}_2′, \mathbf{j}_2′, \mathbf{k}_2′)$ as the fixed frame and $S_2(O_2; \mathbf{i}_2, \mathbf{j}_2, \mathbf{k}_2)$ as the rotating frame. The parabolic roller has its own coordinate system $S_0(O_0; \mathbf{i}_0, \mathbf{j}_0, \mathbf{k}_0)$ fixed to its axis, with $O_0$ located at $(a_2, 0, 0)$ in $S_2$. At the instantaneous point of contact $O_p$ on the roller surface, an active moving frame $S_p(O_p; \mathbf{e}_1, \mathbf{e}_2, \mathbf{n})$ is defined, where $\mathbf{n}$ is the unit normal vector, and $\mathbf{e}_1$ and $\mathbf{e}_2$ are orthogonal unit vectors in the tangent plane. The transformation matrices between these systems are derived from rotation and translation operations. For instance, the transformation from $S_1$ to $S_1’$ is given by:
$$
\mathbf{Q}_{1′} = \mathbf{M}_{1’1} \mathbf{Q}_1, \quad \mathbf{M}_{1’1} = \begin{bmatrix}
\cos\phi_1 & -\sin\phi_1 & 0 & 0 \\
\sin\phi_1 & \cos\phi_1 & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}
$$
where $\phi_1$ is the rotation angle of the worm, and $\mathbf{Q}$ denotes homogeneous coordinates. Similarly, the transformation from the worm wheel frame $S_2$ to the worm frame $S_1$ involves the center distance $A$ and the rotation angles $\phi_1$ and $\phi_2$, related by the transmission ratio $i_{12} = \phi_1 / \phi_2 = \omega_1 / \omega_2 = z_2 / z_1$. The composite matrix $\mathbf{M}_{21}$ is:
$$
\mathbf{M}_{21} = \begin{bmatrix}
-\cos\phi_1 \cos\phi_2 & \sin\phi_1 \cos\phi_2 & -\sin\phi_2 & A\cos\phi_2 \\
\cos\phi_1 \sin\phi_2 & -\sin\phi_1 \sin\phi_2 & -\cos\phi_2 & -A\sin\phi_2 \\
-\sin\phi_1 & -\cos\phi_1 & 0 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}.
$$
The surface of the parabolic roller in $S_0$ is described by the vector equation:
$$
\mathbf{r}_0 = x_0 \mathbf{i}_0 + y_0 \mathbf{j}_0 + z_0 \mathbf{k}_0, \quad \text{with} \quad
\begin{cases}
x_0 = R \cos\theta, \\
y_0 = R \sin\theta, \\
z_0 = u, \\
R = \sqrt{\frac{(R_1^2 – R_2^2)u + u_1 R_2^2}{u_1}},
\end{cases}
$$
where $u$ and $\theta$ are the surface parameters, $R_1$ and $R_2$ are the root and tip radii of the roller, $u_1 = m(h_{ac} + h_{fc} + c_c)$ is the total tooth height, and $m = (2 – k)A / z_2$ is the module. This parabolic profile distinguishes it from standard cylindrical rollers in conventional screw gears.
Kinematic analysis requires determining the relative velocity and angular velocity at the contact point. Let $\boldsymbol{\omega}_1 = \omega_1 \mathbf{k}_1$ and $\boldsymbol{\omega}_2 = \omega_2 \mathbf{k}_2 = i_{21} \omega_1 \mathbf{k}_2$ be the angular velocities of the worm and wheel, respectively, with $i_{21} = 1/i_{12}$. Setting $\omega_1 = 1$ for simplicity, the relative angular velocity vector in $S_2$ is:
$$
\boldsymbol{\omega}_{12} = \boldsymbol{\omega}_1 – \boldsymbol{\omega}_2 = -\sin\phi_2 \mathbf{i}_2 – \cos\phi_2 \mathbf{j}_2 – i_{21} \mathbf{k}_2.
$$
The relative velocity vector $\mathbf{v}_{12}$ at the contact point, considering the fixed center distance, is derived from the kinematic chain:
$$
\mathbf{v}_{12} = \boldsymbol{\omega}_{12} \times \mathbf{r}_1 – \boldsymbol{\omega}_2 \times \boldsymbol{\xi},
$$
where $\mathbf{r}_1$ is the position vector of the contact point in $S_1$, and $\boldsymbol{\xi} = A\cos\phi_2 \mathbf{i}_2 – A\sin\phi_2 \mathbf{j}_2$ is the center distance vector. In $S_2$, its components are:
$$
\mathbf{v}_{12} = B_1 \mathbf{i}_2 + B_2 \mathbf{j}_2 + B_3 \mathbf{k}_2, \quad \text{with} \quad
\begin{cases}
B_1 = y_2 i_{21} – z_2 \cos\phi_2, \\
B_2 = -x_2 i_{21} + z_2 \sin\phi_2, \\
B_3 = x_2 \cos\phi_2 – y_2 \sin\phi_2 – A.
\end{cases}
$$
Transforming $\mathbf{v}_{12}$ into the active frame $S_p$ involves the transformation matrix $\mathbf{A}_{p2}$, which depends on the angle $\beta = \pi/2 – \arctan\left(\frac{2u_1}{R_1^2 – R_2^2} R\right)$. This angle characterizes the local orientation of the parabolic surface relative to the roller axis, a critical detail for screw gear contact mechanics.
The fundamental condition for meshing in any screw gear system is the continuity of contact, expressed by the equation $\mathbf{v}_{12} \cdot \mathbf{n} = 0$, i.e., the relative velocity has no component along the common normal at the contact point. This leads to the meshing function $\Phi$:
$$
\Phi = v_{12n} = M_1 \cos\phi_2 + M_2 \sin\phi_2 + M_3 = 0,
$$
where $[M_1, M_2, M_3]^T = \mathbf{M}_n \mathbf{F}_2 + \mathbf{F}_2’$, with $\mathbf{F}_2 = [x_2, y_2, z_2]^T$ being the contact point coordinates in $S_2$, and $\mathbf{M}_n$ is a matrix incorporating $\beta$ and $\theta$. The explicit form of $\Phi$ governs the relationship between the surface parameters $(u, \theta)$ and the wheel rotation angle $\phi_2$, defining the instantaneous line of contact.
The line of contact on the roller surface for a given $\phi_2$ is obtained by combining the surface equation with the meshing equation $\Phi=0$. This yields a relation $\theta = f(u, \phi_2)$:
$$
\theta = \arctan\left(\frac{P_1}{P_2}\right), \quad \text{with} \quad
\begin{cases}
P_1 = (\sin\beta\, R – x_2 \cos\beta) \cos\phi_2 + A \cos\beta, \\
P_2 = i_{21} (\sin\beta\, R – x_2 \cos\beta),
\end{cases}
$$
where $R$ is a function of $u$. For $\theta \in [0, \pi]$, the left flank contact line is described; for $\theta \in [-\pi, 0]$, the right flank contact line is obtained. These lines are symmetric about $\phi_2 = 0$, corresponding to the throat of the hourglass worm. The parabolic roller surface, being a surface of revolution with varying curvature, presents a non-developable surface, meaning contact lines cannot be simply unfolded onto a plane. However, a quasi-planar representation can be achieved by projecting the surface along its generatrix. The contact lines appear as inclined curves on this projection, with opposite slopes for left and right flanks, indicating a favorable load distribution across the screw gear interface.
The worm tooth surface, as the envelope of the roller family during motion, is derived by transforming the contact line conditions into the worm coordinate system $S_1$. The parametric equations are:
$$
\mathbf{r}_1 = x_1 \mathbf{i}_1 + y_1 \mathbf{j}_1 + z_1 \mathbf{k}_1, \quad \text{with} \quad \mathbf{F}_1 = \mathbf{A}_{12} (\mathbf{F}_2 – \boldsymbol{\xi}),
$$
where $\mathbf{F}_1 = [x_1, y_1, z_1]^T$, $\boldsymbol{\xi} = [A\cos\phi_2, -A\sin\phi_2, 0]^T$, and $\mathbf{A}_{12}$ is the rotational part of $\mathbf{M}_{21}$. The parameters $(u, \phi_2)$ satisfy the meshing equation, fully defining the conjugate screw gear surfaces.
To evaluate the performance of this modified roller enveloping hourglass worm drive as a high-efficiency screw gear, several key meshing characteristics are analyzed: the induced normal curvature, lubrication angle, roller self-rotation angle, and relative entrainment velocity. These parameters directly influence contact stress, wear, lubrication regime, and efficiency.
The induced normal curvature $k_{12}^\sigma$ along the contact line normal direction measures the conformity between the meshing surfaces. Lower absolute values indicate better conformity, reducing contact pressure. Using the active frame method, it is expressed as:
$$
k_{12}^\sigma = -\frac{H_1 + H_2}{\Psi}, \quad \text{where} \quad
\begin{cases}
H_1 = (v_{12}^1 \kappa_1 + v_{12}^2 \tau_{g1} + \omega_{12}^2)^2, \\
H_2 = (v_{12}^2 \kappa_2 + v_{12}^1 \tau_{g1} – \omega_{12}^1)^2, \\
\Psi = \Phi_t + \omega_{12}^2 v_{12}^1 – \omega_{12}^1 v_{12}^2 + \kappa_1 (v_{12}^1)^2 + \kappa_2 (v_{12}^2)^2 + 2\tau_{g1} v_{12}^1 v_{12}^2.
\end{cases}
$$
Here, $v_{12}^1, v_{12}^2$ are the relative velocity components in $S_p$, $\omega_{12}^1, \omega_{12}^2$ are the relative angular velocity components, $\kappa_1 = -\cos\beta/R$ and $\kappa_2 = -|u”|/(1+u’^2)^{3/2}$ are the normal curvatures of the roller surface along $\mathbf{e}_1$ and $\mathbf{e}_2$, $\tau_{g1}=0$ is the geodesic torsion, and $\Phi_t$ is the second-order meshing function. For a typical design with worm threads $Z_1=1$, wheel teeth $Z_2=25$, center distance $A=160$ mm, and throat diameter coefficient $k=0.4$, the induced normal curvature varies minimally within the meshing zone ($\phi_2 \in [-0.2\pi, 0.2\pi]$), with a range of about $0.02$ mm$^{-1}$. This small variation and magnitude signify excellent surface conformity throughout the engagement, a desirable trait for screw gears aiming to minimize Hertzian stress.
| Parameter | Symbol | Value |
|---|---|---|
| Number of Worm Threads | $Z_1$ | 1 |
| Number of Wheel Teeth | $Z_2$ | 25 |
| Center Distance | $A$ | 160 mm |
| Throat Diameter Coefficient | $k$ | 0.4 |
| Roller Root Radius | $R_1$ | Design-dependent |
| Roller Tip Radius | $R_2$ | Design-dependent |
| Module | $m$ | $(2-k)A/Z_2$ |
The lubrication angle $\mu$ is defined as the acute angle between the relative velocity vector $\mathbf{v}_{12}$ and the tangent to the contact line (or the $\mathbf{e}_2$ direction in our frame). A larger $\mu$ (closer to $90^\circ$) promotes the formation of a hydrodynamic lubricant film by increasing the entraining velocity component normal to the contact line. For this screw gear, it is calculated as:
$$
\mu = \arcsin\left( \frac{| v_{12}^1 (v_{12}^1 / R – \omega_{12}^2) + v_{12}^2 \omega_{12}^1 |}{\sqrt{(v_{12}^1 / R – \omega_{12}^2)^2 + (\omega_{12}^1)^2} \cdot \sqrt{(v_{12}^1)^2 + (v_{12}^2)^2}} \right).
$$
Analysis shows that $\mu$ remains between $85.6^\circ$ and $88.5^\circ$ over the meshing range for both flanks, with symmetric curves about $\phi_2=0$. The minimum occurs near the worm throat. Such high lubrication angles indicate excellent conditions for elastohydrodynamic lubrication (EHL), significantly reducing friction and wear compared to traditional screw gears with predominantly sliding contact.
The roller self-rotation angle $\mu_{z0}$ measures the effectiveness of the roller’s own rotation about its axis. It is the angle between the relative velocity vector and the roller axis ($\mathbf{k}_0$ direction). A value close to $90^\circ$ means most of the relative motion contributes to rolling, not sliding, along the roller axis. The formula is:
$$
\mu_{z0} = \arccos\left( \frac{|v_{12}^2|}{\sqrt{(v_{12}^1)^2 + (v_{12}^2)^2}} \right).
$$
For the studied parameters, $\mu_{z0}$ ranges from $87.5^\circ$ to $89.5^\circ$, again nearly symmetric and minimal at the throat. This confirms that the parabolic roller experiences predominantly rolling motion, validating the core advantage of this screw gear design in transforming sliding friction into rolling friction.
The relative entrainment velocity $v_{jx}$ is crucial for assessing the lubricant film thickness in the contact zone. It is defined as half the sum of the projections of the absolute velocities of the two surfaces onto the common normal direction along the contact line. Mathematically,
$$
v_{jx} = \frac{v_\sigma^1 + v_\sigma^2}{2}, \quad \text{with} \quad
\begin{cases}
v_\sigma^1 = \frac{v_1^1 (v_{12}^1 / R – \omega_{12}^2) + v_1^2 \omega_{12}^1}{T}, \\
v_\sigma^2 = \frac{v_2^1 (v_{12}^1 / R – \omega_{12}^2) + v_2^2 \omega_{12}^1}{T}, \\
T = \sqrt{(v_{12}^1 / R – \omega_{12}^2)^2 + (\omega_{12}^1)^2},
\end{cases}
$$
where $v_1^1, v_1^2$ and $v_2^1, v_2^2$ are the velocity components of the worm and roller surfaces at the contact point in $S_p$. The entrainment velocity curve is symmetric about the throat, with a minimum near $\phi_2=0$ and maxima at the entry and exit of the meshing zone. This variation influences the film thickness distribution, but the overall values are conducive to maintaining an EHL film, especially given the high lubrication angle.
| Performance Parameter | Left Flank Range | Right Flank Range | Ideal Value | Implication for Screw Gears |
|---|---|---|---|---|
| Induced Normal Curvature $k_{12}^\sigma$ (mm$^{-1}$) | ~ -0.01 to -0.03 | ~ -0.01 to -0.03 | Close to zero | Excellent conformity, low contact stress |
| Lubrication Angle $\mu$ (degrees) | 85.6° to 88.5° | 85.6° to 88.5° | 90° | Superior conditions for fluid film lubrication |
| Roller Self-Rotation Angle $\mu_{z0}$ (degrees) | 87.5° to 89.5° | 87.5° to 89.5° | 90° | Dominant rolling motion, minimal sliding friction |
| Relative Entrainment Velocity $v_{jx}$ (m/s) | Design-speed dependent | Symmetric to left | Sufficient for EHL | Determines lubricant film thickness |
The parabolic modification of the roller plays a significant role in these performance metrics. Compared to a cylindrical roller, the parabolic profile provides a continuously varying curvature that can better accommodate misalignment and thermal deformation, common challenges in precision screw gears. The reduced tip radius alleviates edge loading and reduces the risk of jamming due to thermal expansion. Furthermore, the parabolic shape facilitates the retention of lubricant within the contact zone, enhancing the starved lubrication conditions often encountered in high-pressure screw gear contacts. These attributes make it a superior choice for advanced screw gear applications demanding high efficiency and reliability.
In conclusion, the meshing theory analysis of the modified roller enveloping hourglass worm drive reveals a screw gear system with exceptional performance characteristics. The established mathematical model, based on spatial gearing theory, successfully describes the generation of conjugate surfaces, the instantaneous contact lines, and key kinematic and geometric parameters. The derived performance indicators—including the low and stable induced normal curvature, high lubrication angle, high roller self-rotation angle, and favorable entrainment velocity profile—collectively demonstrate that this design effectively addresses the inherent drawbacks of traditional screw gears. The transformation from sliding to rolling friction is convincingly achieved, promising high transmission efficiency, reduced wear, and increased load capacity. The parabolic roller modification further optimizes lubrication and thermal behavior. This comprehensive theoretical foundation validates the modified roller enveloping hourglass worm drive as a viable and superior alternative for power transmission applications where screw gears are employed, paving the way for further research into its dynamic behavior, manufacturing techniques, and experimental validation. The insights gained contribute to the broader field of advanced gear technology, emphasizing the importance of surface modification and rolling contact in next-generation screw gear systems.
The analysis presented herein can be extended in several directions. Future work could involve optimizing the parabolic profile parameters (e.g., $R_1$, $R_2$, $u_1$) for specific operational conditions using multi-objective algorithms. Thermal analysis considering the heat generation from residual sliding and rolling friction would provide insights into thermal deformation and its effect on meshing. Additionally, a dynamic model incorporating manufacturing errors and assembly misalignments would assess the robustness of this screw gear design. Comparative studies with other rolling-contact screw gears, such as ball worm drives or different roller profiles, would further highlight its advantages. Ultimately, the goal is to develop a comprehensive design methodology for high-performance screw gears that leverage the principles of modified roller enveloping to meet the ever-increasing demands of modern machinery for efficiency, durability, and precision.
Throughout this discussion, the term “screw gears” has been intentionally emphasized to connect this specialized worm drive analysis to the broader category of gear systems involving helical or screw actions. Screw gears, in their various forms, are indispensable for motion control in robotics, automotive steering, aerospace actuators, and industrial machinery. The pursuit of higher efficiency in screw gears is a persistent engineering challenge. The modified roller enveloping hourglass worm drive represents a significant step forward by fundamentally altering the friction mechanism at the interface. Its theoretical performance suggests it could outperform not only standard worm gears but also other types of screw gears in applications requiring high reduction ratios, compactness, and smooth operation. As the demand for energy-efficient transmissions grows, innovations like this will become increasingly important in the evolution of screw gear technology, potentially setting new standards for performance and reliability in power transmission systems worldwide.