
As a researcher focused on advanced gear transmission systems, I have long been intrigued by the persistent challenges inherent in traditional worm drives. While renowned for their high load capacity and compact design, the substantial sliding friction at the tooth interface remains a fundamental drawback. This friction leads to reduced transmission efficiency, significant heat generation, accelerated wear, and the ever-present risk of scuffing and seizure. In my pursuit of a more optimal solution, the concept of replacing sliding contact with rolling contact presents itself as the most direct and effective path forward. This analysis delves into the meshing theory of a novel screw gear configuration born from this principle: the Parabolically Modified Roller-Enveloping Hourglass Worm Drive. This drive evolves from the single-roller enveloping concept, aiming to enhance performance through a strategic modification of the roller profile.
The core innovation lies in the geometry of the worm wheel “teeth.” Instead of conventional gear teeth, the worm wheel is equipped with rollers whose active profile is a surface of revolution generated by a parabolic arc. These rollers are mounted on the wheel body and are free to rotate about their own axes. During operation, transmission occurs through the rolling contact between these parabolic rollers and the conjugated hourglass-shaped worm thread. This design fundamentally transforms the interfacial friction from sliding to rolling. Compared to its cylindrical or conical roller counterparts, the parabolic profile offers two key advantages: it facilitates better lubricant entrapment within the contact zone due to its curvature, and the reduced radius at the roller tip (compared to a cylinder) provides clearance to mitigate potential jamming from thermal expansion. The worm is a single, continuous thread generated by the envelope of the family of roller surfaces as the wheel rotates. The assembly is typically designed for unilateral contact to prevent binding, with a deliberate clearance on the non-working flank.
The geometric configuration of this screw gear pair is central to its function. The worm and wheel are arranged such that their mid-planes, along with the central plane of the roller assembly, are coincident. The fundamental geometric setup, illustrating the relative positioning of the worm (screw gear) and the wheel with its parabolic rollers, is shown below. This arrangement ensures the correct meshing conditions for the enveloping process.
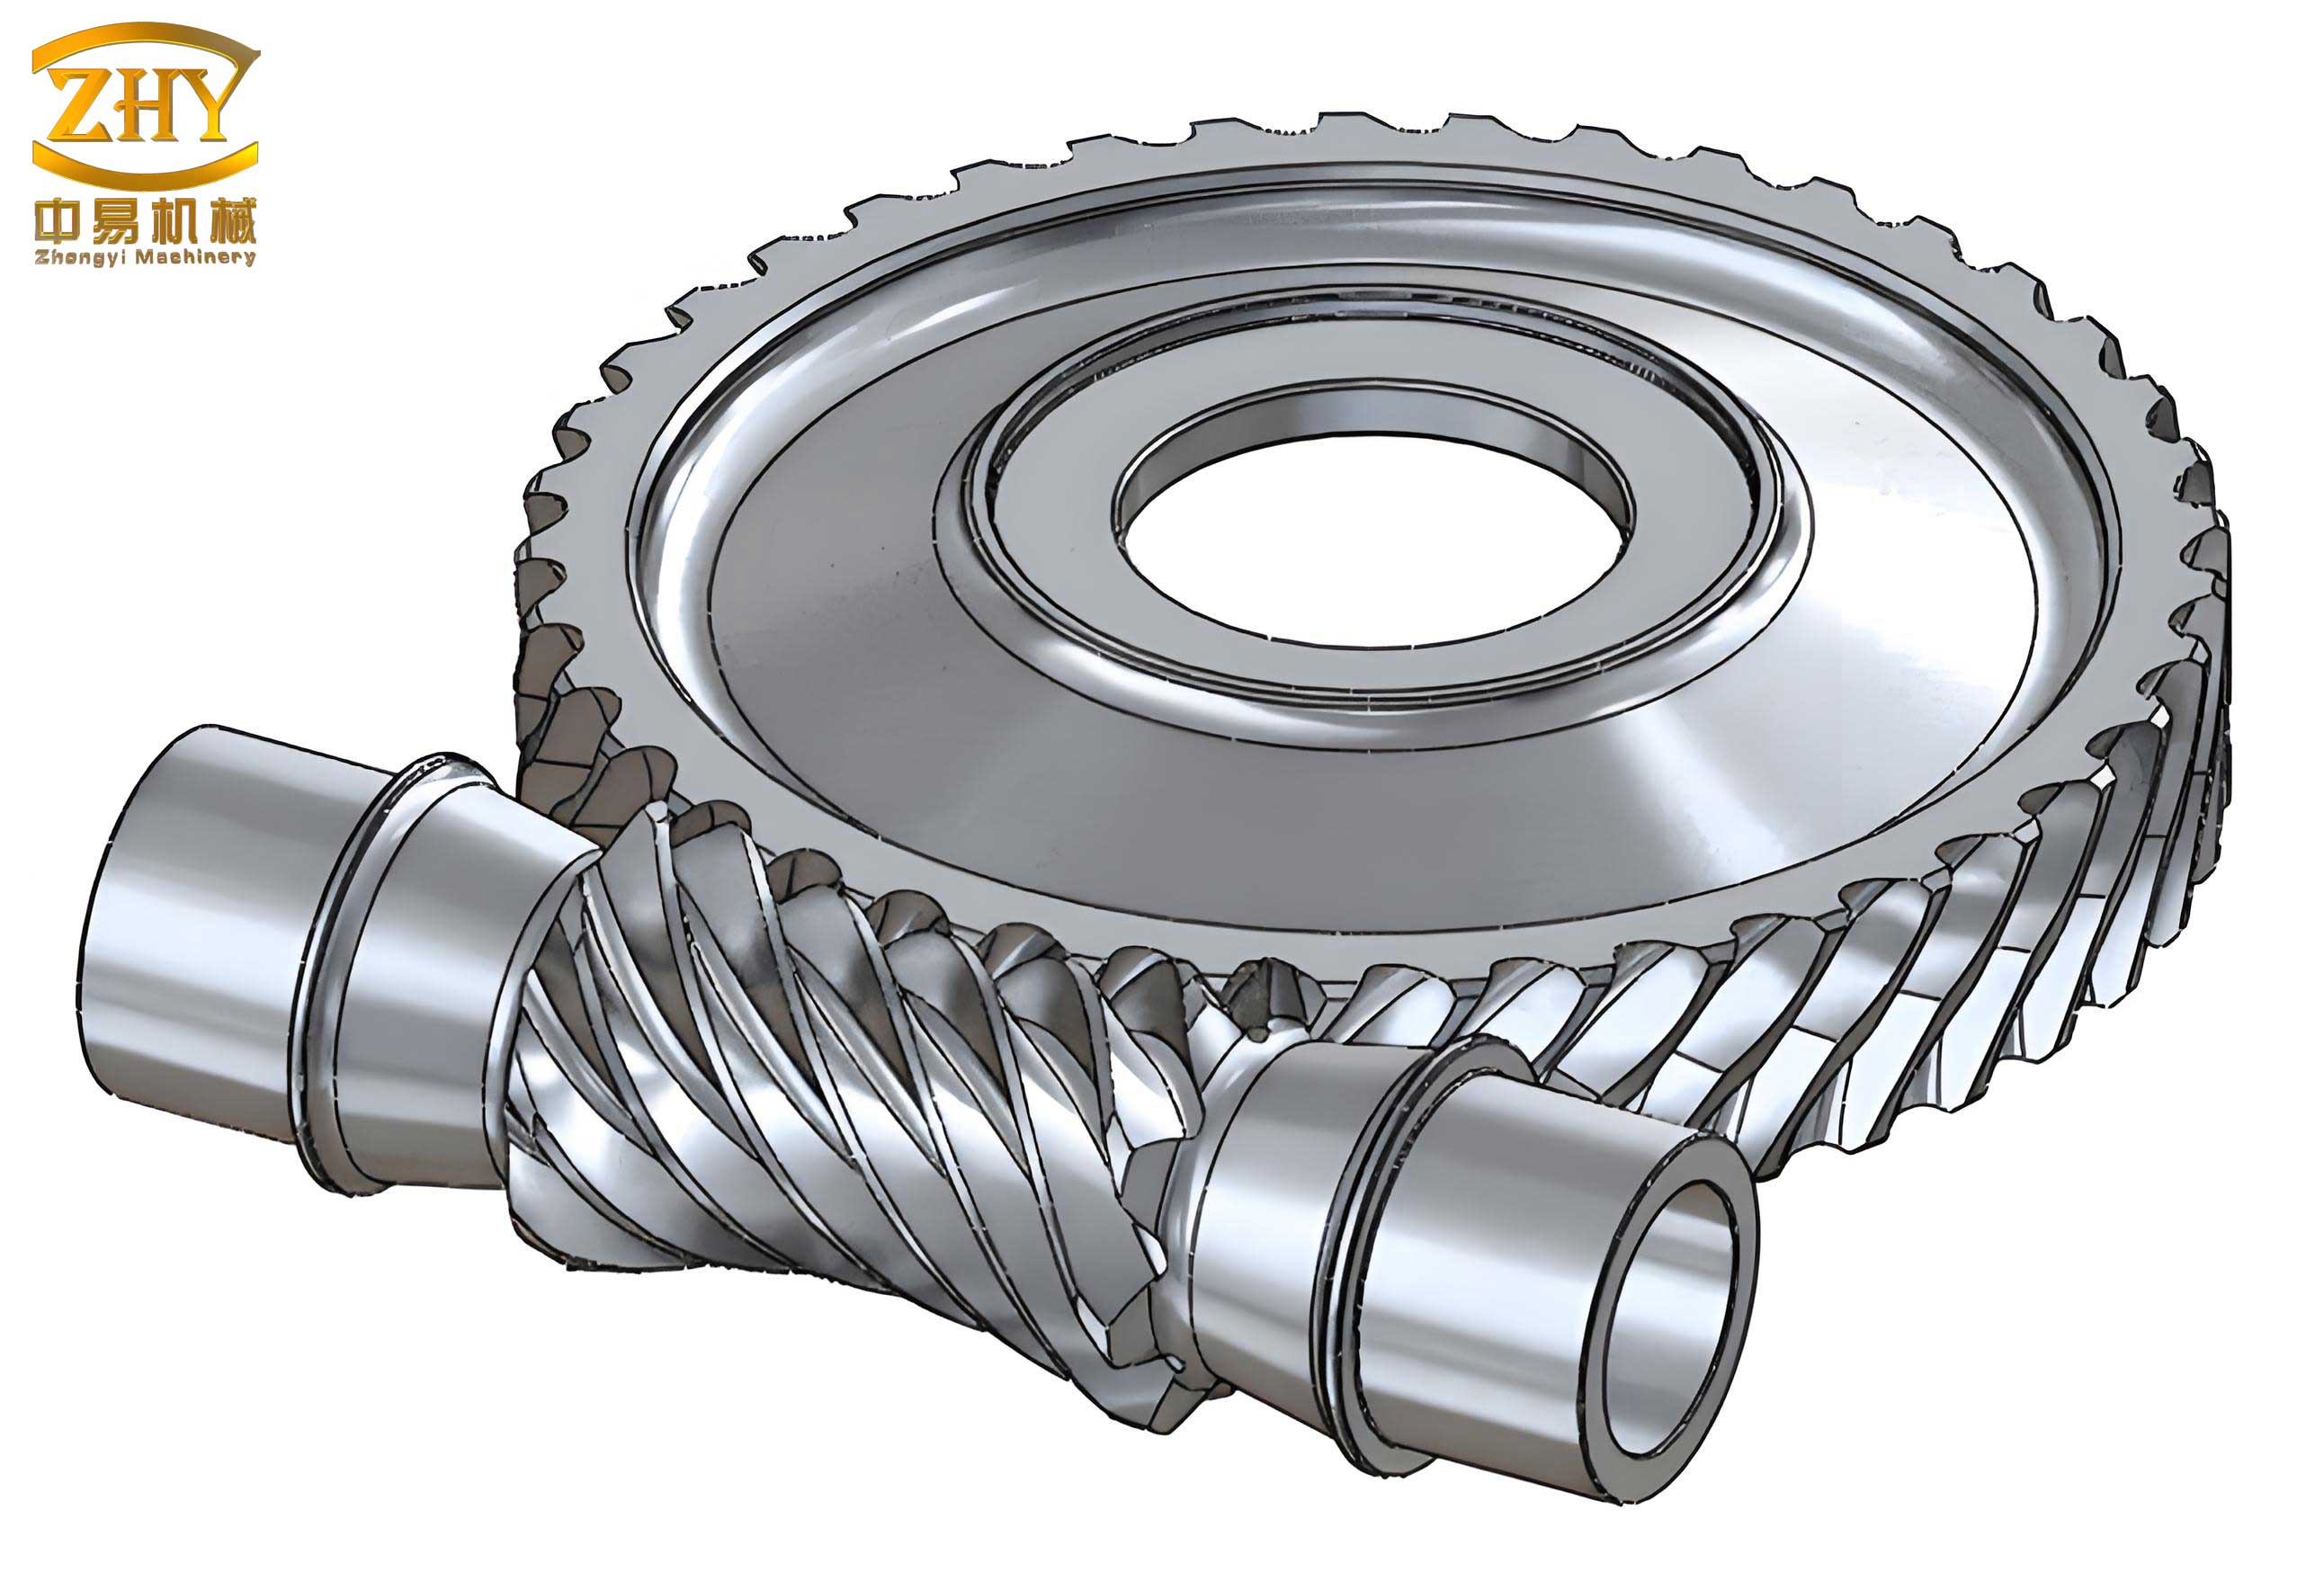
Mathematical Model of the Screw Gear Pair
To rigorously analyze this screw gear system, a precise mathematical model based on spatial gearing theory and differential geometry is essential. This model allows us to derive the equations governing contact, tooth form, and kinematic performance.
Coordinate System Establishment
The analysis begins by defining a series of coordinate systems. Let $S_1′(O_1′; \mathbf{i}_1′, \mathbf{j}_1′, \mathbf{k}_1′)$ and $S_2′(O_2′; \mathbf{i}_2′, \mathbf{j}_2′, \mathbf{k}_2′)$ denote the fixed reference frames attached to the worm and gear wheel, respectively. The rotating frames attached to these bodies are $S_1(O_1; \mathbf{i}_1, \mathbf{j}_1, \mathbf{k}_1)$ and $S_2(O_2; \mathbf{i}_2, \mathbf{j}_2, \mathbf{k}_2)$. The worm rotation angle is $\phi_1$ and the wheel rotation angle is $\phi_2$, with their ratio defining the transmission ratio $i_{12} = \phi_1 / \phi_2 = \omega_1 / \omega_2 = z_2 / z_1$.
A coordinate system $S_0(O_0; \mathbf{i}_0, \mathbf{j}_0, \mathbf{k}_0)$ is fixed to the parabolic roller, with its origin $O_0$ located at the roller’s axial center. In the wheel coordinate system $S_2$, the position of $O_0$ is $(a_2, 0, 0)$, where $a_2$ is the radial installation distance. The parabolic roller surface, representing the wheel tooth, is generated by revolving a parabolic arc about its own axis ($\mathbf{k}_0$). Its vector equation in $S_0$ is given by:
$$
\mathbf{r}_0 = x_0 \mathbf{i}_0 + y_0 \mathbf{j}_0 + z_0 \mathbf{k}_0
$$
where the coordinates are parameterized by the surface parameters $u$ (axial) and $\theta$ (angular):
$$
\begin{aligned}
x_0 &= R(u) \cos\theta \\
y_0 &= R(u) \sin\theta \\
z_0 &= u
\end{aligned}
$$
The parabolic profile defines the radius $R(u)$ as a function of $u$:
$$
R(u) = \sqrt{\frac{(R_1^2 – R_2^2)u + u_1 R_2^2}{u_1}}
$$
Here, $R_1$ and $R_2$ are the roller root and tip radii, respectively. $u_1$ is the total active height of the roller profile, related to the wheel’s module $m$, addendum coefficient $h_{ac}$, dedendum coefficient $h_{fc}$, and tip clearance coefficient $c_c$ by $u_1 = m(h_{ac} + h_{fc} + c_c)$. The module is defined as $m = (2 – k)A / z_2$, where $A$ is the center distance and $k$ is the throat diameter coefficient.
Finally, a moving frame $S_p(O_p; \mathbf{e}_1, \mathbf{e}_2, \mathbf{n})$ is established at the instantaneous contact point $O_p$ on the roller surface. Here, $\mathbf{n}$ is the unit normal to the surface, $\mathbf{e}_1$ is tangent to the surface along the direction of the $u$-parameter curve, and $\mathbf{e}_2$ is tangent along the $\theta$-parameter curve, completing the orthonormal triad.
Coordinate Transformations
The kinematic relationships between these frames are described by transformation matrices. The transformation from the worm’s rotating frame $S_1$ to its fixed frame $S_1’$ is a simple rotation about the $\mathbf{k}_1$ axis:
$$
\mathbf{Q}_{1′} = \mathbf{M}_{1’1} \mathbf{Q}_{1}, \quad \mathbf{M}_{1’1} =
\begin{bmatrix}
\cos\phi_1 & -\sin\phi_1 & 0 & 0 \\
\sin\phi_1 & \cos\phi_1 & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}
$$
A similar transformation exists for the wheel: $\mathbf{Q}_{2′} = \mathbf{M}_{2’2} \mathbf{Q}_{2}$. The crucial transformation between the worm’s rotating frame $S_1$ and the wheel’s rotating frame $S_2$ is derived through the fixed frames and accounts for the center distance $A$:
$$
\mathbf{Q}_{2} = \mathbf{M}_{21} \mathbf{Q}_{1}
$$
where the composite transformation matrix $\mathbf{M}_{21}$ is:
$$
\mathbf{M}_{21} =
\begin{bmatrix}
-\cos\phi_1 \cos\phi_2 & \sin\phi_1 \cos\phi_2 & -\sin\phi_2 & A \cos\phi_2 \\
\cos\phi_1 \sin\phi_2 & -\sin\phi_1 \sin\phi_2 & -\cos\phi_2 & -A \sin\phi_2 \\
-\sin\phi_1 & -\cos\phi_1 & 0 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}
$$
The transformation from the wheel frame $S_2$ to the contact point frame $S_p$ involves aligning the base vectors with the surface geometry. The transformation matrix $\mathbf{A}_{p2}$ is a function of the roller’s angular parameter $\theta$ and the angle $\beta$, which is the angle between $\mathbf{e}_2$ and the roller axis $\mathbf{k}_0$. For a parabolic surface, $\beta = \pi/2 – \arctan(T_\beta)$, where $T_\beta = \frac{2u_1}{R_1^2 – R_2^2} R(u)$.
Relative Velocity and Angular Velocity at the Contact Point
Analyzing the kinematics at the meshing point is fundamental. The position vector of the contact point in the wheel frame $S_2$ is $\mathbf{r}_2 = (a_2 – z_0)\mathbf{i}_2 + y_0 \mathbf{j}_2 + x_0 \mathbf{k}_2$. The vector representing the center distance in $S_2$ is $\boldsymbol{\xi} = A\cos\phi_2 \mathbf{i}_2 – A\sin\phi_2 \mathbf{j}_2$.
The angular velocity vectors, assuming $\omega_1=1$ for generality, are:
$$
\boldsymbol{\omega}_1 = -\sin\phi_2 \mathbf{i}_2 – \cos\phi_2 \mathbf{j}_2, \quad \boldsymbol{\omega}_2 = i_{21} \mathbf{k}_2
$$
where $i_{21} = 1/i_{12}$.
The relative angular velocity is therefore:
$$
\boldsymbol{\omega}_{12} = \boldsymbol{\omega}_1 – \boldsymbol{\omega}_2 = -\sin\phi_2 \mathbf{i}_2 – \cos\phi_2 \mathbf{j}_2 – i_{21} \mathbf{k}_2
$$
The relative velocity at the contact point, considering the fixed center distance ($d\boldsymbol{\xi}/dt = 0$), is derived from the fundamental kinematic equation:
$$
\mathbf{v}_{12} = \boldsymbol{\omega}_{12} \times \mathbf{r}_1 – \boldsymbol{\omega}_2 \times \boldsymbol{\xi}
$$
where $\mathbf{r}_1 = \mathbf{r}_2 – \boldsymbol{\xi}$ is the contact point vector in the worm frame $S_1$ expressed in $S_2$. In the $S_2$ frame, the components of $\mathbf{v}_{12}$ are:
$$
\begin{aligned}
v_{12x}^{(2)} &= y_2 i_{21} – z_2 \cos\phi_2 \\
v_{12y}^{(2)} &= -x_2 i_{21} + z_2 \sin\phi_2 \\
v_{12z}^{(2)} &= x_2 \cos\phi_2 – y_2 \sin\phi_2 – A
\end{aligned}
$$
For meshing condition analysis, it is essential to project these velocities onto the contact point frame $S_p$. The projections are obtained via:
$$
\mathbf{v}_{12}^{(p)} = \mathbf{A}_{p2} \mathbf{v}_{12}^{(2)}, \quad \boldsymbol{\omega}_{12}^{(p)} = \mathbf{A}_{p2} \boldsymbol{\omega}_{12}^{(2)}
$$
where $\mathbf{v}_{12}^{(p)} = [v_{12}^1, v_{12}^2, v_{12}^n]^T$ and $\boldsymbol{\omega}_{12}^{(p)} = [\omega_{12}^1, \omega_{12}^2, \omega_{12}^n]^T$. The component $v_{12}^n$ is the relative velocity along the surface normal $\mathbf{n}$, which governs the meshing condition.
Meshing Analysis and Derived Equations
Meshing Function and Equation
The fundamental condition for contact in gear theory is that the relative velocity must have no component along the common surface normal at the point of contact. This is expressed as:
$$
\Phi = v_{12}^n = 0
$$
This equation, known as the meshing equation, defines the relationship between the surface parameters ($u, \theta$) and the wheel rotation angle $\phi_2$ for which contact occurs. For our screw gear, this function takes the form:
$$
\Phi = M_1 \cos\phi_2 + M_2 \sin\phi_2 + M_3 = 0
$$
where the coefficients $M_1, M_2, M_3$ are derived from the geometric and kinematic parameters:
$$
\mathbf{M} = [M_1, M_2, M_3]^T = \mathbf{M}_n \mathbf{F}_2 + \mathbf{F}_2′
$$
with $\mathbf{F}_2 = [x_2, y_2, z_2]^T$ being the contact point coordinates in $S_2$, and $\mathbf{M}_n$ and $\mathbf{F}_2’$ being matrices/vectors defined by the transformation geometry involving $\beta$ and $\theta$.
Contact Lines and Worm Thread Surface
For a given instant (fixed $\phi_2$), all points on the roller surface that satisfy the meshing equation $\Phi(u, \theta, \phi_2)=0$ form a spatial curve known as the instantaneous contact line. Its equation on the roller is given by $\mathbf{r}_0(u, \theta)$ with the constraint $\theta = f(u, \phi_2)$ solved from the meshing equation. Typically, $\theta = \arctan(P_1 / P_2)$, where $P_1$ and $P_2$ are functions of $u$, $\phi_2$, $\beta$, and the gear parameters. Due to the symmetry of the hourglass screw gear, the contact lines for the left and right flanks are symmetric about the throat plane ($\phi_2=0$).
The worm thread surface is the envelope of the family of roller surfaces generated as the wheel rotates. Its equation in the worm coordinate system $S_1$ is obtained by transforming the roller surface point (which satisfies the meshing equation) from $S_2$ to $S_1$:
$$
\mathbf{r}_1 = \mathbf{A}_{12} (\mathbf{r}_2 – \boldsymbol{\xi})
$$
where $\mathbf{A}_{12}$ is the rotational part of the transformation matrix $\mathbf{M}_{21}$, and $\mathbf{r}_2$, $\boldsymbol{\xi}$ are expressed in $S_2$. The resulting equation is parameterized by $(u, \phi_2)$, providing a complete description of the conjugated screw gear surface.
Performance Parameter Analysis of the Screw Gear
To evaluate the quality and potential of this parabolic roller screw gear design, several key performance indicators are derived and analyzed. For this analysis, a representative set of parameters is chosen: worm threads $z_1=1$, wheel teeth $z_2=25$, center distance $A=160$ mm, and throat coefficient $k=0.4$.
Induced Normal Curvature
The induced normal curvature $k_\sigma^{12}$ along the contact line direction is a critical measure of surface conformity. Lower absolute values indicate better contact and lower contact stress. Using the moving frame method, the formula is:
$$
k_\sigma^{12} = -\frac{H_1 + H_2}{\Psi}
$$
where
$$
\begin{aligned}
H_1 &= (v_{12}^1 \kappa_1 + v_{12}^2 \tau_{g1} + \omega_{12}^2)^2 \\
H_2 &= (v_{12}^2 \kappa_2 + v_{12}^1 \tau_{g1} – \omega_{12}^1)^2 \\
\Psi &= \Phi_t + \omega_{12}^2 v_{12}^1 – \omega_{12}^1 v_{12}^2 + \kappa_1 (v_{12}^1)^2 + \kappa_2 (v_{12}^2)^2 + 2\tau_{g1} v_{12}^1 v_{12}^2
\end{aligned}
$$
Here, $\kappa_1$ and $\kappa_2$ are the normal curvatures of the roller surface in the $\mathbf{e}_1$ and $\mathbf{e}_2$ directions, $\tau_{g1}$ is the geodesic torsion (zero for the lines of curvature on a surface of revolution), and $\Phi_t$ is the derivative of the meshing function with respect to time. For the parabolic roller:
$$
\kappa_1 = -\frac{\cos\beta}{R(u)}, \quad \kappa_2 = -\frac{|u”|}{(1+u’^2)^{3/2}}
$$
with $u’ = dR/du$ and $u” = d^2R/du^2$ derived from the parabolic equation.
Analysis shows that $|k_\sigma^{12}|$ remains very low (on the order of $0.02$ mm$^{-1}$) throughout the meshing zone for both flanks. It increases slightly from the entry to the exit of the mesh, reaching a maximum at the exit point, indicating the contact conformity is best near the entry and degrades slightly towards the exit, which is a common characteristic in worm gears. The overall low value suggests excellent surface matching in this screw gear pair.
Lubrication Angle
The lubrication angle $\mu$ is defined as the acute angle between the relative velocity vector $\mathbf{v}_{12}$ and the tangent to the contact line at the meshing point. A larger angle (closer to $90^\circ$) is desirable as it promotes the formation of a more effective elastohydrodynamic lubrication (EHL) film by enhancing the entraining action. It is calculated as:
$$
\mu = \arcsin\left( \frac{| v_{12}^1 (v_{12}^1 / R – \omega_{12}^2) + v_{12}^2 \omega_{12}^1 |}{ \sqrt{(v_{12}^1 / R – \omega_{12}^2)^2 + (\omega_{12}^1)^2} \cdot \sqrt{(v_{12}^1)^2 + (v_{12}^2)^2} } \right)
$$
For the chosen parameters, the lubrication angle remains remarkably high, varying between approximately $85.6^\circ$ and $88.5^\circ$ across the mesh. The curves for the left and right flanks are nearly symmetric about $\phi_2=0$ (the throat). The minimum value occurs near the throat region. These consistently high angles indicate outstanding lubricant entrainment conditions, which should translate to low friction and high efficiency in this screw gear drive.
Roller Self-Rotation Angle
The self-rotation angle $\mu_{z0}$ measures the effectiveness of the rolling motion. It is the angle between the relative velocity vector $\mathbf{v}_{12}$ and the roller’s axis of rotation ($\mathbf{k}_0$ direction, which aligns with $\mathbf{e}_2$ in our frame). An angle close to $90^\circ$ means $\mathbf{v}_{12}$ is nearly perpendicular to the roller axis, maximizing the component that causes the roller to spin, thus promoting pure rolling.
$$
\mu_{z0} = \arccos\left( \frac{|v_{12}^2|}{||\mathbf{v}_{12}||} \right)
$$
The analysis reveals self-rotation angles consistently above $87.5^\circ$, ranging up to $89.5^\circ$. Like the lubrication angle, the minimum is found near the throat. This confirms that the kinematic design successfully ensures that the relative motion at the interface is predominantly converted into a rolling motion of the parabolic rollers, minimizing sliding and the associated losses in the screw gear system.
Relative Entrainment Velocity
The entrainment velocity $v_{jx}$ is the average of the tangential surface velocities of the two contacting bodies along the contact normal section. It is a key parameter in EHL film thickness calculations. It is given by:
$$
v_{jx} = \frac{v_\sigma^1 + v_\sigma^2}{2}
$$
where $v_\sigma^1$ and $v_\sigma^2$ are the projections of the worm and roller surface velocities, respectively, onto the direction perpendicular to the contact line within the tangent plane. These are computed using the components already derived.
The entrainment velocity varies along the path of contact. It starts at a maximum at the entry point, decreases to a minimum near the throat region ($\phi_2 \approx 0$), and then increases again towards the exit. This parabolic-like trend is symmetric for the two flanks. The magnitude of this velocity influences the lubricant film thickness, with higher velocities generally promoting thicker films.
The following table summarizes the typical ranges and trends of these key performance parameters for the analyzed parabolic roller screw gear configuration:
| Performance Parameter | Symbol | Typical Range (for example setup) | Trend Along Mesh (Entry → Throat → Exit) | Implication |
|---|---|---|---|---|
| Induced Normal Curvature | $k_\sigma^{12}$ | Very low (≈ 0.02 mm⁻¹) | Increases slightly | Excellent contact conformity, low contact stress. |
| Lubrication Angle | $\mu$ | 85.6° to 88.5° | Decreases to min at throat, then increases. | Superior conditions for forming lubricant film, high efficiency. |
| Roller Self-Rotation Angle | $\mu_{z0}$ | 87.5° to 89.5° | Decreases to min at throat, then increases. | Dominant rolling motion, minimal sliding friction. |
| Relative Entrainment Velocity | $v_{jx}$ | Varies with position | Max at entry/min at throat/max at exit. | Governs EHL film thickness; variation affects local lubrication. |
Design Considerations and Conclusion
Based on the derived meshing theory and performance analysis, several design insights for this parabolic roller enveloping screw gear emerge. The parabolic profile parameters $R_1$ and $R_2$ (or the equivalent parabola coefficient) directly influence the surface curvatures $\kappa_1$ and $\kappa_2$, which in turn affect the induced normal curvature and contact pressure distribution. Optimizing this profile can further homogenize contact stress. The installation radius $a_2$ and the throat coefficient $k$ are critical for controlling the path of contact and the meshing zone. They should be chosen to ensure the performance parameters (lubrication angle, self-rotation angle) remain favorable throughout the active mesh while avoiding undercutting or poor contact at the extremes.
The symmetry of the hourglass worm implies that performance on the left and right flanks is nominally identical but occurs at opposite rotational positions. In practice, the drive is designed for unilateral contact (e.g., only the right flank during forward operation). Therefore, the design optimization should focus on maximizing performance over the active flank’s specific range of $\phi_2$. The extremely high lubrication and self-rotation angles suggest that thermal issues related to sliding friction will be greatly reduced compared to a traditional screw gear. However, the heat generation from bearing friction and windage, as well as the elastohydrodynamic losses in the rolling contacts, become more relevant and should be considered in a comprehensive thermal model.
In conclusion, the meshing theory for the parabolically modified roller-enveloping hourglass screw gear has been systematically established. From the fundamental coordinate transformations and kinematic analysis, the key equations for the meshing condition, contact lines, and worm tooth surface have been derived. The analysis of critical performance parameters—induced normal curvature, lubrication angle, roller self-rotation angle, and entrainment velocity—paints a very promising picture. The screw gear exhibits excellent surface conformity, outstanding conditions for fluid film lubrication, and a dominant rolling motion that fundamentally addresses the high-sliding-friction drawback of conventional worm gears. This theoretical foundation confirms the strong potential of this design for applications demanding high efficiency, high load capacity, and reliability, paving the way for subsequent research into detailed load distribution, efficiency measurement, and prototype testing.