
In my research, I study how manufacturing errors influence the transmission accuracy of a miter gear drive. The miter gear in this work is a double-helical gear pair whose left and right tooth flanks are generated as opposite-handed helices. This configuration combines the smoothness of helical action with a natural cancellation of axial force, so it is attractive for heavy-duty, high-precision, and high-reliability transmissions. At the same time, the miter gear is geometrically more complex than a simple spur or helical gear. Its two helical halves, its central alignment condition, and its measured tooth-surface deviations all must be represented if the predicted transmission error is to be meaningful. I therefore build an error-aware miter gear transmission accuracy model, fit measured manufacturing errors, embed them as contact-normal gaps, and solve for the loaded transmission error.
The central idea of my method is that a miter gear pair should not be treated as a single idealized contact line. Instead, I discretize each miter gear along the face width into thin slices. Each slice behaves approximately as a spur gear tooth segment, while the accumulated slice rotations reproduce the helical geometry. Manufacturing errors are then mapped onto each slice as normal gaps. This gives me a miter gear model that retains three-dimensional meshing behavior without the computational cost of a full finite-element contact solution. The same idea is extended later to a planetary miter gear train.
Research Context and Motivation
Mechanical transmission systems continue to move toward higher speed, higher load, and higher precision. A miter gear transmission is often selected when a compact, stable, and high-capacity drive is required. In my view, the accuracy of a miter gear system is not only a geometric property; it is the result of interaction among tooth profile deviation, helix deviation, pitch deviation, alignment error, support stiffness, and load deformation. If any one of these factors is omitted, the predicted transmission error can easily lose its physical meaning.
I treat transmission error as the difference between the actual output rotation and the theoretical output rotation. For a miter gear pair, this quantity is a direct indicator of motion accuracy. A small transmission error means that the miter gear pair follows the ideal kinematic relation closely. A large transmission error means that the miter gear pair introduces periodic or quasi-periodic disturbance into the driveline. In my model, I therefore compute the transmission error from the solved generalized displacement vector rather than from a purely geometric formula.
Manufacturing errors in a miter gear can be grouped into several families. The first family contains profile deviations, which affect contact initiation and recession. The second family contains helix deviations, which affect load distribution along the face width. The third family contains pitch deviations, which affect the angular relation among successive teeth. The fourth family contains alignment error, which is especially important for a miter gear because the two opposite-handed helices must meet in a controlled central region. I include all four families in my miter gear accuracy model.
| Error family | Typical symbol | Physical meaning | Main influence on miter gear behavior |
|---|---|---|---|
| Profile total deviation | $$F_\alpha$$ | Total departure of actual profile from design profile | Small-period fluctuation of transmission error |
| Profile form deviation | $$f_{f\alpha}$$ | Shape deviation relative to mean profile | Local contact stiffness variation |
| Profile slope deviation | $$f_{H\alpha}$$ | Pressure-angle-like inclination of mean profile | Shift of contact path and load sharing |
| Helix total deviation | $$F_\beta$$ | Total departure of actual helix from design helix | Uneven slice load and edge contact |
| Helix form deviation | $$f_{f\beta}$$ | Shape deviation along face width | Localized load concentration |
| Helix slope deviation | $$f_{H\beta}$$ | Inclination of mean helix | Axial load shift and slice gap variation |
| Single pitch deviation | $$f_{pt}$$ | Deviation of one pitch from theoretical pitch | Tooth-to-tooth angular error |
| Cumulative pitch deviation | $$F_{pk}$$ | Accumulated pitch error over k pitches | Long-period transmission error |
| Total cumulative pitch deviation | $$F_p$$ | Maximum accumulated pitch error over full gear | Large-period sinusoidal error component |
| Alignment error of miter gear | $$f_a$$ | Offset of the intersection of opposite-handed helices | Axial floating and unequal left-right contact |
Representation and Fitting of Manufacturing Errors
I begin with measured data from a gear measuring center and a coordinate measuring machine. The profile and helix data are not used as isolated curves. Instead, I construct a deviation surface over the tooth surface. Let the face-width coordinate be $$p$$ and let the working-profile radial coordinate be $$q$$. The deviation surface is written as $$z=G(p,q)$$. I use bicubic B-spline interpolation because it gives a smooth surface that passes through the measured points while remaining differentiable enough for subsequent gap mapping.
If I select $$n+1$$ measured points along the profile direction and $$m+1$$ measured points along the face-width direction, the point matrix of the miter gear tooth surface can be written as follows:
$$
\mathbf{P}
=
\begin{bmatrix}
P_{00} & P_{01} & \cdots & P_{0m}\\
P_{10} & P_{11} & \cdots & P_{1m}\\
\vdots & \vdots & \ddots & \vdots\\
P_{n0} & P_{n1} & \cdots & P_{nm}
\end{bmatrix}
$$
Each $$P_{ij}$$ is a three-dimensional point on the measured miter gear tooth surface. I first interpolate each row of measured points with a cubic B-spline curve. The curve segment for row $$i$$ can be written in compact form as:
$$
\mathbf{Q}_i(u)
=
\frac{1}{6}
\begin{bmatrix}
u^3 & u^2 & u & 1
\end{bmatrix}
\begin{bmatrix}
-1 & 3 & -3 & 1\\
3 & -6 & 3 & 0\\
-3 & 0 & 3 & 0\\
1 & 4 & 1 & 0
\end{bmatrix}
\begin{bmatrix}
V_{i,j-1}\\
V_{i,j}\\
V_{i,j+1}\\
V_{i,j+2}
\end{bmatrix}
$$
After the profile-direction curves are obtained, I fix the parameter $$u$$ and collect points along each row. These points are then interpolated in the face-width direction. Repeating this operation for all parameters produces the final deviation surface of the miter gear. This surface is the basis for the profile and helix error gap used in my transmission accuracy model.
Equivalent Contact Gaps from Miter Gear Errors
A manufacturing error does not enter the miter gear equation directly as a displacement of the whole gear. It enters as a local gap along the contact normal. Therefore I convert every measured or fitted error into an equivalent normal gap. For the profile and helix deviation surface, the meshing point radius is first computed from the geometry. If the center distance and base-circle geometry are known, the radius at a meshing point $$P_i$$ can be expressed as:
$$
r(P_i)=\sqrt{(O_gP_i)^2+r_{bg}^2}
$$
The measured deviation surface is then evaluated at the face-width coordinate $$l(j)$$ and the radial coordinate $$r(P_i)$$. The equivalent normal gap for slice $$j$$ is:
$$
e_j = G[l(j),r(P_i)]\cos\beta_b
$$
Here $$\beta_b$$ is the base helix angle. This equation is one of the most important links in my miter gear model because it transforms a surface deviation into a spring gap that can be assembled into the slice contact equations.
For pitch error, I use the measured cumulative pitch curve. Let the cumulative pitch function be $$F(x)$$, where $$x$$ is the tooth index. When several teeth are in contact at the same instant, I identify the active tooth indices. The equivalent normal pitch gap for the $$w$$-th active tooth is:
$$
e_p(w)=F[s(w)]\cos\beta_b\cos\alpha_t
$$
Here $$\alpha_t$$ is the transverse pressure angle and $$s(w)$$ is the tooth index of the active contact. Because cumulative pitch error is a long-period quantity, it produces the large sinusoidal component observed in the transmission error of the miter gear.
For alignment error, the left and right helices of the miter gear do not meet exactly at the ideal central section. This creates unequal contact between the two halves. I model the resulting axial float and small rotation. If the axial alignment deviations of the two sides are $$\Delta T_h$$ and $$\Delta T_h’$$, the additional normal gap can be written as:
$$
\lambda_m=(T_h-T_h’)\tan\beta_b\cos\beta_s
$$
where $$\beta_s$$ is the helix angle on the reference cylinder. The sign of $$\lambda_m$$ indicates whether the local gap is increased or decreased. When the miter gear floats axially, the side with the smaller gap controls the final contact position, and the other side retains a residual gap. This behavior is essential for a realistic miter gear transmission accuracy prediction.
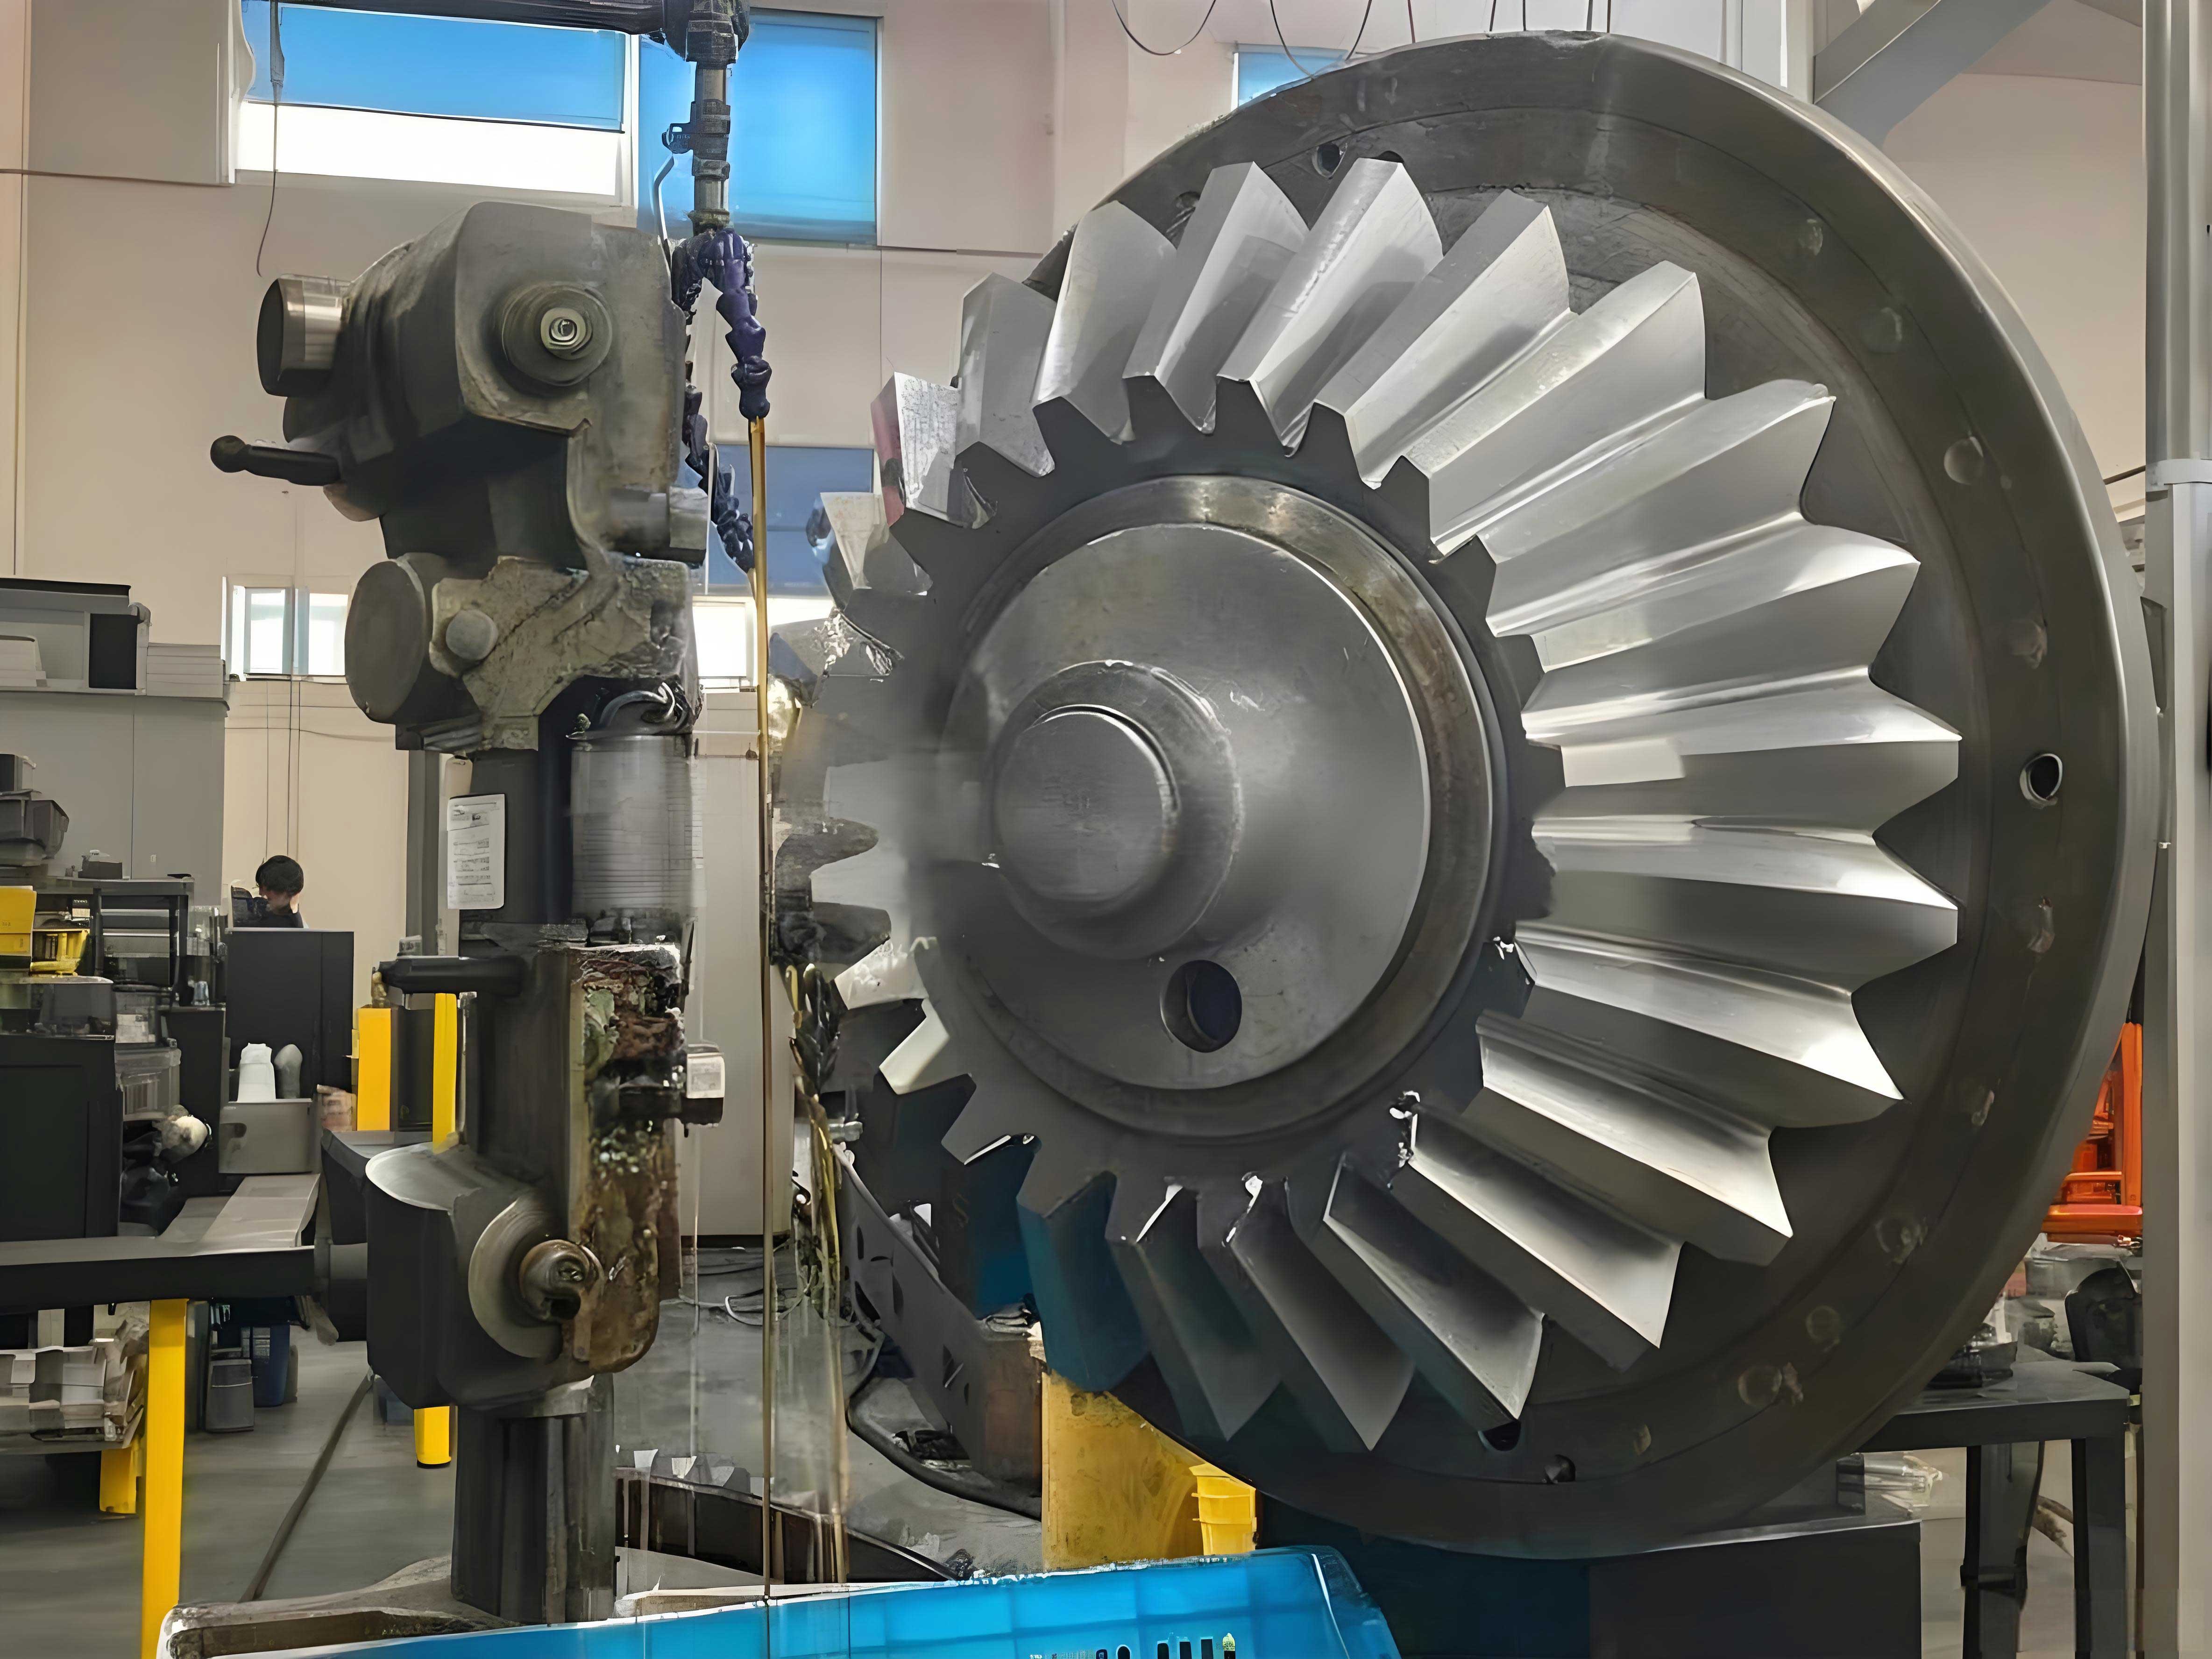
Sliced Discrete Model of a Miter Gear Pair
I now build the transmission accuracy model for one miter gear pair. The assumptions I use are as follows. The meshing and support behavior are represented by springs. The main bodies are treated as rigid. Before errors are introduced, the left and right sides of the miter gear are symmetric about the central section. The radial support stiffnesses of the driving and driven miter gears are equal in their respective radial directions. Damping, friction, and gravity are neglected in the static accuracy solution.
I define a global coordinate system at the center of the driving gear and a local coordinate system at the center of the driven gear. A moving coordinate system is attached to each miter gear. The face width is divided into $$n$$ slices. The relative rotation of slice $$j$$ with respect to the reference tooth is:
$$
\Delta\phi_{Jj}
=
\frac{l}{r_J}[2-(j-1)]\tan\beta,
\quad J=p,g
$$
where $$l$$ is the face width, $$r_J$$ is the reference radius of the driving or driven miter gear, and $$\beta$$ is the helix angle. This rotation expression allows the slice model to recover the helical contact line while keeping each slice locally spur-like. This is the key approximation that makes the miter gear model both efficient and physically meaningful.
Mesh Stiffness of a Miter Gear Slice
For each slice, I calculate the tooth pair mesh stiffness by the energy method. The total stored energy includes bending energy, shear energy, radial compression energy, fillet foundation energy, and Hertz contact energy. The corresponding stiffness components are denoted $$k_b$$, $$k_s$$, $$k_a$$, $$k_f$$, and $$k_h$$. The bending, shear, and radial compression energies are:
$$
U_b=\frac{F^2}{2k_b},\quad
U_s=\frac{F^2}{2k_s},\quad
U_a=\frac{F^2}{2k_a}
$$
Using the cantilever beam representation of a miter gear tooth, these energies can be written as integrals along the tooth height:
$$
U_b=\int_0^d \frac{M^2}{2EI_x}\,dx
$$
$$
U_s=\int_0^d \frac{1.2F_b^2}{2GA_x}\,dx
$$
$$
U_a=\int_0^d \frac{F_a^2}{2EA_x}\,dx
$$
The force components and moment are:
$$
F_a=F\sin\alpha_1,\quad
F_b=F\cos\alpha_1,\quad
M=F(d-x)-F_b h
$$
The fillet foundation stiffness of the miter gear body is calculated from the analytical formula:
$$
\frac{1}{k_f}
=
\frac{\cos^2\alpha}{E l}
\left[
L^*\left(\frac{u_f}{S_f}\right)^2
+
M^*\left(\frac{u_f}{S_f}\right)
+
P^*\left(\frac{u_f}{S_f}\right)
+
Q^*
\right]
$$
The coefficients $$L^*$$, $$M^*$$, $$P^*$$, and $$Q^*$$ are functions of the normalized tooth-root geometry. The Hertz contact stiffness is approximated as:
$$
k_h=\frac{\pi E l}{4(1-\nu^2)}
$$
Thus, the single-slice mesh stiffness of the miter gear pair on the left or right side is:
$$
k_{pg,j}^{L/R}
=
\left(
\frac{1}{k_{b,pj}}+\frac{1}{k_{s,pj}}+\frac{1}{k_{a,pj}}+\frac{1}{k_{f,pj}}
+
\frac{1}{k_{b,gj}}+\frac{1}{k_{s,gj}}+\frac{1}{k_{a,gj}}+\frac{1}{k_{f,gj}}
+
\frac{1}{k_h}
\right)^{-1}
$$
This slice stiffness is time-varying because the contact point moves along the profile and because the number of active slices changes with rotation. For a miter gear, the left and right halves contribute separately. Therefore the total mesh stiffness matrix is assembled from both left-side and right-side slices.
| Stiffness component | Symbol | Physical source | Role in miter gear accuracy |
|---|---|---|---|
| Bending stiffness | $$k_b$$ | Tooth bending as a cantilever | Controls deflection under tangential load |
| Shear stiffness | $$k_s$$ | Transverse shear of tooth section | Important for short, thick miter gear teeth |
| Radial compression stiffness | $$k_a$$ | Compression along tooth height | Modifies contact normal displacement |
| Fillet foundation stiffness | $$k_f$$ | Elastic deformation of gear body near root | Reduces effective mesh stiffness |
| Hertz contact stiffness | $$k_h$$ | Local contact deformation | Controls high-frequency contact compliance |
| Slice mesh stiffness | $$k_{pg,j}^{L/R}$$ | Series combination of tooth and contact stiffness | Basic spring for each miter gear slice |
Deformation Compatibility of the Miter Gear Pair
The generalized displacement vector of the miter gear pair contains twelve degrees of freedom. It can be written as:
$$
\mathbf{X}
=
\begin{bmatrix}
x_p & y_p & z_p & u_{px} & u_{py} & u_{pz} &
x_g & y_g & z_g & u_{gx} & u_{gy} & u_{gz}
\end{bmatrix}^{T}
$$
Here $$x$$, $$y$$, and $$z$$ are translational displacements, while $$u_x$$, $$u_y$$, and $$u_z$$ are equivalent angular displacements transformed to linear form at the reference radius. For slice $$j$$ on the left or right side, the normal deformation is:
$$
\delta_{pg,j}^{L/R}
=
\mathbf{n}^{L/R}\cdot\mathbf{X}
–
e_{pg,j}^{L/R}
$$
The slice is in contact only when the deformation is positive. Therefore the active slice stiffness is:
$$
k_{pg,j}^{L/R}
=
\begin{cases}
k_{pg,j}^{L/R}, & \delta_{pg,j}^{L/R}>0,\\
0, & \delta_{pg,j}^{L/R}\leq 0.
\end{cases}
$$
The projection vector $$\mathbf{n}^{L/R}$$ converts the twelve-degree-of-freedom motion of the miter gear pair into motion along the contact normal. It contains the base helix angle, the transverse pressure angle, the phase angle, and the distance from the slice to the central section. For the left and right sides, the sign of the axial term changes. This is how the two opposite-handed helices of the miter gear are distinguished in the model.
Motion Equation and Transmission Error
The total mesh stiffness matrix of the miter gear pair is:
$$
\mathbf{K}_m=\mathbf{K}_m^L+\mathbf{K}_m^R
$$
where each side is assembled from all active slices:
$$
\mathbf{K}_m^{L/R}
=
\sum_{i=1}^{N}\sum_{j=1}^{n}
k_{pg,j}^{L/R}
\left(\mathbf{n}_{pg,j}^{L/R}\right)
\left(\mathbf{n}_{pg,j}^{L/R}\right)^T
$$
The support stiffness matrix is diagonal:
$$
\mathbf{K}_h
=
\operatorname{diag}
(k_{px},k_{py},k_{pz},k_{pbx},k_{pby},k_{pu},
k_{gx},k_{gy},k_{gz},k_{gbx},k_{gby},0)
$$
For a miter gear pair, the axial support stiffness of the driving gear can be set to zero because the gear is allowed to float axially to balance the two helical halves. This is a direct consequence of the miter gear geometry. The error-induced force vector is:
$$
\mathbf{F}
=
\sum_{i=1}^{N}\sum_{j=1}^{n}
k_{pg,j}^{L}
\mathbf{n}_{pg,j}^{L}
e_{pg,j}^{L}
+
\sum_{i=1}^{N}\sum_{j=n/2+1}^{n}
k_{pg,j}^{R}
\mathbf{n}_{pg,j}^{R}
e_{pg,j}^{R}
$$
The external generalized force vector has the form:
$$
\mathbf{T}
=
\begin{bmatrix}
0 & 0 & 0 & 0 & 0 & T_p &
0 & 0 & 0 & 0 & 0 & T_g
\end{bmatrix}^{T}
$$
The static equilibrium equation of the miter gear pair is therefore:
$$
(\mathbf{K}_m+\mathbf{K}_h)\mathbf{X}
=
\mathbf{F}+\mathbf{T}
$$
After solving for $$\mathbf{X}$$, I obtain the output angular displacement and compute the transmission error:
$$
TE=\theta_{out}-\frac{\theta_{in}}{i}
$$
In my implementation, the input torsional stiffness is set very large so that the input angular displacement is effectively the prescribed rotation. The transmission error is then read directly from the output angular degree of freedom. This gives a clear miter gear accuracy measure in arcseconds.
Influence of Individual Manufacturing Errors on a Miter Gear Pair
I apply the sliced miter gear model to a representative pair. The basic parameters are listed below. These parameters are used to study profile error, pitch error, alignment error, and the combination of all errors.
| Parameter | Driving miter gear | Driven miter gear |
|---|---|---|
| Number of teeth | 25 | 50 |
| Normal module | 4 mm | 4 mm |
| Pressure angle | 20 deg | 20 deg |
| Helix angle | 20 deg | 20 deg |
| Face width | 52 mm | 48 mm |
| Accuracy grade studied | Grade 4, 5, 6 | Grade 4, 5, 6 |
Profile Error
For profile error, I represent the deviation along the involute as a harmonic function of mesh frequency:
$$
e_\alpha^{L/R}(t)
=
F_\alpha^{L/R}
\sin(\omega_m t+\phi_0)\cos\beta_b
$$
where $$\omega_m$$ is the mesh angular frequency and $$F_\alpha$$ is the measured or standardized profile deviation amplitude. When profile error alone is present, the miter gear transmission error develops small-period fluctuations. As the profile error grade changes from grade 4 to grade 6, the amplitude of the transmission error increases. This confirms that profile error mainly affects the short-period accuracy of the miter gear.
Pitch Error
For pitch error, I use a sinusoidal representation of cumulative pitch deviation:
$$
F_{pkJ}(t)
=
F_{pJ}
\sin(\omega_J t+\phi_{fpJ}),
\quad J=p,g
$$
The relative base pitch gap projected to the contact normal is:
$$
e_p
=
\left(F_{pkp}-F_{pkg}\right)
\cos\beta_b\cos\alpha_t
$$
Pitch error produces a long-period, staircase-like variation in the miter gear transmission error. The amplitude increases noticeably from grade 4 to grade 6. Because the cumulative pitch error accumulates around the full circumference, it is one of the dominant sources of the large sinusoidal component in the miter gear output.
Alignment Error
Alignment error is a distinctive error source for a miter gear. It does not simply shift the whole contact line; it changes the balance between the left and right helices. When alignment error alone is present, the transmission error exhibits a stepwise pattern. The step height depends on the difference among the alignment gaps of the simultaneously meshing tooth pairs. The axial float of the miter gear reduces the mean load imbalance, but it does not eliminate the local gap variation.
Combined Error Influence
When profile error, pitch error, helix error, and alignment error act together, the miter gear transmission error contains both long-period and short-period components. The long-period component is mainly caused by cumulative pitch error and alignment error. The short-period component is mainly caused by profile error. The combination is not a simple sum of individual amplitudes because contact is nonlinear: slices with positive deformation carry load, while slices with a gap lose contact. This nonlinear selection is exactly what the sliced miter gear model captures.
| Error condition | No-load TE | TE at 50 N m | TE at 100 N m | Dominant waveform |
|---|---|---|---|---|
| Profile error only | 23.9 arcsec | 17.79 arcsec | 15.04 arcsec | Small-period fluctuation |
| Pitch error only | 31.18 arcsec | 32.21 arcsec | 32.67 arcsec | Large-period staircase |
| Alignment error only | 28.6 arcsec | 28.95 arcsec | 29.26 arcsec | Stepwise transition |
| All errors combined | 62.6 arcsec | 57.98 arcsec | 56.8 arcsec | Mixed long and short period |
Monte Carlo Prediction of Miter Gear Accuracy
Manufacturing errors are random variables. To predict the statistical range of miter gear transmission accuracy, I use Monte Carlo simulation. Each error is sampled according to an assumed probability distribution. Profile error and pitch error are assumed to follow a Rayleigh distribution. Helix error is assumed to follow a normal distribution. For each sample set, I solve the sliced miter gear equation and record the maximum transmission error.
For a Rayleigh-distributed variable, the cumulative distribution is:
$$
F(x)=1-\exp\left(-\frac{x^2}{2\sigma^2}\right),
\quad x\geq 0
$$
A random sample can be generated by:
$$
x=\sigma\sqrt{-2\ln(1-r)}
$$
where $$r$$ is a uniformly distributed random number between zero and one. For a normally distributed helix error, a sample can be generated by:
$$
x=\mu+\sigma\sqrt{-2\ln r_1}\sin(2\pi r_2)
$$
The standard deviation of profile and pitch errors is related to the tolerance value by:
$$
\sigma=\frac{F}{6.8}
$$
This relation is consistent with a high-confidence interval for the random manufacturing error. I sample six thousand sets for each accuracy grade. The resulting transmission error distributions allow me to relate a miter gear accuracy grade to a predicted transmission accuracy range.
| Error item | Grade 4 | Grade 5 | Grade 6 |
|---|---|---|---|
| Driving miter gear profile total deviation | 0.0065 mm | 0.0095 mm | 0.013 mm |
| Driving miter gear total cumulative pitch deviation | 0.014 mm | 0.009 mm | 0.028 mm |
| Driving miter gear helix total deviation | 0.006 mm | 0.0085 mm | 0.012 mm |
| Driven miter gear profile total deviation | 0.0075 mm | 0.011 mm | 0.015 mm |
| Driven miter gear total cumulative pitch deviation | 0.018 mm | 0.025 mm | 0.036 mm |
| Driven miter gear helix total deviation | 0.0065 mm | 0.009 mm | 0.013 mm |
| Accuracy grade | Mean TE | Standard deviation | 99.7 percent interval lower bound | 99.7 percent interval upper bound |
|---|---|---|---|---|
| Grade 4 miter gear | 14.055 arcsec | 10.636 arcsec | 6.542 arcsec | 25.179 arcsec |
| Grade 5 miter gear | 19.248 arcsec | 19.801 arcsec | 8.946 arcsec | 33.568 arcsec |
| Grade 6 miter gear | 26.944 arcsec | 41.372 arcsec | 12.304 arcsec | 48.906 arcsec |
These results show that the miter gear transmission accuracy range widens rapidly as the manufacturing grade becomes coarser. The mean transmission error increases, and the standard deviation increases even faster. Therefore, for a high-precision miter gear, controlling both the systematic pitch error and the random profile error is necessary. The Monte Carlo results provide a quantitative basis for evaluating whether a miter gear design can meet a required transmission accuracy.
Experimental Verification for a Miter Gear Pair
I designed and manufactured a grade-5 miter gear pair to verify the model. The design used a normal module of 4 mm, a pressure angle of 20 deg, a helix angle of 19.37 deg, 25 teeth on the driving gear, and 50 teeth on the driven gear. The measured errors included profile deviation, helix deviation, pitch deviation, and alignment error. The miter gear pair was then mounted on a gear transmission test bench. Input and output angular displacements were measured with angle encoders. The transmission error was computed from the measured input and output angles.
| Design item | Driving miter gear | Driven miter gear |
|---|---|---|
| Number of teeth | 25 | 50 |
| Normal module | 4 mm | 4 mm |
| Pressure angle | 20 deg | 20 deg |
| Helix angle | 19.37 deg | 19.37 deg |
| Single-side face width | 26 mm | 24 mm |
| Accuracy grade | Grade 5 | Grade 5 |
| Test condition | Input torque | Input speed |
|---|---|---|
| Condition 1 | 0 N m | 2 rpm |
| Condition 2 | 50 N m | 2 rpm |
| Condition 3 | 100 N m | 2 rpm |
The measured transmission error curves show a large-period component and a small-period component. The large-period component is synchronized with the gear rotation and is mainly caused by cumulative pitch error and alignment error. The small-period component is synchronized with the mesh frequency and is mainly caused by profile error. This observation agrees with the error influence predicted by the sliced miter gear model.
| Input torque | Simulated TE | Measured TE | Relative difference |
|---|---|---|---|
| 0 N m | 62.6 arcsec | 67.8 arcsec | -7.7 percent |
| 50 N m | 57.98 arcsec | 65.38 arcsec | -11.3 percent |
| 100 N m | 54.8 arcsec | 64.57 arcsec | -15.2 percent |
| Input torque | Simulated tooth-surface-induced TE | Measured filtered TE | Relative difference |
|---|---|---|---|
| 0 N m | 23.9 arcsec | 25.82 arcsec | -7.4 percent |
| 50 N m | 17.79 arcsec | 19.8 arcsec | -10.1 percent |
| 100 N m | 15.3 arcsec | 17.9 arcsec | -14.5 percent |
The simulated and measured miter gear transmission error trends are consistent. The relative differences are within a reasonable range when one considers encoder uncertainty, shaft alignment uncertainty, surface roughness, waviness, and random manufacturing effects that are not represented in the model. I therefore conclude that the sliced miter gear model is reliable for transmission accuracy prediction.
Error-Aware Model of a Planetary Miter Gear Train
I extend the sliced miter gear method to a planetary miter gear train. In this system, a sun gear inputs power, a carrier outputs power, and several planet gears mesh simultaneously with the sun gear and the ring gear. Each component has six degrees of freedom. The generalized coordinate vector contains the carrier, ring, sun, and all planets. This extension is important because a planetary miter gear train combines internal and external meshing in the same system, and both sides of the miter gear teeth must be considered.
For the sun-planet external mesh, the normal deformation of slice $$j$$ on the left and right sides is:
$$
\delta_{spi,j}^{L/R}
=
\mathbf{n}_{Ei}^{L/R}\cdot
\mathbf{X}_{spi}
–
e_{spi,j}^{L/R}
$$
For the ring-planet internal mesh, the normal deformation is:
$$
\delta_{rpi,j}^{L/R}
=
\mathbf{n}_{Ii}^{L/R}\cdot
\mathbf{X}_{rpi}
–
e_{rpi,j}^{L/R}
$$
The projection vectors $$\mathbf{n}_{Ei}^{L/R}$$ and $$\mathbf{n}_{Ii}^{L/R}$$ contain the base helix angle, transverse pressure angle, planet phase angle, and slice axial position. They project the twelve-degree-of-freedom motion of each meshing pair onto the contact normal. This is the same principle used for the single miter gear pair, but now it is applied to both external and internal meshing paths.
The total mesh stiffness matrix of the planetary miter gear train is assembled as:
$$
\mathbf{K}_m=\mathbf{K}_m^L+\mathbf{K}_m^R
$$
The left and right contributions contain both sun-planet and ring-planet slices:
$$
\mathbf{K}_m^{L/R}
=
\sum_{i=1}^{N}
\sum_{j=1}^{n}
k_{spi,j}^{L/R}
\mathbf{n}_{Ei}^{L/R}
\left(\mathbf{n}_{Ei}^{L/R}\right)^T
+
\sum_{i=1}^{N}
\sum_{j=1}^{n}
k_{rpi,j}^{L/R}
\mathbf{n}_{Ii}^{L/R}
\left(\mathbf{n}_{Ii}^{L/R}\right)^T
$$
The support stiffness matrix includes the carrier, ring, sun, and planet bearings. The error-induced force vector contains contributions from all external and internal meshing slices. The static equilibrium equation has the same form as the single-pair miter gear equation:
$$
(\mathbf{K}_m+\mathbf{K}_h)\mathbf{X}
=
\mathbf{F}+\mathbf{T}
$$
After solving for the generalized displacement vector, the transmission error of the planetary miter gear train is:
$$
TE=\phi_{out}-\frac{\phi_{in}}{i}
$$
where $$\phi_{out}$$ is the carrier angular displacement and $$\phi_{in}$$ is the sun angular displacement. Because the sun and carrier are the input and output members, the transmission error reflects the combined effect of all external and internal miter gear mesh errors.
| Planetary miter gear parameter | Sun gear | Planet gear | Ring gear |
|---|---|---|---|
| Number of teeth | 22 | 41 | 104 |
| Normal module | 16 mm | 16 mm | 16 mm |
| Pressure angle | 20 deg | 20 deg | 20 deg |
| Helix angle | 25 deg | 25 deg | 25 deg |
| Face width | 100 mm | 100 mm | 100 mm |
Single-Error Influence in the Planetary Miter Gear Train
For profile error in the planetary miter gear train, the planet gear has the largest influence on the transmission error amplitude. This is because each planet gear participates in both external and internal meshing during its rotation cycle. The sun gear affects only the external mesh, and the ring gear affects only the internal mesh. Therefore, when the planet gear carries profile error, the error enters the system through two mesh paths. The profile error produces short-period fluctuations, and the fluctuation amplitude grows when sun, planet, and ring errors are present simultaneously.
For pitch error, the same ranking appears. The planet gear has the strongest influence, followed by the ring gear and then the sun gear. Pitch error produces a long-period fluctuation. When all gears contain pitch error, the total transmission error amplitude is larger than the amplitude produced by any single gear error. This behavior confirms that error superposition in a planetary miter gear train is path-dependent rather than a simple linear sum.
| Error item | Grade 4 | Grade 5 | Grade 6 |
|---|---|---|---|
| Sun profile total deviation | 0.012 mm | 0.016 mm | 0.023 mm |
| Sun total cumulative pitch deviation | 0.025 mm | 0.036 mm | 0.05 mm |
| Sun helix total deviation | 0.009 mm | 0.013 mm | 0.018 mm |
| Planet profile total deviation | 0.013 mm | 0.018 mm | 0.026 mm |
| Planet total cumulative pitch deviation | 0.032 mm | 0.045 mm | 0.064 mm |
| Planet helix total deviation | 0.0095 mm | 0.014 mm | 0.019 mm |
| Ring profile total deviation | 0.014 mm | 0.02 mm | 0.031 mm |
| Ring total cumulative pitch deviation | 0.047 mm | 0.067 mm | 0.094 mm |
| Ring helix total deviation | 0.011 mm | 0.015 mm | 0.022 mm |
Monte Carlo Accuracy Range for the Planetary Miter Gear Train
I also apply Monte Carlo simulation to the planetary miter gear train. The profile and pitch errors are sampled from Rayleigh distributions, while the helix errors are sampled from normal distributions. Each simulation set contains six thousand samples. For every sample, the full planetary miter gear equilibrium equation is solved, and the maximum transmission error is recorded.
| Accuracy grade | Mean TE | Standard deviation | 99.7 percent interval lower bound | 99.7 percent interval upper bound |
|---|---|---|---|---|
| Grade 4 planetary miter gear | 57.543 arcsec | 236.816 arcsec | 22.094 arcsec | 113.416 arcsec |
| Grade 5 planetary miter gear | 81.218 arcsec | 471.056 arcsec | 81.218 arcsec | 155.899 arcsec |
| Grade 6 planetary miter gear | 115.06 arcsec | 931.403 arcsec | 43.941 arcsec | 223.571 arcsec |
The planetary miter gear train has a wider accuracy range than the single miter gear pair. This is caused by the increased number of mesh paths and the coupling between external and internal meshing. The planet gear errors influence both paths, and the carrier motion integrates the contributions of all planets. Therefore, a planetary miter gear train requires tighter control of planet gear errors than a single pair if the same output accuracy is required.
Discussion and Interpretation
My miter gear model shows that manufacturing errors should be classified by their periodicity and by their path of influence. Profile error is a short-period error. It changes the local contact stiffness and creates small ripples in the transmission error. Pitch error is a long-period error. It creates a staircase-like or sinusoidal component that repeats with the gear rotation. Alignment error is a special miter gear error. It changes the axial force balance between the left and right helices, causing axial floating and unequal contact. Helix error changes the distribution of load along the face width and therefore modifies the effective mesh stiffness of each slice.
For a single miter gear pair, the combined error transmission error is largest at no load. As the load increases, some profile-induced gaps are closed by elastic deformation. This is why the transmission error can initially decrease with load. At higher load, however, the deformation itself becomes significant, and the transmission error can increase again. The nonlinear contact selection in the sliced miter gear model captures this transition naturally.
For a planetary miter gear train, the same mechanisms exist, but they are amplified by multiple mesh paths. The planet gear is the most sensitive component because it meshes with both the sun and the ring. A profile error on the planet affects both external and internal contact. A pitch error on the planet affects the phase relation in both meshes. As a result, the transmission accuracy of a planetary miter gear train is strongly dependent on planet gear quality and on the phase arrangement of the planets.
Modeling Workflow I Use
I organize the miter gear accuracy analysis as a repeatable workflow. First, I measure or obtain the profile, helix, pitch, and alignment errors. Second, I fit the profile and helix deviations into a smooth deviation surface. Third, I convert all errors into equivalent normal gaps. Fourth, I discretize the miter gear along the face width into slices. Fifth, I calculate the slice mesh stiffness from bending, shear, compression, fillet, and Hertz contributions. Sixth, I assemble the deformation compatibility equations and the global equilibrium equation. Seventh, I solve for the generalized displacement vector and compute the transmission error. Eighth, I repeat the solution with Monte Carlo sampling to obtain the statistical accuracy range. Finally, I verify the model with a manufactured miter gear pair and a transmission test bench.
| Step | Action | Output |
|---|---|---|
| 1 | Collect manufacturing error data | Profile, helix, pitch, alignment measurements |
| 2 | Fit measured deviations | Deviation surface and error curves |
| 3 | Convert errors to normal gaps | Equivalent slice gaps |
| 4 | Discretize miter gear | Slice model along face width |
| 5 | Compute slice stiffness | Time-varying mesh stiffness |
| 6 | Assemble compatibility and equilibrium | Global stiffness and force matrices |
| 7 | Solve equilibrium | Generalized displacement and TE |
| 8 | Run Monte Carlo simulation | Statistical accuracy range |
| 9 | Perform experimental verification | Validated miter gear accuracy model |
Key Equations Summary
The geometric rotation of a miter gear slice is:
$$
\Delta\phi_{Jj}
=
\frac{l}{r_J}[2-(j-1)]\tan\beta
$$
The equivalent normal gap from a fitted deviation surface is:
$$
e_j=G[l(j),r(P_i)]\cos\beta_b
$$
The equivalent normal gap from cumulative pitch error is:
$$
e_p(w)=F[s(w)]\cos\beta_b\cos\alpha_t
$$
The equivalent normal gap from alignment error is:
$$
\lambda_m=(T_h-T_h’)\tan\beta_b\cos\beta_s
$$
The slice deformation compatibility condition is:
$$
\delta_{pg,j}^{L/R}
=
\mathbf{n}^{L/R}\cdot\mathbf{X}
–
e_{pg,j}^{L/R}
$$
The active slice stiffness condition is:
$$
k_{pg,j}^{L/R}
=
\begin{cases}
k_{pg,j}^{L/R}, & \delta_{pg,j}^{L/R}>0,\\
0, & \delta_{pg,j}^{L/R}\leq 0.
\end{cases}
$$
The miter gear pair equilibrium equation is:
$$
(\mathbf{K}_m+\mathbf{K}_h)\mathbf{X}
=
\mathbf{F}+\mathbf{T}
$$
The transmission error is:
$$
TE=\theta_{out}-\frac{\theta_{in}}{i}
$$
The planetary miter gear equilibrium equation is:
$$
(\mathbf{K}_m+\mathbf{K}_h)\mathbf{X}
=
\mathbf{F}+\mathbf{T}
$$
These equations form the core of my error-aware miter gear transmission accuracy model. They allow me to connect measured manufacturing errors to the loaded motion error of a single miter gear pair and of a planetary miter gear train.
Conclusions
I have developed a sliced, error-aware model for miter gear transmission accuracy. The model represents the miter gear as a series of thin slices, computes the local mesh stiffness of each slice, maps measured profile, helix, pitch, and alignment errors into normal contact gaps, and solves the global equilibrium equation for the transmission error. The model is efficient enough for repeated Monte Carlo simulation and detailed enough to represent the double-helical behavior of a miter gear.
My results show that profile error creates short-period fluctuations, pitch error creates long-period fluctuations, and alignment error creates stepwise changes in the miter gear transmission error. Helix error changes the load distribution along the face width. When these errors act together, the transmission error contains a mixture of long-period and short-period components. The Monte Carlo results provide accuracy ranges for grade 4, grade 5, and grade 6 miter gears. The experimental measurements of a manufactured grade-5 miter gear pair agree with the simulated trends, which supports the validity of the model.
The same modeling framework is extended to a planetary miter gear train. In that system, the planet gear has the strongest influence on transmission error because it participates in both external and internal meshing. The planetary miter gear accuracy range is wider than that of a single miter gear pair, and the error coupling is more complex. I therefore conclude that a reliable miter gear accuracy prediction must include measured tooth-surface deviations, pitch deviations, alignment error, slice-based mesh stiffness, support stiffness, and nonlinear contact selection. The approach I present provides a practical basis for evaluating, predicting, and improving the transmission accuracy of miter gear systems.