
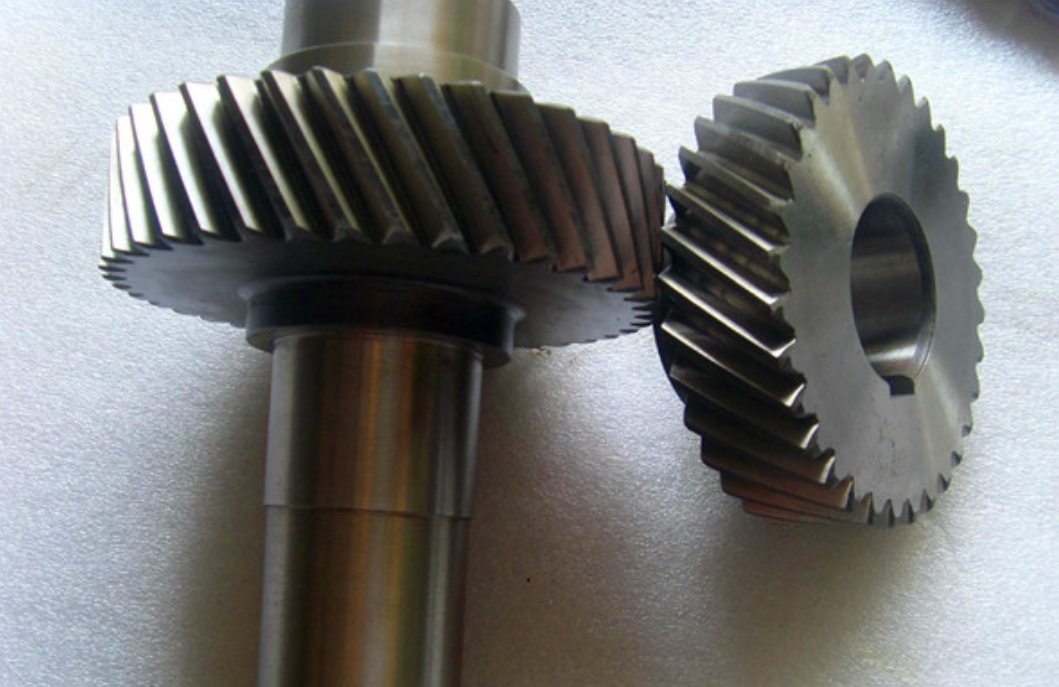
In the realm of high-power transmission systems, such as those found in wind turbine generators, helical gears are the component of choice due to their superior characteristics of high precision, smooth operation, and substantial load-bearing capacity. Their ability to transmit significant torque while maintaining operational stability makes them indispensable. However, this very role exposes them to extreme mechanical stresses, rendering them susceptible to various forms of degradation like tooth surface deformation, cracks, pitting, and spalling. The emergence of such localized tooth defects fundamentally alters the gear mesh interaction, potentially inducing severe nonlinear vibrations that compromise transmission accuracy, generate excessive noise, and can lead to catastrophic system failure. Therefore, a deep understanding of the nonlinear dynamic characteristics of helical gears operating with these imperfections is not merely academic; it is a critical engineering imperative for predictive maintenance and ensuring the reliable operation of critical machinery.
Traditional dynamic analyses often treat helical gears as perfect systems. In reality, their operation is governed by intrinsic and extrinsic nonlinearities. The most prominent among these is the gear backlash, which introduces a piecewise-linear discontinuity in the force-displacement relationship. Furthermore, the time-varying nature of the mesh stiffness, arising from the changing number of tooth pairs in contact throughout the meshing cycle, acts as a parametric excitation. When combined with manufacturing errors (transmission error) and geometric imperfections like eccentricity, the system becomes a hotbed for complex nonlinear phenomena including period-doubling bifurcations, quasi-periodic oscillations, and chaos. A localized tooth defect exacerbates this situation by introducing a sudden, periodic drop in the mesh stiffness, effectively creating an additional internal excitation source. This work aims to dissect this complex interplay by developing a high-fidelity nonlinear dynamic model for a high-power wind turbine helical gear pair and investigating how different severities of tooth defects, modeled as specific reductions in local mesh stiffness, influence the system’s global dynamic response, including its route to chaotic motion.
Dynamic Modeling of the Helical Gear Transmission System
To capture the essential dynamics, an eight-degree-of-freedom (8-DOF) lumped-parameter model is established for a parallel-shaft helical gear pair, as conceptually represented in the schematic. The model accounts for the translational motions of each gear in three perpendicular directions (x, y, z) and their rotational motions about the shaft axis (z-axis). The coordinate system is defined with the y-axis along the line connecting the gear centers, the x-axis perpendicular in the transverse plane, and the z-axis along the shaft direction. Bearing supports are modeled as linear spring-damper elements in all three translational directions.
The fundamental variable governing the gear interaction is the dynamic transmission error (DTE) along the line of action. For helical gears, this must account for the helix angle $\beta$. The total deflection $p$ along the normal direction of the tooth surface can be expressed as:
$$
p = (r_{b1}\theta_1 – r_{b2}\theta_2) + [(x_1 + \rho_1 \cos\omega_1 t) – (x_2 + \rho_2 \cos\omega_2 t)]\sin(\alpha – \alpha_t) + (y_1 – y_2)\cos(\alpha – \alpha_t) + (z_1 – z_2)\tan\beta – e(t)
$$
where $r_{bi}$, $\theta_i$, $\rho_i$, and $\omega_i$ are the base radius, angular displacement, eccentricity, and rotational speed of gear $i$ ($i=1,2$), respectively. $\alpha$ is the angle of the line of centers, $\alpha_t$ is the transverse pressure angle, and $e(t)$ is the static transmission error, often modeled as: $e(t) = e_0 + \sum_{n=1}^N e_n \sin(n\omega_e t + \phi_n)$, with $\omega_e$ being the gear mesh frequency.
The nonlinear meshing force $F$ is the heart of the model, combining the piecewise-linear backlash function with the time-varying mesh stiffness $k(t)$ and damping $c$:
$$
F = k(t) f(p) + c \dot{p}
$$
The backlash function $f(p)$ for a normal backlash of $2b$ is defined as:
$$
f(p) =
\begin{cases}
p – b, & p > b \\
0, & -b \le p \le b \\
p + b, & p < -b
\end{cases}
$$
The time-varying mesh stiffness $k(t)$ for a healthy gear pair can be expanded in a Fourier series, considering the contact ratio $\epsilon_\alpha$:
$$
k(t) = k_0 + \sum_{n=1}^{N} k_n \sin(n\omega_e t + \phi_n)
$$
where $k_0$ is the average mesh stiffness, and $k_n$, $\phi_n$ are the amplitude and phase of the $n$-th harmonic. For a simplified model with one to two pairs of teeth in contact ($a < \epsilon_\alpha < a+1$), these can be approximated as shown in prior studies.
Using Newton’s second law, the equations of motion for the two helical gears can be derived. For Gear 1 (driving gear), the equations are:
$$
\begin{aligned}
m_1 \ddot{x}_1 + c_{x1}\dot{x}_1 + k_{x1}x_1 &= -F_x + m_1 \rho_1 \omega_1^2 \cos\omega_1 t \\
m_1 \ddot{y}_1 + c_{y1}\dot{y}_1 + k_{y1}y_1 &= -F_y – m_1 g + m_1 \rho_1 \omega_1^2 \sin\omega_1 t \\
m_1 \ddot{z}_1 + c_{z1}\dot{z}_1 + k_{z1}z_1 &= -F_z \\
J_1 \ddot{\theta}_1 &= T_1 – F_t r_{b1}
\end{aligned}
$$
For Gear 2 (driven gear), the equations are:
$$
\begin{aligned}
m_2 \ddot{x}_2 + c_{x2}\dot{x}_2 + k_{x2}x_2 &= F_x + m_2 \rho_2 \omega_2^2 \cos\omega_2 t \\
m_2 \ddot{y}_2 + c_{y2}\dot{y}_2 + k_{y2}y_2 &= F_y – m_2 g + m_2 \rho_2 \omega_2^2 \sin\omega_2 t \\
m_2 \ddot{z}_2 + c_{z2}\dot{z}_2 + k_{z2}z_2 &= F_z \\
J_2 \ddot{\theta}_2 &= -T_2 + F_t r_{b2}
\end{aligned}
$$
Here, $m_i$, $J_i$, $T_i$ are mass, moment of inertia, and torque; $g$ is gravity; $c_{ji}$, $k_{ji}$ are damping and stiffness of supports in direction $j$ for gear $i$. The components of the meshing force ($F_t$, $F_x$, $F_y$, $F_z$) are related to the normal force $F$ through the pressure angle and helix angle:
$$
\begin{aligned}
F_t &= F \cos\alpha_n \cos\beta \\
F_x &= F_t \sin(\alpha – \alpha_t) \\
F_y &= F_t \cos(\alpha – \alpha_t) \\
F_z &= F \tan\beta
\end{aligned}
$$
These eight coupled, nonlinear, second-order differential equations form the complete dynamical system for the helical gear transmission.
Modeling of Tooth Defects in Helical Gears
The primary effect of a localized tooth defect—be it a crack, spall, or significant pitting—is a reduction in the local bending and contact stiffness of that particular tooth. This results in a periodic dip in the overall mesh stiffness $k(t)$ every time the defective tooth enters the meshing zone. Instead of modeling a specific physical defect geometry, this analysis adopts a pragmatic approach by quantifying the defect severity as a percentage reduction in the single-tooth-pair mesh stiffness $k_p$ during the defective tooth’s engagement period.
For a gear with a single defective tooth, the time-varying mesh stiffness $k(\tau)$ can be modeled in a piecewise manner as a function of the dimensionless time $\tau$:
$$
k(\tau) = \begin{cases}
k_{\text{def}}, & \text{mod}(\tau, 2\pi/\Omega_i) \le 2\pi/(\Omega_i Z_i) \\
k(\tau)_{\text{healthy}}, & \text{otherwise}
\end{cases}
$$
where $k_{\text{def}}$ is the reduced stiffness value when the defective tooth is in mesh, $\Omega_i$ is the dimensionless rotational speed of the defective gear $i$, $Z_i$ is its number of teeth, and $\text{mod}$ is the modulus function. The defect severity $S$ is defined as:
$$
S = \left(1 – \frac{k_{\text{def}}}{k_p}\right) \times 100\%
$$
This method allows us to systematically investigate the impact of defect severity (e.g., 20%, 40%, 60% stiffness reduction) on system dynamics, irrespective of the defect’s specific shape, providing generalized insights into the fault dynamics of helical gears.
System Parameters and Numerical Solution Methodology
The analysis focuses on a high-power, high-speed stage helical gear pair typical of a multi-megawatt wind turbine gearbox. The key system parameters are summarized in the table below.
| Parameter | Gear 1 (Wheel) | Gear 2 (Pinion) |
|---|---|---|
| Number of Teeth, $Z$ | 100 | 25 |
| Mass, $m$ (kg) | 573.55 | 121.12 |
| Moment of Inertia, $J$ (kg·m²) | 36.35 | 0.167 |
| Eccentricity, $\rho$ (μm) | 90 | 90 |
| Helix Angle, $\beta$ (degrees) | +15 | +15 |
| Normal Pressure Angle, $\alpha_n$ (degrees) | 20 | 20 |
| Average Mesh Stiffness, $k_0$ (N/m) | 5.52 × 10⁸ | |
| Mesh Damping Ratio, $\xi$ | 0.07 | |
| Bearing Stiffness, $k_x$, $k_y$, $k_z$ (N/m) | 6e8, 9e8, 4.8e8 | 2e8, 3e8, 1.6e8 |
The equations of motion are non-dimensionalized and solved numerically using a fourth-order Runge-Kutta integration scheme. Due to the strong nonlinearity from backlash and time-varying stiffness, analytical solutions are intractable. To analyze the long-term, steady-state dynamic behavior, numerical simulations are run for a sufficiently long duration, and the transient data is discarded. The remaining steady-state response data is used to construct key diagnostic tools:
- Bifurcation Diagrams: Plots of the dynamic transmission error (DTE) peaks or Poincaré points against a control parameter (e.g., backlash $b$ or pinion speed $\omega_1$) reveal global stability changes and routes to chaos.
- Phase Portraits: Plots of velocity $\dot{p}$ versus displacement $p$ for the DTE illustrate the attractor’s geometry in state space.
- Poincaré Maps: Sampled points of the trajectory once per mesh period reduce the continuous flow to a discrete map, clearly distinguishing periodic (finite points), quasi-periodic (closed curve), and chaotic (fractal point cloud) motions.
- Power Spectra: The Fast Fourier Transform (FFT) of the DTE time history identifies dominant frequencies and the broadband nature characteristic of chaos.
Nonlinear Dynamic Analysis: The Impact of Tooth Defects
The analysis proceeds by comparing the dynamic response of the healthy helical gear system with systems where either the large wheel (Gear 1) or the high-speed pinion (Gear 2) has a single tooth defect of varying severity.
1. Influence of Defects on Backlash-Induced Bifurcations
First, the rotational speed is fixed at a nominal operational value ($\omega_1 = 1015$ rpm), and the dimensionless backlash $b$ is varied as the control parameter. Bifurcation diagrams of the DTE are constructed for different defect scenarios.
| Defect Scenario | Healthy System Response | Key Observations with Defect |
|---|---|---|
| Healthy Gears | Primarily periodic-1 motion. Regions of multi-periodic or chaotic behavior appear only for specific backlash ranges. | Baseline for comparison. |
| Gear 1 (Wheel) Defect, $S=40\%$ | – | The range of backlash values leading to quasi-periodic and chaotic motions expands noticeably. Periodic windows become narrower. |
| Gear 1 (Wheel) Defect, $S=60\%$ | – | Further expansion of non-periodic regimes. The system exhibits a strong propensity for complex dynamics over a wider operational range. |
| Gear 2 (Pinion) Defect, $S=40\%$ | – | A more dramatic effect than the wheel defect. The bifurcation structure becomes significantly more complex at lower backlash values. |
| Gear 2 (Pinion) Defect, $S=60\%$ | – | The most severe case. Quasi-periodic and chaotic motions dominate almost the entire range of backlash variation examined. The periodic response is nearly eliminated. |
The critical insight is that a tooth defect, by introducing a periodic stiffness disturbance, lowers the threshold for nonlinear instabilities. The system becomes more sensitive to backlash, entering chaotic regimes at smaller clearances. Furthermore, a defect on the high-speed pinion is far more detrimental than one on the low-speed wheel. This is because the pinion’s defect manifests as a higher-frequency excitation ($\omega_{e2} = Z_2 \omega_2 = Z_1 \omega_1$), which more effectively excites the system’s nonlinear resonances.
2. Influence of Defects on Speed-Dependent Bifurcations
Next, the backlash is fixed at a nominal value ($b=0.05$ mm), and the rotational speed of the pinion $\omega_1$ is varied to simulate operational speed changes. The resulting bifurcation diagrams reveal how defects influence the classic jump phenomena and resonance characteristics of helical gears.
| Defect Scenario | Healthy System Response | Key Observations with Defect |
|---|---|---|
| Healthy Gears | Smooth period-1 response over most speeds. Isolated jump phenomena and period-doubling at certain critical speeds. | Baseline behavior. |
| Gear 1 (Wheel) Defect | – | Introduces or amplifies jump phenomena (sudden changes in vibration amplitude) at both low and high speeds. Each jump is associated with a bifurcation (e.g., period-1 to period-2). The speed ranges for periodic and chaotic motions are altered. |
| Gear 2 (Pinion) Defect | – | Even more profound impact. A severe defect (e.g., $S=60\%$) induces multiple jumps and complex sequences of period-doubling bifurcations leading to chaos across various speed ranges. The system’s operational speed range becomes fragmented with islands of instability. |
This analysis underscores that a defective tooth effectively adds a new internal forcing function at the defect frequency and its harmonics. This interacts with the existing parametric excitation from time-varying stiffness and the external excitation from rotational unbalance, creating a rich landscape of nonlinear interactions that manifest as complex bifurcation structures over the speed parameter.
3. Phase Space, Poincaré Maps, and Frequency Spectrum Analysis
To gain a deeper, qualitative understanding, we examine the phase portrait, Poincaré map, and power spectrum for a fixed operating point ( $\omega_1 = 1015$ rpm, $b=0.05$ mm) under different defect conditions.
| Condition | Phase Portrait of DTE | Poincaré Map | Power Spectrum | Diagnosis |
|---|---|---|---|---|
| Healthy | Smooth, closed orbit. | A single, well-defined point. | Discrete peaks at mesh frequency and its harmonics. | Stable period-1 motion. |
| Gear 1 Defect, $S=40\%$ | Orbit thickens, loses smoothness. | Small, clustered point cloud. | Discrete peaks remain but with increased sidebands and noise floor. | Weakly modulated or quasi-periodic motion. |
| Gear 2 Defect, $S=40\%$ | Complex, multi-loop structure. | Points form a distorted closed curve. | Broadband components appear between discrete peaks. | Developed quasi-periodic motion. |
| Gear 2 Defect, $S=60\%$ | Highly complex, seemingly non-repeating structure filling a bounded region. | Fractal-like, scattered point cloud. | Continuous, broadband spectrum with submerged discrete peaks. | Chaotic motion. |
The evolution is clear: As the defect severity on the high-speed pinion increases, the system transitions from periodic motion to quasi-periodicity and finally to chaos. The Poincaré map’s transformation from a point to a closed curve to a fractal scatter is a classic signature of this transition. The spectrum’s evolution from discrete lines to a continuous broadband confirms the onset of deterministic chaos. Notably, the chaotic attractor for the severe pinion defect case shows evidence of period-3 sub-harmonics within its complex structure, a common feature in nonlinear systems.
The governing equations during the defective mesh period can be conceptually seen as a stiffness perturbation:
$$
\ddot{p} + 2\xi\omega_0 \dot{p} + [\omega_0^2 – \Delta k(t)] f(p) = F_m(\omega_e t) + F_e(\Omega_i t)
$$
where $\Delta k(t)$ represents the periodic stiffness loss due to the defect, $F_m$ is the forcing from transmission error, and $F_e$ is from eccentricity. The defect term $\Delta k(t)$ modulates the effective natural frequency of the mesh, potentially driving parametric instabilities that lead to the observed complex dynamics in helical gears.
Conclusion
This comprehensive analysis of a high-power wind turbine helical gear pair establishes a clear link between localized tooth defects and the exacerbation of nonlinear dynamic phenomena. By modeling the defect as a quantifiable reduction in local mesh stiffness within a sophisticated 8-DOF nonlinear dynamical model, we have systematically traced its impact.
The key findings are:
- Defect Severity is Critical: The degree of stiffness reduction in a single tooth directly correlates with the complexity of the system’s dynamic response. Moderate defects induce multi-periodic and quasi-periodic motions, while severe defects can drive the system into full-blown chaotic regimes over wide operational ranges of backlash and speed.
- High-Speed Pinion Defects are More Deleterious: A defect on the smaller, faster-rotating pinion has a disproportionately larger impact than an equivalent defect on the large wheel. The higher meshing frequency associated with the pinion’s rotation acts as a more effective trigger for nonlinear instabilities, making the system significantly more vulnerable.
- Altered Stability Landscapes: Tooth defects effectively reshape the system’s bifurcation diagrams, expanding the regions of parameter space (backlash, speed) where undesirable quasi-periodic and chaotic vibrations occur. This reduces the safe operational envelope of the helical gear transmission.
- Diagnostic Signatures: The transition in phase portraits from closed orbits to chaotic attractors, the evolution of Poincaré maps from points to fractal sets, and the spectral broadening from discrete lines to continuous noise provide clear, model-based signatures for defect detection and severity assessment.
In practical terms, this work underscores the importance of robust condition monitoring for high-power helical gears. Tracking changes in vibration spectra, particularly the emergence of sidebands and broadband noise, and analyzing the structure of vibration signals in phase space can serve as early warnings for developing tooth defects. Understanding that even a single, localized defect can precipitate global chaotic dynamics highlights the critical need for precision in manufacturing, assembly, and maintenance of these essential power transmission components to ensure the longevity and reliability of systems like wind turbine generators.