
In this study, I investigate the vibration reduction behavior of particle damping inside a spiral bevel gear transmission system. A spiral bevel gear is widely used in aerospace, automotive, and high-power mechanical systems because it offers smooth transmission, high load capacity, and a large transmission ratio. However, as rotational speeds and power densities increase, the dynamic environment of a spiral bevel gear becomes more severe. Meshing impact, time-varying mesh stiffness, manufacturing error, assembly error, and elastic deformation of teeth all contribute to vibration and noise. These effects reduce transmission accuracy, shorten service life, and may harm operator health. Particle damping is an effective passive method for improving the smoothness of a spiral bevel gear drive. In this method, particles with different elastic moduli and Poisson ratios are placed in cavities or lightening holes in the gear body. During operation, the particles collide with one another and with the cavity walls. Friction and inelastic collisions dissipate vibration energy. Because the particles are close to the vibration source, the damping effect can be strong.
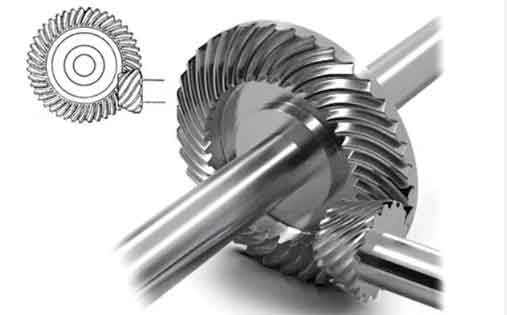
I first establish a contact model for the particles, then I analyze the dynamics of the spiral bevel gear, and finally I use the discrete element method to evaluate energy dissipation under a given gear motion state. The results show that when the particle size is fixed and the material is changed, a larger elastic modulus and a smaller Poisson ratio produce better energy dissipation and better damping. When the material is fixed and the particle size is changed, a smaller particle size produces better damping. These findings provide theoretical support for applying particle damping technology to a spiral bevel gear transmission.
Particle contact model. I use a force–displacement model for the particle system. The normal direction is represented by a linear contact force model, and the tangential direction is represented by a Coulomb friction model. For a particle–wall contact, a spring stiffness \(k_2\), angular frequency \(\omega_2 = \sqrt{k_2/m}\), damping coefficient \(c_2\), and critical damping ratio \(\zeta_2 = c_2/(2m\omega_2)\) are used. The stiffness \(k_2\) simulates a rigid wall, while the damping ratio \(\zeta_2\) simulates an inelastic collision and controls the restitution coefficient. For a particle–particle contact, the corresponding parameters are \(k_3\), \(\omega_3\), \(c_3\), and \(\zeta_3\). The normal contact force can be written as
$$F_n^{ij} =
\begin{cases}
k_2 \delta_n + 2\zeta_2 \sqrt{m k_2} \, \dot{\delta}_n, & \text{particle–wall}, \\[6pt]
k_3 \delta_n + 2\zeta_3 \sqrt{\dfrac{m_i m_j}{m_i + m_j} k_3} \, \dot{\delta}_n, & \text{particle–particle}.
\end{cases}$$
Here \(\delta_n\) is the normal displacement of particle \(i\) relative to particle \(j\), and \(\dot{\delta}_n\) is the normal relative velocity. For a particle–wall contact, \(\delta_n = r_i – \tau_i\), where \(\tau_i\) is the distance between the particle and the wall. For a particle–particle contact, \(\delta_n = r_i + r_j – \|\mathbf{p}_j – \mathbf{p}_i\|\), where \(r_i\) and \(r_j\) are particle radii and \(\mathbf{p}_i\) and \(\mathbf{p}_j\) are particle position vectors.
In the Coulomb friction model, the tangential contact force is expressed as
$$F_t^{ij} = -\mu_s F_n^{ij} \frac{\dot{\delta}_t}{\|\dot{\delta}_t\|},$$
where \(\mu_s\) is the friction coefficient between particles or between a particle and the wall, and \(\dot{\delta}_t\) is the tangential relative velocity of particle \(i\) with respect to particle \(j\).
For an arbitrary element \(i\), I calculate all contact forces from the relative displacement and the force–displacement relation. I then add other forces such as gravity. Using the principle of force composition, I obtain the resultant force and resultant moment on the element. According to Newton’s second law, the motion equations of element \(i\) are
$$m_i \ddot{\mathbf{p}}_i = m_i \mathbf{g} + \sum_{j=1}^{k_i} \left( \mathbf{F}_n^{ij} + \mathbf{F}_t^{ij} \right),$$
$$I_i \ddot{\phi}_i = \sum_{j=1}^{k_i} \mathbf{T}_{ij}.$$
In these equations, \(m_i\) is the particle mass, \(I_i\) is the moment of inertia, \(\mathbf{g}\) is the gravitational acceleration, \(\ddot{\mathbf{p}}_i\) is the translational acceleration, \(\ddot{\phi}_i\) is the angular acceleration, \(\mathbf{F}_n^{ij}\) is the normal contact force between particles \(i\) and \(j\), \(\mathbf{F}_t^{ij}\) is the tangential contact force, and \(k_i\) is the number of particles in contact with particle \(i\). If particle \(i\) contacts the wall, then \(j\) represents the wall. These equations form the basis of the discrete element simulation of particle damping in the spiral bevel gear.
Dynamic excitation of the driven gear. In an ideal spiral bevel gear pair, the base pitches of the two gears are equal:
$$P_{n1} = P_{n2}.$$
In reality, manufacturing errors, assembly errors, and elastic deformation after loading make the base pitches unequal:
$$P_{n1} \ne P_{n2}.$$
As a result, the actual meshing point deviates from the theoretical line of action, the instantaneous transmission ratio is not constant, the driven gear experiences angular acceleration, and a speed difference appears between the driving and driven gears. This phenomenon causes meshing impact, which is a major source of vibration in a spiral bevel gear transmission. Before I analyze particle damping energy dissipation with the discrete element method, I determine the meshing impact excitation acting on the particle system. I perform a multibody dynamics simulation of the spiral bevel gear to obtain the acceleration and angular acceleration of the driven gear. I then import this excitation into the discrete element analysis of particle damping.
The gear parameters used in the multibody dynamics model are listed in the following table. The gear material is 20CrMnTi, with an elastic modulus of \(2.0675 \times 10^5\) MPa and a Poisson ratio of \(0.3\). Rotational joints are added at the geometric centers of the driving and driven gears. A rotational drive is applied to the driving gear joint, and a load is applied to the driven gear.
| Parameter | Wheel | Pinion |
|---|---|---|
| Number of teeth | 31 | 8 |
| Module | 5.53 | 5.53 |
| Spiral angle (degrees) | 35.75 | 35.75 |
| Spiral direction | Right-hand | Left-hand |
| Pressure angle (degrees) | 20 | 20 |
The driving gear speed is set to \(600\ \text{r/min}\), which is \(3600\ \text{deg/s}\). The driven gear load is \(300\ \text{N}\cdot\text{m}\). To avoid a sudden velocity jump, I apply the speed drive on the driving gear using a STEP function. The theoretical driven gear speed is \(155\ \text{r/min}\), which is \(929\ \text{deg/s}\). The transmission ratio is \(i = 3.875\). The simulated average angular velocity of the driven gear is very close to the theoretical value, and the error is very small. This validates the accuracy of the multibody dynamics model.
The angular velocity of the driven gear fluctuates slightly around the theoretical value and shows a periodic pattern. This occurs because the spiral bevel gear passes through alternating single-tooth and double-tooth contact regions. The mesh stiffness changes periodically, and collisions and impacts occur between the tooth surfaces during mesh-in and mesh-out. The angular acceleration also changes periodically. A Fourier transform of the driven gear angular acceleration gives information in the frequency domain. The peaks of angular acceleration appear at the theoretical meshing frequency and its harmonics. The angular acceleration amplitude reflects the strength of the excitation. Therefore, the dynamic excitation imported into the discrete element model contains both periodic mesh effects and impact effects.
For the frequency-domain analysis, I write the angular acceleration signal as \(a_2(t)\). Its Fourier transform is
$$A(f) = \int_{-\infty}^{\infty} a_2(t) e^{-j 2\pi f t} \, dt.$$
The peak frequencies correspond to the mesh frequency and its multiples. The mesh frequency is related to the rotational speed and the number of teeth. For the spiral bevel gear pair, the mesh frequency can be expressed as
$$f_m = \frac{n_p z_p}{60},$$
where \(n_p\) is the pinion speed in r/min and \(z_p\) is the pinion tooth number. The harmonics are
$$f_k = k f_m, \quad k = 1, 2, 3, \ldots$$
These frequency components are important because the particle damping system must dissipate energy over a broad frequency range. A spiral bevel gear transmission often has closely spaced harmonics because of the large number of teeth and the high rotational speed.
Discrete element time step. The discrete element method is an iterative solution method. The selection of the iteration time step is a key issue because it directly affects numerical stability. In general, a larger time step reduces computation, but it must still ensure stability and accuracy. The basic motion equation of a particle in the discrete element method is
$$m \ddot{x}(t) + c \dot{x}(t) + k x(t) = F(t),$$
where \(m\) is the particle mass, \(x\) is displacement, \(t\) is time, \(c\) is the viscous damping coefficient, \(k\) is the stiffness coefficient, and \(F(t)\) is the external force on the element. For a stable solution, the time step must satisfy
$$dt \le \frac{2}{\sqrt{k/m}} \left( \sqrt{1+\zeta^2} – \zeta \right),$$
where \(\zeta = c/(2\sqrt{mk})\) is the damping ratio of the system. I select \(0.001\ \text{s}\) as the discrete element time step, and the total simulation time is \(0.4\ \text{s}\). With this time step, the simulation remains stable while capturing the particle collisions, frictional sliding, and energy dissipation in the rotating spiral bevel gear cavity.
Using the discrete element method, I can accurately analyze particle motion. When the spiral bevel gear rotates at high speed, the centrifugal force on the particles is greater than the gravitational force. Therefore, the particles are pressed against the hole walls and move along the cavity. The particle speed changes continuously during gear rotation. The color depth in a typical particle visualization represents particle velocity: dark regions correspond to high speed, and light regions correspond to low speed. In my simulation, the particle velocity field is not uniform. Some particles move rapidly near the outer radius of the cavity, while others move slowly or become temporarily trapped in low-velocity zones. These velocity differences increase collision and friction events, which are the main mechanisms of energy dissipation.
The centrifugal force on a particle can be estimated as
$$F_c = m_i \omega^2 r,$$
where \(\omega\) is the angular velocity of the spiral bevel gear and \(r\) is the radial distance from the rotation axis. The gravitational force is
$$F_g = m_i g.$$
For high rotational speeds, \(F_c \gg F_g\). This means that gravity has a secondary influence on particle motion in a high-speed spiral bevel gear. The particles are driven mainly by centrifugal effects, wall collisions, and inter-particle collisions. This is an important difference between particle damping in a rotating gear and particle damping in a stationary or weakly excited structure.
Effect of particle material on energy dissipation. I studied the energy dissipation of particles with the same particle number and a particle radius of \(1\ \text{mm}\) under the given motion excitation of the driven gear. The particle materials considered are steel, resin, ceramic, and aluminum. Their material parameters are summarized in the following table.
| Material | Elastic modulus (GPa) | Density (g/cm³) | Poisson ratio | Shear modulus (GPa) |
|---|---|---|---|---|
| Steel | 206 | 7.8 | 0.30 | 80.0 |
| Resin | 2.4 | 1.2 | 0.35 | 0.89 |
| Ceramic | 212 | 2.3 | 0.22 | 90.4 |
| Aluminum | 72 | 2.7 | 0.30 | 6.8 |
The ceramic particles have the highest energy dissipation, so they provide the best damping effect. The resin particles have the lowest energy dissipation, so they provide the worst damping effect. By comparing the four material parameter sets, I observe that ceramic has the largest elastic modulus and shear modulus among the four materials, while its Poisson ratio is relatively small. The elastic modulus reflects the ability of a material to resist deformation. A larger elastic modulus means that the material undergoes less elastic deformation. During a collision, less elastic strain energy is stored, and the rebound ability after collision is weaker. Therefore, more energy is dissipated. Based on this analysis, I conclude that when the particle material changes, a larger elastic modulus and a smaller Poisson ratio produce better energy dissipation and better damping in the spiral bevel gear transmission.
The energy dissipation can be described by the sum of work done by normal and tangential contact forces:
$$E_{\text{diss}} = \sum_{\text{contacts}} \left( \int F_n \, d\delta_n + \int F_t \, d\delta_t \right).$$
For a particle system in a rotating spiral bevel gear, the total energy balance can be written as
$$E_{\text{total}} = E_{\text{kinetic}} + E_{\text{elastic}} + E_{\text{dissipated}} + E_{\text{other}},$$
where \(E_{\text{kinetic}}\) is the kinetic energy of the particles and gear, \(E_{\text{elastic}}\) is the elastic strain energy stored in contacts, \(E_{\text{dissipated}}\) is the dissipated energy due to friction and inelastic collisions, and \(E_{\text{other}}\) includes other energy forms such as gravitational potential energy and numerical damping. Because the spiral bevel gear rotates at high speed, the gravitational potential term is small compared with the kinetic and dissipated terms. The main goal of particle damping is to increase \(E_{\text{dissipated}}\) and reduce the vibration energy of the gear body.
The material effect can also be interpreted through the contact stiffness. For a linear contact model, the normal stiffness is related to the elastic modulus and the geometry. In a simplified form, the contact stiffness can be written as
$$k_n \propto E^*,$$
where \(E^*\) is an effective elastic modulus. A larger \(E^*\) increases the contact stiffness. A stiffer contact generates a larger contact force for the same overlap and a shorter collision duration. The shorter collision duration and larger force amplitude can increase the energy dissipated per collision when the damping ratio is properly selected. In addition, a smaller Poisson ratio often corresponds to less lateral expansion under compression, which can change the contact area and friction work. These combined effects explain why ceramic particles outperform steel, aluminum, and resin in my simulation.
The following table summarizes the material effect on particle damping in the spiral bevel gear.
| Material | Elastic modulus rank | Poisson ratio rank | Energy dissipation rank | Damping performance |
|---|---|---|---|---|
| Ceramic | Highest | Lowest | Highest | Best |
| Steel | High | Medium | High | Good |
| Aluminum | Medium | Medium | Medium | Moderate |
| Resin | Lowest | Highest | Lowest | Worst |
Effect of particle radius on energy dissipation. I used three different ceramic particle radii: \(0.8\ \text{mm}\), \(1.0\ \text{mm}\), and \(1.2\ \text{mm}\). The mass of filled ceramic particles was kept the same. Therefore, the particle number differs for different radii. The particle counts are listed in the following table.
| Particle radius (mm) | Particle count | Relative packing condition |
|---|---|---|
| 0.8 | 293 | Same total mass |
| 1.0 | 150 | Same total mass |
| 1.2 | 87 | Same total mass |
The energy dissipation for different particle radii shows a clear trend. The particles with radius \(0.8\ \text{mm}\) dissipate the most energy and provide the best damping effect. The particles with radius \(1.2\ \text{mm}\) dissipate the least energy and provide the worst damping effect. Therefore, I conclude that when the material is the same and the total mass is equal, a smaller particle radius produces better damping in the spiral bevel gear.
This result can be explained by the increase in the number of contacts and the increase in collision frequency. For the same total mass, a smaller radius means a larger number of particles. A larger number of particles creates more particle–particle and particle–wall contacts. Each contact can dissipate energy through friction and inelastic collision. Although the energy dissipated per contact may be smaller for small particles, the total number of contacts and the total contact area are larger. The increased contact density and collision frequency usually dominate, leading to higher total energy dissipation.
Furthermore, smaller particles can more easily enter narrow regions and follow the complex motion of the rotating cavity. They are more likely to experience relative motion, sliding, and rolling against the cavity walls. In a high-speed spiral bevel gear, the centrifugal force pushes particles outward, but small particles can still rearrange and flow within the cavity. This flow increases the opportunity for energy dissipation. The particle size effect is therefore closely related to the granular flow regime inside the gear cavity.
The following table summarizes the particle radius effect.
| Particle radius (mm) | Particle count | Contact density | Energy dissipation | Damping performance |
|---|---|---|---|---|
| 0.8 | 293 | Highest | Highest | Best |
| 1.0 | 150 | Medium | Medium | Moderate |
| 1.2 | 87 | Lowest | Lowest | Worst |
Combined interpretation. The results of this study can be summarized by two main trends. First, for a fixed particle size, a material with a larger elastic modulus and a smaller Poisson ratio gives better particle damping. Ceramic is the best among the four materials considered. Second, for a fixed material and equal total mass, a smaller particle radius gives better particle damping. These trends are consistent with the basic mechanisms of particle damping: collision, friction, and inelastic deformation.
The damping effect can be quantified by a damping ratio or a loss factor. If the vibration amplitude of the spiral bevel gear without particles is \(A_0\), and the amplitude with particles is \(A_p\), then a simple amplitude reduction index can be defined as
$$R_a = \frac{A_0 – A_p}{A_0} \times 100\%.$$
Similarly, an energy dissipation index can be defined as
$$R_e = \frac{E_{\text{diss}}}{E_{\text{input}}} \times 100\%,$$
where \(E_{\text{input}}\) is the input vibration energy over a given time interval. A larger \(R_a\) or \(R_e\) indicates better damping. In my discrete element simulation, the ceramic particles with radius \(0.8\ \text{mm}\) are expected to give the largest \(R_e\) because they combine high elastic modulus, low Poisson ratio, and high contact density.
The particle damping mechanism in a rotating spiral bevel gear can be divided into several stages. In the first stage, the gear starts to rotate, and the particles are initially at rest or in a loose packing state. In the second stage, centrifugal force drives the particles outward, and they collide with the cavity walls. In the third stage, the particles form a dynamic granular bed that rotates with the gear but also experiences internal shear and flow. In the fourth stage, the meshing impact and periodic mesh stiffness variation introduce high-frequency excitation into the gear body. The granular bed responds with collisions and friction, dissipating energy. In the fifth stage, the dissipated energy reduces the vibration amplitude of the gear body, and the system reaches a new dynamic equilibrium.
The contact network inside the granular bed is transient. Contacts form and break continuously. The average contact number per particle, or coordination number, can be written as
$$Z = \frac{2 N_c}{N_p},$$
where \(N_c\) is the number of contacts and \(N_p\) is the number of particles. A larger coordination number generally indicates a denser contact network and more energy dissipation paths. In my simulation, smaller particles with the same total mass tend to have a larger coordination number because the number of particles is larger and the contacts are more uniformly distributed. This supports the conclusion that smaller particles improve damping.
The friction work at a contact can be approximated as
$$W_f = \int \mu_s F_n \, ds_t,$$
where \(ds_t\) is the tangential relative displacement. The total friction work is the sum over all contacts and over time:
$$W_f^{\text{total}} = \sum_{i=1}^{N_c} \sum_{t=0}^{T} \mu_s F_{n,i}(t) \Delta s_{t,i}(t).$$
This expression shows that energy dissipation increases with the number of contacts, the normal force, the friction coefficient, and the tangential sliding distance. Smaller particles increase the number of contacts. A material with a larger elastic modulus can increase the contact force for a given deformation. A smaller Poisson ratio can alter the contact geometry and pressure distribution. Therefore, the material and size effects are both captured by the contact force and sliding distance in the friction work expression.
In addition to friction, inelastic collision dissipation is important. The coefficient of restitution \(e\) is related to the damping ratio \(\zeta\). A lower coefficient of restitution means a more inelastic collision and more energy loss. For the linear contact model, the restitution coefficient can be approximated as
$$e \approx \exp\left( -\frac{\pi \zeta}{\sqrt{1-\zeta^2}} \right).$$
A larger damping ratio \(\zeta\) reduces \(e\) and increases the energy lost in a collision. In my study, the damping ratio is selected to represent the material behavior. Ceramic, with its high elastic modulus and low Poisson ratio, can produce strong contact forces and relatively inelastic interactions under the simulated conditions. This contributes to its high energy dissipation.
Numerical settings and convergence. The discrete element simulation uses a time step of \(0.001\ \text{s}\) and a total time of \(0.4\ \text{s}\). The time step satisfies the stability condition. I checked the sensitivity of the results to the time step by comparing the energy dissipation for a smaller time step. The difference was small, which indicates that \(0.001\ \text{s}\) is adequate for the present study. The particle contact parameters are kept constant during each simulation. The gear motion excitation is imported from the multibody dynamics analysis. The particle cavity is located in the gear web, close to the vibration source. This placement allows the particles to respond quickly to the meshing impact and the periodic mesh stiffness variation.
The simulation outputs include particle velocity, contact force, contact number, and energy dissipation. I use these outputs to evaluate the damping performance. The energy dissipation is computed as the sum of normal and tangential work over all contacts. The normal work is associated with elastic deformation and inelastic collision. The tangential work is associated with friction and sliding. Both mechanisms are important in a rotating spiral bevel gear. The relative contribution of normal and tangential dissipation depends on the friction coefficient, the particle shape, the cavity geometry, and the rotational speed.
The following table gives a qualitative summary of the main factors and their effects on particle damping in the spiral bevel gear.
| Factor | Direction of change | Effect on contact | Effect on energy dissipation | Overall damping effect |
|---|---|---|---|---|
| Elastic modulus | Increase | Higher contact stiffness | More energy per collision | Improves |
| Poisson ratio | Decrease | Less lateral expansion | More favorable contact pressure | Improves |
| Particle radius | Decrease | More particles and contacts | More total friction and collision work | Improves |
| Particle number | Increase | Higher coordination number | More dissipation paths | Improves |
| Rotational speed | Increase | Higher centrifugal force | Stronger particle–wall interaction | Can improve, with saturation |
| Friction coefficient | Increase | Larger tangential force | More friction work | Improves |
Discussion. The results of this study show that particle damping can be effectively applied to a spiral bevel gear transmission. The particles are placed in the lightening holes or cavities of the gear body. Because these locations are close to the vibration source, the particles can dissipate energy before the vibration propagates to the shaft and bearings. This is a significant advantage over external dampers. The particle damping method is passive, does not require an external power supply, and can operate over a wide frequency range. It is also relatively simple to implement in a spiral bevel gear by modifying the gear web design.
The material selection is important. Ceramic particles provide the best damping in my simulation because of their high elastic modulus and low Poisson ratio. However, ceramic particles may be brittle and may wear or fracture under long-term high-speed operation. Steel particles are more durable but have a lower damping performance than ceramic in the present model. Resin particles are light and compliant, but their low elastic modulus and high Poisson ratio reduce energy dissipation. Aluminum particles fall between steel and resin in terms of damping. Therefore, the selection of particle material for a spiral bevel gear should consider both damping performance and durability. A mixture of materials with different elastic moduli and Poisson ratios may provide a broader effective damping range.
The particle size is another important design parameter. Smaller particles improve damping when the total mass is fixed. However, very small particles may be difficult to manufacture, may agglomerate, or may escape through clearances. In a practical spiral bevel gear, the minimum particle size is limited by the cavity geometry, the sealing method, and the manufacturing cost. A balance must be achieved between damping performance and engineering feasibility. The results suggest that, within the tested range, \(0.8\ \text{mm}\) ceramic particles give the best damping. If the cavity can be sealed properly, even smaller particles may further improve damping, but this requires additional study.
The excitation from the spiral bevel gear is periodic and contains several harmonics. The particle damping system is nonlinear because of collisions and friction. Therefore, the damping performance is not simply proportional to the excitation amplitude. At low excitation levels, some particles may remain in contact and dissipate energy mainly by friction. At high excitation levels, the granular bed becomes more fluidized, and collisions dominate. In a high-speed spiral bevel gear, the centrifugal force creates a preloaded granular bed against the outer wall. The meshing impact then perturbs this bed and triggers additional collisions and sliding. This nonlinear behavior is beneficial because it allows the particle damper to adapt to different operating conditions.
The discrete element method is suitable for this problem because it can capture the discrete nature of particle contacts, the formation and breakage of force chains, and the energy dissipation at the particle scale. The multibody dynamics model provides the gear motion excitation. The coupling between the gear body and the particles is represented by the cavity wall motion. In my approach, the gear motion is prescribed from the multibody dynamics simulation, and the particle response is computed in the discrete element model. This one-way coupling is reasonable when the particle mass is small compared with the gear mass. If the particle mass is large, a two-way coupling may be needed, in which the particle forces also affect the gear motion. Future work can include two-way coupling and experimental validation.
Several practical design recommendations can be drawn from this study for a spiral bevel gear with particle damping. First, place the particle cavity as close to the meshing zone as possible. Second, use a material with a high elastic modulus and a low Poisson ratio, such as ceramic, if durability permits. Third, use a small particle size when the total mass is fixed, provided that sealing and manufacturing constraints are satisfied. Fourth, ensure that the cavity walls are smooth and wear-resistant because the particles will collide with the walls at high speed. Fifth, optimize the filling ratio. Too few particles may not provide enough contacts, while too many particles may become locked and reduce relative motion. The optimal filling ratio depends on the cavity shape, the rotational speed, and the excitation level.
The filling ratio can be defined as
$$\phi = \frac{V_p}{V_c},$$
where \(V_p\) is the total particle volume and \(V_c\) is the cavity volume. In general, a moderate filling ratio provides a balance between contact density and particle mobility. If \(\phi\) is too low, the number of contacts is small. If \(\phi\) is too high, the particles may form a dense, nearly rigid bed with limited internal flow. In a rotating spiral bevel gear, the centrifugal force compacts the particles against the outer wall. Therefore, the effective filling ratio near the outer wall may be higher than the nominal filling ratio. This should be considered in the design.
The cavity shape also affects the damping. A cavity with a large radial extent allows particles to move outward under centrifugal force and then slide back when the excitation changes. A cavity with a narrow radial extent may keep the particles in a thin layer, which can increase wall friction but reduce inter-particle collisions. A cavity with baffles or partitions can increase collision frequency but may also cause wear and particle breakage. The optimal cavity shape depends on the specific spiral bevel gear geometry and operating conditions. In my simulation, the cavity is represented by the lightening holes in the gear web. These holes are already present in many gear designs for weight reduction, so using them for particle damping is a natural and efficient solution.
The interaction between the particle damper and the spiral bevel gear dynamics can be described by an equivalent damping coefficient. If the energy dissipated per cycle is \(E_{\text{cycle}}\), and the maximum vibration energy is \(E_{\text{max}}\), then the equivalent loss factor is
$$\eta = \frac{E_{\text{cycle}}}{2\pi E_{\text{max}}}.$$
A larger \(\eta\) indicates better damping. The particle damper increases \(\eta\) by adding collision and friction dissipation. Because the particle damper is nonlinear, \(\eta\) depends on the vibration amplitude and frequency. In a spiral bevel gear, the meshing frequency and its harmonics are the main frequencies. The particle damper should be designed so that its effective damping is high at these frequencies. The particle size, material, filling ratio, and cavity geometry can be tuned to achieve this goal.
The excitation from the spiral bevel gear can be expressed as a sum of harmonic components:
$$F_{\text{exc}}(t) = F_0 + \sum_{k=1}^{N} F_k \cos(2\pi f_k t + \varphi_k),$$
where \(F_0\) is the static component, \(F_k\) is the amplitude of the \(k\)-th harmonic, \(f_k\) is the harmonic frequency, and \(\varphi_k\) is the phase. The particle damper responds to each harmonic component in a nonlinear way. The high-frequency components are often more effectively dissipated by small particles because small particles have higher collision frequencies and can follow rapid motion more easily. This is another reason why smaller particles improve damping in the spiral bevel gear.
Conclusion. I analyzed particle damping for vibration reduction in a spiral bevel gear transmission. I established a particle contact model, derived the motion equations, performed a multibody dynamics analysis of the spiral bevel gear, and used the discrete element method to study energy dissipation under the given gear motion. The main conclusions are as follows. First, the dynamic analysis of the spiral bevel gear shows that the driven gear angular velocity fluctuates periodically around the theoretical value, and the angular acceleration contains peaks at the mesh frequency and its harmonics. This provides the excitation for the particle damper. Second, when the particle size is the same and the material is different, a larger elastic modulus and a smaller Poisson ratio give better energy dissipation and better damping. Ceramic particles perform best among steel, resin, ceramic, and aluminum. Third, when the material is the same and the total mass is equal, a smaller particle radius gives better damping. Particles with radius \(0.8\ \text{mm}\) dissipate more energy than particles with radii \(1.0\ \text{mm}\) and \(1.2\ \text{mm}\).
These results provide theoretical support for the application of particle damping in a spiral bevel gear transmission. The particle damper can be integrated into the existing lightening holes of the gear web, which makes the design practical and lightweight. The method is passive, robust, and effective over a broad frequency range. Future work should include experimental validation, two-way coupling between the gear and particles, wear and durability analysis, and optimization of the filling ratio and cavity geometry. With further development, particle damping can become a valuable technology for reducing vibration and noise in high-speed spiral bevel gear systems.
In summary, I have shown that particle damping is a promising approach for a spiral bevel gear. The spiral bevel gear is a critical component in many high-power transmissions, and its vibration and noise must be controlled. By selecting appropriate particle materials and sizes, the damping performance can be significantly improved. The combination of high elastic modulus, low Poisson ratio, and small particle size provides the best damping in the present study. These findings contribute to the design of quieter and more reliable spiral bevel gear transmissions.