
Rotary forging, also known as swing forging or orbital forging, is a progressive and localized metal forming technology that has gained significant attention in the field of precision manufacturing. As a typical transmission component, the straight bevel gear is widely used in automotive, aerospace, and industrial machinery. The conventional manufacturing route for straight bevel gears relies heavily on metal cutting processes such as gear hobbing, gear shaping, and gear grinding. These subtractive methods are inherently material-wasting and energy-intensive, and more critically, they interrupt the continuous metal flow lines, leading to reduced tooth strength and fatigue life. In contrast, the precision forging of straight bevel gears offers numerous advantages including superior material utilization, enhanced mechanical properties due to uninterrupted grain flow, higher productivity, and improved dimensional accuracy. Among various forging techniques, rotary forging—or swing rolling—distinguishes itself by employing a tilted upper die that rocks or oscillates over the workpiece, thereby deforming only a small portion of the material at any given instant. This unique mechanism results in a substantial reduction in forming load, typically to 1/5 to 1/10 of that required in conventional forging, while simultaneously enabling the forming of complex geometries with high precision. This thesis is dedicated to a systematic numerical investigation of the rotary forging process for a straight bevel gear blank, with a particular focus on the influence of preform shape on the quality of the formed gear. The study harnesses the power of three-dimensional finite element method (FEM) simulations to reveal the metal flow patterns, stress-strain distributions, and forming load characteristics. Ultimately, an optimization strategy is proposed to identify the most favorable preform geometry, defined by a specific drum-shaped profile parameter, to minimize energy consumption and die stress while ensuring complete die filling.
1. Introduction
Gears are fundamental mechanical elements used to transmit power and motion between rotating shafts. Their quality directly determines the performance and reliability of the entire mechanical system. The manufacturing process for gears has evolved over centuries, yet traditional methods remain prevalent. The conventional manufacturing route for a straight bevel gear typically involves blank preparation, tooth cutting (hobbing, shaping, or milling), heat treatment, and final finishing operations such as grinding or lapping. While these cutting methods can achieve high dimensional accuracy, they suffer from significant drawbacks: low material yield, high energy consumption, prolonged production cycles, and the disruption of the desirable metal fiber continuity, which compromises the gear’s load-carrying capacity and service life.
Precision forging, as an advanced manufacturing technology, directly forms gear teeth through plastic deformation, eliminating or minimizing subsequent machining operations. This near-net-shape or net-shape approach has been increasingly adopted as a competitive alternative to traditional machining. For straight bevel gears, precision forging offers the potential to drastically reduce manufacturing costs while enhancing mechanical properties. However, conventional precision forging processes, particularly hot forging, face challenges such as oxidation, decarburization, and high deformation forces that accelerate die wear and reduce die life.
Rotary forging presents a compelling solution to these challenges. Invented in the 1960s and refined by Polish engineer Marciniak in the early 1970s, the rotary forging process utilizes a rocking die to incrementally deform the workpiece. The process is schematically illustrated in the principle where the upper die (rocking die) is inclined at a small angle γ relative to the machine axis. As the main spindle rotates, the die’s axis precesses around the spindle axis, causing the die to contact the workpiece over only a small, localized area. Simultaneously, the lower die advances upward, feeding the workpiece into the deformation zone. This continuous, localized deformation gradually encompasses the entire cross-section of the workpiece, achieving the desired shape with significantly lower forces compared to conventional forging. The advantages of rotary forging for gears are multifaceted: it dramatically reduces the required forming load, improves the uniformity of metal flow and the resulting fiber structure, enhances the dimensional accuracy and surface finish, and enables the production of complex parts with thin walls or intricate details that are difficult to forge conventionally.
The application of rotary forging to gear manufacturing has been an active area of research. In China, significant progress has been made since the late 1970s, starting with the successful cold rotary forging of an end-face gear at the 59th Research Institute of China Ordnance Industries. Subsequent research has explored the rotary forging of various gear types, including straight bevel gears for automotive differentials, spiral bevel gears, and parts with complex appendages. These studies have primarily focused on the design of rocking die trajectories, the influence of process parameters (such as feed rate and die inclination angle) on die filling, the estimation of forming loads, and the analysis of metal flow. However, a comprehensive understanding of the deformation mechanics and the optimal preform design for a straight bevel gear remains incomplete.
This research is motivated by the need to enhance the die life and forming efficiency in the cold rotary forging of straight bevel gears. The work employs a combination of three-dimensional solid modeling and finite element analysis to simulate the entire forming process. The primary objectives are:
- To establish an accurate finite element model for the rotary forging of a straight bevel gear by using the software Deform-3D, based on rigid-plastic finite element theory.
- To investigate the influence of preform shape (cylindrical, conical, and drum-shaped) on the metal flow, filling quality, stress-strain distribution, and forming load.
- To optimize the geometry of the drum-shaped preform by defining a parameter b to quantify the drum degree, and to identify the optimal value that minimizes forming energy and maximizes die life.
Figure 1 illustrates the research flow, which begins with the construction of a three-dimensional model, followed by numerical simulation in a controlled virtual environment, subsequent analysis of the results, and finally, the optimization of parameters to achieve the desired outcomes.
2. Numerical Simulation Theory and Software
2.1 Rigid-Plastic Finite Element Method
The finite element method is a powerful numerical tool for analyzing the complex material flow during bulk metal forming. For processes like rotary forging, where the elastic deformation is negligible compared to the large plastic deformation, the rigid-plastic finite element method is particularly suitable. Unlike the elastic-plastic FEM, which accounts for both elastic and plastic strains, the rigid-plastic FEM ignores the elastic portion, simplifying the constitutive equations and improving computational efficiency. This method is based on the Marcov variational principle and several fundamental assumptions:
- The material is rigid-plastic and obeys the von Mises yield criterion.
- The material is isotropic and incompressible.
- Volume forces and inertial forces are neglected.
- The material exhibits strain hardening but is insensitive to strain rate for cold forming applications.
The theoretical foundation of the rigid-plastic FEM involves solving a boundary value problem defined by equilibrium equations, geometric (compatibility) equations, constitutive equations, and boundary conditions. The equilibrium equation is given by:
$$ \sigma_{ij,j} = 0 $$
where \(\sigma_{ij}\) is the stress tensor. The strain rate tensor \(\dot{\varepsilon}_{ij}\) is related to the velocity field \(v_i\) by the geometric equation:
$$ \dot{\varepsilon}_{ij} = \frac{1}{2} (v_{i,j} + v_{j,i}) $$
The constitutive relation based on the Levy-Mises flow rule is:
$$ \dot{\varepsilon}_{ij} = \dot{\lambda} \sigma’_{ij} $$
where \(\sigma’_{ij}\) is the deviatoric stress tensor and \(\dot{\lambda}\) is a positive scalar factor. These equations are solved by minimizing a functional that represents the total energy dissipation rate. For a rigid-plastic material, the functional \(\Pi\) is:
$$ \Pi = \int_V \bar{\sigma} \dot{\bar{\varepsilon}} dV – \int_{S_F} F_i v_i dS $$
Here, \(\bar{\sigma}\) is the effective stress, \(\dot{\bar{\varepsilon}}\) is the effective strain rate, \(V\) is the volume, \(S_F\) is the surface where traction \(F_i\) is applied, and \(v_i\) is the velocity. The incompressibility constraint \(\dot{\varepsilon}_v = 0\) is typically handled using either the Lagrange multiplier method or the penalty function method. In the penalty method, the functional is augmented by a term involving the penalty factor \(\alpha\):
$$ \Pi = \int_V \bar{\sigma} \dot{\bar{\varepsilon}} dV – \int_{S_F} F_i v_i dS + \frac{\alpha}{2} \int_V (\dot{\varepsilon}_v)^2 dV $$
The friction at the die-workpiece interface is a critical boundary condition. Due to the high contact pressures, a shear friction model is often preferred over the Coulomb model. The shear friction stress \(\tau_f\) is expressed as:
$$ \tau_f = m k $$
where \(m\) is the friction factor and \(k\) is the shear yield stress of the material. To avoid numerical difficulties at the neutral point where the relative sliding velocity reverses direction, a modified formulation is used:
$$ \tau_f = -m k \left( \frac{2}{\pi} \tan^{-1} \left( \frac{|v_s|}{u_0} \right) \right) \frac{v_s}{|v_s|} $$
where \(v_s\) is the relative sliding velocity and \(u_0\) is a small positive constant.
2.2 The DEFORM-3D Software
The numerical simulations in this study are performed using DEFORM-3D, a commercial finite element software package specifically designed for bulk metal forming processes. DEFORM-3D is built upon the rigid-plastic and rigid-viscoplastic finite element formulations, making it an ideal tool for simulating forging, extrusion, and rotary forming processes. The software offers several key features that are essential for this research:
- Robust mesh generation and automatic remeshing: DEFORM-3D can handle the severe mesh distortion that occurs during large deformation processes by automatically generating a new mesh when the existing one becomes too distorted. The data is interpolated from the old mesh to the new one, ensuring the continuity of the simulation.
- Material library: The software provides a comprehensive library of material models, including rigid-plastic, elastic-plastic, and porous materials. Users can also define custom material data, such as the flow stress as a function of strain, strain rate, and temperature.
- Flexible tool (die) definition: Dies can be modeled as either rigid bodies or deformable objects. In this work, the dies are initially treated as rigid bodies to focus on the workpiece deformation. Later, for the die stress analysis, the lower die is treated as an elastic object.
- Complex kinematic definition: DEFORM-3D allows the user to define intricate die movements, including rotations, translations, and combinations thereof. This is crucial for simulating the rocking and precessing motion of the upper die in rotary forging.
- Comprehensive post-processing capabilities: The software provides tools to visualize the distribution of stress, strain, velocity, and temperature. It also allows for the extraction of forming load-stroke curves and the tracking of specific material points during the deformation.
3. Geometric Modeling and Simulation Preparation
3.1 Gear Material and Blank Dimensions
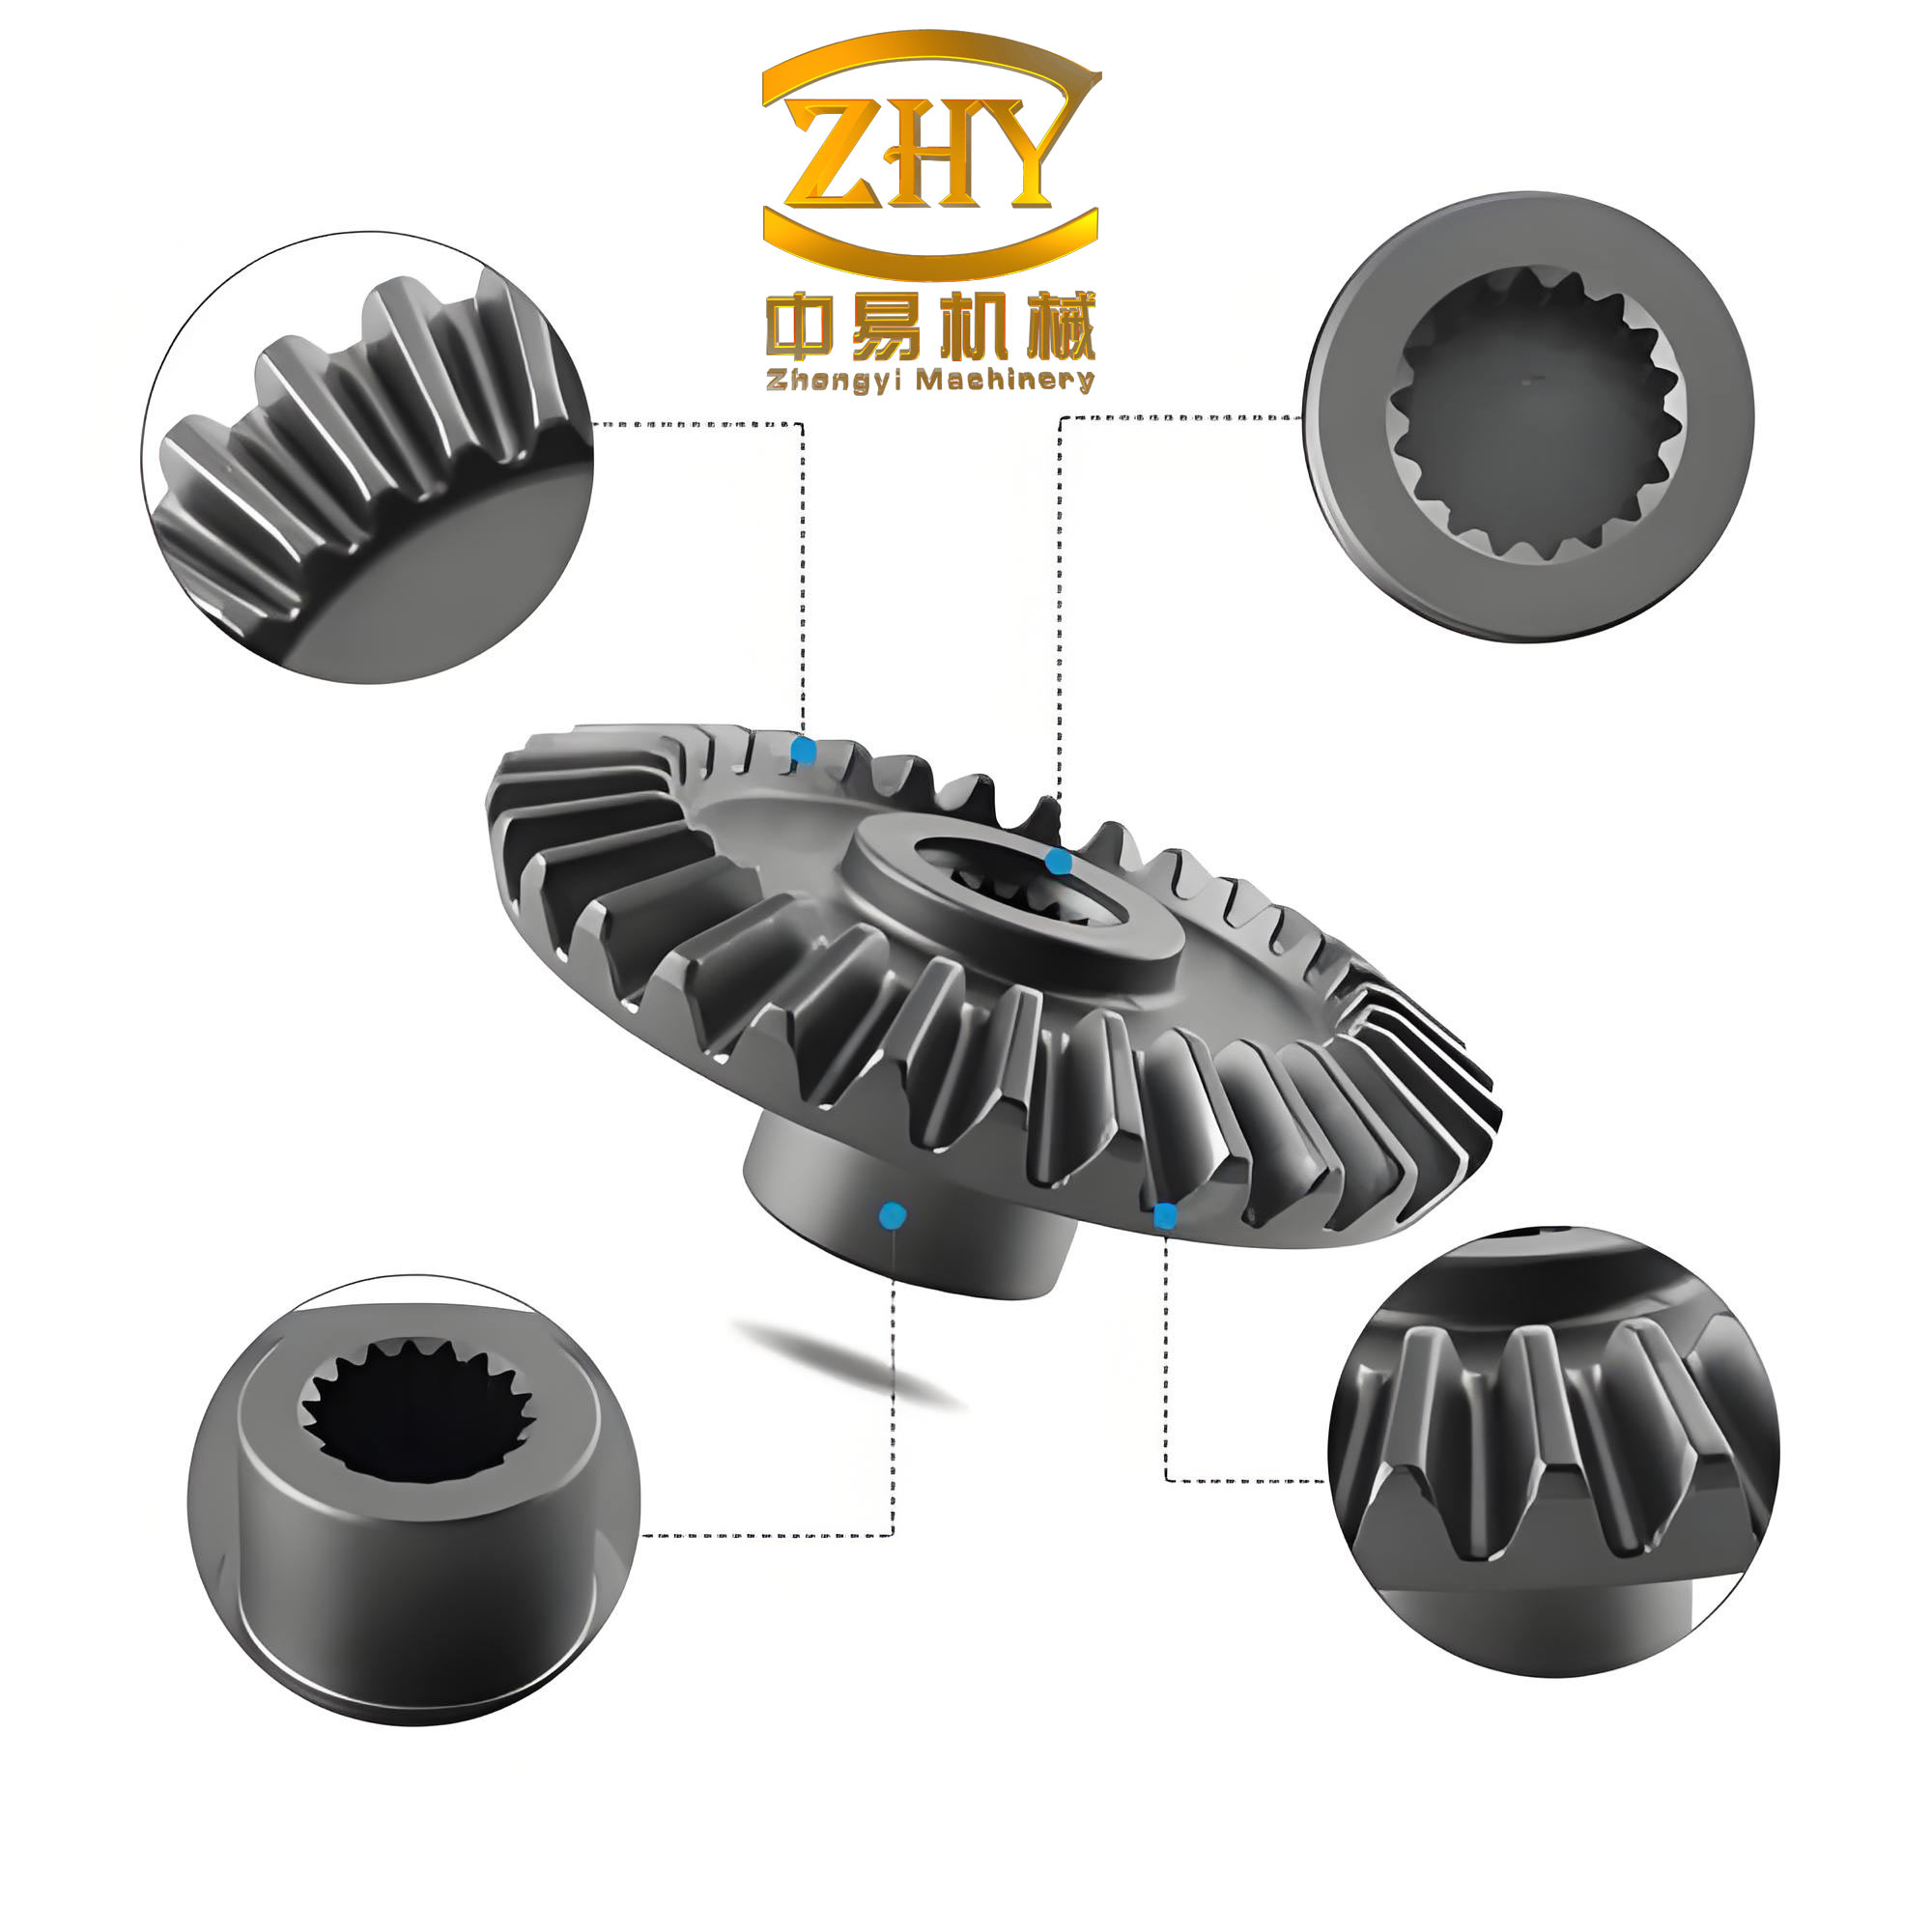
The component under investigation is a straight bevel gear, specifically a differential planetary gear for a passenger car. The gear geometry is defined by its parameters: number of teeth (z = 10), module (m = 3.2 mm), pressure angle (α = 20°), pitch cone angle (δ = 30.58°), and face width (b = 10.5 mm). The final forging requires a blank whose volume is determined based on the gear’s solid model. Using the 3D modeling software Pro/ENGINEER (Pro/E), the solid model of the straight bevel gear is created, and its volume is calculated. The preform volume is determined by applying a scaling factor to account for material waste, primarily scale formation and machining allowance. The initial blank volume is calculated as:
$$ V_{blank} = K \cdot V_{gear} $$
where \(K\) is an empirical coefficient, taken as 1.05 in this study, and \(V_{gear}\) is the gear volume. Three distinct preform shapes—cylindrical, conical, and drum-shaped—are designed, all with an identical volume to ensure a fair comparison.
3.2 Gear and Die Modeling in Pro/ENGINEER
The complex geometry of the straight bevel gear makes it challenging to create directly in the preprocessor of DEFORM-3D. Therefore, the gear and its corresponding dies are modeled in the general-purpose CAD software Pro/ENGINEER. The gear modeling process includes these steps:
| Step | Procedure | Output |
|---|---|---|
| 1 | Create a new part and establish the default datum planes and coordinate system. | Base features |
| 2 | Construct the initial solid geometry using the revolve feature, based on the gear’s back cone dimensions. | Blank cone body |
| 3 | Create the back cone surface and generate the involute tooth profile on this plane. Use the protrusion and cut features to form a single tooth space. | Single tooth gap |
| 4 | Pattern the tooth gap feature to create all ten teeth around the circumference. | Complete gear profile |
| 5 | Add fillets and chamfers to the tooth edges, including the root and tip radii, to finalize the gear model. | Finished 3D solid gear model |
For the dies, the manufacturing module in Pro/ENGINEER (Pro/MOLD) is employed. The lower die (concave die) is created by using the gear model as a reference, splitting it with a parting surface, and adding a shrinkage factor to account for the gear’s elastic recovery.
3.3 Assembly and Finite Element Model Setup
The key to a successful simulation is the precise relative positioning of the dies and the blank. To avoid the complexities of manual positioning in DEFORM-3D, the assembly is performed in Pro/ENGINEER. The upper die, lower die, and blank are first assembled in an assembly file, ensuring that their coordinate systems are perfectly aligned. The assembled model is then exported in the STL format for each component individually. When these STL files are imported into DEFORM-3D, their original relative positions are preserved.
The finite element model, as depicted in Figure 2, is established after importing the geometries. The preform is meshed with tetrahedral elements. To balance computational efficiency and accuracy, a relatively fine mesh is used, especially in regions expected to undergo significant deformation, such as the gear teeth. The upper die is modeled as a rigid body with a precessing angular velocity. Its motion is defined by two components: a rotation around its own symmetry axis (self-rotation) and a precession around the machine axis (revolution). The lower die is also a rigid body and is given a constant upward feed velocity. The material of the gear blank is selected from the DEFORM-3D material library, and its flow stress data at room temperature is used for the simulation.
| Simulation Parameter | Value |
|---|---|
| Upper die inclination angle (γ) | 2° |
| Spindle rotation speed | 1.0 rad/s |
| Lower die feed velocity | 1.0 mm/s |
| Friction factor (m) | 0.3 |
| Forming temperature | 20 °C (cold forging) |
| Penalty factor | 10⁹ |
The trajectory of a point on the upper die is crucial for the forming outcome. For this research, a spiral trajectory is selected because it produces a continuous radial force component that pushes the material outward, enhancing the filling of the gear teeth. This is shown in the comparative table of trajectories:
| Trajectory Type | Axial Force | Radial Force | Tangential Force | Deformation Trend |
|---|---|---|---|---|
| Circular | Yes | No | Yes | Predominantly upsetting and tangential flow |
| Multi-lobed rose | Yes | Variable | Yes | Upsetting, tangential, and variable radial flow |
| Spiral | Yes | Yes (outward) | Yes | Uniform upsetting, tangential flow, and favorable radial outward flow |
4. Numerical Simulation of Various Preform Shapes
4.1 Simulation Conditions and Parameters
To investigate the influence of preform geometry, numerical simulations are carried out for the three initial shapes: cylinder, cone, and drum. The simulation parameters are consistent across all three cases to ensure a valid comparison. The finite element model and simulation parameters were set as described in the previous section.
4.2 Result Analysis: Filling and Metal Flow
Upon completion of the rotary forging simulations, the final geometries of the forged parts are examined. As shown in Figure 4.1, the drum-shaped preform yields a fully filled gear with sharp, well-defined corners and no defects. In contrast, both the cylindrical and conical preforms result in incomplete filling, particularly in the middle section of the gear teeth, a defect commonly referred to as “insufficient filling” or “short shot”. The root cause of this defect can be understood by analyzing the velocity fields during the forming process.
Figure 4.2-4.4 illustrate the velocity distribution in the Y-direction (the feed direction) at various stages of the process. In the early stages, the deformation is largely an upsetting operation. The metal flows primarily in the axial direction, with the surface layers moving faster than the core. This initial phase is common to all three preform shapes. However, as the deformation progresses and the material begins to contact the die cavity walls, the differences become apparent.
For the straight bevel gear, the geometry requires the metal to flow both up and down to fill the tooth spaces. In the middle stage, the drum-shaped preform shows a more uniform distribution of the Y-direction velocity across the central region. Its outward-bulging geometry helps to engage the die cavity earlier and more evenly, promoting simultaneous filling from the tooth root to the tooth tip and from the large end to the small end. Conversely, for the cylindrical and conical preforms, the metal flow velocity is concentrated near the top and bottom of the blank. The material deforms and fills the tooth regions at the top and bottom initially, but the middle of the tooth remains under-filled. As the dies continue to move together, the material in this middle zone is “locked off” and cannot flow into the remaining cavity space, resulting in the observed defect.
4.3 Stress and Strain Distribution
The effective stress and strain distributions at different stages provide valuable insight into the deformation mechanics. The stress distribution during the rotary forging of the drum-shaped preform is shown in Figure 4.5. A characteristic feature of rotary forging is the presence of a localized deformation zone directly beneath the rocking die. This zone, called the active deformation zone, experiences high compressive stresses and undergoes most of the plastic deformation. The rest of the workpiece, the passive deformation zone, is subjected to lower stresses and elastically deforms, only to be plastically deformed when the rocking die returns in the next cycle. The effective stress distribution also reveals a high-stress region near the die contact area and the tooth roots, which is indicative of the intense local loading. This is crucial for predicting die wear and potential failure points.
4.4 Load-Stroke Curves
The forming load-stroke curves for the three preform shapes, shown in Figure 4.9, offer a macroscopic comparison of their formability. Although all curves show an increasing trend with a steeper rise near the end of the stroke, distinct differences exist. The load curve for the drum-shaped preform can be divided into three distinct stages:
- Free Upsetting Stage: A stage where the load increases relatively slowly and steadily as the drum-shaped blank is initially compressed.
- Die Filling Stage: A stage where the load increases more rapidly as the material fills the die cavity in the middle and the tooth profile is formed.
- Corner Filling Stage: A final stage where the load increases sharply as the remaining sharp corners of the die cavity are filled through high-pressure squeezing.
This three-stage behavior is attributed to the fact that the drum-shaped blank is shorter and has a larger contact area with the die from the beginning. The free upsetting stage is, therefore, short-lived. In contrast, the cylindrical and conical blanks undergo a prolonged free upsetting stage, during which the load grows slowly. The transition to the die-filling stage is gradual, making it difficult to distinguish between the two stages on their load curves. The prolonged upsetting stage leads to a more pronounced non-uniform deformation, which is the main cause of the “insufficient filling” defect. The maximum forming load is similar for all three cases, but the total energy consumption (area under the curve) and the final quality are different, favoring the drum-shaped preform. This simulation result confirms that the drum shape is a superior preform for rotary forging of straight bevel gears.
5. Optimization of the Drum-Shaped Preform
5.1 Parametric Modeling and Feasibility Analysis
Having established the superiority of the drum-shaped preform, the next step is to optimize its specific geometry. The drum shape is defined by three parameters: the top and bottom diameters (\(d\)), the height (\(h\)), and the bulge radius (\(R\)). To systematically study the effect of the drum degree, a dimensionless parameter \(b\) is introduced, defined as:
$$ b = \frac{d}{R} $$
This parameter effectively captures the “sharpness” of the bulge. A smaller value of \(b\) indicates a more pronounced bulging. By fixing the volume and the top and bottom diameters, the height and bulge radius are linked. The CAD software’s “Feasibility and Optimization” feature is leveraged to generate models with specific \(b\) values accurately. For instance, when the design constraint is a specific volume and diameter, the software iteratively adjusts the height and bulge radius to match the target \(b\). Six different drum preforms are generated with \(b\) values of 0.2, 0.4, 0.6, 0.8, 1.0 and 1.2.
5.2 Simulation Results for Different Drum Degrees
The six preform shapes are simulated under identical rotary forging conditions. As indicated by Figure 5.2, all six geometries are capable of completely filling the gear die cavity when sufficient stroke is applied. The main differences lie in the forming load and the stress inflicted on the die. The load-stroke curves for the various \(b\) values are shown in Figure 5.4. The analysis of these curves reveals a consistent trend:
- In the initial compression phase (stroke range of 0-8 mm), the required load is lower for larger \(b\) values. This is because a larger \(b\) corresponds to a more slender and taller preform, which requires less force to upset.
- In the primary filling phase (stroke range of 8-20 mm), the forming loads are nearly identical for all \(b\) values. This is the stage where the material is forced into the gear tooth cavity, and the required load is primarily determined by the die geometry and friction.
- In the final corner-filling phase (stroke range of 20-30 mm), the load increases sharply, and the load is higher for larger \(b\) values. A higher \(b\) value means the preform is taller, and it contacts the die cavity walls later in the process. At this point, the corners are not completely filled, and a high local pressure is necessary to force the material into the sharp die corners. A taller preform provides more material in this zone, which might seem beneficial. However, the contact analysis shows that a larger \(b\) value promotes earlier and more complete contact at the bottom of the gear, aiding the die filling.
5.3 Optimization Objectives and Curve Fitting
To determine the optimal \(b\) value, two conflicting objectives are considered:
- Minimizing Total Energy Consumption: The total energy consumed during forming, \(W\), is the integral of the load over the stroke. Lower energy consumption is desired for higher efficiency and lower production costs.
- Minimizing the Maximum Effective Stress on the Lower Die (\(\sigma_m\)): A lower stress on the die will increase its service life. Since die failure is a major concern in forging, minimizing \(\sigma_m\) is crucial.
These two objectives are extracted from the simulation results and are listed in Table 5.1.
| Drum degree (\(b\)) | Max. Effective Stress on Die (\(\sigma_m\) / MPa) | Max. Forming Load (kN) | Total Energy Consumption (\(W\) / kN·mm) |
|---|---|---|---|
| 0.2 | 1383.2 | 96.9 | 1430.5 |
| 0.4 | 1327.7 | 95.7 | 1354.3 |
| 0.6 | 1222.8 | 94.2 | 1275.7 |
| 0.8 | 1230.9 | 94.3 | 1291.6 |
| 1.0 | 1252.3 | 94.4 | 1300.3 |
| 1.2 | 1280.5 | 94.9 | 1378.8 |
Based on the data in Table 5.1, the relationship between the total energy consumption (\(W\)) and the drum degree (\(b\)) is plotted and fitted. The trend shows that \(W\) is high for small \(b\), decreases to a minimum as \(b\) increases, and then increases again. The fitted curve suggests a quadratic relationship. The functional relationship is derived as:
$$ W(b) = 352.14b^2 – 445.32b + 1402.05 $$
Similarly, the relationship between the maximum effective stress on the lower die (\(\sigma_m\)) and the drum degree (\(b\)) is also fitted with a quadratic function:
$$ \sigma_m(b) = 456.23b^2 – 612.78b + 1452.88 $$
These two fitted curves, as shown in Figure 5.6, have different minima points. The objective, therefore, is to find a compromise that balances the two. By plotting both curves on the same axes, the intersection of the two downward-opening parabolas, which represents a trade-off solution, can be found. The intersection point of the two curves is calculated to be at \(b \approx 0.68\). At this point, both the energy consumption and die stress are relatively low, and this \(b\) value is considered the optimal drum degree for this specific straight bevel gear application.
6. Conclusions and Future Perspectives
This research provides a comprehensive numerical analysis of the rotary forging process for a straight bevel gear, with a focus on preform optimization. The key conclusions derived from this work are summarized as follows:
- Finite Element Model: A robust three-dimensional finite element model for the rotary forging of a straight bevel gear was successfully established using DEFORM-3D. The model effectively captures the complex mechanics of the rocking die, reproducing the localized deformation pattern and the precessing contact area.
- Metal Flow and Filling: The metal flow behavior is characterized by an active deformation zone beneath the rocking die and a passive zone in the rest of the workpiece. The shape of the preform significantly affects the filling sequence. The drum-shaped preform facilitates the formation of a more uniform velocity field, promoting even and complete filling of the gear teeth. In contrast, cylindrical and conical preforms lead to premature closure at the top and bottom, trapping a defect in the middle of the tooth.
- Preform Shape Selection: The numerical simulations clearly indicate that the drum-shaped preform is superior to the cylindrical and conical shapes. It provides a more efficient, low-energy forming process and results in a defect-free gear with excellent corner filling.
- Optimal Preform Geometry: By introducing a dimensionless parameter \(b\) to quantify the drum degree, a systematic optimization was performed. The objective functions of total forming energy and maximum die effective stress were considered. After curve fitting and multi-objective trade-off analysis, the optimal drum degree was identified as \(b \approx 0.68\). This preform geometry minimizes the total energy consumption while maintaining the die stress at a relatively low level, thereby contributing to both process efficiency and die longevity.
The findings of this thesis offer valuable theoretical and practical guidance for the design and manufacturing of straight bevel gears via rotary forging. For future research, the following directions are recommended:
- The current rigid-plastic model assumes isothermal conditions. Future work could integrate thermal effects to simulate warm or hot rotary forging, providing a more accurate representation of the process.
- To further enhance the accuracy of the simulation and die life prediction, the analysis of the dies as deformable bodies under cyclic loading conditions should be extended.
- The optimized preform shape should be validated experimentally. Physical trials should be conducted to confirm the simulation results and to assess the real-world impact on process repeatability and product quality.