
In my extensive research into power transmission systems, the quest for higher efficiency in screw gear drives remains a persistent and critical engineering challenge. As a mechanism that transfers motion and power between non-intersecting, non-parallel shafts, the conventional screw gear offers undeniable advantages: remarkable speed reduction ratios, compact design, and smooth, quiet operation. These qualities make it indispensable in applications ranging from precision machine tools and instrumentation to heavy-duty lifting equipment and automotive steering systems. However, its Achilles’ heel has always been its relatively low transmission efficiency, primarily attributed to significant sliding friction losses at the meshing interface between the worm and the gear teeth. This inherent limitation not only wastes energy but also generates heat, leading to thermal management issues and potential lubricant breakdown, thereby restricting the screw gear’s application in high-power or continuous-duty scenarios.
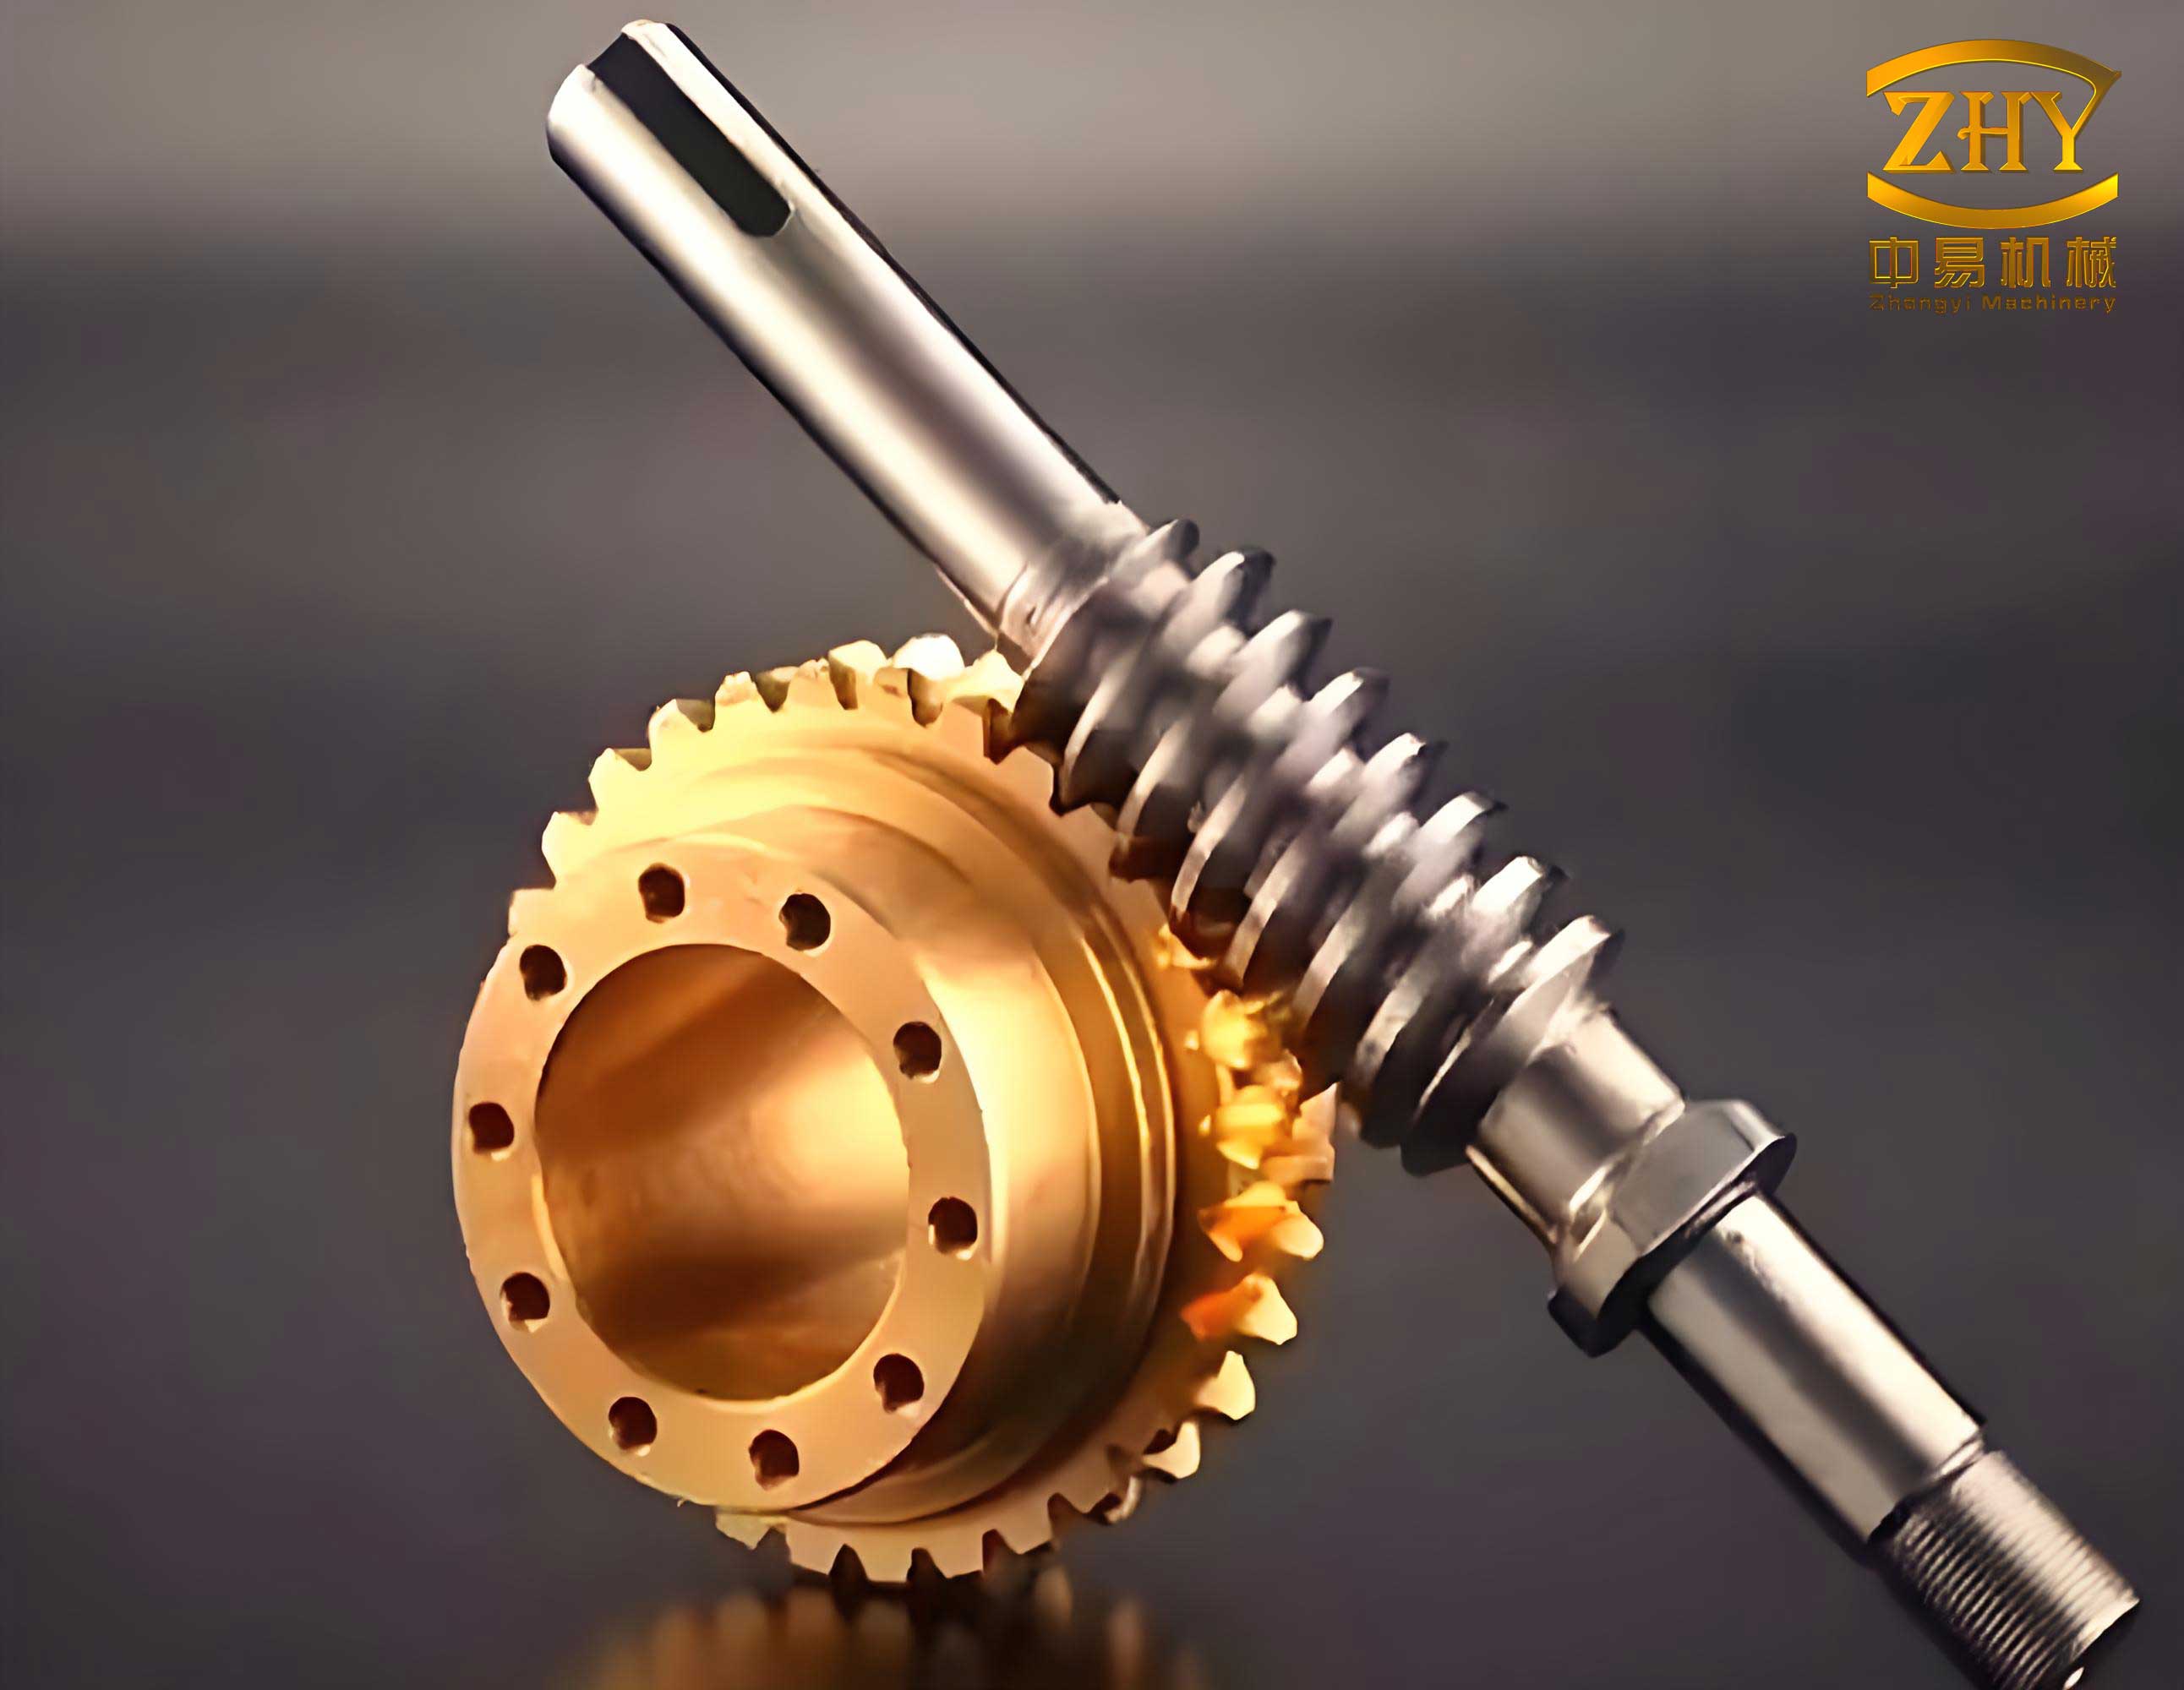
To overcome this fundamental drawback, my work has focused on innovative screw gear architectures that fundamentally alter the nature of the contact. The most promising direction involves replacing the traditional static gear teeth with active, rotating elements. This paradigm shift transforms the dominant sliding friction into rolling friction, promising a substantial leap in performance. One such advanced configuration is the single-roller enveloping end-face screw gear drive. In this design, the worm thread is generated by enveloping a cylindrical roller, which itself serves as the gear “tooth.” These rollers are mounted radially on the gear body and are free to rotate about their own axes. This ingenious arrangement means that as the screw gear rotates, it engages with these rollers, causing them to turn. The primary relative motion at the contact point is thus converted from sliding to rolling, dramatically reducing frictional losses and paving the way for a highly efficient screw gear system.
My investigation into this specific screw gear type aims to build a comprehensive mathematical model to quantify its transmission efficiency. This model must account for the complex spatial kinematics, the unique contact conditions, and the hybrid friction state involving both rolling and residual sliding. Establishing such a model is the first step toward understanding the key design parameters that govern the screw gear’s performance and ultimately optimizing it for maximum efficiency. The analysis begins with a detailed examination of the forces at a single instantaneous contact point between the screw gear flank and the roller surface.
Mathematical Modeling of Contact Mechanics
At any given moment during the engagement of the screw gear drive, complex forces interact at the contact point p. Let us consider the forces acting on the screw gear tooth surface and the roller surface separately. At point p, the forces on the screw gear are: the normal force $F_{n1}$, the tangential force $F_{t1}$, and the axial force $F_{a1}$. Similarly, on the roller, the forces are the normal force $F_{n2}$, the tangential force $F_{t2}$, and the axial force $F_{a2}$. According to the fundamental principles of meshing theory for screw gears, the relative velocity vector $v_{12}$ at the contact point has no component in the direction of the common normal to both surfaces. Consequently, the frictional forces, which arise from relative motion or its tendency, also have no component along this common normal. Therefore, friction acts solely within the common tangent plane. This is the critical insight: the tangential force $F_{t2}$ applied to the roller causes it to spin around its own axis, effectively converting what would be sliding in a conventional screw gear into rolling in this innovative design.
The forces influencing the efficiency of this screw gear drive, considering both sliding and rolling friction, are the normal force, the axial force, and a portion of the tangential force related to rolling friction. For the roller, the resultant force $F_2$ is:
$$F_2 = F_{n2} + F_{a2} + f_g F_{t2}$$
where $f_g$ is the ratio of rolling friction coefficient to sliding friction coefficient. By Newton’s third law and equilibrium, the resultant force on the screw gear is equal and opposite:
$$F_1 = F_{n1} + F_{a1} + f_g F_{t1} = -F_2$$
If we denote the sliding friction coefficient as $f$, the magnitudes of the sliding friction forces on the screw gear and roller are:
$$F_{f1} = f F_{n1}, \quad F_{f2} = f F_{n2}$$
These friction forces are oriented opposite to and along the direction of relative motion $v_{12}$, respectively. Their components can be expressed as:
$$F_{t1} = F_{f1} \cos\alpha_1, \quad F_{a1} = F_{f1} \sin\alpha_1$$
$$F_{t2} = F_{f2} \cos\alpha_2, \quad F_{a2} = F_{f2} \sin\alpha_2$$
The angles $\alpha_1$ and $\alpha_2$ between the tangential and friction force vectors are equal ($\alpha_1 = \alpha_2 = \alpha$) and are determined by the kinematics of the screw gear mesh:
$$\alpha = \arctan\left(\frac{V_2}{V_1}\right)$$
where $V_1$ and $V_2$ are components of the relative velocity, dependent on screw gear geometry parameters:
$$V_1 = A\sin\theta + R\sin\phi_2 + (u – a_2)(i_{21}\cos\theta + \cos\phi_2\sin\theta)$$
$$V_2 = R\cos\theta\cos\phi_2 – i_{21}R\sin\theta$$
In these equations, $A$ is the center distance, $R$ is the roller radius, $i_{21}$ is the gear ratio, $\phi_2$ is the rotation angle of the gear, $\theta$ and $u$ are roller surface parameters, and $a_2$ is an intermediate variable related to the throat form factor $k$ and the number of gear teeth $z_2$, defined as $a_2 = A(2-k)(8-5z_2)/(10z_2)$. This analysis clearly shows that the frictional behavior, and hence the efficiency of this screw gear, is governed by parameters including the sliding friction coefficient $f$, the throat form factor $k$, the roller radius $R$, the number of gear teeth $z_2$, and the center distance $A$.
Transmission Efficiency Calculation Model
To derive the transmission efficiency, we must analyze the power flow. In the moving coordinate system attached to the screw gear assembly, let $v_1$ and $v_2$ be the velocity vectors of the screw gear and roller contact points, respectively. The input power from the screw gear ($P_w$) and the output power to the roller/gear body ($P_g$) are given by the dot products of the resultant forces and their respective velocities:
$$P_w = F_1 \cdot v_1, \quad P_g = F_2 \cdot v_2$$
Therefore, the instantaneous transmission efficiency $\eta$ of the screw gear drive at contact point p is:
$$\eta = \frac{P_g}{P_w}$$
Substituting the expressions for the forces yields the complete equation for the instantaneous efficiency of this screw gear configuration:
$$\eta = \frac{(-e_n \pm f \sin\alpha_2 e_2 \pm f_g f \cos\alpha_2 e_1) \cdot v_2}{(e_n \mp f \sin\alpha_1 e_2 \mp f_g f \cos\alpha_1 e_1) \cdot v_1}$$
where $e_1$, $e_2$, and $e_n$ are the basis vectors of the coordinate system on the roller.
Since contact occurs along a line, the single-tooth instantaneous efficiency $\eta_u$ is the average of $\eta$ along the instantaneous contact line over its total length $h$ (the full depth of engagement):
$$\eta_u = \frac{1}{h} \int_0^h \eta \, du$$
The total tooth depth $h$ is the sum of addendum and dedendum: $h = h_a + h_f$, where $h_f = h_{fc} m$ (with $h_{fc}$ being the dedendum coefficient and $m$ the module).
The single-tooth average efficiency $\eta_p$ is then found by averaging $\eta_u$ over the entire engagement cycle of that tooth, i.e., over the gear rotation angle $\phi_2$ from its start ($\phi_{20}$) to end ($\phi_{2e}$) of contact:
$$\eta_p = \frac{1}{\phi_{2e} – \phi_{20}} \int_{\phi_{20}}^{\phi_{2e}} \eta_u \, d\phi_2$$
Critically, in a screw gear drive, multiple teeth are in contact simultaneously to ensure smooth power transmission. Assuming $n$ teeth are in contact at the same time, the combined instantaneous efficiency $\eta_{un}$ and the overall average transmission efficiency $\eta_{pn}$ for the screw gear drive are calculated as follows:
$$\eta_{un} = \frac{1}{n h} \sum_{i=1}^{n} \int_0^h \eta_i \, du$$
$$\eta_{pn} = \frac{1}{n} \sum_{i=1}^{n} \left[ \frac{1}{\phi_{2ei} – \phi_{20i}} \int_{\phi_{20i}}^{\phi_{2ei}} \eta_{ui} \, d\phi_2 \right]$$
The start and end angles for the i-th tooth are phase-shifted by the angular pitch $\gamma = 360^\circ / z_2$:
$$\phi_{20i} = \phi_{201} + (i-1)\gamma, \quad \phi_{2ei} = \phi_{201} + i\gamma$$
where $\phi_{201}$ is the start angle for the first tooth in the simultaneous contact zone, typically set for symmetric engagement, for example, $\phi_{201} = -90^\circ – n\gamma/2$.
Analysis of Screw Gear Efficiency
To understand the performance characteristics of this screw gear drive, I performed a parametric analysis using the derived model. The base parameters for the single-roller enveloping end-face screw gear are listed in the table below. The analysis employs a single-variable method, where one parameter is varied while others are held constant at their base values.
| Parameter | Symbol | Base Value |
|---|---|---|
| Center Distance | $A$ | 160 mm |
| Number of Screw Gear Threads | $z_1$ | 1 |
| Number of Gear Teeth | $z_2$ | 24 |
| Simultaneous Contact Teeth | $n$ | 4 |
| Throat Form Factor | $k$ | 0.4 |
| Roller Radius | $R$ | 10 mm |
| Screw Gear Angular Speed | $\omega_1$ | 1 rad/s |
| Sliding Friction Coefficient | $f$ | 0.15 |
| Rolling/Sliding Friction Ratio | $f_g$ | 0.2 |
The multi-tooth engagement is modeled as a continuous process where a set of $n$ rollers (e.g., positions 1-4) are considered a single contact group. As the screw gear rotates, this group advances, simulating the periodic engagement of the screw gear drive. For $n=4$ and $z_2=24$, the angular pitch $\gamma$ is $15^\circ$, and the analysis covers one engagement cycle within $\phi_2 \in [-105^\circ, -90^\circ]$. The efficiency calculated over this cycle represents the drive’s operational performance.
1. Influence of Gear Rotation Angle
The curve of average instantaneous efficiency $\eta_{un}$ versus gear angle $\phi_2$ is nearly linear. The instantaneous efficiency of the screw gear consistently increases from the point of tooth engagement to disengagement. For instance, when the sliding friction coefficient $f$ is increased from 0.05 to 0.20, the efficiency rise from engagement to disengagement grows from 4.65% to 11.27%. This indicates that a higher sliding friction coefficient amplifies the variation in efficiency throughout the meshing cycle. Furthermore, at any fixed $\phi_2$, a higher friction coefficient $f$ directly results in a lower instantaneous screw gear efficiency.
2. Influence of Key Design Parameters
The following analysis examines how the overall average transmission efficiency $\eta_{pn}$ of the screw gear is affected by its main design parameters. The trends are summarized comprehensively in the table below.
| Parameter | Effect on Average Efficiency | Magnitude of Influence | Typical Impact (Example) |
|---|---|---|---|
| Friction Coefficient (f) | Strong Negative Correlation | Highest | Reduction of ~31.7% as f increases from 0.05 to 0.20 |
| Number of Gear Teeth (z₂) | Negative Correlation | High | Reduction of ~2.33% per additional tooth (at f=0.20) |
| Throat Form Factor (k) | Negative Correlation | Medium | Reduction of ~7.07% as k increases from 0.30 to 0.50 (at f=0.20) |
| Roller Radius (R) | Weak Negative Correlation | Low | Reduction of ~1.66% as R increases from 5mm to 10mm (at f=0.20) |
| Center Distance (A) | Weak Positive Correlation | Lowest | Increase of ~0.67% as A increases from 160mm to 200mm (at f=0.20) |
Detailed Observations:
- Sliding Friction Coefficient ($f$): This is the most dominant factor affecting screw gear efficiency. The average efficiency drops sharply from approximately 75.29% to 43.59% as $f$ increases from 0.05 to 0.20. This underscores the paramount importance of using low-friction material pairings and effective lubrication in the design of any high-efficiency screw gear.
- Number of Gear Teeth ($z_2$): Increasing the number of teeth on the screw gear’s mating wheel consistently reduces the average efficiency. The impact becomes more pronounced at higher friction levels. This presents a design trade-off, as more teeth can improve load sharing and smoothness but at the cost of efficiency.
- Throat Form Factor ($k$): A larger $k$ value, which influences the curvature and size of the screw gear’s throat, leads to lower efficiency. The negative effect is stronger when the sliding friction is high.
- Roller Radius ($R$): While a larger roller radius slightly diminishes efficiency, the effect is relatively minor. The influence is marginally greater in high-friction conditions.
- Center Distance ($A$): Interestingly, a larger center distance offers a slight improvement in the screw gear’s efficiency. The benefit is more noticeable when the friction coefficient is lower, suggesting that for high-efficiency designs, a more generous center distance can be beneficial.
In summary, to achieve high transmission efficiency in a single-roller enveloping end-face screw gear drive, the design should aim for a low sliding friction coefficient, a lower number of gear teeth (while meeting the required gear ratio), a smaller throat form factor, a moderately sized roller, and a potentially larger center distance, with the friction coefficient being the most critical parameter to control.
Simulation and Optimization of the Screw Gear
To move from parametric analysis to optimal design, I formulated an optimization problem with the goal of maximizing the screw gear’s average transmission efficiency $\eta_{pn}$. The objective function and constraints are defined as follows.
The objective is to maximize $\eta_{pn}$, which is a function of the key design variables:
$$\eta_{pn} = g(k, R, z_2, A, h_{fa}, h_{fc}, n)$$
where $h_{fa}$ and $h_{fc}$ are the addendum and dedendum coefficients, respectively. For use with standard minimization algorithms, the problem is formulated as minimizing the reciprocal of efficiency:
$$\text{min } f(X) = \frac{1}{g(X)}, \quad \text{where } X = [k, R, z_2, A, h_{fa}, h_{fc}, n]$$
Several geometric and operational constraints must be satisfied to ensure a viable screw gear design:
- Tooth Strength and Avoidance of Undercutting: The tooth form must not become pointed. This is ensured by constraints on the parameters that govern the tooth thickness at critical sections.
- Parameter Bounds: Each variable is confined to a practical range based on engineering judgment and typical screw gear design standards:
$$f \in [0.05, 0.20], \quad k \in [0.30, 0.50], \quad R \in [5, 10] \text{ mm}, \quad z_2 \in [20, 30], \quad A \in [160, 200] \text{ mm}, \quad h_{fa} \in [0.8, 1.0], \quad h_{fc} \in [0.8, 1.0], \quad n \in \mathbb{Z}, n \in [3, 5]$$
Using the base parameters from the analysis table, the calculated average efficiency $\eta_{pn}$ was approximately 83.2%, which is already notably higher than that of many conventional screw gear drives. I employed MATLAB’s optimization toolbox to solve this constrained nonlinear problem. Two methods were used: the built-in constrained minimization function `fmincon` and a genetic algorithm (GA) from the global optimization toolbox. The optimization was run for different fixed values of simultaneous contact teeth ($n=3,4,5$). The results are presented below.
| Parameter | Optimized Values via `fmincon` | Optimized Values via Genetic Algorithm | ||||
|---|---|---|---|---|---|---|
| n=3 | n=4 | n=5 | n=3 | n=4 | n=5 | |
| $k$ | 0.3635 | 0.3615 | 0.3623 | 0.3613 | 0.3618 | 0.3604 |
| $R$ (mm) | 8.1917 | 8.1919 | 8.1922 | 8.1914 | 8.1921 | 8.1919 |
| $z_2$ | 23.36 | 23.53 | 23.60 | 23.35 | 23.42 | 23.52 |
| $A$ (mm) | 179.63 | 179.70 | 179.75 | 179.61 | 179.68 | 179.72 |
| $h_{fa}$ | 0.9180 | 0.9184 | 0.9190 | 0.9178 | 0.9187 | 0.9184 |
| $h_{fc}$ | 0.9068 | 0.9073 | 0.9067 | 0.9065 | 0.9068 | 0.9073 |
| $\eta_{pn}$ (%) | 84.81 | 86.44 | 85.45 | 84.78 | 86.42 | 85.26 |
The optimization results from both methods are remarkably consistent, validating the robustness of the solution. The highest screw gear efficiency of 86.44% is achieved with $n=4$ contact teeth. Interpreting and rounding the optimal parameters for this case provides a practical design guideline: $k \approx 0.36$, $R \approx 8.2 \text{ mm}$, $z_2 \approx 24$, $A \approx 180 \text{ mm}$, $h_{fa} \approx 0.92$, $h_{fc} \approx 0.91$. This optimized configuration yields a 3.2% absolute improvement in transmission efficiency compared to the initial base design, a significant gain in the context of screw gear performance.
Conclusions
My comprehensive modeling and analysis of the single-roller enveloping end-face screw gear drive have yielded clear insights into its efficiency characteristics. The mathematical model successfully captures the complex interplay between geometry, kinematics, and friction in this advanced screw gear system. The parametric study reveals that the average transmission efficiency is negatively correlated with the sliding friction coefficient, throat form factor, roller radius, and number of gear teeth, while it is positively correlated with the center distance. Among all factors, the sliding friction coefficient exerts the most profound influence on the screw gear’s efficiency, highlighting the critical role of material selection and lubrication. Among the geometric parameters, the number of gear teeth has the strongest effect, followed by the throat form factor, with the center distance having the least impact. The optimization process demonstrates that systematic tuning of these parameters can enhance the screw gear’s efficiency. The consistent results from gradient-based and genetic algorithm methods confirm an optimal parameter set that boosts efficiency by over 3 percentage points. This work provides a solid foundation for designing high-efficiency screw gear drives. Future work will involve experimental validation of these models, investigation of dynamic loads and thermal effects, and exploration of multi-objective optimization including durability and load capacity to further advance the performance envelope of this promising screw gear technology.