
In the realm of mechanical power transmission between non-parallel, non-intersecting shafts, screw gears, more formally known as worm drives, hold a distinguished position. A screw gear set fundamentally consists of a worm—a screw-like gear—and a meshing worm wheel. This unique configuration facilitates motion and power transfer, predominantly serving as a speed reducer. While less common, the reversal of this role, where the worm wheel drives the worm for speed increase, is utilized in specific machinery like centrifuges. The application of screw gears spans a vast array of industrial equipment, machine tools, and instrumentation due to their singular characteristics.
Fundamental Characteristics of Screw Gears
When juxtaposed with conventional gear systems, screw gears exhibit several distinctive and often advantageous features:
- High Reduction Ratio and Compact Design: The most prominent feature is the ability to achieve very high single-stage reduction ratios. In standard power transmission, ratios (i) from 10:1 to 80:1 are typical. For applications primarily concerned with motion transfer (non-power), this ratio can soar to 1000:1 or more, all within a remarkably compact spatial envelope.
- Smooth and Quiet Operation: The engagement between the worm and the worm wheel teeth is a continuous, sliding action. This, combined with line contact at the meshing point, results in exceptionally smooth and quiet operation compared to the discrete impact of spur or helical gear teeth.
- Irreversibility and Self-Locking Potential: A critical property arises when the lead angle (λ) of the worm is smaller than the equivalent friction angle (ρv) of the material pair. Under this condition, the drive becomes self-locking or irreversible. This means motion can only be transmitted from the worm to the worm wheel, not vice versa. This inherent braking feature is indispensable in hoists, lifting equipment, and systems where positional holding is paramount.
- Lower Efficiency: The primary trade-off for the above benefits is efficiency. The significant relative sliding motion at the tooth interface generates considerable friction, leading to higher power losses in the form of heat. Typical efficiencies range from 70% to 82% for non-self-locking multi-start worms. For self-locking single-start screw gears, efficiency can plummet below 50%. Consequently, they are primarily deployed for medium-to-low power applications.
- Higher Material Cost: To mitigate the high friction and wear, and to prevent scoring or seizure (galling), the worm wheel is often manufactured from expensive bronze or phosphor bronze alloys. While the worm is typically hardened steel, this necessity for a costly wheel material increases the overall drive cost.
Classification and Construction of Screw Gears
Types of Screw Gears
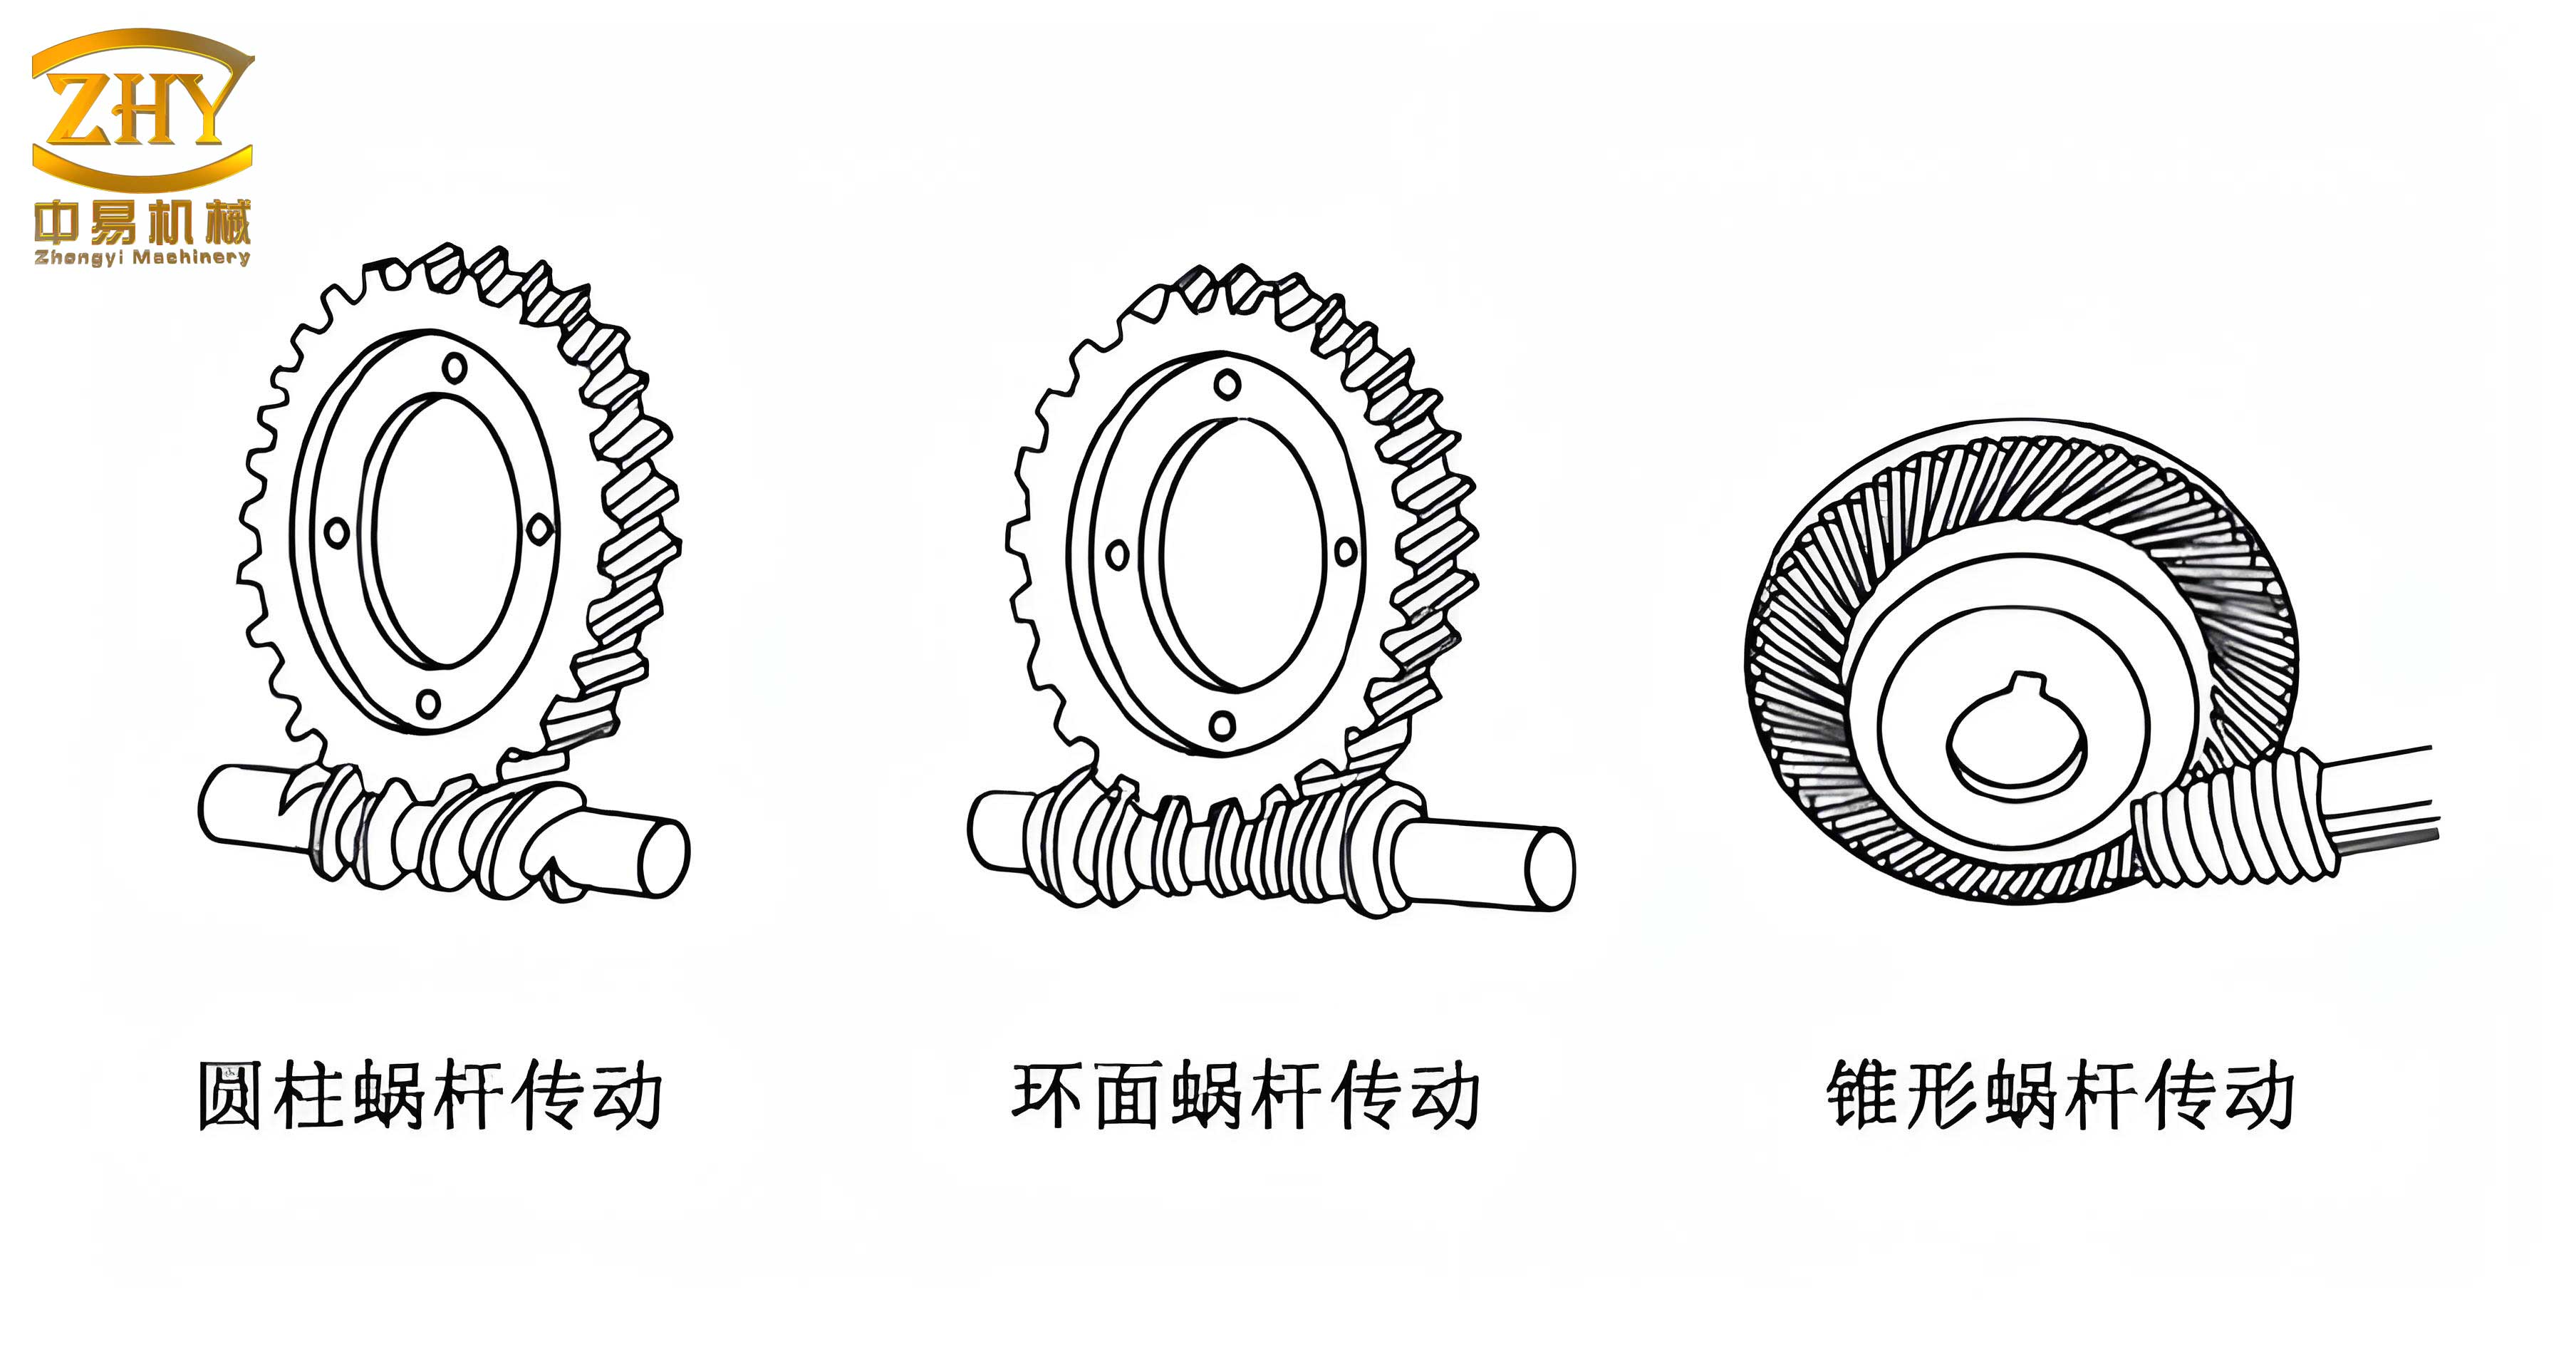
Screw gears can be classified beyond the number of worm threads (starts) and their hand (left or right). The most significant classification is based on the geometrical form of the worm itself.
| Main Category | Sub-types / Common Names | Key Features & Profile Generation | Typical Applications & Notes |
|---|---|---|---|
| Cylindrical Worm Drives | 1. Straight (Parallel) Sided: e.g., ZA (Archimedean), ZN (Normal Straight) | Worm profile is a straight line in a specified plane (axial, normal). Simple to manufacture and inspect. The ZA type has a straight-sided axial profile like a rack. | Widely used in general industrial applications where extreme performance is not critical. Prone to lower load capacity and efficiency compared to other types. |
| 2. Involute Helicoid: ZI (Involute) | The worm’s axial profile is an involute curve. Can be precisely ground, allowing for high precision and load capacity. | Used in high-performance, high-speed applications where precision and durability are required. | |
| Double-Enveloping Worm Drives (Hourglass or Cone Drives) | e.g., Hindley, Cone Double-Enveloping | Both the worm and the wheel envelop each other. This results in a much larger area of contact and multiple tooth engagement simultaneously. | Offers significantly higher load capacity (2-4x) and better efficiency (85%-92%) than cylindrical types. Demands very high manufacturing and alignment precision. |
| Single-Enveloping Worm Drives | e.g., Throated (Concave) Worm Drives | The worm wheel teeth are throated to partially wrap around the cylindrical worm, increasing contact area. | An improvement over standard cylindrical types, offering better load sharing and slightly higher capacity. |
| Circular Arc (Hollow) Worm Drives | e.g., Toroidal, Hourglass with circular arc profile | The worm thread has a circular arc profile in the axial section, meshing with a convex wheel tooth. Minimizes contact stress. | Provides high load capacity (50%-100% higher than ZA) and excellent efficiency (over 90%). Sensitive to center distance errors. |
Structural Design of Screw Gear Components
The worm is most frequently integrated with its shaft, forming a single piece known as a worm shaft. This component is typically manufactured from carbon or alloy steels (e.g., 20MnCr5, 16MnCr5, case-hardening steels) and is subsequently heat-treated (case-hardened, tempered) and often ground or polished to achieve high surface hardness and finish. For high-volume production, worms may also be milled or rolled.
The construction of the worm wheel varies with size and required performance. Small-diameter wheels or those made from cast iron are often manufactured as solid, one-piece components. However, to conserve the costly bronze material, larger worm wheels are universally constructed as composite assemblies. A bronze ring (the gear blank) forms the toothed portion and is securely attached to a central hub made of cast iron or steel. The attachment methods include:
- Interference Fit (Shrink Fit): The bronze ring is heated and shrunk onto the pre-machined hub. Reliable and simple but non-serviceable.
- Bolted Flange Connection: The bronze rim is bolted to the hub’s flange. This allows for replacement of the worn rim without discarding the hub.
- Bonded (Cast-in-Place): The bronze is centrifugally cast directly onto the machined hub, creating a strong metallurgical bond.
Efficiency Analysis of Screw Gears
The overall efficiency (η) of a screw gear drive is the product of three individual loss components:
$$ \eta = \eta_m \cdot \eta_b \cdot \eta_s $$
Where:
ηm = Meshing (or tooth engagement) efficiency
ηb = Bearing efficiency (losses in supporting bearings)
ηs = Churning or windage efficiency (losses from agitating oil/air)
The bearing and churning efficiencies are relatively high, typically in the range of ηbηs ≈ 0.95–0.96. Therefore, the dominant factor is the meshing efficiency ηm, which is governed by the sliding friction at the worm-worm wheel interface.
When the worm is the driving member, the meshing efficiency can be approximated using the formula for a power screw:
$$ \eta_m = \frac{\tan \lambda}{\tan (\lambda + \rho_v)} $$
Where:
λ = Lead angle of the worm thread at the reference/pitch diameter.
ρv = Equivalent (virtual) friction angle, defined as ρv = arctan(μv), where μv is the coefficient of friction.
The equivalent friction angle ρv is not constant; it decreases with increasing sliding velocity (vs). This is because higher sliding speeds promote the formation of a more effective elastohydrodynamic lubricant (EHL) film between the teeth, thereby reducing the friction coefficient. The relationship is often empirically determined.
The lead angle λ is the most influential design parameter on efficiency. Within practical limits, ηm increases with λ. This is why multi-start worms (which have a larger λ for a given center distance) are employed for power transmission where efficiency is a priority. However, manufacturability constraints and diminishing returns limit practical lead angles to about λ ≤ 27°.
The condition for self-locking is λ ≤ ρv. When this inequality holds, the drive cannot be back-driven, but the efficiency is necessarily less than 50% (specifically, ηm < 0.5 when λ = ρv).
For preliminary design before detailed dimensions are known, the total efficiency of enclosed screw gears can be estimated based on the number of worm starts (z1):
| Number of Worm Starts (z1) | Total Efficiency (η) |
|---|---|
| 1 (Single-start) | 0.70 – 0.75 |
| 2 (Double-start) | 0.75 – 0.82 |
| 4 (Quadruple-start) | 0.82 – 0.92 |
Lubrication of Screw Gears
Given the high sliding velocities and associated frictional losses, effective lubrication is not merely beneficial but critical for the longevity and reliable performance of screw gears. The primary objectives are to minimize wear, reduce friction, dissipate heat, and prevent scuffing or adhesive wear (galling).
Screw gears typically require lubricants with higher viscosity and extreme pressure (EP) additives compared to gearboxes using only spur or helical gears. The EP additives form a protective tribofilm on the metal surfaces, preventing direct contact under high load.
The selection of lubricant viscosity grade (ISO VG) and the lubrication method are primarily dictated by the sliding speed (vs) and the transmitted load.
| Sliding Speed (vs) | Lubrication Method | Lubricant Type / Viscosity | Application Notes |
|---|---|---|---|
| vs < 2 m/s | Dip (Bath) Lubrication | High-viscosity mineral oil with EP additives (e.g., ISO VG 460-680). | For slow-speed, high-torque applications. Ensure proper oil level. |
| 2 m/s < vs < 10 m/s | Dip (Bath) or Forced Circulation | Medium to high-viscosity EP gear oil (e.g., ISO VG 150-460). | Most common range. Jet lubrication may be used for high-power units. |
| vs > 10 m/s | Forced Circulation / Jet Lubrication | Lower viscosity EP gear oil (e.g., ISO VG 68-150). | High-speed drives. Oil is pumped, filtered, cooled, and sprayed into the mesh. |
| All speeds (Open Gearing) | Manual Application / Grease | High-viscosity adhesive gear oil or EP grease. | For exposed screw gears. Requires frequent re-application. |
For dip lubrication in a horizontal configuration with the worm below the wheel, the oil level should be high enough to immerse the worm up to one full tooth height, but not so high as to cause excessive churning or oil leakage past seals. For configurations with the worm above the wheel (often used when vs > 5 m/s to reduce churning loss), the oil level should reach approximately one-third of the wheel’s radius.
Thermal Balance and Heat Dissipation
The relatively low efficiency of screw gears means a significant portion of input power is converted into heat within the gearbox housing. If this heat is not adequately dissipated, the oil temperature will rise, leading to a reduction in lubricant viscosity, accelerated oxidation (oil breakdown), loss of the EP film, and ultimately, catastrophic failure via seizure.
Therefore, a thermal equilibrium calculation is essential during the design phase. The condition for equilibrium is that the heat generated (Qgen) equals the heat dissipated (Qdiss) to the surroundings.
1. Heat Generation: The power loss in the drive is Ploss = Pin(1 – η). Therefore, the heat generation rate is:
$$ Q_{gen} = P_{in} (1 – \eta) \times 1000 \quad \text{[W]} $$
where Pin is the input power in kW.
2. Natural Heat Dissipation: For a gearbox naturally cooled by convection and radiation from its external surfaces, the dissipation rate is:
$$ Q_{diss} = k_s A (t_o – t_a) \quad \text{[W]} $$
Where:
ks = Combined heat transfer coefficient [W/(m²·K)]. Typically ks ≈ 12–18 W/(m²·K) for still air, and up to 20–25 W/(m²·K) with good airflow over the housing.
A = Effective heat dissipation area of the housing [m²]. This includes the external surface area in contact with air, often augmented by cooling fins. The internal surface area wetted by oil is not included.
to = Oil sump temperature [°C].
ta = Ambient air temperature [°C].
3. Thermal Equilibrium Temperature: Setting Qgen = Qdiss and solving for the equilibrium oil temperature yields:
$$ t_o = t_a + \frac{P_{in} (1 – \eta) \times 1000}{k_s A} $$
The calculated to must be less than the maximum allowable temperature for the lubricant and sealing materials. For mineral oils, a safe continuous operating temperature is typically to, max ≈ 80–90°C (176–194°F).
If the calculated to exceeds the allowable limit, the following measures can be implemented to enhance cooling:
- Increase Surface Area (A): Add external cooling fins to the gearbox housing.
- Forced Air Cooling: Mount an electric fan on the worm shaft (or separately) to blow air over the finned housing.
- Internal Cooling Coil: Install a serpentine pipe (cooling coil) inside the oil sump through which cooling water is circulated.
- External Oil Cooler: Implement a forced oil circulation system with an external heat exchanger (air-cooled or water-cooled radiator).
Installation, Alignment, and Maintenance
The performance and life of screw gears are highly sensitive to proper installation and alignment. The fundamental requirement is that the central plane of the worm wheel must contain the axis of the worm. Misalignment drastically increases wear, noise, and the risk of premature failure.
Installation Procedure:
- Mount the worm shaft assembly securely, ensuring proper bearing preload and axial location.
- Mount the worm wheel assembly onto its shaft. The axial position of the wheel is critical and must be adjustable.
- Adjust the wheel’s axial position (e.g., using shim packs or an adjustable threaded sleeve between the wheel hub and bearing) until the wheel’s central plane is aligned with the worm axis. Alignment is typically verified using dial indicators or precision feeler gauges in the tooth mesh backlash.
- Once perfect alignment is achieved, the worm wheel’s axial position must be definitively locked using locking nuts, set screws, or similar positive locking devices. The relative positions of the worm and wheel should be permanently marked for future reassembly.
Initial Run-in (Break-in): New screw gears require a careful run-in period to establish proper contact patterns and smooth surfaces. The process should begin at low speed (e.g., 25% of rated speed) and no load. Gradually increase the load in steps (25%, 50%, 75%, 100%) over several hours. During run-in, inspect for any signs of bronze transfer (smearing) onto the worm threads. If transfer is observed, stop immediately, clean the worm with a fine abrasive cloth, and resume run-in. After completing the run-in period, drain the initial oil to remove wear debris, clean the housing, and refill with fresh lubricant.
Ongoing Maintenance:
- Temperature Monitoring: Regularly check the operating temperature, especially during initial operation and after any load changes.
- Oil Analysis and Changes: Follow the manufacturer’s guidelines for oil change intervals, typically every 2,000 to 4,000 operating hours. Use the specified oil type and grade. Mixing different brands or types of lubricant is not recommended.
- Backlash and Wear Inspection: Periodically check the backlash of the screw gear set. A progressive increase in backlash indicates tooth wear. Inspect for abnormal noise or vibration.
- Re-lubrication of Bearings: Ensure bearings are re-greased or provided with oil mist as per their specific requirements, which may differ from the gear mesh lubrication schedule.
In conclusion, screw gears, or worm drives, represent a unique and indispensable solution for high-ratio, compact, and self-locking power transmission. A deep understanding of their characteristics—from the types and materials to the intricacies of efficiency, thermal management, and precise alignment—is paramount for engineers to select, design, and maintain these drives effectively, ensuring reliable and long-lasting performance in diverse mechanical systems.