
In mechanical engineering, screw gear mechanisms, commonly referred to as worm gear systems, are indispensable for motion transmission between non-intersecting shafts, typically arranged at 90 degrees. As a researcher focused on power transmission systems, I have extensively studied these mechanisms, particularly their self-locking property, which prevents back-driving and is crucial in applications like lifting platforms and hoists. This article delves into the fundamental structure, self-locking conditions, and failure causes of screw gear systems, emphasizing analytical insights through formulas and tables. The keyword ‘screw gear’ will be repeatedly highlighted to underscore its centrality in this discussion.
The basic structure of a screw gear mechanism consists of a worm (the screw) and a worm wheel (the gear). The worm, akin to a threaded shaft, meshes with the worm wheel, enabling motion transfer with high reduction ratios and compact design. This configuration is ideal for交错轴传动, where space constraints and torque requirements are stringent. The geometry is defined by parameters such as the number of starts on the worm (Z1), module (m), and characteristic coefficient (q). A key aspect is the lead angle (α) of the worm, which influences the system’s efficiency and self-locking tendency. For a single-start worm, the lead angle is given by:
$$ \alpha = \arctan\left(\frac{Z_1}{q}\right) = \arctan\left(\frac{1}{q}\right) \quad \text{for } Z_1 = 1 $$
This relationship shows that α decreases as q increases, impacting the self-locking capability. To visualize a typical screw gear assembly, consider the following representation:
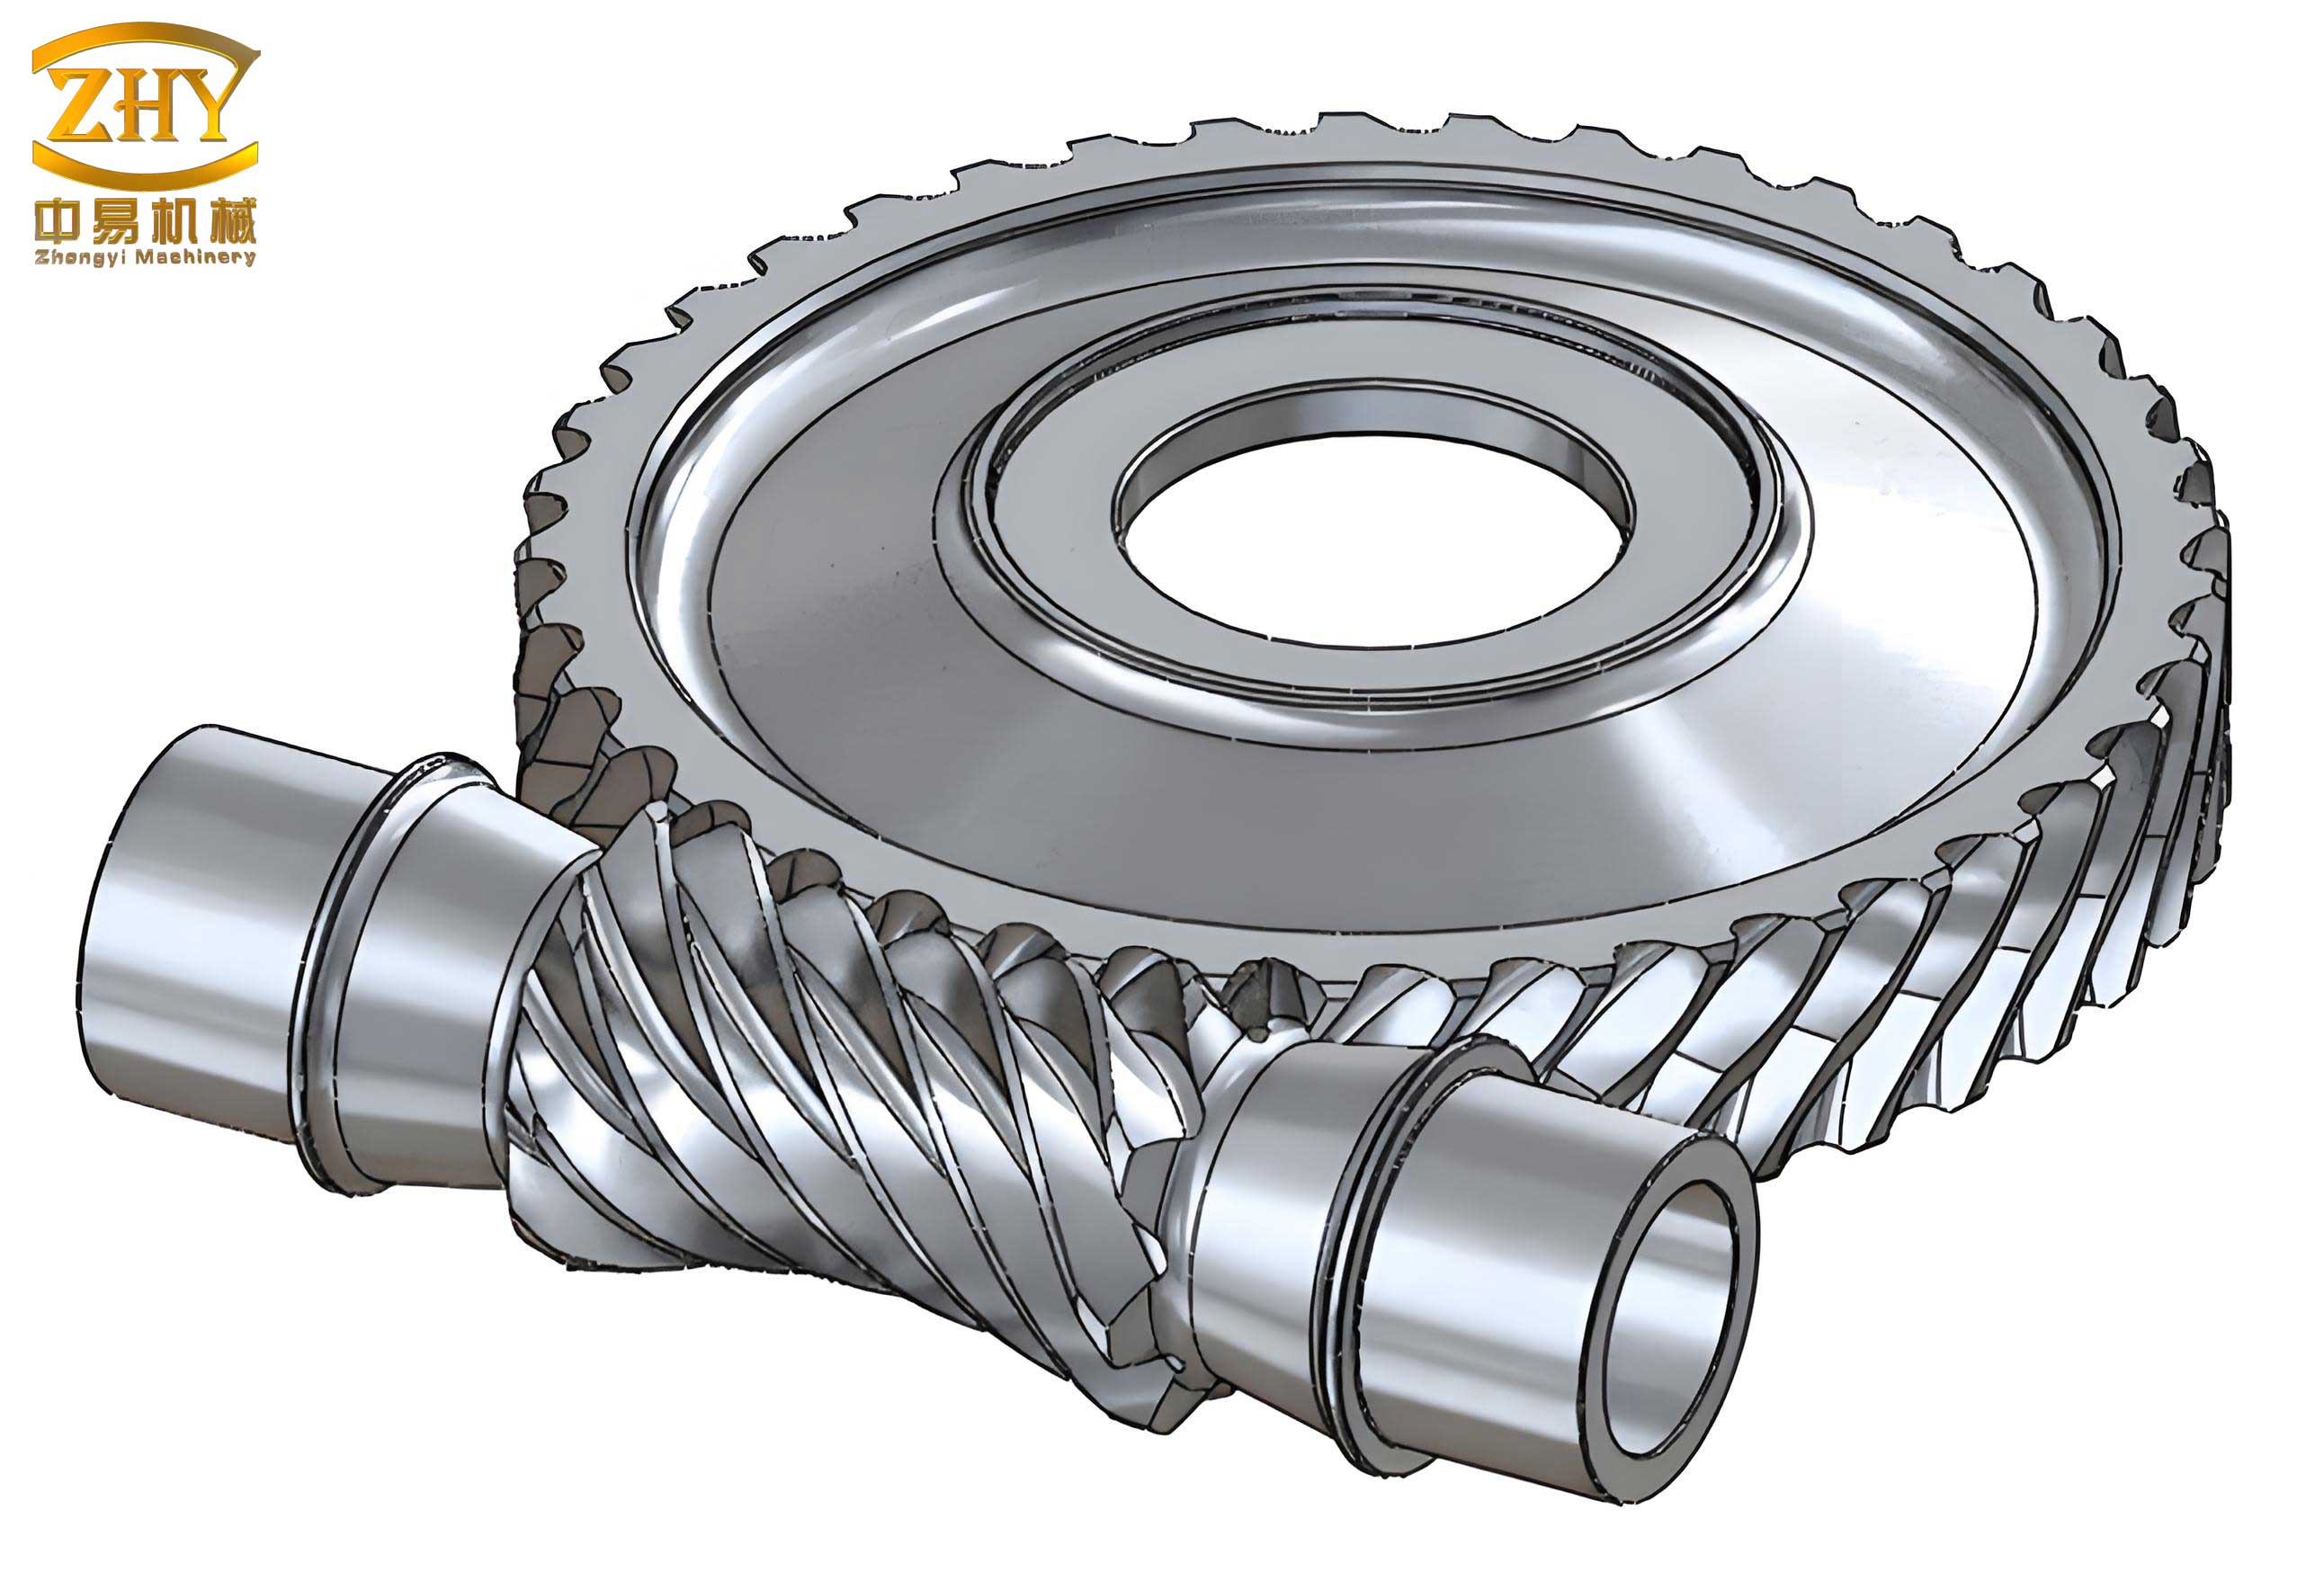
Self-locking in screw gear mechanisms is a phenomenon where the system prevents reversal of motion when the worm wheel is driven backward, essentially acting as a brake. This property is vital for safety in elevators and cranes. The condition for self-locking is often stated as: the lead angle α must be less than the friction angle β. The friction angle depends on the coefficient of friction (f) between the worm and worm wheel materials, expressed as:
$$ \beta = \arctan(f) $$
Thus, self-locking occurs if α < β. However, f is not a constant; it varies with material pairing, surface finish, lubrication, and operational conditions. For instance, different material combinations yield distinct f ranges, as summarized in Table 1.
| Worm Material | Worm Wheel Material | Friction Coefficient (f) Range |
|---|---|---|
| Steel | Bronze | 0.10 – 0.18 |
| Steel | Cast Iron | 0.10 – 0.30 |
| Steel | Brass | 0.03 – 0.15 |
| Steel | Steel | 0.10 – 0.15 |
From this table, we observe that steel-brass pairings have lower friction, making self-locking less likely, whereas steel-cast iron combinations may promote it due to higher friction. This variability underscores why screw gear systems sometimes exhibit inconsistent self-locking behavior in practice. Additionally, surface quality plays a role: poorer finishes increase f, enhancing self-locking, while polished surfaces reduce it. Lubrication further complicates matters; oil immersion, common in screw gear boxes to reduce wear, can lower f, potentially defeating self-locking. Moreover, the contact pressure (P) between meshing teeth affects f, as shown in Table 2.
| Contact Pressure P (MPa) | Friction Coefficient (f) |
|---|---|
| 8.79 | 0.166 |
| 13.08 | 0.300 |
| 18.28 | 0.310 |
| 23.62 | 0.347 |
| 31.50 | 0.354 |
| 42.18 | 0.359 |
This table indicates that f generally rises with P, meaning that under heavy loads, a screw gear might become more prone to self-locking. However, in dynamic conditions, factors like sliding velocity and thermal effects can alter f, making β a variable rather than a fixed value. Therefore, the self-locking criterion α < β is dynamic and must be evaluated contextually. For a screw gear with Z1 = 2 and q = 10, α is calculated as:
$$ \alpha = \arctan\left(\frac{2}{10}\right) \approx 11.31^\circ $$
If f is 0.1, then β ≈ 5.71°, so α > β, and self-locking does not occur. But if wear increases f to 0.3, β ≈ 16.70°, potentially enabling self-locking. This illustrates the sensitivity of screw gear performance to operational changes.
Beyond material and friction, installation errors significantly impact self-locking in screw gear mechanisms. Misalignment between the worm and worm wheel axes can lead to uneven load distribution and accelerated wear, compromising the self-locking function. Consider the force analysis in a screw gear system. The normal force Fn at the meshing point resolves into tangential (Ft), radial (Fr), and axial (Fa) components. For the worm, these forces are:
$$ |F_{t1}| = |F_{a2}| = F_n \cos \alpha_n \cos \gamma $$
$$ |F_{a1}| = |F_{t2}| = F_n \cos \alpha_n \sin \gamma $$
$$ |F_{r1}| = |F_{r2}| = F_n \sin \alpha_n $$
Here, αn is the normal pressure angle, and γ is the lead angle. When external torque T is applied to the worm wheel, such as in a lifting mechanism, T = F L cos θ, where θ is the angular position. Maximum torque often occurs in specific quadrants, influencing the screw gear’s load. If installation deviates from the ideal aligned position—say, offset left or right—the contact pattern shifts, causing asymmetric wear. For example, if the worm rotates counterclockwise and the worm wheel’s contact is biased left, wear concentrates on the left flank, effectively increasing the effective lead angle over time. This wear can be modeled as a gradual change in α, reducing the self-locking margin. Suppose the initial α is 5°, and wear increases it to 7°, while f decreases due to polishing from 0.2 to 0.15. Then, β drops from 11.31° to 8.53°, potentially leading to α < β being violated and self-locking failure. Such scenarios are common in screw gear systems subjected to repetitive stress.
Vibration is another critical factor that can undermine self-locking in screw gear mechanisms. Vibrations from external sources or internal imbalances induce dynamic loads, altering the contact forces and promoting fretting wear. This accelerates the degradation of tooth surfaces, effectively changing f and α. Moreover, vibrations can cause momentary loss of contact, allowing the worm wheel to back-drive briefly, which in high-precision screw gear applications can be catastrophic. To mitigate this, proper mounting rigidity and damping are essential. For instance, using resilient couplings or anti-vibration pads can help maintain alignment and reduce vibrational energy transmitted to the screw gear assembly. Additionally, periodic maintenance to check for wear and realignment is crucial for preserving self-locking integrity.
The self-locking capability of a screw gear also depends on the helix angle and lubrication regime. In oil-bath lubricated systems, the oil film can reduce friction to a point where self-locking is marginal. Experimental studies show that for a screw gear with α = 4° and f = 0.08 (β ≈ 4.57°), self-locking is just achieved, but any contamination or oil breakdown can raise f, altering the balance. Conversely, dry or semi-lubricated screw gears might have higher f, but at the cost of increased wear and heat generation. This trade-off necessitates careful design based on application requirements. For example, in a safety-critical screw gear for a elevator brake, materials with consistent f, like bronze worm wheels paired with hardened steel worms, are preferred, along with regular lubrication monitoring.
To quantify the self-locking tendency, we can derive an efficiency-based criterion. The efficiency η of a screw gear when driving forward is:
$$ \eta = \frac{\tan \alpha}{\tan(\alpha + \beta)} $$
For self-locking to occur when the worm wheel is the driver, the reverse efficiency must be zero or negative, which translates to α ≤ β. However, in practice, due to the variability of β, a safety factor is often applied. Designers might specify α < 0.9β to ensure reliability. For a screw gear with q = 12 and Z1 = 1, α = arctan(1/12) ≈ 4.76°. If the expected f range is 0.1–0.2, then β ranges from 5.71° to 11.31°, so self-locking is likely but not guaranteed at the lower f end. This highlights the importance of selecting materials with predictable friction properties for screw gear systems.
Failure analysis of screw gear self-locking often points to wear as the primary mechanism. Wear progresses through adhesive, abrasive, or corrosive processes, gradually modifying the tooth geometry. As wear increases the effective lead angle and smoothens surfaces, f may decrease, pushing the system out of the self-locking regime. Preventive measures include using wear-resistant coatings, optimizing lubrication, and implementing alignment checks during installation. For instance, laser alignment tools can ensure the worm and worm wheel axes are perfectly perpendicular, minimizing uneven wear. In one case study on industrial screw gear drives, misalignment of just 0.1 mm led to a 40% reduction in self-locking capability within 500 hours of operation, emphasizing the sensitivity of these systems.
In conclusion, the self-locking property of screw gear mechanisms is a complex interplay of geometric parameters like lead angle α and dynamic factors such as friction coefficient f. Through formulas and tables, we’ve seen how material selection, surface conditions, lubrication, installation accuracy, and vibration influence this behavior. For engineers designing screw gear systems, a holistic approach that considers these variables is essential to ensure reliable self-locking. Future research could focus on real-time monitoring of wear and friction in screw gears to predict self-locking failure, enhancing safety in critical applications. As screw gear technology evolves, understanding these fundamentals will remain key to optimizing performance and longevity.
Throughout this analysis, the term ‘screw gear’ has been emphasized to reinforce its relevance in mechanical transmissions. By integrating theoretical principles with practical insights, we can better harness the self-locking potential of screw gear mechanisms in diverse engineering contexts.