
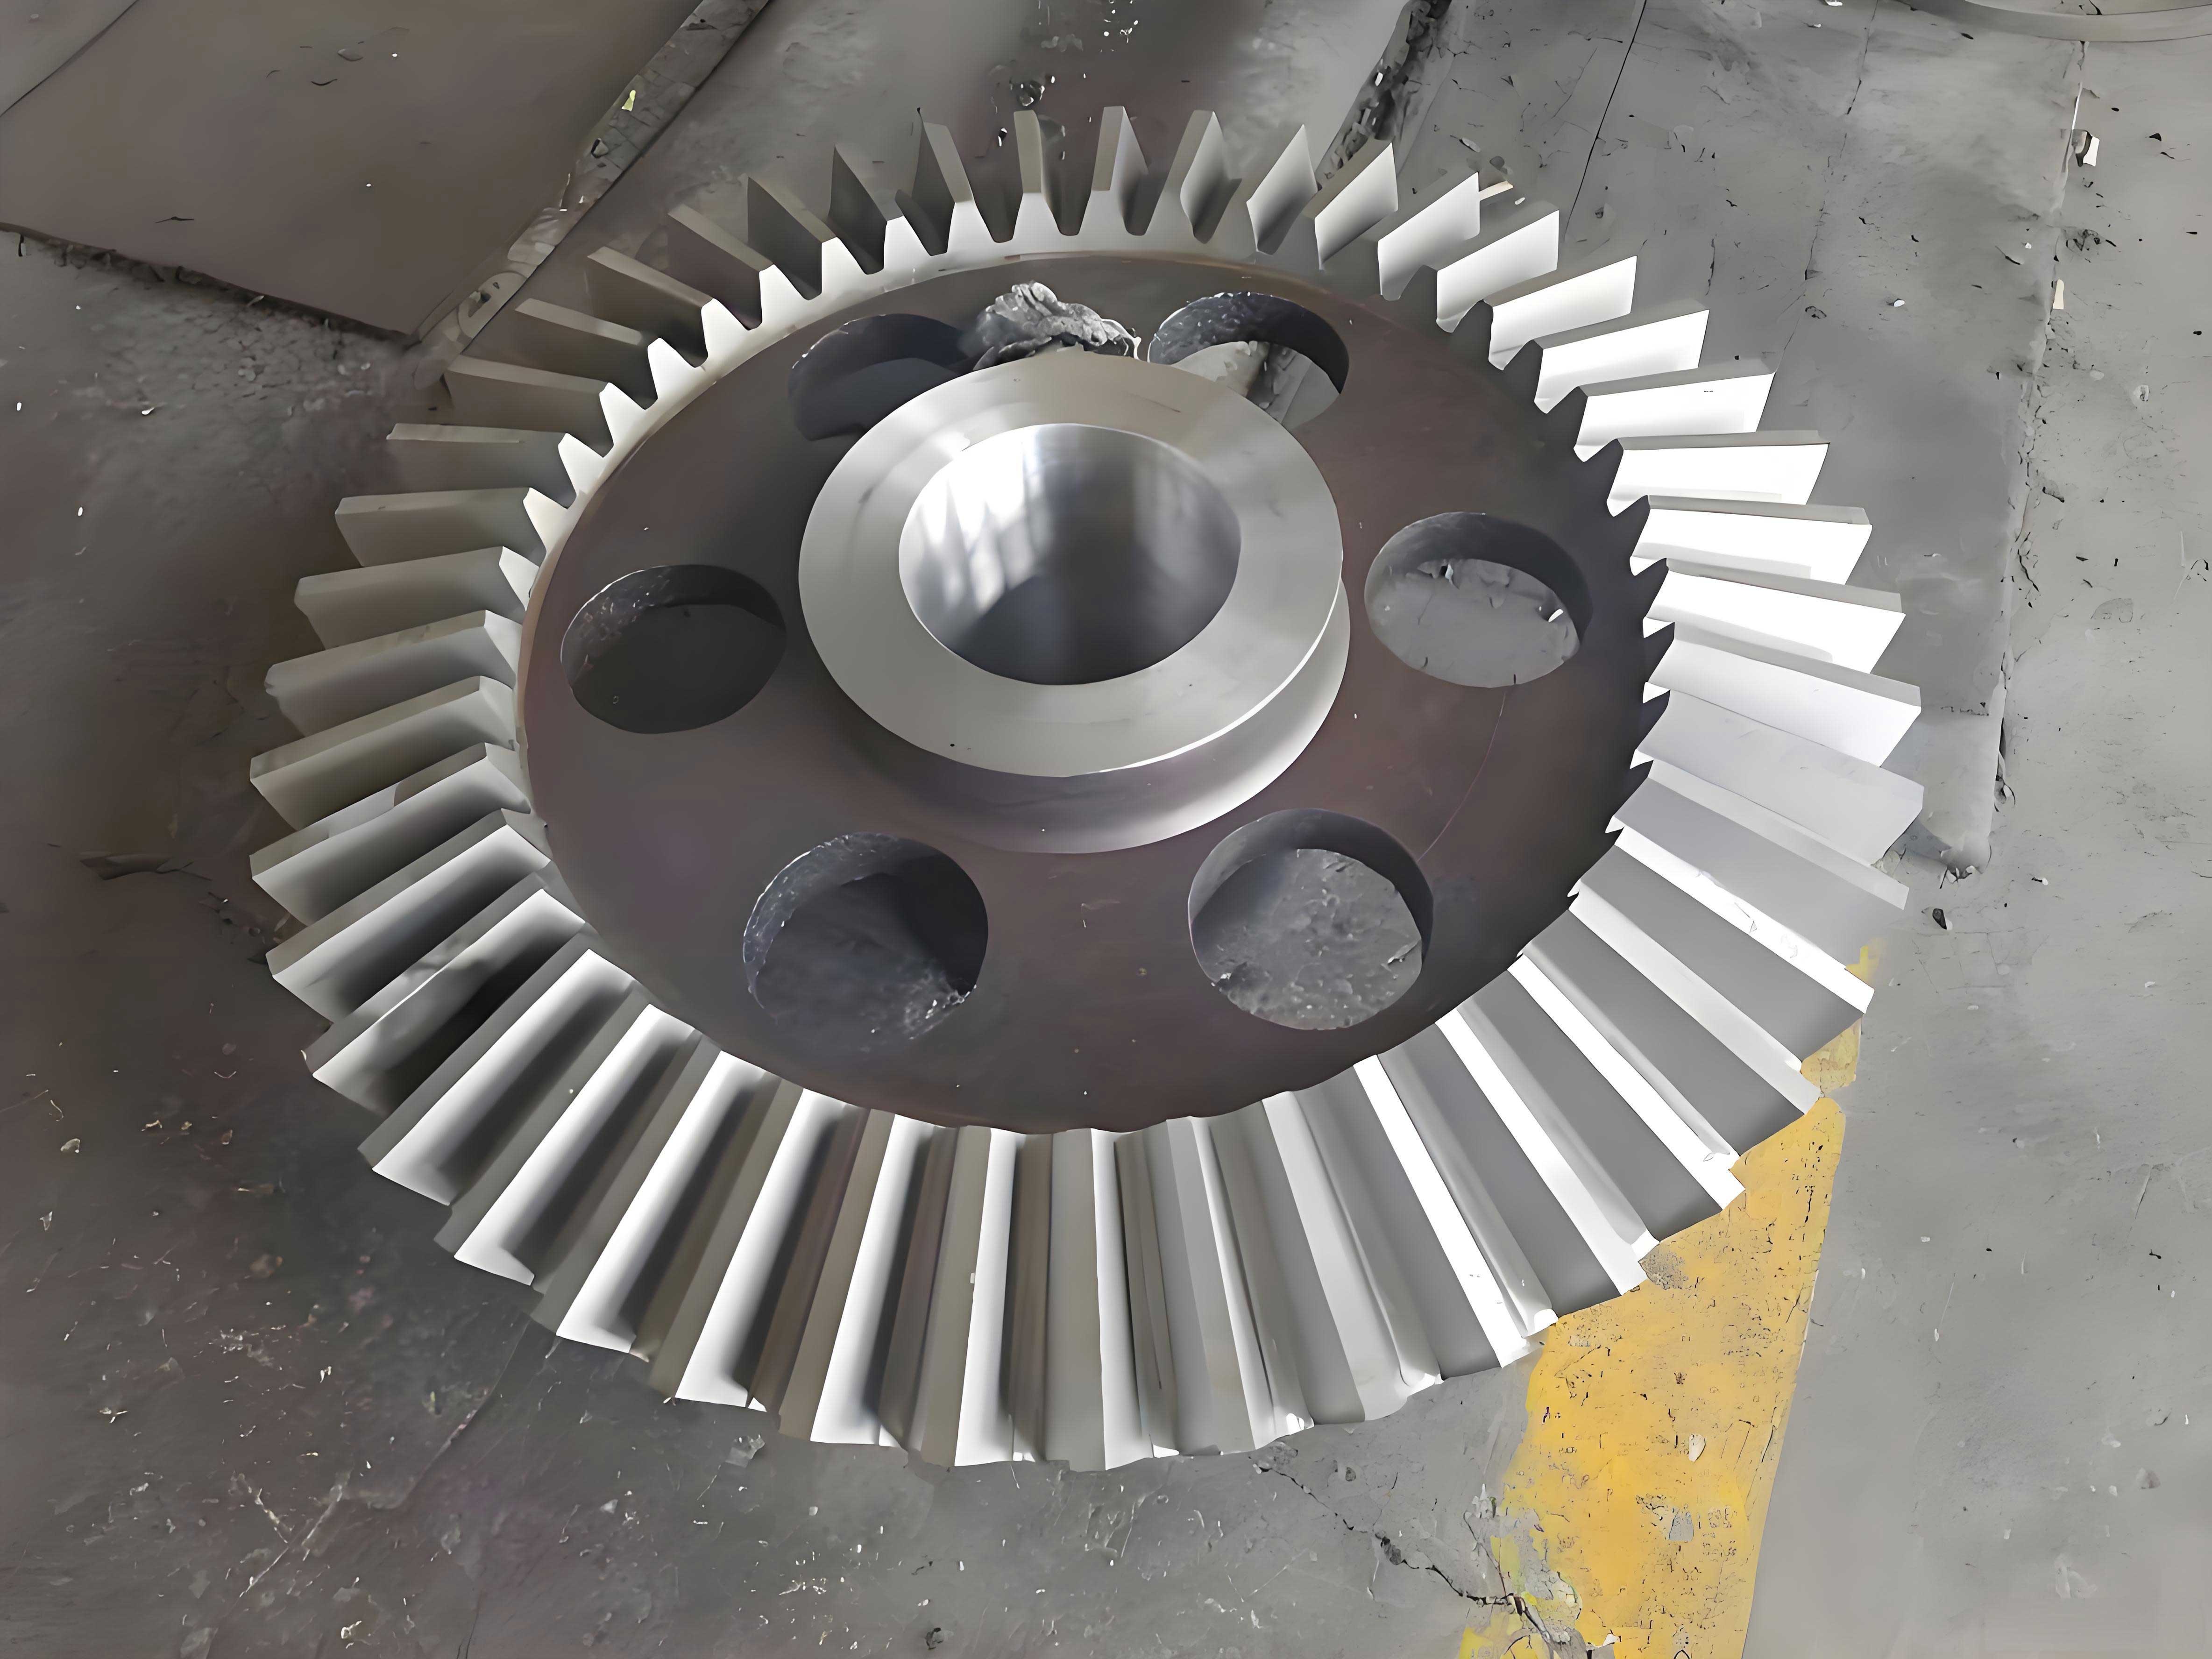
In my work I study how symmetry error changes the meshing behavior of miter gears. I treat miter gears as a paired transmission in which two opposite tooth sets should remain geometrically symmetric about a central reference plane, while manufacturing and assembly deviations inevitably break that symmetry. For miter gears used in high-speed, heavy-load, and high-power systems, the load-sharing state, transmission error, and mesh stiffness are strongly coupled to this symmetry condition. I therefore build a tooth contact analysis model and a loaded tooth contact analysis model for miter gears, then I modify those models to include an explicit symmetry error. I verify the modified models with finite element contact simulations and with experiments on a machined miter gears sample.
My motivation is practical. Miter gears often operate under reversing torque, axial force cancellation, and strict vibration limits. When miter gears are manufactured as two separate tooth sets, the left and right flanks cannot be perfectly identical. A small mismatch in the axial direction changes the initial gap between mating flanks, and because the tooth stiffness of miter gears is large, that small gap can produce a large load bias. In severe cases one side of miter gears may carry most of the load while the other side carries very little. This load bias affects durability, noise, and transmission accuracy. I therefore define a measurable symmetry error, incorporate it into the contact equations, and evaluate its influence on miter gears under axial fixed and axial floating support conditions.
I use the following notation for miter gears. The pinion is denoted by 1, and the gear is denoted by 2. The left and right tooth sets are denoted by L and R. The normal module is \(m_n\), the normal pressure angle is \(\alpha_n\), the helix angle is \(\beta\), the tooth number is \(z\), and the face width of each side is \(b\). For miter gears, I let \(\Delta T\) represent the symmetry error in the axial direction. I let \(\phi_1\) and \(\phi_2\) be the instantaneous rotation angles of the pinion and gear of miter gears. I let \(u_i\) and \(l_i\) be the tooth surface parameters. I let \(\mathbf{r}\) and \(\mathbf{n}\) denote position and unit normal vectors. The central idea is that every contact equation for miter gears must satisfy position coincidence and normal coincidence, while the symmetry error modifies the initial gap of the right tooth set.
| Symbol | Meaning for miter gears | Typical value or unit |
|---|---|---|
| \(z_1,z_2\) | pinion and gear tooth numbers of miter gears | 27, 81 |
| \(m_n\) | normal module | 3.5 mm |
| \(\alpha_n\) | normal pressure angle | 20 deg |
| \(\beta\) | helix angle of the paired miter gears | 30 deg |
| \(b\) | face width of each side | 30 mm |
| \(H\) | central relief groove length | 55 mm |
| \(\Delta T\) | symmetry error of miter gears | 0 to 0.03 mm |
| \(T\) | load torque on the gear of miter gears | 2000 N m |
I begin with the tooth surface generation of miter gears. A rack cutter with a parabolic modification is used to generate the working flanks. The parabolic coefficient is small, so the generated surface remains close to the ideal involute surface, but the contact between mating miter gears becomes a point contact in the numerical model. This is important because a line-contact model for ideal miter gears produces an infinite number of solutions, whereas a point-contact formulation gives a unique solution at each meshing position.
The cutter position vector and unit normal for miter gears are written as
$$ \mathbf{r}_{ai} = \begin{bmatrix} u_i \\ a_i u_i^2 \\ l_i \end{bmatrix} $$
$$ \mathbf{n}_{ai} = \frac{ \frac{\partial \mathbf{r}_{ai}}{\partial u_i} \times \frac{\partial \mathbf{r}_{ai}}{\partial l_i} }{ \left\| \frac{\partial \mathbf{r}_{ai}}{\partial u_i} \times \frac{\partial \mathbf{r}_{ai}}{\partial l_i} \right\| } = \frac{1}{\sqrt{1+4a_i^2u_i^2}} \begin{bmatrix} -2a_i u_i \\ 1 \\ 0 \end{bmatrix} $$
Here \(a_i\) is the parabolic modification coefficient for miter gears, \(u_i\) is the profile parameter, and \(l_i\) is the length parameter along the cutter. I transform the cutter surface into the coordinate system of the generated miter gears by two successive matrix operations:
$$ \mathbf{r}_{ti} = \mathbf{M}_{tn}\mathbf{M}_{na}\mathbf{r}_{ai} $$
$$ \mathbf{n}_{ti} = \mathbf{L}_{tn}\mathbf{L}_{na}\mathbf{n}_{ai} $$
The matrices \(\mathbf{M}_{na}\) and \(\mathbf{M}_{tn}\) for miter gears are
$$ \mathbf{M}_{na} = \begin{bmatrix} \cos\alpha & \sin\alpha & 0 & 0 \\ -\sin\alpha & \cos\alpha & 0 & 0 \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
$$ \mathbf{M}_{tn} = \begin{bmatrix} 1 & 0 & 0 & 0 \\ 0 & \cos\beta_i & \sin\beta_i & 0 \\ 0 & -\sin\beta_i & \cos\beta_i & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
During generation, the rack cutter translates along the pitch line while the miter gears blank rotates about its axis. The meshing condition between the cutter and the generated tooth surface of miter gears is
$$ f_i(u_i,l_i,\theta_i)=\mathbf{n}_{ti}\cdot\mathbf{V}_{ti}^{(i)}=0 $$
For miter gears, the relative velocity between the cutter and the generated tooth surface is
$$ \mathbf{V}_{ti}^{(i)} = \boldsymbol{\omega}_i \times \mathbf{r}_{ti} + \mathbf{r}_{pi}\boldsymbol{\omega}_i \times \mathbf{j}_c – r_{pi}\omega_i \mathbf{k}_c $$
Solving the meshing condition gives the relation
$$ \theta_i = \frac{u_i^2 \sin\beta_i – 2a_i u_i \cos\beta_i}{2a_i u_i \sin\beta_i – \cos\beta_i} + \frac{l_i \cos\beta_i}{r_{pi}} $$
I then obtain the generated tooth surface of miter gears as
$$ \mathbf{r}_i(u_i,\theta_i)=\mathbf{M}_{it}\mathbf{r}_{ti} $$
$$ \mathbf{n}_i(u_i,\theta_i)=\mathbf{L}_{it}\mathbf{n}_{ti} $$
The transformation matrix for miter gears is
$$ \mathbf{M}_{it} = \begin{bmatrix} \cos\theta_i & \sin\theta_i & 0 & r_{pi}(\cos\theta_i+\theta_i\sin\theta_i) \\ -\sin\theta_i & \cos\theta_i & 0 & r_{pi}(-\sin\theta_i+\theta_i\cos\theta_i) \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
With the tooth surface equations established, I formulate the tooth contact analysis model for miter gears. In a fixed frame, two mating tooth surfaces of miter gears must have a common contact point and a common normal at every instant. For the left tooth set of miter gears, the TCA equations are
$$ \mathbf{r}_f^{(1)}(u_1,\theta_1,\phi_1)=\mathbf{r}_f^{(2)}(u_2,\theta_2,\phi_2) $$
$$ \mathbf{n}_f^{(1)}(u_1,\theta_1,\phi_1)=\mathbf{n}_f^{(2)}(u_2,\theta_2,\phi_2) $$
Because the normal vectors are unit vectors, the above system provides five independent scalar equations. There are six unknowns, namely \(u_1,u_2,\theta_1,\theta_2,\phi_1,\phi_2\). I choose \(\phi_1\) as the input parameter, so the remaining five unknowns can be solved. I repeat the solution over one meshing period, and I obtain the contact path, contact trace, and geometric transmission error of miter gears.
For edge contact of miter gears, I include both flank edge contact and tip edge contact. If the pinion flank edge of miter gears contacts the gear tooth surface, the tangency equation is
$$ \mathbf{r}_f^{(1)}(u_1,\theta_1,\phi_1)=\mathbf{r}_f^{(2)}(u_2,\theta_2,\phi_2) $$
$$ \frac{\partial \mathbf{r}_f^{(1)}}{\partial \theta_1}\cdot \mathbf{n}_f^{(2)}=0 $$
The geometric transmission error of miter gears is defined as
$$ \delta\phi_2 = (\phi_2-\phi_2^{(0)}) – \frac{z_1}{z_2}(\phi_1-\phi_1^{(0)}) $$
For the complete miter gears pair, I combine the left and right tooth sets. If a phase difference exists between the two sides, I write
$$ \phi_{1L}=\phi_{1R}-\Delta\phi $$
$$ \Delta\phi = \frac{\Sigma_e}{r_b \cos\beta_b} $$
Therefore, the geometric transmission error of miter gears on the left and right sides is
$$ \delta\phi_L = (\phi_{2L}-\phi_{2L}^{(0)}) – \frac{z_1}{z_2}(\phi_{1L}-\phi_{1L}^{(0)}) $$
$$ \delta\phi_R = (\phi_{2R}-\phi_{2R}^{(0)}) – \frac{z_1}{z_2}(\phi_{1R}-\phi_{1R}^{(0)}) $$
I also determine the instantaneous contact ellipse for miter gears. In the loaded state, the theoretical contact point becomes an elliptical contact area because of elastic deformation. The semi-major axis \(a\) and semi-minor axis \(b\) of the contact ellipse for miter gears are
$$ a=\sqrt{\frac{\varepsilon}{A}} $$
$$ b=\sqrt{\frac{\varepsilon}{B}} $$
where
$$ A=\frac{1}{4}\left[K_{\Sigma}^{(1)}-K_{\Sigma}^{(2)}-\sqrt{g_1^2+g_2^2-2g_1g_2\cos 2\sigma^{(12)}}\right] $$
$$ B=\frac{1}{4}\left[K_{\Sigma}^{(1)}-K_{\Sigma}^{(2)}+\sqrt{g_1^2+g_2^2-2g_1g_2\cos 2\sigma^{(12)}}\right] $$
For miter gears, \(K_{\Sigma}^{(1)}=k_f+k_h\), \(K_{\Sigma}^{(2)}=k_s+k_q\), \(g_1=k_f-k_h\), and \(g_2=k_s-k_q\). The orientation of the contact ellipse is obtained from
$$ \cos 2\alpha^{(1)}=\frac{g_1-g_2\cos 2\sigma^{(12)}}{\sqrt{g_1^2+g_2^2-2g_1g_2\cos 2\sigma^{(12)}}} $$
$$ \sin 2\alpha^{(1)}=\frac{g_2\sin 2\sigma^{(12)}}{\sqrt{g_1^2+g_2^2-2g_1g_2\cos 2\sigma^{(12)}}} $$
After the geometric contact analysis of miter gears, I construct the loaded tooth contact analysis model. The initial gap before loading includes the inter-tooth gap and the normal gap. For miter gears, the inter-tooth gap is controlled by the geometric transmission error. If two adjacent tooth pairs of miter gears are in mesh, the difference in their geometric transmission errors creates a gap that determines load sharing. The normal gap is obtained by projecting the distance between the two tooth surfaces along the common normal.
I express the initial gap vector for miter gears as
$$ \mathbf{w}_k = \mathbf{b}_k + \boldsymbol{\delta}_k $$
$$ \mathbf{w}_k = \begin{bmatrix} w_{1,k} & w_{2,k} & \cdots & w_{n,k} \end{bmatrix}^T $$
$$ \mathbf{b}_k = \begin{bmatrix} b_{1,k} & b_{2,k} & \cdots & b_{n,k} \end{bmatrix}^T $$
$$ \boldsymbol{\delta}_k = \begin{bmatrix} \delta_k & \delta_k & \cdots & \delta_k \end{bmatrix}^T $$
The normal gap at a discrete point is
$$ b_q=\sqrt{(x_1-x_2)^2+(y_1-y_2)^2+(z_1-z_2)^2} $$
For the compliance of miter gears, I use a finite element mesh on the working tooth surface. If there are \(N\) nodes, I apply a unit normal load at each node and compute the flexibility coefficients \(f_{ij}\). After interpolation, the compliance matrix for miter gears is
$$ \mathbf{F}_a = \begin{bmatrix} f_{11} & f_{12} & \cdots & f_{1n} \\ f_{21} & f_{22} & \cdots & f_{2n} \\ \vdots & \vdots & \ddots & \vdots \\ f_{n1} & f_{n2} & \cdots & f_{nn} \end{bmatrix} $$
When several tooth pairs of miter gears mesh simultaneously, the global compliance matrix is assembled as
$$ \mathbf{F} = \begin{bmatrix} \mathbf{F}_a^{(1)} & 0 & \cdots & 0 \\ 0 & \mathbf{F}_a^{(2)} & \cdots & 0 \\ \vdots & \vdots & \ddots & \vdots \\ 0 & 0 & \cdots & \mathbf{F}_a^{(n)} \end{bmatrix} $$
The displacement coordination equation for loaded miter gears is
$$ \mathbf{F}_k\mathbf{P}_k+\mathbf{w}_k+\mathbf{Z}_k=\mathbf{d}_k $$
where
$$ \mathbf{P}_k=\begin{bmatrix} p_{1,k} & p_{2,k} & \cdots & p_{n,k} \end{bmatrix}^T $$
$$ \mathbf{d}_k=\begin{bmatrix} d_{1,k} & d_{2,k} & \cdots & d_{n,k} \end{bmatrix}^T $$
$$ \mathbf{Z}_k=\begin{bmatrix} Z_k & Z_k & \cdots & Z_k \end{bmatrix}^T $$
The force equilibrium condition for miter gears is
$$ \sum_{j=1}^{n} p_{j,k}=P $$
The non-embedded contact condition for miter gears is
$$ p_{j,k}\gt 0,\quad d_{j,k}=0 $$
$$ p_{j,k}=0,\quad d_{j,k}\gt 0 $$
For the complete miter gears pair, I combine the left and right sides. If the left and right tooth sets carry loads \(P_L\) and \(P_R\), then
$$ \sum_{j=1}^{n}p_{j,L}+\sum_{j=1}^{n}p_{j,R}=P_L+P_R=P $$
I solve the loaded contact problem of miter gears as a mathematical programming problem. The solution gives the loaded transmission error \(Z\), the contact load distribution \(P\), and the residual gap \(d\). I then compute the mesh stiffness of miter gears from the total normal load and the total deformation:
$$ k=\frac{p}{\delta} $$
$$ p=\frac{2T}{r_{b2}\cos\alpha_n\cos\beta} $$
$$ \delta=Z-TE $$
Thus, for the left and right sides of miter gears,
$$ k_L=\frac{T}{r_{b2}\cos\alpha_n\cos\beta\left(Z_L-TE_L\right)} $$
$$ k_R=\frac{T}{r_{b2}\cos\alpha_n\cos\beta\left(Z_R-TE_R\right)} $$
My next step is the central contribution of this study: the definition and modeling of symmetry error in miter gears. I unfold miter gears along the pitch cylinder. Without error, the left and right helices intersect on the central plane. When symmetry error exists, the intersection shifts away from the central plane. I define the symmetry error \(\Delta T\) of miter gears as the distance from the actual intersection to the central reference line. This definition is geometric, measurable, and suitable for miter gears with paired left and right tooth sets.
The corresponding angular deviation of miter gears is
$$ \alpha=\frac{\Delta T\tan\beta}{r} $$
I apply this angular deviation to the right pinion tooth surface of miter gears. The transformed position and normal are
$$ \mathbf{r}_1’=\mathbf{M}\mathbf{r}_1 $$
$$ \mathbf{n}_1’=\mathbf{L}\mathbf{n}_1 $$
where
$$ \mathbf{M} = \begin{bmatrix} \cos\alpha & \sin\alpha & 0 & 0 \\ -\sin\alpha & \cos\alpha & 0 & 0 \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
The right-side TCA equation for miter gears becomes
$$ \mathbf{r}_f^{(1)}(u_1,\theta_1,\phi_1+\alpha)=\mathbf{r}_f^{(2)}(u_2,\theta_2,\phi_2) $$
$$ \mathbf{n}_f^{(1)}(u_1,\theta_1,\phi_1+\alpha)=\mathbf{n}_f^{(2)}(u_2,\theta_2,\phi_2) $$
For the loaded contact model of miter gears, the initial gap changes because of symmetry error. I write the modified gap as
$$ \mathbf{w}_k=\mathbf{b}_k+\boldsymbol{\delta}_k-\Delta T\tan\beta $$
$$ \mathbf{w}_k=\mathbf{b}_k+\boldsymbol{\delta}_k+\Delta T\tan\beta $$
The displacement coordination, force equilibrium, and non-embedded conditions remain valid for miter gears, but the left and right loads are no longer equal in general:
$$ P_L\neq P_R $$
I verify the modified model of miter gears with a finite element contact simulation. I build a three-dimensional solid model of miter gears with a prescribed symmetry error, import it into a finite element environment, refine the contact region, and apply a torque to the pinion while fixing the gear. I use surface-to-surface frictional contact and compare the contact pattern, loaded transmission error, and mesh stiffness with my loaded tooth contact analysis results.
| Item | Finite element model of miter gears | Loaded tooth contact analysis of miter gears |
|---|---|---|
| Contact pattern | Short-long-short trace; slight left-right shift | Short-long-short trace; same shift trend |
| Left mean transmission error | -4.9554 arcsec | -4.8008 arcsec |
| Left amplitude | 10.711 arcsec | 8.659 arcsec |
| Right mean transmission error | -4.1588 arcsec | -3.9423 arcsec |
| Right amplitude | 9.332 arcsec | 7.537 arcsec |
| Left mean mesh stiffness | \(6.5292110\times 10^8\) N/m | \(6.3674181\times 10^8\) N/m |
| Right mean mesh stiffness | \(5.33368562\times 10^8\) N/m | \(5.14924434\times 10^8\) N/m |
The comparison shows that my loaded tooth contact analysis model for miter gears is accurate. The mean transmission error difference is about 3.12 percent on the left side and 5.21 percent on the right side. The mean mesh stiffness difference is about 2.48 percent on the left side and 3.46 percent on the right side. These differences are acceptable for engineering analysis of miter gears, especially because the finite element model includes more local compliance and contact nonlinearity.
I now examine the influence of symmetry error on miter gears under axial fixed support. I set \(\Delta T\) to 0 mm, 0.01 mm, 0.02 mm, and 0.03 mm. For each case I solve the TCA equations of miter gears and record the contact trace and geometric transmission error. The left tooth set remains close to the ideal miter gears case, while the right tooth set shifts toward the root. The shift grows with \(\Delta T\). The geometric transmission error on the right side also grows, which means that miter gears with larger symmetry error are more likely to generate vibration and impact.
| Symmetry error of miter gears \(\Delta T\) | Left contact trace | Right contact trace | Right geometric transmission error range |
|---|---|---|---|
| 0 mm | Reference | Reference | Nearly zero |
| 0.01 mm | Almost unchanged | Shifted toward root | -8.062 to -7.275 arcsec |
| 0.02 mm | Almost unchanged | Larger shift | -15.337 to -14.551 arcsec |
| 0.03 mm | Almost unchanged | Largest shift | -22.614 to -21.827 arcsec |
The loaded contact analysis of miter gears gives a clearer picture of load bias. When \(\Delta T=0\), the left and right tooth sets of miter gears share the load equally. When \(\Delta T\) increases, the left side carries more load and the right side carries less load. The load moves toward the side without symmetry error. For \(\Delta T=0.03\) mm, most of the load is concentrated on the left side of miter gears, and the right side is lightly loaded. This is a serious bias condition for miter gears.
| \(\Delta T\) of miter gears | Left load trend | Right load trend | Bias level |
|---|---|---|---|
| 0 mm | Equal and uniform | Equal and uniform | None |
| 0.01 mm | Slightly increased | Slightly reduced | Low |
| 0.02 mm | Clearly increased | Clearly reduced | Moderate |
| 0.03 mm | Dominant | Very low | Severe |
The loaded transmission error of miter gears also changes with symmetry error. As \(\Delta T\) grows, the left loaded transmission error increases and the right loaded transmission error decreases. Because the two sides of miter gears are connected through the same shaft system, this difference in loaded transmission error indicates a torsional and axial excitation. The mesh stiffness of miter gears decreases on both sides when symmetry error is present, and the right side changes more strongly. A lower and more fluctuating mesh stiffness is undesirable for miter gears because it can amplify dynamic response.
I then study miter gears with an axially floating pinion. In many practical miter gears systems, the pinion is allowed to move axially so that the axial forces on the two sides can be balanced. I find that axial floating improves the global load sharing of miter gears: the total load carried by the left and right gear pairs becomes nearly equal. However, axial floating does not fully remove the local load bias on each tooth surface of miter gears. The contact pattern on the right side still differs from the left side, and the tooth surface load is not perfectly uniform. This means that axial floating is a system-level compensation, not a complete tooth-surface correction for miter gears.
The axial displacement of miter gears is periodic because the number of contacting tooth pairs changes during meshing. When symmetry error is present, the initial gap on the two sides differs, so the pinion of miter gears must shift axially to balance the axial force. The axial displacement amplitude increases with \(\Delta T\).
| \(\Delta T\) of miter gears | Axial displacement character | Amplitude trend |
|---|---|---|
| 0.01 mm | Periodic small shift | Low |
| 0.02 mm | Periodic medium shift | Moderate |
| 0.03 mm | Periodic large shift | High |
I also investigate tooth surface modification for miter gears when symmetry error and axial floating are ignored. I use a combined profile and lead modification. The modification curve is formed by two parabolas and one straight line. I denote the maximum modification amounts and modification lengths at the root and tip, and the lead modification amounts at the two ends. The unmodified length in the lead direction is also specified. This modification changes the contact path of miter gears, moves the entry and exit points away from the edges, and concentrates the load toward the middle of the tooth. As a result, the risk of edge contact in miter gears is reduced.
The load distribution of miter gears becomes more favorable after modification. The loaded transmission error amplitude decreases from 7.8688 arcsec to 5.29 arcsec, a reduction of about 32.77 percent. The mean loaded transmission error decreases from -4.4814 arcsec to -3.1112 arcsec, a reduction of about 30.58 percent. The mesh stiffness amplitude decreases from \(2.2362\times 10^8\) N/m to \(0.7681\times 10^8\) N/m, a reduction of about 10.36 percent, and the mean mesh stiffness decreases from \(7.5469\times 10^8\) N/m to \(6.9271\times 10^8\) N/m, a reduction of about 8.21 percent. These results confirm that modification is beneficial for the stability of miter gears.
For miter gears with symmetry error, I propose a lead compensation modification. The principle is simple: where the initial gap is small, I apply a larger modification amount; where the initial gap is large, I apply a smaller modification amount. In this way the lead modification compensates the gap difference caused by symmetry error. I apply this compensation to miter gears and solve the contact problem again.
The compensated miter gears show a more uniform contact pattern and a smaller geometric transmission error. The load distribution becomes nearly equal on the left and right sides. For \(\Delta T=0.01\) mm, the left loaded transmission error amplitude decreases from 8.659 arcsec to 6.28 arcsec, a reduction of about 27.47 percent. The right amplitude increases slightly from 6.0367 arcsec to 6.28 arcsec, an increase of about 4.03 percent, but the two sides become almost equal. The left mesh stiffness amplitude decreases from \(1.233\times 10^8\) N/m to \(1.168\times 10^8\) N/m, a reduction of about 5.27 percent. The right mesh stiffness amplitude decreases from \(1.1912\times 10^8\) N/m to \(1.168\times 10^8\) N/m, a reduction of about 1.95 percent. I conclude that lead compensation modification is an effective way to reduce load bias in miter gears caused by symmetry error.
| Quantity for miter gears | Before compensation | After compensation | Change |
|---|---|---|---|
| Left loaded transmission error amplitude | 8.659 arcsec | 6.28 arcsec | -27.47 percent |
| Right loaded transmission error amplitude | 6.0367 arcsec | 6.28 arcsec | +4.03 percent |
| Left mesh stiffness amplitude | \(1.233\times 10^8\) N/m | \(1.168\times 10^8\) N/m | -5.27 percent |
| Right mesh stiffness amplitude | \(1.1912\times 10^8\) N/m | \(1.168\times 10^8\) N/m | -1.95 percent |
To validate my theoretical treatment of miter gears, I design and machine a pair of miter gears based on an aerospace transmission requirement. I measure the symmetry error with a gear measuring center. The symmetry error of miter gears cannot be measured directly, so I use a full-tooth helix method. I establish a spatial coordinate system with the gear center as the origin, the radial direction as the X axis, and the axial direction as the Z axis. I measure the helix positions on the corresponding left and right tooth surfaces and fit the two spatial lines by least squares. The intersection point of the fitted lines gives the symmetry error of miter gears.
For each helix of miter gears, I fit a line of the form
$$ y=a_0+a_1x $$
$$ y=b_0+b_1x $$
The least-squares conditions are
$$ \varphi(a_0,a_1)=\sum_{i=1}^{n}\left[y_i-(a_0+a_1x_i)\right]^2 $$
$$ \varphi(b_0,b_1)=\sum_{k=1}^{n}\left[y_k-(b_0+b_1x_k)\right]^2 $$
The necessary conditions give
$$ \frac{\partial\varphi}{\partial a_0}=-2\sum_{i=1}^{n}\left[y_i-a_0-a_1x_i\right]=0 $$
$$ \frac{\partial\varphi}{\partial a_1}=-2\sum_{i=1}^{n}\left[y_i-a_0-a_1x_i\right]x_i=0 $$
The fitted parameters are
$$ a_0=\frac{\sum_{i=1}^{n}x_i^2\sum_{i=1}^{n}y_i-\sum_{i=1}^{n}x_i\sum_{i=1}^{n}x_iy_i}{n\sum_{i=1}^{n}x_i^2-\left(\sum_{i=1}^{n}x_i\right)^2} $$
$$ a_1=\frac{n\sum_{i=1}^{n}x_iy_i-\sum_{i=1}^{n}x_i\sum_{i=1}^{n}y_i}{n\sum_{i=1}^{n}x_i^2-\left(\sum_{i=1}^{n}x_i\right)^2} $$
Similarly, I obtain \(b_0\) and \(b_1\). The intersection of the two fitted lines is
$$ x_0=\frac{a_0b_1-a_1b_0}{b_1-a_1} $$
$$ y_0=\frac{a_0b_1-a_1b_0}{b_1-a_1} $$
Because the XOY plane of the measuring coordinate system is the central plane of miter gears, the coordinate \(y_0\) is the symmetry error \(\Delta T\) of miter gears. From the measurement, I take the representative symmetry error as 0.010 mm for the experimental miter gears sample.
| Measurement item for miter gears | Method | Result |
|---|---|---|
| Symmetry error | Full-tooth helix method | 0.010 mm |
| Left helix | Least-squares line fit | Reference |
| Right helix | Least-squares line fit | Shifted intersection |
| Central plane | XOY plane of measuring frame | Reference plane |
I build a test platform for the meshing performance of miter gears. The platform consists of a drive motor, a torque sensor, a gearbox, a load motor, couplings, and a control system. The drive motor supplies power to the input shaft of miter gears, and the load motor applies torque to the output shaft. The torque and speed sensor collects input and output signals in real time. I use the platform to measure contact patterns and axial displacement of miter gears under quasi-static low-speed conditions.
I test two bearing arrangements for miter gears. In the axially fixed arrangement, both the pinion shaft and the gear shaft use self-aligning roller bearings, so neither shaft can move axially. In the axially floating arrangement, the gear shaft uses a self-aligning roller bearing to prevent axial movement, while the pinion shaft uses a cylindrical roller bearing to allow free axial motion. This arrangement allows me to compare the contact behavior of miter gears with and without axial floating.
| Arrangement for miter gears | Pinion bearing | Gear bearing | Axial behavior |
|---|---|---|---|
| Axially fixed | Self-aligning roller bearing | Self-aligning roller bearing | No axial motion |
| Axially floating | Cylindrical roller bearing | Self-aligning roller bearing | Pinion can float |
For contact pattern testing of miter gears, I coat the tooth surfaces with red lead powder, run the gearbox at low speed, and stop after stable operation. I inspect the contact marks on both sides of miter gears. When the pinion is axially fixed, the contact marks on the left and right sides are not symmetric and are not uniformly distributed. When the pinion is axially floating, the contact marks become essentially symmetric on both sides. This experimental result agrees with my simulation and confirms that axial floating improves the global load sharing of miter gears.
For axial displacement testing of miter gears, I place a vibration velocity sensor at three positions along the pinion shaft. I increase the input speed to 1000 rpm and the load torque to 2000 N m, wait for stable operation, and record the velocity signal. I integrate the velocity to obtain the axial displacement of miter gears. The measured displacement is periodic because the meshing tooth pairs alternate. At the beginning of meshing, the initial gap difference caused by symmetry error makes one side contact first, so the axial force is unbalanced and the pinion shifts axially. The measured amplitude is slightly larger than the simulation result because of manufacturing scatter, measurement noise, and environmental effects, but the overall trend is consistent.
| Experimental quantity for miter gears | Observed result | Comparison with simulation |
|---|---|---|
| Contact pattern, axial fixed | Asymmetric and uneven | Matches simulation trend |
| Contact pattern, axial floating | Nearly symmetric | Matches simulation trend |
| Axial displacement | Periodic, about 4.5 to 6.5 micrometers | Same trend, slightly larger |
| Symmetry error effect | Load bias grows with error | Confirmed |
From the entire study I draw several conclusions for miter gears. First, symmetry error changes the contact trace of miter gears. The side without error remains close to the ideal case, while the side with error shifts toward the root, and the shift grows with the magnitude of the error. Second, symmetry error changes the geometric transmission error of miter gears. The right side transmission error increases as symmetry error increases, which can introduce vibration and impact. Third, symmetry error creates load bias in miter gears. The load moves toward the side without error, and the bias becomes severe at larger error values. Fourth, both sides of miter gears experience reduced mesh stiffness when symmetry error is present, and the side with error changes more strongly. Fifth, axial floating improves the global load sharing of miter gears but does not fully eliminate local tooth load bias.
I also conclude that tooth modification is effective for miter gears. Combined profile and lead modification changes the contact path, avoids edge contact, concentrates the load toward the middle of the tooth, and reduces the amplitude and mean value of loaded transmission error and mesh stiffness. For miter gears with symmetry error, lead compensation modification is especially effective. By applying a larger modification where the initial gap is small and a smaller modification where the initial gap is large, I can compensate the gap difference and make the left and right loads nearly equal. This is a practical way to improve the meshing performance of miter gears without changing the basic geometry.
My experimental work supports the theoretical model of miter gears. The measured symmetry error is used as an input to the loaded contact model, and the predicted contact pattern under axial fixed and axial floating conditions agrees with the measured pattern. The measured axial displacement of miter gears is periodic and increases with symmetry error, and its trend agrees with the simulation. The discrepancies are reasonable because the actual miter gears have tooth-to-tooth variation, and the measurement system has limited resolution.
For future work on miter gears, I see three main directions. First, symmetry error should be treated as a random field along the tooth index rather than a single constant value. In real miter gears, each adjacent tooth pair may have a different symmetry deviation. Second, the measurement method for miter gears should be improved. The full-tooth helix method is effective, but a more direct and faster method could reduce uncertainty. Third, the dynamic behavior of miter gears with symmetry error should be studied together with axial floating, time-varying mesh stiffness, and load-dependent friction. Such a dynamic model would help predict noise and vibration of miter gears more accurately.
Overall, my study shows that symmetry error is a key characteristic of miter gears. It affects contact pattern, transmission error, load distribution, mesh stiffness, and axial displacement. By combining tooth contact analysis, loaded tooth contact analysis, finite element verification, and experimental measurement, I establish a consistent method for evaluating miter gears with symmetry error. The method is simple to program, convenient to apply, and useful for the design, manufacturing, and measurement of miter gears. I believe the results provide a practical basis for improving the stability and load capacity of miter gears in high-performance transmission systems.