
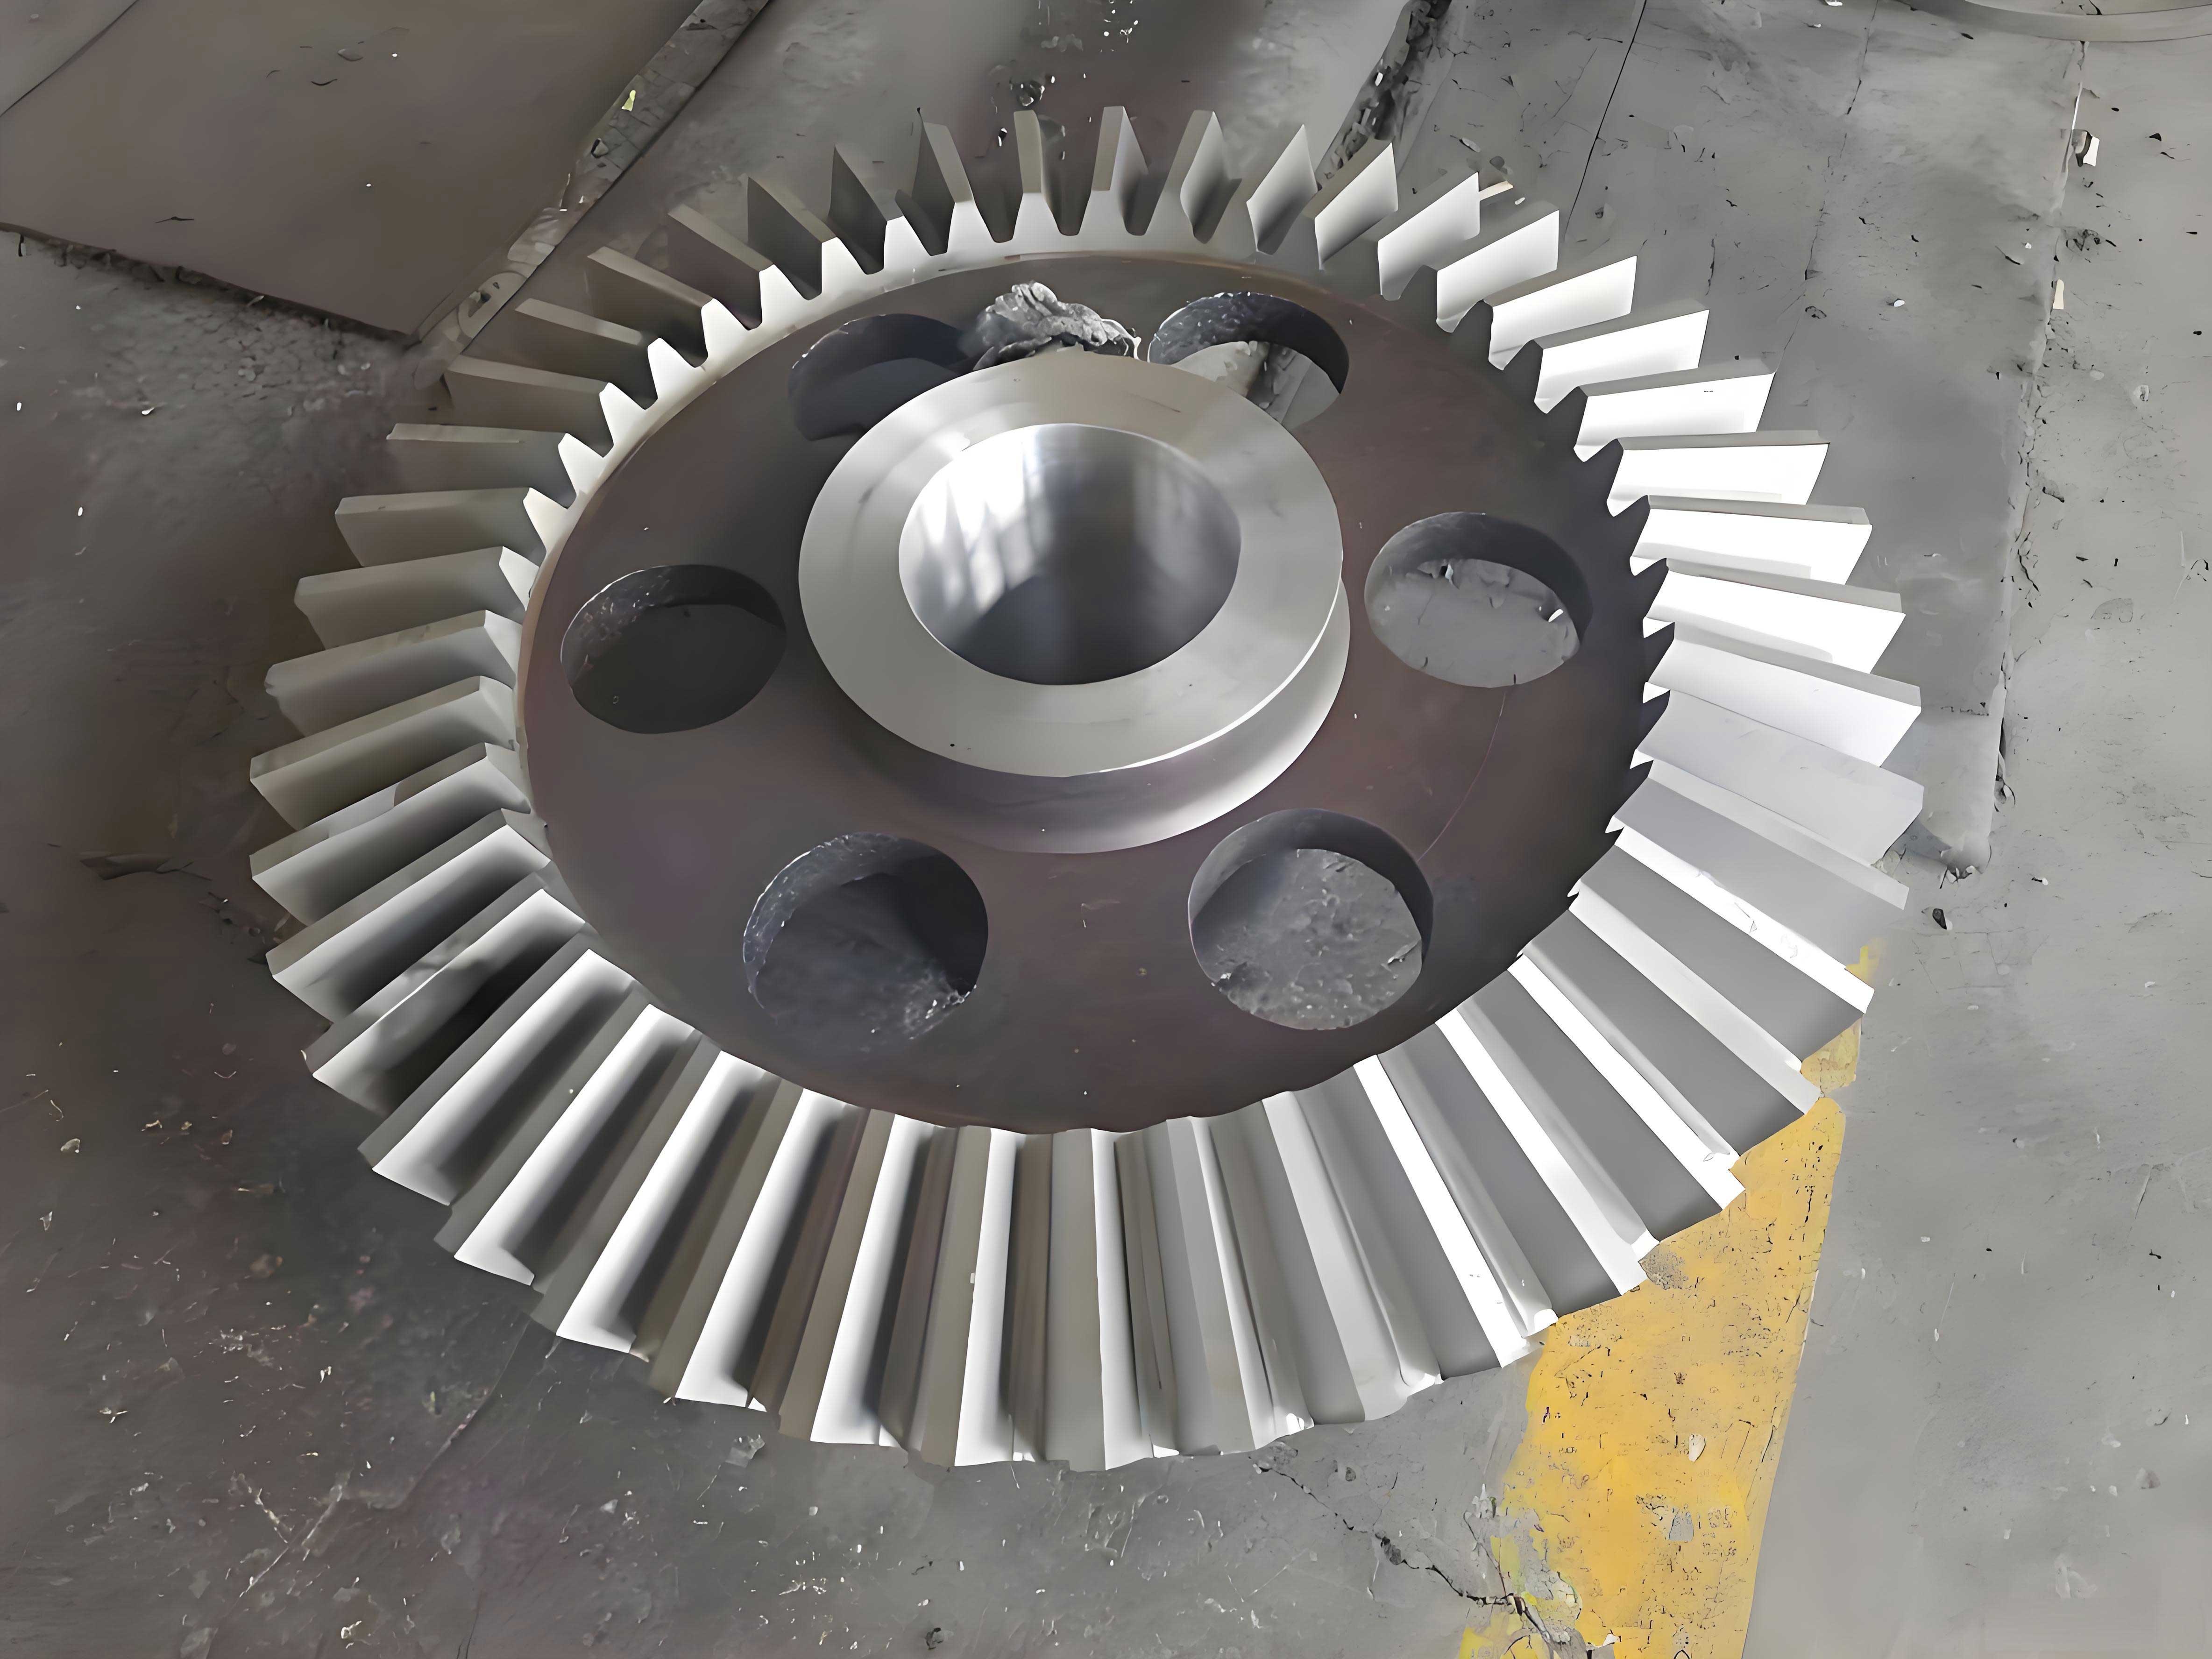
I investigated the thermal-mechanical behavior of high-speed wind-turbine miter gears used in the high-speed stage of a wind-turbine reducer. In this work, the term miter gears refers to the double-helical, herringbone-type miter gear pair that carries high load and high speed under complex service conditions. My purpose was to quantify how friction-induced heat, thermal deformation, and elastic contact deformation interact in miter gears, and then to use the coupled response to design a tooth-profile modification method for improved reliability, lower vibration, and longer service life. I built an accurate parametric model of the miter gears, calculated the frictional heat flux and convection boundaries, solved the steady-state body temperature field, applied the temperature field to the structural field through sequential thermal-mechanical coupling, and finally compared several tooth-profile modification curves. The results show that the coupled thermal-mechanical response of miter gears is not a secondary effect; it controls the local contact state, the maximum von Mises stress, and the load transition at the beginning and end of meshing.
1. Research Context and Objective
I began from the observation that wind energy has become one of the most important renewable energy sources, and that the gearbox is one of the most critical subsystems in a wind turbine. The high-speed stage of a wind-turbine reducer must transmit large torque while rotating at high speed. Under such conditions, miter gears are preferred because their double-helical arrangement improves load sharing, reduces axial force, increases contact ratio, and provides smoother transmission than a simple spur gear pair. However, the same high speed and high load also intensify friction heating. The heat generated on the tooth flanks cannot be dissipated instantly, so a non-uniform body temperature field develops. This temperature field causes thermal expansion, while the transmitted torque causes elastic deformation. The two deformation fields overlap and change the actual meshing path, especially near the beginning and end of contact. Therefore, I treated high-speed wind-turbine miter gears as a coupled thermal-mechanical system rather than as an isothermal elastic system.
My objective was fourfold. First, I derived the exact tooth-profile equations for the miter gears, including the involute profile, the root transition curve, and the double-helical surface. Second, I calculated the dynamic contact parameters and the frictional thermal boundary conditions for the miter gears. Third, I solved the steady-state temperature field and the thermal-mechanical coupled stress and deformation fields. Fourth, I proposed a tooth-profile modification method based on the coupled deformation of the miter gears and evaluated several modification curves. The design and operating parameters of the miter gears are summarized in Table 1.
| Parameter | Symbol | Driving miter gear | Driven miter gear |
|---|---|---|---|
| Number of teeth | \(z\) | 31 | 102 |
| Normal module | \(m_n\) | 4.5 mm | 4.5 mm |
| Normal pressure angle | \(\alpha_n\) | 20° | 20° |
| Helix angle | \(\beta\) | 25° | 25° |
| Face width | \(B\) | 45 mm | 45 mm |
| Relief groove width | \(B_1\) | 10 mm | 10 mm |
| Modification coefficient | \(x\) | 0 | 0 |
| Input torque | \(T\) | 4000 N·m | — |
| Rotational speed | \(n\) | 5000 r/min | 1519.6 r/min |
I selected these miter gears because they represent a typical high-speed, heavy-duty wind-turbine application. The driving miter gear has fewer teeth and therefore experiences more meshing cycles per revolution than the driven miter gear. This difference directly affects the temperature field, the friction heat flux, and the thermal deformation. In my analysis, I paid particular attention to the alternating single-tooth and multi-tooth contact regions because these regions determine the impact at the beginning and end of meshing. For high-speed miter gears, the modification must compensate not only for elastic deflection but also for thermal expansion.
2. Meshing Impact and Modification Principles
I analyzed the meshing impact of miter gears from the viewpoint of actual base pitch variation. In an ideal miter gear pair, the contact ratio and the base pitch are constant, so the load transfer between adjacent tooth pairs is smooth. In reality, the transmitted load deforms the teeth, and the temperature field changes the tooth thickness and profile. The actual base pitch of the driving miter gear and the driven miter gear therefore deviates from the theoretical value. When the driven miter gear enters meshing, the actual base pitch of the driving miter gear becomes smaller than that of the driven miter gear, so the new tooth pair enters contact earlier than expected. The instantaneous transmission ratio becomes:
$$
i_{12}^{\prime}
=
\frac{r_2 – \Delta r}{r_1 – \Delta r}
<
\frac{r_2}{r_1}.
$$
When the driving miter gear leaves meshing, the opposite deviation occurs, and the actual base pitch of the driving miter gear becomes larger than that of the driven miter gear. The tooth pair remains in contact longer than expected, producing a delayed exit. The instantaneous transmission ratio becomes:
$$
i_{12}^{\prime\prime}
=
\frac{r_2 + \Delta r}{r_1 + \Delta r}
>
\frac{r_2}{r_1}.
$$
These two effects produce the meshing-in impact and meshing-out impact, respectively. They cause a sudden change in angular velocity, an abrupt load transfer, and additional vibration and noise. For high-speed miter gears in a wind-turbine gearbox, these impacts are more severe because the rotational speed is high and the thermal deformation is not negligible. Tooth-profile modification is an effective method for reducing these impacts. It removes a small amount of material near the tooth tip or root so that the ideal involute contact is slightly shifted, allowing the miter gears to enter and leave meshing more gradually under load.
I considered three main modification parameters: maximum modification amount, modification length, and modification curve. The maximum modification amount must compensate for elastic deformation, thermal deformation, and manufacturing error. The modification length determines the region over which the profile is changed. The modification curve determines how the modification amount varies from zero to the maximum value. The general form of a power-law modification curve is:
$$
\Delta(x)
=
\Delta_{\max}
\left(
\frac{x}{L}
\right)^p,
$$
where \(x\) is the distance from the beginning of the modification region, \(L\) is the modification length, and \(p\) is the exponent. I also considered a combined linear-quadratic modification curve, expressed as:
$$
\Delta(x)
=
\Delta_{\max}
\left[
0.44
\left(
\frac{x}{L}
\right)
+
0.56
\left(
\frac{x}{L}
\right)^2
\right].
$$
For the maximum modification amount, I used the deformation-based relation:
$$
\Delta_{\max}
=
\delta_m
+
\delta_\theta
+
\delta_e,
$$
where \(\delta_m\) is the elastic deformation, \(\delta_\theta\) is the thermal deformation, and \(\delta_e\) is the manufacturing error. For a more general engineering estimate, I also considered the loaded contact condition:
$$
\Delta_{\max}
=
\frac{K_A F_t / b}{\varepsilon_\alpha C_r},
$$
where \(K_A\) is the application factor, \(F_t\) is the tangential force, \(b\) is the face width, \(\varepsilon_\alpha\) is the transverse contact ratio, and \(C_r\) is the combined mesh stiffness. For miter gears, the total contact ratio is larger than that of spur gears because both the transverse contact ratio and the overlap contact ratio contribute. This means that the modification amount of miter gears can be smaller than that of a comparable spur gear, but the modification length must still cover the alternating contact region. Table 2 summarizes the modification parameters and their functions.
| Modification parameter | Physical role in miter gears | Consideration in my study |
|---|---|---|
| Maximum modification amount | Compensates elastic deformation, thermal expansion, and pitch error | Calculated from coupled deformation at the alternating contact points |
| Modification length | Defines the tip or root region where the involute is changed | Long modification used for high-speed, heavy-duty miter gears |
| Modification curve | Controls the gradual transition from zero to maximum modification | Power-law curves and a combined linear-quadratic curve compared |
| Tip relief | Reduces impact when the driven miter gear enters meshing | Applied to the tooth tip of both miter gears |
| Root relief | Reduces impact when the driving miter gear leaves meshing | Evaluated through the coupled deformation and stress fields |
3. Parametric Modeling of Miter Gears
I used a rack-cutter generation method and coordinate transformation to model the miter gears accurately. The reason for using this method is that the tooth profile of a miter gear consists of an involute segment, a root transition curve, a tip arc, and a root arc. The involute segment governs the main meshing behavior, while the transition curve governs the root strength. If the transition curve is approximated by a simple arc, the root stress and the thermal deformation near the root may be inaccurate. Therefore, I derived the exact transition curve and involute equations from the rack-cutter motion.
For a rack cutter moving relative to the gear blank, the coordinate transformation from the cutter coordinate system to the gear coordinate system can be written as:
$$
\begin{aligned}
x &= (r-x_0)\cos\phi – (r-y_0)\sin\phi,\\
y &= (r-x_0)\sin\phi + (r-y_0)\cos\phi,
\end{aligned}
$$
where \(r\) is the pitch radius, \(x_0\) and \(y_0\) are the cutter coordinates, and \(\phi\) is the rolling angle. For the root transition curve produced by the cutter tip radius, I used:
$$
\begin{aligned}
x_0 &= x_c + \rho_0\cos\gamma,\\
y_0 &= y_c – \rho_0\sin\gamma,
\end{aligned}
$$
where \(x_c\) and \(y_c\) are the coordinates of the cutter tip center, \(\rho_0\) is the cutter tip radius, and \(\gamma\) is the angular parameter. Substituting these relations into the coordinate transformation gives the root transition curve of the miter gears. For the involute segment produced by the straight cutter flank, I used the relation:
$$
\begin{aligned}
x_0 &= \frac{1}{2}(r-y_w)\sin 2\phi,\\
y_0 &= (r-y_w)\cos\phi + y_w,
\end{aligned}
$$
where \(y_w\) is the half-tooth-space width on the rack pitch line. The corresponding involute profile in the gear coordinate system is obtained by applying the same coordinate transformation. I then extended the transverse profile along the helix direction to form the helical tooth surface:
$$
\begin{aligned}
X &= r\cos(\theta+\beta t),\\
Y &= r\sin(\theta+\beta t),\\
Z &= B t,\qquad 0\le t\le 1.
\end{aligned}
$$
For the double-helical miter gears, I mirrored the helical surface about the mid-plane of the relief groove. The herringbone surface can be written as:
$$
\begin{aligned}
X &= r\cos(\theta+\beta t),\\
Y &= r\sin(\theta+\beta t),\\
Z &= \pm(B_m+B t),\qquad 0\le t\le 1,
\end{aligned}
$$
where \(B_m\) is half of the relief groove width. This parametric procedure allowed me to generate a smooth three-dimensional model of the miter gears with an accurate involute, accurate root transition curve, and a symmetric herringbone arrangement. I then imported the model into a finite-element preprocessor, created a hexahedral mesh, and refined the mesh on the tooth flanks and near the root fillets. The mesh quality was controlled by checking the Jacobian, aspect ratio, and warpage. I used a region-based mesh strategy so that the contact regions and thermal boundary regions had sufficient density, while the inner body remained coarser to reduce computation time. This modeling approach was essential for the later thermal-mechanical coupling analysis of the miter gears because the temperature gradient and contact stress are both concentrated near the tooth surface.
4. Dynamic Contact and Thermal Analysis of Miter Gears
I derived the dynamic contact and thermal parameters of the miter gears from the meshing geometry. The relative sliding velocity is one of the most important quantities because friction heat is proportional to both contact pressure and sliding velocity. For a contact point \(k\), the curvature radii of the driving and driven miter gears are:
$$
\rho_{1k}
=
r_{b1}\tan\alpha_{1k},
\qquad
\rho_{2k}
=
r_{b2}\tan\alpha_{2k}.
$$
The combined curvature radius is:
$$
\frac{1}{\rho_{12}}
=
\frac{1}{\rho_{1k}}
+
\frac{1}{\rho_{2k}}.
$$
The relative sliding velocity at the contact point is:
$$
v_{g,k}
=
v_{1k}
–
v_{2k}
=
\frac{\pi n_1}{30\times1000}\rho_{1k}
–
\frac{\pi n_2}{30\times1000}\rho_{2k}.
$$
I found that the relative sliding velocity reaches a maximum near the tooth root and tooth tip, while it approaches zero near the pitch point. This distribution explains why the friction heat flux of miter gears is high near the root and tip and low near the pitch point. It also explains why the temperature field of the miter gears exhibits two peaks on the tooth flank.
I used a sliced-cylinder contact model to calculate the contact pressure. The normal contact pressure at contact point \(k\) was approximated as:
$$
p_k
=
\sqrt{
\frac{w_k E^*}{2\pi \rho_{12}(1-\nu^2)}
},
$$
where \(E^*\) is the equivalent elastic modulus, \(\nu\) is Poisson’s ratio, and \(w_k\) is the load per unit contact length. I estimated the load per unit length from the transmitted torque:
$$
w_k
=
\frac{F_t}{L}
=
\frac{T_2 z_1}{r_1 B \cos\alpha_\epsilon}.
$$
The friction coefficient was evaluated from a mixed-lubrication relation:
$$
f
=
0.12
\left(
\frac{\eta_f v_{g,k}}{p_k R_a}
\right)^{0.25},
$$
where \(\eta_f\) is the lubricant dynamic viscosity and \(R_a\) is the equivalent surface roughness. In my finite-element thermal model, I used a representative friction coefficient of 0.06 for the miter gears. The friction heat flux at the contact point was calculated as:
$$
q_k
=
\gamma f p_k v_{g,k},
$$
where \(\gamma\) is the fraction of friction energy converted into heat. I used \(\gamma=0.95\). Because the friction heat is shared between the two miter gears, I introduced the heat partition coefficient:
$$
\beta
=
\frac{
\sqrt{\lambda_1 \rho_1 c_1}
}{
\sqrt{\lambda_1 \rho_1 c_1}
+
\sqrt{\lambda_2 \rho_2 c_2}
}.
$$
The heat fluxes entering the driving and driven miter gears are then:
$$
q_{1k}
=
\beta q_k,
\qquad
q_{2k}
=
(1-\beta)q_k.
$$
Because each contact point remains in contact for only a short time during one meshing cycle, I converted the instantaneous heat flux into an average heat flux over one cycle:
$$
Q_{k,i}
=
\frac{q_{k,i}\tau_i}{T_0},
$$
where \(\tau_i\) is the contact duration of gear \(i\) and \(T_0\) is the meshing period. For the miter gears, the driving gear has fewer teeth and therefore more meshing cycles per unit time. As a result, the average friction heat flux on the driving miter gear is higher than that on the driven miter gear. I also observed that the alternating single-tooth and double-tooth contact regions produce a local increase in contact pressure, which in turn produces a local peak in the friction heat flux. Table 3 lists the material properties used for the miter gears, and Table 4 lists the lubricant properties.
| Property | Driving miter gear | Driven miter gear |
|---|---|---|
| Elastic modulus | \(2.06\times10^5\) MPa | \(2.06\times10^5\) MPa |
| Poisson ratio | 0.3 | 0.3 |
| Density | 7850 kg/m³ | 7850 kg/m³ |
| Specific heat | 452 J/(kg·K) | 452 J/(kg·K) |
| Thermal conductivity | 48 W/(m·K) | 48 W/(m·K) |
| Thermal expansion coefficient | \(1.1\times10^{-5}\) K⁻¹ | \(1.1\times10^{-5}\) K⁻¹ |
| Lubricant property | Value |
|---|---|
| Kinematic viscosity | 220 mm²/s |
| Density | 863.7 kg/m³ |
| Specific heat | 2129.87 J/(kg·K) |
| Temperature | 338 K |
| Thermal conductivity | 0.14 W/(m·K) |
I then calculated the convection heat transfer coefficients for different surfaces of the miter gears. For the end faces, I treated the surface as a rotating disk. The Reynolds number is:
$$
Re
=
\frac{\omega r_c^2}{\nu_f},
$$
where \(\omega\) is the angular velocity, \(r_c\) is the characteristic radius, and \(\nu_f\) is the kinematic viscosity. For the laminar regime, the Nusselt number is:
$$
Nu
=
0.308(m+2)^{0.5}Pr^{0.5}Re^{0.5},
$$
and the convection coefficient is:
$$
h_s
=
\frac{Nu\lambda_f}{r}.
$$
For the tooth flanks, I used an intermittent cooling model. The local convection coefficient varies with the tooth height and the rotational speed. I found that the tooth-flank convection coefficient of the driving miter gear is higher than that of the driven miter gear at the same rotational speed. It also increases from the root toward the tip. For the tooth tip, I treated the flow as flow over a flat plate and used:
$$
Nu
=
0.664Re^{0.5}Pr^{1/3}.
$$
The corresponding convection coefficient again increases with rotational speed. These boundary conditions are essential for the thermal analysis of the miter gears because they determine how much heat is carried away by the lubricant and how much heat remains in the gear body. Table 5 summarizes the thermal boundary conditions I applied to the miter gears.
| Surface | Boundary type | Main quantity | Applied condition |
|---|---|---|---|
| End face | Convection | \(h_{\text{end}}\) | Rotating-disk correlation, laminar regime |
| Tooth flank | Heat flux + convection | \(q_k,\ h_{\text{flank}}\) | Region-based average heat flux and local convection |
| Tooth tip | Convection | \(h_{\text{tip}}\) | Flat-plate correlation |
| Tooth root | Convection | \(h_{\text{root}}\) | Lubricant immersion correlation |
| Inner bore | Adiabatic or fixed temperature | — | Simplified boundary for steady-state solution |
5. Steady-State Temperature Field of Miter Gears
I solved the steady-state temperature field of the miter gears by using the heat balance equation. Because the gears rotate continuously and reach thermal equilibrium after a short period, I treated the body temperature field as steady. The governing equation is:
$$
\frac{\partial^2 T}{\partial x^2}
+
\frac{\partial^2 T}{\partial y^2}
+
\frac{\partial^2 T}{\partial z^2}
=
0.
$$
The convection boundary condition is:
$$
-k\frac{\partial T}{\partial n}
=
h(T-T_f),
$$
and the combined heat-flux and convection boundary on the tooth flank is:
$$
-k\frac{\partial T}{\partial n}
=
h(T-T_f)-q.
$$
I applied the calculated heat flux and convection coefficients to the finite-element model of the miter gears. I used a region-based loading method. The meshing tooth flank was divided into twenty regions along the profile direction, and the average friction heat flux was applied to each region. The convection coefficient was divided into ten regions along the tooth height. The end faces, tooth tips, and roots were assigned their respective average convection coefficients. I used a hexahedral mesh and a sequential thermal solution. The resulting steady-state temperature field showed a clear non-uniform pattern in the miter gears.
I found that the temperature on the meshing flank is higher than that on the non-meshing flank, and the tooth-flank temperature is higher than the gear-body temperature. The maximum temperature of the driving miter gear reached about 134.5°C, while the maximum temperature of the driven miter gear reached about 98.9°C. The higher temperature of the driving miter gear is caused by its smaller number of teeth, higher meshing frequency, and higher average friction heat flux. The temperature distribution on both miter gears showed a double-peak pattern. The local maxima occurred near the tooth root and tooth tip, and the local minimum occurred near the pitch point. This pattern is consistent with the relative sliding velocity distribution: sliding is large near the root and tip, so friction heat is large there; sliding is small near the pitch point, so friction heat is small there.
To verify the finite-element temperature field, I compared the simulated average body temperature with the integral-temperature result obtained from a standardized gear-temperature calculation. The difference between the simulated average body temperature and the standardized average body temperature was less than 7°C. This agreement supports the reliability of my thermal model for the miter gears. The comparison is summarized in Table 6.
| Quantity | Finite-element maximum | Finite-element average | Standardized average | |
|---|---|---|---|---|
| Driving miter gear body | 134.5°C | 104.2°C | 109.6°C | 5.4°C |
| Driven miter gear body | 98.9°C | 87.6°C | 94.7°C | 7.1°C |
| Driving miter gear flank | 134.5°C | 131.8°C | — | — |
| Driven miter gear flank | 98.9°C | 94.8°C | — | — |
I also extracted the temperature along two paths on the tooth flank. Along the profile direction, the driving miter gear showed a larger temperature variation than the driven miter gear. Along the tooth height direction, the temperature increased from the root toward the tip. These results confirm that the thermal load on high-speed miter gears is concentrated near the addendum and dedendum regions. Therefore, any modification method for miter gears must account for the fact that the tip and root are both thermally and mechanically critical.
6. Thermal-Mechanical Coupling Analysis of Miter Gears
I used a sequential thermal-mechanical coupling method for the miter gears. In this method, I first solved the steady-state temperature field, then imported the temperature field into the structural model as a predefined field, and finally applied the torque and rotational boundary conditions. The coupling relation between thermal strain and stress is:
$$
\varepsilon_T
=
\alpha \Delta T \mathbf{I},
$$
$$
\sigma
=
\mathbf{D}
\left(
\varepsilon-\varepsilon_T
\right),
$$
where \(\alpha\) is the thermal expansion coefficient, \(\Delta T\) is the temperature change, \(\mathbf{D}\) is the elasticity matrix, \(\varepsilon\) is the total strain, and \(\varepsilon_T\) is the thermal strain. I used a face-to-face contact pair between the meshing flanks of the miter gears. For the normal contact behavior, I used hard contact. For the tangential behavior, I used a penalty friction formulation with a friction coefficient of 0.06. I coupled the inner bore surfaces to reference points so that the torque and rotation could be applied without introducing artificial stress concentrations. I used two analysis steps: the first step applied the temperature field, and the second step applied the torque and rotation.
The thermal deformation results showed that the driving miter gear had a maximum thermal deformation of about 6 μm, while the driven miter gear had a maximum thermal deformation of about 4 μm. The deformation was larger at the two ends of the tooth width and smaller in the middle, producing a slight barrel-shaped distribution. This distribution is important because it indicates that the thermal expansion of miter gears is not uniform along the face width. The coupled deformation, which includes both thermal and mechanical effects, was much larger. The maximum coupled deformation of the driving miter gear reached about 28 μm, and the maximum coupled deformation of the driven miter gear reached about 25 μm. The circumferential component dominated the total deformation, while the axial component increased gradually with radius. These values are large enough to change the contact pattern and the load transition of the miter gears.
I then compared the stress state with and without the temperature field. The von Mises stress under thermal-mechanical coupling was slightly higher than that under torque loading alone. In addition, the thermal deformation caused some regions of the miter gears to contact on both sides of the tooth space, which is a clear sign that the coupled deformation changes the effective backlash. Therefore, in the finite-element analysis of high-speed miter gears, it is not sufficient to use a nominal backlash; the thermal-mechanical coupling must be included. The maximum contact stress occurred near the meshing-in position. The driven miter gear showed a larger maximum contact stress than the driving miter gear. Table 7 summarizes the deformation and stress results before modification.
| Response | Driving miter gear | Driven miter gear |
|---|---|---|
| Maximum thermal deformation | 6 μm | 4 μm |
| Maximum coupled deformation | 28 μm | 25 μm |
| Maximum von Mises stress at meshing-in | 1004.776 MPa | — |
| Maximum von Mises stress at meshing-out | 1279.561 MPa | — |
| Maximum contact stress at meshing-in | Lower than driven gear | Higher than driving gear |
| Maximum contact stress at meshing-out | Higher than at meshing-in | Higher than driving gear |
The contact stress distribution of the miter gears showed that the contact line is not uniformly loaded. Because the miter gears have a double-helical arrangement, the contact line moves across the tooth flank as the gears rotate. The thermal deformation and elastic deformation together shift the contact line toward the tip or root at the beginning and end of meshing. This shift increases the local contact stress and accelerates wear. For this reason, I used the coupled deformation at the alternating contact points as the basis for the maximum modification amount of the miter gears.
7. Tooth Profile Modification Based on Coupled Response
I designed the tooth-profile modification of the miter gears by using the thermal-mechanical coupled deformation. The maximum modification amount of the driving miter gear was determined from the coupled deformation when the driving miter gear leaves meshing. The maximum modification amount of the driven miter gear was determined from the coupled deformation when the driven miter gear enters meshing. The calculation gave:
$$
\Delta_{\max,1}
=
\delta_{1D}
+
\delta_{2D}
=
6.56
+
18.24
=
24.80\ \mu m,
$$
$$
\Delta_{\max,2}
=
\delta_{1C}
+
\delta_{2C}
=
4.72
+
17.15
=
21.87\ \mu m.
$$
I selected a long modification length because the miter gears operate at high speed and heavy load. The modification start radius was calculated from the base radius and the distance to the alternating contact point:
$$
r_m
=
\sqrt{
r_b^2
+
\left(
N B – P_b
\right)^2
}.
$$
The corresponding modification height was about 4.5 mm. I applied the modification to the tooth tip of both miter gears. I then compared four modification curves: a linear curve with \(p=1\), a curve with \(p=1.22\), a curve with \(p=1.5\), and a combined linear-quadratic curve. The combined curve was:
$$
\Delta(x)
=
\Delta_{\max}
\left[
0.44
\left(
\frac{x}{L}
\right)
+
0.56
\left(
\frac{x}{L}
\right)^2
\right].
$$
The modification parameters of the miter gears are listed in Table 8.
| Modification item | Driving miter gear | Driven miter gear |
|---|---|---|
| Maximum modification amount | 24.80 μm | 21.87 μm |
| Modification length | Long modification | Long modification |
| Modification height | 4.5 mm | 4.5 mm |
| Candidates curves | \(p=1,\ p=1.22,\ p=1.5\), combined | \(p=1,\ p=1.22,\ p=1.5\), combined |
| Selected curve | Combined linear-quadratic | Combined linear-quadratic |
I found that all modification curves reduced the tooth-flank temperature of the miter gears, but the amount of reduction depended strongly on the curve. The linear curve with \(p=1\) reduced the maximum temperature of the driving miter gear by about 7°C. The curve with \(p=1.22\) reduced it by about 14°C. The curve with \(p=1.5\) reduced it by about 17°C. The combined linear-quadratic curve produced the best result: the maximum temperature of the driving miter gear decreased by about 25°C, from 134.5°C to about 109.2°C, and the maximum temperature of the driven miter gear decreased by about 22°C, from 98.9°C to about 75.5°C. The temperature distribution also shifted slightly along the profile because the modification changed the local sliding and contact pressure. The high-temperature regions near the tip and root moved toward the middle of the flank. This is a beneficial effect because it reduces the risk of scuffing and thermal damage in high-speed miter gears.
The structural response of the miter gears also improved. The modification reduced the maximum coupled deformation, the von Mises stress, and the contact stress. The linear curve reduced the maximum deformation of the driving miter gear by about 8 μm and the driven miter gear by about 6 μm. The combined curve reduced the maximum deformation of the driving miter gear by about 15 μm and the driven miter gear by about 12 μm. The maximum von Mises stress at meshing-in decreased from about 1004.776 MPa to about 709.196 MPa, a reduction of about 29.4%. The maximum von Mises stress at meshing-out decreased from about 1279.561 MPa to about 763.604 MPa, a reduction of about 40.3%. The maximum contact stress of the driving miter gear decreased by about 433 MPa, and the maximum contact stress of the driven miter gear decreased by about 586 MPa. These results show that the combined linear-quadratic modification curve is the most effective for the high-speed wind-turbine miter gears studied here. Table 9 summarizes the performance of the modification curves.
| Modification curve | Driving temperature reduction | Driven temperature reduction | Driving deformation reduction | Driven deformation reduction | Maximum stress reduction |
|---|---|---|---|---|---|
| \(p=1\) | About 7°C | Small | About 8 μm | About 6 μm | Moderate |
| \(p=1.22\) | About 14°C | Moderate | Higher than \(p=1\) | Higher than \(p=1\) | Higher than \(p=1\) |
| \(p=1.5\) | About 17°C | Higher than \(p=1.22\) | Higher than \(p=1.22\) | Higher than \(p=1.22\) | Higher than \(p=1.22\) |
| Combined linear-quadratic | About 25°C | About 22°C | About 15 μm | About 12 μm | 29.4% at meshing-in, 40.3% at meshing-out |
I also examined the contact stress distribution after modification. The modified miter gears showed a smoother contact pattern. The stress concentration near the tooth tip was significantly reduced. The improvement was more obvious for the driving miter gear when it leaves meshing and for the driven miter gear when it enters meshing. This is exactly the intended effect of tooth-profile modification: the modified miter gears avoid the sharp load transition that occurs in the unmodified pair. Because the combined curve gives a gentle transition from zero modification to the maximum value, it matches the gradual deformation of the miter gears better than a simple linear or parabolic curve.
8. Engineering Implications for High-Speed Wind-Turbine Miter Gears
The results of my study have several practical implications for the design of high-speed wind-turbine miter gears. First, the thermal field must be included in the contact analysis of miter gears. The maximum body temperature of the driving miter gear can exceed 130°C, and the thermal deformation can reach several micrometers. This deformation is comparable to the elastic deformation and to the intended modification amount. If the thermal effect is ignored, the modification amount may be underestimated, and the miter gears may still suffer from tip interference and high contact stress. Second, the modification amount should be derived from the coupled deformation at the alternating contact points rather than from a fixed empirical value. The alternating contact points are the locations where the miter gears change from single-tooth contact to multi-tooth contact, and they control the impact behavior. Third, the modification curve should be selected carefully. A linear curve is easy to manufacture but does not match the nonlinear deformation of miter gears. A combined linear-quadratic curve provides a better balance between gradual load transfer and adequate load capacity.
I also observed that the driven miter gear experiences a larger maximum contact stress than the driving miter gear, even though the driving miter gear has a higher temperature. This indicates that the contact stress of miter gears is controlled by both geometry and thermal deformation. The larger contact stress on the driven miter gear suggests that the driven gear may be the limiting component for surface durability. Therefore, when I design a modification scheme for miter gears, I should not optimize only the driving gear. I must evaluate the contact stress on both members and ensure that the modification reduces the peak stress on the more heavily loaded member.
The double-helical arrangement of the miter gears also introduces a special consideration. The two helical halves of the miter gear produce opposite axial forces, so the net axial force is small. However, the thermal deformation along the face width is not perfectly symmetric if the lubricant distribution or the cooling condition is uneven. In my analysis, I assumed a symmetric thermal boundary. In service, the miter gears may experience uneven cooling, oil starvation, or transient load changes. These effects can shift the contact pattern and increase the local temperature. Therefore, a robust modification method for miter gears should include a safety margin for uneven thermal conditions. The modification length should be long enough to cover the alternating contact region, and the maximum modification amount should be based on the worst-case coupled deformation rather than the average value.
From a manufacturing viewpoint, the combined linear-quadratic modification curve is practical. It can be produced by profile grinding, form grinding, or a modified hob. The required maximum modification amounts of the miter gears are approximately 24.80 μm for the driving gear and 21.87 μm for the driven gear, with a modification height of about 4.5 mm. These values are within the capability of modern gear grinding machines. The key is to control the modification curve accurately, because a small error in the curve can change the load transition and the contact stress. I therefore recommend that the modification of high-speed miter gears be verified by a loaded contact pattern test or by a thermal-mechanical finite-element analysis before mass production.
9. Conclusions
I studied the thermal-mechanical coupling and tooth-profile modification of high-speed wind-turbine miter gears. The main conclusions are as follows.
I derived an accurate parametric model of the miter gears using rack-cutter coordinate transformation, involute equations, root transition curve equations, and a double-helical mirror procedure. This model provided the geometric basis for the thermal and structural simulations of the miter gears.
I calculated the relative sliding velocity, contact pressure, friction coefficient, friction heat flux, heat partition, and convection coefficients for the miter gears. The relative sliding velocity is highest near the tooth root and tip and approaches zero near the pitch point. The friction heat flux therefore shows a double-peak distribution on the tooth flank. The convection coefficient of the driving miter gear is higher than that of the driven miter gear at the same speed, and it increases with rotational speed and tooth height.
I solved the steady-state temperature field of the miter gears. The maximum temperature of the driving miter gear was about 134.5°C, and the maximum temperature of the driven miter gear was about 98.9°C. The temperature field showed two peaks on the meshing flank and a local minimum near the pitch point. The finite-element average body temperature agreed with the standardized average body temperature within about 7°C, which validated the thermal model of the miter gears.
I performed a sequential thermal-mechanical coupling analysis of the miter gears. The maximum coupled deformation was about 28 μm for the driving miter gear and about 25 μm for the driven miter gear. The circumferential deformation dominated, and the axial deformation increased with radius. The thermal-mechanical coupling increased the contact stress compared with the torque-only case and caused local two-sided contact because of thermal expansion. The maximum contact stress occurred near the meshing-in position, and the driven miter gear showed a larger maximum contact stress than the driving miter gear.
I designed a tooth-profile modification method for the miter gears based on the coupled deformation. I selected a long modification with a height of about 4.5 mm, a maximum modification amount of 24.80 μm for the driving miter gear, and 21.87 μm for the driven miter gear. I compared linear, power-law, and combined linear-quadratic modification curves. The combined linear-quadratic curve gave the best performance. It reduced the maximum temperature of the driving miter gear by about 25°C and the driven miter gear by about 22°C. It reduced the maximum coupled deformation by about 15 μm for the driving miter gear and about 12 μm for the driven miter gear. It reduced the maximum von Mises stress by about 29.4% at meshing-in and about 40.3% at meshing-out. It also reduced the maximum contact stress by about 433 MPa for the driving miter gear and about 586 MPa for the driven miter gear.
Overall, my study shows that thermal-mechanical coupling is a governing factor in the design of high-speed wind-turbine miter gears. A modification method that uses the coupled deformation as input and a combined linear-quadratic curve as the profile change can significantly improve the thermal state, stress state, and deformation state of miter gears. I believe this approach can support the design of more reliable and longer-life miter gears for wind-turbine gearboxes and other high-speed heavy-duty transmission systems.