
Herringbone gears, also referred to as double helical gears, are a special type of cylindrical gear that consists of two helical gear halves with opposite helix angles. Because of this symmetric design, the axial forces generated by the two halves cancel each other, which eliminates the need for heavy thrust bearings and allows a larger helix angle to be used. As a result, herringbone gears offer a higher overlap ratio, smoother engagement, and a higher load-carrying capacity compared with conventional spur or single helical gears. These advantages make herringbone gears particularly attractive for high-speed, heavy-load applications such as aeronautical transmissions, marine propulsion systems, and industrial power trains.
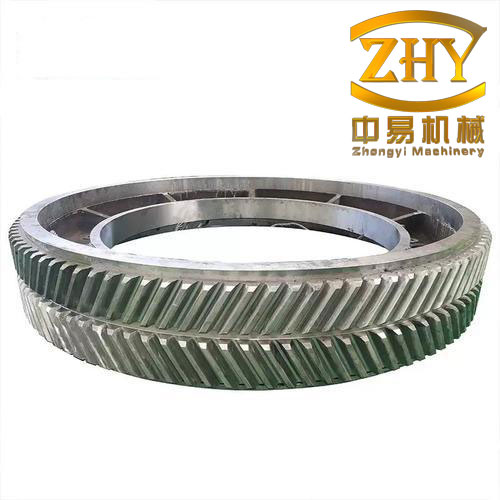
Despite these benefits, herringbone gears are prone to tooth surface fatigue damage, especially scoring and pitting, because the contact stress can be very high at localized regions. In many practical cases, edge contact occurs at the tooth end faces or at the tooth tip/root boundaries, which further increases the stress concentration and accelerates surface failure. To mitigate these problems, tooth modification is one of the most effective approaches. Traditional modifications include profile modification, lead modification, and combined modifications. However, these methods were originally developed for spur gears, where the contact lines are parallel to the gear axis. For herringbone gears, the tooth surfaces are helical, and the contact lines are inclined spiral lines tangent to the base cylinder. Consequently, the interaction between the modification direction and the actual contact-line orientation is not straightforward. A more flexible modification design that accounts for the meshing characteristics of herringbone gears is therefore needed.
In this work, we focus on the topological modification of herringbone gear tooth surfaces. We first derive the theoretical tooth surface equation of the helical flank. Then we analyze the meshing process of a herringbone gear pair and identify the key geometric features of the contact lines. Based on this analysis, we propose a new topological modification method in which the modification amount is designed along the contact-line direction and then mapped onto the tooth surface through an affine transformation. This method allows us to control the contact-line length and the number of contact lines independently, which is more consistent with the actual meshing process of herringbone gears.
To demonstrate the effectiveness of the proposed method, we compare it with conventional profile modification, lead modification, and combined modification using finite element contact analysis. The results show that the topological modification produces a more uniform contact pattern and reduces the maximum contact stress by approximately 15% while preserving the overlap ratio. In addition, we extend the method to a system-level split-torque herringbone gear transmission. Because the system contains multiple gear pairs, the simulation is computationally expensive and the modeling process is repetitive. We therefore develop a parametric finite element modeling technique that automatically generates gear meshes and finite element input files. With this automation, different design parameters can be evaluated in parallel, and the optimization process becomes much more efficient.
Finally, we investigate the manufacturability of the proposed topology-modified tooth surfaces using disc wheel grinding. We derive the disc wheel profile from the theoretical herringbone gear tooth surface and construct a five-axis CNC machining model. By introducing high-order polynomial motions for each machine axis, we can approximate the desired topological modification. Machining and measurement experiments are carried out, and the results confirm that the proposed topological modification can be manufactured with acceptable accuracy. Contact-pattern experiments also show good agreement with the finite element predictions, which validates the simulation methodology.
1 Introduction
The transmission system is one of the most critical components in rotating machinery. In aeronautical applications, the main gearbox must be lightweight, efficient, and highly reliable. Herringbone gears have been widely adopted in helicopter main gearboxes, marine reduction gearboxes, and industrial gear units because they provide a large torque-transmitting capacity in a compact arrangement. The main reason is that the two mirrored helical flanks of a herringbone gear eliminate the net axial force, so the thrust bearing can be simplified or even omitted. At the same time, the helix angle can be increased to achieve a higher overlap ratio, which improves smoothness and reduces noise and vibration.
Nevertheless, the contact conditions of herringbone gears are severe. The tooth surface contact is nominally a line contact, but under load the line spreads into a rectangular or elliptical contact area. Without modification, edge contact often appears at the tooth ends because of misalignment, shaft deflections, and bearing deformations. Edge contact causes a high stress concentration that can lead to premature pitting, micro-pitting, or tooth surface fatigue. Therefore, tooth modification is an essential step in the design of high-performance herringbone gears.
1.1 Literature review
Tooth modification has been studied for several decades. Walker was one of the first to propose profile modification for spur gears, focusing on the removal of material near the tooth tip to reduce the engagement shock. With the development of computer-aided engineering, many researchers began to optimize profile modification and lead modification using gear contact analysis and finite element analysis. For example, Tavakoli and Houser computed the static transmission error of spur gears and proposed optimization methods for profile modification. Bonori and Pellicano used genetic algorithms to optimize profile modifications for vibration reduction. Sun Yuehai and co-workers experimentally investigated profile modifications and their effects on noise and dynamic load. These works established the foundation for modern gear modification design.
For helical gears and herringbone gears, the contact line is an inclined spiral on the tooth surface. Therefore, the conventional mutually perpendicular profile and lead modifications are not necessarily optimal. The concept of diagonal modification was introduced to address this issue. Diagonal modification removes material from the two opposite corners of the tooth flank, where the gear teeth engage and disengage. In this way, the modification is roughly aligned with the contact lines, and the overlap ratio can be maintained more precisely. Several studies have shown that diagonal modification can reduce the mesh impact and improve the transmission error characteristics of helical gears.
Topological modification is a more general and flexible approach. Instead of separating the profile and lead directions, the entire tooth surface is represented as a grid of discrete points, and each point can have a prescribed normal deviation. The resulting modification surface is often called an ease-off surface. Topological modification can realize arbitrary smooth deviations from the ideal involute surface, but the design parameters are numerous and the relation to the meshing process is not always clear. Litvin and co-workers proposed topologically modified involute helical gears with a combined crowning pattern. Fang Zongde and co-workers studied three-dimensional modifications for helical gears and suggested that topological modification is necessary because the contact lines are inclined.
Most of the existing topological modification methods for cylindrical gears are based on polynomial representations in the tooth coordinate system. The polynomial coefficients have intuitive meanings: linear terms correspond to pressure-angle and helix-angle corrections, quadratic terms correspond to profile crowning and lead crowning, and the cross term represents flank twist. However, these methods still do not fully exploit the actual contact-line orientation of herringbone gears.
1.2 Objectives of this work
The main objective of this work is to develop a topological modification design method that is directly based on the meshing characteristics of herringbone gears. We aim to:
- Derive the theoretical tooth surface model of a herringbone gear flank and analyze the geometry of the contact lines.
- Propose a topological modification method that can control the contact-line length and the number of contact lines independently.
- Verify the proposed method using finite element contact analysis and compare it with conventional modification approaches.
- Extend the method to a system-level split-torque herringbone gear transmission and develop an efficient parametric modeling procedure for optimization.
- Investigate the manufacturing feasibility using disc wheel grinding on a five-axis CNC machine, including theoretical derivation and experimental validation.
2 Theoretical modeling of herringbone gear tooth surface
To design a meaningful topological modification, we need an accurate mathematical description of the theoretical gear tooth surface. A herringbone gear flank is a helical involute surface. The generation process can be described by sweeping a plane involute curve along a helical path around the gear axis.
2.1 Involute curve and helical tooth surface
The involute curve in the transverse plane is generated by a straight line rolling without slipping on the base circle of radius $r_b$. In the coordinate system $S_a(x_a,y_a,z_a)$, the involute curve can be expressed as:
$$
\begin{cases}
x_a(\phi) = r_b (\sin\phi – \phi \cos\phi) \\
y_a(\phi) = r_b (\cos\phi + \phi \sin\phi)
\end{cases}
$$
where $\phi$ is the roll angle. In a more convenient form, we can write the involute profile as:
$$
\mathbf{r}_a(\phi) = \begin{bmatrix} r_b(\sin\phi – \phi\cos\phi) \\ r_b(\cos\phi + \phi\sin\phi) \\ 0 \\ 1 \end{bmatrix}
$$
To obtain a helical tooth surface, this planar curve is rotated and translated along the gear axis with a constant screw parameter $p$. The helical motion can be represented by the transformation matrix:
$$
\mathbf{M}_{1a}(\psi) = \begin{bmatrix}
\cos\psi & -\sin\psi & 0 & 0 \\
\sin\psi & \cos\psi & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}
\begin{bmatrix}
1 & 0 & 0 & 0 \\
0 & 1 & 0 & 0 \\
0 & 0 & 1 & p\psi \\
0 & 0 & 0 & 1
\end{bmatrix}
$$
Let $u = p\psi$. Then the helical involute surface can be written as:
$$
\mathbf{r}_1(\phi,u) = \begin{bmatrix}
x_1 \\ y_1 \\ z_1 \\ 1
\end{bmatrix}
= \begin{bmatrix}
\cos(u/p) & -\sin(u/p) & 0 & 0 \\
\sin(u/p) & \cos(u/p) & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}
\begin{bmatrix}
x_a(\phi) \\ y_a(\phi) \\ 0 \\ 1
\end{bmatrix}
$$
Thus, the tooth surface point coordinates are:
$$
\begin{aligned}
x_1 &= x_a(\phi)\cos(u/p) – y_a(\phi)\sin(u/p) \\
y_1 &= x_a(\phi)\sin(u/p) + y_a(\phi)\cos(u/p) \\
z_1 &= u
\end{aligned}
$$
The unit normal vector of the tooth surface is obtained by taking the cross product of the partial derivatives and normalizing:
$$
\mathbf{n}_1(\phi,u) = \frac{\frac{\partial \mathbf{r}_1}{\partial \phi} \times \frac{\partial \mathbf{r}_1}{\partial u}}{\left| \frac{\partial \mathbf{r}_1}{\partial \phi} \times \frac{\partial \mathbf{r}_1}{\partial u} \right|}
$$
This theoretical surface is used as the baseline for all subsequent modification calculations.
2.2 Meshing characteristics of herringbone gears
The meshing process of a herringbone gear is essentially the same as that of a helical gear, except that two mirrored helical flanks engage simultaneously. In an ideal involute helical gear pair, the instantaneous contact lines are straight lines in the tangent plane, but in three-dimensional space they are spiral lines tangent to the base cylinder. When the tooth surfaces are developed onto a plane, the contact lines appear as a series of parallel inclined lines. The inclination angle is equal to the base helix angle $\beta_b$.
Because of the inclination, the contact lines of a helical gear have different lengths during the mesh cycle. Some contact lines are completely contained within the tooth surface, while others start or end at the tooth end faces and at the tip/root boundaries. This is fundamentally different from spur gears, where all contact lines have the same length and are parallel to the gear axis.
In the conventional design framework, profile modification affects the contact lines near the tooth tip and root, while lead modification affects the contact lines near the tooth ends. For a spur gear, these two modification directions are perpendicular to the contact lines. For a herringbone gear, however, the contact lines are inclined, so the profile and lead modifications are neither parallel nor perpendicular to the contact lines. Consequently, a profile modification may unintentionally reduce the effective contact-line length, and a lead modification may also change the number of active contact lines. This coupling makes it difficult to achieve a desired contact pattern using conventional methods.
| Gear type | Contact-line orientation | Contact-line length | Conventional modification effectiveness |
|---|---|---|---|
| Spur gear | Parallel to gear axis | Constant | High |
| Single helical gear | Inclined spiral | Variable | Moderate |
| Herringbone gear | Two mirrored inclined spirals | Variable | Moderate |
The inclined contact-line pattern suggests that a modification method designed along the contact-line direction would be more appropriate for herringbone gears. In the following section, we propose such a method.
3 Topological modification based on meshing characteristics
Topological modification is a flexible way to define an arbitrary smooth deviation from the theoretical tooth surface. In this work, we describe the modification amount using a second-order surface equation. The modification amounts are defined on a rectangular grid over the tooth surface, where the horizontal and vertical axes are normalized coordinates along the face width and the profile direction.
3.1 Representation of modification surface
Let $(X,Y)$ be the normalized coordinates on the tooth surface, where $X \in [-1,1]$ represents the face-width direction and $Y \in [-1,1]$ represents the profile (involute length) direction. The modification amount $Z$ is positive when material is removed. We define the modification surface as:
$$
Z = a_1 X + a_2 Y + a_3 X^2 + a_4 Y^2 + a_5 X Y
$$
The five coefficients have clear geometric meanings:
- $a_1$: linear term in $X$, which adjusts the helix angle
- $a_2$: linear term in $Y$, which adjusts the pressure angle
- $a_3$: quadratic term in $X$, corresponding to lead crowning
- $a_4$: quadratic term in $Y$, corresponding to profile crowning
- $a_5$: cross term, which controls the tooth surface twist
For a herringbone gear, the two helical flanks must be modified symmetrically to avoid internal stress. If the right-handed flank is described by the equation above, the left-handed flank should use the mirrored coefficients:
$$
Z_L = -a_1 X + a_2 Y – a_3 X^2 + a_4 Y^2 – a_5 X Y
$$
This ensures the modification is symmetric with respect to the central plane of the herringbone gear.
3.2 Proposed contact-line-oriented modification
To make the modification more consistent with the meshing process, we introduce an auxiliary coordinate system $(X_t, Y_t)$ where the $X_t$ axis is parallel to the contact-line direction and the $Y_t$ axis is perpendicular to it. In this coordinate system, we can define the modification amount in a way that directly controls the length and position of the contact lines. For example, we can use:
$$
Z_t = a_{1t} X_t + a_{2t} Y_t + a_{3t} X_t^2 + a_{4t} Y_t^2 + a_{5t} X_t Y_t
$$
The transformation between the tooth-surface coordinate system and the contact-line-oriented coordinate system is an affine transformation:
$$
\begin{bmatrix} X_t \\ Y_t \\ 1 \end{bmatrix} = \mathbf{T} \begin{bmatrix} X \\ Y \\ 1 \end{bmatrix}
$$
where $\mathbf{T}$ is a $3\times3$ matrix that includes scaling, shearing, and translation. To preserve the orthogonality of the coordinate axes, the transformation matrix can be written as:
$$
\mathbf{T} = \begin{bmatrix}
n & k & 0 \\
-k & n & 0 \\
0 & 0 & 1
\end{bmatrix}
$$
Here $n$ and $k$ determine the scaling and rotation of the coordinate system. The relationship between $n$ and $k$ should be chosen so that the $X_t$ axis is aligned with the base helix direction. Since the $X_t$ axis should make an angle $\beta_b$ with the gear axis, we have:
$$
k = n \tan\beta_b
$$
Using this transformation, a modification surface designed in the contact-line-oriented system can be mapped back to the physical tooth surface. In this way, the desired modification pattern is automatically aligned with the contact lines.
For instance, if we want to reduce the contact-line length, we choose $a_{3t}$ to be positive. If we want to control the number of active contact lines near the mesh-in and mesh-out regions, we choose $a_{4t}$ to be positive. The sign and magnitude of the coefficients can be determined based on the desired load distribution.
3.3 Comparison with traditional modifications
To evaluate the proposed method, we performed a series of finite element contact analyses on a herringbone gear pair. The basic parameters of the gear pair are listed in Table 2.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth | 27 | 107 |
| Normal module (mm) | 2.75 | 2.75 |
| Helix angle (deg) | 30 | 30 |
| Normal pressure angle (deg) | 22.5 | 22.5 |
| Profile shift coefficient | 0.1672 | -0.2120 |
| Total face width (mm) | 70 | 70 |
| Tooth number of herringbone half | 27 | 107 |
We designed seven cases to compare the different modification strategies. The cases are summarized in Table 3.
| Case | Modification type | Description |
|---|---|---|
| Case 1 | None | Theoretical involute surface |
| Case 2 | Profile (tip relief) | Linear profile modification near tooth tip |
| Case 3 | Lead crowning | Parabolic lead modification |
| Case 4 | Combined | Superposition of Cases 2 and 3 |
| Case 5 | Topological along mesh direction | Modification designed along the contact-line perpendicular direction |
| Case 6 | Topological along contact-line length | Modification designed along the contact-line direction |
| Case 7 | Combined topological | Superposition of Cases 5 and 6 |
The maximum modification amount was kept the same for all modified cases to allow a fair comparison. Finite element models were built using the parametric gear mesh generation technique described later. The contact stress, transmission error, and overlap ratio were extracted from the simulations.
Figure below shows the contact stress contours at a particular instant for Cases 1, 4, and 7. The unmodified gear exhibits strong edge contact, with a maximum contact stress exceeding 1600 MPa. The combined modification (Case 4) reduces the stress to about 1035 MPa, but the high-stress region is not perfectly centered and has an irregular four-sided shape. In contrast, the proposed combined topological modification (Case 7) produces an elliptical, centered high-stress region and lowers the maximum contact stress to approximately 894 MPa, which is about 15% lower than Case 4.
| Case | Maximum contact stress (MPa) | Overlap ratio (heavy load) |
|---|---|---|
| Case 1 (no modification) | 1653 | 3.83 |
| Case 4 (combined conventional) | 1035 | 3.50 |
| Case 7 (combined topological) | 894 | 3.56 |
The overlap ratio of Case 7 is slightly higher than that of Case 4, which indicates that the topological modification preserves the load-sharing capability better than the conventional combined modification. This result confirms that the proposed method is beneficial for herringbone gears.
4 System-level optimization of a split-torque herringbone gear transmission
After demonstrating the advantages of the topological modification at the gear-pair level, we apply the method to a more complex system: a split-torque herringbone gear transmission used in helicopter main gearboxes. This system consists of multiple gear pairs arranged symmetrically to split the input power into two branches and then merge it again at the output. Due to the symmetry and the use of herringbone gears, axial forces are balanced and bearing arrangements are simplified.
4.1 System description
The split-torque transmission considered in this study contains four meshing gear pairs arranged in two stages. The input pinion $Z_1$ meshes with two identical gears $Z_{2L}$ and $Z_{2R}$, which are located on the left and right branches. Each of these gears is connected to a second-stage pinion $Z_{3L}$ or $Z_{3R}$ through a torsional elastic shaft. The second-stage pinions mesh with the output gear $Z_4$. The gear parameters are listed in Table 5.
| Parameter | $Z_1$ | $Z_2$ | $Z_3$ | $Z_4$ |
|---|---|---|---|---|
| Number of teeth | 27 | 107 | 29 | 115 |
| Normal module (mm) | 2.75 | 2.75 | 4.187 | 4.187 |
| Helix angle (deg) | 30 | 30 | 30 | 30 |
| Normal pressure angle (deg) | 22.5 | 22.5 | 22.5 | 22.5 |
| Profile shift coefficient | 0.1672 | -0.2120 | 0.0463 | -0.0585 |
| Face width (mm) | 70 | 70 | 100 | 100 |
| Input torque (N·m) | 2175 | – | – | – |
To build the system-level finite element model, we first determine the relative positions of all gear axes. The assembly angles satisfy several geometric conditions, including collinearity of the elastic shafts, interference avoidance, and a closure condition for the closed loop formed by the two branches. After solving these equations, we obtain the exact coordinates for assembling the gear components in the finite element package.
4.2 Parametric finite element modeling
System-level gear finite element analysis is usually time-consuming to set up because of the large number of parts and contact interfaces. To make the optimization process practical, we developed an automated modeling procedure. The key idea is to generate the gear mesh directly from the gear design parameters, including the topological modification coefficients, without building a CAD model. This avoids repeated geometry clean-up and mesh generation steps.
The gear mesh generation procedure works as follows. First, the tooth surface points are calculated using the analytical expression of the modified tooth surface. Then, a “rice-shaped” zone is defined around each tooth to create a structured hexahedral mesh. The remaining parts of the gear blank are coarsened to reduce the element count. The node numbering is fully controlled by the program, so the mesh topology remains the same for different modification parameters.
Once the first simulation model is created, the subsequent models can be generated by simply replacing the coordinate values of the node sets in the input file. This is possible because the modification amount is usually in the range of a few micrometers, which does not change the overall geometry enough to require re-meshing. As a result, we can directly edit the INP file for each design iteration.
For the post-processing, we wrote a Python script for Abaqus that automatically extracts the maximum contact stress, transmission error, and contact patterns from the output database. This script uses the fixed node numbering to locate the tooth surfaces and therefore works for all design variants.
4.3 Optimization of topological modification parameters
Using the parametric modeling framework, we optimized the topological modification coefficients for all gears in the split-torque system. The optimization objective was to minimize the maximum contact stress on all tooth surfaces, subject to constraints on the contact pattern and the overlap ratio. Because the system is symmetric, the left and right branch gears were assumed to have the same modification parameters.
The optimization was performed in a parallel computing environment. Several design candidates with different combinations of $a_{3t}$ and $a_{4t}$ were evaluated simultaneously. After the first round, the best candidates were refined by slightly adjusting $a_{1t}$ and $a_{2t}$ to center the contact pattern. The final optimized coefficients are listed in Table 6.
| Gear | $a_{o1}$ | $a_{o2}$ | $a_{o3}$ | $a_{o4}$ | $a_{o5}$ |
|---|---|---|---|---|---|
| $Z_1$ | 0 | -3.0 | 11.0 | 18.3 | -13.0 |
| $Z_{2L}$ / $Z_{2R}$ | 0 | 3.0 | 12.0 | 18.5 | -12.7 |
| $Z_{3L}$ / $Z_{3R}$ | 0 | -3.0 | 13.0 | 21.0 | -15.5 |
| $Z_4$ | 0 | 3.0 | 13.0 | 20.8 | -15.2 |
The simulation results show that the unmodified system exhibits severe edge contact and high contact stresses, especially in the first stage. After applying the optimized topological modification, the maximum contact stress on each gear is reduced significantly. Table 7 summarizes the maximum contact stresses before and after optimization.
| Gear flank | Before (MPa) | After (MPa) |
|---|---|---|
| $Z_1$ left flank | 2104 | 909 |
| $Z_{2L}$ left flank | 2162 | 969 |
| $Z_{3R}$ right flank | 1736 | 821 |
| $Z_4$ right flank | 1542 | 776 |
The optimized modification reduces the maximum stress by about 50% compared with the unmodified case. The high-stress regions are moved away from the tooth edges and are more uniformly distributed. The remaining stress levels are well within the allowable range for typical gear steels at the given load.
The parametric finite element modeling procedure greatly reduces the human effort required for repeated analysis. Instead of manually rebuilding the model for every new set of modification parameters, we can generate the entire finite element model automatically and run multiple designs in parallel. This approach is especially useful in the early design stage, where many candidate designs need to be evaluated quickly.
5 Disc wheel grinding of topological modified herringbone gears
To verify that the designed topological modification can be manufactured, we studied the disc wheel grinding process for herringbone gears. In this process, a disc-shaped grinding wheel is used to machine the tooth flank. The wheel profile must be calculated from the theoretical gear tooth surface and the relative motion between the wheel and the workpiece.
5.1 Form grinding principle
In form grinding, the grinding wheel has a profile that is the conjugate of the desired tooth surface. The wheel is positioned so that its axis lies in the plane perpendicular to the gear axis and forms the helix angle with the gear tooth. During grinding, the wheel rotates about its own axis, and the workpiece rotates slowly in synchronization with the axial feed movement to generate the helical tooth surface.
For a herringbone gear, each flank is ground separately by changing the wheel orientation to the opposite helix angle. The small gap between the two herringbone halves provides space for wheel run-out and prevents interference.
5.2 Calculation of the disc wheel profile
To find the disc wheel profile, we start from the known theoretical tooth surface of the involute helical gear. The contact between the grinding wheel and the tooth surface is a line coinciding with the instantaneous contact line. Because the wheel is a surface of revolution, the contact line is the intersection of the gear tooth surface with a plane perpendicular to the wheel axis. Consequently, we can derive the wheel profile by considering the meshing equation:
$$
\mathbf{n}_1 \cdot \mathbf{v}_{rel} = 0
$$
where $\mathbf{n}_1$ is the unit normal vector of the tooth surface and $\mathbf{v}_{rel}$ is the relative velocity between the wheel and the tooth surface at the contact point. After solving this equation numerically, we obtain a set of points on the wheel surface. The wheel profile is then obtained by projecting these points onto the axial cross-section of the wheel.
The discrete wheel profile can be fitted with a high-order polynomial:
$$
b_p(u_p) = k_0 + k_1 u_p + k_2 u_p^2 + \cdots + k_n u_p^n
$$
where $u_p$ is the radial coordinate and $b_p$ is the axial coordinate of the wheel profile. This polynomial representation simplifies the subsequent calculation of the ground tooth surface.
5.3 Five-axis CNC grinding and high-order motion
To generate an arbitrary topological modification, the simple constant-feed motion is not sufficient. We therefore used a five-axis CNC form grinding machine with three translational axes ($X$, $Y$, $Z$), one wheel swivel axis ($B$), and one workpiece rotary axis ($C$). The five-axis motion equations in terms of the workpiece rotation angle $\phi_1$ can be expressed as high-order polynomials:
$$
\begin{aligned}
C_x(\phi_1) &= a_{x0} + a_{x1}\phi_1 + a_{x2}\phi_1^2 + a_{x3}\phi_1^3 + a_{x4}\phi_1^4 + a_{x5}\phi_1^5 \\
C_y(\phi_1) &= a_{y0} + a_{y1}\phi_1 + a_{y2}\phi_1^2 + a_{y3}\phi_1^3 + a_{y4}\phi_1^4 + a_{y5}\phi_1^5 \\
C_z(\phi_1) &= a_{z0} + a_{z1}\phi_1 + a_{z2}\phi_1^2 + a_{z3}\phi_1^3 + a_{z4}\phi_1^4 + a_{z5}\phi_1^5 \\
C_b(\phi_1) &= a_{b0} + a_{b1}\phi_1 + a_{b2}\phi_1^2 + a_{b3}\phi_1^3 + a_{b4}\phi_1^4 + a_{b5}\phi_1^5 \\
C_c(\phi_1) &= a_{c0} + a_{c1}\phi_1 + a_{c2}\phi_1^2 + a_{c3}\phi_1^3 + a_{c4}\phi_1^4 + a_{c5}\phi_1^5
\end{aligned}
$$
The zeroth-order terms are the initial machine settings, and the higher-order coefficients are the unknowns to be determined. The influence of each coefficient on the resulting tooth surface error can be represented by a sensitivity matrix. For a target topological modification, we can set up a system of linear equations:
$$
\left\{ \delta R_i \right\} = \left[ S_{ij} \right] \left\{ \delta \zeta_j \right\}
$$
where $\delta R_i$ is the desired normal deviation at the $i$-th grid point, $\delta \zeta_j$ is the change in the $j$-th machine motion coefficient, and $S_{ij}$ is the sensitivity coefficient. Since the number of grid points is larger than the number of unknown coefficients, the system is overdetermined. We used a sequential quadratic programming method to solve the least-squares problem with constraints that keep the machine motions stable.
We applied this approach to grind the optimized topological modification for gear $Z_3$ from the split-torque system. The designed and actual modification surfaces were compared, and the residual error was found to be less than 8 micrometers. This demonstrates that the proposed topological modification can be realized with high accuracy using five-axis disc wheel grinding.
6 Experimental validation
To further validate the feasibility of the proposed design and the correctness of the finite element simulation, we conducted machining and contact-pattern experiments on a physical herringbone gear specimen.
6.1 Machining and measurement experiment
The test specimen was the second-stage pinion $Z_3$ from the split-torque transmission. The gear was first rough-machined and heat-treated, then finish-ground using the five-axis form grinding machine. A small disc wheel with a diameter of 60 mm was selected to avoid interference with the herringbone flanks. The grinding wheel profile was dressed according to the calculated polynomial coefficients.
After grinding, the tooth surfaces were measured on a coordinate measuring machine. Five profile sections and nine lead positions were selected on each flank. The measured deviations from the theoretical surface were plotted as a contour map. The maximum deviation was within 8 micrometers, which is acceptable for high-performance herringbone gears. The edge areas showed slightly larger deviations, which is consistent with the expected principle error of the five-axis high-order motion.
| Flank | Max deviation (μm) | Mean deviation (μm) | Standard deviation (μm) |
|---|---|---|---|
| Left-handed flank | 7.8 | 3.2 | 2.1 |
| Right-handed flank | 8.1 | 3.6 | 2.4 |
6.2 Contact pattern testing
The ground herringbone gear pair was mounted on a back-to-back gear test rig. The tooth surfaces of the pinion were coated with a thin layer of marking compound, and the gears were run under a gradually increasing load until the rated torque was reached. After running for a short period, the gears were disassembled and the contact patterns were inspected.
The observed contact patterns were compared with the finite element predictions. For the unmodified gear pair, the contact pattern was concentrated at the tooth edges, indicating severe edge contact. For the topologically modified gear pair, the contact pattern was centered on the tooth flank and had an elliptical shape, which matches the simulation result well. The contact area covered a large portion of the tooth surface without touching the edges, confirming that the proposed modification successfully improves the contact behavior.
| Condition | Simulation | Experiment |
|---|---|---|
| Unmodified | Edge contact, high stress | Edge wear, concentrated marking |
| Topological modification | Centered elliptical contact | Centered elliptical marking |
The good agreement between the simulation and the experiment validates the finite element contact analysis procedure and confirms the practical value of the proposed topological modification method for herringbone gears.
7 Conclusion
In this work, we studied the design, simulation, and manufacturing of topological modifications for herringbone gears. The main conclusions are summarized as follows:
- We derived the theoretical tooth surface equation for a herringbone gear flank and analyzed its meshing process. The contact lines on a herringbone gear tooth surface are inclined spirals, which makes conventional profile and lead modifications less effective.
- We proposed a new topological modification method in which the modification amount is defined along the contact-line direction and then mapped to the tooth surface through an affine transformation. This method allows independent control of the contact-line length and the number of contact lines. Finite element contact analyses showed that the proposed method reduces the maximum contact stress by about 15% compared with a conventional combined modification, while maintaining similar or slightly better overlap ratio.
- We developed a parametric finite element modeling procedure for a split-torque herringbone gear transmission. The automated mesh generation and input file editing greatly reduce the human effort in system-level simulations. Using parallel evaluation, we optimized the topological modification parameters for all gears in the system. The optimized design reduced the maximum contact stress by approximately 50% compared with the unmodified baseline.
- We derived the disc wheel profile for form grinding of herringbone gears and implemented a five-axis CNC high-order motion algorithm to generate the desired topological modification. Machining and measurement experiments confirmed that the proposed topological modification is manufacturable with an accuracy of about 8 micrometers.
- Contact-pattern experiments on the ground gears showed good agreement with finite element predictions, validating both the design method and the simulation approach.
Future work will focus on improving the computational efficiency of the system-level finite element model so that more sophisticated optimization algorithms can be applied automatically. The influence of herringbone gear manufacturing asymmetry on the meshing characteristics will also be investigated, together with the development of more robust grinding strategies for topology-modified flanks.