
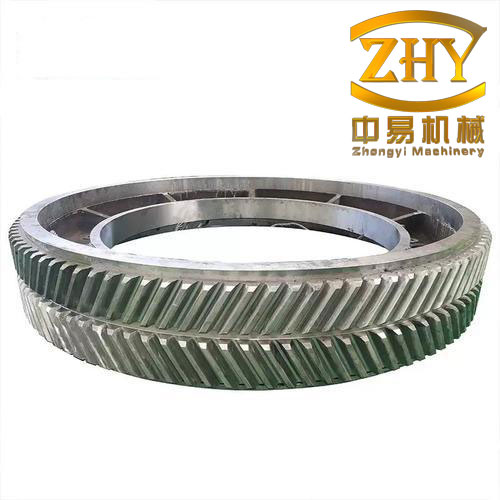
Herringbone gears are widely adopted in high-speed and heavy-duty marine transmission systems due to their excellent load-carrying capacity, compact structure, and inherent axial force cancellation. However, the vibration and noise generated by herringbone gear pairs remain a critical issue for the acoustic stealth performance of ships. Among various tooth surface modification techniques, triangular end relief, also known as diagonal modification, has been proven to effectively reduce meshing impact force and loaded transmission error fluctuation, thereby suppressing gear whine. In this work, we systematically investigated the optimum design of triangular end relief for herringbone gears, its realization by form grinding with a three-section grinding wheel, and its dynamic performance through both numerical simulation and experiments. The entire study is presented from the perspective of a master’s thesis research project, with an emphasis on the theoretical derivation, optimization algorithms, machining principles, dynamic modeling, and experimental validation.
1. Introduction and Motivation
With the increasing competition in the international maritime environment, more stringent requirements have been imposed on the vibration and noise levels of ship propulsion systems. Herringbone gears are one of the main noise sources in the transmission chain. The internal excitations that cause gear vibration include the time-varying mesh stiffness and the meshing impact force at the entry/exit of engagement. These excitations propagate through the gear body, shafts, bearings, and housings, generating audible noise and structural vibration. Tooth surface modification is a practical and effective approach to reduce these unwanted excitations. Conventional profile and lead modifications have been widely used, but they often reduce the effective contact area and increase contact stress. Triangular end relief, on the other hand, removes material only in the tooth tip and tooth root regions along the direction of the contact line, leaving the middle part of the flank unaffected. This preserves a large effective contact area while mitigating the entry and exit impacts.
The objective of this thesis is to develop a complete design and manufacturing procedure for triangular end relief of herringbone gears. The main contributions include: (1) establishing a parametric model of the triangular end relief tooth surface based on the ISO definition; (2) performing multi-objective optimization to minimize loaded transmission error fluctuation and meshing impact force; (3) proposing a novel three-section grinding wheel method to realize triangular end relief on a CNC form grinding machine; (4) constructing a 12-degree-of-freedom dynamic model of the herringbone gear pair to evaluate the vibration reduction; and (5) verifying the theoretical predictions by experiments on a loaded transmission error test rig and a high-speed enclosed gearbox test rig.
2. Design of Triangular End Relief for Herringbone Gears
2.1 Standard Tooth Surface Equation
The standard involute tooth surface of a herringbone gear can be generated by a virtual rack cutter. The coordinate system for the generation of a left-hand helical flank of the workpiece is established. The position vector and unit normal vector of the standard flank in the gear coordinate system \(S_i\) are expressed as:
$$ \mathbf{r}_{ti}(u_i,l_i,\theta_i) = \mathbf{M}_{i,ti}(\theta_i)\mathbf{r}_{ti}(u_i,l_i), \qquad \mathbf{n}_{ti}(u_i,l_i,\theta_i) = \mathbf{L}_{i,ti}(\theta_i)\mathbf{n}_{ti}(u_i,l_i) $$
where \(u_i\) and \(l_i\) are the surface parameters of the rack cutter, \(\theta_i\) is the gear rotation angle, \(\mathbf{M}_{i,ti}\) is the coordinate transformation matrix from the rack cutter reference frame to the gear rotating frame, and \(\mathbf{L}_{i,ti}\) is the corresponding rotation sub-matrix. The meshing equation is obtained by applying the envelope condition:
$$ f(u_i,l_i,\theta_i) = \frac{\partial \mathbf{r}_{ti}}{\partial \theta_i} \cdot \mathbf{n}_{ti} = 0 $$
For the fillet surface, a similar derivation is performed using the rack cutter tip rounding, resulting in the transition surface equation with the parameter \(\varphi_i\). Once the right flank is generated, the left flank is obtained by mirroring with respect to the plane perpendicular to the gear axis at the center of the gap, thus forming the complete herringbone gear model.
2.2 Parametric Model of Triangular End Relief
According to ISO 21771:2007, the triangular end relief is characterized by the tip relief height \(L_{Ea}\), tip relief amount \(C_{Ea}\), root relief height \(L_{Ef}\), and root relief amount \(C_{Ef}\). The modification zone is bounded by the start lines \(BC\) and \(EF\) on the tooth tip and root, respectively, which are approximately straight lines on the rotational projection plane. The helix angles of these start lines, denoted as \(\beta_a\) and \(\beta_f\), are determined from the projected geometry. In this study, the modification curve along the direction perpendicular to the start line is taken as either a linear function or a quadratic parabola. For any point \(P\) inside the modification zone, the modification amount \(\delta\) is given by:
$$ \delta(z,x’) = \begin{cases} \displaystyle C_{Ea}\left(\frac{l_p}{l_a}\right)^{k_a}, & P \in \triangle ABC \\[6pt] \displaystyle C_{Ef}\left(\frac{l_p}{l_f}\right)^{k_f}, & P \in \triangle DEF \\[6pt] 0, & \text{otherwise} \end{cases} $$
where \(l_p\) is the distance from point \(P\) to the modification start line, \(l_a\) and \(l_f\) are the total modification lengths in the tip and root zones, and \(k_a, k_f\) are the power exponents (\(k=1\) for linear, \(k=2\) for quadratic parabola). The triangular end relief tooth surface is then obtained by adding the modification amount along the unit normal vector of the standard flank:
$$ \mathbf{r}_{1m}(u_1,l_1,\theta_1) = \mathbf{r}_1(u_1,l_1,\theta_1) + \delta\left(z,x’\right)\mathbf{n}_1(u_1,l_1,\theta_1) $$
The same procedure is applied to both the left and right flanks of the two helical sides of the herringbone pinion. Only the pinion is modified, while the gear is kept as a standard involute flank.
2.3 Loaded Transmission Error and Meshing Impact Force
The loaded transmission error (LTE) of the gear pair is determined by the loaded tooth contact analysis (LTCA). The tooth contact analysis (TCA) provides the initial separations along the contact lines. A three-dimensional finite element meshing of the contacting tooth surfaces is used to obtain the flexibility matrices. The load distribution is solved by a mathematical programming method under the displacement compatibility and force equilibrium conditions. The loaded transmission error is expressed in arc-seconds as:
$$ T_e = \frac{23600 \times 180}{\pi r_{bi} \cos\beta} Z_k $$
where \(Z_k\) is the normal displacement along the line of action and \(r_{bi}\) is the base circle radius of the considered gear. The loaded transmission error fluctuation is defined as:
$$ \Delta T_e = \max(T_e) – \min(T_e) $$
The meshing impact force is evaluated based on the actual entry point that deviates from the theoretical line of action due to tooth deflection and modification. By applying the energy conservation law at the instant of impact, the maximum impact force can be derived as:
$$ F_s = v_{12}\sqrt{\frac{J_1 J_2}{J_2 r_{b1}^2 + J_1 r_{b2}^2} k_s} $$
where \(v_{12}\) is the relative sliding velocity along the common normal at the actual entry point, \(J_1\) and \(J_2\) are the moments of inertia of the pinion and gear, \(r_{b1}\), \(r_{b2}\) are the base radii, and \(k_s\) is the mesh stiffness at the actual entry point obtained by LTCA.
2.4 Multi-Objective Optimization
To achieve the best modification parameters, a multi-objective optimization model is formulated with the objective to minimize the loaded transmission error fluctuation and the meshing impact force simultaneously. The normalized objective function is:
$$ F(y_1,y_2,y_3,y_4) = w_1 \frac{\Delta T_e}{\Delta T_{e0}} + w_2 \frac{F_s}{F_{s0}} $$
where \(\Delta T_{e0}\) and \(F_{s0}\) are the values of the standard unmodified gear pair, and \(w_1=w_2=0.5\) are the weighting factors. The design variables \(y_1\) to \(y_4\) represent the tip modification amount, tip modification height, root modification amount, and root modification height, respectively. The parameter ranges are determined based on the single-tooth and double-tooth contact zones. The NSGA-II genetic algorithm is used because of its ability to find global optima in non-convex and multi-modal problems. The population size is 200 and the number of generations is 400. The optimization loop executes TCA and LTCA for each candidate design until convergence.
2.5 Optimization Results
The basic parameters of the herringbone gear pair used in this study are listed in Table 1.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth | 30 | 72 |
| Normal module (mm) | 5 | 5 |
| Normal pressure angle (°) | 20 | 20 |
| Helix angle (°) | 33.273 | 33.273 |
| Face width per side (mm) | 44 | 40 |
| Gap width (mm) | 46 | 50 |
| Rated speed (r/min) | 2500 | — |
| Rated torque (Nm) | — | 3000 |
After optimization, the optimal parameters for the linear triangular end relief are given in Table 2, and those for the quadratic parabolic triangular end relief are given in Table 3.
| Parameter | Range | Optimal value (linear) |
|---|---|---|
| Tip relief amount \(C_{Ea}\) (μm) | (8,20) | 16.10 |
| Tip relief height \(L_{Ea}\) (mm) | (2.01,5) | 2.72 |
| Root relief amount \(C_{Ef}\) (μm) | (8,20) | 9.31 |
| Root relief height \(L_{Ef}\) (mm) | (1.27,4.04) | 2.81 |
| Parameter | Range | Optimal value (quadratic) |
|---|---|---|
| Tip relief amount \(C_{Ea}\) (μm) | (8,20) | 16.53 |
| Tip relief height \(L_{Ea}\) (mm) | (2.01,5) | 4.52 |
| Root relief amount \(C_{Ef}\) (μm) | (8,20) | 11.63 |
| Root relief height \(L_{Ef}\) (mm) | (1.27,4.03) | 2.44 |
The simulation results at the rated torque of 3000 Nm are summarized in Table 4. The quadratic parabolic modification yields a more significant reduction in both loaded transmission error fluctuation and meshing impact force than the linear modification. The loaded transmission error fluctuation is reduced by 75.5% for the linear case and 83.7% for the quadratic case compared to the standard gear pair. The meshing impact force is reduced by 93.6% and 94.4%, respectively. The multi-load results indicate that the loaded transmission error fluctuation reaches its minimum near the rated load for both modified cases, which confirms the effectiveness of the optimization.
| Gear pair | \(\Delta T_e\) (arcsec) | \(F_s\) (N) |
|---|---|---|
| Standard | 0.810 | 2983 |
| Linear triangular end relief | 0.197 | 191 |
| Quadratic triangular end relief | 0.132 | 168 |
3. Form Grinding with a Three-Section Grinding Wheel
3.1 Coordinate Transformation and Wheel Profile Derivation
To realize the triangular end relief by form grinding, a CNC form grinding machine (YK7332A) is used. The coordinate system between the grinding wheel and the workpiece is established. The transformation matrix from the gear coordinate system to the wheel coordinate system is denoted by \(\mathbf{M}_{t1}\), which includes the setting angle \(\gamma_m\), the center distance \(E_t\), the axial translation \(L_t\), and the gear rotation angle \(\theta_1\). The position vector and normal vector of the gear flank transformed into the wheel coordinate system are:
$$ \mathbf{r}_t(u_1,l_1,\theta_1) = \mathbf{M}_{t1}(\gamma_m,E_t,L_t,\theta_1)\mathbf{r}_1(u_1,l_1) $$
$$ \mathbf{n}_t(u_1,l_1,\theta_1) = \mathbf{L}_{t1}(\gamma_m,E_t,L_t,\theta_1)\mathbf{n}_1(u_1,l_1) $$
For a given grinding wheel, the contact condition between the wheel and the tooth surface requires that the normal vector, the radial vector, and the wheel axis are coplanar:
$$ \left[ \mathbf{n}_t \cdot \left( \mathbf{z}_t \times \mathbf{r}_t \right) \right] = 0 $$
Solving this equation with \(\theta_1=0\) yields the contact line on the wheel. The axial profile of the wheel is then obtained by projecting the contact points onto the axial plane:
$$ y_c = \sqrt{x_t^2 + y_t^2}, \qquad x_c = x_t $$
For the actual machine, the axis parameters are derived by comparing the general transformation matrix with the machine-specific matrix. The results are \(\psi_a = \theta_1\), \(\psi_b = \gamma_m\), \(C_x = -L_t\), and \(C_y = E_t\). For the given gear parameters and a wheel diameter of 100 mm, the machine settings are listed in Table 5.
| Axis | Expression | Value |
|---|---|---|
| \(C_x\) | \(-136.7044\,\theta_1\) | — |
| \(C_y\) | — | 139.7058 mm |
| \(\psi_a\) | — | \(\theta_1\) |
| \(\psi_b\) | — | 0.5807 rad |
3.2 Three-Section Wheel Method
The fundamental idea of the three-section grinding wheel method is to approximate the triangular end relief surface by three different helical surfaces: the tip relief surface, the standard surface, and the root relief surface. For a linear triangular end relief, only the basic parameters (normal module \(m_n\), normal pressure angle \(\alpha_n\), and helix angle \(\beta\)) of the tip and root helical surfaces are optimized. For a quadratic triangular end relief, additional profile modifications with a parabolic curve are superimposed, introducing two extra design variables: the profile modification height \(h\) and the profile modification amount \(\varsigma\).
The target modified tooth surface is discretized into a set of points along lines parallel to the modification start line. The normal deviation between the actual approximated surface and the target surface at each discrete point is:
$$ h_{i,j}^{(t)} = \left( \mathbf{p}_{i,j}^{(t)} – \mathbf{p}_{i,j}^{*,t} \right) \cdot \mathbf{n}_{i,j}^{*,t} $$
The optimization objective is to minimize the sum of squared deviations for the tip and root zones separately:
$$ f_j^{(t)} = \mathbf{H}_j^{(t)T}\mathbf{H}_j^{(t)} \qquad (j=a,f; \; t=1,2) $$
where \(t=1\) for the linear case with design vector \([\alpha_n, m_n, \beta]^T\), and \(t=2\) for the quadratic case with design vector \([\alpha_n, m_n, \beta, h, \varsigma]^T\). The NSGA-II algorithm is used again with a population size of 200 and 400 generations. The optimized parameters and the resulting sum of squared deviations are presented in Tables 6 and 7.
| Optimization variable | Range | Tip zone optimal value | Root zone optimal value |
|---|---|---|---|
| Module \(m_n\) (mm) | (4.5,5.5) | 5.00053 | 5.00383 |
| Pressure angle \(\alpha_n\) (°) | (19.5,20.5) | 20.5342 | 19.9219 |
| Helix angle \(\beta\) (°) | (32.773,33.773) | 33.4012 | 33.2534 |
| Sum of squared deviations | — | 6.12×10⁻⁷ | 1.30×10⁻⁶ |
| Optimization variable | Range | Tip zone optimal value | Root zone optimal value |
|---|---|---|---|
| Module \(m_n\) (mm) | (4.5,5.5) | 4.9995 | 5.00432 |
| Pressure angle \(\alpha_n\) (°) | (19.5,20.5) | 20.0423 | 19.9641 |
| Helix angle \(\beta\) (°) | (32.773,33.773) | 33.3354 | 33.2498 |
| Profile modification height \(h\) (mm) | (1,9) | 6.44 | 3.89 |
| Profile modification amount \(\varsigma\) (μm) | (1,30) | 16.25 | 3.5 |
| Sum of squared deviations | — | 1.12×10⁻⁴ | 5.43×10⁻⁵ |
The maximum normal deviation for the linear three-section wheel is below 1 μm, while for the quadratic three-section wheel it is below 3 μm. These results confirm that the proposed method is capable of producing the desired triangular end relief with high accuracy. The wheel profiles corresponding to the three sections are obtained by rotating the optimized axial profiles, and the wheel is dressed with a CNC diamond roller.
3.3 Machining and Inspection of the Modified Pinion
The linear triangular end relief was implemented on a herringbone pinion. The pinion is designed as a single-piece shaft and mounted between centers to ensure concentricity. The grinding process is performed in three steps: first, the full flank is ground with the standard wheel profile; second, the root modification zone is ground with the root-section wheel profile; third, the tip modification zone is ground with the tip-section wheel profile. Careful attention is paid to the indexing and reference positioning so that the three cuts are aligned within the same tooth space.
After grinding, the tooth surfaces were measured on a Klingelnberg P40 gear measuring instrument. The tooth profile and helix deviations were evaluated along six measurement paths on each flank. The measured single pitch deviation was 3.1 μm, and the cumulative pitch deviation was 8.6 μm, both within the ISO 4-grade tolerances. Most profile and lead deviations were within the 4-grade envelope, except for the tip modification zone on the left flank which exceeded the envelope by approximately 2 μm. This is attributed to the inherent positioning error of the machine axes and the difficulty in maintaining the spindle angular position during the three dressing and grinding steps. Nevertheless, the rolling test with red paint showed that the contact pattern was smooth and continuous, and the modified zones appeared bright without paint sticking, confirming that the triangular end relief was correctly generated.
4. Dynamic Characteristics Analysis
4.1 Dynamic Model
A 12-degree-of-freedom lumped parameter model is constructed for the herringbone gear pair, as shown schematically in the following. The model includes two helical gear pairs (left and right sides) coupled through the shaft and the floating pinion arrangement. Each gear body has two translational degrees of freedom in the radial and axial directions and one rotational degree of freedom about the gear axis. The pinion is supported by radial bearings, while the gear is supported by both radial and axial bearings. The axial motion of the floating pinion is free, which balances the axial forces from the two helical sides.
The generalized displacement vector is:
$$ \mathbf{q} = [y_{p1}, z_{p1}, \theta_{p1}, y_{p2}, z_{p2}, \theta_{p2}, y_{g1}, z_{g1}, \theta_{g1}, y_{g2}, z_{g2}, \theta_{g2}]^T $$
where subscripts \(p\) and \(g\) denote pinion and gear, respectively, and \(1\) and \(2\) denote the left and right helical sides. The equations of motion for the left pinion side are:
$$ m_{p1}\ddot{y}_{p1} + c_{p1y}\dot{y}_{p1} + k_{p1y} y_{p1} = -F_{y1} $$
$$ m_{p1}\ddot{z}_{p1} + c_{p1z}(\dot{z}_{p1}-\dot{z}_{p2}) + k_{p1z}(z_{p1}-z_{p2}) = -F_{z1} $$
$$ I_{p1}\ddot{\theta}_{p1} = -F_{y1} R_{bp} + T_{p1} $$
For the gear side, similar equations apply. The dynamic mesh force along the line of action is expressed as:
$$ F_{n1} = c_{m1}\left( \dot{y}_{p1}-\dot{y}_{g1} + R_{bp}\dot{\theta}_{p1} – R_{bg}\dot{\theta}_{g1} + \dot{z}_{p1}\cos\beta + \dot{z}_{g1}\cos\beta + \dot{\varepsilon}_z \right) + k_{m1}\left( y_{p1}-y_{g1} + R_{bp}\theta_{p1} – R_{bg}\theta_{g1} + z_{p1}\cos\beta + z_{g1}\cos\beta + \varepsilon_z \right) $$
The radial and axial components of the mesh force are \(F_y = F_n \cos\beta\) and \(F_z = F_n \sin\beta\). The time-varying mesh stiffness \(k_{m1}(t)\) and \(k_{m2}(t)\) are calculated from LTCA and represented as periodic functions by Fourier series. The meshing impact force \(F_s\) is applied as an additional external excitation at the entry instant.
4.2 Excitation Calculation
The comprehensive time-varying mesh stiffness is obtained from the loaded tooth contact analysis as:
$$ K_m = \frac{F_n}{Z_k} $$
The results for the standard and modified gear pairs are shown in Table 8. The mesh stiffness fluctuation of the standard gear pair is \(1.16\times10^8\) N/m. After linear triangular end relief, it drops to \(2.4\times10^7\) N/m, and after quadratic triangular end relief, it drops further to \(1.6\times10^7\) N/m. The reduction is mainly caused by the decrease of single tooth stiffness in the modification zones, which smooths the transition between single and double tooth contact.
| Gear pair | Mesh stiffness fluctuation (N/m) | Impact force \(F_s\) (N) | Mesh line vibration acceleration RMS (m/s²) | Dynamic mesh force fluctuation (N) |
|---|---|---|---|---|
| Standard | 1.16×10⁸ | 2983 | 70.24 | 624 |
| Linear triangular end relief | 2.4×10⁷ | 191 | 11.83 | 206 |
| Quadratic triangular end relief | 1.6×10⁷ | 168 | 8.43 | 161 |
4.3 Dynamic Response
The equations of motion are solved numerically using the Newmark integration method. The frequency-domain response is obtained by fast Fourier transform of the time-domain acceleration signal. For the standard gear pair, the dominant peak in the vibration spectrum occurs at three times the mesh frequency, with a magnitude of 47.97 m/s². After linear modification, the dominant peak shifts to the fundamental mesh frequency with a much smaller magnitude of 11.15 m/s². For the quadratic modification, the dominant peak is also at the fundamental mesh frequency with a magnitude of 7.30 m/s². These results indicate that the triangular end relief effectively suppresses the mesh frequency excitations.
Multi-load simulations are performed for torques from 1000 Nm to 4000 Nm. The mesh line vibration acceleration RMS values are plotted against the torque. The standard gear pair shows a monotonic increase with torque, whereas the modified gear pairs exhibit a minimum near the rated torque. This is expected because the modification parameters are optimized for the rated load. The simulation results confirm that the quadratic triangular end relief provides the greatest vibration reduction, followed by the linear one, and both are significantly better than the standard unmodified gear pair.
5. Experimental Verification
5.1 Test Rigs and Instrumentation
To validate the theoretical predictions, two experimental setups are established. The first is a low-speed, high-torque loaded transmission error test rig, which consists of an AC motor with a large reduction ratio, a magnetic powder loader, and two high-precision rotary encoders mounted on the input and output shafts. The encoders have an angular accuracy of ±1 arcsec and a resolution of 0.1 arcsec. The test gearbox is supported by rolling element bearings to minimize friction at low speed. The second is a high-speed enclosed gearbox test rig using a mechanical power circulation configuration, where a DC motor drives the system and a hydraulic or mechanical loader applies the torque. This rig is used for vibration measurement. The test gearbox housing is supported by sliding bearings to simulate real marine operating conditions. A three-axis accelerometer is mounted on the foot of the gearbox housing to measure the vertical vibration response.
The loaded transmission error measurement is performed at a very low pinion speed of 4.18 r/min to avoid dynamic effects. The output torque is set to 1000, 1500, 2000, 2500, 3000, 3500, and 4000 Nm. The gear mesh frequency component is extracted from the measured transmission error signal using a median filter to remove the shaft-frequency components caused by pitch accumulation errors. The peak-to-peak value of the filtered mesh-frequency signal represents the loaded transmission error fluctuation. For vibration tests, the pinion speed is set to 2500 r/min and the load is varied from 1000 Nm to 3600 Nm. The vibration acceleration signal is recorded for 100 mesh cycles and the RMS value is computed in the frequency band of interest.
5.2 Experimental Results and Comparison
Table 9 presents the measured loaded transmission error fluctuations for the standard gear pair (P01G01) and the linearly modified gear pair (P02G01) at different loads. The simulation results are also included for comparison. The experimental values are higher than the simulated ones due to manufacturing errors, assembly errors, and the approximate nature of the linear three-section grinding method. However, the relative trend is consistent. At the rated load of 3000 Nm, the measured LTE fluctuation of the modified gear pair is 0.76 arcsec, which is 34% lower than the standard gear pair’s 1.16 arcsec. The simulation predicts a reduction of 75% (from 0.81 to 0.20 arcsec). The larger discrepancy in the absolute values is attributed to the manufacturing deviations of the modified flank, as well as the fact that the measurement includes mounting eccentricities that are not fully removed by the filtering process.
| Torque (Nm) | P01G01 LTE fluctuation (arcsec) | P02G01 LTE fluctuation (arcsec) | ||
|---|---|---|---|---|
| Test | Simulation | Test | Simulation | |
| 1000 | 0.73 | 0.26 | 0.91 | 0.48 |
| 1500 | 0.80 | 0.39 | 0.85 | 0.45 |
| 2000 | 0.86 | 0.53 | 0.74 | 0.36 |
| 2500 | 1.02 | 0.67 | 0.69 | 0.27 |
| 3000 | 1.16 | 0.81 | 0.76 | 0.20 |
| 3500 | 1.25 | 0.95 | 0.86 | 0.26 |
| 4000 | 1.33 | 1.09 | 1.01 | 0.36 |
Table 10 lists the measured gearbox foot vibration acceleration (vertical direction) for the two gear pairs at four torque levels, together with the simulated mesh-line vibration acceleration. Since no finite element model of the gearbox was built, the simulated mesh-line vibration is used as a reference. The measured housing vibration is much smaller than the simulated mesh-line vibration because the sliding bearings and the housing provide significant damping and attenuation. Nevertheless, the relative reduction due to triangular end relief is consistent. At 3000 Nm, the measured foot vibration acceleration drops from 4.22 m/s² for the standard pair to 3.36 m/s² for the modified pair, a reduction of 20%. The simulated mesh-line vibration drops by 83% (from 70.24 to 11.83 m/s²).
| Torque (Nm) | P01G01 Vibration (m/s²) | P02G01 Vibration (m/s²) | ||
|---|---|---|---|---|
| Test (foot) | Simulation (mesh line) | Test (foot) | Simulation (mesh line) | |
| 1000 | 3.34 | 22.72 | 2.93 | 26.87 |
| 2000 | 3.51 | 44.55 | 2.33 | 20.21 |
| 3000 | 4.22 | 70.24 | 3.36 | 11.83 |
| 3600 | 4.76 | 80.12 | 4.07 | 14.86 |
The experimental results clearly demonstrate that the loaded transmission error fluctuation and the housing vibration are strongly correlated. For both gear pairs, the change of vibration acceleration with torque follows the same trend as the change of LTE fluctuation. The modified gear pair exhibits lower vibration at all loads above 1500 Nm, and the minimum vibration occurs near the design load of 3000 Nm. This confirms that the proposed triangular end relief design and the three-section grinding wheel manufacturing method are effective in reducing the vibration and noise of herringbone gear pairs.
6. Conclusion
In this thesis, we have systematically investigated the optimum design, manufacturing, and dynamic performance of triangular end relief for herringbone gears. The following conclusions can be drawn:
- A parametric model of the triangular end relief tooth surface has been established by superposing the modification amount on the standard involute flank along the normal direction. The modification start lines are determined from the ISO definition and projected geometry.
- Multi-objective optimization using NSGA-II has been performed to minimize the loaded transmission error fluctuation and the meshing impact force. Both linear and quadratic parabolic modification curves were optimized. The quadratic modification showed better performance than the linear one, with a 83.7% reduction in LTE fluctuation and a 94.4% reduction in impact force at the rated load.
- A novel three-section grinding wheel method has been proposed to realize triangular end relief on a CNC form grinding machine. The linear three-section method optimizes three basic gear parameters (module, pressure angle, helix angle) and achieves a maximum deviation below 1 μm. The quadratic three-section method adds two profile modification parameters and achieves a maximum deviation below 3 μm. A linear herringbone pinion was successfully ground and inspected, with most accuracy indicators within ISO 4-grade.
- A 12-degree-of-freedom dynamic model has been established for the herringbone gear pair. The dynamic analysis reveals that triangular end relief significantly reduces the mesh stiffness fluctuation and the meshing impact excitation, leading to a substantial reduction in the mesh-line vibration acceleration. The quadratic modification provides the lowest vibration level.
- Experimental tests on loaded transmission error and housing vibration were conducted on standard and linearly modified gear pairs. The measured LTE fluctuation and vibration acceleration of the modified gear pair are lower than those of the standard gear pair at most loads, and the variation trends with torque are consistent with the simulation results. This validates the correctness and effectiveness of the proposed triangular end relief design and the form grinding implementation.
The research provides a complete design and manufacturing solution for high-precision herringbone gears with triangular end relief, which can be directly applied to the vibration and noise reduction of marine transmission systems. Future work will focus on extending the method to a quadratic profile modification with a more robust machining process, incorporating manufacturing errors into the optimization model, and building a full gearbox finite element model to correlate the simulated mesh-line vibration with the measured housing vibration more accurately.