
In modern mechanical transmission systems, helical gears play a pivotal role due to their smooth operation, high load capacity, and efficiency. Non-orthogonal helical gears, where the axes intersect at an angle other than 90 degrees, are particularly valuable in applications such as automotive differentials, helicopter reducers, robotic joints, and conveyor drives. These gears often operate with point contact, which can offer advantages in torque splitting and misalignment tolerance. However, designing such gears requires precise mathematical models to predict their contact behavior, stress distribution, and overall performance. In this study, we develop a comprehensive mathematical framework for non-orthogonal helical gear systems based on conjugate curve theory. Our goal is to enhance the load-bearing capacity and transmission characteristics of helical gear drives by analyzing key properties like undercutting conditions, slip ratio, and contact stress. We also validate our model through experimental fabrication and testing, providing insights for practical engineering applications.
The core of our approach lies in representing the tooth profiles as spatial curves derived from conjugate principles. Traditional gear design often relies on surface contact models, but we focus on curve contact elements to simplify the analysis while maintaining accuracy. This method allows us to model the intricate geometry of non-orthogonal helical gears with intersecting axes. We establish coordinate systems and derive equations for the contact points, relative velocities, and tooth profiles. Through simulations and comparisons with involute gears, we demonstrate that our proposed helical gear design exhibits superior contact characteristics, including reduced slip and lower stress concentrations. This article details our mathematical derivations, numerical analyses, and experimental results, aiming to contribute to the advancement of helical gear technology.
To model the non-orthogonal helical gear system, we define several coordinate systems as illustrated in the spatial configuration. Let \( S(O – x, y, z) \) be the fixed reference frame, while \( S_1(O_1 – x_1, y_1, z_1) \) and \( S_2(O_2 – x_2, y_2, z_2) \) are attached to the pinion and gear, respectively. The axes intersect at an angle \( \Sigma \), with a center distance \( a \). The angular velocities are denoted by \( \omega^{(1)} \) and \( \omega^{(2)} \), and the rotation angles are \( \phi_1 \) and \( \phi_2 \). The contact point \( P \) moves along the tooth profiles during meshing. We assume a spatial curve \( \Gamma_1 \) on the pinion, parameterized by an arc length parameter \( t \):
$$ \mathbf{r}_1 = x_1(t) \mathbf{i}_1 + y_1(t) \mathbf{j}_1 + z_1(t) \mathbf{k}_1 $$
where \( \mathbf{r}_1 \) is the position vector in \( S_1 \). Based on the relative motion between the gears, the relative velocity at the contact point in \( S_1 \) is derived as:
$$ \mathbf{v}^{(12)}_1 = [-y_1(1 + i_{21} \cos \Sigma) – z_1 i_{21} \cos \phi_1 \sin \Sigma – a i_{21} \sin \phi_1 \cos \Sigma] \mathbf{i}_1 + [x_1(1 + i_{21} \cos \Sigma) + z_1 i_{21} \sin \phi_1 \sin \Sigma – a i_{21} \cos \phi_1 \cos \Sigma] \mathbf{j}_1 + i_{21} \sin \Sigma (x_1 \cos \phi_1 – y_1 \sin \phi_1 – a) \mathbf{k}_1 $$
Here, \( i_{21} = \phi_2 / \phi_1 \) is the transmission ratio. The normal vector at the contact point is expressed as \( \mathbf{n}_n = u \mathbf{n}_\beta + v \mathbf{n}_\gamma \), where \( \mathbf{n}_\beta \) and \( \mathbf{n}_\gamma \) are the principal normal and binormal vectors, respectively. The conjugate curve \( \Gamma_2 \) on the gear can be obtained through coordinate transformations and meshing conditions. Its coordinates in \( S_2 \) are given by:
$$ x_2 = x_1 (\cos \phi_1 \cos \phi_2 – \sin \phi_1 \sin \phi_2 \cos \Sigma) + y_1 (-\sin \phi_1 \cos \phi_2 – \cos \phi_1 \sin \phi_2 \cos \Sigma) – z_1 \sin \phi_2 \sin \Sigma – a \cos \phi_2 $$
$$ y_2 = x_1 (\cos \phi_1 \sin \phi_2 + \sin \phi_1 \cos \phi_2 \cos \Sigma) + y_1 (-\sin \phi_1 \sin \phi_2 + \cos \phi_1 \cos \phi_2 \cos \Sigma) + z_1 \cos \phi_2 \sin \Sigma – a \sin \phi_2 $$
$$ z_2 = (1 + i_{21} \cos \Sigma)(n_{nx1} y_1 – n_{ny1} x_1) + n_{nz1} a i_{21} \sin \Sigma $$
where \( n_{nx1}, n_{ny1}, n_{nz1} \) are components of the unit normal vector. To generate the tooth surfaces, we employ the equidistant envelope method. The tooth profiles are defined as offset curves from the conjugate curves, with radii \( \rho_1 \) and \( \rho_2 \) for convex and concave parts, respectively. The general equation for the tooth surface is:
$$ \mathbf{r}_{\Gamma_i} = \mathbf{r}_i \pm \rho_i \mathbf{n}^0_{ni} + \rho_i (\cos \phi_i \cos \alpha_i \mathbf{i}_i + \cos \phi_i \sin \alpha_i \mathbf{j}_i + \sin \phi_i \mathbf{k}_i) $$
$$ \Phi(t, \phi, \alpha) = (\mathbf{r}_{it}, \mathbf{r}_{i\phi}, \mathbf{r}_{i\alpha}) = 0 \quad \text{for } i=1,2 $$
Here, \( \phi_i \) and \( \alpha_i \) are rotation and pressure angles, and \( \Phi \) represents the envelope condition. This formulation allows us to model helical gear teeth with precise geometry, facilitating further analysis of contact characteristics.
For a specific helical gear design, we consider a cylindrical helix curve on the pinion, parameterized by \( \theta \):
$$ x_1 = R \cos \theta, \quad y_1 = R \sin \theta, \quad z_1 = p \theta $$
where \( R \) is the pitch radius and \( p \) is the helical parameter. Using this curve, we derive the tooth profile equations for both gears. For the pinion (gear 1), the convex tooth profile is:
$$ x_{\Sigma1} = R \cos \theta + h_1 n^{0′}_{nx1} + h_1 \cos \phi_1 \cos \alpha_1 $$
$$ y_{\Sigma1} = R \sin \theta + h_1 n^{0′}_{ny1} + h_1 \cos \phi_1 \sin \alpha_1 $$
$$ z_{\Sigma1} = 0 $$
For the gear (gear 2), the concave tooth profile is:
$$ x_{\Sigma2} = R \cos \phi_2 \cos(\theta + \phi_1) + R \sin \phi_2 \cos \Sigma \sin(\theta + \phi_1) + p \theta \sin \phi_2 \sin \Sigma – a \cos \phi_2 – h_2 n^{0′}_{nx2} + h_2 \cos \phi_2 \cos \alpha_2 $$
$$ y_{\Sigma2} = R \sin \phi_2 \cos(\theta + \phi_1) + R \cos \phi_2 \cos \Sigma \sin(\theta + \phi_1) + p \theta \cos \phi_2 \sin \Sigma – a \sin \phi_2 – h_2 n^{0′}_{ny2} + h_2 \cos \phi_2 \sin \alpha_2 $$
$$ z_{\Sigma2} = 0 $$
In these equations, \( h_1 \) and \( h_2 \) are the radii of convex and concave profiles, and \( n^{0′}_{nxi}, n^{0′}_{nyi} \) are components of the modified normal vectors. We use a set of design parameters to compute numerical results, as summarized in Table 1. These parameters are typical for non-orthogonal helical gears with a small shaft angle, ensuring realistic simulation conditions.
| Parameter | Value |
|---|---|
| Shaft angle \( \Sigma \) (degrees) | 15 |
| Pinion pitch radius \( R_1 \) (mm) | 36 |
| Center distance \( a \) (mm) | 136 |
| Normal module \( m_n \) (mm) | 5 |
| Pressure angle \( \alpha_\alpha \) (degrees) | 30 |
| Transmission ratio \( i_{21} \) | 31/11 |
| Pinion teeth number \( Z_1 \) | 11 |
| Gear teeth number \( Z_2 \) | 31 |
| Helical parameter \( p \) | 39.3 |
| Convex profile radius \( h_1 \) (mm) | 5 |
| Concave profile radius \( h_2 \) (mm) | 6 |
| Face width \( B \) (mm) | 32 |
| Curve parameter \( \theta \) (rad) | [0, 0.75] |
| Coefficient \( u \) | -0.58 |
| Coefficient \( v \) | -0.85 |
Using MATLAB, we simulate the meshing process of this helical gear pair. The results show continuous motion with a constant transmission ratio, and point contact occurs along the tooth profiles without interference. This validates our mathematical model for non-orthogonal helical gears. Next, we analyze critical tooth profile characteristics, starting with undercutting conditions. Undercutting in gears is often caused by singularities during the generation process. For our helical gear design, we derive the condition to avoid undercutting based on the geometry of the tooth surfaces. Consider the surface \( \Sigma_1 \) generating \( \Sigma_2 \). Singularities on \( \Sigma_2 \) occur when the relative velocity satisfies \( \mathbf{v}^{(2)}_r = 0 \), which leads to the equation:
$$ \frac{d}{ds} [\Phi(t, \phi, \alpha)] = 0 $$
where \( s \) is the arc length. Expanding this using differential geometry, we obtain a system of equations. The condition for no undercutting can be expressed as the determinant of a matrix being non-zero. Specifically, we define matrices involving partial derivatives of the position vector and the envelope condition. For the tubular tooth surfaces of our helical gear, the undercutting condition reduces to:
$$ \Delta_1 = 0, \quad \Delta_2 = 0, \quad \Delta_3 = 0 $$
where \( \Delta_1, \Delta_2, \Delta_3 \) are determinants derived from the Jacobian of the transformation. In practice, we ensure that the design parameters avoid these singularities, thus preventing undercutting in the non-orthogonal helical gear teeth.
Another important characteristic is the slip ratio, which affects wear and efficiency. For helical gears, slip occurs due to relative motion between contacting surfaces. We analyze slip by considering arcs along the conjugate curves during meshing. Let \( \Delta S_1 \) and \( \Delta S_2 \) be the arc lengths on curves \( \Gamma_1 \) and \( \Gamma_2 \) over a small time interval \( \Delta t \). The slip ratios \( U_1 \) and \( U_2 \) for pinion and gear are defined as:
$$ U_1 = \lim_{\Delta S_1 \to 0} \frac{\Delta S_1 – \Delta S_2}{\Delta S_1}, \quad U_2 = \lim_{\Delta S_2 \to 0} \frac{\Delta S_2 – \Delta S_1}{\Delta S_2} $$
Using our model, we compute these arcs:
$$ \Delta S_1 = \sqrt{R^2 + p^2} \, \Delta \theta $$
$$ \Delta S_2 = \sqrt{ [R \cos \phi_2 \cos(\theta + \phi_1) + R \sin \phi_2 \cos \Sigma \sin(\theta + \phi_1) + p \theta \sin \phi_2 \sin \Sigma – a \cos \phi_2]’^2 + [R \sin \phi_2 \cos(\theta + \phi_1) + R \cos \phi_2 \cos \Sigma \sin(\theta + \phi_1) + p \theta \cos \phi_2 \sin \Sigma – a \sin \phi_2]’^2 + [-R \cos \theta \sin \phi_1 \sin \Sigma – R \sin \theta \cos \phi_1 \sin \Sigma + p \theta \cos \Sigma]’^2 } \, \Delta \theta $$
With the parameters from Table 1, we calculate the slip ratios over the meshing cycle. The results, plotted in Figure 1, show that the slip ratio for our non-orthogonal helical gear pair changes sign near the pitch point and reaches maximum absolute values at the tooth root. Importantly, we compare this with a traditional involute helical gear pair under the same conditions. The involute gear exhibits higher slip ratios, indicating that our design reduces sliding friction, which can enhance efficiency and longevity in helical gear transmissions.
To assess mechanical performance, we conduct stress analysis using finite element methods. We build a 3D model of the helical gear pair based on our derived tooth profiles and import it into ANSYS Workbench. The gear material is set as 20CrMnTi steel with a Young’s modulus of 205 GPa and Poisson’s ratio of 0.25. We apply a torque of 200 N·m to the pinion and analyze contact stresses using the Hertzian contact model with the augmented Lagrangian algorithm. The finite element mesh uses SOLID185 elements for the bodies and CONTA173/TARGE170 elements for the contact interfaces. The results, shown in Figure 2, reveal that the maximum contact stress is 1266.5 MPa, occurring at the mid-point of the tooth contact region. The stress distribution is elliptical along the tooth width, extending toward the root. The pinion’s maximum von Mises stress is 793.69 MPa. In comparison, an involute helical gear pair under the same load shows a higher maximum contact stress of 1639 MPa and a von Mises stress of 1233.8 MPa. This demonstrates that our non-orthogonal helical gear design offers better contact characteristics with lower stress concentrations, which is crucial for high-load applications.
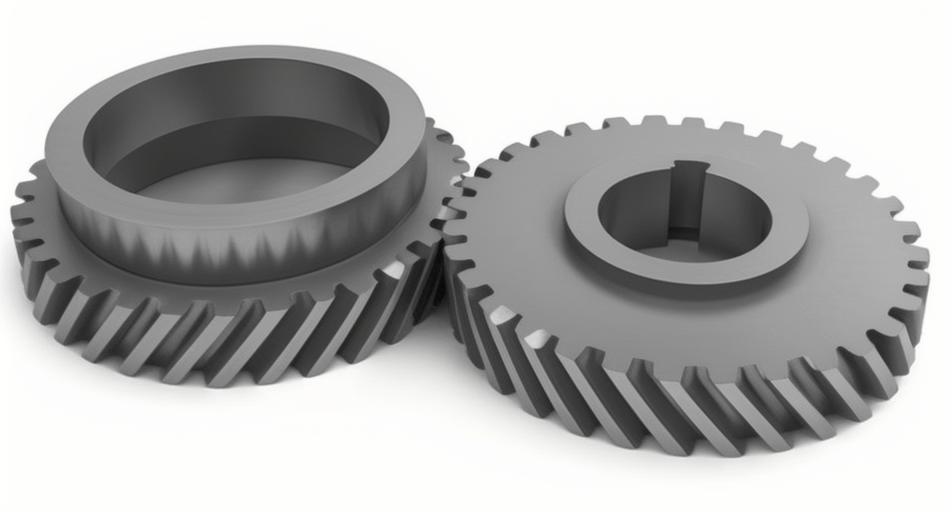
For experimental validation, we fabricate prototype helical gears using a five-axis machining center. Due to the complex tooth geometry, we employ ball-end milling based on the CAD model derived from our equations. The machining process simulates the tool paths for generating both convex and concave profiles. The fabricated pinion and gear are shown in Figure 3. We then test the prototypes on a gear performance rig, measuring input and output torques with sensors and controlling speeds with a variable-frequency motor. The transmission efficiency \( \eta \) is calculated as:
$$ \eta = \frac{n_o T_o}{n_i T_i} $$
where \( T_i, n_i \) are input torque and speed, and \( T_o, n_o \) are output torque and speed. We test under various conditions: speeds of 200, 400, 600, 800, and 1000 rpm, and loads of 200, 300, 400, 500, and 600 N·m. The results, summarized in Table 2, show that efficiency increases with both speed and load. At 600 N·m load, the peak efficiency reaches 95.9%, with an overall range of 91.2% to 95.9% across tests. This confirms that our helical gear design performs well in practice, achieving high efficiency comparable to or better than conventional gears.
| Speed (rpm) | Load (N·m) | Efficiency (%) |
|---|---|---|
| 200 | 200 | 91.2 |
| 200 | 300 | 92.5 |
| 200 | 400 | 93.1 |
| 200 | 500 | 94.0 |
| 200 | 600 | 94.5 |
| 400 | 200 | 92.0 |
| 400 | 300 | 93.3 |
| 400 | 400 | 94.2 |
| 400 | 500 | 95.0 |
| 400 | 600 | 95.5 |
| 600 | 200 | 92.8 |
| 600 | 300 | 94.0 |
| 600 | 400 | 95.0 |
| 600 | 500 | 95.6 |
| 600 | 600 | 95.9 |
| 800 | 200 | 93.5 |
| 800 | 300 | 94.7 |
| 800 | 400 | 95.4 |
| 800 | 500 | 95.8 |
| 800 | 600 | 95.9 |
| 1000 | 200 | 94.0 |
| 1000 | 300 | 95.2 |
| 1000 | 400 | 95.7 |
| 1000 | 500 | 95.9 |
| 1000 | 600 | 95.9 |
In conclusion, we have developed a comprehensive mathematical model for non-orthogonal helical gear systems based on conjugate curve theory. Our approach enables precise design of tooth profiles with point contact, improving load distribution and transmission characteristics. Through analysis, we derived conditions to avoid undercutting, computed slip ratios that are lower than those of involute helical gears, and performed stress simulations showing reduced contact stresses. Experimental fabrication and testing validated the model, demonstrating high efficiency and practical feasibility. This work provides a foundation for optimizing helical gear designs in various industrial applications, particularly where non-orthogonal axes are involved. Future research could explore dynamic behavior, noise reduction, and further optimization of tooth geometry for specific helical gear applications.
The helical gear, with its angled teeth, offers inherent advantages in smoothness and strength, and our non-orthogonal variant extends these benefits to intersecting shaft configurations. By integrating mathematical modeling with advanced simulation tools, we can push the boundaries of helical gear technology, leading to more efficient and reliable mechanical systems. We hope this study inspires further innovation in the field of gear design, especially for complex transmission scenarios where traditional helical gears may fall short.