
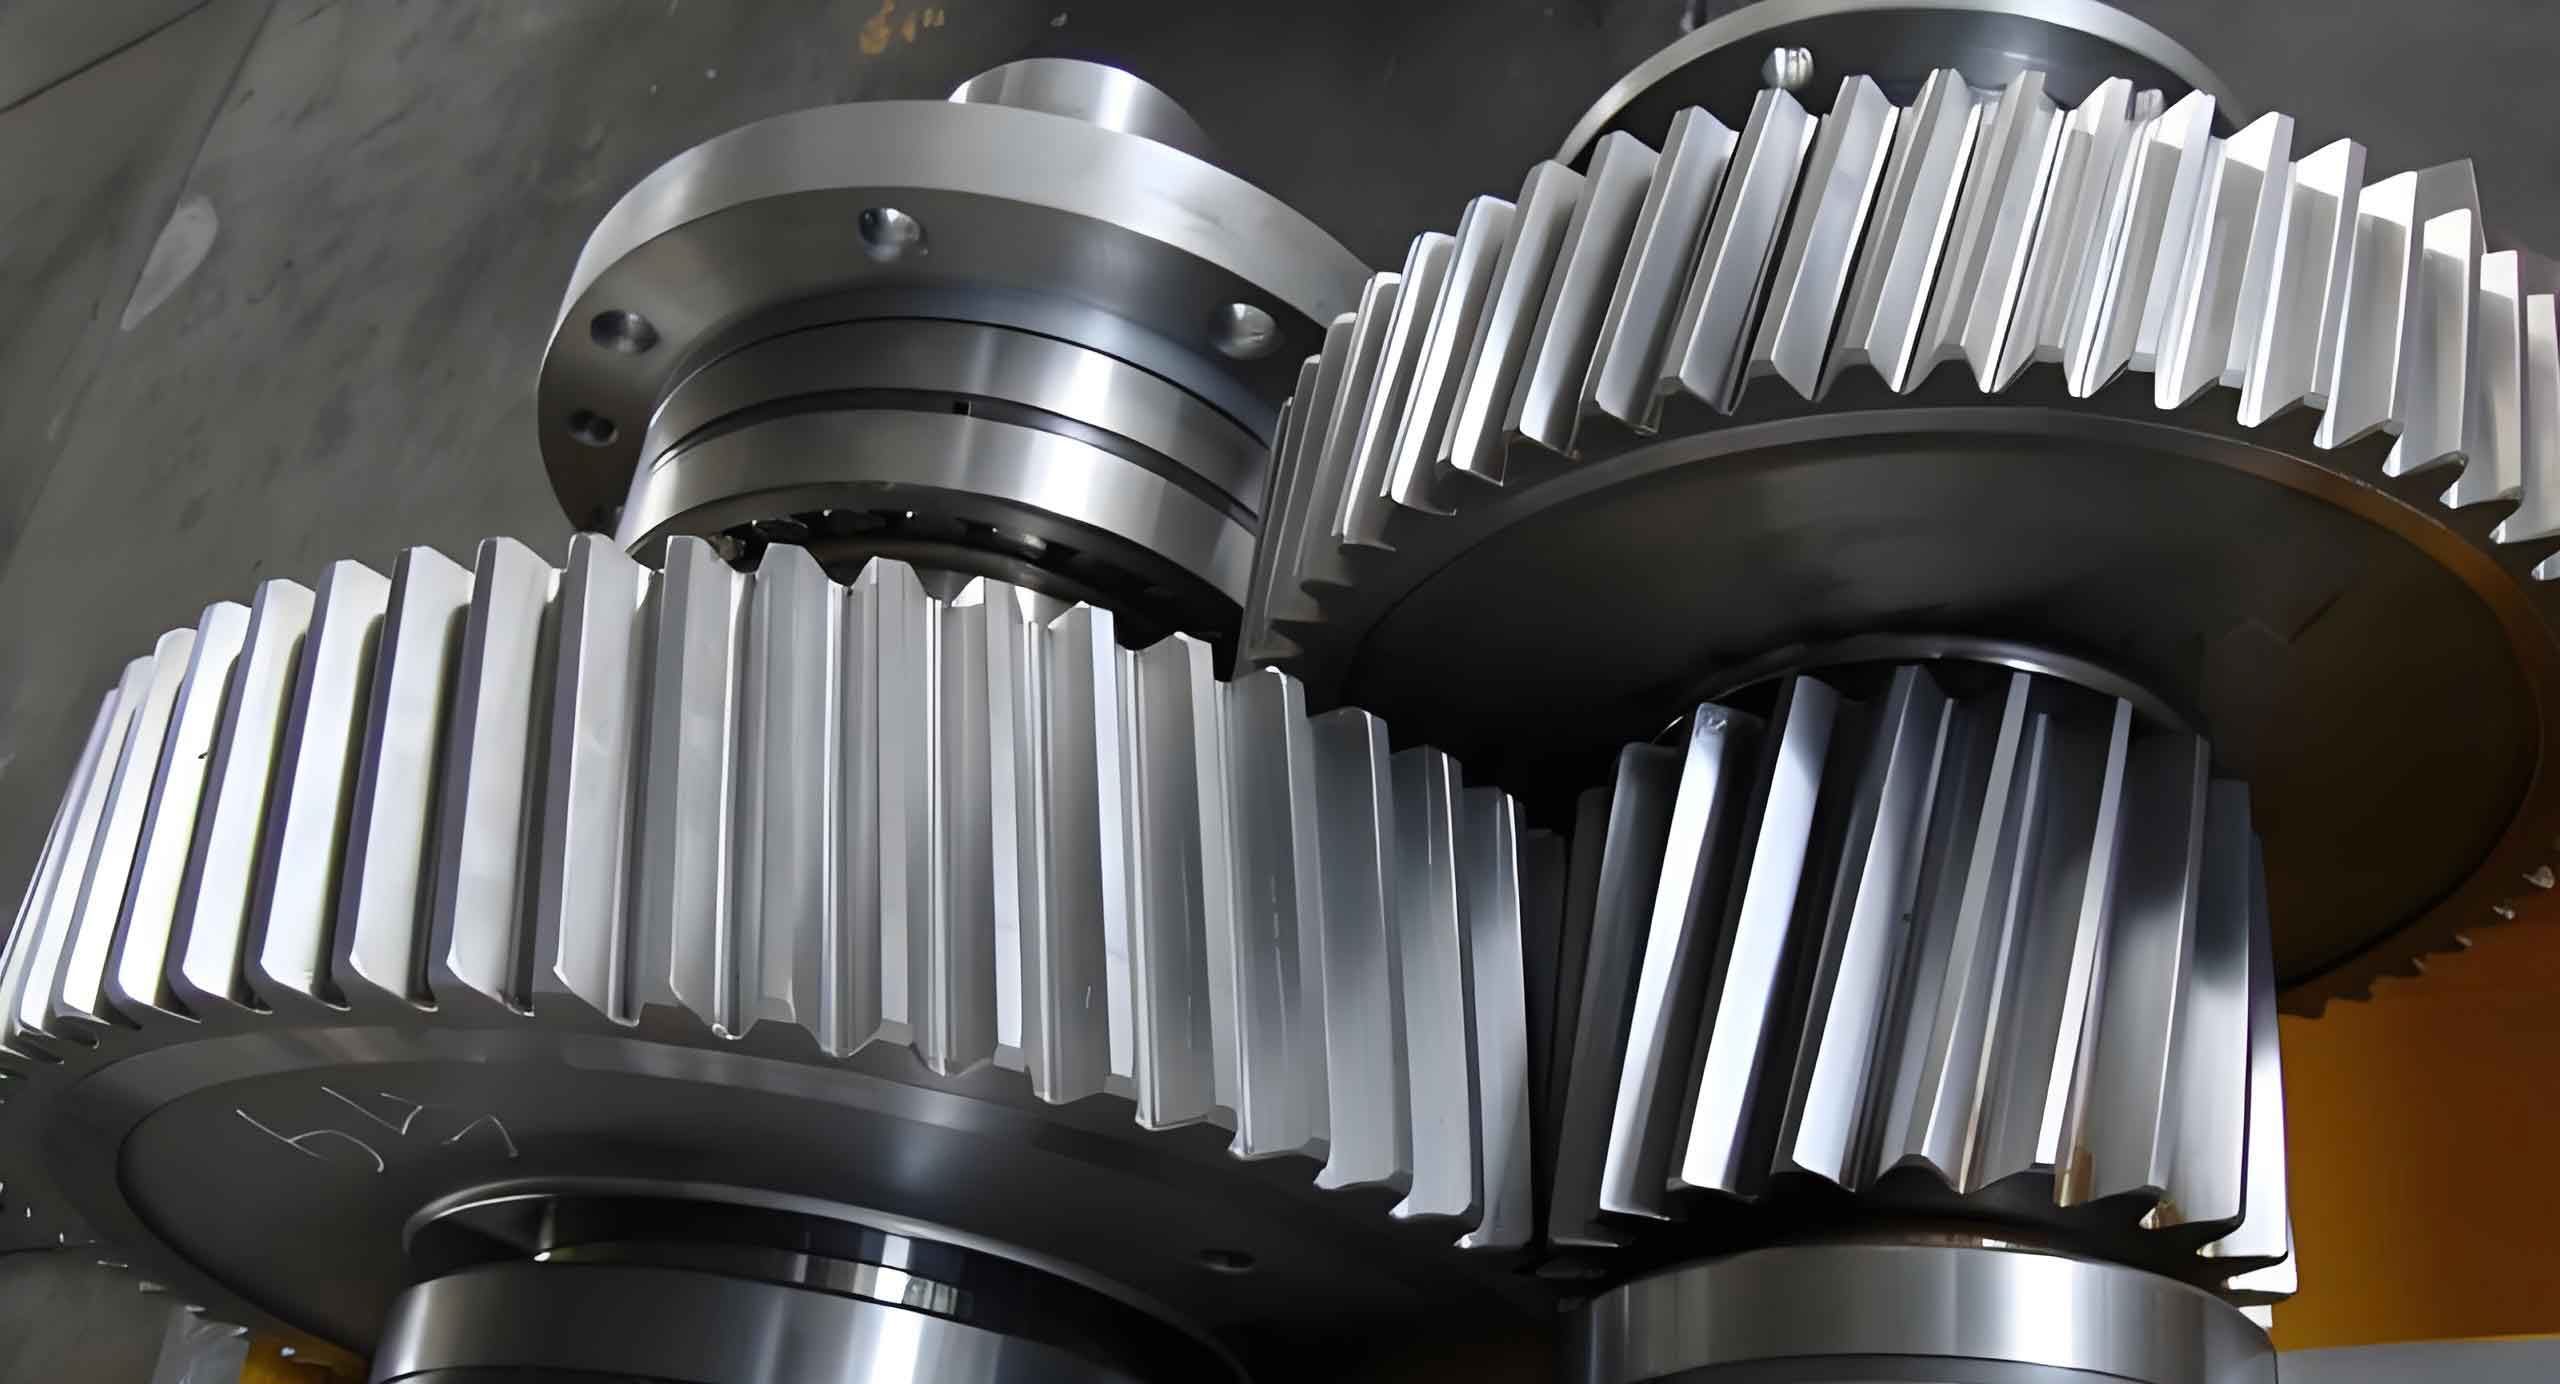
In modern manufacturing, the production of high-precision helical gears is critical for various industrial applications, including automotive transmissions, aerospace systems, and heavy machinery. Helical gears offer advantages such as smoother operation and higher load capacity compared to spur gears, but their complex geometry poses significant challenges in machining, particularly during hobbing processes. As helical gears require multi-axis synchronous control involving the rotational motion of the hob and the axial movement along the gear blank, synchronization errors can accumulate, leading to reduced gear quality. Traditional error compensation methods often struggle with the non-stationary and nonlinear nature of these errors in high-speed dry hobbing. In this article, I present a novel approach based on the wavelet packet algorithm to decompose, reconstruct, and compensate for synchronization errors in helical gear hobbing, aiming to enhance machining accuracy. We will explore the motion relationships, error signal acquisition, wavelet packet decomposition, error reconstruction, and practical compensation techniques, supported by formulas, tables, and experimental validation. Throughout, we emphasize the importance of helical gears in precision engineering and how this method can improve their manufacturing.
The hobbing process for helical gears involves intricate interactions between multiple axes. Typically, a CNC hobbing machine controls axes such as the hob rotation (B-axis), workpiece rotation (C-axis), and axial feed (Z-axis). For helical gears, the synchronization between these axes must be precise to generate the correct helix angle. The relationship can be expressed mathematically. Let $n_C$ be the rotational speed of the C-axis (workpiece), $n_B$ the rotational speed of the B-axis (hob), and $v_Z$ the axial feed rate along the Z-axis. The synchronization equation for helical gears is given by:
$$ n_C = K_B \frac{Z_B}{Z_C} \cdot n_B + K_Z \frac{360 \sin \beta}{\pi m z} \cdot v_Z $$
where $Z_B$ is the number of hob starts, $Z_C$ is the number of gear teeth, $\beta$ is the helix angle of the helical gear, $m$ is the module, and $K_B$ and $K_Z$ are coefficients depending on the hob and gear handedness. For right-handed hobs and gears with specific feed directions, these coefficients are typically set to 1 or -1. This equation highlights the linear superposition of errors from the B-C and Z-C linkages, which are the primary sources of synchronization errors in helical gear machining. The synchronization error, denoted as $\Delta \phi_{sync}$, is the difference between the theoretical angular displacement of the C-axis and its actual measured displacement. It can be decomposed into components from each linkage:
$$ \Delta \phi_{sync} = \Delta \phi_{BC} + \Delta \phi_{ZC} $$
with $\Delta \phi_{BC} = \frac{Z_B}{Z_C} \cdot \Delta \delta_B$ and $\Delta \phi_{ZC} = \frac{360 \sin \beta}{\pi m z} \cdot \Delta \delta_Z$, where $\Delta \delta_B$ and $\Delta \delta_Z$ are incremental errors in the B-axis and Z-axis movements, respectively. Understanding this superposition is crucial for error compensation in helical gears.
To address these errors, we first acquire synchronization error signals during the hobbing of helical gears. Using a data acquisition system connected to the CNC controller, we collect real-time data from the C-axis encoder, focusing on the synchronization error register (e.g., D50 in some systems). The sampling frequency is set to 1000 Hz, ensuring that we capture relevant dynamics based on the Nyquist theorem. The raw error signal, $S(k)$, where $k$ is the sample index, typically contains useful error components along with noise from various sources such as machine vibrations, thermal effects, and electrical interference. For helical gears, these signals are often non-stationary due to the varying cutting conditions and complex kinematics. The signal model can be represented as:
$$ S(k) = f(k) + \epsilon \cdot e(k) $$
where $f(k)$ is the true synchronization error related to helical gear machining, $e(k)$ is noise, and $\epsilon$ is the noise intensity. Our goal is to extract $f(k)$ for compensation. Traditional filtering methods may not suffice because they cannot adapt to the frequency-localized features of helical gear errors. Therefore, we employ the wavelet packet algorithm, which provides a multi-resolution analysis capable of decomposing signals into sub-bands across different frequency scales.
The wavelet packet transform extends the standard wavelet decomposition by further splitting detail coefficients, offering a richer set of bases for signal representation. Given a scaling function $\phi(t)$ and a wavelet function $\psi(t)$, we define a family of wavelet packet functions $u_n(t)$ recursively:
$$ u_0(t) = \phi(t), \quad u_1(t) = \psi(t) $$
$$ u_{2n}(t) = \sqrt{2} \sum_k h_k u_n(2t – k) $$
$$ u_{2n+1}(t) = \sqrt{2} \sum_k g_k u_n(2t – k) $$
where $\{h_k\}$ and $\{g_k\}$ are quadrature mirror filters satisfying orthogonality conditions. This allows us to decompose a signal into a complete binary tree. For our application, we apply a 3-level wavelet packet decomposition to the synchronization error signal $S(k)$ of helical gears. With a sampling frequency of 1000 Hz, the Nyquist frequency is 500 Hz, and after 3 levels, we obtain $2^3 = 8$ sub-bands, each with a bandwidth of 62.5 Hz. The decomposition can be expressed as:
$$ S = S_{3,0} + S_{3,1} + S_{3,2} + S_{3,3} + S_{3,4} + S_{3,5} + S_{3,6} + S_{3,7} $$
where $S_{3,i}$ represents the sub-band signal at node $i$ of the third level. We use the Db1 wavelet packet basis due to its good regularity properties. By analyzing the amplitude distribution across these sub-bands, we can identify which components contain the dominant error features related to helical gear machining. Typically, for helical gears, the main error components are concentrated in specific sub-bands (e.g., nodes 0 and 3), while others represent noise or irrelevant disturbances.
After decomposition, we reconstruct the synchronization error by selecting the relevant sub-bands. Let $D_{50}$ denote the original error signal, and $D’_{50}$ the reconstructed error after wavelet packet processing. The reconstruction involves inverse wavelet packet transform on the selected nodes. For helical gears, we often choose nodes where the signal energy correlates with the periodic errors from the B-C and Z-C linkages. The reconstructed error $D’_{50}$ has a reduced amplitude compared to the original, as noise is discarded. We quantify this reduction; for instance, in our experiments, the peak error decreased from 0.0514° to 0.0292°, a 43% improvement. This reconstructed error is then used for compensation.
Next, we decouple the reconstructed error into components attributable to the B-axis and Z-axis motions, based on the superposition principle. For helical gears, the contributions are proportional to the terms in the synchronization equation. The decoupled errors are:
$$ D’_{50,(B-C)} = \frac{\Delta \phi_{BC}}{\Delta \phi_{BC} + \Delta \phi_{ZC}} \cdot D’_{50} $$
$$ D’_{50,(Z-C)} = \frac{\Delta \phi_{ZC}}{\Delta \phi_{BC} + \Delta \phi_{ZC}} \cdot D’_{50} $$
These decoupled errors are then compensated by modifying the NC code in the CNC system. We use electronic gearbox (EGB) functionality to implement software-based compensation. The EGB parameters are adjusted to introduce corrective movements in the B-axis and Z-axis, effectively canceling the synchronization errors during the hobbing of helical gears. The compensation commands are integrated into the NC program, ensuring real-time error reduction without hardware changes.
To validate our method, we conducted experiments on a CNC hobbing machine, such as the YK3126 model, machining helical gears with specifications shown in Table 1. The helical gears had a module of 3 mm, 59 teeth, a helix angle of 20°, and were cut using a right-handed hob with three starts. We compared the gear accuracy before and after compensation by measuring tooth profile (Fα) and tooth direction (Fβ) errors using a gear measuring center. The results are summarized in Table 2.
| Parameter | Value | Parameter | Value |
|---|---|---|---|
| Module (mm) | 3 | Number of Teeth | 59 |
| Helix Angle (°) | 20 | Hob Starts | 3 |
| Pressure Angle (°) | 20 | Feed Rate (mm/rev) | 1.5 |
| Hob Handedness | Right | Hob Speed (rpm) | 680 |
| Gear Handedness | Right | Cutting Depth (mm) | 6.45 |
The table above illustrates the key parameters for machining helical gears, which influence the synchronization requirements. In practice, these parameters are used to calculate the EGB ratios for error compensation.
| Condition | Fα Error (μm) | Fβ Error (μm) |
|---|---|---|
| Before Compensation (Left Flank) | 17.8 | 23.0 |
| Before Compensation (Right Flank) | 12.1 | 18.0 |
| After Compensation (Left Flank) | 8.9 | 9.3 |
| After Compensation (Right Flank) | 11.5 | 15.3 |
As seen in Table 2, the errors for helical gears are significantly reduced after applying wavelet packet-based compensation. The tooth profile errors decreased by approximately 50% on average, and tooth direction errors improved by a similar margin. This demonstrates the effectiveness of our approach in enhancing the accuracy of helical gears. The compensation process involves setting EGB parameters in the CNC system. For example, in a typical implementation, we use G-code commands like G146 to configure the EGB, with parameters defining the master and slave axes, gear ratios, and synchronization modes. The specific settings for helical gears are shown in Table 3.
| Parameter | Value | Description |
|---|---|---|
| #101 | 1 | Phase synchronization enabled |
| #102 | 0 | Phase deviation angle set to zero |
| #103 | 1 | C-axis follows command |
| #104 | 5 | Master axis B (hob) identifier |
| #105 | 19.6664543 | Gear ratio for B-axis contribution |
| #106 | 1 | Master axis Z identifier |
| #107 | 2 | Gear ratio factor for Z-axis |
| #108 | 4.51617739 | Gear ratio for Z-axis contribution |
These parameters are derived from the helical gear geometry and the decoupled error components. By adjusting them dynamically based on the reconstructed error, we achieve precise compensation. The overall compensation model can be summarized as follows: acquire synchronization error signals from helical gear hobbing, apply wavelet packet decomposition to isolate error features, reconstruct the error, decouple it into axis-specific components, and compensate via EGB settings. This closed-loop approach ensures that helical gears are machined with higher precision, meeting stringent industrial standards.
In addition to the technical aspects, it’s important to note that the wavelet packet algorithm offers flexibility in handling non-stationary signals common in helical gear machining. Unlike Fourier-based methods, it provides time-frequency localization, which is crucial for capturing transient errors during gear hobbing. We can further optimize the decomposition level and wavelet basis selection based on the specific characteristics of helical gears. For instance, using higher decomposition levels (e.g., 4 or 5) may yield finer frequency resolution, but at the cost of increased computational complexity. In practice, for helical gears, a 3-level decomposition with Db1 wavelet strikes a balance between accuracy and efficiency.
The benefits of this method extend beyond error reduction. By improving the accuracy of helical gears, we enhance the performance of gear systems in terms of noise reduction, durability, and efficiency. Helical gears are widely used in high-speed applications, and even minor errors can lead to vibrations and premature failure. Our compensation approach addresses this by targeting synchronization errors at their source. Moreover, the method is cost-effective, as it relies on software modifications rather than hardware upgrades, making it accessible for many manufacturing setups involved in helical gear production.
To illustrate the mathematical foundation, consider the wavelet packet energy distribution. For a signal $S(k)$, the energy in sub-band $i$ at level $j$ is $E_{j,i} = \sum |S_{j,i}(k)|^2$. For helical gear errors, we often observe that $E_{3,0}$ and $E_{3,3}$ dominate, indicating that the primary error frequencies fall within 0-62.5 Hz and 187.5-250 Hz ranges, respectively. This aligns with the rotational frequencies of the hob and workpiece in helical gear hobbing. By reconstructing only these sub-bands, we preserve the essential error components while filtering out noise. The reconstruction error $D’_{50}$ can be expressed as:
$$ D’_{50} = \text{IDWT}(S_{3,0} + S_{3,3}) $$
where IDWT denotes the inverse discrete wavelet packet transform. This reconstructed signal is then used in the decoupling equations mentioned earlier.
In conclusion, the wavelet packet algorithm provides a robust framework for error compensation in helical gear hobbing. Through multi-resolution analysis, we effectively decompose synchronization errors, identify relevant features for helical gears, and reconstruct a cleaner error signal for compensation. The method leverages the linear superposition of errors in helical gear machining, allowing precise decoupling and axis-specific corrections via electronic gearbox settings. Experimental results show significant improvements in tooth profile and direction accuracy for helical gears, validating the approach. Future work could explore adaptive wavelet packet bases or real-time implementation for dynamic compensation during high-speed hobbing of helical gears. Overall, this technique enhances the manufacturing precision of helical gears, contributing to advanced gear technology and industrial applications.
Throughout this article, we have emphasized the importance of helical gears and their machining challenges. By integrating signal processing with CNC compensation, we offer a practical solution that can be adopted in various settings. The use of tables and formulas helps summarize key parameters and relationships, making the method accessible to engineers and researchers. As helical gears continue to be integral in mechanical systems, advancements in error compensation like this will play a crucial role in achieving higher quality and performance.