
The advancement of intelligent manufacturing is a strategic priority in the era of the fourth industrial revolution. Within these advanced production systems, industrial robots represent a critical class of high-end equipment. Their performance, reliability, and precision are paramount. The rotary vector (RV) reducer is a core component in the joints of industrial robots, prized for its high torsional stiffness, compact size, significant reduction ratio, and excellent load-bearing capacity. The transmission accuracy and service life of an RV reducer are fundamentally determined by the meshing performance of its core component: the cycloid-pin gear pair.
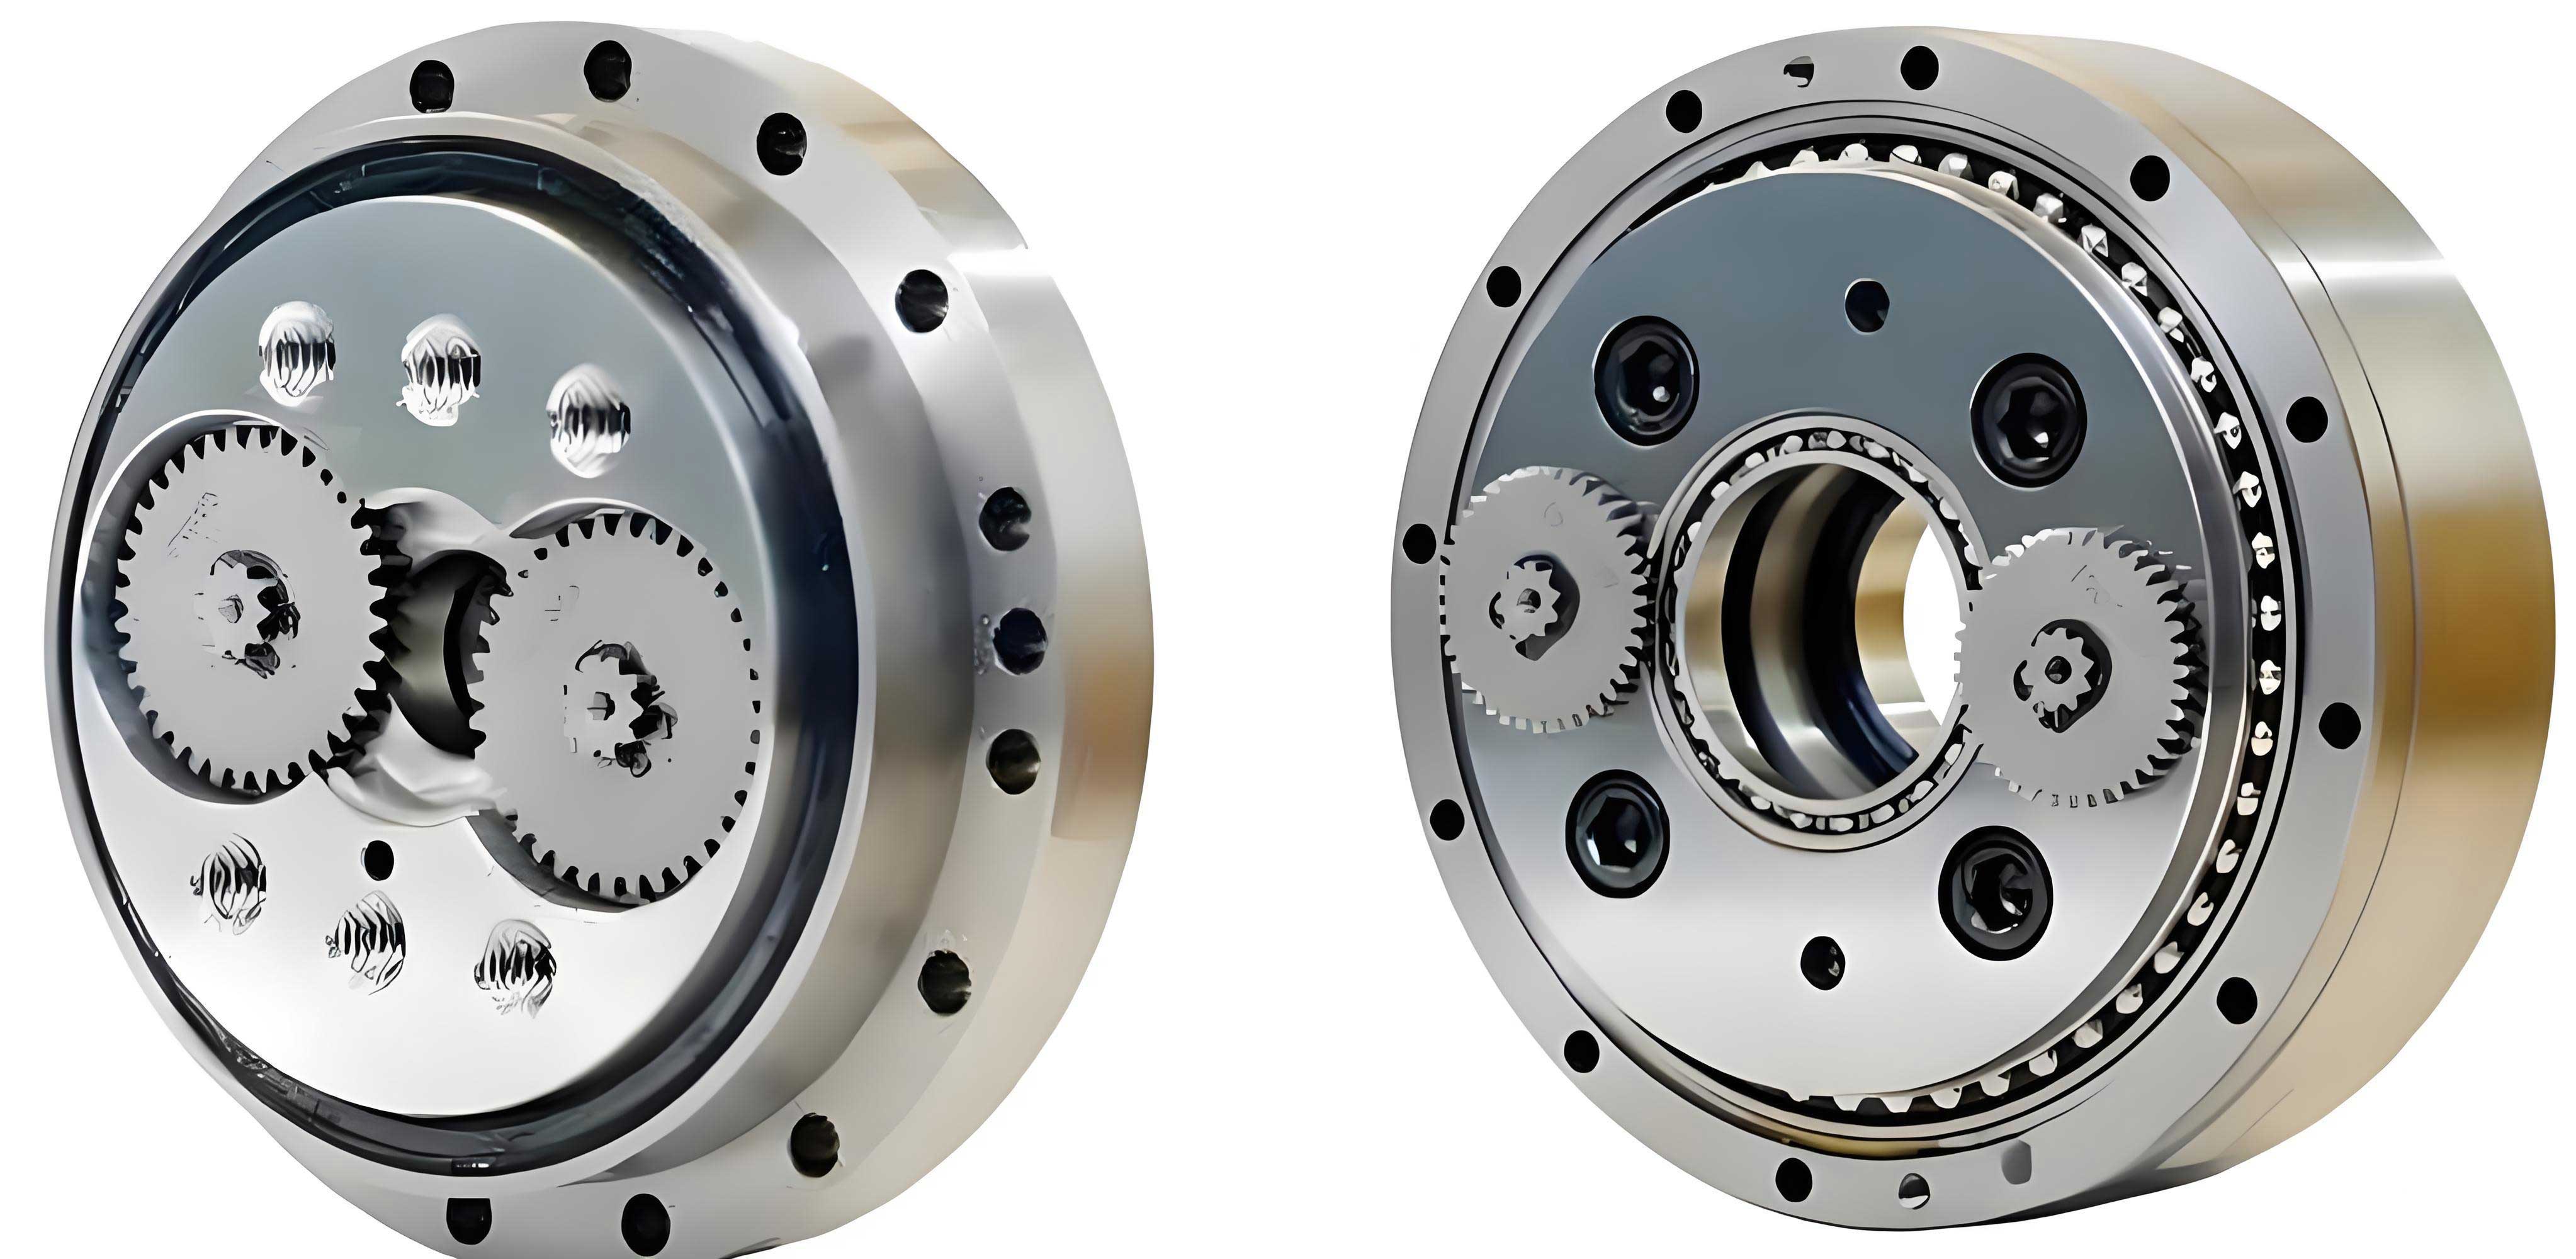
Tooth profile wear, a prevalent form of early-stage failure in gear transmissions, gradually degrades transmission smoothness, increases vibration and noise, introduces transmission error, and ultimately leads to premature system failure. For precision components like the RV reducer, even microscopic wear can have a pronounced impact on the positioning accuracy and repeatability of a robotic arm. Therefore, a profound understanding and accurate prediction of the dynamic wear characteristics of the cycloid and pin teeth are essential for optimizing the design, enhancing durability, and implementing predictive maintenance strategies for RV reducers.
Existing research on RV reducers has extensively covered areas such as transmission error analysis, tooth profile modification design, and static contact mechanics. However, studies focusing on the quantification and dynamic evolution of tooth wear are relatively scarce. Most wear models for gears, often based on the Archard wear equation, typically assume a constant wear coefficient. This is an oversimplification for the RV reducer’s unique meshing action. During a full engagement cycle, a single cycloid tooth contacts multiple pins under varying pressure angles, sliding velocities, and contact conditions. Consequently, the wear coefficient cannot be treated as a constant across the entire tooth profile. Furthermore, as wear progresses, it alters the tooth profile geometry. This change feeds back into the system, modifying the load distribution among simultaneously engaged teeth, the contact pressure, and the kinematic conditions—factors that subsequently influence the wear rate itself. Ignoring this coupled, dynamic interaction between wear evolution and system response leads to inaccurate wear predictions.
This article presents a comprehensive numerical framework for simulating the dynamic wear process on the tooth flanks of an RV reducer. The model integrates a nonlinear multi-body dynamic model of the RV transmission system, a discrete tooth contact analysis considering wear-induced profile errors, and a generalized Archard wear model with position-dependent wear coefficients determined through equivalent experimental tests. Taking a commercial BX-40E type RV reducer as a case study, we investigate the evolution of meshing forces, contact pressure distribution, relative sliding distance, and wear depth over multiple operating cycles. The results reveal unique wear patterns on the cycloid and pin profiles and quantify the feedback effect of wear on the system’s dynamic behavior.
Theoretical Modeling of the RV Reducer System
The RV reducer is a two-stage precision speed reducer. The first stage is a planetary gear train, and the second stage is a cycloidal-pin gear mechanism. The analysis in this work focuses primarily on the dynamics and wear of the second-stage cycloid drive, as it is the primary contributor to the overall reduction ratio and is highly susceptible to wear. A dynamic model of the BX-40E RV reducer system is established, incorporating the essential degrees of freedom and component interactions.
1.1 Geometric Analysis of the Worn Cycloid-Pin Tooth Pair
The geometry of the meshing pair is foundational for contact analysis. The standard profile of a cycloid tooth is generated by a circle rolling around the outside of the pin circle. When wear occurs, material is removed from the contacting surfaces, effectively acting as a time-varying profile modification. Considering the wear depth as a small deviation from the ideal profile, the modified equation for the cycloid tooth profile in the coordinate system fixed to the cycloid disc can be expressed as:
$$
\begin{align*}
x &= (R_p + \Delta R_p \cos \alpha_i) \cos(\theta – \theta_{iH}) – a \cos(\theta_{iH}) \\
&+ (R_{rp} + \Delta R_{rp}) S^{-1/2} \left[ K \cos(\theta_{iH}) – \cos(\theta – \theta_{iH}) \right] \\
y &= (R_p + \Delta R_p \cos \alpha_i) \sin(\theta – \theta_{iH}) + a \sin(\theta_{iH}) \\
&- (R_{rp} + \Delta R_{rp}) S^{-1/2} \left[ K \sin(\theta_{iH}) – \sin(\theta – \theta_{iH}) \right]
\end{align*}
$$
where \(R_p\) is the pin radius, \(R_{rp}\) is the pin center circle radius, \(a\) is the eccentricity, \(Z_p\) is the number of cycloid teeth, and \(K = a Z_p / R_p\) is the shortening coefficient. The term \(S = 1 + K^2 – 2K\cos\theta\). The wear depths on the cycloid and pin surfaces in the direction normal to the profile at the i-th contact point are denoted by \(\Delta R_p\) and \(\Delta R_{rp}\), respectively. The pressure angle \(\alpha_i\) at the contact point is a critical parameter governing the direction of the contact force and is given by:
$$
\alpha_i = \tan^{-1}\left( \frac{a Z_p \sin \phi_i}{R_p – a Z_p \cos \phi_i} \right)
$$
The equivalent curvature radius \(\rho_i\) at the contact point, required for Hertzian contact pressure calculation, is derived from the cycloid geometry:
$$
\rho_i = \frac{R_p S^{3/2}}{\left| K(Z_p+1)\cos\theta – (1+Z_p K^2) \right|} + R_{rp}
$$
1.2 Discrete Contact Force Model
In an RV reducer, approximately half of the cycloid teeth are in simultaneous contact with the pins, sharing the load. The contact between a cycloid tooth and a pin is modeled as line contact between two cylinders. A discrete contact analysis is performed by dividing the potential contact zone into a finite number of points. For each discrete point \(i\), the composite deformation \(\delta_i(t)\) consists of the rigid-body approach due to input torque and the accumulated wear error \(e_{cpi}(t)\):
$$
\delta_i(t) = \vartheta r_i – e_{cpi}(t)
$$
where \(\vartheta\) is the angular displacement of the cycloid disc under load, and \(r_i\) is the distance from the contact point’s line of action to the center of the pin circle. The wear error is \(e_{cpi}(t) = \Delta R_{pi} – \Delta R_{rpi}\). Contact is established only if \(\delta_i(t) \geq 0\). Based on the condition of deformation compatibility among all contacting teeth, the normal contact force \(F_{Ni}\) at the i-th meshing point can be solved as:
$$
F_{Ni} = \frac{4T_c \sin(\theta – \Delta\beta)}{K Z_c R_p S}
$$
where \(T_c\) is the torque on the cycloid disc, \(Z_c\) is the number of pins, and \(\Delta\beta\) is a small angle variation due to the wear error. The average contact pressure \(P_{Ni}\) is then calculated using the Hertzian formula for line contact:
$$
P_{Ni} = \frac{\pi \sigma_H}{4}, \quad \text{where} \quad \sigma_H = 0.418 \sqrt{\frac{E_c F_{Ni}}{b R}}
$$
Here, \(E_c\) is the equivalent elastic modulus, \(b\) is the face width of the cycloid gear, and \(R\) is the composite radius of curvature (\(1/R = 1/\rho_{cycloid} + 1/R_p\)).
To account for the dynamic nature of contact, especially during impact events like teeth engaging and disengaging due to wear, the Lankarani-Nikravesh contact force model is employed. This model includes a hysteresis damping component, making it suitable for impact analysis in multi-body systems:
$$
F_N = k \delta^{n} \left[ 1 + \frac{3(1-c_e^2)}{4} \frac{\dot{\delta}}{\dot{\delta}^{(-)}} \right]
$$
where \(k\) is the contact stiffness, \(\delta\) is the penetration depth, \(n\) is usually 1.5 for metallic contact, \(c_e\) is the coefficient of restitution, \(\dot{\delta}\) is the relative penetration velocity, and \(\dot{\delta}^{(-)}\) is the initial impact velocity.
1.3 System Dynamics Equations
A multi-degree-of-freedom translational-rotational dynamic model of the RV reducer is established. The model includes the rotational dynamics of the input sun gear, the planet gears, the crankshafts, the cycloid discs, and the output carrier, as well as the translational vibrations of the cycloid discs caused by the eccentric motion and wear-induced displacements. The equation of motion for the cycloid disc, considering wear-induced displacement errors (\(\delta x_{cyci}, \delta y_{cyci}\)), is given by:
$$
\begin{aligned}
m_{cyc} \ddot{\delta x}_{cyci} + \sum_{i=1}^{n} F_{Ni} \cos \beta_i + \sum_{i=1}^{2} F_{fsi} \cos \phi_i &= 0 \\
m_{cyc} \ddot{\delta y}_{cyci} + \sum_{i=1}^{n} F_{Ni} \sin \beta_i + \sum_{i=1}^{2} F_{fsi} \sin \phi_i &= 0 \\
J_{cyc} \ddot{\theta}_{cyc} + \sum_{i=1}^{n} F_{Ni} r_i + \sum_{i=1}^{2} (F_{fsi} r_c \sin \phi_i + F_{fsi} r_c \cos \phi_i) &= 0
\end{aligned}
$$
where \(m_{cyc}\) and \(J_{cyc}\) are the mass and mass moment of inertia of the cycloid disc, \(F_{fsi}\) are the bearing forces from the crankshaft, and \(\beta_i\) is the angle of the contact normal. The system equations are assembled into a matrix form and solved numerically using the Newmark-β integration method.
Dynamic Wear Model for the RV Reducer
2.1 Generalized Archard Wear Model
The wear on the tooth flanks of the RV reducer is modeled using the Archard wear equation, which is widely applicable for adhesive and abrasive wear mechanisms. The generalized form states that the wear volume \(V\) is proportional to the normal load \(W\) and the sliding distance \(S\), and inversely proportional to the material hardness \(H\):
$$
\frac{V}{S} = \kappa \frac{W}{H}
$$
For the purpose of simulating profile evolution, it is more convenient to work with wear depth \(h\). Assuming wear is uniform across the face width, the incremental wear depth \(\Delta h_i\) at a discrete point \(i\) on the tooth profile after a small sliding distance \(\Delta s_i\) is:
$$
\Delta h_i = \kappa_i p_i \Delta s_i
$$
where \(p_i\) is the contact pressure at point \(i\), and \(\kappa_i\) is the dimensionless wear coefficient specific to the local contact conditions at that point. The total wear depth after \(N\) operating cycles is obtained by cumulative summation:
$$
h_i(N) = \sum_{k=1}^{N} \kappa_i(k) \cdot p_i(k) \cdot s_i(k)
$$
This formulation highlights the need to determine \(\kappa_i\), which is not a universal constant but depends on factors like contact pressure, sliding speed, lubrication, and material pair.
2.2 Determination of Position-Dependent Wear Coefficient
To accurately capture the variation in wear rate across the tooth profile, the wear coefficient \(\kappa\) must be characterized as a function of local operating conditions. Given the complexity of direct measurement on the actual RV reducer gear, an equivalent experimental approach is adopted. The contact between a cycloid tooth and a pin is analogous to the sliding contact between a flat or curved block and a rotating ring. Therefore, pin-on-disk wear tests are conducted using specimens made of the same materials as the RV reducer components (e.g., GCr15 bearing steel).
| Parameter | Upper Specimen (Pin) | Lower Specimen (Disk) |
|---|---|---|
| Material | GCr15 | GCr15 |
| Diameter | 5 mm | 50 mm |
| Normal Load | 20, 40, 60, 80 N | – |
| Rotational Speed | – | 30 rpm |
| Surface Roughness, Ra | 3.2 µm | 3.2 µm |
The tests are run under controlled conditions covering a range of normal loads representative of the contact pressures found in the RV reducer. The wear mass is measured at regular intervals. The instantaneous wear coefficient \(\kappa(t)\) for the test configuration is calculated from the measured data:
$$
\kappa(t) = \frac{Q(t)}{2\pi (n_1 r_1 – n_2 r_2) F_N \rho t}
$$
where \(Q(t)\) is the wear mass loss, \(n\) and \(r\) are rotational speeds and radii, \(F_N\) is the applied normal load, \(\rho\) is the material density, and \(t\) is time. The results show that \(\kappa\) is not constant; it decreases with time as the surface run-in occurs and tends to stabilize. More importantly, \(\kappa\) increases with the applied normal load. This relationship \(\kappa = f(p, v, …)\) is extracted from the experimental data. In the numerical simulation, for each discrete contact point \(i\) on the tooth profile, the local contact pressure \(p_i\) and sliding velocity \(v_i\) are calculated dynamically. The corresponding wear coefficient \(\kappa_i\) is then interpolated from the experimentally derived map based on these local conditions. This method provides a more realistic and accurate representation of the wear process than using a single averaged value.
2.3 Calculation of Dynamic Relative Sliding Distance
A key factor in the wear equation is the relative sliding distance between the cycloid tooth and the pin. In ideal kinematics, the cycloid drive has pure rolling at the pitch point. However, due to profile modifications, elastic deformations, and especially the continuously changing geometry caused by wear, relative sliding occurs across the entire active profile. The sliding velocity \(v_s\) at a contact point can be derived from kinematic analysis of the eccentric mechanism:
$$
v_s = |u_1 – u_2|
$$
where \(u_1\) is the linear velocity of the cycloid tooth at the contact point and \(u_2\) is the linear velocity of the pin. Considering the geometry and the eccentric motion, these velocities are functions of the angular velocity \(\omega\), the eccentricity \(a\), the pin circle radius \(R_{rp}\), and the instantaneous meshing angle \(\theta\). The incremental sliding distance \(\Delta s_i\) for a discrete time step \(\Delta t\) is simply \(\Delta s_i = v_{s,i} \cdot \Delta t\). This value is accumulated over the contact period for each profile point during a mesh cycle.
Results and Discussion
The developed dynamic wear simulation framework is applied to the BX-40E RV reducer operating under a steady output torque of 400 Nm and an output speed of 300 rpm. The wear evolution is simulated over a significant number of operating cycles (representing long-term wear). The following sections present and analyze the key results.
3.1 Dynamic Meshing Force and Load Distribution
The dynamic meshing force, which is the sum of all individual tooth-pair contact forces, exhibits periodic fluctuations. The fluctuation amplitude is approximately 1.8% of the mean force, reflecting the dynamic excitations from time-varying mesh stiffness and wear-induced errors. The engagement process can be divided into two phases: a region of decaying oscillation during initial contact (Region I) and a region with impact-like behavior during disengagement (Region II).
The distribution of force among the simultaneously engaged tooth pairs is crucial. Figure YY shows the force carried by each tooth pair as a function of its meshing position (from root to tip) for different cumulative wear cycles. The force distribution pattern resembles an inverted “V” or “入” shape. As wear accumulates, two primary effects are observed: (1) The number of teeth sharing the load decreases, and (2) The load on the remaining teeth increases non-uniformly. Teeth near the root and tip regions experience more severe load increases and may even lose contact temporarily (“de-meshing”), only to re-engage with impact. A strong linear correlation is found between the meshing force on a tooth pair and its corresponding pressure angle \(\alpha_i\) at that instant:
$$
F_{Ni} \propto \alpha_i
$$
This relationship stems from the force equilibrium conditions in the cycloid drive mechanism.
| Wear Cycles | Max. Single Tooth Force (N) | Approx. Number of Loaded Teeth | Force Increase from Initial (%) |
|---|---|---|---|
| 0 (Initial) | 350 | ~18 | 0 |
| 2,490 | 385 | ~17 | 10 |
| 4,980 | 400 | ~16 | 14.3 |
3.2 Contact Pressure Distribution
The contact pressure distribution along the tooth profile directly drives the wear process. The pressure profile generally follows the force distribution but exhibits a distinct feature: a noticeable pressure drop occurs precisely at the profile inflection point (where the cycloid tooth curvature changes from convex to concave). At this point, the equivalent radius of curvature is minimal, which, according to Hertz theory, leads to a reduction in contact pressure for a given load. With progressive wear, the overall contact pressure level rises due to the reduced load-sharing capacity, as shown in the table below. The pressure increment is non-linear, initially slowing down as surfaces harden and then potentially accelerating as severe wear alters the profile drastically.
| Wear Cycles | Max. Contact Pressure (MPa) | Pressure at Inflection Point (MPa) | Avg. Pressure Increase (MPa) |
|---|---|---|---|
| 0 | 12.0 | 8.0 | 0 |
| 2,490 | 12.18 | 8.04 | 0.04 |
| 4,980 | 12.20 | 8.08 | 0.08 |
3.3 Relative Sliding Distance
The relative sliding distance per mesh cycle varies significantly along the tooth profile. For both the cycloid tooth and the pin, the sliding distance profile is asymmetric and M-shaped. The most significant finding is that the sliding distance approaches zero in the vicinity of the profile inflection point. This aligns with the theoretical kinematical property of the cycloid drive, where the pitch point (theoretically pure rolling) is located near this region. The magnitude of sliding increases with wear because the altered profile geometry disrupts the ideal rolling conditions. The sensitivity of sliding distance to wear depth is highest in the regions flanking the inflection point, covering about two-thirds of the active profile.
3.4 Wear Depth Profile and Evolution
The simulated wear depth profiles for the cycloid and pin teeth reveal a characteristic and complex pattern, best described as an asymmetric, irregular double-peak (“W”) shape. The results from the model using variable wear coefficients are compared conceptually with a simplified model using a constant coefficient.
Key Features of the Wear Profile:
- Double Wear Peaks (Sensitive Zones): Two primary peaks in wear depth occur on either side of the profile inflection point. These zones correspond to regions of high contact pressure and significant sliding distance, resulting in maximum wear rates. They constitute the wear-sensitive areas of the tooth profile.
- Wear Valley at Inflection Point: At the inflection point itself, wear is minimal. This is a direct consequence of the locally low contact pressure and nearly zero sliding distance predicted by the model.
- Micro-Peaks near Root and Tip: Small, secondary peaks in wear depth appear near the very root and tip of the cycloid tooth. This is a dynamic effect caused by wear. As these regions wear, they can temporarily lose contact (de-mesh). Subsequent re-engagement often occurs with impact, leading to higher instantaneous loads and localized wear spikes. This phenomenon is captured only by the dynamic model that accounts for wear-induced profile errors and time-varying mesh conditions.
Effect of Variable vs. Constant Wear Coefficient: The importance of using a position-dependent wear coefficient \(\kappa_i\) is evident. A model assuming a constant \(\kappa\) produces a smoother, single-hump wear profile that fails to predict the double-peak structure and the micro-peaks at the ends. The quantitative wear depth in the sensitive zones is significantly underestimated by the constant-kappa model, while it may be overestimated in other regions. The discrepancy between the two models widens as the number of wear cycles increases, demonstrating that the feedback effect amplified by the variable wear rate is crucial for accurate long-term wear prediction.
Wear Evolution Over Cycles: As operation continues, wear depth accumulates non-uniformly. The wear rate (depth increment per cycle) is not constant. Initially, the rate may be higher during the run-in period. As wear progresses and load concentration increases, the wear rate’s growth itself tends to slow down non-uniformly, likely due to work-hardening of the surface material and the changing contact geometry. The sensitive wear zones become slightly more concentrated (narrower) with increased cycles.
| Tooth | Location | Wear Depth after 5k cycles (µm) – Var. κ | Wear Depth after 5k cycles (µm) – Const. κ | Key Observation |
|---|---|---|---|---|
| Cycloid | Primary Peak 1 | ~9.8 | ~6.5 | Underestimated by constant κ |
| Inflection Valley | ~0.5 | ~2.0 | Overestimated by constant κ | |
| Root Micro-Peak | ~2.5 | Not Present | Dynamic de-mesh/re-mesh effect | |
| Pin | Primary Peak | ~8.5 | ~5.8 | Similar underestimation |
| Corresponding Valley | ~1.0 | ~2.3 | Similar overestimation |
Conclusion
This study developed an integrated numerical framework for simulating the dynamic wear process in the critical cycloid-pin gear pair of an industrial robot RV reducer. The model uniquely combines a nonlinear multi-body dynamic model, a discrete contact analysis accounting for wear-induced geometry changes, and a generalized Archard wear model with wear coefficients determined from equivalent experiments that reflect local contact conditions.
The simulation of the BX-40E RV reducer case yielded significant insights. The wear coefficient for the gear pair material is not constant but varies with contact pressure, validating the need for its experimental characterization. The dynamic interaction between wear and system response is critical: wear alters the load distribution, increasing force and pressure on remaining teeth and inducing dynamic events like de-meshing and re-meshing impacts, particularly near the tooth root and tip.
The resulting wear profile on both the cycloid and pin teeth is complex, featuring asymmetric double peaks flanking the profile inflection point, a wear valley at the inflection point itself, and micro-peaks at the profile extremities due to dynamic impacts. These features are not predicted by models using a constant wear coefficient, highlighting the importance of the presented methodology for accurate wear life prediction.
The findings provide a theoretical foundation for improving the wear resistance of RV reducers. The identified wear-sensitive zones inform targeted profile modifications or surface treatments. Furthermore, the model can be used as a tool for optimizing RV reducer design parameters and operating conditions to minimize wear and extend the service life of these precision components, thereby enhancing the reliability and accuracy of industrial robots.