
In my extensive experience with bulk material handling equipment, particularly bucket wheel reclaimers, the reliability of ancillary systems is paramount for continuous operation. One persistent point of failure I have encountered is within the control cable winding mechanism. The core of this mechanism is a specific type of screw gear reducer, where a worm (the screw) drives a worm wheel. The chronic issues observed in this screw gear assembly necessitated a fundamental redesign of its axial constraint system. This article details the failure analysis, the engineering principles behind the corrective modification, and the quantifiable results achieved. The focus will remain on the technical aspects of the screw gear drive, utilizing formulas and tables to summarize the design logic and validation.
The primary function of the control cable drum drive is to synchronize the winding and unwinding of the vital control cable with the reclaimer’s travel. The drive assembly comprises an electric motor vertically mounted atop a worm gear reducer. This motor directly drives the input worm shaft. The rotation of this worm shaft engages with and drives the bronze worm wheel. The worm wheel is keyed directly to the shaft of the cable drum, thereby transmitting the necessary torque for coiling and uncoiling operations. The entire system is encapsulated in a housing filled with lubricating oil.
The fundamental problem stemmed from the inherent kinematic characteristic of a screw gear pair. The meshing action between the worm and the worm wheel is analogous to a screw thread advancing a nut. Consequently, during power transmission, a significant axial force is generated along the axis of the worm shaft. The magnitude of this axial force is directly proportional to the transmitted torque. In the original design, while some provision existed to restrain upward movement, the design was inadequate in constraining the downward axial thrust generated under typical and peak load conditions. This persistent downward force led to a cascade of mechanical failures.
Failure Mode and Effects Analysis of the Original Screw Gear Assembly
The unconstrained axial movement had several detrimental effects, which I systematically investigated:
- Bearing Failure: The persistent axial load was primarily borne by the radial support bearings at the bottom of the worm shaft. These bearings were not designed to handle substantial continuous thrust loads, leading to premature fatigue, brinelling, and ultimately, catastrophic failure.
- Gear Wear and Contamination: The axial play altered the optimal meshing contact pattern between the hardened steel worm and the bronze worm wheel. This misalignment accelerated wear, generating fine particulates of bronze and steel. These wear particles settled in the oil sump, acting as abrasives that further accelerated the wear of all components and degraded the lubricant’s properties.
- Reduced Transmission Accuracy and Vibration: The developed axial clearance introduced backlash and irregular motion into the screw gear transmission. This resulted in torsional vibrations, audible noise, and reduced positioning accuracy for the cable drum, potentially causing uneven winding.
- Risk of Shaft Failure: In extreme cases, the cyclical bending stress induced by the misalignment and shock loads could contribute to fatigue cracking and eventual fracture of the worm shaft itself.
The following table summarizes this failure analysis:
| Observed Failure Mode | Root Cause | Direct Consequence |
|---|---|---|
| Worm Shaft Support Bearing Seizure/Spalling | Sustained unconstrained axial thrust load on radial bearings. | Loss of rotation, overheating, potential for shaft lock-up. |
| Excessive Bronze Wear on Worm Wheel | Poor meshing contact due to axial movement of worm. | Increased backlash, metal contamination of oil, loss of torque capacity. |
| Increased Noise and Vibration | Axial play and resulting backlash in the screw gear mesh. | Reduced system stability, accelerated wear of all components. |
| Lubricant Degradation | Infiltration of wear particles (copper and iron). | Loss of lubricity, increased friction and wear. |
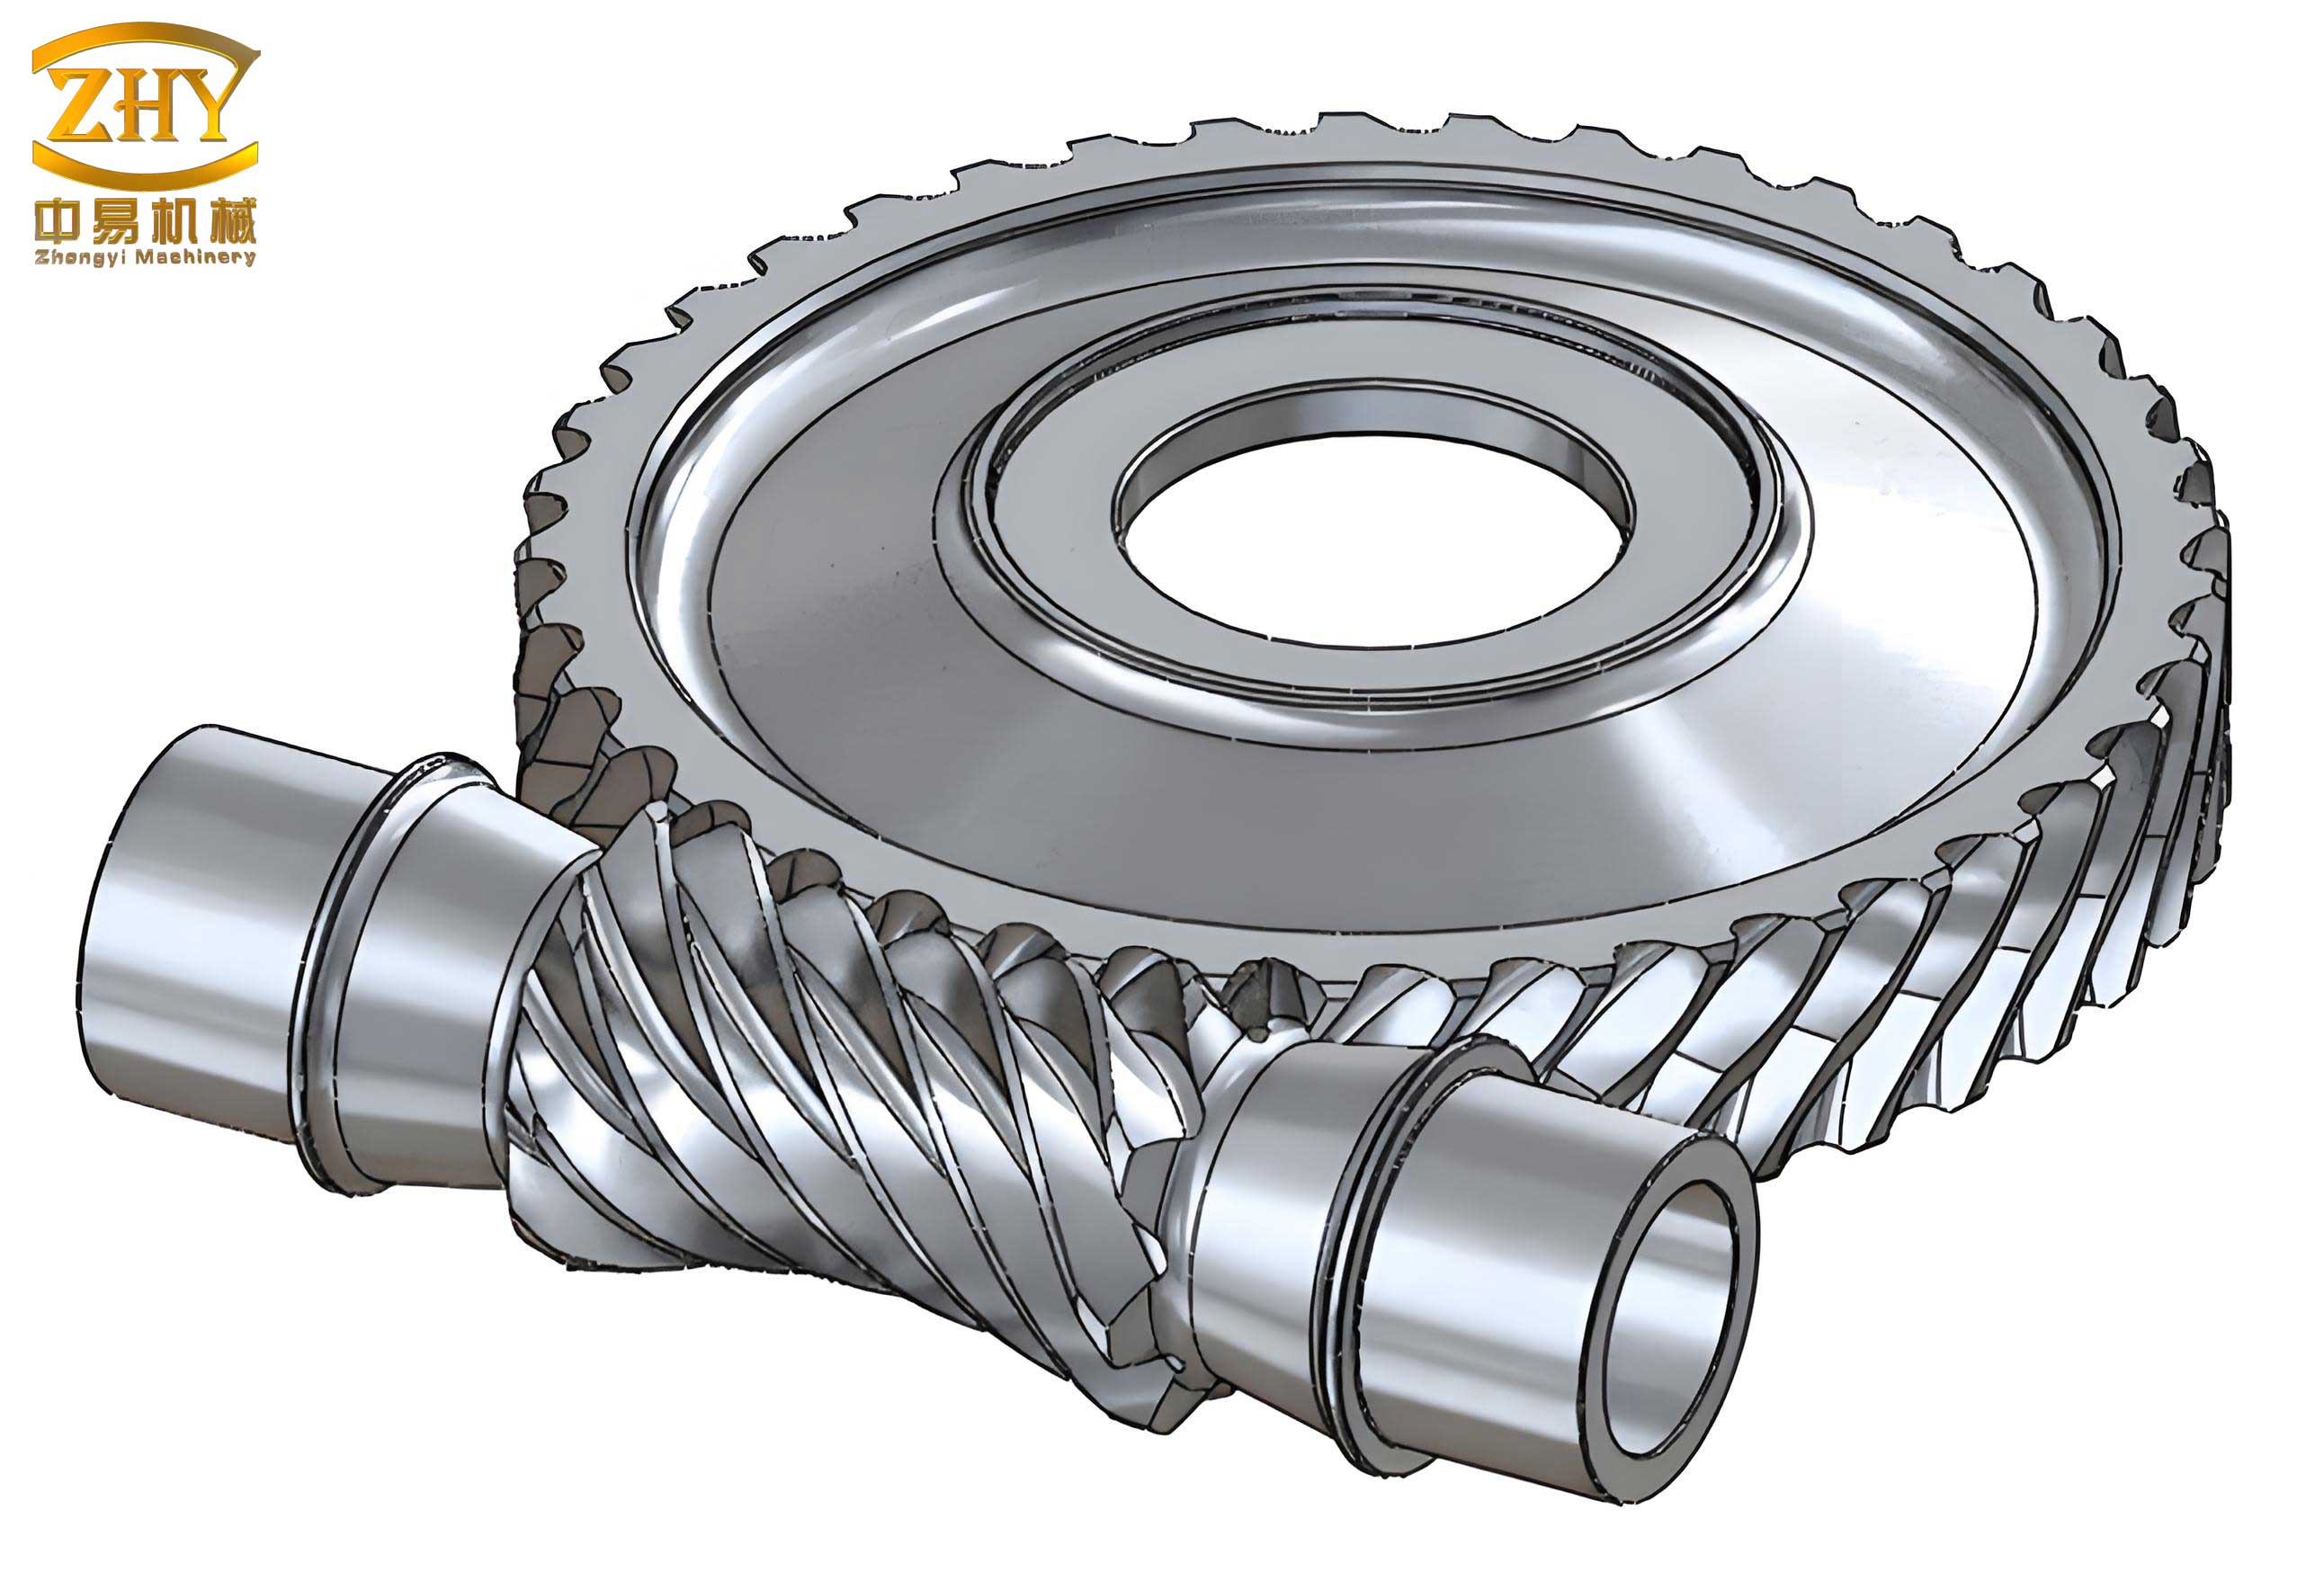
The image above illustrates the general geometry of a screw gear pair, highlighting the helical nature of the worm which is responsible for generating the axial thrust force during operation. This visual reference is key to understanding the core challenge we needed to address in the redesign.
Engineering Analysis: Quantifying the Axial Force
To design an appropriate solution, it was first necessary to quantify the axial force ($F_a$) acting on the worm shaft. The force generated in a screw gear system can be derived from the transmitted torque and the geometry of the worm. The primary relationship is given by:
$$ F_a = \frac{2T}{D_w} $$
where $T$ is the torque on the worm wheel and $D_w$ is the pitch diameter of the worm wheel. However, the input parameter is the torque on the worm shaft from the motor. A more practical formula relating the input torque ($T_{in}$) at the worm to the axial force considers the efficiency ($\eta$) of the screw gear pair:
$$ F_a = \frac{2 T_{in} i \eta}{D_w} $$
where $i$ is the gear ratio. For a single-start worm, the ratio $i$ is approximately equal to the number of teeth on the worm wheel ($N_w$). Since $T_{out} = T_{in} i \eta$, the initial formula holds, using the output torque. From the reducer’s nameplate and design data, the key parameters were:
- Maximum Output Torque, $T_{max}$ = 100 daN·m = 1000 N·m
- Worm Wheel Pitch Diameter, $D_w$ = 120 mm = 0.12 m
- Estimated Worm Gear Efficiency, $\eta$ = 0.75
Applying the formula with the output torque:
$$ F_a = \frac{2 \times T_{max}}{D_w \eta} = \frac{2 \times 1000 \, \text{N·m}}{0.12 \, \text{m} \times 0.75} $$
$$ F_a \approx \frac{2000}{0.09} \approx 22,222 \, \text{N} $$
This calculation provides a theoretical maximum. A more conservative estimate for sustained operational load would be lower. For the purpose of selecting a thrust bearing, a design axial load ($F_{a, design}$) of 5000 N was considered adequate, factoring in a significant safety margin and dynamic load conditions. The original design’s omission of a dedicated thrust bearing meant this entire force, cyclically applied, was being inadequately handled.
The Reconstruction: Design and Implementation of a Thrust Bearing System
The core objective of the modification was to introduce a dedicated, adjustable mechanism to absorb the downward axial thrust from the worm shaft, thereby protecting the radial support bearings and stabilizing the screw gear mesh. The solution involved designing and installing a thrust bearing assembly at the bottom end of the worm shaft, within the constraints of the existing reducer housing.
Design Concept: The concept was to create a “landing” point for the worm shaft. A custom flange would be mounted to the bottom of the reducer housing. A hardened thrust post with a conical tip would be inserted through this flange. This tip would engage a center drill hole in the bottom of the worm shaft. A thrust ball bearing would be placed between the base of this post and an adjustable screw mechanism within the flange. This arrangement directly transfers the worm’s axial load through the thrust bearing and into the rigid housing via the flange, completely bypassing the original radial bearings for thrust loads.
Component Specification: Each component was meticulously designed and machined from Grade 45 steel for strength and wear resistance. The key component specifications are tabulated below:
| Component No. | Description | Key Dimensions & Specifications | Material & Function |
|---|---|---|---|
| 1 | Mounting Flange | Ø130 mm x 85 mm long. Bore: Ø68 mm (45 mm deep) + M64x4 internal thread (40 mm deep). | 45 Steel. Provides rigid mounting to reducer housing and houses the bearing assembly. |
| 2 | Thrust Ball Bearing | Type 51307. Dynamic load capacity ($C$) = 100,500 N. | Commercial Bearing. Directly absorbs the axial thrust force. $C \gg F_{a,design}$, ensuring longevity. |
| 3 | Thrust Post (with conical tip) | Custom shaft with conical tip to engage worm shaft center. | 45 Steel, hardened. Transmits axial force from worm shaft to Bearing (2). |
| 4 | Lock Washer | Ø70 mm, 5 mm thick. | 45 Steel. Prevents loosening of the adjustment nut. |
| 5 | Lock Nut | M64x4, 50 mm thick. | 45 Steel. Locks the final adjustment in place. |
| 6 | Adjustment Screw | M64x4 thread, 75 mm long, with 38 mm square drive head. | 45 Steel. Allows precise setting of worm shaft axial preload/clearance. |
Installation and Adjustment Procedure:
1. The original bottom cover of the reducer was removed.
2. The mounting flange (Component 1) was secured to the machined bottom face of the reducer housing using four M8 bolts.
3. The thrust bearing (51307) was placed into the large bore of the flange.
4. The thrust post (Component 3) was inserted through the bearing, with its conical tip engaging the center hole of the worm shaft.
5. The adjustment screw (Component 6) was threaded into the base of the flange, applying upward force on the outer race of the thrust bearing.
6. The critical step was adjusting the screw to apply a slight preload, eliminating the axial play in the screw gear assembly without causing excessive binding. This was done by feel and by checking the rotational torque of the input shaft.
7. Once optimal setting was achieved, the lock washer (4) and lock nut (5) were tightened against the adjustment screw to prevent any rotation due to vibration.
The fundamental improvement is demonstrated by comparing the force paths. In the original design, the path was: Worm Axial Force → Worm Shaft → Radial Support Bearing (failed) → Housing. In the new design, the path is: Worm Axial Force → Worm Shaft → Thrust Post → Thrust Ball Bearing → Adjustment Screw/Lock Nut → Mounting Flange → Housing. This dedicated path is designed explicitly for thrust loads.
Performance Evaluation and Conclusion
The reconstructed screw gear reducer system was subjected to over one year of continuous operation in a demanding port environment. The performance outcomes were systematically positive:
- Elimination of Axial Movement: The thrust bearing assembly successfully arrested all measurable axial displacement of the worm shaft, confirmed by dial indicator measurements during maintenance.
- Dramatic Reduction in Wear: Inspection after one year showed minimal wear on the bronze worm wheel and the worm threads. The lubricant remained clean and free of excessive metallic debris.
- Elimination of Vibration and Noise: The screw gear transmission operated smoothly and quietly, indicating stable meshing and eliminated backlash.
- Extended Component Life: The original radial support bearings, now relieved of axial duty, showed no signs of premature wear.
- Increased Operational Availability: The chronic failures were eliminated, removing unplanned downtime associated with the control cable drive and increasing the overall equipment utilization rate.
The following table contrasts key performance indicators before and after the reconstruction:
| Performance Indicator | Before Reconstruction | After Reconstruction |
|---|---|---|
| Worm Shaft Axial Play | Greater than 0.5 mm, increasing with use. | Less than 0.05 mm (effectively zero). |
| Bearing Replacement Interval | 6-12 months due to thrust-induced failure. | Expected life aligned with standard L10 life for radial loads (>5 years). |
| Oil Contamination Rate | High; required biannual changes. | Low; annual change sufficient. |
| Transmission Noise/Vibration | Significant, increasing over time. | Negligible, stable over time. |
| System Reliability | Low; a known recurrent failure point. | High; integrated into routine preventive maintenance. |
In conclusion, the failure of the original screw gear reducer was a classic case of an incomplete mechanical design that did not adequately address the fundamental force vectors generated by its own operating principle. By performing a detailed force analysis and designing a simple yet robust auxiliary thrust bearing system, the root cause was mitigated. This reconstruction serves as a pertinent case study in the importance of proper axial constraint in any screw gear application. The solution is characterized by its conceptual simplicity, mechanical effectiveness, and significant return on investment through enhanced reliability and reduced maintenance costs. The principles applied—quantifying operational forces, selecting appropriate bearing elements, and ensuring adjustable, lockable preload—are universally applicable to the redesign and maintenance of similar power transmission systems.