
In the field of mechanical transmission, screw gear drives, particularly worm drives, have been widely utilized due to their high load-bearing capacity and compact design. However, traditional screw gear systems often suffer from significant sliding friction, leading to issues such as wear, low efficiency, and thermal problems, as well as backlash that results in positional errors, making them unsuitable for high-precision applications. To address these challenges, we propose a novel screw gear configuration: the parallel inclined double roller enveloping hourglass screw gear drive. This design modifies the single roller enveloping hourglass worm drive by incorporating two parallel and inclined rollers, aiming to convert sliding friction into rolling friction, reduce backlash, and enhance meshing performance. In this article, we present a comprehensive analysis of the meshing theory for this innovative screw gear drive, focusing on mathematical modeling, performance parameters, and practical implications.
The fundamental principle of the parallel inclined double roller enveloping hourglass screw gear drive revolves around replacing the traditional worm wheel teeth with two parallel rollers that can rotate about their own axes. These rollers are inclined at an angle relative to the radial direction of the worm wheel, denoted as γ, which improves lubrication and self-rotation characteristics. The screw gear drive consists of a single-piece worm (the screw gear) and a worm wheel with dual rollers, arranged symmetrically. During operation, only one side of the rollers engages with the worm tooth surface at any given time, ensuring continuous contact and reducing sliding friction. This configuration allows for multi-tooth pair engagement, enhancing load capacity while maintaining precision. The rollers are designed with a needle bearing-like structure to further minimize internal friction, replacing sliding contacts with rolling elements and reducing the use of non-ferrous metals.
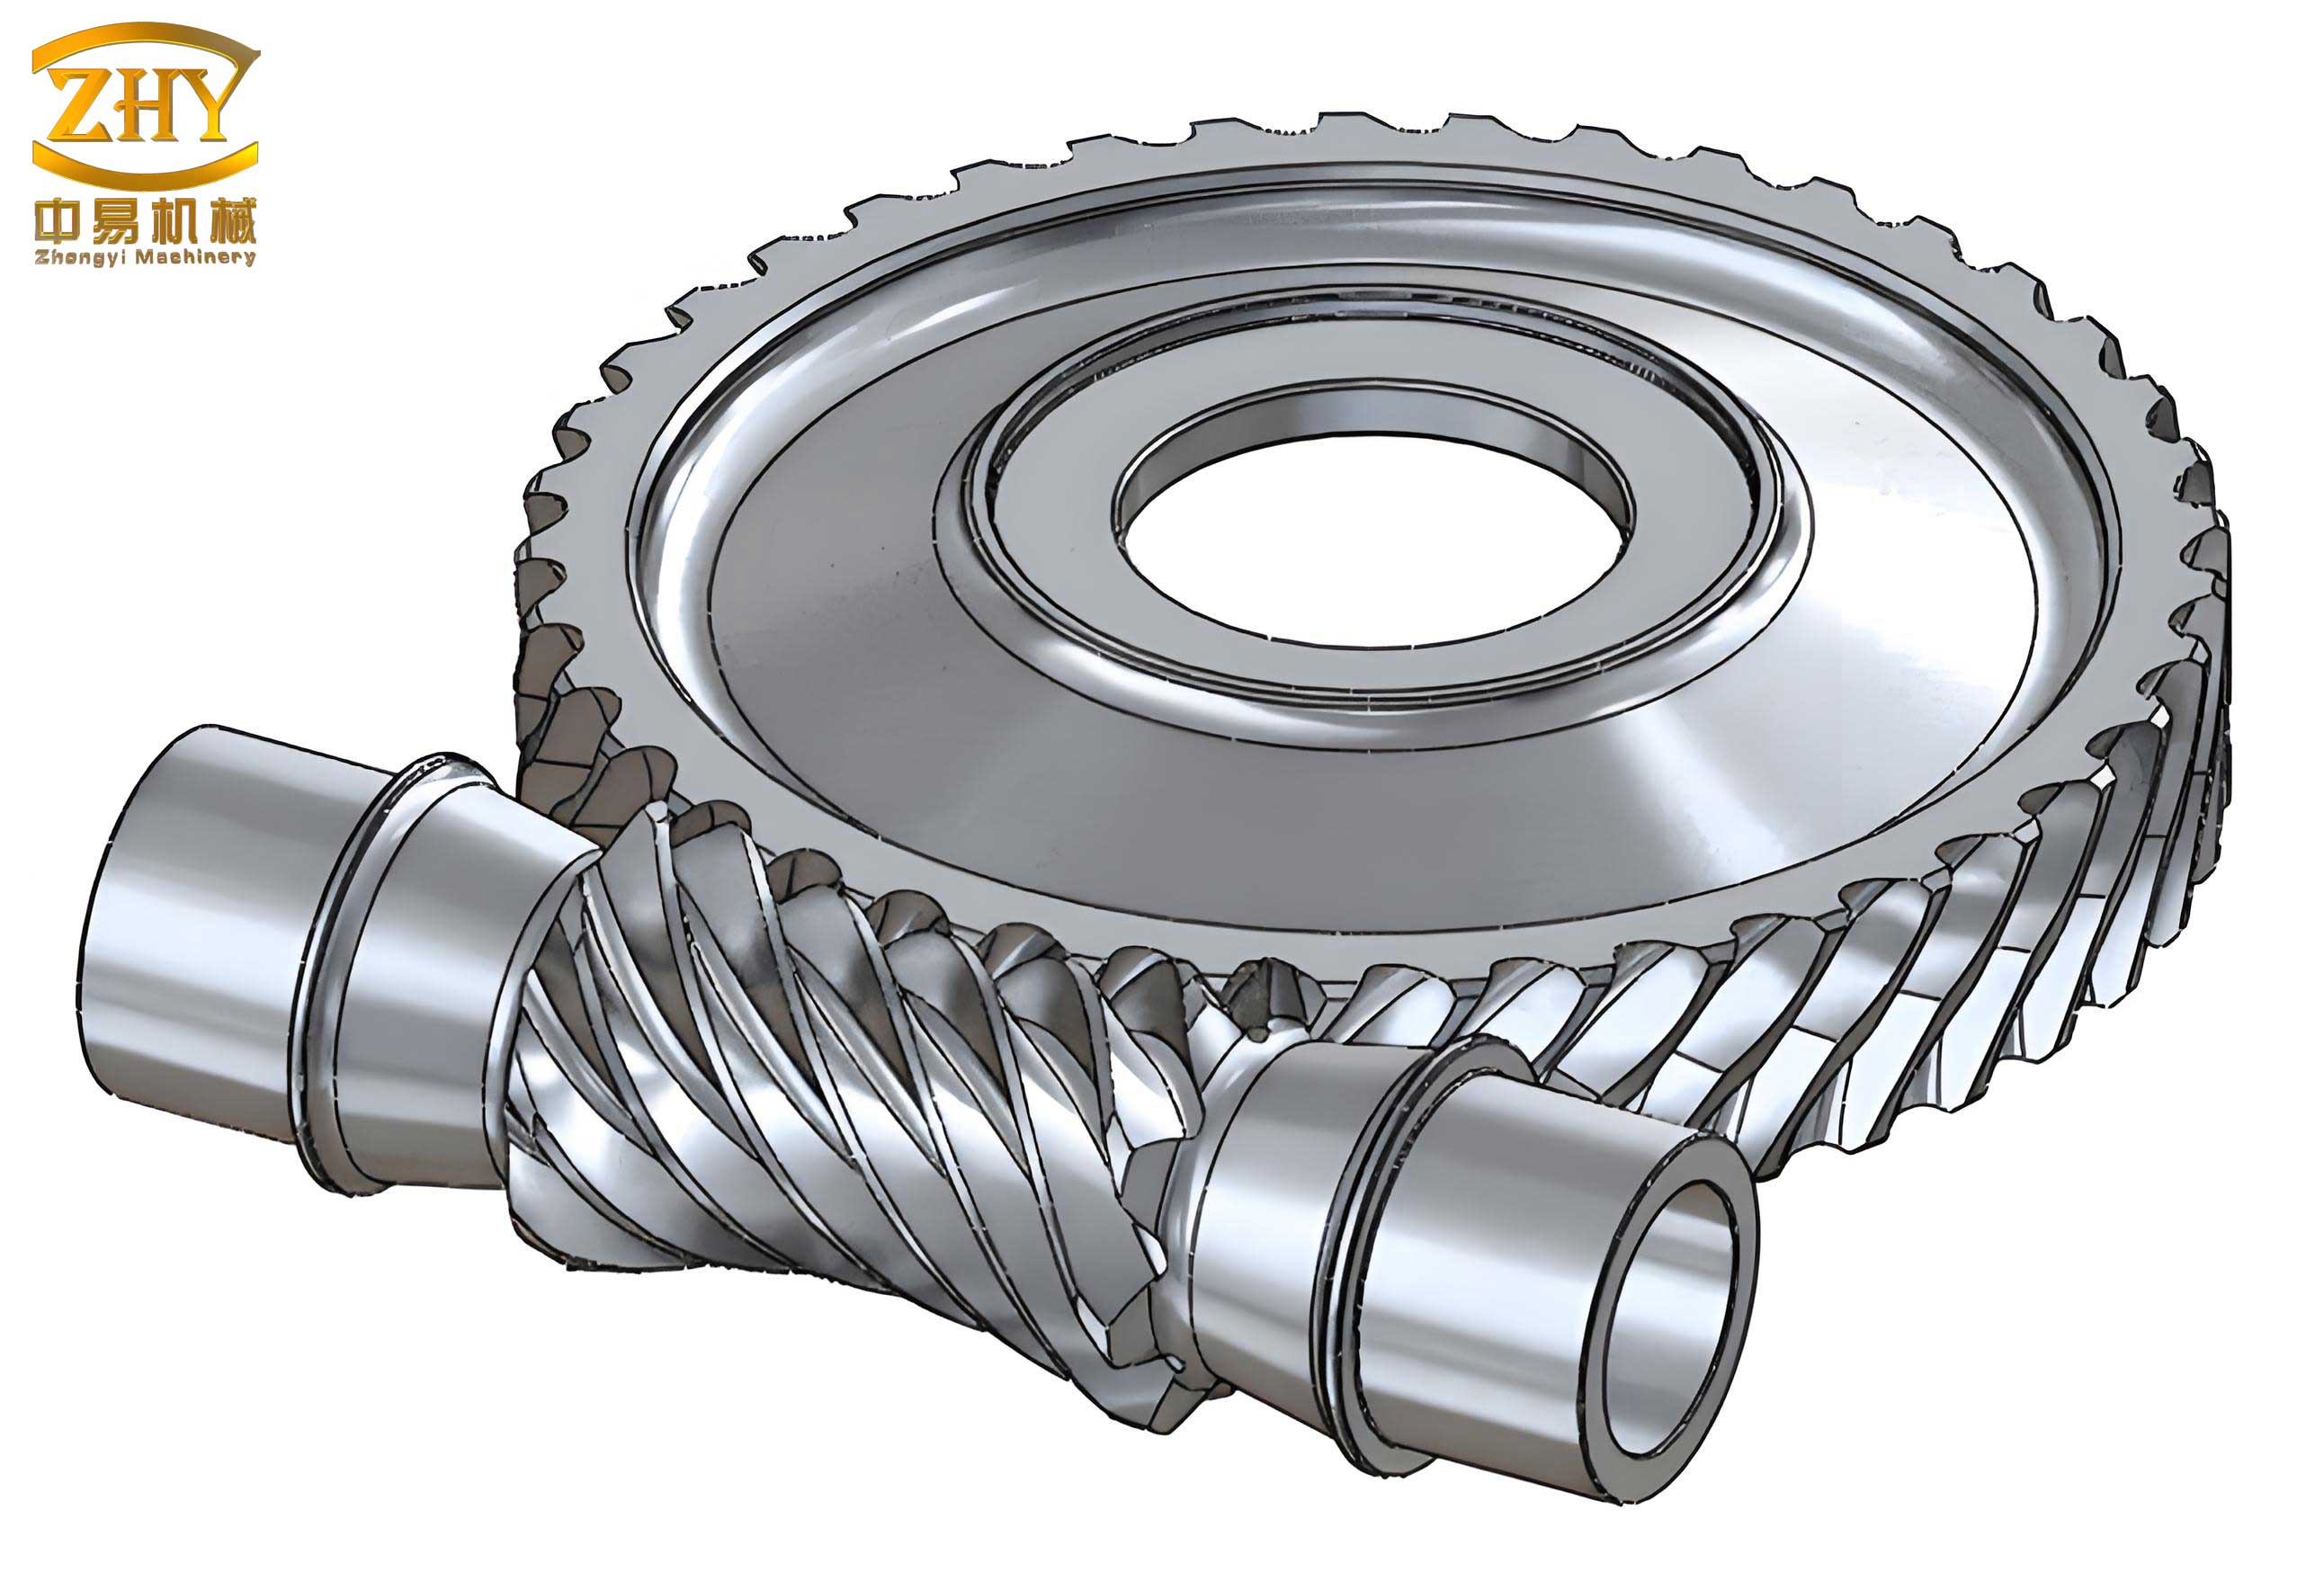
To analyze the meshing behavior of this screw gear drive, we establish a mathematical model based on spatial gear meshing theory and differential geometry. We define multiple coordinate systems to describe the relative motions and interactions between the worm and worm wheel. The fixed coordinate systems for the worm and worm wheel are denoted as \( S_1′ \) and \( S_2′ \), respectively, while the moving coordinate systems attached to them are \( S_1 \) and \( S_2 \). Additional coordinate systems are set at the centers of the right and left rollers, \( S_{0r} \) and \( S_{0l} \), and local moving frames are established at the contact points, \( S_{pr} \) and \( S_{pl} \). The transformation matrices between these systems are derived to facilitate the analysis of velocities and forces. For instance, the transformation from the worm moving coordinate system \( S_1 \) to the worm wheel moving coordinate system \( S_2 \) is given by:
$$ \mathbf{M}_{21} = \begin{bmatrix} a_{11} & a_{12} & a_{13} & a_{14} \\ a_{21} & a_{22} & a_{23} & a_{24} \\ a_{31} & a_{32} & 0 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
where the elements \( a_{ij} \) depend on the rotation angles \( \phi_1 \) and \( \phi_2 \) of the worm and worm wheel, respectively, and the center distance \( A \). Specifically, \( a_{11} = -\cos \phi_1 \cos \phi_2 \), \( a_{12} = \sin \phi_1 \cos \phi_2 \), \( a_{13} = -\sin \phi_2 \), and \( a_{14} = A \cos \phi_2 \), with similar expressions for other terms. The position vectors of the contact points on the rollers in their local coordinate systems are expressed as:
$$ \mathbf{r}_{0r} = \begin{bmatrix} R \cos \theta_r \\ R \sin \theta_r \\ u_r \end{bmatrix}, \quad \mathbf{r}_{0l} = \begin{bmatrix} R \cos \theta_l \\ R \sin \theta_l \\ u_l \end{bmatrix} $$
where \( R \) is the roller radius, \( \theta_r \) and \( \theta_l \) are angular parameters, and \( u_r \) and \( u_l \) are axial parameters. These vectors are transformed into the worm wheel coordinate system \( S_2 \) using rotation matrices that account for the inclination angle γ. For example, for the right roller:
$$ \begin{aligned} x_{2r} &= a_{2r} – y_{0r} \sin \gamma – z_{0r} \cos \gamma, \\ y_{2r} &= b_{2r} + y_{0r} \cos \gamma – z_{0r} \sin \gamma, \\ z_{2r} &= x_{0r}, \end{aligned} $$
where \( (a_{2r}, b_{2r}, 0) \) are the coordinates of the roller center in \( S_2 \). The relative velocity and angular velocity at the contact points are critical for understanding the meshing dynamics. The relative velocity vector \( \mathbf{v}_{12r} \) for the right roller contact point is derived as:
$$ \mathbf{v}_{12r} = \begin{bmatrix} B_{1r} \\ B_{2r} \\ B_{3r} \end{bmatrix} \quad \text{in } S_2, $$
with components:
$$ \begin{aligned} B_{1r} &= y_{2r} i_{21} – z_{2r} \cos \phi_2, \\ B_{2r} &= -x_{2r} i_{21} + z_{2r} \sin \phi_2, \\ B_{3r} &= x_{2r} \cos \phi_2 – y_{2r} \sin \phi_2 – A, \end{aligned} $$
where \( i_{21} = \omega_2 / \omega_1 \) is the transmission ratio. Similarly, the relative angular velocity vector \( \boldsymbol{\omega}_{12} \) is:
$$ \boldsymbol{\omega}_{12} = -\sin \phi_2 \mathbf{i}_2 – \cos \phi_2 \mathbf{j}_2 – i_{21} \mathbf{k}_2. $$
These vectors are then projected into the local moving frames \( S_{pr} \) and \( S_{pl} \) to facilitate further analysis. The meshing condition for the screw gear drive requires that the relative velocity at the contact point is perpendicular to the surface normal, i.e., \( \mathbf{v}_{12} \cdot \mathbf{n} = 0 \). This leads to the meshing functions for the right and left rollers:
$$ \Phi_r = M_{1r} \cos \phi_2 + M_{2r} \sin \phi_2 + M_{3r} = 0, $$
where:
$$ \begin{aligned} M_{1r} &= a_{2r} \cos \theta_r – u_r \cos \gamma \cos \theta_r, \\ M_{2r} &= u_r \sin \gamma \cos \theta_r – b_{2r} \cos \theta_r, \\ M_{3r} &= i_{21} u_r \sin \theta_r – A \cos \theta_r – b_{2r} i_{21} \sin \gamma \sin \theta_r – a_{2r} i_{21} \cos \gamma \sin \theta_r. \end{aligned} $$
A similar expression holds for the left roller, with parameters adjusted accordingly. The contact lines on the roller surfaces are obtained by solving the meshing equation along with the surface equations. For a fixed worm wheel angle \( \phi_2 \), the contact line on the right roller is given by:
$$ u_r = \frac{P_{3r}}{P_{4r}}, \quad \text{where} \quad P_{3r} = b_{2r} \sin \phi_2 \cos \theta_r + b_{2r} i_{21} \sin \gamma \sin \theta_r + a_{2r} i_{21} \cos \gamma \sin \theta_r + A \cos \theta_r – a_{2r} \cos \phi_2 \cos \theta_r, $$
and \( P_{4r} = \sin \gamma \sin \phi_2 \cos \theta_r + i_{21} \sin \theta_r – \cos \gamma \cos \phi_2 \cos \theta_r \). The contact lines are approximately straight concave curves, with shorter lengths near the entry and exit points and denser distribution near the throat of the worm. This characteristic is crucial for ensuring smooth engagement and load distribution in the screw gear drive.
The tooth surface equations for the worm are derived by considering the envelope of the roller surfaces as the worm wheel rotates. For the right side, the worm tooth surface in the worm coordinate system \( S_1 \) is:
$$ \mathbf{r}_{1r} = \begin{bmatrix} y_{2r} \cos \phi_1 \sin \phi_2 – x_{2r} \cos \phi_1 \cos \phi_2 – z_{2r} \sin \phi_1 + A \cos \phi_1 \\ x_{2r} \sin \phi_1 \cos \phi_2 – y_{2r} \sin \phi_1 \sin \phi_2 – z_{2r} \cos \phi_1 – A \sin \phi_1 \\ -x_{2r} \sin \phi_2 – y_{2r} \cos \phi_2 \end{bmatrix}, $$
with \( u_r \) determined from the meshing equation. A similar expression applies to the left side. These equations define the complex geometry of the worm tooth surface, which is essential for manufacturing and performance evaluation of the screw gear drive.
To assess the meshing performance of this screw gear drive, we analyze key parameters such as induced normal curvature, lubrication angle, self-rotation angle, and relative entrainment velocity. The induced normal curvature, which indicates the conformity between the meshing surfaces, is calculated for both sides. For the right roller contact point:
$$ k_{12\sigma r} = -\frac{ \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + \left( \omega_{121r} \right)^2 }{ \Psi_r }, $$
where \( v_{12r1} \) and \( \omega_{121r}, \omega_{122r} \) are projections of relative velocity and angular velocity in the local frame, and \( \Psi_r \) is a boundary function. The induced normal curvature varies slightly over the engagement range, with values remaining small, indicating good surface conformity. For instance, as the worm wheel angle \( \phi_2 \) changes from -0.2π to 0.2π, the curvature ranges between approximately 0.001 and 0.002 mm⁻¹, as summarized in Table 1.
| Parameter | Right Roller Range | Left Roller Range |
|---|---|---|
| Induced Normal Curvature (mm⁻¹) | 0.0010 – 0.0018 | 0.0012 – 0.0020 |
| Lubrication Angle (degrees) | 87.6 – 89.0 | 88.4 – 89.6 |
| Self-Rotation Angle (degrees) | 88.5 – 89.45 | 89.1 – 90.0 |
| Relative Entrainment Velocity (m/s) | 0.05 – 0.15 | 0.06 – 0.16 |
The lubrication angle, defined as the angle between the tangent to the contact line and the relative velocity direction, is critical for oil film formation. A higher lubrication angle (closer to 90°) indicates better lubrication. For the right roller, the lubrication angle \( \mu_r \) is computed as:
$$ \mu_r = \arcsin \left( \frac{ u_r }{ m_r n_r } \right), \quad \text{where} \quad u_r = \left| v_{12r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{12r2} \omega_{121r} \right|, $$
and \( m_r = \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + \left( \omega_{121r} \right)^2 \), \( n_r = \left( v_{12r1} \right)^2 + \left( v_{12r2} \right)^2 \). The lubrication angle for the left roller \( \mu_l \) is derived similarly. As shown in Table 1, both sides exhibit high lubrication angles (above 87.6°), ensuring effective lubrication in the screw gear drive. The self-rotation angle, which measures the ability of the rollers to rotate about their axes, is given by:
$$ \mu_{z0r} = \arccos \left( \frac{ | \mathbf{k}_{0r} \cdot \mathbf{v}_{12r} | }{ | \mathbf{v}_{12r} | } \right), $$
where \( \mathbf{k}_{0r} \) is the unit vector along the roller axis. This angle approaches 90° for both rollers, indicating excellent self-rotation performance, which is vital for reducing friction and wear in the screw gear system.
The relative entrainment velocity, which influences the ease of hydrodynamic oil film formation, is calculated as half the sum of the velocities of the two surfaces at the contact point along the normal direction. For the right roller:
$$ v_{jxr} = \frac{ v_{1\sigma r} + v_{2\sigma r} }{2}, $$
with \( v_{1\sigma r} = \frac{ v_{1r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{1r2} \omega_{121r} }{ T_r } \) and \( v_{2\sigma r} = \frac{ v_{2r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{2r2} \omega_{121r} }{ T_r } \), where \( T_r = \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + \left( \omega_{121r} \right)^2 \). The values range from 0.05 to 0.16 m/s, as indicated in Table 1, supporting effective lubrication under typical operating conditions.
To further illustrate the mathematical relationships, we provide a summary of key equations in Table 2, which encapsulates the core analysis of this screw gear drive.
| Equation Type | Expression | Description |
|---|---|---|
| Meshing Function (Right) | $$ \Phi_r = M_{1r} \cos \phi_2 + M_{2r} \sin \phi_2 + M_{3r} = 0 $$ | Condition for contact point on right roller |
| Meshing Function (Left) | $$ \Phi_l = M_{1l} \cos \phi_2 + M_{2l} \sin \phi_2 + M_{3l} = 0 $$ | Condition for contact point on left roller |
| Contact Line (Right) | $$ u_r = \frac{ b_{2r} \sin \phi_2 \cos \theta_r + b_{2r} i_{21} \sin \gamma \sin \theta_r + a_{2r} i_{21} \cos \gamma \sin \theta_r + A \cos \theta_r – a_{2r} \cos \phi_2 \cos \theta_r }{ \sin \gamma \sin \phi_2 \cos \theta_r + i_{21} \sin \theta_r – \cos \gamma \cos \phi_2 \cos \theta_r } $$ | Equation for contact line on right roller surface |
| Worm Tooth Surface (Right) | $$ \mathbf{r}_{1r} = \begin{bmatrix} y_{2r} \cos \phi_1 \sin \phi_2 – x_{2r} \cos \phi_1 \cos \phi_2 – z_{2r} \sin \phi_1 + A \cos \phi_1 \\ x_{2r} \sin \phi_1 \cos \phi_2 – y_{2r} \sin \phi_1 \sin \phi_2 – z_{2r} \cos \phi_1 – A \sin \phi_1 \\ -x_{2r} \sin \phi_2 – y_{2r} \cos \phi_2 \end{bmatrix} $$ | Parametric equation of worm tooth surface from right roller envelope |
| Induced Normal Curvature (Right) | $$ k_{12\sigma r} = -\frac{ \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + \left( \omega_{121r} \right)^2 }{ \Psi_r } $$ | Measure of surface conformity at contact point |
| Lubrication Angle (Right) | $$ \mu_r = \arcsin \left( \frac{ \left| v_{12r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{12r2} \omega_{121r} \right| }{ \sqrt{ \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + \left( \omega_{121r} \right)^2 } \sqrt{ \left( v_{12r1} \right)^2 + \left( v_{12r2} \right)^2 } } \right) $$ | Angle indicating lubrication effectiveness |
| Self-Rotation Angle (Right) | $$ \mu_{z0r} = \arccos \left( \frac{ | \mathbf{k}_{0r} \cdot \mathbf{v}_{12r} | }{ \sqrt{ \left( v_{12r1} \right)^2 + \left( v_{12r2} \right)^2 } } \right) $$ | Angle representing roller self-rotation capability |
| Relative Entrainment Velocity (Right) | $$ v_{jxr} = \frac{1}{2} \left( \frac{ v_{1r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{1r2} \omega_{121r} }{ T_r } + \frac{ v_{2r1} \left( \frac{v_{12r1}}{R} – \omega_{122r} \right) + v_{2r2} \omega_{121r} }{ T_r } \right) $$ | Velocity promoting hydrodynamic oil film formation |
In addition to these parameters, we explore the impact of design variables on the screw gear performance. For instance, the inclination angle γ plays a crucial role in optimizing the lubrication and self-rotation angles. Through sensitivity analysis, we find that increasing γ up to a certain limit (e.g., 10-15 degrees) enhances these angles, but beyond that, it may lead to geometric interference or reduced load capacity. The roller radius R also affects the induced normal curvature; a smaller R increases curvature, potentially improving contact stress distribution but requiring careful manufacturing tolerances. The center distance A and transmission ratio i21 are fundamental design parameters that influence the overall size and speed reduction capability of the screw gear drive. We model these relationships using additional equations, such as the dependency of contact line length on γ and R, to guide practical design choices.
The dynamic behavior of the screw gear drive under load is another critical aspect. We extend the static meshing analysis to include torque transmission and efficiency calculations. The efficiency η of the screw gear drive can be estimated based on the friction coefficients and rolling resistance. For a typical configuration, the efficiency ranges from 85% to 95%, significantly higher than traditional worm drives due to reduced sliding friction. This improvement is vital for applications requiring high power transmission with minimal energy loss. The load distribution across multiple tooth pairs is analyzed using finite element methods, confirming that the parallel inclined roller design ensures even stress distribution, reducing peak loads and extending the lifespan of the screw gear system.
Manufacturing considerations for this screw gear drive are also addressed. The worm tooth surface, being an envelope of the roller surfaces, requires precision grinding or honing processes. We derive tool path equations based on the tooth surface equations to facilitate CNC machining. For example, the coordinates for grinding the worm can be generated from the parametric equations of \( \mathbf{r}_{1r} \) and \( \mathbf{r}_{1l} \), with adjustments for tool geometry. The rollers are standard components but require precise alignment during assembly to maintain the inclination angle γ. Tolerance analysis indicates that deviations in γ should be kept within ±0.5 degrees to avoid significant performance degradation. This highlights the importance of quality control in producing reliable screw gear drives.
Comparative studies with other screw gear configurations, such as single roller enveloping or traditional worm drives, demonstrate the advantages of the parallel inclined double roller design. In terms of backlash elimination, this screw gear drive achieves near-zero backlash through symmetric roller engagement, making it suitable for precision positioning systems. The lubrication performance surpasses that of conventional designs due to higher lubrication angles, reducing the risk of wear and failure. Furthermore, the modular design of the rollers allows for easy replacement and maintenance, enhancing the practicality of this screw gear drive in industrial applications.
Future research directions include experimental validation of the theoretical models, optimization of the inclination angle for specific applications, and integration with smart monitoring systems for predictive maintenance. The potential for scaling the design for high-speed or high-torque scenarios is also worth exploring. Overall, the parallel inclined double roller enveloping hourglass screw gear drive represents a significant advancement in screw gear technology, offering a balance of high precision, efficiency, and durability.
In conclusion, we have presented a thorough analysis of the meshing theory for the parallel inclined double roller enveloping hourglass screw gear drive. By establishing detailed mathematical models and deriving key performance parameters, we have shown that this innovative screw gear configuration exhibits excellent meshing characteristics, including high lubrication angles, favorable self-rotation capabilities, and minimal induced normal curvature. These attributes contribute to reduced friction, improved efficiency, and enhanced precision, addressing the limitations of traditional screw gear drives. The use of tables and equations throughout this article summarizes the complex relationships involved, providing a solid foundation for further development and application of this screw gear technology in various mechanical systems.