
The manufacturing of high-performance hyperboloid gears represents a critical challenge in modern powertrain systems for automotive, aerospace, and heavy machinery applications. These gears are indispensable for transmitting power between non-parallel, non-intersecting axes, offering significant advantages such as high load-bearing capacity, large reduction ratios, and smooth, quiet operation. Traditional machining methods, while precise, suffer from inherent drawbacks including low material utilization, severed metal fiber lines which compromise bending fatigue strength, and relatively low production efficiency. Consequently, net-shape or near-net-shape forging has emerged as a highly attractive alternative for mass production. However, the complex geometry of hyperboloid gears, characterized by curved teeth and varying pressure angles, often leads to challenges like incomplete die filling, especially in fillet regions, and insufficient dimensional accuracy post-forging. Subsequent finishing operations, if performed via cutting or grinding, negate the very benefits of forging by cutting through the work-hardened surface and dense fiber lines, leading to reduced gear life and increased tool wear.
To address this technological gap, this article introduces and elaborates on an innovative cold rotary forging (also known as orbital forging) scheme specifically designed for the precision finishing of forged hyperboloid gear wheels. The proposed method fundamentally simplifies die design and utilizes a localized, line-contact, continuous plastic forming process. While this approach successfully reduces forming forces and optimizes material flow, it introduces a significant challenge inherent to all cold forming processes: springback. Springback is the elastic recovery of the workpiece material upon the removal of the forming load, causing deviations from the intended die geometry. For precision components like hyperboloid gears, uncompensated springback can critically affect meshing performance, noise, vibration, and longevity. Therefore, the successful implementation of this advanced cold rotary forging technology is contingent upon developing and applying a robust, iterative system for springback error prediction and die compensation. This work details such a system, employing a displacement adjustment algorithm within an iterative framework powered by finite element analysis (FEA), thereby eliminating the need for costly and time-consuming physical trial-and-error in die development.
The Proposed Cold Rotary Forging Scheme for Hypoid Gears
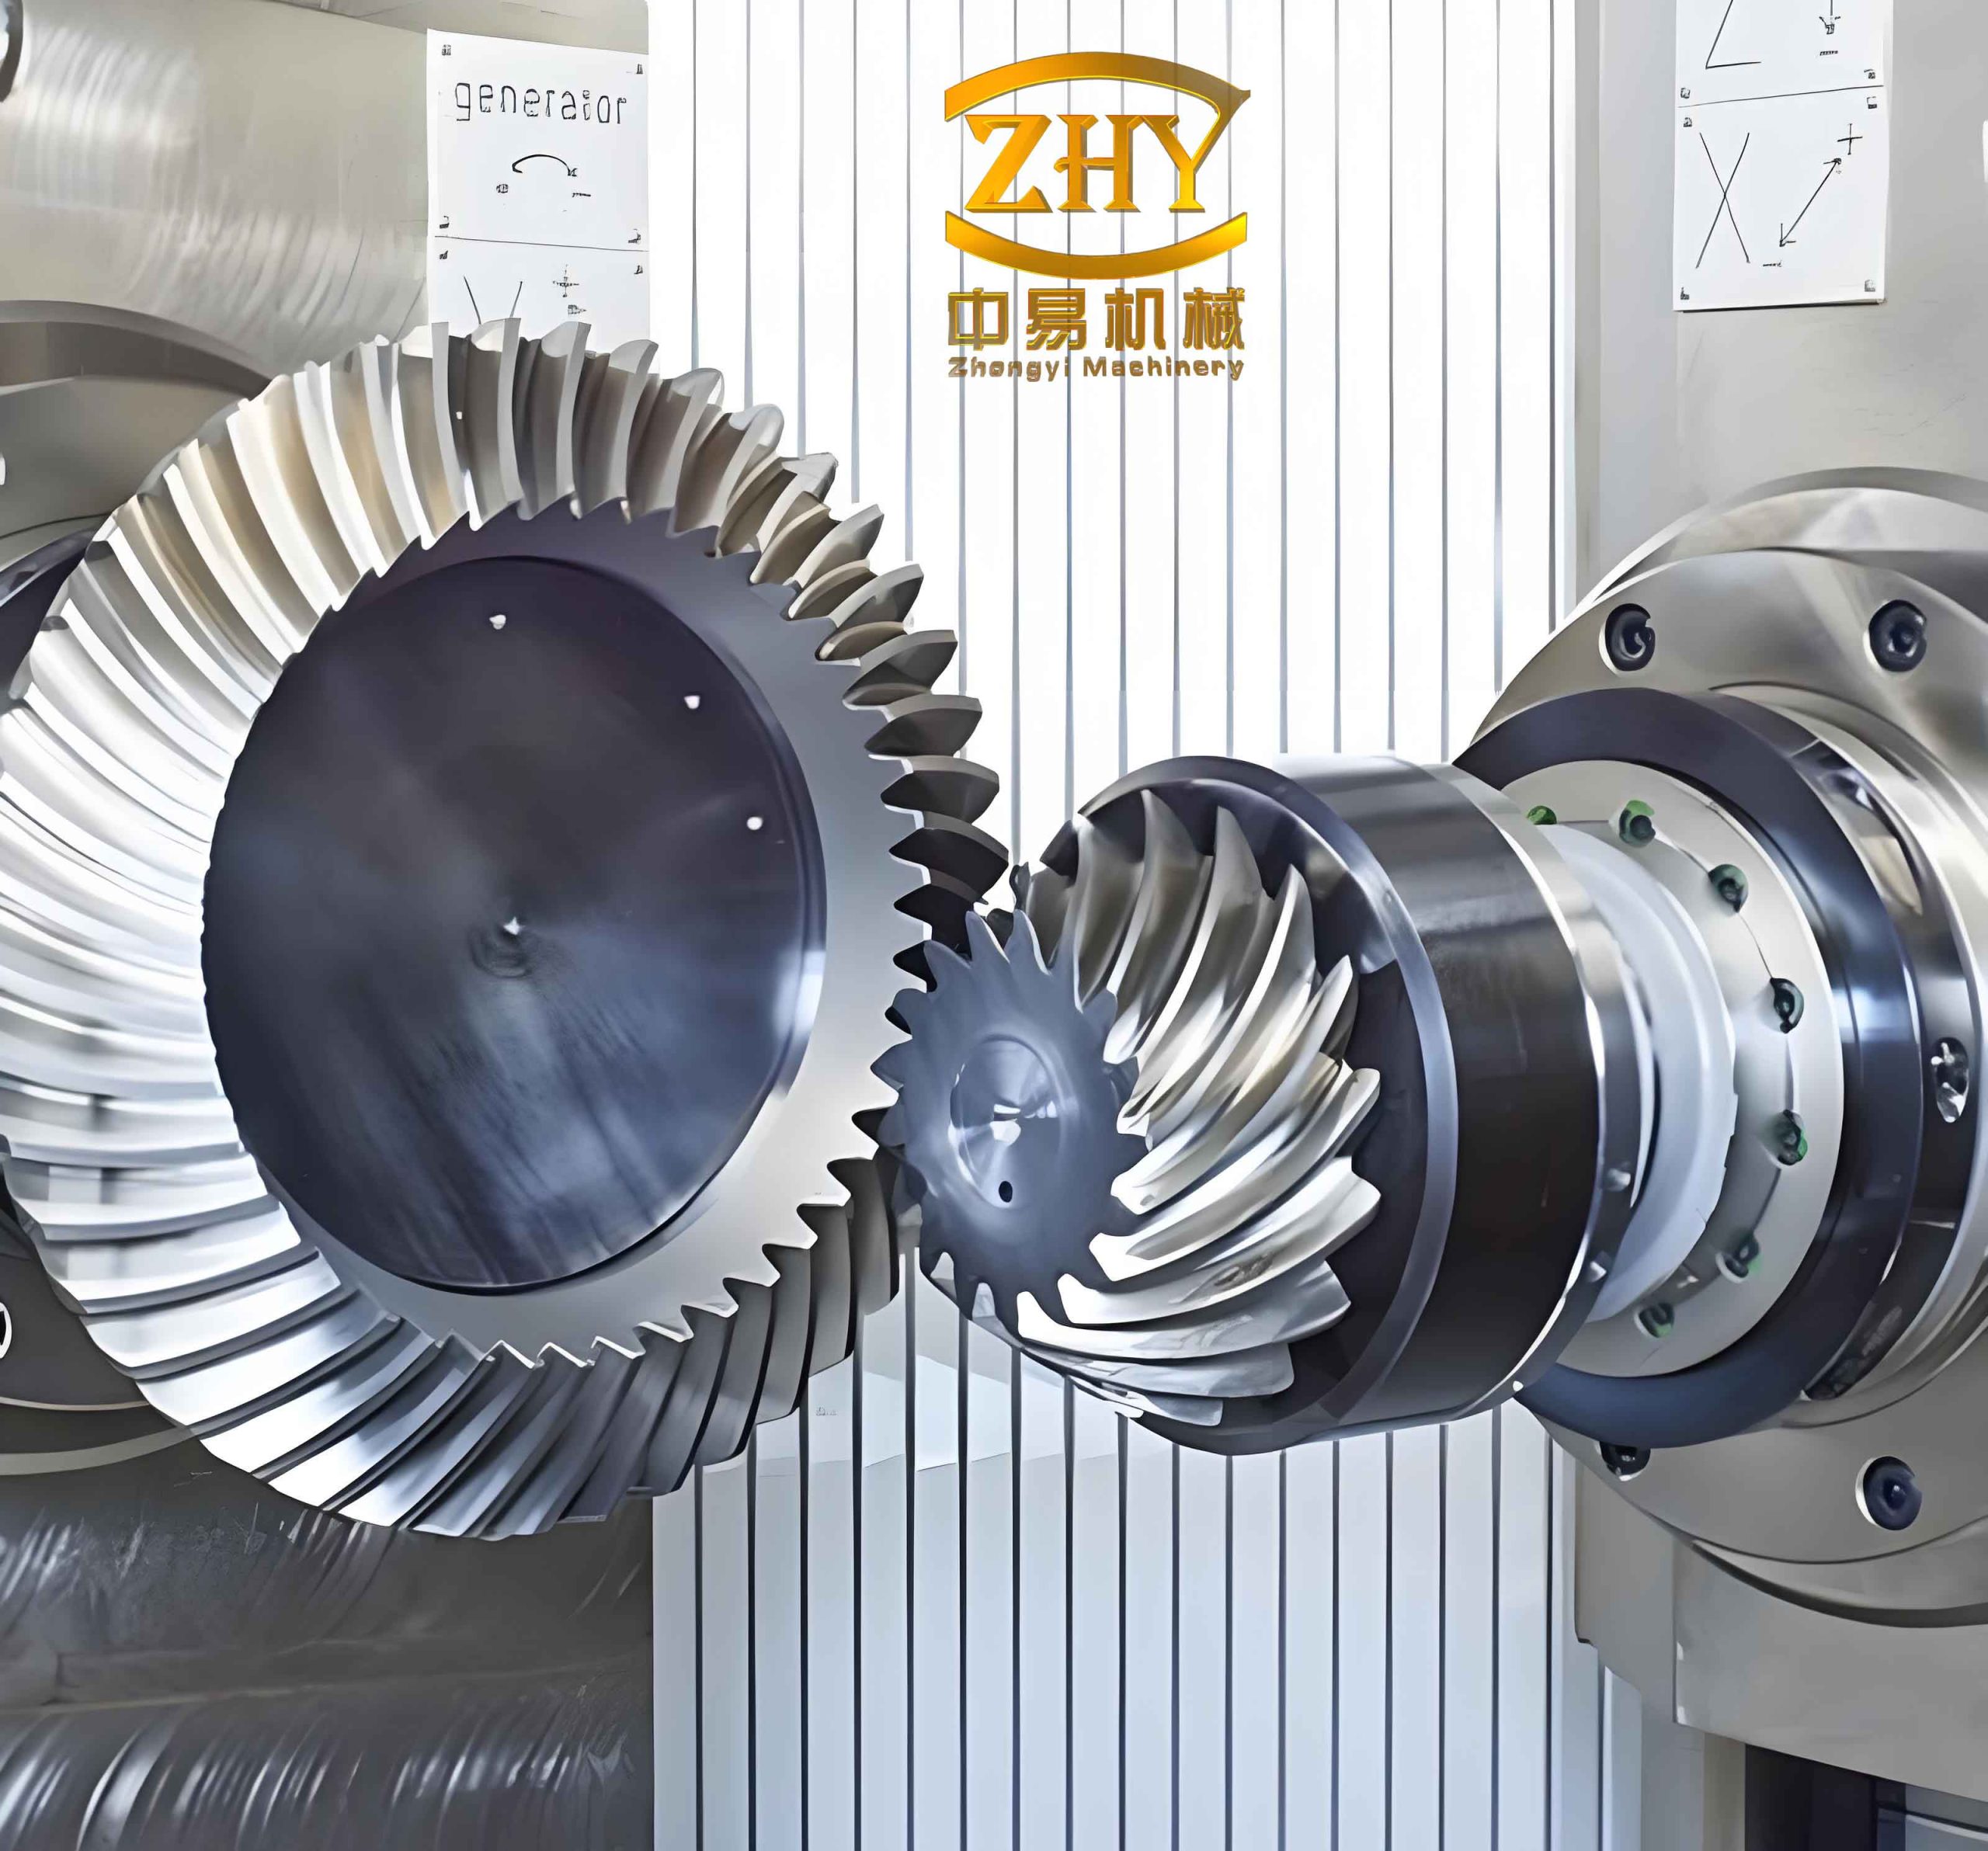
The core innovation of the proposed finishing technique lies in its simulation of the form-grinding process used in conventional gear manufacturing, adapted for single-tooth, incremental plastic forming. Unlike conventional forging with complex, full-tooth cavity dies, this method employs a remarkably simple trapezoidal die. The axial cross-section of this trapezoidal die is designed to be geometrically congruent with the normal cross-section of the theoretical gear tooth slot at the point of contact.
The die is mounted on a conical pendulum head, which is itself tilted at a specific angle relative to the machine’s central axis. This precise orientation ensures instantaneous line contact between the trapezoidal die face and the target tooth slot surface. During the operation, the die undergoes a compound motion: it revolves around the machine’s central axis (orbital motion) while simultaneously rotating about its own geometric axis (spinning motion). This controlled motion ensures that the contact line between the die and the workpiece continuously traverses along the ideal tooth flank surface, precisely mirroring the path of a grinding wheel in form-grinding. The process is characterized by highly localized plastic deformation, significantly reducing the required forming tonnage. After one tooth is completed, the gear blank is indexed to present the next tooth slot to the forging die.
The advantages of this scheme are multifaceted:
- Simplified Die Construction: The trapezoidal die is far easier and cheaper to manufacture, heat-treat, and maintain compared to a full, complex cavity die for an entire hyperboloid gear.
- Reduced Forming Force: The line-contact, incremental nature of deformation drastically lowers the instantaneous load, allowing for the use of smaller-capacity machinery.
- Improved Material Properties: The process induces favorable grain flow lines along the tooth profile and root, enhancing bending fatigue strength—a critical performance metric for hyperboloid gears.
- Elimination of Secondary Machining: A properly designed and compensated process can achieve the required surface finish and dimensional accuracy, making subsequent grinding or cutting operations unnecessary.
The Springback Error Compensation System: An Iterative Framework
Springback control in metal forming generally follows two principal strategies: process parameter control and die geometry compensation. Given that the final shape of a cold rotary forged hyperboloid gear tooth is a cumulative result of the entire forming and elastic recovery history, influenced by a multitude of interacting factors (die geometry, material hardening behavior, friction, contact conditions), adjusting process parameters alone is often insufficient to achieve the micron-level accuracy required. Therefore, a die compensation strategy is essential.
This work constructs an integrated, simulation-driven iterative compensation system. The system employs the displacement adjustment method, recognized for its effectiveness and convergence speed. The overarching workflow is as follows:
- Initial Die Design: A CAD model of the initial cold rotary forging die is created based purely on the target (nominal) geometry of the hyperboloid gear tooth slot.
- Finite Element Simulation (Forming & Springback): A coupled explicit-implicit FEA is performed. The explicit analysis simulates the dynamic cold rotary forging process. The resulting deformed workpiece, with its internal stress state, is then imported into an implicit static analysis where the forming constraints are removed to calculate the equilibrium state—the sprung-back shape.
- Error Evaluation: The nodal coordinates of the sprung-back tooth flank surface are extracted. This surface is compared against the target CAD surface using 3D metrology software (conceptually represented). The deviation at each node, $\delta_i$, is computed.
- Die Correction via Displacement Adjustment: If the maximum error $\max(|\delta_i|)$ exceeds a predefined tolerance $\varepsilon$, the die is corrected. The correction algorithm does not directly modify the die. Instead, it first calculates a hypothetical “pre-springback” workpiece shape that, if it were formed and then sprung back, would ideally land on the target shape. This desired intermediate shape $C^{t+1}$ for the next iteration $(t+1)$ is calculated from the current iteration’s $(t)$ results:
$$ C^{t+1} = C^{t} + \alpha (S^{t} – R) $$
where:- $R$ is the vector of nodal coordinates of the target (reference) surface.
- $S^{t}$ is the vector of nodal coordinates of the sprung-back surface from iteration $t$.
- $C^{t}$ is the vector of nodal coordinates for the “pre-springback” shape used in iteration $t$ (initially, $C^{0} = R$).
- $\alpha$ is the compensation factor, typically a negative value between -2.5 and -1.0, which accelerates convergence.
Once $C^{t+1}$ is determined, the new required trapezoidal die profile is derived backwards based on the fundamental kinematics of the line-contact process described earlier. Essentially, the die’s axial profile is extracted from a normal section of the new target preform shape $C^{t+1}$.
- Iteration: Steps 2-4 are repeated with the updated die geometry until the condition $\max(|\delta_i|) < \varepsilon$ is satisfied.
This closed-loop system effectively replaces expensive physical try-outs with numerical experiments, dramatically reducing development time and cost for forging hyperboloid gears.
Mathematical Modeling and FEA Implementation
The success of the iterative compensation system hinges on accurate numerical simulation. The modeling is based on the theory of elastoplastic finite element analysis.
Material Constitutive Model
The workpiece material (typically a case-hardenable steel like 20CrMnTi for automotive hyperboloid gears) is modeled as an isotropic, rate-independent elastoplastic solid following the Von Mises yield criterion and associated flow rule. The plastic hardening behavior is often described by a power law:
$$ \sigma = K \varepsilon^n $$
where $\sigma$ is the true stress, $\varepsilon$ is the true plastic strain, $K$ is the strength coefficient, and $n$ is the strain-hardening exponent. Elastic properties are defined by Young’s modulus $E$ and Poisson’s ratio $\nu$.
| Material Property | Symbol | Typical Value |
|---|---|---|
| Young’s Modulus | $E$ | 210 GPa |
| Poisson’s Ratio | $\nu$ | 0.3 |
| Yield Strength | $\sigma_y$ | ~450 MPa |
| Strength Coefficient | $K$ | ~1200 MPa |
| Strain-hardening Exponent | $n$ | ~0.15 |
Contact and Friction
The interaction between the rigid die and the deformable gear blank is governed by a surface-to-surface contact algorithm with a “finite sliding” formulation. The Coulomb friction model is adopted:
$$ \tau_{fric} = \mu \cdot p $$
where $\tau_{fric}$ is the frictional shear stress, $\mu$ is the coefficient of friction (typically set between 0.1 and 0.2 for cold forging with lubrication), and $p$ is the contact pressure. A “hard” contact pressure-overclosure relationship is used, preventing penetration.
Finite Element Model Setup
To balance computational accuracy and cost, a sector model of the hyperboloid gear wheel containing multiple teeth (e.g., 8 teeth) is used instead of a full model. This avoids unrealistic boundary condition effects from a single-tooth model. The trapezoidal die is modeled as an analytical rigid body. The simulation is performed in two sequential steps:
- Explicit Dynamic Analysis (Abaqus/Explicit): Simulates the nonlinear, dynamic forming process. The die is given prescribed orbital and rotational velocities. Mass scaling may be judiciously applied to improve computational efficiency.
- Implicit Static Analysis (Abaqus/Standard): The deformed mesh and stress state from the explicit step are imported. All contact constraints and external loads are removed. A static analysis is run to find the new stress equilibrium, resulting in the sprung-back geometry. The internal “pseudo” forces used to initialize equilibrium are gradually dissipated during this step.
Case Study: Application to an Automotive Hypoid Gear
The proposed methodology is applied to the finishing process of a driven wheel (ring gear) from an automotive drive axle. The key geometric parameters are summarized below.
| Parameter | Value |
|---|---|
| Number of Teeth | 41 |
| Outer Cone Distance | 101.26 mm |
| Whole Depth | 9.73 mm |
| Face Width | 28 mm |
| Pitch Angle | 73.70° |
Initial Simulation and Springback Analysis
The first iteration uses a die designed from the nominal tooth slot geometry. The FEA results reveal the characteristic stress distribution and metal flow. The contact pressure and plastic strain are highly localized along the moving line of contact. After springback, the stress redistributes, and the tooth flank geometry deviates from the target. The extracted sprung-back surface shows a distinct pattern: displacement is smaller in the central region of the tooth face width (indicating more elastic recovery) and larger towards the toe and heel (indicating greater permanent plastic deformation). This naturally leads to a slight “crowned” or barrel-shaped tooth form, which can be beneficial for contact pattern under load.
A quantitative 3D comparison of the first-iteration sprung-back surface against the target yields the initial springback error.
| Error Metric | Iteration 1 Value |
|---|---|
| Maximum Positive Error | +0.101 mm |
| Maximum Negative Error | -0.101 mm |
| Average Absolute Error | 0.0429 mm |
This level of error is unacceptable for precision hyperboloid gears, confirming the necessity for compensation.
Iterative Die Correction and Results
The displacement adjustment algorithm is invoked with a compensation factor $\alpha = -0.5$. The target preform shape $C^{1}$ is calculated. A new die profile is derived from a normal section of $C^{1}$. This new die is used in the second FEA simulation. The process is repeated. Convergence is rapidly achieved.
The table below tracks the improvement in geometric accuracy over three iterations.
| Iteration (t) | Max Positive Error (mm) | Max Negative Error (mm) | Avg. Positive Error (mm) | Avg. Negative Error (mm) | Comment |
|---|---|---|---|---|---|
| 0 (Initial) | +0.101 | -0.101 | N/A | N/A | Uncompensated die |
| 1 | +0.065 | -0.080 | 0.012 | 0.018 | First compensation |
| 2 | +0.054 | -0.077 | 0.0029 | 0.0093 | Second compensation; error within tolerance |
After just two compensation iterations, the average error is reduced to the order of microns, and the maximum error is significantly curtailed, demonstrating the remarkable efficiency of the proposed system for developing cold rotary forging processes for hyperboloid gears.
Performance Validation: Loaded Tooth Contact Analysis (LTCA)
To verify the functional quality of the cold rotary forged and springback-compensated hyperboloid gear, a Loaded Tooth Contact Analysis is performed. A three-dimensional model of the forged gear wheel is reconstructed from the FEA nodal data of the final iteration. This model is meshed and assembled with its mating pinion in a multi-tooth segment (e.g., 5 tooth pairs) to simulate realistic boundary conditions.
A torque of 9000 N·m is applied to the wheel, and the pinion is driven at 500 RPM. A dynamic explicit analysis is conducted to observe the contact pressure distribution and stress fields under load. The results for the convex side of the wheel (driving side in one rotational direction) are critically examined. A desirable contact pattern for hyperboloid gears is characterized by an elliptical patch located centrally on the tooth flank, with a slight bias towards the toe on the concave side and towards the heel on the convex side under load. The LTCA results confirm that the cold forged gear exhibits:
- A well-defined, centralized contact ellipse on the tooth flank.
- A smooth gradient of contact pressure within the ellipse.
- Maximum stresses located in the mid-region of the contact path, avoiding edge-loading at the toe or heel.
- Contact pattern movement from the toe to the heel (or vice-versa, depending on rotation) that follows established design principles for hyperboloid gears.
These findings provide conclusive evidence that the springback-compensated cold rotary forging process not only achieves geometric accuracy but also produces a tooth form with excellent functional meshing characteristics, validating the entire methodology.
Conclusion
This work presents a comprehensive and practical framework for the precision cold rotary forging of hyperboloid gears, with a focused solution to the critical challenge of springback error. The proposed forging scheme itself offers a paradigm shift through its use of a simple trapezoidal die and localized line-contact forming, yielding benefits in tooling cost, forming force, and final part strength. The core contribution, however, is the development and demonstration of an efficient, simulation-based iterative compensation system.
By employing the displacement adjustment algorithm within an elastoplastic FEA environment, the system successfully predicts and corrects for springback by intelligently modifying the target preform geometry from which the forging die is derived. The case study on an automotive ring gear demonstrates rapid convergence, achieving micron-level accuracy within just three iterations. This represents a drastic reduction in the traditional die development cycle and associated costs for manufacturing hyperboloid gears. Finally, validation via Loaded Tooth Contact Analysis confirms that the forged gears possess not only dimensional precision but also superior meshing performance under operational loads. This integrated approach paves the way for the wider industrial adoption of cold forging as a high-performance, cost-effective finishing technology for critical power transmission components like hyperboloid gears.