
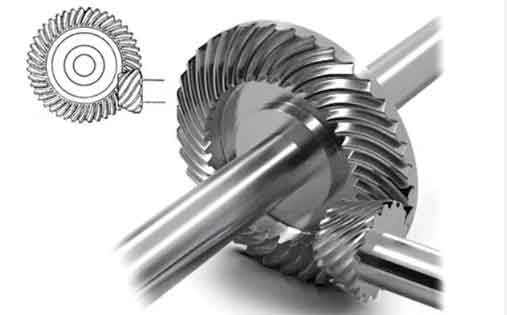
I treat the spiral bevel gear as a critical transmission element in automotive, aerospace, and heavy machinery systems. A spiral bevel gear must transmit high torque with smooth motion, low noise, and long fatigue life. Conventional cutting of a spiral bevel gear often requires repeated setup, complex tool motion, and substantial material removal. Those operations interrupt the metal flow lines along the tooth profile and can reduce the load-bearing capacity of the final spiral bevel gear. Rotary forging, especially single-roller and double-roller rotary forging, offers a promising route for producing a spiral bevel gear with continuous fibrous flow, better material utilization, and improved mechanical performance. In my analysis, the motion of the upper die is controlled by the inner and outer eccentric sleeves. Therefore, eccentric sleeve rotational speed is not a secondary machine setting; it directly changes the trajectory period, trajectory shape, contact area, forming load, deformation uniformity, and root damage of the spiral bevel gear.
I begin with the kinematic foundation. If the inner and outer eccentric sleeves rotate at signed speeds \(n_1\) and \(n_2\), the nominal center of the upper die follows a two-frequency closed curve. I express the planar motion as
$$x(t)=e_1\cos\left(\frac{2\pi n_1}{60}t\right)+e_2\cos\left(\frac{2\pi n_2}{60}t\right)$$
$$y(t)=e_1\sin\left(\frac{2\pi n_1}{60}t\right)+e_2\sin\left(\frac{2\pi n_2}{60}t\right)$$
where \(e_1\) and \(e_2\) are the eccentricities of the inner and outer sleeves, and \(t\) is time in seconds. When the two speeds have opposite signs, the resulting path can form a rose-line pattern. When the two speeds have the same sign, the path can form a helical-line pattern. The motion period \(T\) is governed by the greatest common divisor of the absolute speeds:
$$T=\frac{60}{\gcd(|n_1|,|n_2|)}$$
I define the reduced integers \(p\), \(q\), and the speed ratio \(R\) as
$$g=\gcd(|n_1|,|n_2|),\quad p=\frac{|n_1|}{g},\quad q=\frac{|n_2|}{g}$$
$$R=\left|\frac{n_1}{n_2}\right|=\frac{p}{q}$$
For a rose-line path, the number of petals is
$$N_{\mathrm{rose}}=p+q$$
For a helical-line path, the number of turns is
$$N_{\mathrm{helix}}=q$$
These relationships are important because they let me separate changes in motion period from changes in trajectory shape. In the single-roller rotary forging of a spiral bevel gear, a different eccentric sleeve speed can keep the same petal count or turn count while changing the period, or it can keep the period fixed while changing the density and shape of the trajectory. Both effects matter for the final spiral bevel gear.
Table 1. Geometric and material data for the spiral bevel gear and the rotary forging model.
| Item | Value |
|---|---|
| Number of teeth | 43 |
| Module | 5.697 |
| Pressure angle | 22.5° |
| Pitch diameter | 244.96 mm |
| Face width | 38 mm |
| Root angle | 68.23° |
| Pitch cone angle | 72.82° |
| Face cone angle | 73.45° |
| Billet material | 20CrMnTiH steel |
| Billet temperature in single-roller study | 900 °C |
| Die temperature | 200 °C |
| Friction coefficient in single-roller study | 0.3 |
| Upper die swing angle | 2° |
| Lower die feed speed in single-roller study | 4 mm·s⁻¹ |
| Finite element mesh count | 300000 |
| Local mesh refinement | Tooth profile region |
I used a three-dimensional finite element model to study the spiral bevel gear. The gear geometry was built parametrically, and the rotary forging dies were assembled with the billet and lower die. The tooth region received a finer mesh because the local strain, damage, and contact pressure are concentrated there. The upper die motion was imposed through the eccentric sleeve speeds, and the lower die moved upward with a controlled feed speed. I then extracted the axial load, rolling torque, effective strain, strain standard deviation, root damage factor, and contact area at each time step.
Table 2. Speed schedules for the period study of the spiral bevel gear.
| Trajectory | Signed speeds \(n_1/n_2\) (r·min⁻¹) | \(g\) | Period \(T\) (s) | Petal or turn count | Speed ratio \(R\) |
|---|---|---|---|---|---|
| Rose line | 60 / −70 | 10 | 6 | 13 petals | 6/7 |
| Rose line | 90 / −105 | 15 | 4 | 13 petals | 6/7 |
| Rose line | 120 / −140 | 20 | 3 | 13 petals | 6/7 |
| Rose line | 150 / −175 | 25 | 2.4 | 13 petals | 6/7 |
| Rose line | 180 / −210 | 30 | 2 | 13 petals | 6/7 |
| Helical line | 60 / 70 | 10 | 6 | 7 turns | 6/7 |
| Helical line | 90 / 105 | 15 | 4 | 7 turns | 6/7 |
| Helical line | 120 / 140 | 20 | 3 | 7 turns | 6/7 |
| Helical line | 150 / 175 | 25 | 2.4 | 7 turns | 6/7 |
| Helical line | 180 / 210 | 30 | 2 | 7 turns | 6/7 |
Table 3. Speed schedules for the trajectory-shape study of the spiral bevel gear at a fixed period.
| Trajectory | Signed speeds \(n_1/n_2\) (r·min⁻¹) | \(g\) | Period \(T\) (s) | Petal or turn count | Speed ratio \(R\) |
|---|---|---|---|---|---|
| Rose line | 40 / −60 | 20 | 3 | 5 petals | 2/3 |
| Rose line | 80 / −100 | 20 | 3 | 9 petals | 4/5 |
| Rose line | 120 / −140 | 20 | 3 | 13 petals | 6/7 |
| Rose line | 160 / −180 | 20 | 3 | 17 petals | 8/9 |
| Rose line | 200 / −220 | 20 | 3 | 21 petals | 10/11 |
| Helical line | 40 / 60 | 20 | 3 | 3 turns | 2/3 |
| Helical line | 80 / 100 | 20 | 3 | 5 turns | 4/5 |
| Helical line | 120 / 140 | 20 | 3 | 7 turns | 6/7 |
| Helical line | 160 / 180 | 20 | 3 | 9 turns | 8/9 |
| Helical line | 200 / 220 | 20 | 3 | 11 turns | 10/11 |
For the force and energy analysis, I define the instantaneous axial load as the integral of normal and tangential contact stresses over the active contact area. The rolling torque is the first moment of the tangential stress field. The relevant expressions are
$$F_a(t)=\int_{A_c(t)}\left[\sigma_n(\xi,t)\cos\alpha+\tau_t(\xi,t)\sin\alpha\right]dA$$
$$M_r(t)=\int_{A_c(t)} r(\xi,t)\times \tau_t(\xi,t)dA$$
where \(A_c(t)\) is the instantaneous contact area, \(\sigma_n\) is the normal contact stress, \(\tau_t\) is the tangential contact stress, \(\alpha\) is the local inclination, and \(r\) is the position vector. The contact area itself is
$$A_c(t)=\sum_{i=1}^{N_c(t)} A_i(t)$$
and the contact area ratio is
$$\lambda_c(t)=\frac{A_c(t)}{A_p}$$
where \(A_p\) is the projected area of the spiral bevel gear tooth region. I use \(\lambda_c\) to explain why the forming load peaks change with eccentric sleeve speed.
When I increased the motion period \(T\), the maximum axial load and maximum rolling torque both decreased. The decrease was rapid before \(T=4\) s and slower after \(T=4\) s. At short periods, the eccentric sleeves rotate quickly, so the upper die covers a larger fraction of the spiral bevel gear surface per unit time. The contact area ratio rises, the instantaneous interaction force grows, and the axial load peak becomes larger. Once the speed is already high, further speed increases do not increase the contact area ratio as strongly. Therefore, the force and torque curves flatten after about \(T=4\) s. The helical-line trajectory consistently produced lower maximum force and torque than the rose-line trajectory under the same period. This tells me that the helical line distributes the contact better for the spiral bevel gear at equal period.
Table 4. Effect of motion period on the single-roller rotary forging of a spiral bevel gear.
| Response | Trend as \(T\) increases | Rose line versus helical line | Interpretation |
|---|---|---|---|
| Maximum axial load | Decreases; rapid before 4 s, slow after 4 s | Rose line is higher | Higher speed increases contact area ratio and load peak |
| Maximum rolling torque | Decreases; rapid before 4 s, slow after 4 s | Rose line is higher | Torque follows the contact stress moment |
| Average effective strain | Nonmonotonic: up, down, up, down | Rose and helical alternate | Accumulated plastic deformation depends on both period and path overlap |
| Effective strain standard deviation | Minimum near \(T=3\) s and \(T=4\) s | Rose line is lower | Rose line gives more uniform deformation of the spiral bevel gear |
| Maximum root damage factor | Decreases as \(T\) increases | Rose and helical alternate | Faster eccentric motion intensifies root loading |
| Maximum contact area | Decreases as \(T\) increases | Rose line is larger | Larger contact area correlates with larger force parameters |
For deformation uniformity, I used the effective strain
$$\varepsilon_{\mathrm{eff}}=\sqrt{\frac{2}{3}\varepsilon_{ij}\varepsilon_{ij}}$$
and the volume-averaged effective strain
$$\bar{\varepsilon}=\frac{1}{V}\int_V \varepsilon_{\mathrm{eff}}dV$$
I also computed the standard deviation of the effective strain over the selected tooth and root nodes:
$$S_{\varepsilon}=\sqrt{\frac{1}{N-1}\sum_{i=1}^{N}\left(\varepsilon_{\mathrm{eff},i}-\bar{\varepsilon}\right)^2}$$
A smaller \(S_{\varepsilon}\) means that the spiral bevel gear deforms more uniformly. In the period study, \(S_{\varepsilon}\) was relatively small at \(T=3\) s and \(T=4\) s. At the same period, the rose-line trajectory gave a lower standard deviation than the helical-line trajectory. I therefore concluded that the rose line improves deformation uniformity of the spiral bevel gear, while the helical line can create a larger average strain.
The root damage factor is especially important because the root of a spiral bevel gear is a fatigue-critical region. I used a cumulative damage form:
$$D=\int_0^{\bar{\varepsilon}_f}\frac{d\bar{\varepsilon}}{\bar{\varepsilon}_f(\eta,\theta)}$$
where \(\bar{\varepsilon}_f\) is the effective fracture strain, \(\eta\) is the stress triaxiality, and \(\theta\) is the Lode angle parameter. As the period decreased, the maximum root damage factor increased. A faster eccentric sleeve speed made the upper die interact more strongly with the die cavity. The metal at the root experienced more severe cyclic loading under the eccentric axial load and the lower die tooth top. The damage factor at the root of the spiral bevel gear therefore became larger. The rose-line and helical-line trajectories alternated in the damage ranking over the period range, but the general trend was consistent.
The maximum contact area between billet and lower die decreased as the period increased. This trend matched the force and torque trends. A larger contact area means more of the spiral bevel gear surface is under pressure at the same instant, which raises the forming load. The rose-line trajectory produced a larger maximum contact area than the helical-line trajectory at the same period. If I wanted better filling of the tooth cavity, the rose line was more favorable in this single-roller arrangement.
Next I fixed the period at \(T=3\) s and changed only the trajectory shape through the speed ratio \(R=|n_1/n_2|\). The maximum axial load and maximum rolling torque did not vary monotonically with \(R\). Even with the same period, a different speed ratio changes the petal count or turn count, so the path density and the local dwell time of the upper die change. The spiral bevel gear therefore experiences a combined effect of period and shape. In all cases, the rose-line trajectory produced higher maximum force and torque than the helical-line trajectory. This means the helical line can lower the forming load requirement for the spiral bevel gear, but I must also check strain uniformity and root damage.
Table 5. Effect of speed ratio on the single-roller rotary forging of a spiral bevel gear at \(T=3\) s.
| Response | Trend as \(R=|n_1/n_2|\) increases | Rose line versus helical line | Optimum or preferred range |
|---|---|---|---|
| Maximum axial load | Nonmonotonic | Rose line is higher | Moderate shape density |
| Maximum rolling torque | Nonmonotonic | Rose line is higher | Moderate shape density |
| Average effective strain | Generally increases | Helical line is higher | Higher \(R\) increases plastic deformation |
| Effective strain standard deviation | First decreases, then increases | Rose line is lower | Best uniformity near \(R=6/7\) |
| Maximum root damage factor | Increases | Helical line is lower | Lower \(R\) reduces root damage |
| Maximum contact area | First increases, then decreases | Rose line is larger | Best filling near \(R=6/7\) |
The average effective strain generally increased with the speed ratio, which indicates that a denser or more complex path can accumulate more plastic deformation in the spiral bevel gear. However, the effective strain standard deviation first decreased and then increased. A very low speed ratio produces a sparse trajectory, so some regions of the spiral bevel gear receive less deformation. A very high speed ratio produces an overly dense trajectory, which can create local over-deformation and a less uniform strain field. The minimum standard deviation occurred at an intermediate ratio. In my simulations, the best uniformity and the best contact area both appeared near \(R=6/7\).
The root damage factor increased as the speed ratio increased. A more complex trajectory means that the upper die and the die cavity interact more frequently with the root region. The metal at the root of the spiral bevel gear is then more likely to experience damage accumulation and possible crack initiation. The helical-line trajectory gave a lower maximum damage factor than the rose-line trajectory at the same speed ratio. If root damage is the limiting criterion, the helical line is safer, but if cavity filling and uniformity are limiting, the rose line is more attractive.
I summarized the multi-objective trade-off in a qualitative optimization table. To reduce the forming force, I can increase the motion period and choose a moderate speed ratio. To improve deformation uniformity, I need a period near \(T=3\) s and a speed ratio near \(R=6/7\). To reduce root damage, I should decrease the speed ratio and increase the period. To improve filling, I should decrease the period and choose \(R=6/7\). The compromise that satisfies all these requirements for the spiral bevel gear is \(T=3\) s and \(|n_1/n_2|=6/7\).
Table 6. Multi-objective compromise for the single-roller rotary forging of a spiral bevel gear.
| Objective | Preferred direction for period \(T\) | Preferred direction for speed ratio \(R\) | Best compromise |
|---|---|---|---|
| Reduce forming force | Increase \(T\) | Moderate increase in \(R\) | \(T=3\) s, \(R=6/7\) |
| Improve deformation uniformity | Near \(T=3\) s | Near \(R=6/7\) | \(T=3\) s, \(R=6/7\) |
| Reduce root damage | Increase \(T\) | Decrease \(R\) | Balance with \(T=3\) s, \(R=6/7\) |
| Improve cavity filling | Decrease \(T\) | Near \(R=6/7\) | \(T=3\) s, \(R=6/7\) |
I validated the single-roller result with a physical trial. The speed ratio was set to \(|n_1/n_2|=6/7\), and the speeds were 120 r·min⁻¹ and 140 r·min⁻¹. The resulting spiral bevel gear had good tooth filling, no visible root cracking, and a smooth surface. The experimental observation agreed with the finite element prediction. This confirmed that eccentric sleeve speed control is a practical lever for improving the rotary forging of a spiral bevel gear.
After the single-roller study, I extended the work to double-roller rotary forging of a spiral bevel gear. In double-roller rotary forging, two rollers act on the billet while the lower die feeds upward. The process parameters interact strongly. I chose an orthogonal experiment because a full factorial study would require too many simulations and trials. The factors I considered were the initial billet temperature, the lower die feed speed, the friction coefficient, the double-roller revolution speed, and the blank thickness. The response variables were the contact area between the billet and the die, the maximum forming load, and the average grain size.
The range analysis method I used is based on the mean response at each factor level:
$$\bar{y}_{j,k}=\frac{1}{r}\sum_{i=1}^{r}y_{i,j,k}$$
where \(j\) is the factor index, \(k\) is the level index, \(r\) is the number of repetitions at that level, and \(y\) is the measured response. The range of factor \(j\) is
$$R_j=\max_k \bar{y}_{j,k}-\min_k \bar{y}_{j,k}$$
A larger \(R_j\) means that factor \(j\) has a stronger influence on the response. For a larger-is-better response, such as contact area, the preferred level is
$$k_{\mathrm{opt},j}=\arg\max_k \bar{y}_{j,k}$$
For a smaller-is-better response, such as maximum forming load or average grain size, the preferred level is
$$k_{\mathrm{opt},j}=\arg\min_k \bar{y}_{j,k}$$
I then combined the preferred levels into a single process recipe. The best combination I obtained was \(A_3B_2C_1D_2E_3\). This means an initial billet temperature of 950 °C, a lower die feed speed of 2 mm·s⁻¹, a friction coefficient of 0.2, a double-roller revolution speed of 75 r·min⁻¹, and a blank thickness of 31.22 mm.
Table 7. Optimized double-roller rotary forging parameters for the spiral bevel gear.
| Factor | Process parameter | Selected level | Value | Role in the spiral bevel gear forming |
|---|---|---|---|---|
| A | Initial billet temperature | \(A_3\) | 950 °C | Controls flow stress and die filling |
| B | Lower die feed speed | \(B_2\) | 2 mm·s⁻¹ | Controls strain rate and load peak |
| C | Friction coefficient | \(C_1\) | 0.2 | Controls material flow along the tooth flank |
| D | Double-roller revolution speed | \(D_2\) | 75 r·min⁻¹ | Controls contact sequence and temperature history |
| E | Blank thickness | \(E_3\) | 31.22 mm | Controls volume distribution and flash formation |
The optimized double-roller process produced a clear improvement in all three response variables. The contact area between the billet and die increased by about 43.9%. The maximum forming load decreased from 1827 kN to 1358 kN. The average grain size decreased from 58.2 μm to 33.3 μm. These are meaningful gains for a spiral bevel gear because a larger contact area means better cavity filling, a lower forming load reduces machine capacity requirements, and a finer grain size improves strength and fatigue resistance.
$$I_A=\frac{A_{\mathrm{opt}}-A_{\mathrm{base}}}{A_{\mathrm{base}}}\times100\%=43.9\%$$
$$\Delta F=1827-1358=469\,\mathrm{kN}$$
$$R_F=\frac{469}{1827}\times100\%\approx25.7\%$$
$$\Delta d=58.2-33.3=24.9\,\mu\mathrm{m}$$
$$R_d=\frac{24.9}{58.2}\times100\%\approx42.8\%$$
The grain refinement is especially important. According to the Hall–Petch relation,
$$\sigma_y=\sigma_0+k_y d^{-1/2}$$
where \(\sigma_y\) is the yield strength, \(d\) is the average grain size, and \(k_y\) is the strengthening coefficient. A reduction from 58.2 μm to 33.3 μm increases the grain-boundary strengthening contribution. For a spiral bevel gear, this can improve tooth root fatigue life and surface durability. The lower forming load also means that the double-roller process can be run on a smaller press or with less tool stress.
Table 8. Comparison of baseline and optimized double-roller rotary forging results for the spiral bevel gear.
| Response | Baseline | Optimized | Change | Relative improvement |
|---|---|---|---|---|
| Contact area between billet and die | Reference value | Higher | Increase | About 43.9% |
| Maximum forming load | 1827 kN | 1358 kN | −469 kN | About 25.7% reduction |
| Average grain size | 58.2 μm | 33.3 μm | −24.9 μm | About 42.8% reduction |
I also compared the simulation and experiment for the optimized double-roller process. The experimental spiral bevel gear showed better die filling, lower load demand, and finer microstructure than the baseline. The measured trends matched the finite element simulation. This agreement supports the use of orthogonal experiment plus finite element analysis for process design of a spiral bevel gear.
When I integrate the single-roller and double-roller findings, I see a coherent process window. For single-roller rotary forging, the eccentric sleeve speed ratio should be set near \(|n_1/n_2|=6/7\), and the trajectory period should be near \(T=3\) s. For a rose-line path, this corresponds to opposite signs, for example 120 r·min⁻¹ and −140 r·min⁻¹. For a helical-line path, this corresponds to the same sign, for example 120 r·min⁻¹ and 140 r·min⁻¹. For double-roller rotary forging, the best combination is 950 °C billet temperature, 2 mm·s⁻¹ lower die feed speed, 0.2 friction coefficient, 75 r·min⁻¹ roller revolution speed, and 31.22 mm blank thickness.
Table 9. Integrated process recommendations for rotary forging of a spiral bevel gear.
| Process route | Parameter | Recommended value | Main benefit for the spiral bevel gear |
|---|---|---|---|
| Single-roller rotary forging | Trajectory type | Rose line or helical line | Continuous fiber flow along the tooth profile |
| Single-roller rotary forging | Motion period \(T\) | 3 s | Balanced load, uniformity, and filling |
| Single-roller rotary forging | Speed ratio \(|n_1/n_2|\) | 6/7 | Best uniformity and contact area compromise |
| Single-roller rotary forging | Example rose-line speeds | 120 / −140 r·min⁻¹ | Thirteen-petal rose trajectory |
| Single-roller rotary forging | Example helical-line speeds | 120 / 140 r·min⁻¹ | Seven-turn helical trajectory |
| Double-roller rotary forging | Initial billet temperature | 950 °C | Improved flow and filling |
| Double-roller rotary forging | Lower die feed speed | 2 mm·s⁻¹ | Lower forming load |
| Double-roller rotary forging | Friction coefficient | 0.2 | Favorable material flow |
| Double-roller rotary forging | Roller revolution speed | 75 r·min⁻¹ | Controlled contact and temperature history |
| Double-roller rotary forging | Blank thickness | 31.22 mm | Better volume distribution |
The physical meaning of these recommendations is important. The eccentric sleeve speed controls the trajectory period and shape, but it also controls how long the upper die remains in contact with a given region of the spiral bevel gear. At a short period, the die moves quickly, the contact area ratio rises, and the load peak increases. At a long period, the die moves slowly, the load peak decreases, but the filling may become less complete. The ratio \(|n_1/n_2|=6/7\) provides a path density that is neither too sparse nor too dense. In the rose-line case, the 13-petal pattern distributes the contact over the tooth surface in a way that improves uniformity. In the helical-line case, the 7-turn pattern provides a different contact sequence that reduces the maximum load and root damage. Both trajectories are useful, but the process window is similar.
For the double-roller process, the orthogonal optimization shows that the initial temperature and friction coefficient strongly affect material flow. A higher temperature reduces flow stress, but too high a temperature can cause grain growth and scale. The selected 950 °C is a compromise. The lower die feed speed of 2 mm·s⁻¹ gives a moderate strain rate and avoids an excessive load peak. A friction coefficient of 0.2 promotes sliding along the tooth flank, which helps fill the root and flank of the spiral bevel gear. A roller revolution speed of 75 r·min⁻¹ provides a suitable number of loading cycles without overheating. The blank thickness of 31.22 mm ensures enough material for the tooth cavity and a controlled flash.
I also note that the single-roller and double-roller processes share the same physical target: a spiral bevel gear with a continuous metal flow line, uniform effective strain, low root damage, and complete tooth filling. In single-roller rotary forging, the eccentric sleeve speed is the main trajectory control. In double-roller rotary forging, the process parameters are the main control. When I combine them, I can design a robust manufacturing chain for a spiral bevel gear. First, I choose the rotary forging route. Second, I set the trajectory period and speed ratio to control contact area and strain uniformity. Third, I optimize temperature, feed speed, friction, roller speed, and blank thickness to reduce load and refine grain size. Fourth, I verify the result by finite element simulation and physical trial.
From my analysis, several quantitative trends are clear. Increasing the motion period reduces the maximum axial load and rolling torque. The decrease is fast before 4 s and slow after 4 s. The maximum contact area also decreases with increasing period. The average effective strain is nonmonotonic, and the strain standard deviation is minimized near 3 s and 4 s. The root damage factor decreases with increasing period. When the period is fixed at 3 s and the speed ratio is varied, the average effective strain generally increases, the standard deviation first decreases and then increases, the root damage factor increases, and the contact area first increases and then decreases. The best compromise for a spiral bevel gear is 3 s and 6/7. For double-roller rotary forging, the orthogonal experiment gives 950 °C, 2 mm·s⁻¹, 0.2, 75 r·min⁻¹, and 31.22 mm. That recipe increases contact area by about 43.9%, lowers the maximum load from 1827 kN to 1358 kN, and reduces average grain size from 58.2 μm to 33.3 μm.
Table 10. Summary of quantitative findings for rotary forging of a spiral bevel gear.
| Finding | Quantitative expression or value | Effect on the spiral bevel gear |
|---|---|---|
| Motion period | $$T=\frac{60}{\gcd(|n_1|,|n_2|)}$$ | Controls cycle time and contact repetition |
| Speed ratio | $$R=\left|\frac{n_1}{n_2}\right|=\frac{p}{q}$$ | Controls rose petal count and helical turn count |
| Rose petal count | $$N_{\mathrm{rose}}=p+q$$ | Controls path density on the tooth surface |
| Helical turn count | $$N_{\mathrm{helix}}=q$$ | Controls contact sequence and load distribution |
| Contact area | $$A_c=\sum_{i=1}^{N_c}A_i$$ | Larger area improves filling but raises load |
| Effective strain | $$\varepsilon_{\mathrm{eff}}=\sqrt{\frac{2}{3}\varepsilon_{ij}\varepsilon_{ij}}$$ | Measures plastic deformation intensity |
| Strain uniformity | $$S_{\varepsilon}=\sqrt{\frac{1}{N-1}\sum_{i=1}^{N}(\varepsilon_{\mathrm{eff},i}-\bar{\varepsilon})^2}$$ | Smaller value gives more uniform deformation |
| Root damage | $$D=\int_0^{\bar{\varepsilon}_f}\frac{d\bar{\varepsilon}}{\bar{\varepsilon}_f(\eta,\theta)}$$ | Smaller value reduces crack risk |
| Single-roller optimum | \(T=3\) s, \(|n_1/n_2|=6/7\) | Best balance of load, uniformity, and filling |
| Double-roller optimum | 950 °C, 2 mm·s⁻¹, 0.2, 75 r·min⁻¹, 31.22 mm | Higher contact area, lower load, finer grain |
| Contact area improvement | $$I_A=43.9\%$$ | Better die filling of the spiral bevel gear |
| Maximum load reduction | $$1827\,\mathrm{kN}\rightarrow1358\,\mathrm{kN}$$ | Lower press capacity demand |
| Grain size reduction | $$58.2\,\mu\mathrm{m}\rightarrow33.3\,\mu\mathrm{m}$$ | Improved strength and fatigue resistance |
I conclude that eccentric sleeve rotational speed is a first-order variable in the rotary forging of a spiral bevel gear. It changes the trajectory period, the trajectory shape, the contact area ratio, the forming load, the rolling torque, the effective strain distribution, the root damage factor, and the final contact area. The rose-line and helical-line trajectories show similar qualitative trends when the eccentric sleeve speed changes, but they differ in magnitude. The rose line tends to produce a larger contact area and better deformation uniformity, while the helical line tends to produce lower maximum load and lower root damage. The speed ratio \(|n_1/n_2|=6/7\) and the period \(T=3\) s are the most suitable single-roller settings for the spiral bevel gear among the cases I studied. For double-roller rotary forging, the orthogonal optimization gives a process recipe that improves contact area by about 43.9%, reduces the maximum forming load from 1827 kN to 1358 kN, and refines the average grain size from 58.2 μm to 33.3 μm. These results give me a practical and physically consistent basis for designing rotary forging processes for a high-performance spiral bevel gear.