
In my study, I focus on a high-speed wind turbine miter gear pair used in the high-speed stage of a wind power gearbox. The miter gear is treated as a double-helical, herringbone-type transmission element because it provides high contact ratio, strong load capacity, smooth meshing, and good stability under high-speed and heavy-load conditions. I investigate the coupled thermal and mechanical behavior of the miter gear, and I use the resulting deformation and stress fields to design a tooth profile modification method. My aim is to reduce mesh impact, lower contact stress, control thermal deformation, and improve the service reliability of the high-speed miter gear transmission.
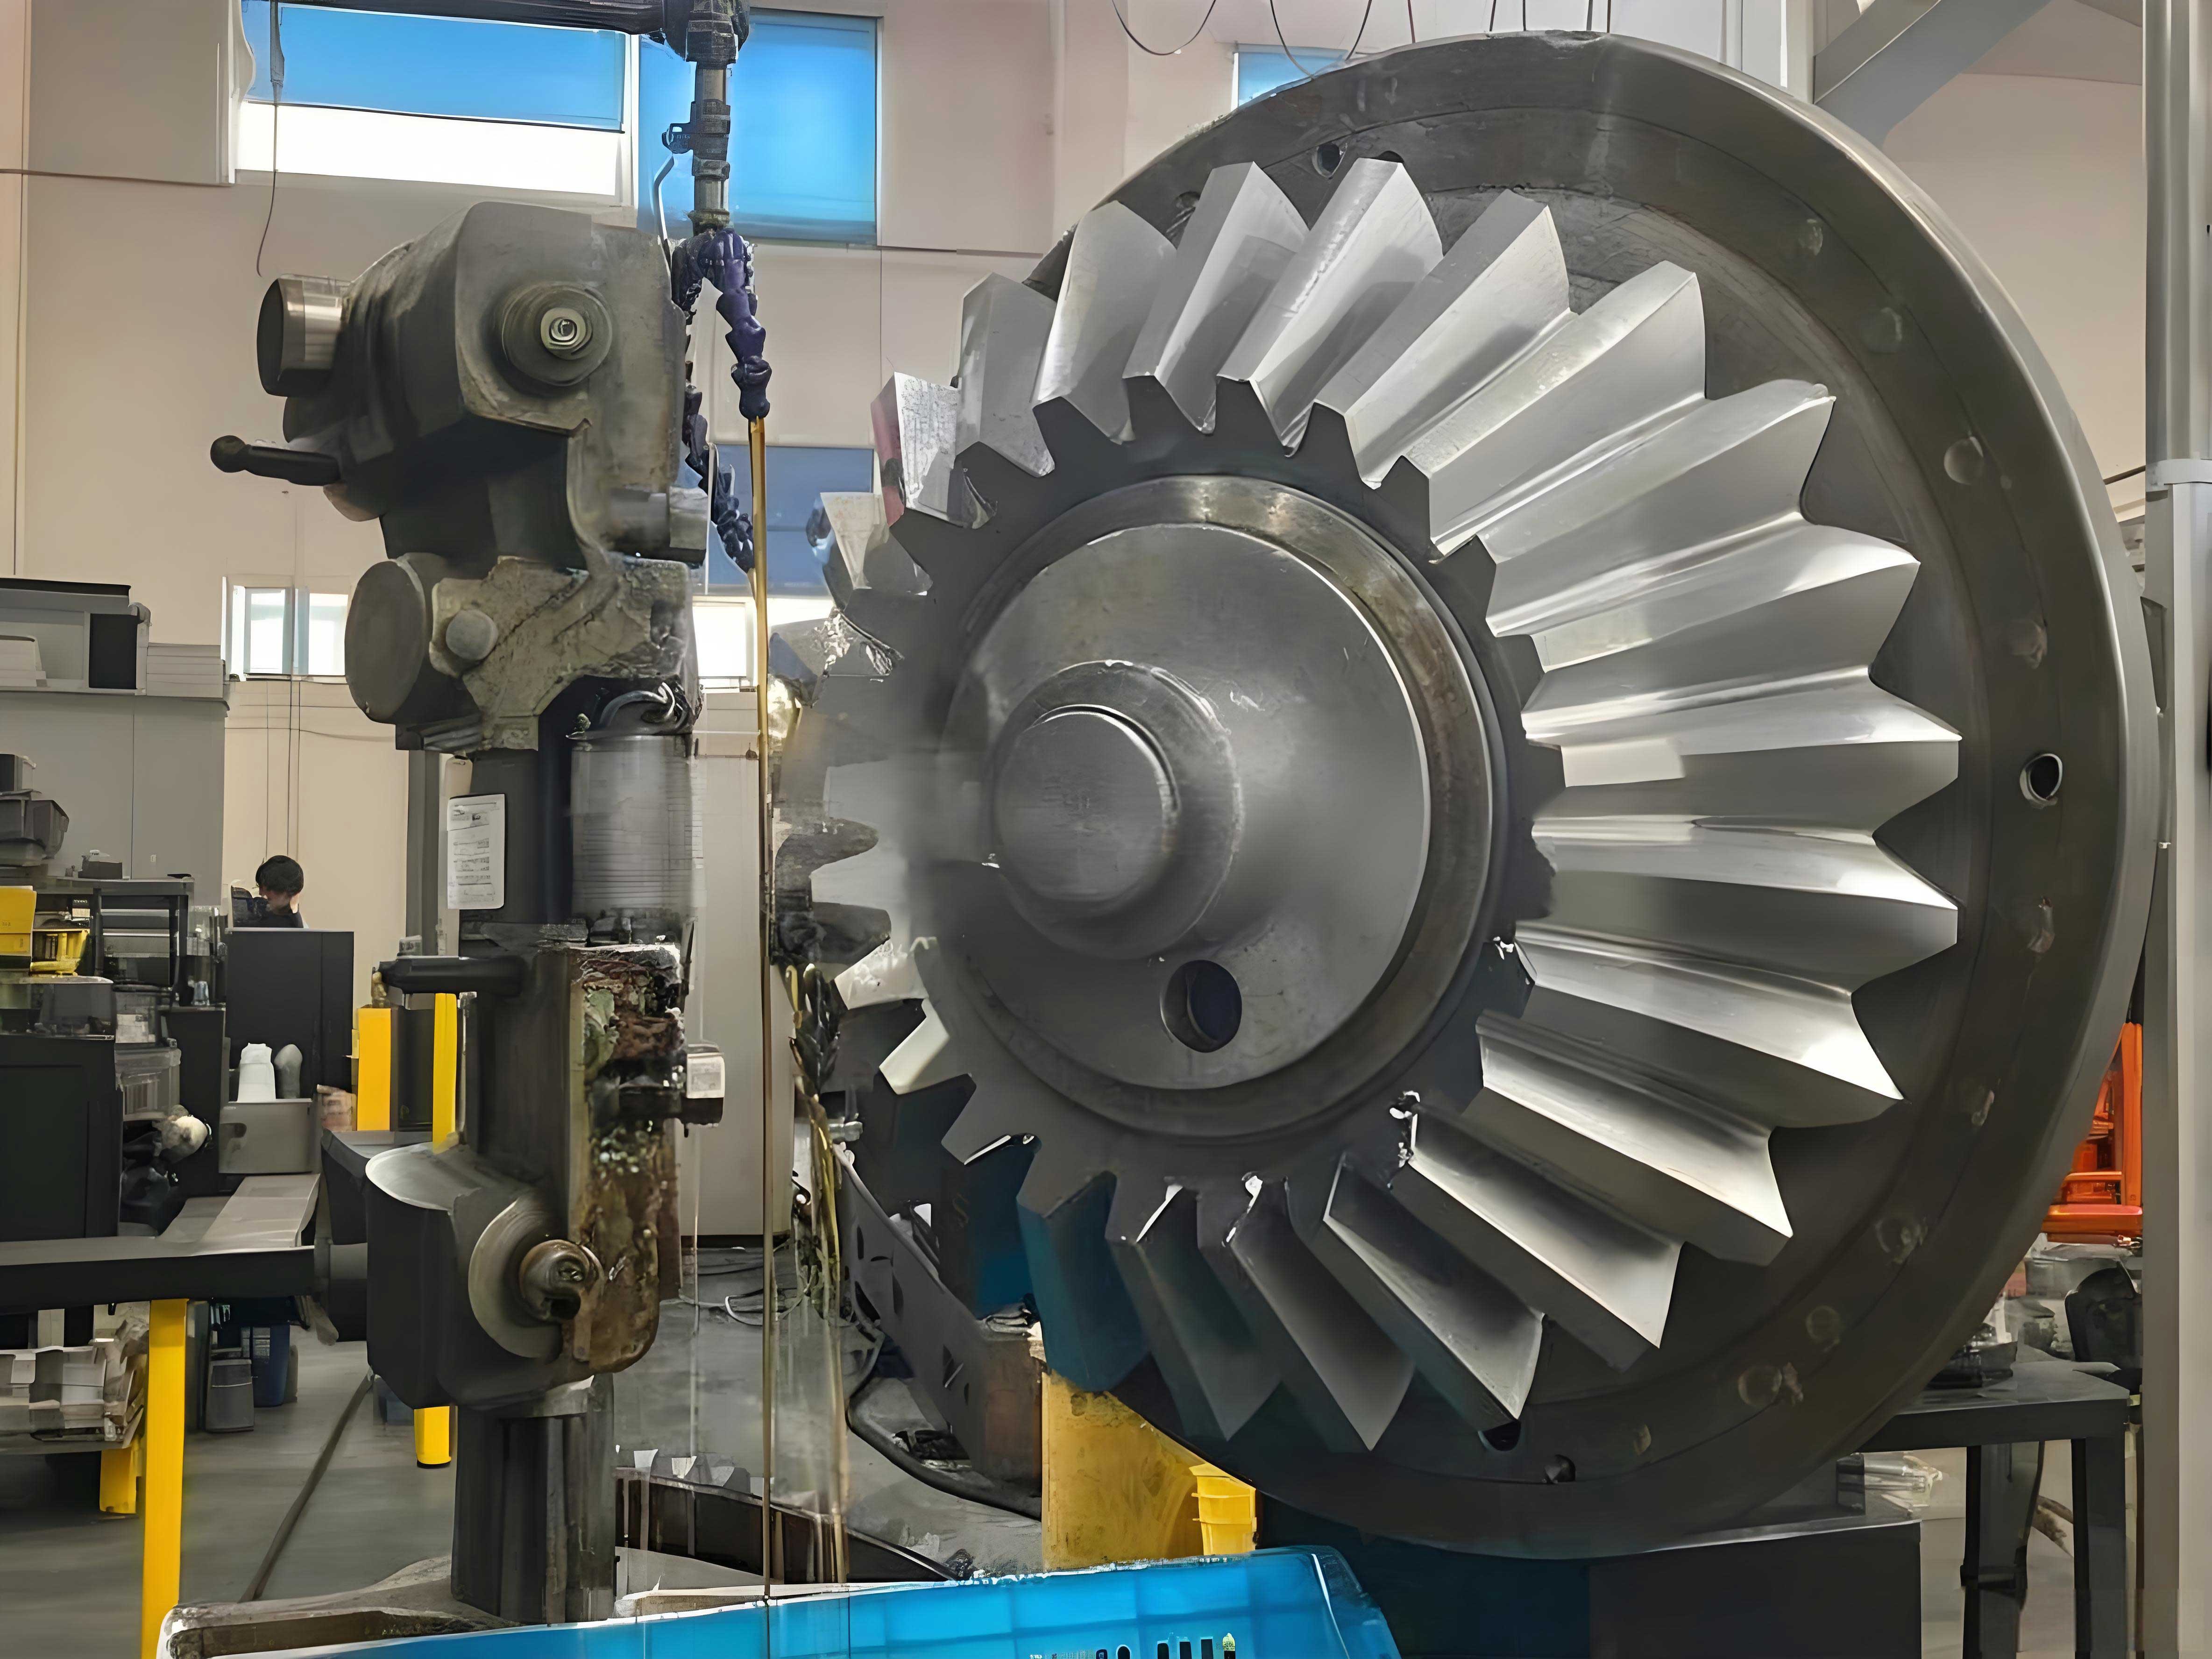
From my perspective, the wind turbine gearbox is not merely a speed-increasing device. It is a complex thermo-mechanical system in which the miter gear carries alternating contact loads at high rotational speed. Friction between the meshing flanks generates heat, and the heat cannot be removed instantly because the miter gear body has finite thermal conductivity. As a result, a nonuniform body temperature field forms. The miter gear then expands thermally, while the same tooth pair also deforms elastically under torque. The two deformation sources occur at comparable orders of magnitude, so ignoring either one can produce an inaccurate prediction of tooth contact, transmission error, and stress concentration. In my work, I therefore combine dynamic contact analysis, thermal analysis, and sequential thermal-mechanical coupling to evaluate the high-speed miter gear.
I first define the basic kinematic relation of the miter gear pair. If the driving miter gear has \(z_1\) teeth and the driven miter gear has \(z_2\) teeth, the nominal transmission ratio is
$$i_{12}=\frac{n_1}{n_2}=\frac{\omega_1}{\omega_2}=\frac{z_2}{z_1}=\frac{102}{31}\approx 3.2903.$$
For a single helical half of the miter gear, the total contact ratio is the sum of the transverse contact ratio and the overlap contact ratio:
$$\varepsilon_\gamma=\varepsilon_\alpha+\varepsilon_\beta.$$
In my model, the transverse contact ratio is \(1.519\), the overlap contact ratio is \(1.345\), and the total contact ratio is \(2.864\). This value indicates that the miter gear operates with alternating double-tooth and triple-tooth contact. Such alternating contact is exactly where mesh impact and load fluctuation become important, and it is also where tooth profile modification can be most effective.
The geometric parameters of the high-speed wind turbine miter gear pair are summarized in Table 1. I use these parameters in all subsequent thermal, structural, and modification simulations.
| Parameter | Symbol | Driving miter gear | Driven miter gear |
|---|---|---|---|
| Number of teeth | \(z\) | 31 | 102 |
| Normal module | \(m_n\) | 4.5 mm | 4.5 mm |
| Normal pressure angle | \(\alpha_n\) | 20° | 20° |
| Helix angle | \(\beta\) | 25° | 25° |
| Face width of each half | \(B\) | 45 mm | 45 mm |
| Groove width | \(B_1\) | 10 mm | 10 mm |
| Profile shift coefficient | \(x\) | 0 | 0 |
| Input torque | \(T_1\) | 4000 N·m | — |
| Rotational speed | \(n\) | 5000 r/min | 1519.6 r/min |
I next examine the meshing impact mechanism of the miter gear. When a tooth pair enters mesh, the actual base pitch can deviate from the ideal base pitch because of elastic deformation, thermal expansion, manufacturing error, and assembly error. If the actual base pitch of the driving miter gear becomes smaller than that of the driven miter gear, the new tooth pair enters mesh earlier than expected. The instantaneous ratio then differs from the nominal value, and a sudden angular velocity change occurs. This is the mesh-in impact. In the same way, when a tooth pair leaves mesh, delayed separation can produce a mesh-out impact. For the high-speed miter gear, these impacts are not negligible because the circumferential speed is large and the thermal deformation changes the effective tooth thickness.
I express the mesh-in impact tendency through the instantaneous ratio deviation:
$$i’_{12}=\frac{r_2}{r_1-\Delta r}<i_{12},$$
and the mesh-out impact tendency through
$$i”_{12}=\frac{r_2}{r_1+\Delta r}>i_{12},$$
where \(\Delta r\) represents the shift of the contact point along the line of action. These relations explain why I treat profile modification as a compensation tool: I remove a very small amount of material near the tooth tip and root so that the miter gear can pass through the alternating contact region more smoothly. The modification is not intended to change the basic involute law. It is intended to correct the loaded and heated state of the miter gear.
For my parametric model, I use the generation principle of a rack cutter. The coordinate transformation from the cutter frame to the gear blank frame is the foundation of the exact tooth profile. If a point on the cutter is \((x_0,y_0)\), and the rolling angle is \(\varphi\), the corresponding point on the miter gear tooth profile is
$$x=(r-x_0)\cos\varphi+(r\varphi-y_0)\sin\varphi,$$
$$y=(r-x_0)\sin\varphi-(r\varphi-y_0)\cos\varphi,$$
where \(r\) is the pitch radius and \(\varphi=PN/r\). This transformation allows me to generate the involute flank, the root fillet, and the tip curve in a consistent mathematical form. I then extend the transverse profile along the helix direction to obtain the three-dimensional miter gear surface.
For the involute portion, I use the standard parametric form
$$x_b=r_b(\cos\phi+\phi\sin\phi),$$
$$y_b=r_b(\sin\phi-\phi\cos\phi),$$
where \(r_b\) is the base radius and \(\phi\) is the involute roll angle. For the root transition curve, I use the envelope generated by the cutter tip radius. If the cutter tip center is \((x_c,y_c)\) and the tip radius is \(\rho_0\), then a point on the transition curve can be written as
$$x_0=x_c+\rho_0\cos\gamma,$$
$$y_0=y_c-\rho_0\sin\gamma,$$
with
$$\gamma=\tan^{-1}\left(\frac{r\varphi-y_c}{x_c}\right).$$
After substituting these expressions into the coordinate transformation, I obtain the exact root fillet equation. I use this equation in my parametric model so that the miter gear tooth root is not approximated by a simple circular arc. The exact root shape is important because the root fillet influences the bending stress and the thermal deformation of the miter gear.
For the helical part, I apply the helix transformation
$$X=r\cos(\theta+\beta z),$$
$$Y=r\sin(\theta+\beta z),$$
$$Z=z,$$
where \(r=\sqrt{x^2+y^2}\), \(\beta\) is the helix angle, and \(z\) is the axial coordinate. For the complete miter gear, I mirror the two helical halves about the central groove. Thus the miter gear surface equation becomes
$$X=r\cos(\theta+\beta z),$$
$$Y=r\sin(\theta+\beta z),$$
$$Z=B_m\pm B t,$$
where \(B_m\) is half of the groove width and \(B\) is the half-face width. In my modeling workflow, I generate the transverse profile in a mathematical environment, export the point set, fit the curve in a three-dimensional CAD environment, sweep it along the helix, and finally mirror and array the tooth to form the complete miter gear. This procedure gives me a precise miter gear solid model for finite element analysis.
My thermal analysis begins with the friction heat generated on the miter gear flanks. The three most important quantities are the relative sliding velocity, the contact pressure, and the friction coefficient. The relative sliding velocity at a contact point \(k\) is
$$V_{gk}=|\omega_1\rho_{k1}-\omega_2\rho_{k2}|,$$
where \(\omega_1\) and \(\omega_2\) are the angular velocities of the driving and driven miter gears, and \(\rho_{k1}\) and \(\rho_{k2}\) are the local radii of curvature. The curvature radii are obtained from the involute geometry:
$$\rho_{k1}=\frac{r_{b1}\tan\alpha_{k1}}{\cos\beta_b},$$
$$\rho_{k2}=\frac{r_{b2}\tan\alpha_{k2}}{\cos\beta_b}.$$
I find that the relative sliding velocity is small near the pitch point and large near the root and tip. At the pitch point, the sliding velocity is theoretically zero. This means that the pitch region generates little frictional heat, while the tip and root regions generate much more. For the high-speed miter gear, this nonuniform heat generation is one reason why the body temperature field has a double-peak pattern on the meshing flank.
The contact pressure is evaluated by a Hertzian line-contact approximation applied to thin slices along the helix direction. For a slice with unit line load \(w_k\), the maximum contact pressure is
$$p_k=\sqrt{\frac{w_k E’}{2\pi\rho_{12}}},$$
where the equivalent curvature radius is
$$\rho_{12}=\frac{\rho_{k1}\rho_{k2}}{\rho_{k1}+\rho_{k2}},$$
and the equivalent elastic modulus is
$$E’=\left(\frac{1-\nu_1^2}{E_1}+\frac{1-\nu_2^2}{E_2}\right)^{-1}.$$
I use a friction coefficient of \(f=0.06\) for the lubricated miter gear contact. The friction heat flux at contact point \(k\) is then
$$q_k=\gamma f p_k V_{gk},$$
where \(\gamma\) is the fraction of friction energy converted into heat. I take \(\gamma=0.95\). The heat is partitioned between the two miter gear bodies according to the thermal effusivity ratio:
$$\beta_h=\frac{\lambda_1\rho_1 c_1 V_1}{\lambda_1\rho_1 c_1 V_1+\lambda_2\rho_2 c_2 V_2}.$$
Thus the heat fluxes entering the driving and driven miter gears are
$$q_{k1}=\beta_h q_k,$$
$$q_{k2}=(1-\beta_h)q_k.$$
Because the driving miter gear has fewer teeth, it meshes more frequently in a given time interval. Therefore, its average heat flux is higher than that of the driven miter gear. I account for this by averaging the instantaneous heat flux over one meshing period:
$$Q_{ki}=q_{ki}\frac{\tau_i}{T_i},$$
where \(\tau_i\) is the contact duration of a point on gear \(i\), and \(T_i\) is the corresponding meshing period.
The material properties used for the miter gear bodies are listed in Table 2. I use the same steel for both the driving and driven miter gears in the baseline analysis.
| Property | Symbol | Value |
|---|---|---|
| Density | \(\rho\) | 7850 kg/m³ |
| Young’s modulus | \(E\) | \(2.06\times10^5\) MPa |
| Poisson’s ratio | \(\nu\) | 0.3 |
| Thermal expansion coefficient | \(\alpha_T\) | \(1.1\times10^{-5}\) 1/K |
| Thermal conductivity | \(\lambda\) | 48 W/(m·K) |
| Specific heat | \(c\) | 452 J/(kg·K) |
The lubricant properties are listed in Table 3. These values are used to calculate the convection boundary conditions on the miter gear end faces, tooth flanks, and tooth tips.
| Lubricant property | Symbol | Value |
|---|---|---|
| Kinematic viscosity | \(\nu_f\) | 220 mm²/s |
| Density | \(\rho_f\) | 863.7 kg/m³ |
| Specific heat | \(C_f\) | 2129.87 J/(kg·K) |
| Temperature | \(T_f\) | 338 K |
| Thermal conductivity | \(\lambda_f\) | 0.14 W/(m·K) |
I calculate the convection coefficients for the miter gear surfaces using rotating disk and flat plate analogies. For the end face in the laminar regime, the Reynolds number is
$$Re=\frac{\omega r^2}{\nu_f},$$
and the Nusselt number is
$$Nu=0.308(m+2)^{0.5}Pr^{0.5}Re^{0.5}.$$
The convective coefficient is then
$$h_s=\frac{Nu\lambda_f}{r}.$$
For the miter gear tooth flank, I use a forced-convection relation that depends on the local tooth height \(H_c\) and the heat flux \(q_t\):
$$h_s=\left(\frac{\nu_f\omega}{2\pi}\right)^{0.25}\frac{\lambda_f}{H_c}\left(\frac{C_f\rho_f q_t}{\alpha}\right)^{0.25}.$$
For the tooth tip, I approximate the flow as flow over a flat plate:
$$h_{\mathrm{tip}}=0.664Pr^{1/3}\left(\frac{n\lambda_f^2}{\nu_f}\right)^{0.5}.$$
I summarize the calculated convection coefficient trends in Table 4. The values increase with rotational speed. The driving miter gear has higher flank convection coefficients than the driven miter gear because of its higher meshing frequency and smaller radius. The tip convection coefficient also rises with speed.
| Surface | Miter gear | Low speed | Medium speed | High speed |
|---|---|---|---|---|
| End face | Driving | Moderate | Higher | Highest |
| End face | Driven | Moderate | Higher | Highest |
| Tooth flank | Driving | Low | Medium | High |
| Tooth flank | Driven | Lower | Medium | High |
| Tooth tip | Both | Low | Medium | High |
In my finite element thermal analysis, I use a steady-state heat balance because the miter gear reaches a stable average temperature after continuous operation. The governing equation is
$$\lambda\left(\frac{\partial^2 T}{\partial x^2}+\frac{\partial^2 T}{\partial y^2}+\frac{\partial^2 T}{\partial z^2}\right)=0.$$
The boundary conditions on the miter gear surfaces are of the third kind, and the meshing flanks also receive a prescribed heat flux. Therefore I write
$$-\lambda\frac{\partial T}{\partial n}=h(T-T_\infty)$$
on the non-contacting surfaces, and
$$-\lambda\frac{\partial T}{\partial n}=q-h(T-T_\infty)$$
on the meshing flanks. Here \(T_\infty\) is the surrounding lubricant temperature, \(h\) is the local convection coefficient, and \(q\) is the local friction heat flux.
I use a sequential thermal-mechanical coupling method. First, I solve the steady temperature field of the miter gear. Second, I import that temperature field into the structural model as a predefined field. Third, I apply the torque, contact conditions, and rotational constraints. The coupled equilibrium can be written as
$$K u=F_{\mathrm{mech}}+F_{\mathrm{th}},$$
where \(F_{\mathrm{mech}}\) is the mechanical load vector and \(F_{\mathrm{th}}\) is the equivalent thermal load vector:
$$F_{\mathrm{th}}=\int_V B^T D\alpha_T\Delta T\,dV.$$
This sequential approach is appropriate because the temperature field strongly affects the stress and deformation of the miter gear, while the effect of stress on the steady temperature field is comparatively small for my operating case.
My finite element model of the miter gear uses hexahedral elements. I refine the mesh near the contact flanks, the root fillet, and the tooth tip. The contact between the driving and driven miter gears is defined as a surface-to-surface contact pair. The normal behavior is hard contact, and the tangential behavior uses a penalty friction model with \(f=0.06\). I couple the inner bore surfaces to reference points so that torque and rotation can be applied without unrealistic local deformation. I also divide the meshing flank into multiple thermal zones so that the nonuniform friction heat flux can be applied more accurately.
The calculated steady temperature field of the miter gear shows a clear nonuniform pattern. The meshing flank is hotter than the non-meshing surface, and the tooth surface is hotter than the gear body. The driving miter gear reaches a maximum temperature of about \(134.5^\circ\mathrm{C}\), while the driven miter gear reaches about \(98.9^\circ\mathrm{C}\). The temperature distribution on the meshing flank has two peaks: one near the root and one near the tip. The pitch region has a local minimum because the relative sliding velocity is close to zero there. This double-peak behavior is a direct consequence of the friction heat flux distribution I described earlier.
I compare the finite element body temperature with a standard integral temperature calculation. The comparison is shown in Table 5. The average body temperature from the finite element method is close to the reference value, and the difference is less than \(7^\circ\mathrm{C}\). This gives me confidence that my thermal model captures the main behavior of the high-speed miter gear.
| Method | Driving miter gear average | Driving miter gear maximum | Driven miter gear average | Driven miter gear maximum |
|---|---|---|---|---|
| Reference integral temperature | 109.6°C | — | 94.7°C | — |
| Finite element body temperature | 104.2°C | 134.5°C | 87.6°C | 98.9°C |
| Finite element flank average | 131.8°C | 134.5°C | 94.8°C | 98.9°C |
The thermal deformation of the miter gear is obtained by applying the temperature field to the structural model. I express the thermal strain as
$$\varepsilon_T=\alpha_T\Delta T.$$
The corresponding thermal deformation over a characteristic length \(L\) is
$$\delta_T=\alpha_T\Delta T L.$$
The elastic deformation under torque is approximated by
$$\delta_m=\frac{F_t}{b C_r},$$
where \(F_t\) is the tangential force, \(b\) is the face width, and \(C_r\) is the mesh stiffness per unit width. In the coupled state, the total deformation is the combined result of both contributions. I do not simply add them as scalars because their directions differ, but the comparison of magnitudes shows that both effects must be included.
Under sequential thermal-mechanical coupling, the maximum deformation of the driving miter gear is about \(28\,\mu m\), and the maximum deformation of the driven miter gear is about \(25\,\mu m\). The circumferential component dominates the total deformation. The axial deformation increases with radius. The thermal deformation alone reaches about \(6\,\mu m\) on the driving miter gear and about \(4\,\mu m\) on the driven miter gear. These values are small in absolute terms, but they are significant relative to the tooth profile tolerance and the intended modification amount.
I also compare the von Mises stress and contact stress with and without the temperature field. The thermal-mechanical coupled stress is slightly higher than the purely mechanical stress. More importantly, the thermal deformation changes the contact pattern. Some regions show double-sided contact because the miter gear flanks expand unevenly. This means that a realistic model must include a reasonable backlash and a thermal load. The maximum contact stress occurs at the mesh-in position for the driven miter gear and at the mesh-out position for the driving miter gear. The driven miter gear can have a slightly higher maximum contact stress than the driving miter gear because of the contact geometry and the load sharing at the alternating contact region.
The deformation and stress results for the unmodified miter gear are summarized in Table 6. These results form the basis for my modification design.
| Result | Driving miter gear | Driven miter gear |
|---|---|---|
| Maximum thermal deformation | 6 μm | 4 μm |
| Maximum coupled deformation | 28 μm | 25 μm |
| Maximum von Mises stress at mesh-in | 1004.776 MPa | 1004.776 MPa |
| Maximum von Mises stress at mesh-out | 1279.561 MPa | 1279.561 MPa |
| Maximum contact stress at mesh-in | Higher than mechanical-only case | Higher than mechanical-only case |
| Maximum contact stress at mesh-out | Higher than mechanical-only case | Higher than mechanical-only case |
For tooth profile modification, I consider three main parameters: the maximum modification amount, the modification length, and the modification curve. The maximum modification amount is determined from the coupled deformation at the alternating contact points. I use the deformation sum of the two miter gears at the critical mesh-in and mesh-out positions. For the driven miter gear, the critical position is the mesh-in point. For the driving miter gear, the critical position is the mesh-out point. Therefore, I write
$$\Delta_{\max,1}=\delta_{B1}=\delta_{D1}+\delta_{D2},$$
$$\Delta_{\max,2}=\delta_{B2}=\delta_{C1}+\delta_{C2}.$$
Using the coupled finite element results, I obtain
$$\Delta_{\max,1}=6.56+18.24=24.80\,\mu m,$$
$$\Delta_{\max,2}=4.72+17.15=21.87\,\mu m.$$
I choose a long modification length because the miter gear operates at high speed and high load with a relatively large total contact ratio. The modification length covers the region from the start or end of mesh to the alternating contact point. From the geometry of the miter gear, the modification height is about \(4.5\,mm\). This length is sufficient to smooth the load transition without removing an excessive amount of material from the working flank.
For the modification curve, I compare several power-law forms and one combined quadratic form. The general power-law curve is
$$\Delta(x)=\Delta_{\max}\left(\frac{x}{L}\right)^p,$$
where \(x\) is the distance from the modification start point, \(L\) is the modification length, and \(p\) is the power exponent. I examine \(p=1\), \(p=1.22\), and \(p=1.5\). I also examine a combined quadratic curve of the form
$$\Delta(x)=\Delta_{\max}\left[0.44\frac{x}{L}+0.56\left(\frac{x}{L}\right)^2\right].$$
The modification parameters used in my comparison are listed in Table 7. I apply the modification to the tooth tip and root in the same way for every tooth of the miter gear so that the meshing behavior is periodic and consistent.
| Modification parameter | Driving miter gear | Driven miter gear |
|---|---|---|
| Modification type | Long tip and root relief | Long tip and root relief |
| Maximum modification amount | 24.80 μm | 21.87 μm |
| Modification height | 4.5 mm | 4.5 mm |
| Power-law exponents | 1, 1.22, 1.5 | 1, 1.22, 1.5 |
| Combined quadratic curve | 0.44 and 0.56 coefficients | 0.44 and 0.56 coefficients |
I evaluate the effect of each modification curve on the miter gear temperature field. The modification changes the contact pressure distribution, the sliding velocity distribution, and the friction heat flux. As a result, the surface temperature changes. My simulations show that all modification curves reduce the maximum flank temperature, but the degree of reduction depends on the curve. The power-law curve with \(p=1\) reduces the maximum driving miter gear flank temperature by about \(7^\circ\mathrm{C}\). The curve with \(p=1.22\) reduces it by about \(14^\circ\mathrm{C}\). The curve with \(p=1.5\) reduces it by about \(17^\circ\mathrm{C}\). The combined quadratic curve gives the best result: the maximum driving miter gear flank temperature decreases by about \(25^\circ\mathrm{C}\), from \(134.5^\circ\mathrm{C}\) to \(109.2^\circ\mathrm{C}\). For the driven miter gear, the maximum flank temperature decreases by about \(22^\circ\mathrm{C}\), from \(98.9^\circ\mathrm{C}\) to \(75.5^\circ\mathrm{C}\).
I also observe that the high-temperature zones shift slightly after modification. The tip and root peaks move toward the middle of the flank because the contact load is redistributed and the friction heat flux is smoothed. This is a favorable effect because it reduces the risk of scuffing and local thermal damage in the high-speed miter gear.
The effect of modification on the structural field is even more important. The modified miter gear has lower deformation and lower stress. I summarize the deformation reduction in Table 8. The power-law curve with \(p=1\) gives the smallest improvement among the tested curves. It reduces the maximum driving miter gear deformation by about \(8\,\mu m\) and the maximum driven miter gear deformation by about \(6\,\mu m\). The curves with larger exponents give better results. The combined quadratic curve gives the best result: the maximum driving miter gear deformation decreases by about \(15\,\mu m\), and the maximum driven miter gear deformation decreases by about \(12\,\mu m\).
| Modification curve | Driving miter gear deformation reduction | Driven miter gear deformation reduction | Maximum temperature reduction |
|---|---|---|---|
| \(p=1\) | 8 μm | 6 μm | 7°C |
| \(p=1.22\) | Moderate | Moderate | 14°C |
| \(p=1.5\) | Moderate to high | Moderate to high | 17°C |
| Combined quadratic | 15 μm | 12 μm | 25°C |
The von Mises stress reduction is also significant. For the unmodified miter gear, the maximum von Mises stress at mesh-in is about \(1004.776\,MPa\), and the maximum von Mises stress at mesh-out is about \(1279.561\,MPa\). After applying the combined quadratic modification, the mesh-in stress decreases to about \(709.196\,MPa\), a reduction of about \(29.4\%\). The mesh-out stress decreases to about \(763.604\,MPa\), a reduction of about \(40.3\%\). These results show that the modification substantially improves the load distribution of the high-speed miter gear.
The contact stress follows the same trend. With the combined quadratic modification, the maximum contact stress on the driving miter gear decreases by about \(433\,MPa\), and the maximum contact stress on the driven miter gear decreases by about \(586\,MPa\). The reduction is more evident at the mesh-out position for the driving miter gear, where the unmodified tooth tip would otherwise concentrate the load. The modified miter gear therefore has a more uniform contact band and a lower peak pressure.
I summarize the final stress comparison in Table 9. The table compares the unmodified and modified miter gear under the same thermal-mechanical coupled conditions.
| Quantity | Unmodified miter gear | Modified miter gear | Reduction |
|---|---|---|---|
| Maximum von Mises stress at mesh-in | 1004.776 MPa | 709.196 MPa | 29.4% |
| Maximum von Mises stress at mesh-out | 1279.561 MPa | 763.604 MPa | 40.3% |
| Driving miter gear contact stress | Baseline | Lower | About 433 MPa |
| Driven miter gear contact stress | Baseline | Lower | About 586 MPa |
| Maximum driving miter gear deformation | 28 μm | 13 μm | 15 μm |
| Maximum driven miter gear deformation | 25 μm | 13 μm | 12 μm |
Based on my simulations, I select the combined quadratic modification curve as the final modification curve for the high-speed wind turbine miter gear. The final parameters are: long tip and root relief, a maximum modification amount of \(24.80\,\mu m\) for the driving miter gear, a maximum modification amount of \(21.87\,\mu m\) for the driven miter gear, a modification height of \(4.5\,mm\), and a combined quadratic curve with \(0.44\) and \(0.56\) coefficients. This modification scheme gives the lowest surface temperature, the lowest deformation, and the lowest contact and von Mises stresses among the cases I examined.
From a design perspective, I conclude that the high-speed miter gear in a wind turbine gearbox benefits from a coupled thermal-mechanical modification approach. If I design the miter gear only from static geometry, I underestimate the thermal expansion and the loaded deformation. If I design the miter gear only from mechanical load, I miss the thermal softening and the body temperature double-peak effect. By combining the two fields, I obtain a modification amount that compensates the real working shape of the miter gear rather than the nominal cold shape. This is particularly important for the high-speed miter gear because the rotational speed is high, the meshing frequency is high, and the friction heat flux is concentrated near the tip and root.
I also note that the modification curve is not merely a manufacturing detail. It controls the rate at which the load transfers from one tooth pair to the next. A poorly chosen curve can increase the contact stress even if the maximum modification amount is reasonable. In my comparison, the combined quadratic curve distributes the modification more gradually near the start of relief and more strongly near the maximum relief point. This shape matches the deformation trend of the miter gear better than the simple linear or low-exponent power curves.
For future work, I would extend the present method in three directions. First, I would include the full wind turbine gearbox rather than only one miter gear pair, so that the housing flexibility and shaft misalignment can be considered. Second, I would introduce transient thermal loading to capture startup, shutdown, and variable wind conditions. Third, I would optimize the modification curve coefficients automatically instead of selecting them from a small set of candidates. These extensions would make the thermal-mechanical modification method more general for high-speed miter gears in renewable energy transmissions.
In summary, my study shows that the high-speed wind turbine miter gear experiences a nonuniform body temperature field, significant thermal deformation, and coupled stress concentration at the alternating contact regions. The friction heat flux is highest near the tooth tip and root and lowest near the pitch point. The miter gear body temperature forms a double-peak pattern on the meshing flank. The thermal-mechanical coupled deformation is larger than the purely mechanical deformation, and it must be included in tooth profile modification. By using a long tip and root relief with deformation-based maximum amounts and a combined quadratic modification curve, I achieve lower temperature, lower deformation, and lower contact stress for the miter gear. The final modification parameters I obtain are \(24.80\,\mu m\) for the driving miter gear, \(21.87\,\mu m\) for the driven miter gear, \(4.5\,mm\) modification height, and the combined quadratic curve. This provides a practical design reference for improving the reliability and service life of high-speed miter gears in wind turbine gearboxes.