
In my research, I focused on the contact fatigue life of miter gears, especially herringbone-type miter gears with centring errors and angular misalignment errors. A miter gear is widely used in heavy-load transmission systems because it can balance axial forces and provide high load capacity. However, a miter gear is sensitive to manufacturing and assembly errors, which cause uneven load sharing between the left and right helical tooth sides. This uneven load sharing reduces the contact fatigue life of the miter gear. I developed a numerical and analytical framework to predict the contact fatigue life of a miter gear with errors and to calculate its eccentric load coefficient. The framework includes finite element contact analysis, critical plane fatigue life prediction, tip relief optimization, angular adjustment, and time-varying mesh stiffness calculation. The main objective is to provide a reliable method for evaluating the fatigue performance of a miter gear under error conditions.
I first derived the tooth surface equations of a miter gear based on the generating machining principle. Then I built a precise geometric model and a finite element contact model. I used a multi-step loading method to obtain the complete stress history. After that, I analyzed the loading path type and applied a critical plane method suitable for non-proportional multiaxial loading. I calculated the crack initiation life of standard and error-containing miter gears. I also investigated the effects of tip relief and angular adjustment on the fatigue life of the miter gear. Finally, I proposed an analytical method for the eccentric load coefficient of a miter gear with centring error or angular misalignment. The method is based on the potential energy principle and the slice method. The results show that errors significantly reduce the contact fatigue life of a miter gear, and proper tip relief or angular adjustment can improve the life.
Geometric Modeling of a Miter Gear
The miter gear studied in this work consists of two symmetric helical gear sides separated by an undercut groove. The generating machining principle is used to describe the tooth profile. The rack cutter moves along the pitch line of the gear, and the envelope of the cutter profile forms the tooth surface. I established several coordinate systems to derive the tooth surface equations. Let the fixed coordinate system be \(C_0(OXY)\), the coordinate system attached to the rack cutter be \(C_d(O_dX_dY_d)\), and the coordinate system attached to the gear be \(C_g(O_gX_gY_g)\). The transformation between \(C_d\) and \(C_g\) is given by
$$
\begin{bmatrix}
x_g \\
y_g \\
1
\end{bmatrix}
=
M_{gd}
\begin{bmatrix}
x_d \\
y_d \\
1
\end{bmatrix}
$$
where the transformation matrix \(M_{gd}\) is
$$
M_{gd}
=
\begin{bmatrix}
\cos\varphi & \sin\varphi & r\sin\varphi + r\varphi\cos\varphi \\
-\sin\varphi & \cos\varphi & r\cos\varphi – r\varphi\sin\varphi \\
0 & 0 & 1
\end{bmatrix}
$$
Here \(r\) is the pitch radius of the gear and \(\varphi\) is the rotation angle of the gear. The tooth profile of the miter gear includes the addendum circle, the involute profile, and the root fillet. The root fillet is generated by the tip corner of the rack cutter. The involute profile is generated by the straight line of the rack cutter. For a point \(M_2\) on the cutter tip corner, its coordinates in \(C_d\) are
$$
\begin{cases}
x_2 = x_c + \rho \cos\gamma \\
y_2 = y_c – \rho \sin\gamma
\end{cases}
$$
where \(x_c\) and \(y_c\) are the coordinates of the corner center, \(\rho\) is the corner radius, and \(\gamma\) is the normal angle. The root fillet equation can be obtained by substituting these coordinates into the transformation equation. Similarly, for a point \(M_c\) on the straight line of the rack cutter, the coordinates are
$$
\begin{cases}
x_c = (r – y_0)\sin\varphi + \frac{y_0}{\cos\alpha}\cos\varphi \\
y_c = (r – y_0)\cos\varphi – \frac{y_0}{\cos\alpha}\sin\varphi
\end{cases}
$$
where \(\alpha\) is the pressure angle and \(y_0\) is the distance from the point to the pitch line. The involute profile equation is then obtained by substituting the above expression into the transformation equation.
For a helical gear, the tooth surface is generated by sweeping the profile along a helix. The equation of the helical tooth surface can be written as
$$
\begin{cases}
X = R \cos\left(\frac{\tan\beta}{r} t\right) \\
Y = R \sin\left(\frac{\tan\beta}{r} t\right) \\
Z = b t
\end{cases}
\quad 0 \le t \le 1
$$
where \(R = \sqrt{x^2 + y^2}\), \(b\) is the face width, and \(\beta\) is the helix angle. A miter gear is formed by mirroring two helical gears with opposite hands. The tooth surface equation of a miter gear is therefore
$$
\begin{cases}
X = R \cos\left(\frac{\tan\beta}{r} t\right) \\
Y = R \sin\left(\frac{\tan\beta}{r} t\right) \\
Z = \pm \left( \frac{L_{an}}{2} + b t \right)
\end{cases}
\quad 0 \le t \le 1
$$
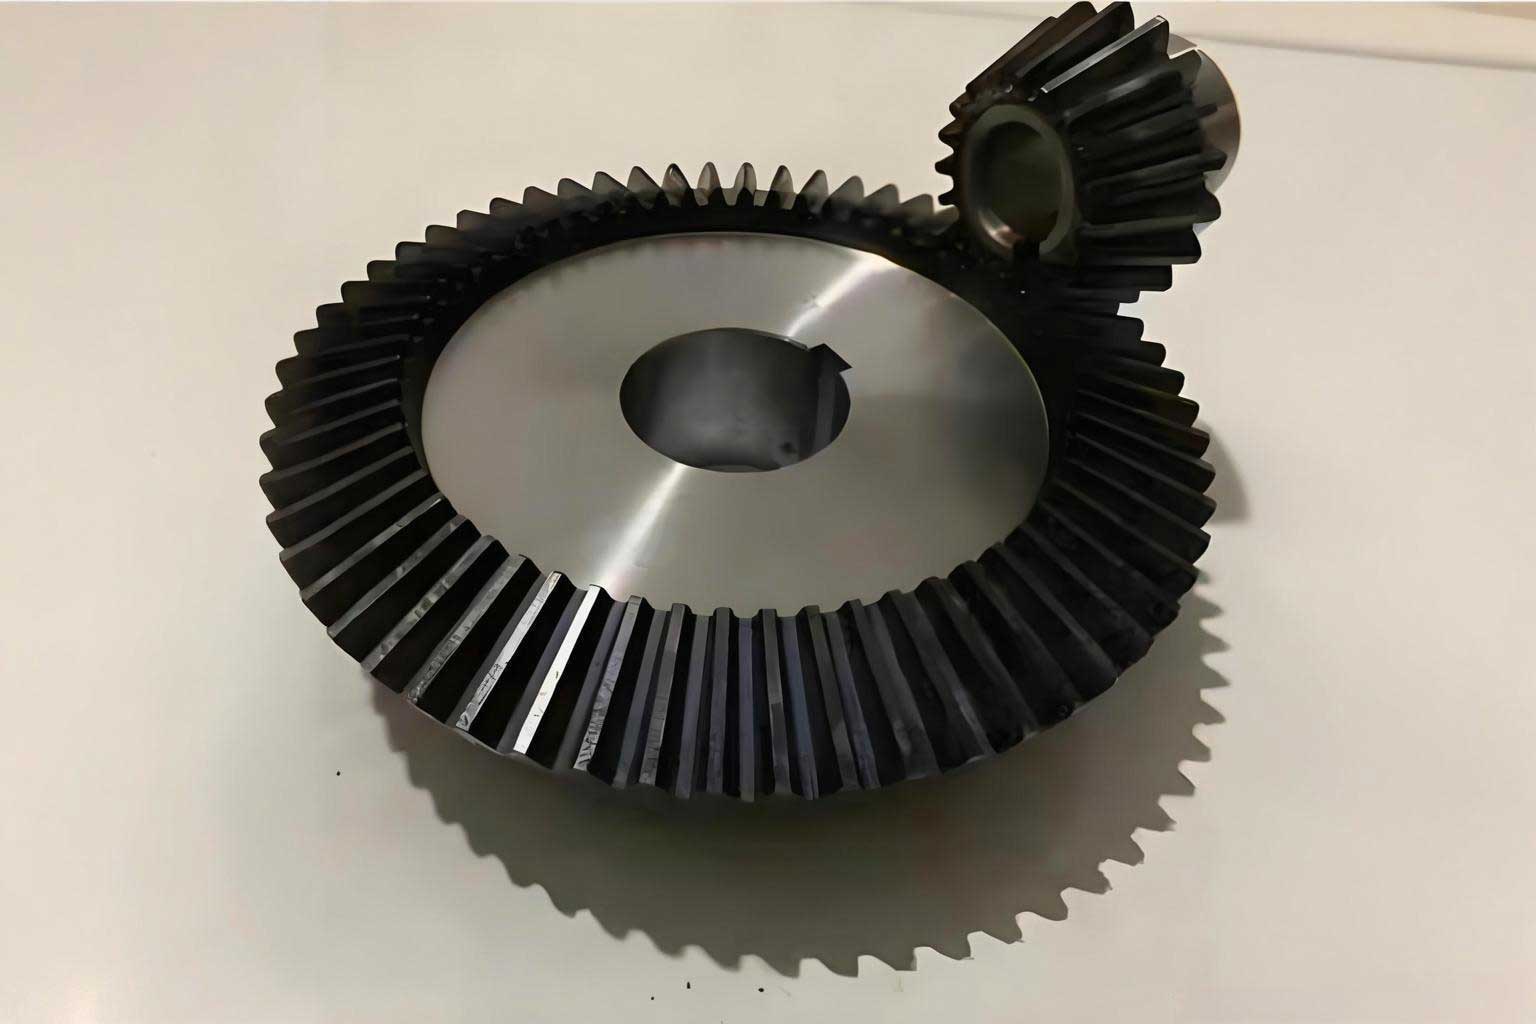
where \(L_{an}\) is the undercut groove width. Using these equations, I generated discrete points on the tooth surface and imported them into a three-dimensional modeling software to create a precise miter gear model. The assembled miter gear model showed good meshing contact, which verified the correctness of the derived equations.
Finite Element Contact Analysis of a Miter Gear
I established a finite element contact model of the miter gear. To reduce the computational cost, I first calculated the contact half-width and the maximum stress depth using Hertz contact theory. This allowed me to determine the optimal mesh size near the tooth surface. The contact half-width \(a\) is given by
$$
a = \sqrt{\frac{4P}{\pi} \frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2} \Big/ \left( \frac{1}{r_1} + \frac{1}{r_2} \right)}
$$
where \(P\) is the load per unit length along the contact line, \(r_1\) and \(r_2\) are the radii of curvature at the contact point, \(E_1\) and \(E_2\) are the elastic moduli, and \(\nu_1\) and \(\nu_2\) are the Poisson’s ratios. The surface pressure distribution is
$$
p(x) = \frac{2P}{\pi a} \sqrt{1 – \frac{x^2}{a^2}}
$$
The subsurface stress field can be obtained by integrating the Flamant solution. For a point \(D(x_1,z_1)\) below the surface, the stress components are
$$
\begin{aligned}
\sigma_x &= -\frac{2z_1}{\pi} \int_{-a}^{a} \frac{p(x)(x_1-x)^2}{(x_1-x)^2+z_1^2} \, dx \\
\sigma_z &= -\frac{2z_1^3}{\pi} \int_{-a}^{a} \frac{p(x)}{(x_1-x)^2+z_1^2} \, dx \\
\tau_{xy} &= -\frac{2z_1^2}{\pi} \int_{-a}^{a} \frac{p(x)(x_1-x)}{(x_1-x)^2+z_1^2} \, dx
\end{aligned}
$$
For the standard miter gear, the maximum von Mises equivalent stress occurs at a depth of about \(0.7a\), which is approximately \(0.10\,\text{mm}\). Therefore, I set the minimum mesh size near the contact surface to \(0.05\,\text{mm}\). The finite element model used C3D8R hexahedral elements. The total number of elements was about \(450,000\). The material properties of the miter gear are listed in Table 1. The gear material is 45 steel. The boundary conditions included a torque of \(408\,\text{N}\cdot\text{m}\), a face-to-face contact definition, and a friction coefficient of \(0.04\) under oil lubrication.
| Material | Tensile strength \(\sigma_T\) (MPa) | Yield strength \(\sigma_S\) (MPa) | Elastic modulus \(E\) (MPa) | Poisson’s ratio \(\nu\) |
|---|---|---|---|---|
| 45 steel | 897.7 | 807.9 | \(2.06 \times 10^5\) | 0.3 |
I used a multi-step loading method to obtain a continuous meshing process. First, I fixed all degrees of freedom except the rotation of the driving miter gear about its axis. A small rotational displacement was applied to bring the two miter gears into contact. Then, I released the rotational degree of freedom and gradually increased the torque to the rated value. Finally, I released the rotational degree of freedom of the driven miter gear and applied a rotational displacement. The maximum analysis step increment was controlled to ensure a smooth meshing process. The complete meshing cycle was achieved after about 200 increments.
For the standard miter gear, the contact stress and contact area on the left and right helical sides were symmetric. The von Mises equivalent stress was also symmetric. The maximum stress below the surface occurred at a depth between \(0.10\,\text{mm}\) and \(0.13\,\text{mm}\). This result agrees with the literature and with the ISO and AGMA standards.
Effects of Centring Error and Angular Misalignment on Contact Stress
A miter gear is often manufactured as two separate helical gear sides. Therefore, a centring error is inevitable. The centring error \(\delta_{ce}\) is defined as the distance between the intersection points of the left and right helix lines on the symmetry plane of the miter gear. When the miter gear has a centring error, the load on one side is higher than that on the other side. I introduced a centring error of \(5\,\mu\text{m}\), \(10\,\mu\text{m}\), and \(15\,\mu\text{m}\) in the driven miter gear while keeping the driving miter gear standard. The results showed that the stress on the left side increased significantly, while the stress on the right side decreased. When the centring error increased from \(5\,\mu\text{m}\) to \(15\,\mu\text{m}\), the maximum von Mises stress increased by \(10\%\) to \(43\%\). The contact force history also showed that the left side carried more load than the right side. The maximum contact force increased with the centring error.
I also studied two types of angular misalignment errors. The first type is \(\Delta f_{x-z}\), where the driven miter gear axis is tilted in the \(x-z\) plane. The second type is \(\Delta f_{y-z}\), where the driven axis is tilted in the \(y-z\) plane. I set the misalignment values to \(10\,\mu\text{m}\) and \(20\,\mu\text{m}\). For both types, the stress on the left side increased, and the stress on the right side decreased. When \(\Delta f_{x-z}\) increased from \(10\,\mu\text{m}\) to \(20\,\mu\text{m}\), the stress increase ranged from \(24\%\) to \(44\%\). When \(\Delta f_{y-z}\) increased from \(10\,\mu\text{m}\) to \(20\,\mu\text{m}\), the stress increase ranged from \(19\%\) to \(40\%\). The contact force history confirmed the uneven load sharing. The angular misalignment also caused a non-uniform stress distribution along the face width of a single helical tooth.
Table 2 summarizes the maximum von Mises stress and the load sharing ratio for the standard miter gear and the error-containing miter gears. The load sharing ratio is defined as the contact force on the high-load side divided by the total contact force. It can be seen that both centring error and angular misalignment significantly increase the load on one side of the miter gear.
| Error type | Error value (\(\mu\)m) | Maximum von Mises stress (MPa) | Load sharing ratio on high-load side |
|---|---|---|---|
| Standard | 0 | 620 | 0.50 |
| Centring error | 5 | 682 | 0.58 |
| Centring error | 10 | 758 | 0.67 |
| Centring error | 15 | 887 | 0.75 |
| \(\Delta f_{x-z}\) | 10 | 769 | 0.64 |
| \(\Delta f_{x-z}\) | 20 | 893 | 0.78 |
| \(\Delta f_{y-z}\) | 10 | 738 | 0.61 |
| \(\Delta f_{y-z}\) | 20 | 868 | 0.74 |
Loading Path and Critical Plane Method
The contact stress history obtained from the finite element analysis was used to determine the loading path type. I selected nodes on the tooth surface and at the subsurface. For each node, I calculated the time-varying maximum shear stress using elasticity theory. The critical plane direction was determined by the maximum shear stress plane. The normal stress and shear stress on the critical plane showed a phase difference of about \(90^\circ\). Therefore, the loading path of the miter gear is multiaxial non-proportional. This means that a multiaxial fatigue criterion suitable for non-proportional loading should be used.
The stress state at any point on the tooth surface is represented by the stress tensor
$$
\boldsymbol{\sigma} =
\begin{bmatrix}
\sigma_{11} & \sigma_{12} & \sigma_{13} \\
\sigma_{21} & \sigma_{22} & \sigma_{23} \\
\sigma_{31} & \sigma_{32} & \sigma_{33}
\end{bmatrix}
$$
where \(\sigma_{12}=\sigma_{21}\), \(\sigma_{23}=\sigma_{32}\), and \(\sigma_{13}=\sigma_{31}\). For a plane with unit normal vector \(\mathbf{n}=(l,m,n)\), the traction vector \(\mathbf{p}\) is
$$
\begin{cases}
p_1 = \sigma_{11} l + \sigma_{21} m + \sigma_{31} n \\
p_2 = \sigma_{22} m + \sigma_{32} n + \sigma_{12} l \\
p_3 = \sigma_{33} n + \sigma_{13} l + \sigma_{23} m
\end{cases}
$$
The principal stresses \(\sigma_1\), \(\sigma_2\), and \(\sigma_3\) are obtained by solving the eigenvalue problem
$$
\begin{vmatrix}
\sigma_{11} – \sigma & \sigma_{12} & \sigma_{13} \\
\sigma_{21} & \sigma_{22} – \sigma & \sigma_{23} \\
\sigma_{31} & \sigma_{32} & \sigma_{33} – \sigma
\end{vmatrix}
= 0
$$
The maximum shear stress plane is the plane that bisects the maximum and minimum principal stresses. The normal vector of the critical plane is
$$
\mathbf{v}_{cp} = \frac{\mathbf{v}_1 + \mathbf{v}_3}{2}
$$
where \(\mathbf{v}_1\) and \(\mathbf{v}_3\) are the unit vectors of the maximum and minimum principal stresses, respectively. In the finite element analysis, the stress history is recorded at each increment step. The time-varying maximum shear stress is calculated as
$$
\tau_{max}(n) = \max_{ij} \left( \frac{\sigma_1(n) – \sigma_3(n)}{2} \right)
$$
The critical plane is the plane where the maximum shear stress occurs. Once the critical plane is determined, the normal strain and shear strain on that plane can be calculated. I used the Shang-Wang multiaxial fatigue model to calculate the equivalent damage parameter. The equivalent strain range is
$$
\Delta \varepsilon_{eq}^{er} = \left[ \left( \frac{\Delta \gamma_{max}}{2} \right)^2 + \frac{1}{3} \left( \frac{\Delta \varepsilon_n^*}{2} \right)^2 \right]^{1/2}
$$
where \(\Delta \gamma_{max}\) is the maximum shear strain range on the critical plane, and \(\Delta \varepsilon_n^*\) is the normal strain range between the reversal points. The normal strain range is
$$
\Delta \varepsilon_n^* = \frac{1}{2} \Delta \varepsilon_n \left[ 1 + \cos(\Delta \beta) \right]
$$
where \(\Delta \beta\) is the phase difference between the normal strain and shear strain. The fatigue life is then calculated using the Manson-Coffin equation
$$
\frac{\Delta \varepsilon_{eq}^{er}}{2} = \frac{\sigma_f’}{E} (2N_f)^b + \varepsilon_f’ (2N_f)^c
$$
where \(\sigma_f’\) is the fatigue strength coefficient, \(\varepsilon_f’\) is the fatigue ductility coefficient, \(b\) is the fatigue strength exponent, and \(c\) is the fatigue ductility exponent. The material constants for 45 steel are listed in Table 3.
| Fatigue strength coefficient \(\sigma_f’\) (MPa) | Fatigue ductility coefficient \(\varepsilon_f’\) | Fatigue strength exponent \(b\) | Fatigue ductility exponent \(c\) |
|---|---|---|---|
| 1041.4 | 1.5048 | -0.0967 | -0.7338 |
Contact Fatigue Life of Standard and Error-Containing Miter Gears
I calculated the contact fatigue crack initiation life of the standard miter gear and the miter gears with errors. For the standard miter gear, the life distribution along the tooth height and tooth width was obtained. The lowest life occurred near the pitch line and at the addendum, where stress concentration exists. The life at the tooth root was higher because the bending stress is lower. Along the tooth width, the life decreased from the surface to a depth of \(0.10\,\text{mm}\), and then increased. This means that the minimum life occurs at the subsurface, which is consistent with rolling contact fatigue theory.
For the miter gear with centring error, the fatigue life decreased significantly. The life decreased as the centring error increased. When the centring error was \(5\,\mu\text{m}\), the life reduction was moderate. When the centring error increased to \(10\,\mu\text{m}\) or \(15\,\mu\text{m}\), the life dropped dramatically. Table 4 shows the minimum life near the pitch line for different error conditions. The standard miter gear had a life of \(5.31 \times 10^6\) cycles, which was set as \(100\%\). With a centring error of \(10\,\mu\text{m}\), the life dropped to \(13.5\%\) of the standard value. With a centring error of \(15\,\mu\text{m}\), the life dropped to \(5.6\%\).
| Case | Centring error (\(\mu\)m) | \(\Delta f_{x-z}\) (\(\mu\)m) | \(\Delta f_{y-z}\) (\(\mu\)m) | Life (cycles) | Percentage (%) |
|---|---|---|---|---|---|
| Standard | 0 | 0 | 0 | \(5.31 \times 10^6\) | 100.0 |
| Centring error | 5 | 0 | 0 | \(3.35 \times 10^6\) | 63.0 |
| Centring error | 10 | 0 | 0 | \(7.18 \times 10^5\) | 13.5 |
| Centring error | 15 | 0 | 0 | \(2.99 \times 10^5\) | 5.6 |
| \(\Delta f_{x-z}\) | 0 | 10 | 0 | \(1.04 \times 10^6\) | 19.5 |
| \(\Delta f_{x-z}\) | 0 | 20 | 0 | \(2.88 \times 10^5\) | 5.4 |
| \(\Delta f_{y-z}\) | 0 | 0 | 10 | \(1.32 \times 10^6\) | 24.8 |
| \(\Delta f_{y-z}\) | 0 | 0 | 20 | \(3.16 \times 10^5\) | 5.9 |
For the angular misalignment errors, the fatigue life also decreased significantly. When the error value was the same, the \(\Delta f_{x-z}\) error caused a lower minimum life than the \(\Delta f_{y-z}\) error. However, the \(\Delta f_{y-z}\) error caused a more uniform reduction in life along the tooth width. The life reduction was more severe for larger error values. For example, with \(\Delta f_{x-z}\) of \(20\,\mu\text{m}\), the life dropped to \(5.4\%\) of the standard value. With \(\Delta f_{y-z}\) of \(20\,\mu\text{m}\), the life dropped to \(5.9\%\). The results show that when the error magnitude is the same, the centring error has the most detrimental effect on the contact fatigue life of a miter gear.
Tip Relief and Angular Adjustment for Life Improvement
Stress concentration at the addendum and dedendum is a major cause of fatigue life reduction in a miter gear. I applied tip relief to the miter gear to reduce the stress concentration. The tip relief was defined by a maximum relief amount \(\Delta t\), a relief height \(\Delta h\), and a relief curve. The relief curve used in this work is
$$
\Delta(x) = \Delta t \left( \frac{x}{\Delta h} \right)^n
$$
where \(n=2\) for a non-linear relief. I set \(\Delta t\) to \(5\,\mu\text{m}\), \(10\,\mu\text{m}\), and \(20\,\mu\text{m}\). The relief height \(\Delta h\) was \(1\,\text{mm}\). Both the driving and driven miter gears were tip-relieved. The finite element results showed that a moderate tip relief of \(5\,\mu\text{m}\) or \(10\,\mu\text{m}\) effectively eliminated the stress concentration at the addendum and dedendum. However, an excessive tip relief of \(20\,\mu\text{m}\) created new stress concentrations at the transition between the relief curve and the involute profile.
The contact fatigue life of the miter gear with centring error and tip relief was calculated. The results showed that a moderate tip relief increased the minimum life near the pitch line. For a miter gear with \(10\,\mu\text{m}\) centring error, a tip relief of \(5\,\mu\text{m}\) increased the minimum life by \(48.9\%\). A tip relief of \(10\,\mu\text{m}\) increased the minimum life by \(41.1\%\). However, a tip relief of \(20\,\mu\text{m}\) decreased the life because of the new stress concentration. For the miter gear with angular misalignment, a tip relief of \(5\,\mu\text{m}\) increased the minimum life by a factor of about \(2.0\). These results indicate that proper tip relief is an effective way to improve the contact fatigue life of a miter gear with errors.
I also studied the effect of angular adjustment on the fatigue life of a miter gear with centring error. Angular adjustment means that the driven miter gear axis is intentionally tilted to compensate for the centring error. Two types of angular adjustment were considered: \(\Delta a_{x-z}\) and \(\Delta a_{y-z}\). I set the adjustment value to \(10\,\mu\text{m}\), which was equal to the centring error. The finite element results showed that the angular adjustment reduced the maximum stress and improved the load sharing between the left and right helical sides. For a miter gear with \(10\,\mu\text{m}\) centring error, the life without adjustment was \(13.5\%\) of the standard value. With \(\Delta a_{x-z}\) adjustment, the life increased to \(28.8\%\) of the standard value. With \(\Delta a_{y-z}\) adjustment, the life increased to \(61.1\%\) of the standard value. Table 5 summarizes the life improvement due to angular adjustment.
| Case | Centring error (\(\mu\)m) | \(\Delta a_{x-z}\) (\(\mu\)m) | \(\Delta a_{y-z}\) (\(\mu\)m) | Life (cycles) | Percentage (%) |
|---|---|---|---|---|---|
| Standard | 0 | 0 | 0 | \(5.31 \times 10^6\) | 100.0 |
| Centring error | 10 | 0 | 0 | \(7.18 \times 10^5\) | 13.5 |
| Adjusted in \(x-z\) | 10 | 10 | 0 | \(1.53 \times 10^6\) | 28.8 |
| Adjusted in \(y-z\) | 10 | 0 | 10 | \(3.24 \times 10^6\) | 61.1 |
Time-Varying Mesh Stiffness and Eccentric Load Coefficient of a Miter Gear
The finite element method can accurately calculate the load sharing of a miter gear, but it is computationally expensive. Therefore, I developed an analytical method to calculate the eccentric load coefficient of a miter gear with errors. The method is based on the time-varying mesh stiffness (TVMS) and the slice method. A miter gear is equivalent to two symmetric helical gears. A helical gear is equivalent to a series of spur gear slices along the face width. The TVMS of each spur gear slice is calculated using the potential energy method. The total stiffness of the helical gear is obtained by summing the slice stiffnesses.
The potential energy method decomposes the tooth deflection into Hertzian contact deflection, bending deflection, shear deflection, axial compression deflection, and gear body deflection. The total mesh stiffness of a spur gear slice is
$$
k_i = \left( \frac{1}{k_h} + \frac{1}{k_{b1}} + \frac{1}{k_{s1}} + \frac{1}{k_{a1}} + \frac{1}{k_{f1}} + \frac{1}{k_{b2}} + \frac{1}{k_{s2}} + \frac{1}{k_{a2}} + \frac{1}{k_{f2}} \right)^{-1}
$$
where \(k_h\) is the Hertzian contact stiffness, \(k_b\) is the bending stiffness, \(k_s\) is the shear stiffness, \(k_a\) is the axial compression stiffness, and \(k_f\) is the gear body stiffness. The subscripts 1 and 2 refer to the driving and driven gears, respectively. The Hertzian contact stiffness is
$$
k_h = \frac{\pi E \Delta b}{4(1-\nu^2)\cos\beta}
$$
where \(\Delta b\) is the slice thickness and \(\beta\) is the helix angle. The gear body stiffness is calculated using the formula by Sainsot et al.
$$
k_f = \frac{1}{\frac{\cos^2\beta}{E \Delta b} \left( L^* \left( \frac{u_f}{S_f} \right)^2 + M^* \left( \frac{u_f}{S_f} \right) + P^* \left( 1 + Q^* \tan^2\beta \right) \right)}
$$
where \(u_f\) and \(S_f\) are geometric parameters, and \(L^*\), \(M^*\), \(P^*\), and \(Q^*\) are coefficients. For the double-tooth contact region, the gear body stiffness is corrected using the method by Xie et al. The combined stiffness of two teeth in the double-tooth region is
$$
k_{double} = \frac{1}{\frac{1}{k_{c1}} + \frac{1}{k_{c2}}}
$$
where \(k_{c1}\) and \(k_{c2}\) are the corrected single-tooth mesh stiffnesses. The TVMS of the helical gear is
$$
k_h = \sum_{i=1}^{n} k_{si}
$$
where \(k_{si}\) is the stiffness of the \(i\)-th slice. Because the slice method neglects the axial deformation, a correction factor is applied:
$$
k_h = k_h^0 \cos^2\beta
$$
where \(k_h^0\) is the uncorrected stiffness. The TVMS of a standard miter gear is twice the TVMS of a single helical gear:
$$
K_h = 2 k_h
$$
The eccentric load coefficient \(\eta\) is defined as the ratio of the maximum normal force per unit length on the high-load side of the miter gear to the average normal force per unit length of the standard miter gear. For a miter gear with centring error, the load sharing can be divided into two stages. In the first stage, only one side of the helical teeth is in contact. The eccentric load coefficient is
$$
\eta = 2 \quad \text{for } 0 < \varepsilon_1 < \delta_{ce}, \ \varepsilon_2 = 0
$$
In the second stage, both sides are in contact. The eccentric load coefficient is
$$
\eta = \frac{F_n + F_{ce}}{F_n} \quad \text{for } \varepsilon_1 > \delta_{ce}, \ \varepsilon_2 > 0
$$
where \(F_n\) is the normal force on one side of the standard miter gear, and \(F_{ce}\) is the additional normal force caused by the centring error. The additional force is calculated as
$$
F_{ce} = k_h \delta_{ce} \cos\alpha_n \cos\beta
$$
where \(\alpha_n\) is the normal pressure angle. The normal force \(F_n\) is related to the input torque \(T\) by
$$
F_n = \frac{T}{r_i \cos\alpha_n \cos\beta}
$$
where \(r_i\) is the radius of the contact point. For the angular misalignment error, the calculation is more complex. I divided the helical gear into slices along the face width. The deformation of each slice due to the angular misalignment is calculated. The normal force on each slice is the product of the slice stiffness and the slice deformation. The total force on the high-load side is obtained by summing the slice forces. The eccentric load coefficient is then calculated as
$$
\eta = \frac{F_{fn,max}}{F_{na}}
$$
where \(F_{fn,max}\) is the maximum normal force per unit length on the high-load side, and \(F_{na}\) is the average normal force per unit length of the standard miter gear. Table 6 compares the eccentric load coefficient calculated by the analytical method with that obtained by the finite element method. The maximum difference is less than \(4\%\), which verifies the accuracy of the analytical method.
| Error type | Error value (\(\mu\)m) | Analytical \(\eta\) | Finite element \(\eta\) | Difference (%) |
|---|---|---|---|---|
| Centring error | 5 | 1.16 | 1.15 | 0.9 |
| Centring error | 10 | 1.34 | 1.31 | 2.3 |
| Centring error | 15 | 1.50 | 1.47 | 2.0 |
| \(\Delta f_{x-z}\) | 10 | 1.28 | 1.25 | 2.4 |
| \(\Delta f_{x-z}\) | 20 | 1.56 | 1.52 | 2.6 |
| \(\Delta f_{y-z}\) | 10 | 1.22 | 1.20 | 1.7 |
| \(\Delta f_{y-z}\) | 20 | 1.48 | 1.45 | 2.1 |
Effects of Torque and Undercut Groove Width on Eccentric Load Coefficient
The eccentric load coefficient of a miter gear with errors depends not only on the error magnitude but also on the input torque and the undercut groove width. I studied these effects using the analytical model. For a miter gear with centring error, the eccentric load coefficient shows a plateau at low torque. In this plateau region, only one side of the helical teeth is in contact, so the eccentric load coefficient is \(2\). As the torque increases, the second side comes into contact, and the eccentric load coefficient decreases rapidly. With a further increase in torque, the eccentric load coefficient approaches \(1\), meaning that the load becomes more evenly shared. The larger the centring error, the longer the plateau region. The relationship between the eccentric load coefficient and the input torque can be expressed as
$$
\eta =
\begin{cases}
2, & 0 < \varepsilon_1 < \delta_{ce}, \ \varepsilon_2 = 0 \\
\displaystyle \frac{T}{T + T_{ce}}, & \varepsilon_1 > \delta_{ce}, \ \varepsilon_2 > 0
\end{cases}
$$
where \(T_{ce}\) is the additional torque caused by the centring error. For the angular misalignment error, a similar trend is observed. The eccentric load coefficient is high at low torque, then decreases as the torque increases, and finally approaches \(1\). The effect of the undercut groove width \(L_{an}\) is different for the two types of angular misalignment. For \(\Delta f_{x-z}\), the eccentric load coefficient increases as the undercut groove width increases. This is because a wider undercut groove increases the deformation difference between the two sides. For \(\Delta f_{y-z}\), the eccentric load coefficient decreases as the undercut groove width increases. This is because a wider undercut groove reduces the projection of the misalignment on the normal force direction. Table 7 summarizes the effects of torque and undercut groove width on the eccentric load coefficient.
| Parameter | Condition | Trend of eccentric load coefficient \(\eta\) |
|---|---|---|
| Input torque | Low torque, one side contact | Plateau at \(\eta=2\) |
| Input torque | Increasing torque, two sides contact | Rapid decrease, then approaches 1 |
| Undercut groove width | \(\Delta f_{x-z}\) error | Increases with \(L_{an}\) |
| Undercut groove width | \(\Delta f_{y-z}\) error | Decreases with \(L_{an}\) |
Discussion
The results of my research show that a miter gear with errors experiences significant load sharing problems. The centring error is the most detrimental error for the contact fatigue life of a miter gear. When the centring error is \(10\,\mu\text{m}\), the life drops to \(13.5\%\) of the standard miter gear. The angular misalignment errors also reduce the life, but their effect is less severe than that of the centring error for the same error magnitude. The tip relief is an effective method to improve the life of a miter gear with errors. A moderate tip relief of \(5\,\mu\text{m}\) or \(10\,\mu\text{m}\) eliminates the stress concentration at the addendum and dedendum, and increases the minimum life by about \(40\%\) to \(50\%\). An excessive tip relief of \(20\,\mu\text{m}\) creates new stress concentrations and should be avoided. The angular adjustment is also an effective method. By tilting the driven miter gear axis to compensate for the centring error, the load sharing becomes more uniform and the life increases significantly. The \(y-z\) angular adjustment is more effective than the \(x-z\) adjustment for a miter gear with centring error.
The analytical method for the eccentric load coefficient provides a fast and accurate way to evaluate the load sharing of a miter gear with errors. The method is based on the time-varying mesh stiffness and the slice method. The difference between the analytical results and the finite element results is less than \(4\%\). This method can be used to predict the contact stress and fatigue life of a miter gear with errors without expensive finite element simulations. The eccentric load coefficient depends on the input torque and the undercut groove width. For a miter gear with centring error, the eccentric load coefficient is \(2\) at low torque and decreases as the torque increases. For a miter gear with \(\Delta f_{x-z}\) angular misalignment, the eccentric load coefficient increases with the undercut groove width. For a miter gear with \(\Delta f_{y-z}\) angular misalignment, the eccentric load coefficient decreases with the undercut groove width. These findings are important for the design and assembly of a miter gear.
Conclusions
I developed a comprehensive method to calculate the contact fatigue life of a miter gear with errors. The method includes finite element contact analysis, critical plane fatigue life prediction, tip relief optimization, angular adjustment, and analytical eccentric load coefficient calculation. The main conclusions are as follows:
1. The standard miter gear has a symmetric contact stress distribution on the left and right helical sides. The maximum stress occurs at the subsurface. The loading path of the miter gear is multiaxial non-proportional, with a phase difference of about \(90^\circ\) between the normal stress and shear stress. Therefore, a multiaxial fatigue criterion such as the Shang-Wang model should be used.
2. The centring error causes uneven load sharing in the miter gear. The high-load side experiences a significant stress increase, and the fatigue life decreases. When the centring error is \(10\,\mu\text{m}\), the life drops to \(13.5\%\) of the standard value. The angular misalignment errors also cause uneven load sharing and reduce the fatigue life. For the same error magnitude, the centring error has the most detrimental effect on the miter gear life.
3. A moderate tip relief of \(5\,\mu\text{m}\) or \(10\,\mu\text{m}\) effectively eliminates the stress concentration at the addendum and dedendum of the miter gear. It increases the minimum contact fatigue life by \(40\%\) to \(50\%\). An excessive tip relief of \(20\,\mu\text{m}\) creates new stress concentrations and reduces the life. Angular adjustment of the driven miter gear axis can compensate for the centring error and increase the life. The \(y-z\) adjustment is more effective than the \(x-z\) adjustment.
4. The analytical method based on the time-varying mesh stiffness and the slice method accurately calculates the eccentric load coefficient of a miter gear with errors. The difference from the finite element results is less than \(4\%\). The eccentric load coefficient depends on the input torque and the undercut groove width. For a miter gear with centring error, the eccentric load coefficient is \(2\) at low torque and decreases as the torque increases. For a miter gear with \(\Delta f_{x-z}\) angular misalignment, the eccentric load coefficient increases with the undercut groove width. For a miter gear with \(\Delta f_{y-z}\) angular misalignment, the eccentric load coefficient decreases with the undercut groove width.
5. The results of this work provide a theoretical basis for the design, manufacturing, and assembly of a miter gear. The proposed methods can be used to predict the contact fatigue life and load sharing of a miter gear with errors. They can also be used to optimize the tip relief and angular adjustment to improve the fatigue performance of a miter gear. Future work should include experimental validation and consideration of residual stress, lubrication, and surface roughness.