
In my research, I focus on the measurement and evaluation of symmetry errors in miter gears, which are also widely known as herringbone gears in many heavy-duty transmission systems. Miter gears possess high load capacity and small axial load, making them suitable for marine power, aerospace, and large industrial equipment. However, the symmetry between the left and right tooth flanks of miter gears directly affects the uniformity of contact load distribution. When the two sides of a miter gear are not perfectly symmetric, the gear transmission may experience vibration, noise, and uneven load, which reduces its service life and reliability. Therefore, I study the measurement and evaluation of miter gears symmetry from the perspective of performance. I define the contact line of miter gears and propose a symmetry error evaluation method based on this contact line. I also develop a measurement principle, design measurement software, and conduct experiments to verify my method. The results demonstrate that my method is feasible and effective for high-precision measurement of miter gears symmetry.
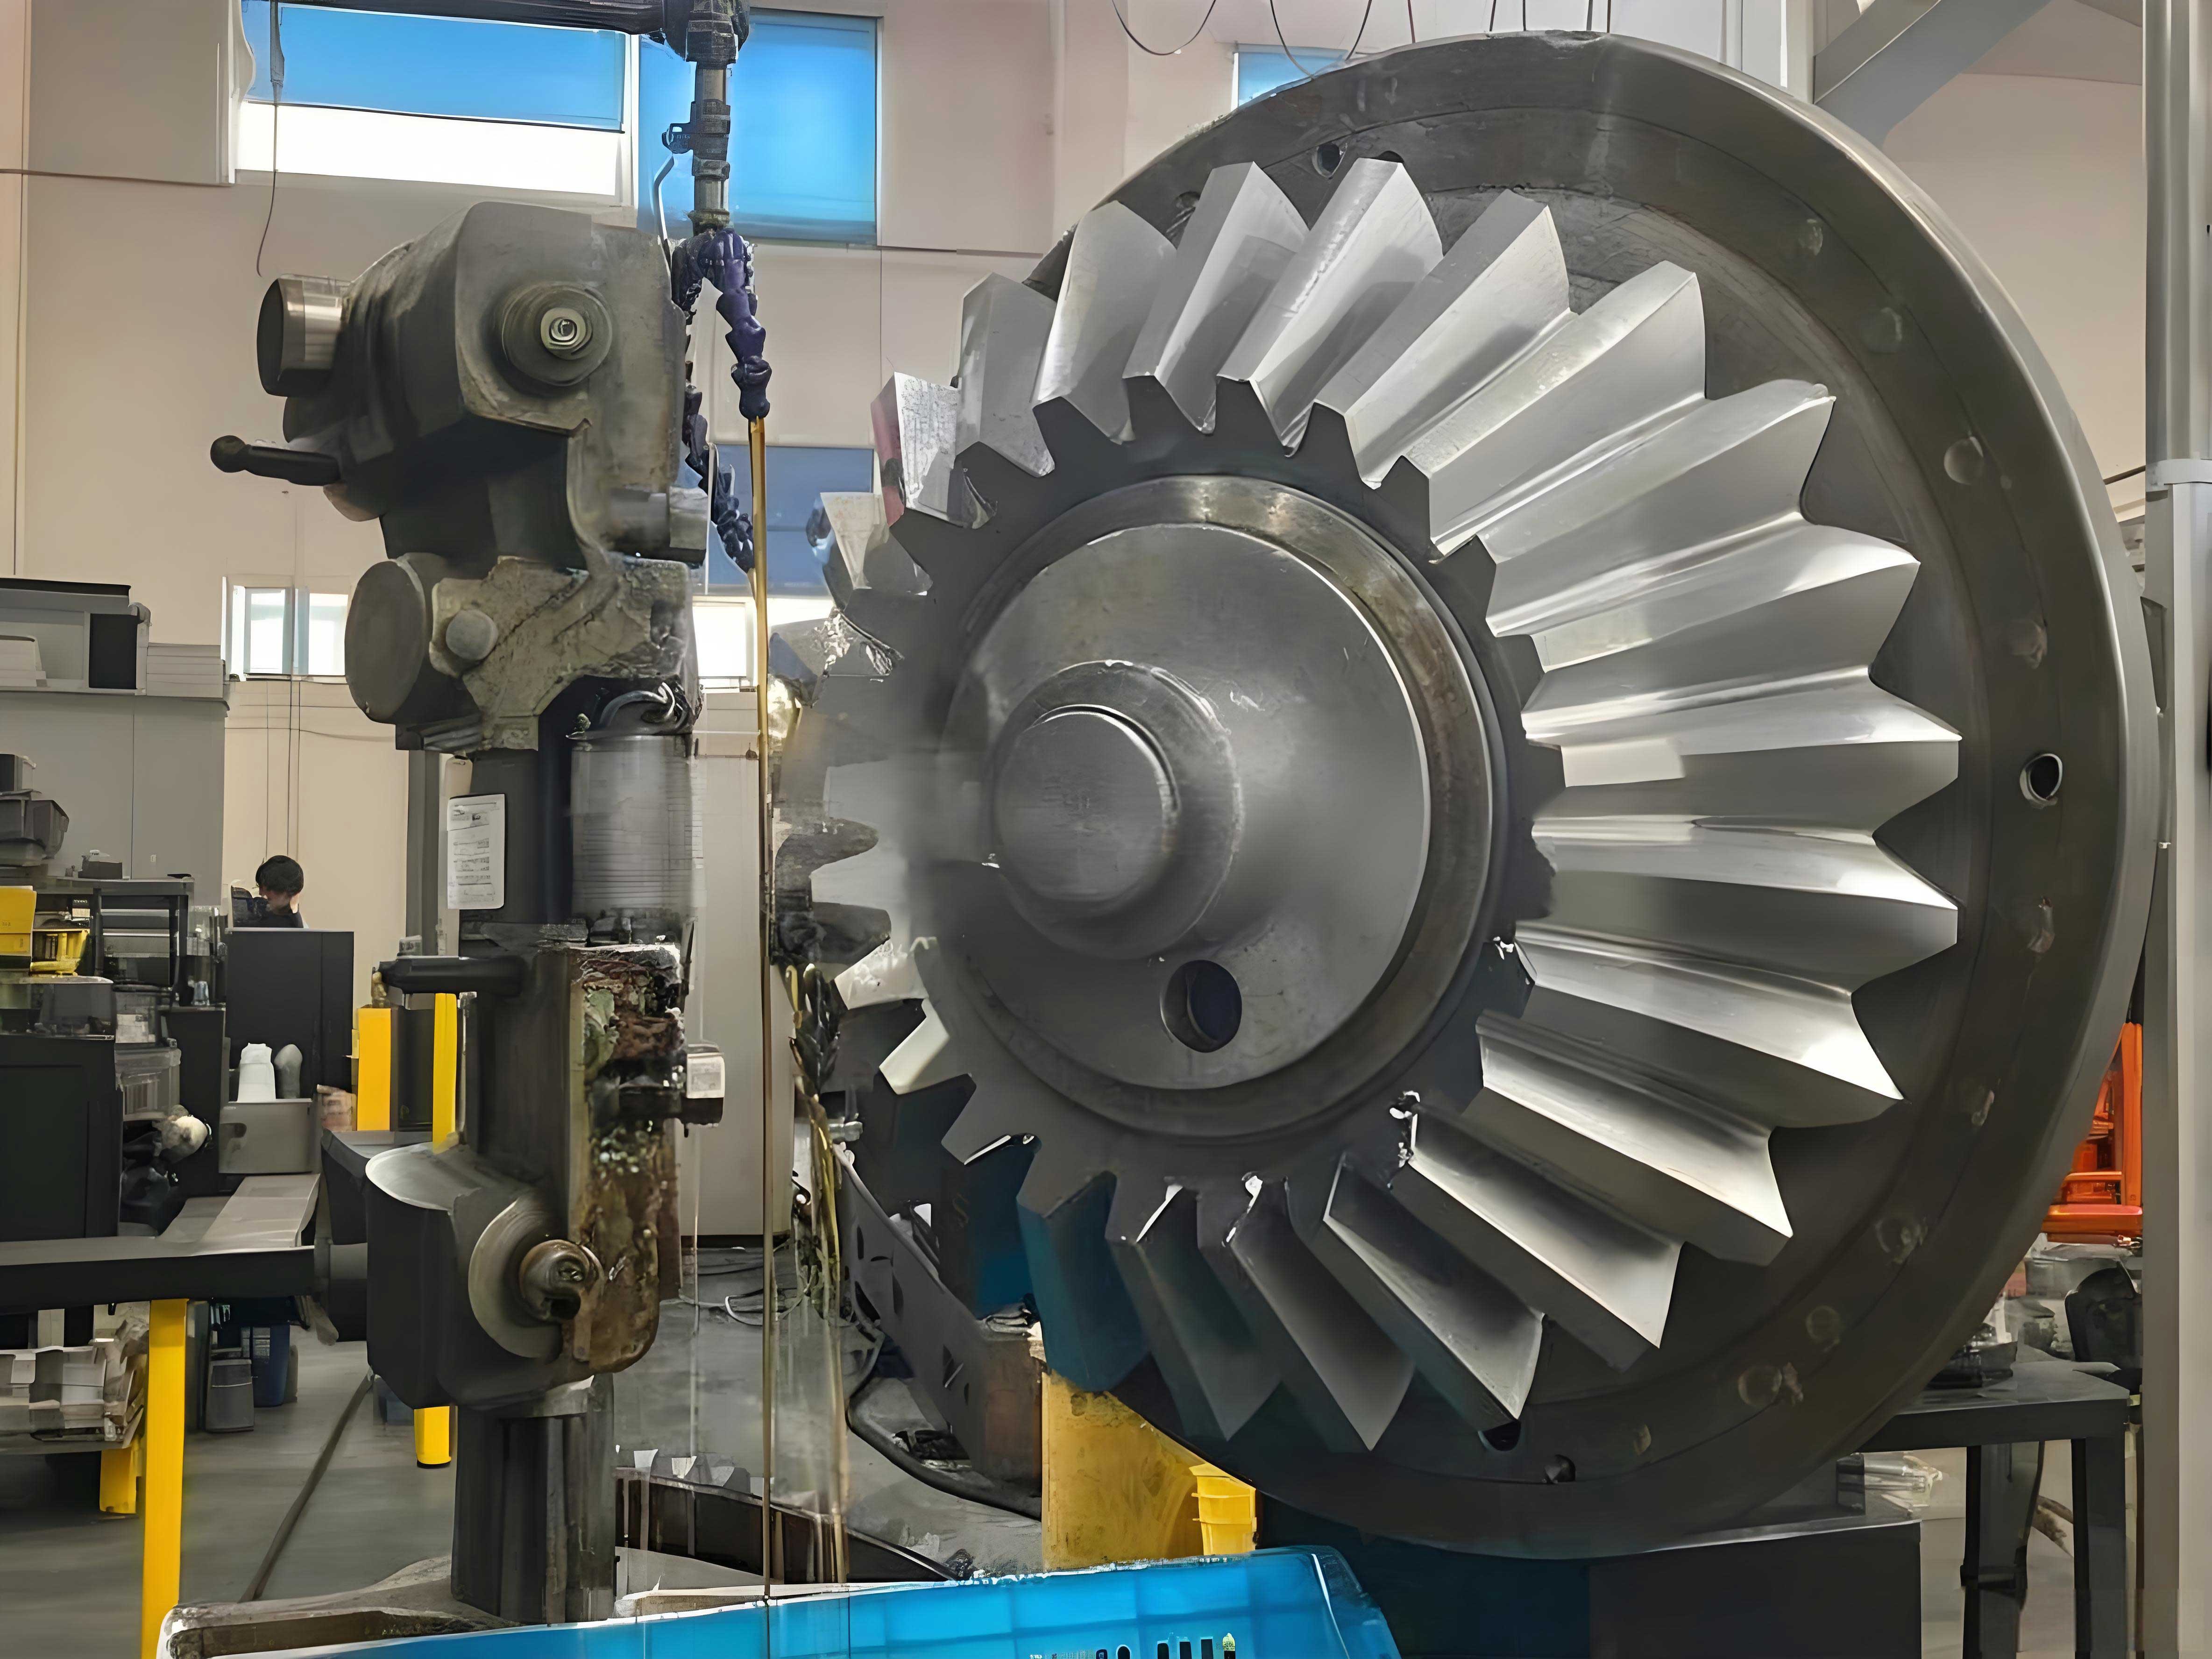
1. Characteristics and Importance of Miter Gears
Miter gears are widely used in applications where two intersecting shafts need to transmit motion at a 90-degree angle. In my study, I extend the concept of miter gears to include double-helical gears, which are often called herringbone gears. These miter gears consist of two opposite-handed helical gear sections rigidly connected. Because the axial forces generated by the two sections are nearly equal and opposite, the net axial force on the supporting bearings is greatly reduced. This is a key advantage of miter gears over single-helical gears. Nevertheless, manufacturing errors can cause the left and right tooth flanks of miter gears to be asymmetric. This asymmetry leads to axial vibration, uneven contact load, and premature failure. Thus, accurate measurement and evaluation of miter gears symmetry are essential for ensuring their performance.
I classify miter gears into four types based on their manufacturing and application characteristics: no-groove miter gears, split miter gears, staggered miter gears, and positive-negative miter gears. Among them, split miter gears are the most common in high-speed and high-precision applications because they require a relief groove for machining. In my research, I primarily investigate split miter gears. To avoid ambiguity in describing the tooth flanks, I name the concave and convex flanks as inner and outer flanks, respectively. This naming convention helps me to clearly define the measurement and evaluation procedure for miter gears.
2. Definition of Contact Line and Symmetry Error for Miter Gears
The contact line of a miter gear is the instantaneous contact trace of two meshing tooth flanks under ideal, non-deformed conditions. For a helical gear, the contact line is a straight line located in the tangent plane of the base cylinder and inclined at the base helix angle. Since miter gears can be considered as two helical gear sections with equal but opposite helix angles, the contact line definition of helical gears also applies to miter gears. I define the contact line of miter gears as the intersection of the tooth flank with the tangent plane of the base cylinder. The contact line reflects the meshing state of miter gears and is therefore a suitable basis for evaluating symmetry errors.
In my definition, the symmetry error of miter gears is the axial distance between the intersection point of the two opposite-handed contact lines and the symmetry center plane of the gear. For a single tooth, I denote this error as \(f_{Ai}\), where \(i\) is the tooth number. If the intersection point deviates from the symmetry center plane along the axial direction, the symmetry error is positive or negative depending on the direction. I also define the difference between adjacent teeth symmetry errors as \(f_{Au}\), the total symmetry error as \(F_A\), and the mean symmetry error as \(f_{As}\). These definitions are summarized in Table 1.
| Symbol | Description | Formula |
|---|---|---|
| \(f_{Ai}\) | Symmetry error of a single tooth | \(f_{Ai} = Z_i\) |
| \(f_{Au}\) | Difference between adjacent teeth symmetry errors | \(f_{Au} = \max |f_{Ai+1} – f_{Ai}|\) |
| \(F_A\) | Total symmetry error | \(F_A = \max f_{Ai} – \min f_{Ai}\) |
| \(f_{As}\) | Mean symmetry error | \(f_{As} = \frac{1}{z} \sum_{i=1}^{z} f_{Ai}\) |
These definitions allow me to quantify the symmetry of miter gears in a way that directly relates to their transmission performance. The contact line intersection point is the key geometric feature, and its axial deviation from the symmetry plane is the fundamental error.
3. Theoretical Evaluation Method Based on Contact Line
To evaluate the symmetry error of miter gears, I establish a mathematical model of the contact line in a Cartesian coordinate system. I set the tangent plane of the base cylinder as the \(T’RZ’\) plane. The left-handed contact line and right-handed contact line are expressed as linear functions. Let the left-handed contact line be:
$$Z’ = k_L \times T’ + b_L$$
And the right-handed contact line be:
$$Z’ = k_R \times T’ + b_R$$
where \(k_L\) and \(k_R\) are the slopes, and \(b_L\) and \(b_R\) are the intercepts. The slopes are determined by the base helix angle \(\beta_b\):
$$k_L = \tan(90^\circ – \beta_b)$$
$$k_R = -\tan(90^\circ – \beta_b)$$
The base helix angle is calculated from the normal pressure angle \(\alpha_n\) and the reference helix angle \(\beta\):
$$\beta_b = \tan^{-1} \left\{ \tan\beta \times \cos \left[ \tan^{-1} \left( \frac{\tan\alpha_n}{\cos\beta} \right) \right] \right\}$$
I select the evaluation interval of the contact line within \(\pm 0.3B\) from the centerline of the single-side tooth width, where \(B\) is the single-side tooth width. This interval avoids the tooth modification region and ensures that the measured contact line represents the effective meshing area. I then extract theoretical measurement points along the contact line at equal intervals. For the left-handed tooth, I denote the theoretical points as \(P_{Lj}\) (\(j=1,2,\ldots,n\)), and for the right-handed tooth as \(P_{Rj}\). To simulate actual measurement points, I add a random error \(\delta_n\) perpendicular to the theoretical contact line. The actual points are denoted as \(G_{Lj}\) and \(G_{Rj}\).
I use the least squares method to fit the theoretical and actual measurement points. For the left-handed contact line, the objective function is:
$$\varphi(b_L, k_L) = \sum_{j=1}^{n} \left[ Z_j – (b_L + k_L T_j) \right]^2$$
By taking partial derivatives with respect to \(b_L\) and \(k_L\) and setting them to zero, I obtain:
$$b_L = \frac{\sum T_j^2 \sum Z_j – \sum T_j \sum T_j Z_j}{n \sum T_j^2 – (\sum T_j)^2}$$
$$k_L = \frac{n \sum T_j Z_j – \sum T_j \sum Z_j}{n \sum T_j^2 – (\sum T_j)^2}$$
Similarly, I obtain \(b_R\) and \(k_R\) for the right-handed contact line. After fitting, I extend the two contact lines to their intersection point \(A(T, Z)\). The symmetry error of the miter gear tooth is then:
$$f_A = \Delta T_h = Z$$
I apply the same procedure to the actual measurement points to obtain the actual contact lines and their intersection point. The actual symmetry error is then calculated. This method allows me to evaluate the symmetry error of each tooth of the miter gears.
4. Validation with a Numerical Example
To verify my theoretical evaluation method, I use a real miter gear with the basic parameters listed in Table 2. The gear has 27 teeth, a normal module of 2.2 mm, a normal pressure angle of 22°, a helix angle of 30°, a single-side tooth width of 30 mm, and a relief groove width of 20 mm. I select two teeth with a circumferential angle of 120° (tooth 1 and tooth 10) and generate 41 theoretical measurement points on each contact line. I add random errors to simulate actual measurement points. The simulation data are partially shown in Table 3.
| Parameter | Value |
|---|---|
| Normal module \(m_n\) | 2.2 mm |
| Number of teeth \(z\) | 27 |
| Normal pressure angle \(\alpha_n\) | 22° |
| Helix angle \(\beta\) | 30° |
| Single-side tooth width \(B\) | 30 mm |
| Relief groove width \(b_t\) | 20 mm |
| Point index | Theoretical \(T_j\) (mm) | Theoretical \(Z_j\) (mm) | Random error \(\delta_n\) (mm) | Actual \(T_j\) (mm) | Actual \(Z_j\) (mm) |
|---|---|---|---|---|---|
| 1 | 3.1250 | 16.0000 | 0.0147 | 3.1514 | 16.0063 |
| 2 | 3.3537 | 16.4390 | 0.0112 | 3.3769 | 16.4423 |
| 3 | 3.5824 | 16.8781 | 0.0124 | 3.6066 | 16.8823 |
| … | … | … | … | … | … |
After fitting the theoretical points, I find that the theoretical symmetry error is zero, as expected. For the actual points, I obtain the symmetry errors of tooth 1 and tooth 10 as \(-0.0275\) mm and \(-0.0256\) mm, respectively. These values are very close to the results obtained by the cross-section method, which are \(-0.0278\) mm and \(-0.0258\) mm. This agreement confirms that my contact-line-based evaluation method is correct and feasible for miter gears. The numerical example demonstrates that my method can accurately capture the symmetry error of miter gears.
5. Measurement Principle for Miter Gears Contact Line
To measure the contact line of miter gears, I apply the evaluation coordinate system to a CNC gear measuring center. I mount the miter gear on the measuring machine and align its axis with the rotary table. The measuring head moves along three axes: \(R\), \(T\), and \(Z\). The \(Z\)-axis is parallel to the gear axis, the \(R\)-axis is along the radial direction, and the \(T\)-axis is along the tangential direction. The rotary axis is denoted as \(\theta\). The coordinate system is illustrated in my measurement setup. I first establish the axial measurement reference. I measure the upper and lower end faces of the miter gear to determine their axial coordinates \(Z_1\) and \(Z_2\). The symmetry center plane is then located at:
$$Z_{\text{mid}} = \frac{Z_1 + Z_2}{2}$$
I set this plane as the zero reference for the \(Z\)-axis. Then, I measure the contact lines on each tooth of the miter gears. For a single tooth, I measure two opposite-handed contact lines by moving the probe along the \(T\)-axis and \(Z\)-axis simultaneously. The measurement is performed within the evaluation interval, which is \([0.5b_t + 0.2B, 0.5b_t + 0.8B]\) for the upper side and \([-0.5b_t – 0.8B, -0.5b_t – 0.2B]\) for the lower side. The probe follows the contact line, and the measuring machine records the coordinates. I repeat this process for all teeth on both sides of the miter gears. The measurement principle is based on the fact that the contact line is a straight line in the tangent plane of the base cylinder. By measuring the actual coordinates, I can fit the contact lines and calculate the intersection point.
6. Design of Measurement Software
I design the measurement software for the CNC gear measuring center using C++. The software architecture consists of three main modules: parameter input, measurement motion control, and data processing. I use library functions to control the motors, read the probe status, and acquire data. The key functions include:
| Function | Description |
|---|---|
| StartLampOn / EndLampOn | Detect the state of start and end buttons |
| IsStartHit / IsEndHit | Check if start or end button is pressed |
| motordrv | Control motor movement with given frequency and target positions |
| is_motor_stop | Check if the motor has stopped |
| TouchProbe | Drive the probe to touch the workpiece |
| sample11 | Record the sampling point values |
| counterwrite / counterste | Set the counter and coordinate system |
I establish the axial measurement reference by first calibrating the probe. I move the probe to touch the upper end face of the miter gear and record \(Z_{\text{up}}\). Then I move the probe to touch the lower end face and record \(Z_{\text{down}}\). The symmetry center plane is calculated as \(Z_{\text{mid}} = (Z_{\text{up}} + Z_{\text{down}})/2\). I set the current \(Z\)-coordinate to \(-D_{\text{is}}\) where \(D_{\text{is}} = Z_{\text{point}} – Z_{\text{mid}}\). Then I move the probe to the middle of the upper tooth width and start the measurement. The motion control program drives the probe along the contact line from the start position to the end position. The start and end positions are given in Table 4.
| Gear side | Start \(Z\)-coordinate | End \(Z\)-coordinate |
|---|---|---|
| Upper side | \(0.5b_t + 0.2B\) | \(0.5b_t + 0.8B\) |
| Lower side | \(-0.5b_t – 0.8B\) | \(-0.5b_t – 0.2B\) |
After the measurement, the data processing program fits the contact lines using the least squares method. The \(T\)-axis values are converted to \(X_j\) coordinates by:
$$X_j = \sum_{j=1}^{n} P_{Tj} + p$$
where \(p\) is the circular pitch. The \(Z\)-axis values are used as \(Z_j\). Then I fit the left and right contact lines and find their intersection point. The symmetry error is the \(Z\)-coordinate of the intersection point. I plot the symmetry error curve for all teeth. The software has been successfully applied on the CNC gear measuring center, and the measurement results are reliable.
7. Experimental Verification and Comparison
I conduct experiments on two miter gears: a small-module gear and a large-module gear. The parameters are listed in Table 5. I measure the contact lines on the inner flanks of all teeth. The measurement interval is \([16, 34]\) mm for the small-module gear and \([19, 48]\) mm for the large-module gear. The measurement results are shown in Table 6. For the small-module gear, the single tooth symmetry error \(f_{Ai}\) ranges from \(-0.0201\) mm to \(-0.0002\) mm. The total symmetry error \(F_A\) is \(0.0199\) mm, the adjacent difference \(f_{Au}\) is \(0.0101\) mm, and the mean symmetry error \(f_{As}\) is \(-0.0113\) mm. For the large-module gear, \(f_{Ai}\) ranges from \(-0.0322\) mm to \(-0.0245\) mm, \(F_A = 0.0077\) mm, \(f_{Au} = 0.0056\) mm, and \(f_{As} = -0.0281\) mm.
| Parameter | Small-module gear | Large-module gear |
|---|---|---|
| Normal module \(m_n\) | 2.2 mm | 3.9 mm |
| Number of teeth \(z\) | 27 | 27 |
| Normal pressure angle \(\alpha_n\) | 22° | 22° |
| Helix angle \(\beta\) | 30° | 30° |
| Single-side tooth width \(B\) | 30 mm | 47 mm |
| Relief groove width \(b_t\) | 20 mm | 20 mm |
| Error item | Small-module gear (contact line) | Small-module gear (cross-section) | Large-module gear (contact line) | Large-module gear (cross-section) |
|---|---|---|---|---|
| \(f_{Ai}\) (mm) | \(-0.0201 \sim -0.0002\) | \(-0.0309 \sim -0.0020\) | \(-0.0322 \sim -0.0235\) | \(-0.0369 \sim -0.0271\) |
| \(f_{Au}\) (mm) | 0.0101 | 0.0215 | 0.0056 | 0.0101 |
| \(F_A\) (mm) | 0.0199 | 0.0228 | 0.0087 | 0.0098 |
| \(f_{As}\) (mm) | \(-0.0113\) | \(-0.0243\) | \(-0.0281\) | \(-0.0301\) |
| Measurement time (min) | 105 | 10 | 105 | 10 |
I also compare my contact line method with the cross-section method for rapid measurement of miter gears symmetry. The cross-section method measures points on the intersection of the tooth flank with the pitch cylinder. Although the cross-section method meets the definition of symmetry error, its measurement accuracy is lower and the data are less stable than my contact line method. For the small-module gear, the difference in \(f_{Ai}\) between the two methods is about 10 μm, and for the large-module gear, it is about 5 μm. The measurement time of my contact line method is about 10 times longer than that of the cross-section method. Therefore, my contact line method provides higher accuracy, while the cross-section method is more efficient. For high-precision measurement of miter gears, my contact line method is recommended.
I also perform a verification experiment by changing the clamping orientation. I mount the miter gear with the left-handed side up and repeat the measurement. The results are consistent with the previous results. For the small-module gear, the symmetry error of tooth 15 is found to be anomalous, which is likely due to a trial grinding process on that tooth. This anomaly is confirmed by repeated measurements. I also analyze the measurement uncertainty. I repeat the measurement five times for each gear. The standard uncertainty \(u\) and expanded uncertainty \(U\) (with a coverage factor of 2, corresponding to a 95% confidence level) are calculated. The results are shown in Table 7.
| Error item | Standard uncertainty \(u\) (mm) | Expanded uncertainty \(U\) (mm) |
|---|---|---|
| \(f_{Au}\) | 0.0007 | 0.0014 |
| \(F_A\) | 0.0012 | 0.0024 |
| \(f_{As}\) | 0.0003 | 0.0006 |
For individual teeth, the uncertainty is also analyzed. The results for the small-module gear and large-module gear are given in Table 8 and Table 9, respectively. The uncertainty is small, demonstrating the high reliability of my measurement method for miter gears.
| Tooth number | Mean \(f_{Ai}\) (mm) | Standard uncertainty \(u\) (mm) | Expanded uncertainty \(U\) (mm) |
|---|---|---|---|
| 1 | \(-0.0098\) | 0.0002 | 0.0004 |
| 2 | \(-0.0108\) | 0.0007 | 0.0014 |
| 3 | \(-0.0111\) | 0.0003 | 0.0006 |
| … | … | … | … |
| 15 | \(-0.0003\) | 0.0002 | 0.0004 |
| Tooth number | Mean \(f_{Ai}\) (mm) | Standard uncertainty \(u\) (mm) | Expanded uncertainty \(U\) (mm) |
|---|---|---|---|
| 1 | \(-0.0246\) | 0.0015 | 0.0030 |
| 2 | \(-0.0277\) | 0.0011 | 0.0022 |
| 3 | \(-0.0287\) | 0.0009 | 0.0018 |
| … | … | … | … |
| 15 | \(-0.0281\) | 0.0011 | 0.0022 |
8. Discussion
My research provides a comprehensive method for measuring and evaluating the symmetry error of miter gears. The key innovation is the use of the contact line as the measurement object. The contact line reflects the actual meshing state of miter gears, and its intersection point with the symmetry plane directly indicates the symmetry error. By using the least squares method to fit the measured points, I can accurately determine the contact lines and their intersection. The experimental results show that my method has higher accuracy than the traditional cross-section method. The measurement uncertainty is also low, which confirms the reliability of my method.
In my study, I also find that the symmetry error of miter gears can be affected by manufacturing processes. For example, tooth 15 of the small-module gear shows an abnormal symmetry error, which is likely due to a trial grinding process. This finding highlights the importance of controlling the manufacturing process to ensure the symmetry of miter gears. My method can be used for quality inspection and process optimization of miter gears.
Furthermore, I compare the measurement efficiency of the contact line method and the cross-section method. The contact line method takes about 105 minutes for a complete gear, while the cross-section method takes only 10 minutes. However, the contact line method provides much higher accuracy. Therefore, the choice of method depends on the specific requirements. For high-precision applications, the contact line method is preferred. For rapid inspection, the cross-section method can be used as a preliminary check.
9. Conclusion
In my research, I have developed a measurement and evaluation method for the symmetry error of miter gears based on the contact line. I defined the contact line of miter gears and established its mathematical model. I proposed a symmetry error evaluation method using the least squares principle. I designed a measurement principle and developed measurement software for a CNC gear measuring center. I conducted experiments on two miter gears and compared my method with the cross-section method. The results show that my method is accurate, reliable, and suitable for high-precision measurement of miter gears symmetry. The measurement uncertainty is low, and the method can be used for quality control and process improvement of miter gears.
My future work will focus on optimizing the measurement software to make it more user-friendly and integrating the error evaluation method into the software. I will also investigate the relationship between the contact line symmetry error and the dynamic behavior of miter gears, such as axial vibration and noise. I believe that my research will contribute to the design and manufacturing of high-performance miter gears.
Nomenclature
| Symbol | Description |
|---|---|
| \(\beta_b\) | Base helix angle |
| \(r_b\) | Base cylinder radius |
| \(A\) | Intersection point of contact lines |
| \(i\) | Tooth number |
| \(f_{Ai}\) | Symmetry error of a single tooth |
| \(f_{Au}\) | Difference between adjacent teeth symmetry errors |
| \(F_A\) | Total symmetry error |
| \(f_{As}\) | Mean symmetry error |
| \(B\) | Single-side tooth width |
| \(b_t\) | Relief groove width |
| \(S_{Tat}\) | Projection of tip circle tooth thickness on base tangent plane |
| \(S_{Tbt}\) | Projection of base circle tooth thickness on base tangent plane |
| \(E_{Tbt}\) | Projection of base circle tooth space on base tangent plane |
| \(P_{Lj}\) | Theoretical measurement point on left-handed tooth |
| \(P_{Rj}\) | Theoretical measurement point on right-handed tooth |
| \(n\) | Number of measurement points |
| \(G_{Lj}\) | Actual measurement point on left-handed tooth |
| \(G_{Rj}\) | Actual measurement point on right-handed tooth |
| \(m_n\) | Normal module |
| \(\alpha_n\) | Normal pressure angle |
| \(z\) | Number of teeth |
| \(\beta\) | Reference helix angle |
These symbols and definitions are used throughout my research on miter gears. The contact line method I have developed provides a robust and accurate way to evaluate the symmetry error of miter gears. I hope that my work will be useful for engineers and researchers working with miter gears in various applications.