
The precise and reliable operation of industrial robots and high-precision machinery is fundamentally dependent on the performance of their core drive components. Among these, the rotary vector reducer stands out due to its compact structure, high reduction ratio, significant load-bearing capacity, and excellent torsional rigidity. The heart of this transmission system is the cycloid-pin gear mechanism, where the meshing performance between the cycloidal gear and the pin teeth directly determines the overall efficiency, positioning accuracy, and service life of the rotary vector reducer.
To compensate for manufacturing errors, facilitate assembly, and optimize load distribution, the theoretical tooth profile of the cycloidal gear must be deliberately altered—a process known as tooth profile modification. Extensive research has been conducted on how different modification methods, such as equidistant modification, radial moving modification, and their combinations (including the anti-bow profile), affect the transmission error, load-sharing characteristics, and mechanical stress state. However, a critical aspect that has received comparatively less attention is the impact of these profile modifications on the lubrication performance within the gear pair. The modification alters the local contact geometry and load distribution, which in turn directly influences the formation and stability of the lubricant film, the frictional power losses, and the operating temperature. Therefore, a comprehensive analysis of the lubrication performance under various tooth profile modification schemes is essential for the holistic design of a high-performance rotary vector reducer.
This article focuses on establishing a thermal elastohydrodynamic lubrication (TEHL) model for the line contact between the modified cycloidal gear and the pin teeth in a rotary vector reducer, considering the non-Newtonian behavior and piezoviscous-thermoviscous properties of the grease lubricant. The goal is to analyze how different modification methods and amounts affect key lubrication parameters, providing a new perspective for designing modifications that balance mechanical and tribological performance.
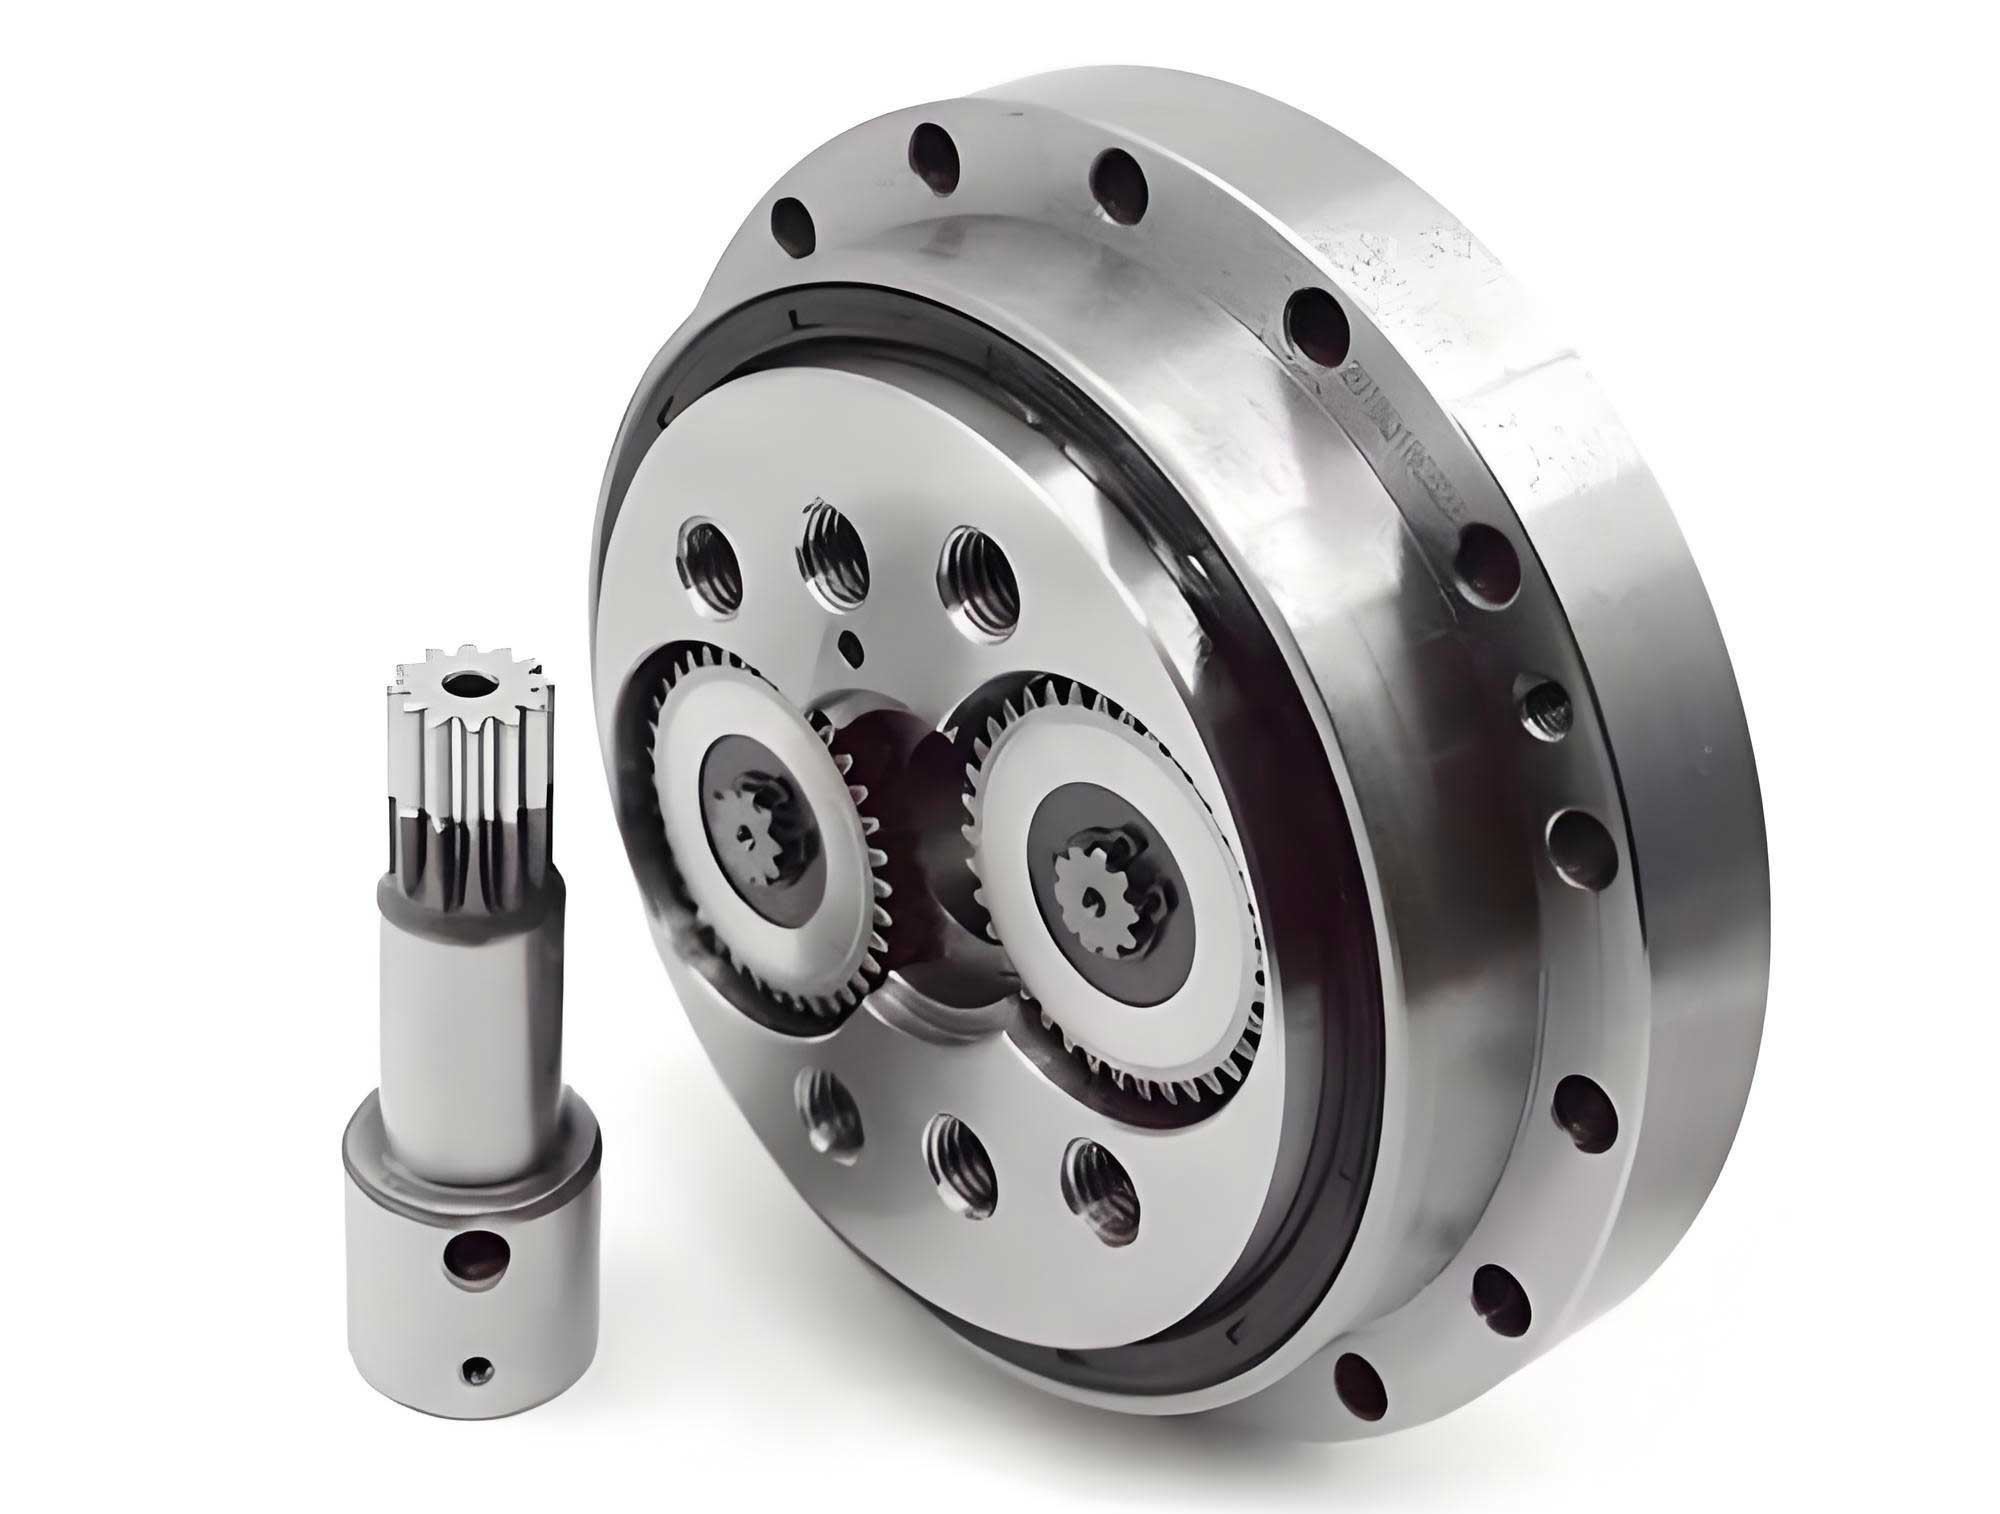
Theoretical Foundation of the Cycloid-Pin Gear Pair
The geometric and force interaction between the cycloidal gear and the pin wheel is complex. The theoretical tooth profile of the cycloidal gear, generated by the hypocycloid principle, is defined by parameters including the pin wheel center circle radius $$r_p$$, the pin radius $$r_{rp}$$, the eccentricity $$a$$, the number of pins $$z_p$$, and the number of cycloid gear teeth $$z_c$$. The short width coefficient $$K_1$$ is a key parameter given by:
$$
K_1 = \frac{a z_p}{r_p}
$$
A typical theoretical profile equation in the rotary vector reducer coordinate system can be expressed as:
$$
\begin{aligned}
x &= (r_p – r_{rp}) \sin(\psi) – a \sin(z_p \psi) \\
y &= (r_p – r_{rp}) \cos(\psi) – a \cos(z_p \psi)
\end{aligned}
$$
where $$\psi$$ is the rotation angle of the crank relative to the pin.
Tooth profile modification introduces a controlled deviation from this theoretical curve. The two primary types are:
- Equidistant Modification (Δrrp): A constant offset applied normal to the theoretical profile, effectively changing the “size” of the cycloidal gear.
- Radial Moving Modification (Δrp): A shift of the entire generating circle in the radial direction, altering the “position” of the tooth profile relative to the center.
These can be applied positively or negatively and in combination. Another sophisticated method is the anti-bow modification, which aims to create an optimal concave-convex contact pattern across the full engagement arc rather than at a single point.
After modification, an initial clearance $$\Delta(\phi_i)$$ exists at each potential contact point $$i$$ before loading. Under an output torque $$T_1$$, the system deforms until multiple teeth share the load. The force on the $$i$$-th tooth, $$F_i$$, is proportional to its relative elastic approach, accounting for this initial clearance:
$$
F_i = \frac{\delta_i – \Delta(\phi_i)}{\delta_{max}} F_{max}
$$
where $$\delta_i$$ is the elastic deformation at point $$i$$, $$\delta_{max}$$ is the maximum deformation among all contacting teeth, and $$F_{max}$$ is the maximum tooth load. The load distribution and the position $$\psi_{max}$$ where $$F_{max}$$ occurs are solved iteratively based on force and moment equilibrium conditions, considering the stiffness of the teeth and pins. This maximum load position is critical as it represents the most severe contact condition for lubrication analysis in the rotary vector reducer.
The kinematics at the point of maximum load are essential for lubrication modeling. The entrainment velocity $$u_r$$, which drags the grease into the contact, and the equivalent radius of curvature $$R$$, which defines the contact geometry, must be calculated. The entrainment velocity is the average of the surface velocities of the cycloid gear and the pin at the contact point. The equivalent radius for the external contact between the convex pin and the (typically concave) cycloid tooth flank is given by:
$$
R = \frac{\xi r_{rp}}{\xi – r_{rp}}
$$
where $$\xi$$ is the radius of curvature of the modified cycloid tooth profile at the contact point, a function of $$\psi_{max}$$ and the modification parameters.
Establishment of the Thermal Elastohydrodynamic Lubrication (TEHL) Model
At the most heavily loaded contact position identified in the force model, a line-contact TEHL model is established. The lubricant is grease, commonly modeled as a non-Newtonian Ostwald fluid. Its rheological behavior is described by the constitutive equation:
$$
\tau = \phi \left( \frac{du}{dz} \right)^n
$$
where $$\tau$$ is the shear stress, $$\phi$$ is the plastic viscosity, $$du/dz$$ is the shear rate across the film, and $$n$$ is the flow index ($$n < 1$$ for shear-thinning behavior). The viscosity $$\phi$$ is highly dependent on pressure $$p$$ and temperature $$T$$:
$$
\phi = \phi_0 \exp\left\{ (\ln(\eta_0) + 9.67) \left[ (1 + 1.98 \times 10^{-8} p)^{z_0} – 1 \right] \left( \frac{T – 138}{T_0 – 138} \right)^{-s} \right\}
$$
Here, $$\phi_0$$ and $$T_0$$ are the ambient viscosity and temperature, $$z_0 = \alpha / [5.1 \times 10^{-9}(\ln(\eta_0)+9.67)]$$, $$s = \beta (T_0 – 138)/\ln(\eta_0+9.67)$$, with $$\alpha$$ and $$\beta$$ being the pressure-viscosity and temperature-viscosity coefficients, respectively.
The governing modified Reynolds equation for the steady-state, line-contact grease lubrication is:
$$
\frac{n}{2n+1}\left(\frac{1}{2}\right)^{\frac{n+1}{n}}\left\{ \frac{\partial}{\partial x}\left[ \rho h^{\frac{2n+1}{n}} \left( \frac{1}{\phi}\frac{\partial p}{\partial x} \right)^{\frac{1}{n}} \right] \right\} = u_r \frac{\partial (\rho h)}{\partial x}
$$
The film thickness equation, accounting for the geometry, elastic deformation, and rigid body displacement, is:
$$
h(x) = h_0 + \frac{x^2}{2R} + v_e(x)
$$
where $$h_0$$ is the central rigid film thickness and $$v_e(x)$$ is the total elastic deformation of the two surfaces, calculated using the Boussinesq integral:
$$
v_e(x) = -\frac{4}{\pi E’} \int_{x_{in}}^{x_{out}} p(s) \ln|x-s| \, ds
$$
Here, $$E’$$ is the equivalent elastic modulus: $$1/E’ = (1-\nu_1^2)/E_1 + (1-\nu_2^2)/E_2$$.
The density of grease also varies with pressure and temperature:
$$
\rho = \rho_0 \left[ \frac{1 + 0.6 \times 10^{-9}p}{1 + 1.7 \times 10^{-9}p} – 0.00065 (T – T_0) \right]
$$
The system must satisfy the force balance equation:
$$
F_{max} = \int_{x_{in}}^{x_{out}} p(x) \, dx
$$
The boundary conditions for pressure are $$p(x_{in}) = p(x_{out}) = 0$$.
To account for thermal effects, the energy equation within the grease film is solved:
$$
c \left( \rho u \frac{\partial T}{\partial x} + q \frac{\partial T}{\partial z} \right) = k \frac{\partial^2 T}{\partial z^2} – \frac{T u}{\rho} \frac{\partial \rho}{\partial T} \frac{\partial p}{\partial x} + \phi \left( \frac{\partial u}{\partial z} \right)^2
$$
where $$c$$ and $$k$$ are the specific heat and thermal conductivity of the grease, $$u$$ is the flow velocity profile across the film, and $$q$$ is a flux term. The energy equations for the two solids (cycloid gear and pin) are also considered, assuming semi-infinite bodies:
$$
c_a \rho_a u_1 \frac{\partial T}{\partial x} = k_a \frac{\partial^2 T}{\partial z_a^2}, \quad c_b \rho_b u_2 \frac{\partial T}{\partial x} = k_b \frac{\partial^2 T}{\partial z_b^2}
$$
Continuity of heat flux is enforced at the interfaces between the grease and the solids. The frictional power loss per unit width, a critical performance metric for the rotary vector reducer, is calculated by integrating the product of shear stress and sliding velocity across the film:
$$
Q = \int_{x_{in}}^{x_{out}} \left( \int_0^h \tau \frac{du}{dz} \, dz \right) dx
$$
The numerical solution involves discretizing the governing equations using the finite difference method. The elastic deformation is efficiently computed using the Discrete Convolution and Fast Fourier Transform (DC-FFT) technique. A coupled iterative procedure is employed: first, an isothermal EHL solution is obtained; this solution is then used as the initial guess for solving the full thermal system (energy equations coupled with the Reynolds, film thickness, and force balance equations). Iteration continues until pressure, film thickness, and temperature fields all converge. This process is repeated for each distinct tooth profile modification case in the rotary vector reducer analysis.
Results and Discussion
The analysis is performed for a representative RV550-E type rotary vector reducer. Key parameters for the cycloid-pin pair and the grease are summarized below.
| Parameter | Value | Parameter | Value |
|---|---|---|---|
| Pin wheel center circle radius, $$r_p$$ (mm) | 165 | Tooth width, $$b_c$$ (mm) | 25 |
| Pin radius, $$r_{rp}$$ (mm) | 5 | Short width coefficient, $$K_1$$ | 0.8 |
| Eccentricity, $$a$$ (mm) | 2.2 | Slide-to-roll ratio | 0.1 |
| Number of pins, $$z_p$$ | 60 | Flow index, $$n$$ | 0.9 |
| Number of cycloid teeth, $$z_c$$ | 59 | Ambient temperature, $$T_0$$ (K) | 313 |
| Output torque, $$T_1$$ (Nm) | 9310 | Grease ambient viscosity, $$\phi_0$$ (Pa·s) | 0.08 |
| Input speed (rpm) | 300 | Pressure-viscosity coeff., $$\alpha$$ (Pa$$^{-1}$$) | 2.91e-8 |
| Elastic modulus, $$E_1, E_2$$ (GPa) | 206 | Temperature-viscosity coeff., $$\beta$$ (K$$^{-1}$$) | 0.0476 |
| Density of solids (kg/m$$^3$$) | 7850 | Density of grease, $$\rho_0$$ (kg/m$$^3$$) | 870 |
| Specific heat of solids (J/kg·K) | 470 | Specific heat of grease (J/kg·K) | 2000 |
| Thermal conductivity of solids (W/m·K) | 46 | Thermal conductivity of grease (W/m·K) | 0.14 |
General Characteristics of the TEHL Solution
The solution for a modified profile (e.g., $$\Delta r_{rp}=0.12\text{ mm}, \Delta r_p=0.07\text{ mm}$$) reveals classic TEHL features but with grease-specific traits. The pressure profile closely follows the Hertzian dry contact pressure in the central region, with a sharp secondary pressure spike just before the outlet. The film profile is nearly parallel in the central contact zone, followed by a pronounced constriction (necking) at the location of the pressure spike, after which the film thickness rapidly increases. Comparing isothermal and thermal solutions highlights the significant influence of temperature rise within the grease film. The thermal solution shows a slightly thicker central film and a slightly higher pressure than the isothermal case for the same operating conditions. This is attributed to the variable density effect; the significant temperature rise in the film (especially in the central layers and near the outlet) reduces the grease density locally. This density reduction enhances the film’s load-carrying capacity in the parallel region, sometimes enough to offset the load-carrying capacity lost due to thermal viscosity reduction, leading to a net increase in film thickness. Eliminating this effect by performing an isothermal analysis at a uniformly elevated temperature confirms that thermal viscosity reduction alone would decrease the film thickness.
Effect of Modification Amount for a Single Method
Analyzing the effect of increasing the modification amount for a specific method, such as positive equidistant modification, reveals clear trends. As the modification (and thus the initial radial clearance) increases:
- Contact Pressure & Area: The maximum contact force $$F_{max}$$ increases substantially as fewer teeth share the load effectively. The Hertzian contact half-width increases, and the pressure spike at the outlet generally becomes more pronounced.
- Film Thickness: The central film thickness remains relatively stable, but the minimum film thickness (usually at the outlet constriction) exhibits a non-monotonic behavior. It initially increases slightly with small clearance increases due to stronger entrainment effects over a larger contact zone, but then decreases as the significantly higher contact pressure dominates, squeezing the film thinner.
- Temperature Rise & Friction: The maximum and average temperature rises within the contact increase significantly. The region of high temperature expands. Consequently, the total frictional power loss $$Q$$ rises markedly, driven by both higher shear stresses and the enlarged contact area.
Excessively large modifications lead to very high pressure gradients at the outlet, which can promote lubricant reverse flow and degrade performance. The associated high temperatures also risk accelerating grease thermal aging.
Comparative Analysis of Different Modification Methods
A crucial question is which modification method offers the best lubrication performance for a given nominal radial clearance. The analysis compares four schemes: Positive Equidistant (PE), Positive Radial Moving (PRM), a Positive Combination (PC: PE+PRM), and a Negative Combination (NC: Negative Equidistant + Negative Radial Moving). The anti-bow modification is analyzed separately due to its different load distribution characteristics. Key results are consolidated in the table below.
| Modification Scheme | Modification Amount (mm) | Max. Contact Force, $$F_{max}$$ (N) | Min. Film Thickness, $$h_{min}$$ (μm) | Frictional Power Loss, $$Q$$ (W·s$$^{-1}$$) |
|---|---|---|---|---|
| Positive Equidistant (PE) | Δrrp = 0.001 | 2689.8 | 1.8025 | 478.8 |
| Δrrp = 0.01 | 3171.3 | 1.8083 | 649.3 | |
| Δrrp = 0.10 | 5233.4 | 1.7831 | 1438.7 | |
| Δrrp = 0.20 | 6411.5 | 1.7541 | 1931.4 | |
| Δrrp = 0.40 | 7943.5 | 1.7141 | 2606.7 | |
| Positive Radial Moving (PRM) | Δrp = 0.001 | 2707.2 | 1.8030 | 484.9 |
| Δrp = 0.01 | 3326.5 | 1.8097 | 703.2 | |
| Δrp = 0.10 | 5943.7 | 1.7676 | 1730.1 | |
| Δrp = 0.20 | 7424.8 | 1.7286 | 2373.9 | |
| Δrp = 0.40 | 9234.7 | 1.6787 | 3202.8 | |
| Positive Combination (PC) | Δrrp=0.002, Δrp=0.001 | 2672.4 | 1.8021 | 473.0 |
| Δrrp=0.02, Δrp=0.01 | 2997.9 | 1.8078 | 586.9 | |
| Δrrp=0.20, Δrp=0.10 | 4394.3 | 1.7993 | 1107.7 | |
| Δrrp=0.40, Δrp=0.20 | 5118.3 | 1.7855 | 1392.9 | |
| Δrrp=0.80, Δrp=0.40 | 6127.1 | 1.7623 | 1811.7 | |
| Negative Combination (NC) | Δrrp=-0.001, Δrp=-0.002 | 2724.6 | 1.8033 | 491.5 |
| Δrrp=-0.01, Δrp=-0.02 | 3476.6 | 1.8085 | 761.0 | |
| Δrrp=-0.10, Δrp=-0.20 | 6554.2 | 1.7513 | 1991.5 | |
| Δrrp=-0.20, Δrp=-0.40 | 8183.1 | 1.7075 | 2716.2 | |
| Δrrp=-0.40, Δrp=-0.80 | 10286.0 | 1.6492 | 3706.2 |
The table clearly shows that for a given increase in nominal radial clearance, the negative combination (NC) method results in the highest maximum contact force $$F_{max}$$ and the highest frictional power loss $$Q$$, while also suffering the greatest reduction in minimum film thickness $$h_{min}$$ at larger modifications. The positive combination (PC) method yields the most favorable lubrication characteristics among the standard methods for a given clearance, achieving a lower $$F_{max}$$ and $$Q$$, and maintaining a higher $$h_{min}$$. The single positive modification methods (PE and PRM) fall between these two extremes, with PRM generally causing slightly higher loads and losses than PE for comparable clearances.
To fairly compare the anti-bow modification, which inherently has a different load distribution (the position of $$F_{max}$$ varies), its lubrication performance was evaluated across the entire meshing arc. The results demonstrate that for the same overall design clearance, the anti-bow profile consistently maintains a thicker lubricant film and induces lower frictional power loss over the primary load-bearing region of the engagement compared to all other modification methods. While its friction may be higher at the extreme edges of engagement, the contact forces there are minimal, resulting in negligible contribution to the total power loss. Therefore, from a purely tribological standpoint within the context of the rotary vector reducer, the anti-bow modification offers the best potential for minimizing wear and power loss while ensuring adequate film protection.
Conclusion
This analysis establishes a comprehensive thermal elastohydrodynamic lubrication model tailored for the modified cycloid-pin contact in a rotary vector reducer. The model successfully captures the complex interplay between non-Newtonian grease rheology, thermal effects, elastic deformation, and the altered geometry from profile modification. The key findings are:
- The grease film in a rotary vector reducer exhibits classic TEHL features with a pressure spike and film constriction. Thermal effects, particularly the variable-density effect, play a significant role in determining the final film thickness and pressure profile.
- As the radial clearance introduced by tooth profile modification increases, the maximum contact stress and frictional power loss increase monotonically. The minimum film thickness shows an initial slight increase followed by a consistent decrease as the modification becomes larger.
- For an identical nominal radial clearance, the lubrication performance varies significantly with the modification method. The anti-bow tooth profile demonstrates the most favorable overall tribological performance, maintaining thicker films and lower friction losses. Among conventional linear modifications, a positive combination of equidistant and radial moving modification provides better lubrication performance (lower $$F_{max}$$, higher $$h_{min}$$, lower $$Q$$) than single modifications, while a negative combination scheme yields the worst performance.
This study provides a new, lubrication-focused methodology for evaluating and selecting tooth profile modification parameters for rotary vector reducers. By considering tribological performance alongside traditional mechanical criteria, designers can optimize modifications to achieve not only good load distribution and accuracy but also high efficiency, low operating temperature, and long service life.