
In mechanical engineering, the pursuit of efficient and reliable power transmission systems is perpetual. Traditional involute worm gear pairs, while offering advantages such as compact structure and high transmission ratios, often face challenges in open drives or scenarios with excessively large ratios, where the helical gear is prone to root fracture due to material and structural limitations. This issue restricts their application in heavy-duty or high-impact environments, such as in special vehicles or aerospace systems. To address this, I propose a novel design based on unequal module and unequal pressure angle principles for ZI worm helical gear transmissions. This design significantly enhances the root strength of the helical gear by simultaneously increasing its module and pressure angle, thereby expanding the applicability of involute worm drives. In this study, I explore the transmission characteristics, perform finite element analysis (FEA), and employ grey prediction models for stress forecasting, providing a comprehensive framework for engineering design and validation.
The core of this innovation lies in the helical gear, a critical component in many transmission systems. Its ability to transmit motion smoothly and efficiently makes it ideal for various applications, but under high loads, traditional designs may fail. By rethinking the meshing conditions, I aim to optimize the helical gear’s performance. The helical gear in this context is not just a passive element but an actively strengthened part of the system. The design leverages the fact that in the mid-plane, the ZI worm helical gear pair resembles an involute helical gear transmission, allowing for non-standard meshing parameters. This approach, often referred to as multi-module design, enables the helical gear to bear higher stresses without increasing its size disproportionately, making it suitable for compact and high-ratio drives where space and weight are constraints.
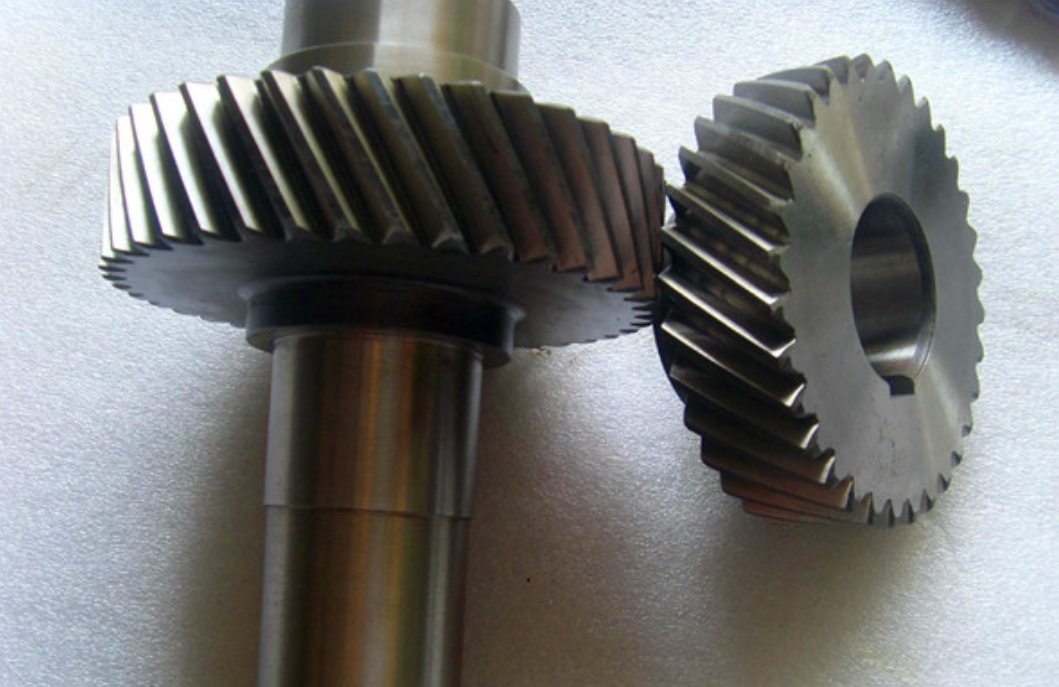
The fundamental principle behind this design is the modification of the correct meshing conditions. Typically, for worm gear pairs, the module and pressure angle in the mid-plane must be equal, along with the matching of lead and helix angles. However, for a ZI worm helical gear pair, which operates similarly to an involute helical gear set, the correct meshing condition reduces to the equality of base pitches in the transverse plane, while the lead angle of the worm must equal the helix angle of the helical gear. This allows for the use of different modules and pressure angles for the worm and helical gear, as long as the base pitch condition is satisfied. Mathematically, this can be expressed as:
$$m_{x1} \cos \alpha_1 = m_{t2} \cos \alpha_2$$
$$\gamma_1 = \beta_2$$
where \(m_{x1}\) is the axial module of the worm, \(m_{t2}\) is the transverse module of the helical gear, \(\alpha_1\) and \(\alpha_2\) are the pressure angles of the worm and helical gear respectively, \(\gamma_1\) is the lead angle of the worm, and \(\beta_2\) is the helix angle of the helical gear. This condition ensures proper engagement without interference, enabling the helical gear to have a larger module and pressure angle, which directly contributes to its root strength. The helical gear thus benefits from a thicker tooth profile, reducing stress concentrations at the fillet region.
To further elucidate, the meshing angle and center distance for such a pair require special calculation methods. Based on the condition of zero backlash in theoretical analysis, the relationship between the tooth thickness of the worm and the space width of the helical gear at the pitch circle must hold. Through derivation, the meshing angle \(\alpha\) can be determined from the following implicit equation, which involves the inverse involute function:
$$\alpha = \text{inv}^{-1}\left( \frac{q_1 (\tan \alpha_1 – \alpha_1) + z_2 (\tan \alpha_2 – \alpha_2)}{q_1 + z_2} \right)$$
where \(q_1\) is the diameter factor of the worm, and \(z_2\) is the number of teeth on the helical gear. This equation typically requires numerical methods, such as those implemented in MATLAB, for solution. Subsequently, the standard center distance \(a\) is given by:
$$a = r_{H1} + r_{H2} = \frac{p_{bt} (q_1 + z_2)}{2 \cos \alpha}$$
Here, \(p_{bt}\) is the transverse base pitch, and \(r_{H1}\) and \(r_{H2}\) are the pitch radii of the worm and helical gear, respectively. These formulas are pivotal for designing the helical gear pair with unequal modules, ensuring that the helical gear achieves enhanced mechanical properties without compromising meshing integrity.
To validate the practicality of this design, I conducted a finite element analysis comparing the proposed multi-module helical gear with a traditional helical gear under the same transmission ratio. The worm was modeled as a standard ZI type with parameters chosen for typical applications, while the helical gear was designed with increased module and pressure angle. The materials were selected to reflect realistic scenarios: the worm from carbon steel and the helical gear from ABS plastic, as the latter is often used in applications where weight reduction and cost-effectiveness are priorities, such as in automotive or household appliances. The helical gear’s material choice also highlights its versatility, though it introduces challenges in manufacturing due to the non-standard parameters.
| Parameter | Worm | Traditional Helical Gear | Multi-Module Helical Gear |
|---|---|---|---|
| Module (mm) | 4 | 4 | 4.5 |
| Pressure Angle (degrees) | 20 | 20 | 33.35 |
| Number of Teeth | 1 | 20 | 20 |
| Material | 45# Steel | ABS Plastic | ABS Plastic |
| Young’s Modulus (GPa) | 200 | 1.63 | 1.63 |
| Poisson’s Ratio | 0.3 | 0.41 | 0.41 |
The FEA was performed using ANSYS, with the worm subjected to a torque of 20 N·m. The mesh was refined to ensure accuracy, resulting in over 250,000 elements for the multi-module pair. The results demonstrated a significant improvement in the helical gear’s root strength. Specifically, the maximum root stress \(\sigma_{1max}\) in the multi-module helical gear was found to be 5.13 MPa, whereas the traditional helical gear exhibited a stress \(\sigma_{2max}\) of 15.17 MPa. This translates to a stress reduction factor \(N\) of approximately 0.338, meaning the root strength increased by about 2.956 times. This enhancement is attributed to the larger module and pressure angle, which increase the tooth thickness and improve load distribution. Moreover, the contact stress also showed improvement, with the multi-module helical gear having a maximum contact stress of 134.01 MPa compared to 145.58 MPa for the traditional one, a reduction of about 8%, aligning with Hertzian contact theory due to increased effective curvature radius.
The helical gear in this configuration not only bears higher loads but also operates with greater durability. To further assess the performance under varying conditions, I employed grey prediction models to forecast the maximum stress in the helical gear under different torques. Grey systems theory, particularly the GM(1,1) model, is effective for short-term predictions with limited data. The model involves accumulating the original stress data to reveal underlying trends. For instance, given stress values at torques of 20 to 24 N·m, the accumulated series is generated, and the model parameters are estimated using least squares methods. The general form of the GM(1,1) model is:
$$x^{(0)}(k) + a z^{(1)}(k) = b$$
where \(x^{(0)}(k)\) is the original stress data, \(z^{(1)}(k)\) is the background value from the accumulated series, and \(a\) and \(b\) are the development coefficient and grey input, respectively. The solution provides predicted values, and to enhance accuracy, I compared traditional GM(1,1) with improved versions like the new information GM(1,1) and metabolism GM(1,1) models. Using MATLAB, the metabolism GM(1,1) model showed the smallest sum of squared errors (SSE), making it the most reliable for prediction. The predicted stresses for torques from 25 to 30 N·m are summarized below, offering insights for design validation and safety checks.
| Predicted Torque (N·m) | Predicted Maximum Stress \(\sigma_{1max}\) (MPa) |
|---|---|
| 25 | 6.4452 |
| 26 | 6.7314 |
| 27 | 7.0326 |
| 28 | 7.3495 |
| 29 | 7.6758 |
| 30 | 8.0188 |
The prediction process involved residual and grade ratio deviation tests to ensure model fidelity. For the metabolism GM(1,1) model, the average relative residual was 0.0009856, and the average grade ratio deviation was 0.0020766, both well below thresholds of 0.1, indicating excellent fit. This predictive capability is crucial for engineering applications, as it allows designers to estimate stress levels without extensive testing, especially for the helical gear which is often the limiting component. However, it’s important to note that grey predictions are best for short-term forecasts within material limits, as long-term extrapolation may lead to exponential errors.
Beyond analysis, I also validated the design physically by fabricating a scaled-down helical gear using 3D printing with transparent rigid resin. The helical gear meshed correctly with a POM worm, demonstrating the feasibility of the unequal module approach. This practical verification underscores the helical gear’s adaptability to non-traditional manufacturing methods, though mass production might require specialized tools due to the unconventional pressure angle and module.
The advantages of this multi-module design are manifold. Firstly, the helical gear gains substantial root strength, making it suitable for high-ratio transmissions where torque fluctuations are common. Secondly, the contact stress reduction enhances wear resistance, prolonging the helical gear’s lifespan. Thirdly, the design allows for more compact arrangements, as the helical gear can handle higher loads without increasing its diameter excessively. This is particularly beneficial in aerospace and automotive sectors, where space and weight are critical. However, there are trade-offs: the increased pressure angle may reduce the contact ratio, potentially affecting smoothness in high-speed applications. But for low to medium-speed, heavy-duty scenarios, the strength benefits outweigh this drawback. The helical gear thus becomes a cornerstone of reliable power transmission in demanding environments.
In terms of broader implications, this research opens avenues for optimizing other types of worm drives, such as TVP or TI worms, by applying similar unequal module principles. The methodology here—combining theoretical derivation, FEA, and grey prediction—can be extended to various gear systems. Future work could explore dynamic analysis, thermal effects, or the integration of advanced materials like composites for the helical gear. Additionally, topological optimization could be employed to further lightweight the helical gear while maintaining stress limits, leveraging the predicted stress data for iterative design improvements.
In conclusion, the multi-module ZI worm helical gear transmission presents a robust solution to the limitations of traditional designs. Through careful adjustment of meshing parameters, the helical gear achieves remarkable strength enhancements, as confirmed by finite element analysis and physical prototypes. The use of grey prediction models provides a reliable tool for stress forecasting, aiding in design validation and risk assessment. This approach not only extends the application range of involute worm drives but also exemplifies how innovative thinking can overcome classical engineering challenges. The helical gear, with its improved performance, stands as a testament to the potential of customized gear design in advancing mechanical transmission systems.