
In the field of mechanical transmission, worm gear drives are widely used due to their high reduction ratios and smooth operation. Among various types, the inclined double-roller enveloped hourglass worm gear drive offers advantages in load capacity and backlash elimination. However, the lubrication performance of this worm gear drive under realistic rough surface conditions remains a critical aspect that influences its efficiency and service life. In this study, we develop a comprehensive elasto-hydrodynamic lubrication (EHL) model for a worm gear pair considering surface roughness, focusing on the contact between the worm and the roller-based worm wheel. The worm gear drive under investigation consists of a double-row roller configuration with an inclined axis, which provides enhanced meshing characteristics and adjustable clearance.
The worm gear drive mechanism is illustrated schematically in the figure below. The worm wheel is composed of fixed and movable sections, with rollers distributed circumferentially and inclined relative to the radial direction. The worm tooth surfaces are generated by the enveloping motion of these rollers, resulting in a complex spatial contact line during meshing.
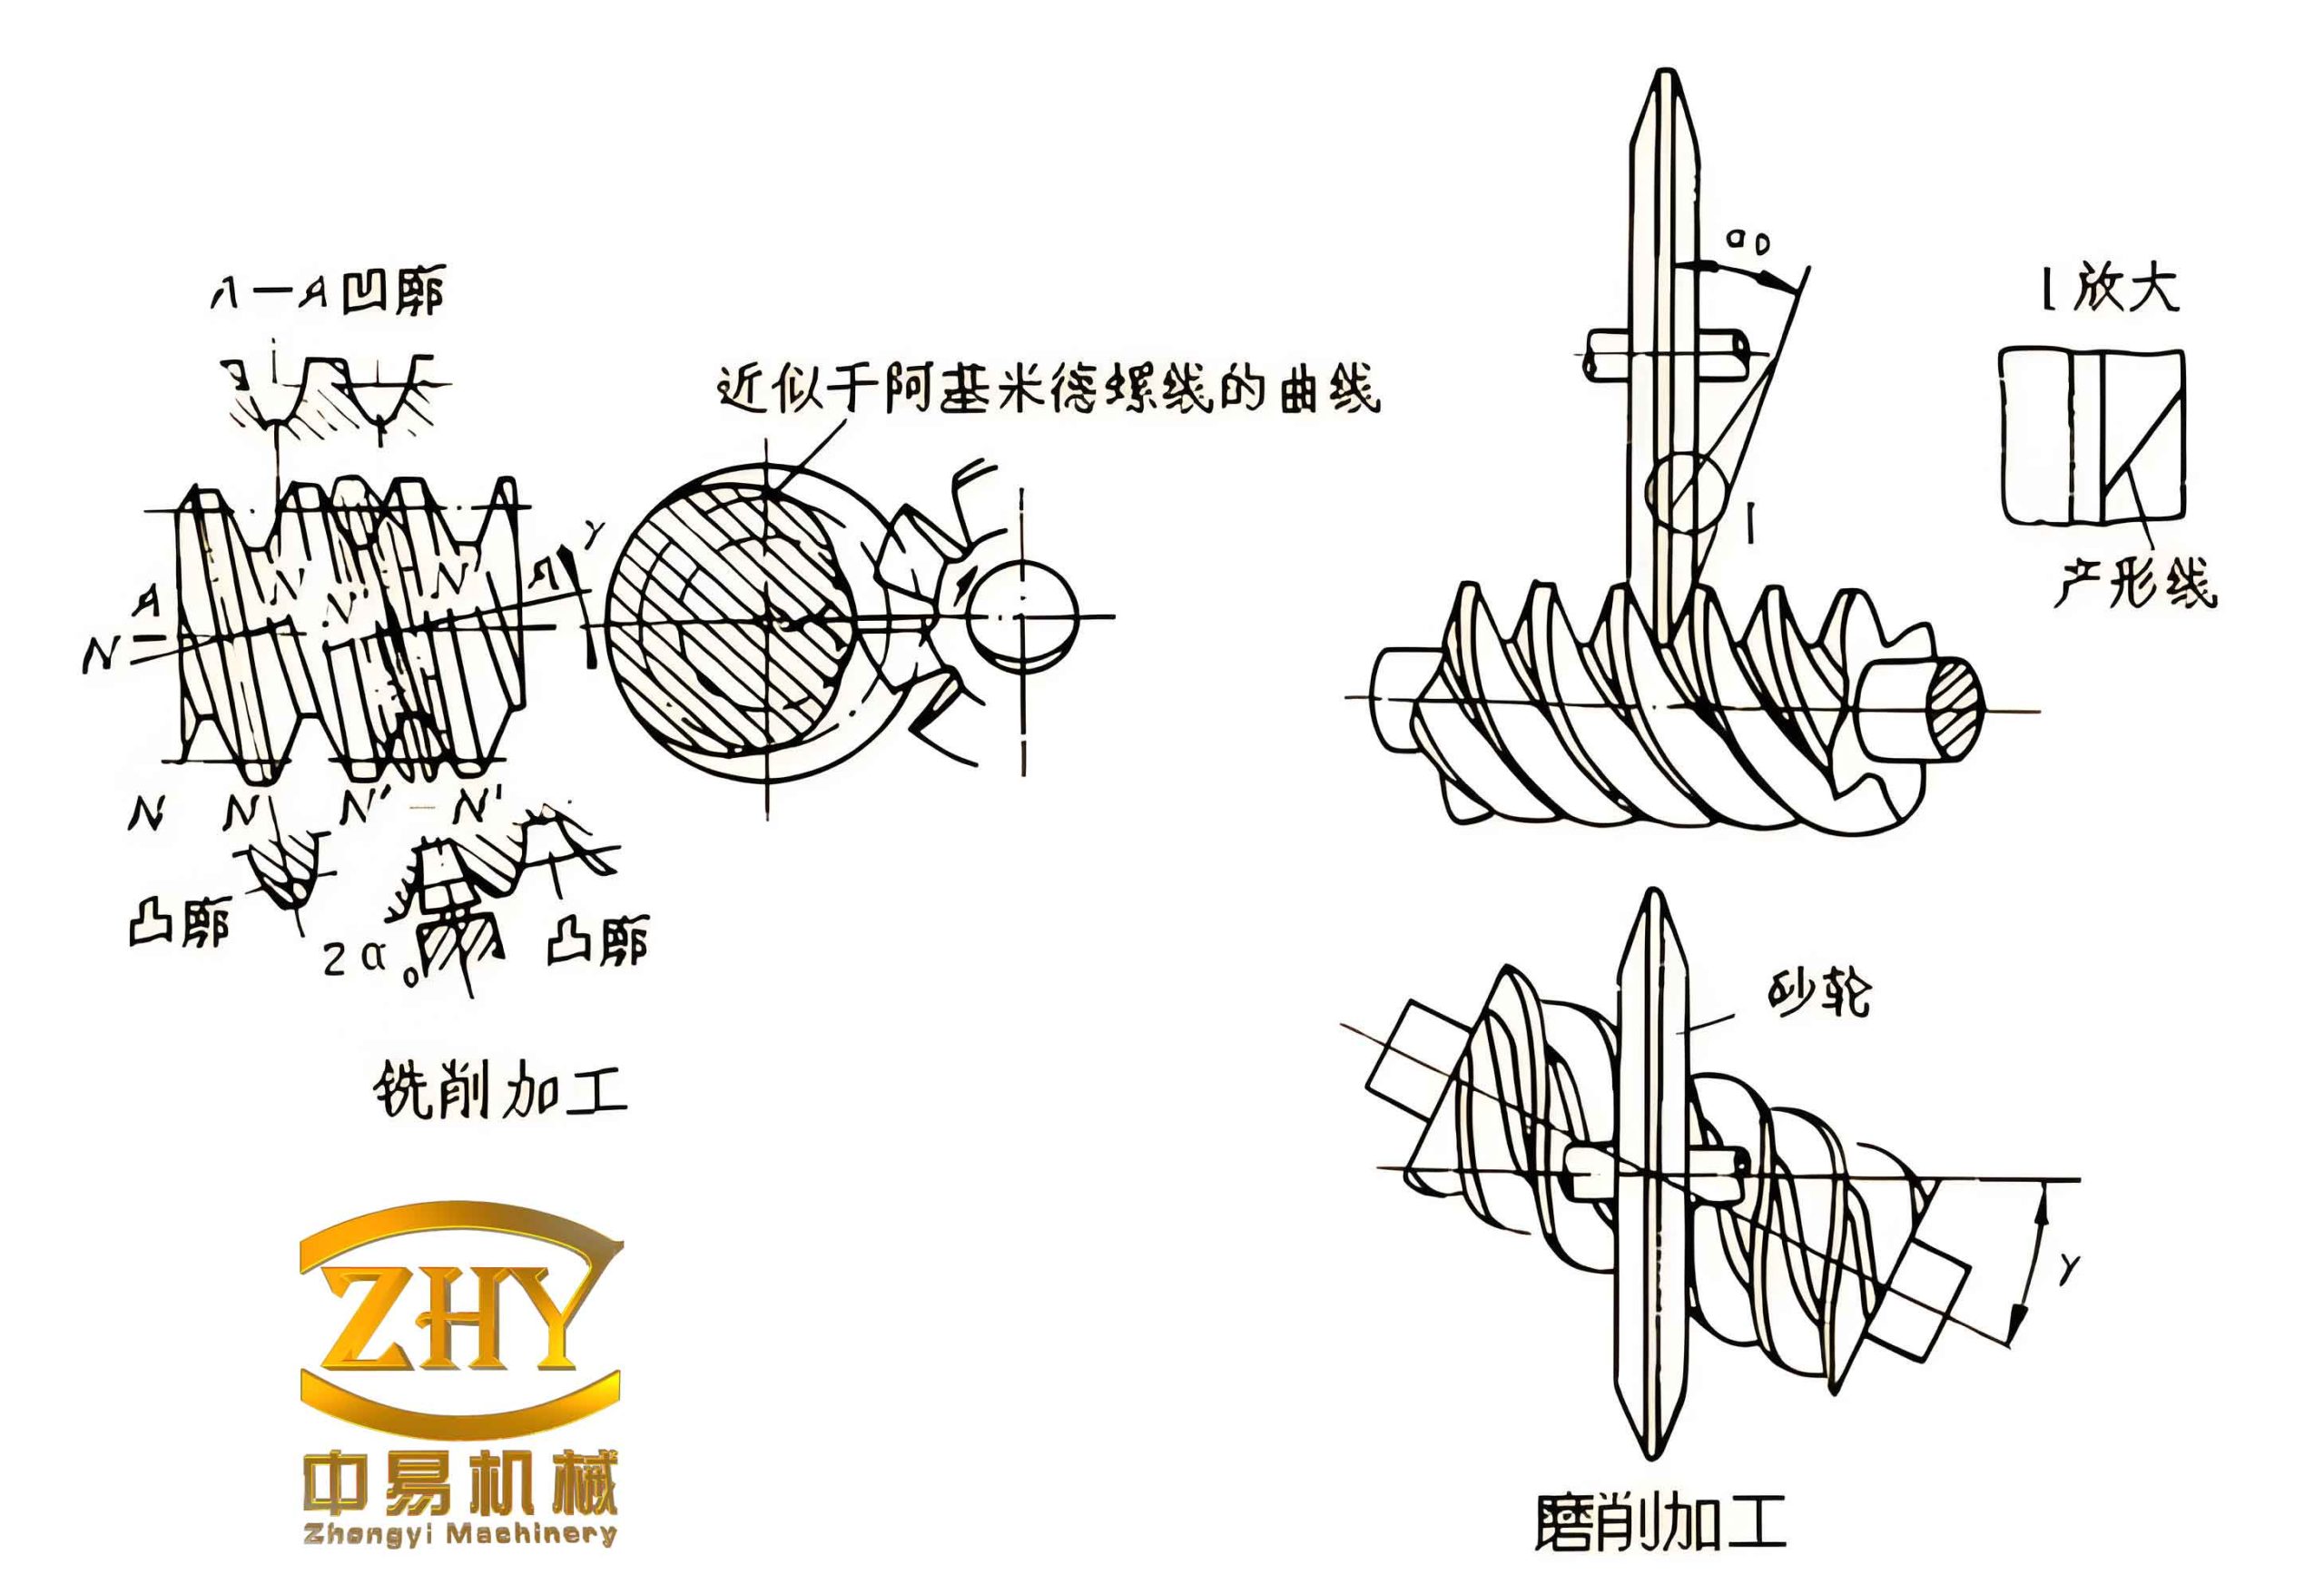
To analyze the lubrication behavior of this worm gear, we adopt a line contact EHL model. The contact between the worm tooth and the roller is simplified as a cylinder on a plane, where the equivalent curvature radius, entrainment velocity, and load per unit length vary along the meshing cycle. These parameters are derived from the meshing theory of the worm gear drive.
The equivalent radius of curvature \( R \) at the contact point is given by:
$$
R = \frac{1}{k_\sigma}
$$
where \( k_\sigma \) is the induced normal curvature. Based on the relative motion of the worm and roller, the entrainment velocity \( v_{jx} \) is calculated as:
$$
v_{jx} = \frac{v_w + v_g}{2}
$$
with \( v_w \) and \( v_g \) being the velocities of the worm wheel and worm at the contact point along the normal direction. The load per unit length \( w_i \) on each meshing tooth pair is expressed as:
$$
w_i = \frac{F_{ni}}{L} = \frac{2K_i T_1}{L d_1 \cos\alpha_n \cos\beta}
$$
where \( K_i \) is the load sharing factor among teeth, \( L \) is the contact line length, \( T_1 \) is the input torque, \( d_1 \) is the worm pitch diameter, \( \alpha_n \) is the pressure angle, and \( \beta \) is the helix angle. The variation of these parameters from the entry to the exit of the meshing cycle is shown in Table 1 for a typical worm gear drive.
| Meshing Position | Equivalent Radius \( R \) (mm) | Entrainment Velocity \( v_{jx} \) (m/s) | Load per Unit Length \( w \) (N/m) |
|---|---|---|---|
| Entry | 8.2 | 1.45 | 1250 |
| Mid-engagement (single tooth) | 10.5 | 1.12 | 2100 |
| Throat region (three teeth) | 12.8 | 0.98 | 2800 |
| Exit | 14.1 | 1.30 | 1500 |
The EHL model for the worm gear drive incorporates the Reynolds equation, film thickness equation with roughness, viscosity-pressure relation, density-pressure relation, and load balance equation. The dimensionless forms are employed for numerical stability. The Reynolds equation for line contact is:
$$
\frac{d}{dx}\left(\frac{\rho h^3}{\eta}\frac{dp}{dx}\right) = 12 v_{jx} \frac{d(\rho h)}{dx} + 12 \frac{d(\rho h)}{dt}
$$
After introducing dimensionless parameters \( X = x/b \), \( H = h/R \), \( P = p/p_h \), etc., the equation becomes:
$$
\frac{d}{dX}\left(\varepsilon \frac{dP}{dX}\right) = \frac{d(\rho^* H)}{dX} + \frac{d(\rho^* H)}{dT}
$$
where \( \varepsilon = \frac{\rho^* H^3}{\eta^* \lambda} \) and \( \lambda = \frac{12\eta_0 U R^2}{p_h b^2} \). Boundary conditions are \( P(X_{in})=0 \) at the inlet and \( P(X_{out}) = dP/dX|_{X_{out}} = 0 \) at the outlet.
Surface roughness is modeled as sinusoidal waves on both the worm and roller surfaces. The combined roughness function is:
$$
S(X) = A_w \cos\left(\frac{2\pi}{l_w}(X – U_w T)\right) + A_g \cos\left(\frac{2\pi}{l_g}(X – U_g T)\right)
$$
where \( A_w, A_g \) are roughness amplitudes and \( l_w, l_g \) are wavelengths. The film thickness equation including roughness is:
$$
H(X) = H_0 + \frac{X^2}{2} – \frac{1}{\pi}\int_{X_{in}}^{X_{out}} \ln|X – X’| P(X’) dX’ – S(X)
$$
The viscosity under pressure follows the Barus-like form (Roelands equation):
$$
\eta^* = \exp\left\{(\ln\eta_0 + 9.67)\left[(1 + 5.1\times10^{-9}p)^z – 1\right]\right\}
$$
with \( z = \alpha/(5.1\times10^{-9}(\ln\eta_0 + 9.67)) \). The density variation is given by:
$$
\rho^* = \frac{1 + 0.6\times10^{-9}p}{1 + 1.7\times10^{-9}p}
$$
The load balance condition in dimensionless form is:
$$
W = \int_{X_{in}}^{X_{out}} P(X) dX = \frac{\pi}{2}
$$
These equations are discretized using the finite difference method. A multigrid technique (W-cycle) with six grid levels is employed to solve the Reynolds equation efficiently. The finest grid contains 961 nodes. Gauss-Seidel relaxation is applied, and the convergence criteria are set as pressure error < 0.001 and load error < 0.001. The numerical solution yields the pressure and film thickness distributions at each meshing instant.
We select a specific worm gear drive with parameters listed in Table 2.
| Parameter | Value |
|---|---|
| Number of worm threads \( Z_1 \) | 1 |
| Number of worm wheel teeth \( Z_2 \) | 25 |
| Center distance \( A \) (mm) | 125 |
| Roller radius \( R_k \) (mm) | 6.5 |
| Roller offset \( c_2 \) (mm) | 7 |
| Throat coefficient \( k_1 \) | 0.4 |
| Inclination angle \( \gamma \) (deg) | 6 |
| Ambient viscosity \( \eta_0 \) (Pa·s) | 0.028 |
| Ambient density \( \rho_0 \) (kg/m³) | 870 |
| Pressure-viscosity coefficient \( \alpha \) (m²/N) | 2.2×10⁻⁸ |
| Roughness amplitude \( A_w = A_g \) (μm) | 0.06 |
| Roughness wavelength \( l_w = l_g \) (μm) | 12 |
| Modulus of elasticity \( E_1 = E_2 \) (GPa) | 210 |
| Poisson’s ratio \( \mu_1 = \mu_2 \) | 0.3 |
The simulation is performed for a full meshing cycle with 100 time steps. At each step, both smooth and rough surface solutions are obtained. Figure 1 (not shown) illustrates the pressure and film thickness distributions at different meshing instants. For the rough surface case, pressure oscillations appear near each asperity, especially in the heavily loaded central region. The maximum pressure peak increases while the minimum film thickness decreases compared to the smooth case. The most critical condition occurs when three tooth pairs are simultaneously in contact, corresponding to the throat region where the entrainment velocity is lowest and load is highest.
We further investigate the influence of four design parameters: roller radius \( R_k \), throat coefficient \( k_1 \), roller offset \( c_2 \), and inclination angle \( \gamma \). The results at the three-tooth meshing instant are summarized in Table 3.
| Parameter | Value range | Max pressure (GPa) | Min film thickness (μm) |
|---|---|---|---|
| Roller radius \( R_k \) (mm) | 5.5, 6.5, 7.5 | 1.12, 1.25, 1.43 | 0.38, 0.32, 0.26 |
| Throat coefficient \( k_1 \) | 0.3, 0.4, 0.5 | 1.52, 1.25, 1.08 | 0.21, 0.32, 0.44 |
| Roller offset \( c_2 \) (mm) | 5, 7, 9 | 1.18, 1.25, 1.36 | 0.36, 0.32, 0.28 |
| Inclination angle \( \gamma \) (deg) | 4, 6, 8 | 1.20, 1.25, 1.31 | 0.35, 0.32, 0.29 |
The data indicate that increasing the roller radius, offset, or inclination angle leads to higher pressure peaks and thinner oil films, which are detrimental to lubrication. Conversely, a larger throat coefficient improves film thickness and reduces pressure. Among all parameters, the throat coefficient has the most significant impact, followed by roller radius and offset, while the inclination angle shows the least sensitivity.
These trends can be explained by the fact that larger roller radius and offset increase the equivalent curvature, thereby raising the Hertzian contact pressure. A smaller throat coefficient corresponds to a narrower worm throat, which concentrates the load and reduces the entrainment velocity. The inclination angle affects the orientation of the roller, altering the geometry of the contact ellipse and the local sliding velocity.
In summary, the elasto-hydrodynamic lubrication analysis of the inclined double-roller enveloped hourglass worm gear drive reveals that surface roughness significantly alters the pressure and film thickness distributions. The presence of roughness increases the maximum pressure and reduces the minimum film thickness, indicating a higher risk of asperity contact and wear. To maintain satisfactory lubrication, designers should avoid excessively large roller radius, roller offset, and inclination angle, while ensuring the throat coefficient is not too small. The optimized selection of these parameters, guided by the EHL model, can enhance the performance and durability of this worm gear drive.