
In the evolving landscape of industrial automation, particularly within robotics, the demand for precision, durability, and high performance in motion control systems is paramount. As a critical component in the joint of industrial robots, the rotary vector reducer has become the focus of extensive research due to its exceptional load-bearing capacity, high transmission ratio, compact structure, and superior torsional rigidity. The operational precision and longevity of these robotic systems are intrinsically linked to the dynamic characteristics of their internal components. Notably, resonance—induced when operational excitation frequencies align with a structure’s natural frequencies—can lead to excessive vibrations, accelerated fatigue, noise, and ultimately, a failure to meet precision requirements. Therefore, a profound understanding of the inherent dynamic properties, specifically the natural frequencies and mode shapes, of the core components within a rotary vector reducer is indispensable for predictive design and reliability enhancement.
Traditional analytical methods often fall short in accurately predicting the complex vibrational behavior of intricate mechanical assemblies. This is where finite element analysis (FEA) has established itself as a cornerstone of modern engineering simulation. By discretizing a complex geometry into a finite number of elements and solving the governing equations of motion, FEA provides a powerful tool for virtual prototyping and analysis. Modal analysis, a fundamental branch of FEA, is specifically dedicated to determining the inherent vibration characteristics of a structure. It assumes linear elastic material behavior and ignores damping and time-varying loads to solve for the natural frequencies and corresponding mode shapes—the characteristic patterns of deformation at each frequency.
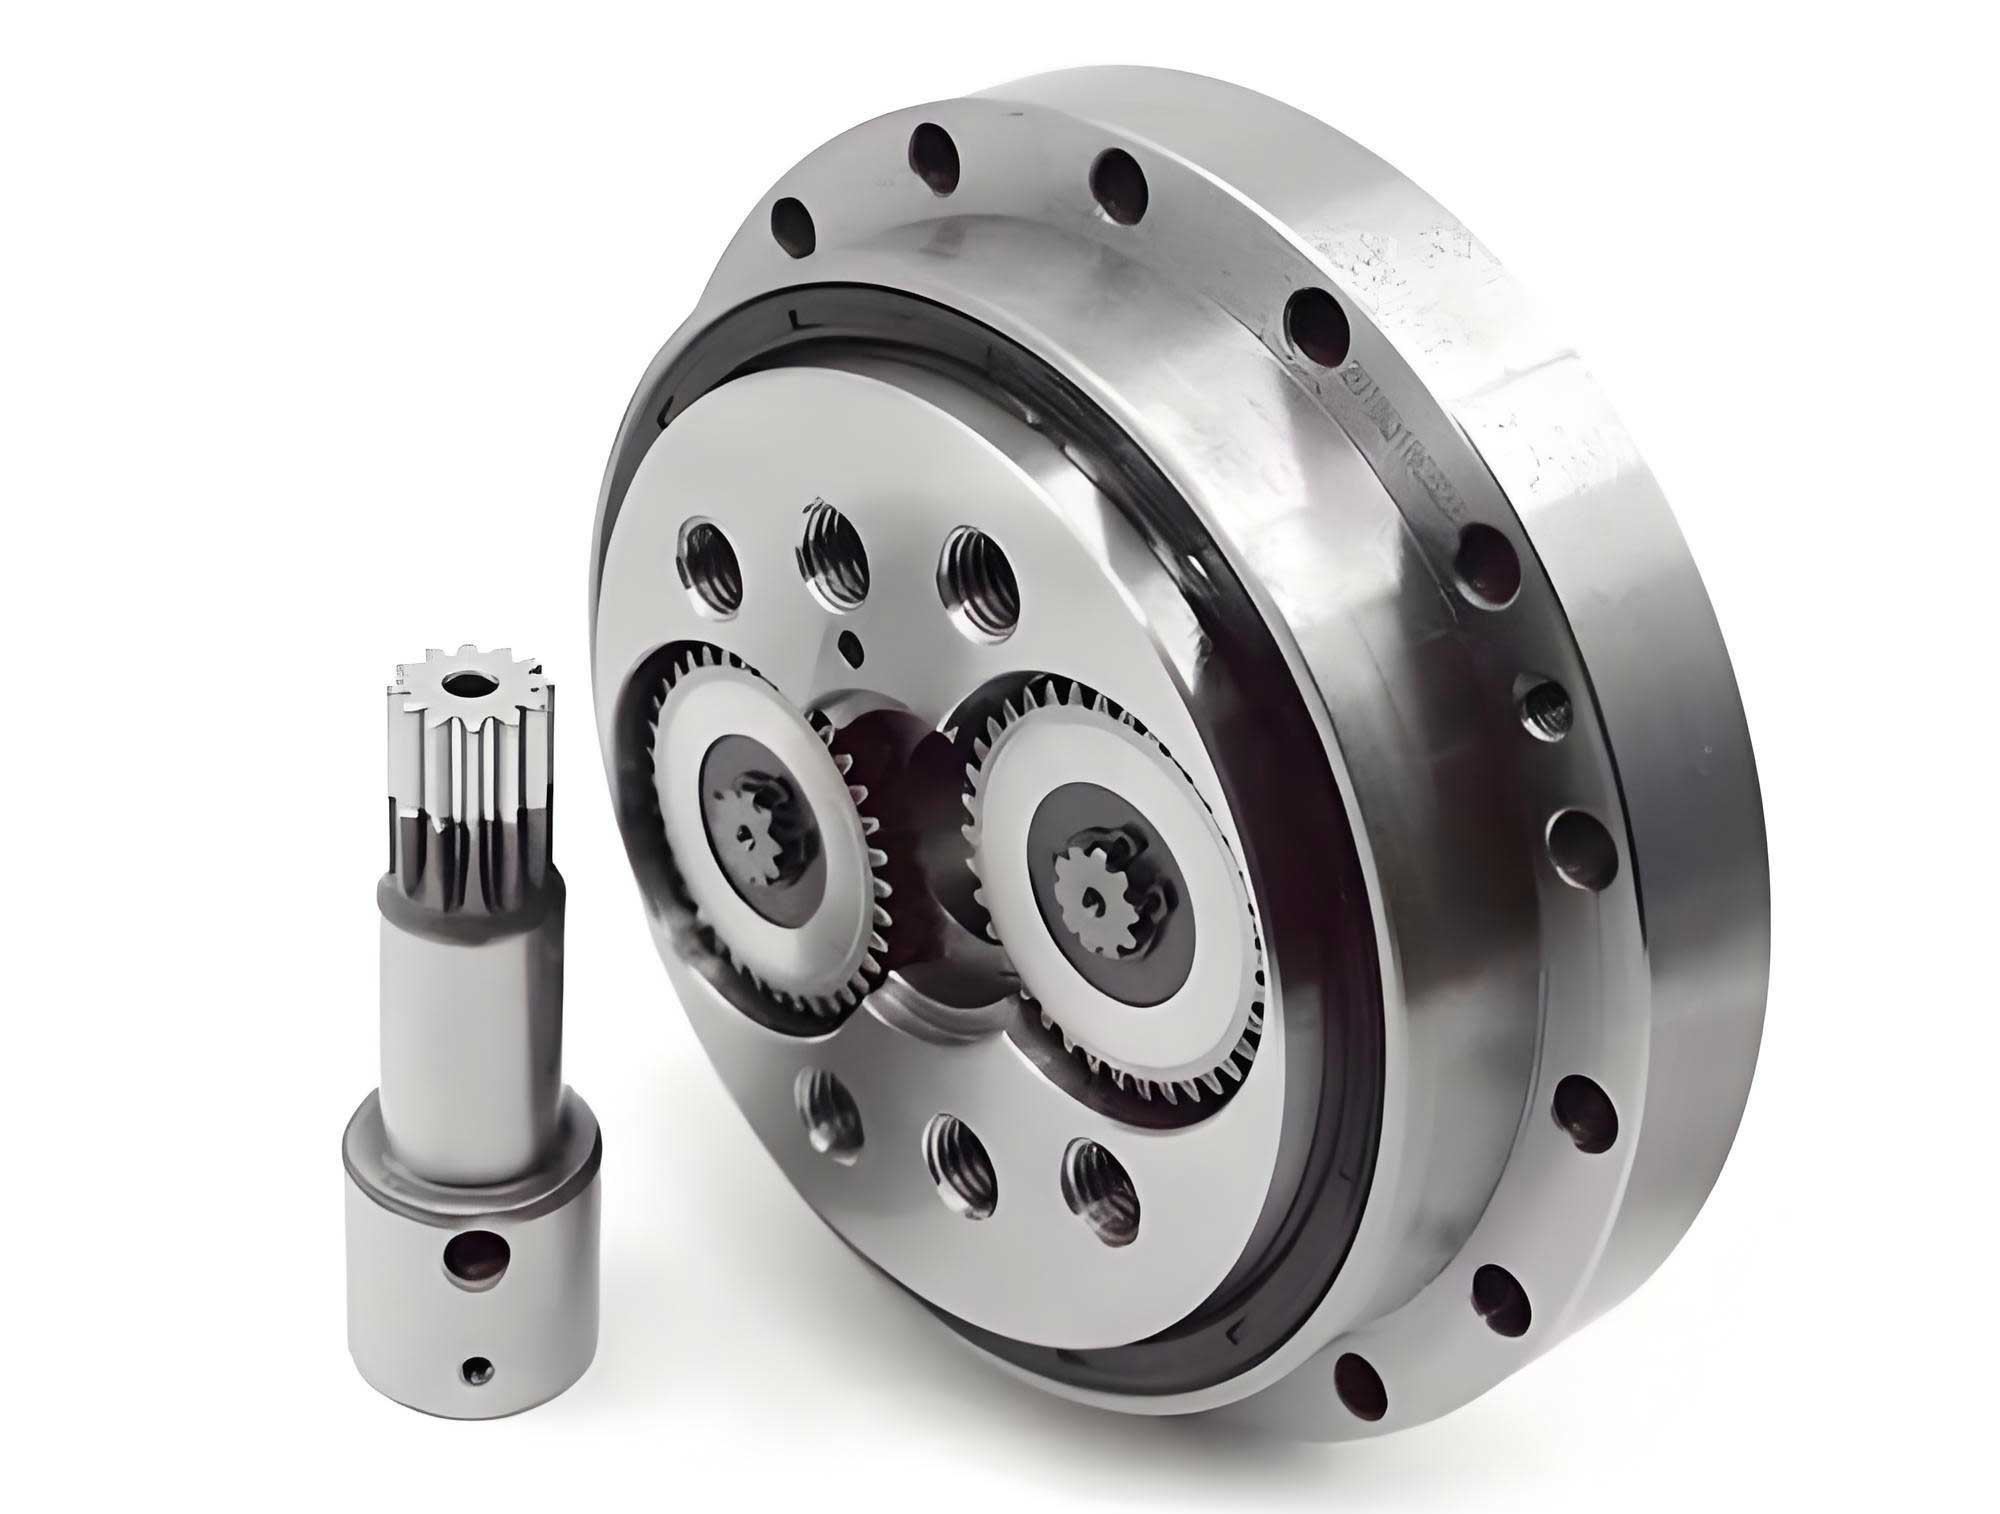
The primary objective of this investigation is to employ finite element-based modal analysis to evaluate the dynamic characteristics of two crucial components in a rotary vector reducer: the crankshaft (integrating with its planetary gear) and the planet carrier. The analysis is conducted under two distinct boundary conditions: free-free and constrained, to understand the spectrum of their dynamic response. By extracting and comparing the natural frequencies against potential excitation sources, such as gear meshing frequencies, we can assess the risk of resonance. Furthermore, by examining the mode shapes, we can identify structural weaknesses and areas of high deformation, providing a theoretical foundation for the structural optimization of the rotary vector reducer.
Fundamentals of Modal Analysis Theory
At its core, modal analysis seeks the solution to the undamped, free-vibration equation of a multi-degree-of-freedom system. The governing equation of motion for a linear, undamped structure can be expressed in matrix form as:
$$ [M]\{\ddot{u}\} + [K]\{u\} = \{0\} $$
where $[M]$ is the global mass matrix, $[K]$ is the global stiffness matrix, $\{u\}$ is the nodal displacement vector, and $\{\ddot{u}\}$ is the nodal acceleration vector. For a system undergoing free vibration, the solution is assumed to be harmonic, taking the form:
$$ \{u\} = \{\phi_i\} \cos(\omega_i t) $$
Here, $\{\phi_i\}$ represents the $i$-th mode shape vector (or eigenvector), $\omega_i$ is the corresponding $i$-th natural frequency (eigenvalue in rad/s), and $t$ is time. Substituting this assumed solution into the equation of motion yields the classic eigenvalue problem:
$$ (-\omega_i^2[M] + [K])\{\phi_i\} = \{0\} $$
For a non-trivial solution ($\{\phi_i\} \neq 0$), the determinant of the coefficient matrix must vanish, leading to the characteristic equation:
$$ |-\omega_i^2[M] + [K]| = 0 $$
Solving this equation yields $n$ eigenvalues $\omega_i^2$ (where $n$ is the number of degrees of freedom) and their associated eigenvectors $\{\phi_i\}$. The natural frequency in Hertz is calculated as $f_i = \omega_i / (2\pi)$. The eigenvectors describe the relative displacement pattern of the structure when vibrating at its corresponding natural frequency. These mode shapes are typically normalized with respect to the mass matrix, such that:
$$ \{\phi_i\}^T [M] \{\phi_i\} = 1 $$
This normalization facilitates meaningful comparisons between different mode shapes. In the context of a rotary vector reducer, performing this analysis on key components like the crankshaft and planet carrier reveals their fundamental dynamic signature, which is critical for avoiding resonant conditions during operation.
Finite Element Modeling and Analysis Procedure
The accuracy of a finite element modal analysis is heavily contingent upon the fidelity of the model, which encompasses geometry, material properties, mesh quality, and boundary conditions. The following steps outline the comprehensive procedure adopted for this study.
Parametric Geometry Creation
Given the complex geometries involved, especially the involute gear teeth of the planetary gear, a dedicated computer-aided design (CAD) software (Pro/ENGINEER) was utilized for parametric modeling. This approach allows for efficient model generation and future design iterations. Key design parameters for the planetary gear were defined, including the number of teeth (45), module (2 mm), pressure angle (20°), face width (12 mm), addendum coefficient (0.9), and dedendum coefficient (0.25). The geometric model was then exported in a neutral format (IGES) for subsequent import into the simulation environment. The crankshaft was modeled as an integrated assembly with its mounted planetary gear, considering they are fixed together via a spline connection. Similarly, the output plate was modeled as an integral part of the primary planet carrier.
Material Property Assignment
Accurate material properties are essential for realistic dynamic simulation. The components of the rotary vector reducer are typically manufactured from high-strength alloy steels. The material properties assigned in the finite element model are summarized in the table below.
| Component | Material | Young’s Modulus, E (GPa) | Density, ρ (kg/m³) | Poisson’s Ratio, ν |
|---|---|---|---|---|
| Planetary Gear & Crankshaft | 40Cr / GCr15 | 215.5 (Avg.) | 7,860 (Avg.) | 0.295 (Avg.) |
| Planet Carrier | 45 Steel | 209 | 7,890 | 0.269 |
Meshing Strategy
The imported geometries were discretized using ANSYS Workbench’s meshing tools. A higher-order 3D solid element, SOLID186, was selected. This element is a 20-node quadratic hexahedral element with three translational degrees of freedom per node (x, y, z) and exhibits superior performance in modeling irregular meshes and capturing stress gradients. A global element size of 2 mm was specified, and a curvature-based refinement was applied to critical features like gear teeth and fillets. The resulting mesh for the crankshaft assembly and the planet carrier was checked for quality metrics (aspect ratio, skewness) to ensure solution accuracy. The final mesh consisted of approximately 450,000 nodes and 280,000 elements for the crankshaft assembly, and 520,000 nodes and 320,000 elements for the planet carrier assembly.
Definition of Boundary Conditions
Two distinct sets of boundary conditions were applied to understand the component’s behavior in different states:
- Free-Free Boundary: No constraints are applied to the model. This condition is useful for extracting the theoretical inherent dynamic properties of the component itself, isolating it from any external support stiffness. The first six modes (three translational and three rotational) under this condition will have natural frequencies near zero, representing rigid body motions.
- Constrained (Fixed-Supported) Boundary: This condition aims to simulate the actual mounting and interaction conditions within the rotary vector reducer as closely as possible.
- For the crankshaft, cylindrical support constraints were applied on the outer surfaces of the two bearing journals where it connects to the planet carrier. Only 180 degrees of the cylindrical surface was constrained in the radial direction to approximate real bearing contact.
- For the planet carrier, multiple constraints were applied: (a) Cylindrical supports on the inner surfaces of the three bearing bores that house the crankshaft bearings (radial constraint). (b) Fixed supports on the axial faces adjacent to these bores to simulate the locating effect of snap rings. (c) Cylindrical supports on the outer cylindrical surfaces of the carrier where it interfaces with the main bearings in the cycloid housing (radial and axial constraints).
Modal Solution Settings
The Block Lanczos eigenvalue extraction method was employed due to its efficiency and reliability for large models. For the free-free analysis, the first fifteen (15) modes were extracted to capture several flexible body modes beyond the initial rigid body modes. For the constrained analysis, the first ten (10) modes were calculated, as these represent the practically significant vibration modes under operating conditions.
Modal Analysis Results and Discussion for the Crankshaft Assembly
Free-Free Boundary Condition Results
The first fifteen natural frequencies of the crankshaft-planetary gear assembly under free-free conditions are listed in the table below. Modes 1 through 6 are rigid body modes with frequencies very close to zero and are not considered in the flexible mode analysis.
| Mode Order | Natural Frequency (Hz) | Description of Dominant Deformation (Mode Shape) |
|---|---|---|
| 1-3 | ≈ 0 | Rigid Body Translation |
| 4-6 | ≈ 0 | Rigid Body Rotation |
| 7 | 2,759.5 | First bending of crankshaft arms; axial rocking of planetary gear. |
| 8 | 2,763.3 | Complex torsion combined with planetary gear sway. |
| 9 | 4,187.1 | Second-order bending of crankshaft; radial deformation of gear teeth. |
| 10 | 6,379.8 | Higher-order torsional-bending coupling. |
| 11 | 6,746.9 | Planetary gear disk-mode deformation. |
| 12 | 6,748.1 | Similar to mode 11, with phase difference. |
| 13 | 9,417.6 | Complex three-dimensional deformation of gear teeth and shaft ends. |
| 14 | 9,460.0 | High-frequency bending of crankshaft arms. |
| 15 | 14,239 | Localized vibration at extreme ends and gear tooth tips. |
Analysis of the mode shapes (e.g., modes 7 and 13) reveals that the maximum displacement consistently occurs at the tips of the planetary gear teeth and the free ends of the crankshaft. This identifies these regions as areas of relatively lower stiffness and potential vulnerability to dynamic stresses. The gear teeth, in particular, undergo significant radial and axial deformation in higher modes, which could influence meshing dynamics and noise generation in the rotary vector reducer.
Constrained Boundary Condition Results
Applying the bearing support constraints significantly alters the dynamic signature of the crankshaft assembly. The results for the first ten flexible modes are presented below.
| Mode Order | Natural Frequency (Hz) | Description of Dominant Deformation (Mode Shape) |
|---|---|---|
| 1 | 1,910.9 | First bending mode of the supported shaft; planetary gear tilting. |
| 2 | 1,953.3 | Torsional vibration about the shaft axis; gear teeth distortion. |
| 3 | 4,244.6 | Second-order bending with node near mid-span. |
| 4 | 4,876.4 | Coupled bending and gear disk mode. |
| 5 | 5,266.7 | Pronounced radial deformation (ovalization) of planetary gear. |
| 6 | 5,223.2 | Complex deformation involving multiple gear teeth. |
| 7 | 6,849.2 | Third-order bending of the shaft. |
| 8 | 6,849.3 | High-frequency localized gear tooth bending. |
| 9 | 14,446 | Very high-frequency local mode at shaft ends and tooth roots. |
Under constrained conditions, the lower-frequency modes (1 and 2, around 1.9 kHz) become critically important as they fall within a range more likely to be excited by operational forces. The mode shapes confirm that the planetary gear remains the primary source of flexibility, exhibiting significant radial (ovalization) and torsional deformations. The maximum displacement is still concentrated on the gear tooth profiles.
Resonance Risk Assessment for Crankshaft
A primary source of excitation in the first stage of a rotary vector reducer is the meshing frequency of the input sun gear and the planetary gears. The meshing frequency $f_m$ is calculated by:
$$ f_m = \frac{n \cdot z}{60} $$
where $n$ is the rotational speed of the input shaft in RPM, and $z$ is the number of teeth on the sun gear. For a typical high-performance application with an input speed of $n = 3,500$ RPM and a sun gear with $z = 22$ teeth, the meshing frequency is:
$$ f_m = \frac{3500 \times 22}{60} \approx 1283.3 \text{ Hz} $$
Comparing this excitation frequency with the constrained-mode natural frequencies of the crankshaft assembly reveals no direct coincidence. The first constrained natural frequency (~1910 Hz) is about 49% higher than the meshing frequency. However, the proximity warrants attention. Harmonic excitations at multiples of the meshing frequency (e.g., $2f_m \approx 2566$ Hz) or sidebands due to modulation could potentially interact with higher-order modes. While a clear resonance condition is not predicted at the fundamental meshing frequency, the analysis suggests that the gear mesh dynamics are a dominant factor, and the stiffness of the planetary gear teeth is a critical design parameter for the rotary vector reducer.
Modal Analysis Results and Discussion for the Planet Carrier
Free-Free Boundary Condition Results
The planet carrier, being a larger and more complex structure, exhibits a different set of dynamic characteristics. Its first fifteen natural frequencies under free-free conditions are as follows.
| Mode Order | Natural Frequency (Hz) | Description of Dominant Deformation (Mode Shape) |
|---|---|---|
| 1-6 | ≈ 0 | Rigid Body Modes |
| 7 | 2,635.8 | First overall bending of the carrier arms/disk. |
| 8 | 2,635.9 | Torsional deformation about the central axis. |
| 9 | 2,808.7 | Warping of the carrier disk. |
| 10 | 3,703.3 | Second-order bending with deformation at the outer rim. |
| 11 | 3,704.0 | Radial expansion/contraction of the outer rim. |
| 12 | 4,131.3 | Complex deformation involving the bearing boss flexure. |
| 13 | 4,131.4 | Localized bending of individual arms. |
| 14 | 4,374.5 | Combined radial and axial vibration of the outer edge. |
| 15 | 4,576.8 | High-frequency local modes at sharp geometry transitions. |
The mode shapes (e.g., modes 8 and 14) consistently show that the maximum displacement occurs at the outermost edges of the carrier structure, particularly at the tips of the arms and the peripheral rim. This indicates that these areas are the most flexible parts of the carrier and are likely to experience the highest dynamic strain during operation of the rotary vector reducer.
Constrained Boundary Condition Results
Applying the realistic bearing and interface constraints drastically increases the stiffness and natural frequencies of the planet carrier. The results for the first ten modes are summarized below.
| Mode Order | Natural Frequency (Hz) | Description of Dominant Deformation (Mode Shape) |
|---|---|---|
| 1 | 2,068.8 | Radial “breathing” mode of the carrier disk. |
| 2 | 2,668.2 | Axial rocking/tilting of the entire carrier structure. |
| 3 | 2,980.8 | First bending of the carrier arms relative to the constrained hub. |
| 4 | 4,215.3 | Torsional deformation about the central axis. |
| 5 | 4,524.9 | Second-order bending with significant rim deflection. |
| 6 | 4,829.0 | Local deformation around the bearing boss areas. |
| 7 | 5,460.8 | Complex coupled mode involving multiple arms. |
| 8 | 5,923.9 | High-frequency bending of individual arms. |
| 9 | 6,433.3 | Warping and radial vibration of the outer rim. |
| 10 | 6,570.6 | Very localized vibration at sharp corners and edges. |
The constrained modes confirm that the outer edges and arms of the planet carrier remain the primary loci of deformation. The fundamental constrained frequency (~2069 Hz) is significantly higher than the first-stage gear meshing frequency (1283 Hz), suggesting a low risk of direct resonance from this source. However, these modes could be excited by forces transmitted through the crankshafts or from the second-stage cycloidal disc meshing.
Resonance and System Interaction Assessment
To fully assess resonance risk, the component frequencies must be compared not only to mesh frequencies but also to the global modes of the assembled rotary vector reducer. Literature reports the first nine global natural frequencies of an assembled RV reducer to be approximately: 75 Hz, 135 Hz, 136 Hz, 178 Hz, 426 Hz, 452 Hz, 844 Hz, 847 Hz, and 1163 Hz. Comparing these system-level frequencies with the constrained modes of both the crankshaft (>1900 Hz) and the planet carrier (>2000 Hz) shows a substantial gap. This indicates that the primary components, as individual entities, are unlikely to be excited into resonance by the dominant low-frequency global modes of the complete rotary vector reducer assembly. This is a positive finding for the basic structural design. However, the identified component modes in the 2-7 kHz range represent local vibrations that could contribute to high-frequency noise or influence localized stress conditions, even if they do not cause full-system resonance.
Conclusions and Implications for Design Optimization
This comprehensive finite element modal analysis has successfully characterized the inherent dynamic properties of two critical components within a rotary vector reducer: the integrated crankshaft-planetary gear assembly and the planet carrier. The study was conducted under both free and constrained boundary conditions, providing a complete picture of their vibrational behavior.
The key findings and their implications are summarized as follows:
- Resonance Avoidance: The constrained natural frequencies of both major components lie significantly above the fundamental gear meshing frequency of the first transmission stage (~1283 Hz) and the reported low-frequency global modes of the assembled rotary vector reducer. This suggests that the basic design possesses a good margin against catastrophic resonant conditions during typical operation. However, the proximity of the first crankshaft constrained mode (~1910 Hz) to the second harmonic of the meshing frequency warrants consideration in high-precision or high-speed applications.
- Identification of Structural Weak Points: The mode shape analysis consistently identified specific areas as foci of maximum displacement and, therefore, relatively lower dynamic stiffness:
- For the Crankshaft Assembly: The tips and profiles of the planetary gear teeth, along with the free ends of the crankshaft, are the most vulnerable regions. Deformation here can directly affect meshing accuracy, load distribution, and noise generation.
- For the Planet Carrier: The outermost peripheral rim and the tips of the support arms are the primary flexible zones. Dynamic deflection in these areas could affect the alignment and loading of the crankshaft bearings and the output interface.
- Value of Constrained Analysis: The comparison between free and constrained results highlights the critical importance of applying realistic boundary conditions. The constrained frequencies and mode shapes are far more representative of the component’s behavior within the operating environment of the rotary vector reducer and should form the primary basis for design decisions.
- Guidance for Structural Optimization: The results provide clear targets for design enhancement:
- The stiffness of the planetary gear teeth could be improved through profile optimization (e.g., considering tip relief, root fillet optimization) or material selection, potentially shifting its local modes to higher frequencies.
- The design of the planet carrier could be reinforced at its outer edges. This might involve adding subtle ribs, increasing the rim thickness, or using a more optimized geometric contour to increase its natural frequencies without adding excessive mass. Optimizing the transition geometry at the base of the arms can also reduce stress concentrations identified in high-frequency local modes.
In conclusion, this modal simulation analysis serves as a powerful virtual prototyping tool. It validates the fundamental dynamic integrity of the rotary vector reducer components while pinpointing precise areas for potential refinement. By integrating these findings into an iterative design process, engineers can develop more robust, reliable, and quiet rotary vector reducers, ultimately enhancing the performance and longevity of the advanced robotic systems that depend on them.