
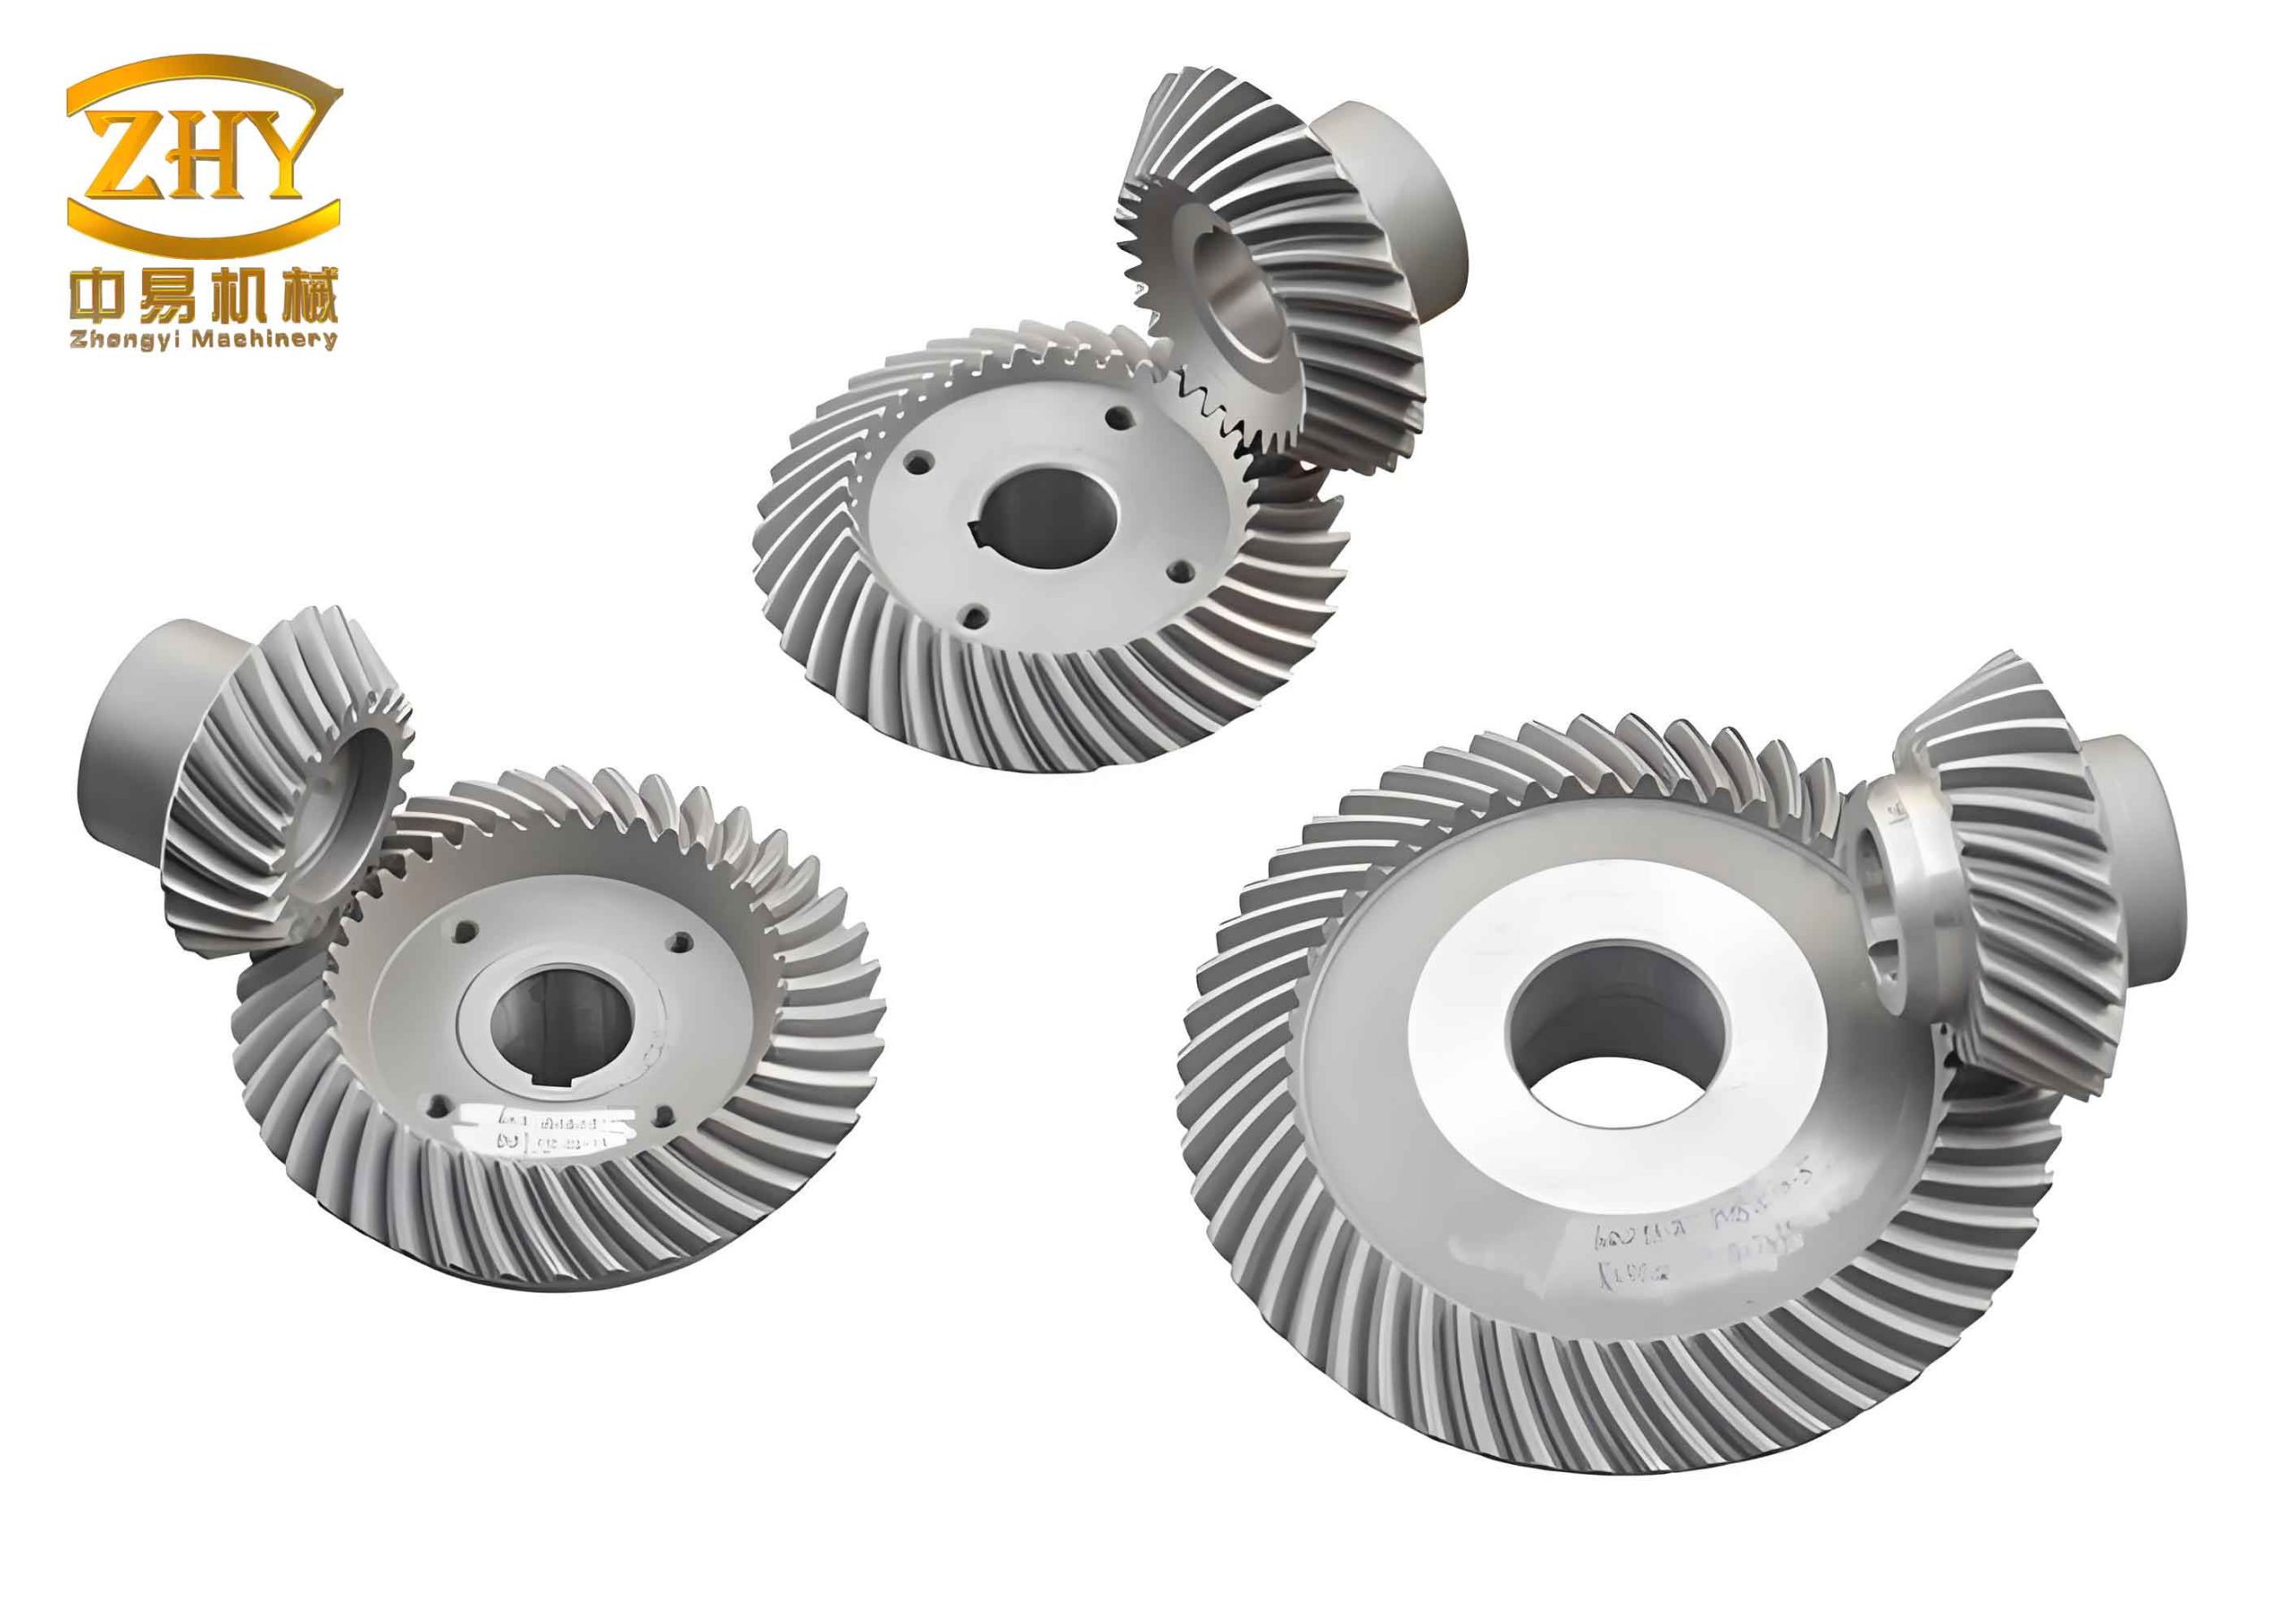
In the field of gear transmission technology, the precise control of tooth surface engagement performance has long been a critical research focus. For hyperboloidal gears, which are widely used in automotive and industrial applications due to their ability to transmit motion between non-intersecting axes, achieving optimal contact patterns and load distribution is essential for durability, efficiency, and noise reduction. Traditional design methods often rely on trial-and-error adjustments, but a more systematic approach—known as function-oriented design or active design of point-contact tooth surfaces—offers a robust framework for tailoring gear performance. This method involves defining the first tooth surface (typically the gear, or larger wheel) and then deriving the second tooth surface (the pinion, or smaller wheel) based on desired contact characteristics. In this article, I will present a comprehensive technical platform for the function-oriented design of point-contact tooth surfaces for hyperboloidal gears, with a focus on gears generated using a three-axis CNC bevel gear machine. This platform aims to facilitate practical applications and enable deeper research into hyperboloidal gear technology.
The foundation of function-oriented design lies in the mathematical modeling of the gear tooth surface. For hyperboloidal gears, the gear tooth surface can be generated either by forming or generating methods. When the gear’s pitch cone angle is less than 70°, generating methods are necessary, making this study particularly relevant. I will base my discussion on a three-axis CNC bevel gear machine, which provides flexibility in controlling tooth surface geometry through coordinated movements along three axes: the rotational axis of the workpiece (A-axis) and two translational axes (x and y) for the cutter head. This setup allows for a generalized mathematical model that can also accommodate traditional cradle-type machines by imposing specific motion constraints. The key advantage of this model is its universality, enabling the design of hyperboloidal gears with various generation types.
To begin, let me establish the coordinate systems and parameters for the gear generation process. Consider a three-axis CNC bevel gear machine with a machine coordinate system Oxyz. The workpiece gear is mounted on the A-axis, which coincides with the z₂-axis of a gear coordinate system O₂x₂y₂z₂ fixed to the gear. The cutter head, equipped with a blade having a profile angle α₀₂ and tip radius r₀₂, moves along the x and y axes. The installation parameters include the distance d₀₂ from the gear’s pitch cone vertex O₂ to the machine origin O, and the installation angle γ. The center of the cutter head Oc has coordinates (xoc, yoc, zoc) in the machine system, where xoc and yoc are functions of the gear rotation angle φ₂, defining the generation motion. For hyperboloidal gears, these functions can be tailored to achieve desired tooth surface properties, making the design process active rather than passive.
The generated gear tooth surface Σ⁽²⁾ (where superscript (2) denotes the gear) is described by a position vector r⁽²⁾ in the gear coordinate system O₂x₂y₂z₂. Based on the machine kinematics, the coordinates of any point on Σ⁽²⁾ are given by:
$$ r^{(2)} = x_2 \mathbf{i}_2 + y_2 \mathbf{j}_2 + z_2 \mathbf{k}_2 $$
with:
$$ x_2 = -x^{(c)} \sin \gamma \sin \varphi_2 + y^{(c)} \cos \varphi_2 + z^{(c)} \cos \gamma \sin \varphi_2 $$
$$ y_2 = -x^{(c)} \sin \gamma \cos \varphi_2 – y^{(c)} \sin \varphi_2 + z^{(c)} \cos \gamma \cos \varphi_2 $$
$$ z_2 = x^{(c)} \cos \gamma + z^{(c)} \sin \gamma – d_{02} $$
Here, (x⁽ᶜ⁾, y⁽ᶜ⁾, z⁽ᶜ⁾) are coordinates in a cutter coordinate system, expressed as:
$$ x^{(c)} = x_{oc} + r_c \cos \theta_c $$
$$ y^{(c)} = y_{oc} + r_c \sin \theta_c $$
$$ z^{(c)} = z_{oc} + \frac{r_c – r_{02}}{2 \tan \alpha_{02}} $$
where rc and θc are radial and angular parameters on the cutter blade surface. The parameter rc is derived from the generation conditions and can be expressed as:
$$ r_c = \frac{r_{02}}{\tan \alpha_{02}} + \left( x_{oc} \tan \gamma – z_{oc} – \frac{dy_{oc}}{d\varphi_2} \frac{1}{\cos \gamma} \right) \frac{\sin \alpha_{02} \cos \alpha_{02}}{2} – \left( y_{oc} \tan \gamma + \frac{dx_{oc}}{d\varphi_2} \frac{1}{\cos \gamma} \right) \frac{\sin \alpha_{02} \cos \alpha_{02}}{2} \cos \theta_c – y_{oc} \sin^2 \alpha_{02} \sin \theta_c $$
This formulation captures the influence of machine settings and cutter geometry on the tooth surface of hyperboloidal gears. The unit normal vector e⁽²⁾n at any point on Σ⁽²⁾ is crucial for contact analysis and is given by:
$$ \mathbf{e}^{(2)}_n = e^{(2)}_{nx2} \mathbf{i}_2 + e^{(2)}_{ny2} \mathbf{j}_2 + e^{(2)}_{nz2} \mathbf{k}_2 $$
with components:
$$ e^{(2)}_{nx2} = -e^{(c)}_{nx} \sin \gamma \sin \varphi_2 + e^{(c)}_{ny} \cos \varphi_2 + e^{(c)}_{nz} \cos \gamma \sin \varphi_2 $$
$$ e^{(2)}_{ny2} = -e^{(c)}_{nx} \sin \gamma \cos \varphi_2 – e^{(c)}_{ny} \sin \varphi_2 + e^{(c)}_{nz} \cos \gamma \cos \varphi_2 $$
$$ e^{(2)}_{nz2} = e^{(c)}_{nx} \cos \gamma + e^{(c)}_{nz} \sin \gamma $$
where the cutter normal vector components are:
$$ e^{(c)}_{nx} = -\cos \alpha_{02} \cos \theta_c $$
$$ e^{(c)}_{ny} = -\cos \alpha_{02} \sin \theta_c $$
$$ e^{(c)}_{nz} = \sin \alpha_{02} $$
Furthermore, second-order parameters such as normal curvatures and geodesic torsion are essential for predicting contact ellipse dimensions and orientation. For hyperboloidal gears, these parameters on Σ⁽²⁾ can be derived from the cutter surface parameters and machine kinematics. Specifically, the normal curvature κ⁽²⁾n1 along one principal direction is:
$$ \kappa^{(2)}_{n1} = \kappa^{(c)}_{n1} – \frac{(\mathbf{P}_{02} \cdot \mathbf{e}_{t1})^2}{2(\mathbf{e}_n \cdot \mathbf{q}_{02} + \mathbf{P}_{02} \cdot \mathbf{v}^{(c2)})} $$
and along the other principal direction:
$$ \kappa^{(2)}_{n2} = \kappa^{(c)}_{n2} – \frac{(\mathbf{P}_{02} \cdot \mathbf{e}_{t2})^2}{2(\mathbf{e}_n \cdot \mathbf{q}_{02} + \mathbf{P}_{02} \cdot \mathbf{v}^{(c2)})} $$
The geodesic torsion τ⁽²⁾g1 is:
$$ \tau^{(2)}_{g1} = \tau^{(c)}_{g1} – \frac{(\mathbf{P}_{02} \cdot \mathbf{e}_{t1})(\mathbf{P}_{02} \cdot \mathbf{e}_{t2})}{2(\mathbf{e}_n \cdot \mathbf{q}_{02} + \mathbf{P}_{02} \cdot \mathbf{v}^{(c2)})} $$
In these equations, v⁽ᶜ²⁾ represents the relative velocity between cutter and gear, ω⁽²⁾ is the gear angular velocity vector, and P02 and q02 are terms involving derivatives of machine motions. For instance:
$$ \mathbf{v}^{(c2)} = \omega_2 \left( \frac{dx_{oc}}{d\varphi_2} + y^{(c)} \sin^2 \gamma \right) \mathbf{i} + \left( \frac{dy_{oc}}{d\varphi_2} – x^{(c)} \sin \gamma + z^{(c)} \cos^2 \gamma \right) \mathbf{j} – y^{(c)} \cos \gamma \, \gamma \mathbf{k} $$
and
$$ \mathbf{P}_{02} = \kappa^{(c)}_{nv} \mathbf{v}^{(c2)} + \tau^{(c)}_{gv} \mathbf{e}_n \times \mathbf{v}^{(c2)} + \mathbf{e}_n \times \boldsymbol{\omega}^{(2)} $$
with ω⁽²⁾ = ω₂(cos γ i + sin γ k). The term q02 accounts for second derivatives of xoc and yoc with respect to φ₂. These formulas provide a complete set for characterizing the geometry of generated gear tooth surfaces for hyperboloidal gears, enabling precise control in design.
Moving to the core of function-oriented design, the goal is to determine the pinion tooth surface Σ⁽¹⁾ such that it engages with the gear tooth surface Σ⁽²⁾ at a prescribed set of points, forming a point-contact pattern with desired transmission characteristics. This requires defining a locus of contact points on Σ⁽²⁾, often called the contact path or contact point trajectory. For hyperboloidal gears, this locus is typically a space curve, but it can be conveniently described in a rotated projection coordinate system aligned with the gear axis. Let O₂ρszs be this system, where ρs is the radial coordinate and zs is the axial coordinate, rotated by the gear pitch angle δ₂. The transformation from gear coordinates (x₂, y₂, z₂) is:
$$ \rho_s = \sqrt{x_2^2 + y_2^2} \sin \delta_2 + z_2 \cos \delta_2 $$
$$ z_s = -\sqrt{x_2^2 + y_2^2} \cos \delta_2 + z_2 \sin \delta_2 $$
The contact point locus on Σ⁽²⁾ is then expressed as a function f₂(ρs, zs) = 0. For example, a straight line in this plane can be set as f₂(ρs, zs) = ρs + zs tan λ – ρs0 – zs0 tan λ = 0, where λ is the angle relative to the tooth height direction, and (ρs0, zs0) is a reference point. This flexibility allows designers to tailor contact patterns for specific performance goals in hyperboloidal gears, such as optimizing load distribution or minimizing sensitivity to misalignment.
To design Σ⁽¹⁾, the unit tangent vector e⁽²⁾t along the contact point locus on Σ⁽²⁾ must be computed. This vector is derived from the derivative of r⁽²⁾ with respect to φ₂, considering the implicit dependence via θc from the locus equation. Specifically:
$$ \mathbf{e}^{(2)}_t = \frac{d\mathbf{r}^{(2)}}{d\varphi_2} \bigg/ \left\| \frac{d\mathbf{r}^{(2)}}{d\varphi_2} \right\| $$
where
$$ \frac{d\mathbf{r}^{(2)}}{d\varphi_2} = \left( \frac{\partial x_2}{\partial \varphi_2} + \frac{\partial x_2}{\partial \theta_c} \cdot \frac{d\theta_c}{d\varphi_2} \right) \mathbf{i}_2 + \left( \frac{\partial y_2}{\partial \varphi_2} + \frac{\partial y_2}{\partial \theta_c} \cdot \frac{d\theta_c}{d\varphi_2} \right) \mathbf{j}_2 + \left( \frac{\partial z_2}{\partial \varphi_2} + \frac{\partial z_2}{\partial \theta_c} \cdot \frac{d\theta_c}{d\varphi_2} \right) \mathbf{k}_2 $$
The derivative dθc/dφ₂ is obtained from the implicit function f₂(ρs, zs) = 0 using the chain rule:
$$ \frac{d\theta_c}{d\varphi_2} = -\frac{\partial f_2}{\partial \varphi_2} \bigg/ \frac{\partial f_2}{\partial \theta_c} $$
with partial derivatives:
$$ \frac{\partial f_2}{\partial \varphi_2} = \frac{\partial f_2}{\partial \rho_s} \cdot \frac{\partial \rho_s}{\partial \varphi_2} + \frac{\partial f_2}{\partial z_s} \cdot \frac{\partial z_s}{\partial \varphi_2} $$
$$ \frac{\partial f_2}{\partial \theta_c} = \frac{\partial f_2}{\partial \rho_s} \cdot \frac{\partial \rho_s}{\partial \theta_c} + \frac{\partial f_2}{\partial z_s} \cdot \frac{\partial z_s}{\partial \theta_c} $$
The terms ∂ρs/∂φ₂, ∂ρs/∂θc, ∂zs/∂φ₂, and ∂zs/∂θc are computed from the coordinate transformations and gear surface equations. For instance:
$$ \frac{\partial \rho_s}{\partial \varphi_2} = \frac{\partial \rho_s}{\partial x_2} \cdot \frac{\partial x_2}{\partial \varphi_2} + \frac{\partial \rho_s}{\partial y_2} \cdot \frac{\partial y_2}{\partial \varphi_2} + \frac{\partial \rho_s}{\partial z_2} \cdot \frac{\partial z_2}{\partial \varphi_2} $$
$$ \frac{\partial \rho_s}{\partial \theta_c} = \frac{\partial \rho_s}{\partial x_2} \cdot \frac{\partial x_2}{\partial \theta_c} + \frac{\partial \rho_s}{\partial y_2} \cdot \frac{\partial y_2}{\partial \theta_c} + \frac{\partial \rho_s}{\partial z_2} \cdot \frac{\partial z_2}{\partial \theta_c} $$
and similarly for zs. The partial derivatives of x₂, y₂, z₂ with respect to φ₂ and θc can be derived from the earlier surface equations. Once e⁽²⁾t is determined, the pinion tooth surface parameters can be designed using the fundamental equations of point-contact tooth surface theory. These include the contact condition, transmission law, and curvature requirements to achieve a specific contact ellipse size. For hyperboloidal gears, the transmission law might be expressed as φ₂ = φ₂₀ – (z₁/z₂) φ₁ + Δ(φ₁), where z₁ and z₂ are tooth numbers, and Δ(φ₁) is a correction function for optimizing motion transfer. The contact ellipse dimensions are related to the relative curvatures of the two surfaces at the contact point, with the major axis length l often specified as a design target (e.g., l = 10 mm).
To illustrate the application of this methodology, I will provide a detailed design example for a pair of hyperboloidal gears. The gear set has an axis angle of 90°, an offset distance of 34 mm, and geometric parameters as summarized in the table below. The gear is generated on a three-axis CNC machine with specific installation settings and cutter parameters.
| Parameter | Gear (Wheel 2) | Pinion (Wheel 1) |
|---|---|---|
| Number of Teeth (z) | 43 | 11 |
| Normal Pressure Angle (α) [°] | 18 | 18 |
| Pitch Cone Angle (δ) [°] | 75 | 14.0114 |
| Face Cone Angle (δa) [°] | 75.7874 | 18.3332 |
| Root Cone Angle (δf) [°] | 70.4294 | 13.3837 |
| Mean Spiral Angle (β) [°] | 28.6300 (right) | 50 (left) |
| Mean Cone Distance (Rm) [mm] | 91.1043 | 126.9550 |
| Mean Addendum (ha) [mm] | 1.2519 | 6.1123 |
| Mean Dedendum (hf) [mm] | 7.2670 | 2.4066 |
The generation parameters for the gear tooth surface are: d₀₂ = 0.0169 mm, γ = 70.4294°, r₀₂ = 95.25 mm, and cutter center coordinates as functions of φ₂:
$$ x_{oc} = 91.7042 \cos\left( \frac{\varphi_2}{1.0394} + 58.5241 \right) – 3.4365 $$
$$ y_{oc} = 91.7042 \sin\left( \frac{\varphi_2}{1.0394} + 58.5241 \right) + 4.9921 $$
$$ z_{oc} = 9.666 $$
For the function-oriented design, the contact point locus on the gear tooth surface is set as a straight line with λ = 60° and reference point (ρs0, zs0) = (91.1043 mm, 3.0 mm). The transmission law is specified as φ₂ = φ₂₀ – (11/43) φ₁ – 0.002 φ₁², and the contact ellipse major axis length is l = 10 mm. Using the derived formulas, the pinion tooth surface parameters are computed at multiple points along the contact path. Below is a subset of results showing the position vector r⁽¹⁾, unit normal vector e⁽¹⁾n, and principal directions and curvatures for the pinion concave side (drive side).
| Point | Position Vector r⁽¹⁾ (mm) | Unit Normal e⁽¹⁾n | Principal Direction e⁽¹⁾1 | Principal Direction e⁽¹⁾2 | Normal Curvature κ⁽¹⁾1 (mm⁻¹) | Normal Curvature κ⁽¹⁾2 (mm⁻¹) |
|---|---|---|---|---|---|---|
| 1 | (106.508, -42.606, -4.850) | (-0.034752, -0.163586, 0.985916) | (0.352967, -0.924946, -0.141028) | (0.934990, 0.343095, 0.089885) | 0.000468 | -0.001448 |
| 2 | (75.247, -33.499, -3.255) | (-0.024495, -0.163726, 0.986202) | (0.428640, -0.892936, -0.137596) | (0.903143, 0.419355, 0.092052) | 0.000480 | -0.001393 |
| 3 | (112.997, -6.458, 1.256) | (0.000212, -0.160701, 0.987003) | (0.624609, -0.770966, -0.125628) | (0.780937, 0.616518, 0.100212) | 0.000544 | -0.001216 |
These results demonstrate the effectiveness of the function-oriented design approach for hyperboloidal gears. The pinion surface is derived to ensure point contact along the prescribed path with the desired transmission behavior and contact ellipse size. This methodology can be extended to other generation types, such as those on traditional cradle machines, by adapting the functions for xoc and yoc. For instance, in a cradle-type machine, xoc and yoc might follow a circular path relative to a cradle angle, but the same mathematical framework applies by substituting the appropriate kinematic relationships. This universality makes the platform valuable for both modern CNC and conventional hyperboloidal gear production.
In addition to the core design formulas, several practical considerations enhance the applicability of this platform for hyperboloidal gears. First, the choice of contact point locus significantly influences gear performance. A straight line locus, as in the example, often provides a balanced compromise between load capacity and alignment sensitivity. However, curves such as parabolas or splines can be used to optimize stress distribution or noise characteristics. The function f₂(ρs, zs) can be defined numerically or analytically, allowing designers to experiment with different patterns through simulation. Second, the transmission law correction term Δ(φ₁) can be optimized to minimize transmission error, a key factor in noise and vibration reduction for hyperboloidal gears. Techniques like polynomial fitting or finite element analysis can be integrated into the design loop. Third, the contact ellipse size and orientation depend on the relative curvatures, which are controlled via the second-order parameters of both surfaces. By adjusting machine settings or cutter geometry, designers can fine-tune these curvatures to achieve specific contact conditions, such as a larger ellipse for higher load capacity or a more centralized pattern for better wear resistance.
To further elaborate on the mathematical derivations, let me discuss the computation of second-order parameters in more detail. For hyperboloidal gears, the normal curvature and geodesic torsion on the generated gear surface are derived from the cutter surface parameters and the kinematics of the generation process. The cutter surface, typically a conical surface, has known principal curvatures κ⁽ᶜ⁾n1 and κ⁽ᶜ⁾n2, and geodesic torsion τ⁽ᶜ⁾g1. During generation, the relative motion between cutter and gear induces additional curvature components. The formulas provided earlier account for this through terms involving P02 and q02. For example, P02 captures the effect of relative velocity and angular velocity on the surface normal, while q02 relates to accelerations in the machine motions. These terms ensure that the designed hyperboloidal gear tooth surface accurately reflects the manufacturing process, enabling predictable performance in service.
Another critical aspect is the numerical implementation of the design platform. Given the complexity of the equations, software tools are essential for practical application. I recommend developing algorithms that automate the following steps: (1) input gear geometric parameters and machine settings, (2) define the contact point locus f₂(ρs, zs) = 0, (3) compute the gear tooth surface coordinates and normals using the parametric equations, (4) derive the unit tangent vector e⁽²⁾t along the locus, (5) solve for pinion surface parameters based on contact conditions and transmission law, and (6) output pinion data for manufacturing. This process can be iterated to optimize performance, making it a powerful tool for hyperboloidal gear design. Additionally, the platform can be linked to finite element analysis (FEA) software to validate contact stresses and transmission error under load, closing the loop between design and verification.
The versatility of this approach extends beyond standard hyperboloidal gears to modified designs, such as those with non-uniform tooth profiles or asymmetric teeth for specialized applications. By adjusting the generation functions xoc(φ₂) and yoc(φ₂), designers can create tooth surfaces with localized corrections or optimized flank topography. This is particularly useful in high-performance automotive differentials or aerospace gearboxes, where weight reduction and efficiency are paramount. Moreover, the platform supports research into new gear types, such as hybrid hyperboloidal gears that combine elements of spiral bevel and hypoid gears, by allowing flexible definition of generation kinematics.
In conclusion, the function-oriented design of point-contact tooth surfaces for hyperboloidal gears, based on a generated gear model, offers a robust and universal framework for achieving desired transmission performance. The mathematical model built on three-axis CNC machine kinematics provides a foundation that accommodates various generation types, from modern CNC to traditional cradle machines. The derivation of explicit formulas for the contact point locus and unit tangent vector enables precise control over tooth surface engagement, facilitating active design rather than passive adjustment. The design example demonstrates the practical application, yielding pinion surface parameters that meet specified contact and transmission requirements. This platform not only simplifies the design process for hyperboloidal gears but also opens avenues for advanced research, such as integrating optimization algorithms or exploring novel gear geometries. As hyperboloidal gears continue to evolve in demanding applications, this methodology will play a key role in enhancing their performance, reliability, and manufacturability.
Future work could focus on expanding the platform to include dynamic analysis, thermal effects, and material considerations, further bridging the gap between design and real-world operation. Additionally, machine learning techniques could be employed to automate the selection of optimal contact paths and transmission laws based on performance datasets. By continuing to refine this technical platform, the gear industry can push the boundaries of what is possible with hyperboloidal gears, driving innovation in power transmission systems worldwide.