
The herringbone gear is widely recognized as a core transmission component in aviation engines, helicopters, vehicles, and other high-performance power transmission systems. Its unique herringbone structural configuration eliminates axial force, provides excellent load-carrying capacity, and ensures high transmission efficiency, outstanding structural stability, long service life, and broad load adaptability. In the context of modern high-speed and heavy-duty operating environments, however, the herringbone gear often encounters severe thermal and tribological challenges. Tooth surface failures such as pitting, scuffing, wear, and even tooth fracture are strongly related to the lubrication condition at the meshing interface. Therefore, understanding the lubrication characteristics of the herringbone gear under oil jet conditions is of great theoretical and engineering significance.
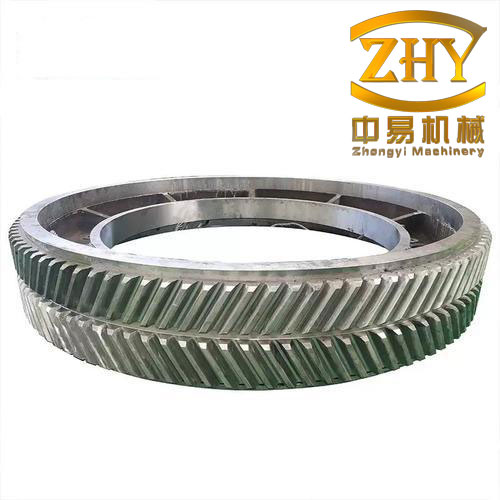
Oil jet lubrication is the preferred cooling and lubrication strategy for high-speed gear drives. In this process, a high-speed oil jet is directed toward the gear meshing zone. The impingement of the oil jet on the rapidly rotating tooth surfaces creates a complex gas-liquid two-phase flow field. The oil performs two main functions: reducing the friction between mating tooth surfaces and dissipating the heat generated within the meshing contact. The performance of the lubrication system strongly depends on injection parameters such as injection velocity, gear rotational speed, injection distance, and nozzle configuration. Consequently, this study focuses on the multiphase flow behavior and thermal characteristics of the high-speed herringbone gear under oil jet lubrication. The research aims to provide a systematic design methodology for oil jet parameters to achieve superior lubrication and cooling performance.
The work presented in this thesis is organized as follows. First, a three-dimensional model of the herringbone gear is created, and drum-shaped modification is introduced to improve the meshing behavior. A computational fluid dynamics (CFD) model of the herringbone gear pair is then constructed, and the multiphase mathematical model is established. Second, the influence of single injection parameters on the lubricating oil film thickness is investigated, and the optimal oil injection method is determined by comparing the jet trajectory on the incoming and outgoing mesh sides. Third, the coupling effects of injection velocity, gear speed, and injection distance on the oil-air ratio and the total gas-liquid pressure in the meshing region are systematically evaluated. Fourth, the temperature field of the herringbone gear is computed on the basis of friction heat generation analysis, and the convective heat transfer coefficient of the tooth surfaces under different injection conditions is examined. Finally, an experimental test rig is developed to validate the numerical simulations and to further reveal the lubrication and cooling behavior of the high-speed herringbone gear.
Computational Fluid Dynamics Simulation Model of the Herringbone Gear
Herringbone Gear Modeling and Contact Analysis
The herringbone gear used in this study is composed of two opposite-handed helical gears integrated into a single gear blank. The basic geometric parameters of the gear pair are provided in Table 1. The active gear has 40 teeth while the driven gear has 37 teeth. The normal module is 3.5 mm, and the normal pressure angle is 23°. The helix angle is 27.5°, and the gear width is 60 mm. The center distance between the two gears is 170.42 mm. The gear material is 18CrNiMo7-6, with a density of 7870 kg/m³, specific heat capacity of 460 J/(kg·K), and thermal conductivity of 38 W/(m·K).
| Parameter | Value |
|---|---|
| Number of teeth of driving gear | 40 |
| Number of teeth of driven gear | 37 |
| Normal module (mm) | 3.5 |
| Normal pressure angle (°) | 23 |
| Helix angle (°) | 27.5 |
| Face width (mm) | 60 |
| Center distance (mm) | 170.42 |
| Addendum coefficient | 1.297 |
| Tip clearance coefficient | 0.25 |
| Transverse pressure angle (°) | 25.573 |
| Density (kg/m³) | 7870 |
| Specific heat capacity (J/(kg·K)) | 460 |
| Thermal conductivity (W/(m·K)) | 38 |
| Elastic modulus (Pa) | 2.1 × 10¹¹ |
| Poisson’s ratio | 0.30 |
To improve the tooth contact behavior and reduce the sensitivity to manufacturing and assembly errors, the herringbone gear is modified with a drum-shaped profile in the lengthwise direction. A modification amount of 20 µm is applied. The drum-shaped modification transforms the ideal line contact into a localized point-like contact pattern, thereby reducing stress concentration and improving the lubrication condition at the tooth edges.
The contact analysis of the herringbone gear is performed to provide input parameters for subsequent friction heat calculations. The time-varying contact line length in the meshing zone is expressed as a piecewise function of the meshing position. In the case of \(\varepsilon_\alpha > \varepsilon_\beta\), the contact line length can be represented by the following relationships:
$$
l_i =
\begin{cases}
\dfrac{s_i}{\sin\beta_b}, & 0 \le s_i < p_{bt} \\[6pt]
\dfrac{B}{\cos\beta_b}, & p_{bt} \le s_i < \varepsilon_\beta p_{bt} \\[6pt]
\dfrac{s_i + B – L_0 \tan\beta_b}{\sin\beta_b}, & \varepsilon_\beta p_{bt} \le s_i < (\varepsilon_\alpha + \varepsilon_\beta) p_{bt} \\[6pt]
0, & s_i \ge (\varepsilon_\alpha + \varepsilon_\beta) p_{bt}
\end{cases}
$$
where \(B\) is the gear width, \(\beta_b\) is the base helix angle, and \(p_{bt}\) is the transverse base pitch. The total mesh line length is obtained by summing up the individual contact line segments. The curvature radii of the two tooth surfaces along the contact line direction and the equivalent curvature radius are then calculated. The entrainment velocity at any meshing point is obtained from the angular velocities of the driving and driven gears:
$$
U = \frac{U_1 + U_2}{2}
$$
where \(U_1 = \omega_1 R_{x1}\) and \(U_2 = \omega_2 R_{x2}\) are the rolling velocities of the driving and driven gears at the mesh point, respectively. The normal contact force on a single tooth in mesh is determined through the load-sharing ratio:
$$
F_{ni} = \gamma F_n, \qquad \gamma = \frac{l_i}{L}
$$
where \(F_n\) is the total normal contact force, \(l_i\) is the instantaneous contact line length, and \(L\) is the total contact line length. In this study, the input power is 70 kW, and the driving gear rotational speed is 8000 r/min. The slide-roll ratio along the line of action is expressed as:
$$
s = \frac{|U_1 – U_2|}{U_{e}}
$$
The numerical results reveal that the slide-roll ratio is relatively high near the tooth root and tooth tip regions, while it approaches zero near the pitch point, indicating a nearly pure rolling state during the central phase of meshing.
Mathematical Model of Gas-Liquid Two-Phase Flow
The oil jet lubrication process involves high-speed interaction between the lubricating oil and the surrounding air. Therefore, a multiphase flow model is adopted to describe the gas-liquid mixture. The volume fraction conservation equation for the two-phase system is given by:
$$
r_o + r_a = 1
$$
where \(r_o\) and \(r_a\) represent the volume fractions of the oil and air phases, respectively. The continuity equation for each phase is:
$$
\frac{\partial}{\partial t} (r_o \rho_o) + \nabla \cdot (r_o \rho_o \mathbf{U}) = 0
$$
$$
\frac{\partial}{\partial t} (r_a \rho_a) + \nabla \cdot (r_a \rho_a \mathbf{U}) = 0
$$
The momentum conservation equation for the gas-liquid mixture is written as:
$$
\frac{\partial}{\partial t}(r_o \rho_o \mathbf{U}_o) + \nabla \cdot (r_o \rho_o \mathbf{U}_o \mathbf{U}_o) = -r_o \nabla p + \nabla \cdot \left[ r_o \mu_o (\nabla \mathbf{U}_o + \nabla \mathbf{U}_o^T) \right] + \mathbf{M}_o
$$
where \(\mathbf{M}_o\) represents the interfacial interaction forces between the oil and air phases. In the present simulation, the standard \(k-\varepsilon\) turbulence model is applied for the high-Reynolds-number jet and rotating flow. The turbulent kinetic energy \(k\) and its dissipation rate \(\varepsilon\) are solved from:
$$
\frac{\partial}{\partial t}(\rho k) + \nabla \cdot (\rho \mathbf{U} k) = \nabla \cdot \left[ \left(\mu + \frac{\mu_t}{\sigma_k}\right) \nabla k \right] + P_k – \rho \varepsilon
$$
$$
\frac{\partial}{\partial t}(\rho \varepsilon) + \nabla \cdot (\rho \mathbf{U} \varepsilon) = \nabla \cdot \left[ \left(\mu + \frac{\mu_t}{\sigma_\varepsilon}\right) \nabla \varepsilon \right] + C_{\varepsilon 1} \frac{\varepsilon}{k} P_k – C_{\varepsilon 2} \rho \frac{\varepsilon^2}{k}
$$
where \(\mu_t = \rho C_\mu k^2 / \varepsilon\), \(C_\mu = 0.09\), \(C_{\varepsilon 1} = 1.44\), and \(C_{\varepsilon 2} = 1.92\).
CFD Model Setup and Boundary Conditions
To avoid mesh distortion caused by the extremely small clearance at the gear meshing zone, the driven gear is shifted by a small amount along the line of centers while keeping all other dimensions unchanged. This approach is commonly referred to as the tooth-surface displacement method. The fluid domain is constructed based on the gear housing space and the oil jet region. The computational model includes the two gear bodies, the surrounding fluid domain, and the nozzle region. Unstructured tetrahedral meshes are generated, with refined grid sizes near the tooth surfaces and the nozzle. The final mesh consists of approximately 906,000 cells. The lubricating oil density is 860 kg/m³, the dynamic viscosity is 0.039 Pa·s, and the surface tension coefficient is 0.071 N/m. The gear tooth faces are set as no-slip rotating walls, while the nozzle outlet is defined as a velocity inlet. The remaining outer boundaries are set as open atmospheric conditions. A transient solver with a time step of \(1\times10^{-5}\) s is used, and the convergence residual level is set to \(1\times10^{-4}\).
Influencing Factors of Oil Jet Lubrication Effect on the Herringbone Gear
Selection of the Oil Injection Method
For a rotating herringbone gear, the oil jet can be directed either to the incoming mesh side or to the outgoing mesh side. The trajectory of the oil jet is strongly influenced by the rotating flow field. When the jet is directed to the incoming side, the oil jet gradually deflects with increasing gear speed. At low shaft speeds, the jet reaches the meshing zone easily; at high speeds, the jet is severely deflected, resulting in a significant reduction in the amount of oil entering the mesh. Conversely, when the gear speed is fixed, a higher injection velocity increases the momentum of the jet and reduces its deflection. Thus, the injection velocity and gear speed must be matched to achieve effective lubrication.
For the outgoing mesh side, the rotating flow field creates a counter-pressure against the jet. In many cases, especially at high speeds, the jet is completely reversed, leading to an almost oil-free meshing zone. This gas-barrier phenomenon indicates that the outgoing-side injection is unsuitable for high-speed herringbone gear lubrication. Based on comparative simulations of the oil volume fraction in the meshing region, the incoming-side injection method is selected for all subsequent analyses.
Oil Film Spreading on the Tooth Surface
The spreading of the oil film after jet impingement is a critical process that determines the amount of lubricant retained on the tooth surface. The spreading is governed by inertial forces, viscous forces, surface tension, and the dynamic behavior of the three-phase contact line. To validate the numerical approach, a numerical model of a single oil droplet impinging obliquely on a solid wall is created using the volume-of-fluid method. The computed film thickness evolution is compared with previously published experimental data. The agreement between the numerical and experimental results confirms the reliability and accuracy of the present simulation framework.
Based on this validated model, the oil film deposition and spreading process on the herringbone gear tooth surface is studied. The time-dependent film thickness at the meshing point is extracted. At the initial instant of impact, the film thickness reaches a maximum value of approximately 640 nm. As the oil film spreads outward, the thickness decreases and eventually stabilizes at about 67 nm after several milliseconds. This indicates that a thin lubricating film can be maintained on the tooth surface under the specified operating condition.
Single-Factor Analysis
To investigate the effect of individual injection parameters on the oil film thickness, a series of simulations are performed by varying one parameter while keeping the others constant. The results are summarized in Table 2.
| Parameter | Range | Effect on stabilized film thickness |
|---|---|---|
| Injection velocity | 24–40 m/s | Film thickness increases with injection velocity |
| Gear rotational speed | 4200–15400 r/min | Film thickness decreases with increasing speed |
| Injection distance | 28–76 mm | Minor effect on film thickness; only affects the initial spreading dynamics |
The simulation results show that increasing the injection velocity from 24 m/s to 40 m/s increases the amount of oil delivered to the tooth surface, thereby increasing the final film thickness. On the other hand, at higher gear speeds, the reduced residence time on the tooth surface leads to thinner oil films. The injection distance has a relatively minor influence on the equilibrium film thickness; however, it affects the arrival time of the oil jet and the dynamic spreading behavior. A moderate injection distance is recommended to avoid both oil starvation and obstruction of the jet by the rotating teeth.
Coupling Influence of Two Variables on the Lubrication Effect
In practical applications, multiple injection parameters act simultaneously. It is therefore necessary to analyze the coupling effects of injection velocity, gear speed, and injection distance on the lubrication quality of the herringbone gear. The oil-air ratio and the total gas-liquid pressure in the meshing zone are selected as evaluation criteria. A high oil-air ratio and a low total gas-liquid pressure are desirable for effective lubrication.
Coupling of Injection Velocity and Gear Speed
With the injection distance fixed at 56 mm, the oil-air ratio is computed for different combinations of injection velocity and gear speed. Table 3 presents the oil-air ratio values, and Table 4 presents the corresponding total gas-liquid pressures.
| Speed (r/min) | 24 m/s | 28 m/s | 32 m/s | 36 m/s | 40 m/s |
|---|---|---|---|---|---|
| 4200 | 24.56 | 24.98 | 25.23 | 25.99 | 26.40 |
| 7000 | 21.16 | 22.35 | 23.67 | 23.99 | 24.84 |
| 9800 | 19.68 | 20.05 | 21.39 | 21.96 | 23.31 |
| 12600 | 19.03 | 20.19 | 20.91 | 21.58 | 22.39 |
| 15400 | 17.30 | 17.98 | 18.83 | 19.27 | 20.84 |
| Speed (r/min) | 24 m/s | 28 m/s | 32 m/s | 36 m/s | 40 m/s |
|---|---|---|---|---|---|
| 4200 | 1987.82 | 3021.73 | 5063.97 | 6962.87 | 8054.23 |
| 7000 | 2450.52 | 3964.25 | 5445.63 | 7022.97 | 8705.65 |
| 9800 | 3123.27 | 4285.09 | 5831.78 | 7354.44 | 9603.21 |
| 12600 | 3507.92 | 4807.92 | 6470.06 | 7976.18 | 9914.89 |
| 15400 | 4723.42 | 5783.31 | 7098.47 | 8825.45 | 10189.24 |
It is observed that the oil-air ratio increases with increasing injection velocity and decreases with increasing gear speed. Conversely, the total gas-liquid pressure rises with both parameters. The highest oil-air ratio occurs at an injection velocity of 40 m/s and a gear speed of 4200 r/min, whereas the lowest pressure is found at the same low speed condition. These findings indicate that an appropriate reduction in gear speed and an increase in injection velocity can effectively improve the lubricant supply in the meshing zone of the herringbone gear.
Coupling of Injection Velocity and Injection Distance
When the gear speed is fixed at 8000 r/min, the oil-air ratio and total gas-liquid pressure are obtained for various injection velocities and distances. The results are listed in Tables 5 and 6.
| Distance (mm) | 24 m/s | 28 m/s | 32 m/s | 36 m/s | 40 m/s |
|---|---|---|---|---|---|
| 28 | 28.96 | 30.11 | 37.19 | 42.98 | 48.12 |
| 40 | 26.35 | 28.54 | 34.25 | 37.54 | 41.44 |
| 52 | 23.82 | 22.65 | 30.08 | 33.15 | 40.25 |
| 64 | 23.03 | 23.97 | 27.82 | 30.19 | 36.58 |
| 76 | 19.05 | 20.30 | 22.14 | 26.48 | 31.61 |
| Distance (mm) | 24 m/s | 28 m/s | 32 m/s | 36 m/s | 40 m/s |
|---|---|---|---|---|---|
| 28 | 2465.16 | 2868.72 | 3648.53 | 4209.84 | 5758.64 |
| 40 | 2156.75 | 2702.31 | 3559.48 | 3995.42 | 5569.34 |
| 52 | 2005.51 | 2465.41 | 3184.73 | 3526.68 | 4827.43 |
| 64 | 1694.28 | 2263.15 | 2711.59 | 3658.29 | 4758.69 |
| 76 | 1163.49 | 1755.28 | 2025.48 | 2891.57 | 3995.88 |
A shorter injection distance and a higher injection velocity are beneficial for increasing the oil-air ratio in the herringbone gear meshing zone. In particular, the combination of 40 m/s injection velocity and 28 mm injection distance yields the highest oil-air ratio (48.12%) and a moderate total gas-liquid pressure. This suggests that the nozzle should be placed as close as possible to the meshing zone without affecting the rotating tooth motion.
Coupling of Gear Speed and Injection Distance
With the injection velocity fixed at 35 m/s, the oil-air ratio and total gas-liquid pressure are computed for different gear speeds and injection distances. The results are shown in Tables 7 and 8.
| Distance (mm) | 4200 r/min | 7000 r/min | 9800 r/min | 12600 r/min | 15400 r/min |
|---|---|---|---|---|---|
| 28 | 43.34 | 39.25 | 31.86 | 24.66 | 18.34 |
| 40 | 41.27 | 38.28 | 32.65 | 24.02 | 16.52 |
| 52 | 38.26 | 34.14 | 29.08 | 21.44 | 15.79 |
| 64 | 37.95 | 34.62 | 27.59 | 19.99 | 15.21 |
| 76 | 34.16 | 31.68 | 24.22 | 20.23 | 13.54 |
| Distance (mm) | 4200 r/min | 7000 r/min | 9800 r/min | 12600 r/min | 15400 r/min |
|---|---|---|---|---|---|
| 28 | 3128.95 | 2762.18 | 3038.29 | 3305.30 | 2923.24 |
| 40 | 2866.15 | 3466.22 | 2891.32 | 3496.09 | 3045.78 |
| 52 | 2568.27 | 4025.88 | 3225.43 | 4124.12 | 3489.67 |
| 64 | 3358.29 | 3662.63 | 3195.11 | 3513.14 | 2898.87 |
| 76 | 3046.64 | 3433.16 | 2995.57 | 3215.19 | 3321.34 |
The oil-air ratio decreases monotonically with increasing gear speed and injection distance. However, the total gas-liquid pressure does not follow a smooth trend, suggesting that the pressure field in the meshing zone is also influenced by the complex interaction between the rotating flow and the jet impingement. Despite this non-linearity, the general conclusion is that low gear speed and short injection distance are preferred for improving the lubrication state of the herringbone gear.
Temperature Field and Convective Heat Transfer Coefficient of the Herringbone Gear
Friction Heat Generation Calculation
The frictional heat generated at the meshing interface is the primary heat source for the herringbone gear. The relative sliding velocity between the tooth surfaces along the line of action is calculated from the gear kinematics. The local sliding velocity of the driving and driven gears at the meshing point \(O_3\) can be expressed as:
$$
v_{sO_3} = \omega_1 r_{b1} \tan \alpha_{tO_3} – \omega_2 r_{b2} \tan \alpha_{tO_3}
$$
where \(r_{b1}\) and \(r_{b2}\) are the base circle radii of the driving and driven gears, and \(\alpha_{tO_3}\) is the transverse pressure angle at the meshing point. The friction coefficient is estimated using the Ree-Eyring non-Newtonian fluid model. The total friction force in the lubricated contact is obtained by integrating the shear stress over the contact area:
$$
F = \iint_{\Omega} \tau_0 \sinh^{-1}\left(\frac{\eta u_s}{\tau_0 h}\right) \mathrm{d}x\,\mathrm{d}y
$$
where \(\tau_0\) is the limiting shear stress of the lubricant, \(\eta\) is the dynamic viscosity, \(u_s\) is the sliding velocity, and \(h\) is the local film thickness. The friction coefficient is then determined as \(f = F / F_n\).
Based on the computed friction coefficient and the relative sliding velocity, the instantaneous frictional heat flux is obtained from the equation:
$$
q = f \, F_n \, v_s
$$
Since the thermal properties of the driving and driven gears are identical, the heat partition ratio \(\kappa\) is calculated from the material thermal conductivity, density, and specific heat of both gears:
$$
\kappa = \frac{\sqrt{\lambda_1 \rho_1 c_1 u_{s1}}}{\sqrt{\lambda_1 \rho_1 c_1 u_{s1}} + \sqrt{\lambda_2 \rho_2 c_2 u_{s2}}}
$$
The average steady-state heat flux on the driving and driven gear tooth surfaces is then obtained by multiplying the instantaneous heat flux by the contact area ratio and the meshing frequency. The results reveal that the steady-state frictional heat flux is highest near the tooth root and tooth tip regions, while it approaches zero at the pitch point. The driving gear generally experiences a higher heat flux than the driven gear.
Body Temperature Field Simulation
The body temperature field of the herringbone gear is analyzed using a steady-state thermal finite element model. The heat balance equation for a rotating gear tooth can be written as:
$$
k \nabla^2 T_B + q_F = \rho c \frac{\partial T_B}{\partial t}
$$
where \(T_B\) is the body temperature, \(q_F\) is the frictional heat source term, and \(k\), \(\rho\), \(c\) are the thermal conductivity, density, and specific heat of the gear material, respectively. The boundary conditions include the convective heat transfer from the tooth surfaces, the tooth flank, and the gear end faces to the surrounding lubricating oil and air. In the steady state, the temperature distribution reaches a stationary condition.
The finite element model is generated for a single tooth segment of the herringbone gear. The average frictional heat flux computed in the previous step is applied to the tooth flanks. The convective heat transfer coefficients are applied to the tooth flank, tooth tip, and end faces. The simulation results show that the highest body temperature occurs near the tooth tip, reaching approximately 60 °C under the specified operating conditions. The overall temperature distribution is consistent with the heat flux distribution, with higher temperatures in the regions of high sliding velocity.
Influence of Injection Parameters on Convective Heat Transfer Coefficient
To investigate the cooling performance of the oil jet, a simplified CFD model of the herringbone gear pair is established. The gear surfaces are treated as rotating walls, and the nozzle is modeled as a velocity inlet. The average convective heat transfer coefficient on the tooth surfaces is evaluated under different injection velocities and injection distances.
The effect of injection velocity on the convective heat transfer coefficient is shown in Table 9. The average heat transfer coefficient increases from 1650 W/(m²·K) at 24 m/s to 3520 W/(m²·K) at 40 m/s. This significant enhancement is attributed to the higher mass flux and improved oil impingement onto the tooth surfaces. In contrast, the influence of injection distance is relatively weak. The average heat transfer coefficient varies only slightly when the injection distance is changed from 28 mm to 76 mm, with the maximum value occurring at approximately 52 mm.
| Injection velocity (m/s) | 24 | 28 | 32 | 36 | 40 |
|---|---|---|---|---|---|
| Heat transfer coefficient | 1650 | 2140 | 2690 | 3150 | 3520 |
| Injection distance (mm) | 76 | 64 | 52 | 40 | 28 |
|---|---|---|---|---|---|
| Heat transfer coefficient | 1850 | 2010 | 2150 | 2080 | 1920 |
Based on the above analysis, it can be concluded that the injection velocity is the dominant parameter governing the convective heat transfer performance of the herringbone gear, while the injection distance has a secondary influence. Therefore, during the design of an oil jet lubrication system for high-speed herringbone gears, priority should be given to increasing the injection velocity, while the injection distance should be maintained at a moderate value to balance between heat transfer efficiency and geometric constraints.
Experimental Validation of Oil Jet Lubrication for the Herringbone Gear
Experimental Setup
To validate the numerical results and to investigate the actual oil jet behavior, a power-open type test rig is constructed. The test rig consists of a drive motor, a coupling, the herringbone gear pair, an oil pump, a nozzle assembly, and a temperature measurement system. The gear pair used in the experiments has the same parameters as those listed in Table 1. The motor is a three-phase asynchronous motor with a rated power of 300 kW and a rated speed of 1400 r/min. A contact-type thermocouple is placed on the gear tooth surface to measure the temperature during the lubrication and cooling tests.
Oil Jet Flow Shape Tests
The first series of experiments focuses on the deflection of the oil jet when injected on the incoming mesh side. The injection distance is fixed at 56 mm, and the injection velocity is set to 3.5 m/s. The gear rotational speed is varied from 380 r/min to 840 r/min. It is observed that the jet deflection increases with gear speed. When the gear speed is fixed at 690 r/min and the injection velocity is varied from 1 m/s to 4 m/s, the jet deflection decreases with increasing injection velocity. These observations are in good agreement with the numerical simulations.
When the motor is reversed to inject the oil on the outgoing mesh side, a gas-barrier phenomenon is clearly observed. At a gear speed of 280 r/min and an injection velocity of 3.5 m/s, the oil jet is partially reversed; at 690 r/min and 4 m/s, the reversal is nearly complete, leading to almost no oil entering the meshing region. This confirms that the incoming mesh side injection is superior for the lubrication of the high-speed herringbone gear.
Lubrication Cooling Tests
Cooling tests are performed by heating a test specimen to a uniform temperature of 60 °C and then spraying it with oil at different injection velocities and distances. The surface temperature is recorded after 30 seconds of cooling. The temperature drop is used as a proxy for the convective heat transfer coefficient. The results show that a higher injection velocity results in a larger temperature drop, indicating a higher cooling efficiency. Increasing the injection distance reduces the cooling rate. The influence of injection velocity is considerably stronger than that of injection distance, which is consistent with the numerical heat transfer analysis.
Conclusion and Outlook
In this thesis, the oil jet lubrication characteristics of the high-speed herringbone gear are systematically investigated through numerical simulation and experimental validation. The main conclusions are summarized as follows:
First, a comprehensive CFD model of the herringbone gear pair is established, and the drum-shaped tooth modification is applied to improve the contact behavior. The multiphase flow model is used to simulate the gas-liquid two-phase flow in the meshing zone. The results indicate that the incoming mesh side injection provides better lubrication than the outgoing mesh side injection, especially at high gear speeds.
Second, the single-factor analysis shows that the oil film thickness on the tooth surface increases with increasing injection velocity and decreases with increasing gear speed, while the injection distance has a relatively minor influence on the equilibrium film thickness. The coupling analysis reveals that the oil-air ratio in the meshing zone is maximized when the injection velocity is high, the gear speed is low, and the injection distance is short. In contrast, the total gas-liquid pressure increases with both gear speed and injection velocity, which may hinder the penetration of the oil jet into the meshing zone.
Third, the temperature field of the herringbone gear is calculated based on the friction heat generation analysis. The maximum body temperature occurs near the tooth tip. The convective heat transfer coefficient of the tooth surfaces increases with the injection velocity and decreases with the injection distance. The injection velocity is found to be the dominant parameter for heat dissipation.
Finally, the experimental results confirm the numerical observations regarding jet deflection, gas-barrier phenomena, and cooling performance. The agreement between simulations and experiments demonstrates the accuracy and reliability of the proposed modeling approach.
Future work may extend the present analysis to include the influence of nozzle geometry, oil temperature effects, and the interaction between adjacent gear meshing stages. Additionally, advanced turbulence models and experimental measurement techniques could be applied to further refine the prediction of oil jet dynamics and thermal behavior of the high-speed herringbone gear.