
In my research, I focus on the meshing stiffness prediction of miter gears, which are widely used in energy equipment, large ships, and high-speed aerospace transmissions because of their high contact ratio, low axial force, high load capacity, and smooth operation. I treat miter gears as double-helical transmission elements that can be modeled as two helical gear halves with opposite hands. The meshing stiffness of miter gears is a critical internal excitation parameter for gear dynamics, and it directly influences vibration, noise, load sharing, and fatigue life. In this work, I develop a finite element method to calculate the time-varying meshing stiffness of miter gears, and I further investigate how assembly errors, misalignment errors, tooth profile modification, and lead crowning affect the stiffness. I also compare my finite element results with an analytical method to validate the proposed approach.
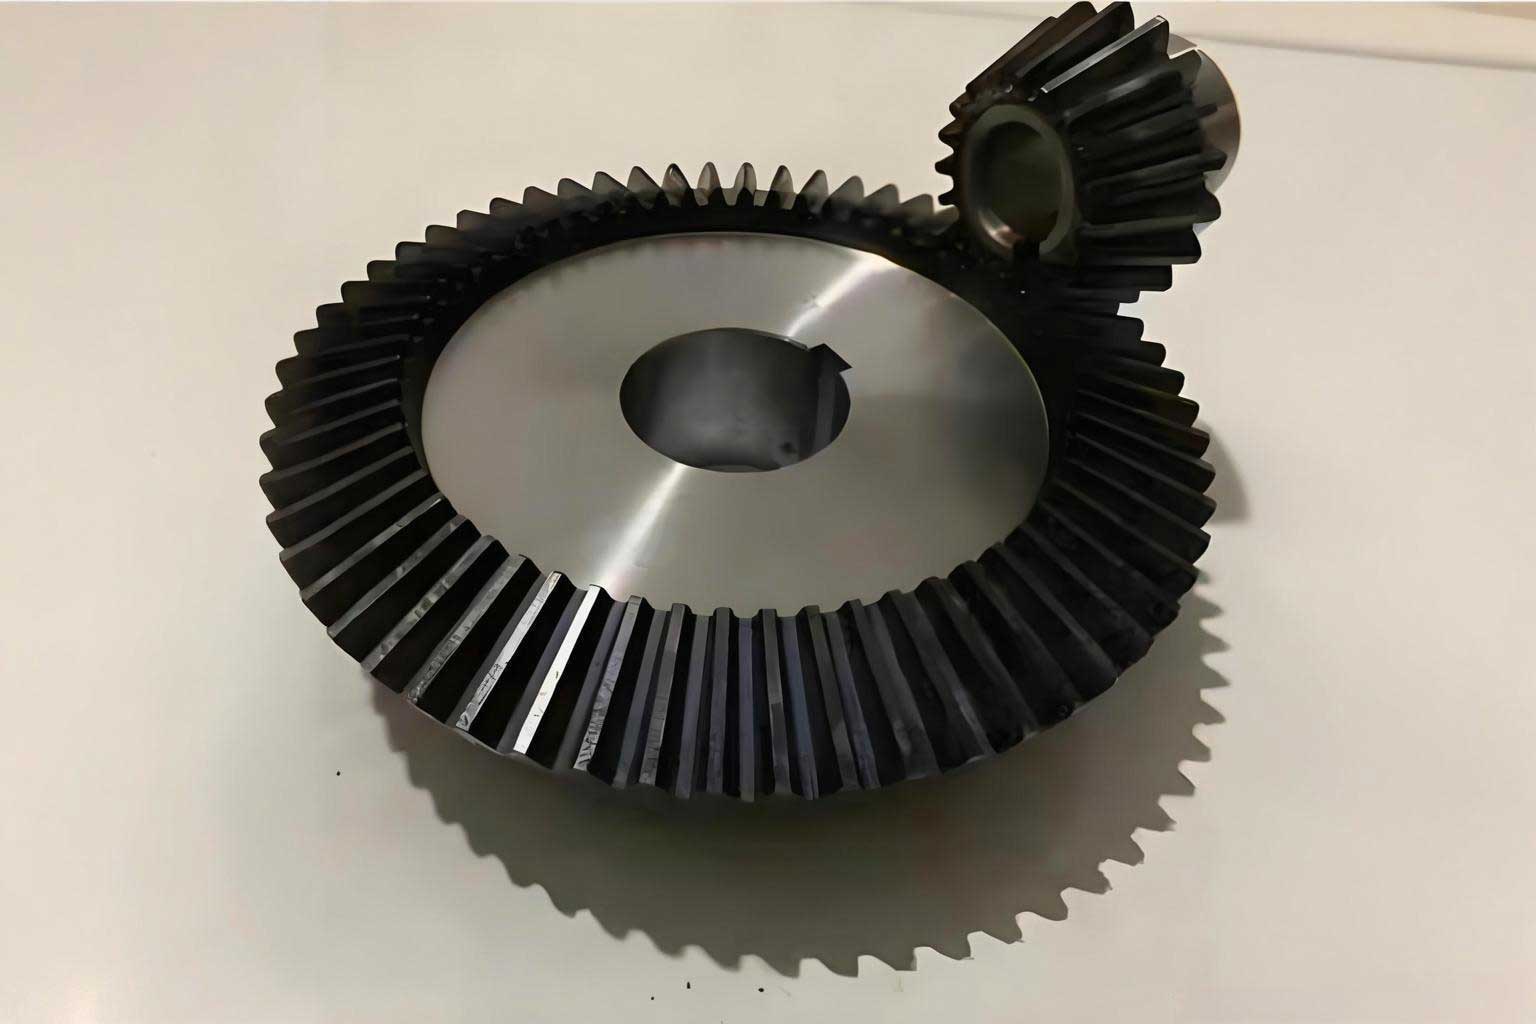
I begin with the geometric modeling of miter gears. Based on the generating principle of involute gears, I derive the tooth profile and tooth surface equations. I use a rack cutter and coordinate transformation to obtain the fillet transition curve and the involute profile. The general equation for the generated tooth profile can be written as:
$$ \begin{cases} x_2 = r \cos\varphi + (x_1 – r\varphi)\sin\varphi + y_1 \cos\varphi \\ y_2 = r \sin\varphi – (x_1 – r\varphi)\cos\varphi + y_1 \sin\varphi \end{cases} $$
where \(r\) is the pitch radius, \(\varphi\) is the gear rotation angle, and \((x_1, y_1)\) are the coordinates of the cutter. For the fillet transition curve, I use the tip rounding of the rack cutter. The coordinates of a point on the cutter tip arc are:
$$ \begin{cases} x_1 = x_c + \rho \cos\gamma \\ y_1 = y_c – \rho \sin\gamma \end{cases} $$
with \(\gamma = \arctan\left(\frac{r\varphi – y_c}{x_c}\right)\). Substituting these into the general transformation gives the fillet curve. For the involute segment, the cutter line profile yields:
$$ \begin{cases} x_1 = (r\varphi – y_0)\sin\alpha + \frac{r – y_0}{\cos\alpha} \\ y_1 = (r\varphi – y_0)\cos\alpha \end{cases} $$
where \(\alpha\) is the pressure angle and \(y_0\) is the distance from the pitch line to the cutter tip. After obtaining the end-face profile, I extend it along a helix to form the helical tooth surface. For a helical gear with helix angle \(\beta\) and face width \(B\), the tooth surface coordinates are:
$$ \begin{cases} X = R \cos\left(\frac{B t \tan\beta}{r}\right) \\ Y = R \sin\left(\frac{B t \tan\beta}{r}\right) \\ Z = B t \end{cases}, \quad 0 \le t \le 1 $$
For miter gears, I mirror the helical surface to create the double-helical form with a relief groove. The final tooth surface equation for miter gears becomes:
$$ \begin{cases} X = R \cos\left(\frac{B_w t \tan\beta}{r}\right) \\ Y = R \sin\left(\frac{B_w t \tan\beta}{r}\right) \\ Z = \pm \frac{B_w}{2} + B t \end{cases} $$
where \(B_w\) is the width of the relief groove. I use MATLAB to generate discrete points on the tooth surface and import them into CATIA to build a three-dimensional geometric model of miter gears. I then transfer the model to ABAQUS for finite element analysis. The basic parameters of my miter gear pair are listed in Table 1.
| Parameter | Driving gear | Driven gear |
|---|---|---|
| Number of teeth, \(z\) | 34 | 31 |
| Normal module, \(m_n\) (mm) | 6 | 6 |
| Normal pressure angle, \(\alpha_n\) (°) | 25 | 25 |
| Helix angle, \(\beta\) (°) | 35.9891 | 35.9891 |
| Face width, \(b_1\) (mm) | 180 | 180 |
| Relief groove width, \(b_2\) (mm) | 24 | 24 |
| Relief groove depth, \(d\) (mm) | 5.5 | 4 |
| Torque, \(T\) (N·m) | 9545 | 9545 |
For the finite element model, I partition each tooth into eight regions to enable structured hexahedral meshing. I use linear reduced-integration elements (C3D8R) to reduce computational cost while maintaining accuracy. The material properties of the miter gears are given in Table 2. I define surface-to-surface contact pairs between the driving and driven gears. For dynamic analysis, I define contact pairs on both flanks to account for possible backlash contact. I use a friction coefficient of 0.06. I apply boundary conditions through rigid body reference points coupled to the inner surfaces of the gears, which allows me to simulate rotation and torque without rotational degrees of freedom on solid elements.
| Property | Value |
|---|---|
| Material | 45 steel |
| Elastic modulus, \(E\) (GPa) | 210 |
| Poisson’s ratio, \(\mu\) | 0.3 |
| Density, \(\rho\) (kg/m³) | 7800 |
I perform both static and dynamic contact analyses. For static analysis, I apply a rotation angle of 1.5 rad and a torque of 9545 N·m. For dynamic analysis, I consider four rotational speeds: 1000, 5000, 8000, and 10000 r/min, all with the same torque. The static analysis yields a maximum contact stress of 364.9 MPa and a maximum bending stress of 120.6 MPa. The contact stress at the beginning of meshing is 484.9 MPa, and at the end of meshing it is 535.8 MPa. These values indicate that there is a meshing impact at the entry and exit of the miter gear pair. The contact ratio calculated from the contact force history is 4.0. Table 3 summarizes the static results.
| Condition | Maximum contact stress (MPa) | Maximum bending stress (MPa) | Contact stress at entry (MPa) | Contact stress at exit (MPa) |
|---|---|---|---|---|
| Static | 364.9 | 120.6 | 484.9 | 535.8 |
For dynamic analysis, I obtain the rotational speeds, contact forces, contact areas, contact stresses, and bending stresses. The maximum contact stress and bending stress increase with rotational speed. At 1000 r/min, the maximum contact stress is 877.2 MPa and the maximum bending stress is 289.3 MPa. At 5000 r/min, these values become 2800.0 MPa and 1574.6 MPa. At 8000 r/min, they reach 5203.0 MPa and 4803.0 MPa. At 10000 r/min, the maximum contact stress is 6829.6 MPa and the maximum bending stress is 5468.9 MPa. The dynamic results are summarized in Table 4. I observe that at high speeds, the miter gears experience loss of contact and back-flank meshing, which follows a sequence of normal meshing, loss of contact, back-flank meshing, and normal meshing. This phenomenon is more pronounced at 8000 and 10000 r/min.
| Case | Speed (r/min) | Torque (N·m) | Maximum contact stress (MPa) | Maximum bending stress (MPa) |
|---|---|---|---|---|
| 2 | 1000 | 9545 | 877.2 | 289.3 |
| 3 | 5000 | 9545 | 2800.0 | 1574.6 |
| 4 | 8000 | 9545 | 5203.0 | 4803.0 |
| 5 | 10000 | 9545 | 6829.6 | 5468.9 |
Next, I calculate the meshing stiffness of miter gears. The meshing stiffness is defined as the ratio of the normal contact force to the comprehensive elastic deformation. For a single tooth, the stiffness is:
$$ K_n = \frac{F_n}{u_n} $$
where \(F_n\) is the normal contact force and \(u_n\) is the comprehensive elastic deformation, which includes the Hertzian contact deformation \(u_H\) and the bending deformation \(u_b\):
$$ u_n = u_H + u_b $$
For a single tooth pair, the meshing stiffness is obtained by combining the two gears in series:
$$ K = \frac{K_1 K_2}{K_1 + K_2} $$
where \(K_1\) and \(K_2\) are the single-tooth stiffnesses of the driving and driven gears. For multiple tooth pairs in mesh, the total meshing stiffness is the sum of the individual pair stiffnesses because they are in parallel:
$$ K_{\text{total}} = \sum_{i=1}^{n} K_i $$
I calculate the single-tooth stiffness by applying a torque and fixing the other gear, then extracting the normal contact force and the average deformation of the contact nodes. I divide the meshing cycle into 25 positions, each corresponding to a rotation of 0.03 rad. Table 5 lists the stiffness values at each position. From these values, I obtain the single-tooth meshing stiffness. Then I shift the single-tooth stiffness according to the contact ratio to obtain the multi-tooth total meshing stiffness. The contact ratio is 4.0, and the shift angle is \(\Delta\alpha = \Phi / \varepsilon\), where \(\Phi\) is the rotation angle over one meshing period.
| Rotation angle (rad) | Driving gear stiffness (N/m) | Driven gear stiffness (N/m) |
|---|---|---|
| 0.03 | 1.898686×10⁸ | 3.067052×10⁸ |
| 0.06 | 7.367521×10⁸ | 6.091630×10⁸ |
| 0.09 | 1.212667×10⁹ | 9.290257×10⁸ |
| 0.12 | 1.675959×10⁹ | 1.363793×10⁹ |
| 0.15 | 2.198675×10⁹ | 1.875465×10⁹ |
| 0.18 | 2.497343×10⁹ | 2.449099×10⁹ |
| 0.21 | 2.687129×10⁹ | 3.112956×10⁹ |
| 0.24 | 2.900461×10⁹ | 3.559245×10⁹ |
| 0.27 | 3.037737×10⁹ | 3.750572×10⁹ |
| 0.30 | 3.131559×10⁹ | 3.894012×10⁹ |
| 0.33 | 3.210415×10⁹ | 3.864422×10⁹ |
| 0.36 | 3.213005×10⁹ | 3.860768×10⁹ |
| 0.39 | 3.219164×10⁹ | 3.909906×10⁹ |
| 0.42 | 3.242201×10⁹ | 3.875142×10⁹ |
| 0.45 | 3.238331×10⁹ | 3.813841×10⁹ |
| 0.48 | 3.165176×10⁹ | 3.759140×10⁹ |
| 0.51 | 3.071321×10⁹ | 3.540088×10⁹ |
| 0.54 | 2.849351×10⁹ | 3.301845×10⁹ |
| 0.57 | 2.296435×10⁹ | 3.046531×10⁹ |
| 0.60 | 1.851348×10⁹ | 2.734256×10⁹ |
| 0.63 | 1.396123×10⁹ | 2.267925×10⁹ |
| 0.66 | 1.015858×10⁹ | 1.839452×10⁹ |
| 0.69 | 7.008340×10⁸ | 1.175099×10⁹ |
| 0.72 | 4.466770×10⁸ | 5.827601×10⁸ |
| 0.75 | 9.361600×10⁷ | 3.976296×10⁷ |
I also use an analytical method to calculate the meshing stiffness for comparison. The analytical method is based on the instantaneous total contact line length. For a helical gear, the total contact line length \(L(t)\) can be expressed as a Fourier series. The meshing stiffness is then:
$$ K(t) = 2 c_\gamma L(t) $$
where \(c_\gamma\) is the meshing stiffness per unit contact line length, and the factor 2 accounts for the two halves of the miter gear. The unit stiffness \(c_\gamma\) is calculated from ISO standards:
$$ c_\gamma = (0.75 \varepsilon_\alpha + 0.25) c’ $$
where \(\varepsilon_\alpha\) is the transverse contact ratio and \(c’\) is the single-tooth stiffness per unit face width. The single-tooth stiffness \(c’\) is obtained from the flexibility \(q\):
$$ c’ = \frac{1}{q} $$
and \(q\) is given by:
$$ q = C_1 + \frac{C_2}{z_{n1}} + \frac{C_3}{z_{n2}} + C_4 x_1 + C_5 x_2 + C_6 x_1^2 + C_7 x_2^2 + C_8 x_1 x_2 + C_9 x_1^2 x_2^2 $$
where \(z_{n1}, z_{n2}\) are the equivalent numbers of teeth, \(x_1, x_2\) are the modification coefficients, and the constants \(C_1\) to \(C_9\) are given in Table 6. The contact line length for miter gears depends on whether the transverse contact ratio \(\varepsilon_\alpha\) is less than or greater than the overlap ratio \(\varepsilon_\beta\). I derive the piecewise functions for both cases and express them as Fourier series. The total contact line length is then:
$$ L(t) = \frac{p_{bt}}{\sin\beta} \left( a_0 + \sum_{k=1}^{\infty} (a_k \cos 2\pi k \varepsilon_m t + b_k \sin 2\pi k \varepsilon_m t) \right) $$
where \(p_{bt}\) is the base pitch, \(\varepsilon_m\) is the total contact ratio, and the coefficients \(a_k, b_k\) are functions of \(\varepsilon_\alpha, \varepsilon_\beta, \varepsilon_\gamma\). I compare the analytical and finite element results in Table 7. The maximum single-tooth meshing stiffness from the finite element method is \(1.765 \times 10^9\) N/m, while the analytical method gives \(1.650 \times 10^9\) N/m. The maximum total meshing stiffness from the finite element method is \(4.778 \times 10^9\) N/m, compared to \(4.660 \times 10^9\) N/m from the analytical method. The difference is within 7%, which validates the finite element approach for miter gears.
| Coefficient | Value |
|---|---|
| \(C_1\) | 0.04723 |
| \(C_2\) | 0.15551 |
| \(C_3\) | 0.25791 |
| \(C_4\) | -0.00635 |
| \(C_5\) | -0.11654 |
| \(C_6\) | -0.00193 |
| \(C_7\) | -0.24188 |
| \(C_8\) | 0.00529 |
| \(C_9\) | 0.00182 |
| Method | Maximum single-tooth meshing stiffness (N/m) | Maximum total meshing stiffness (N/m) |
|---|---|---|
| Analytical | \(1.650 \times 10^9\) | \(4.660 \times 10^9\) |
| Finite element | \(1.765 \times 10^9\) | \(4.778 \times 10^9\) |
| Difference | \(0.115 \times 10^9\) (7.0%) | \(0.118 \times 10^9\) (2.0%) |
After validating the finite element method, I investigate the effects of errors on the meshing stiffness of miter gears. I consider two types of assembly errors: axis parallel misalignment in the plane of the axes, \(\Delta f_x\), and axis parallel misalignment in the perpendicular plane, \(\Delta f_y\). According to gear design standards, \(\Delta f_x = 2 \Delta f_y\). I choose \(\Delta f_y = 24 \, \mu m\) and \(48 \, \mu m\), which correspond to \(\Delta f_x = 48 \, \mu m\) and \(96 \, \mu m\). I also consider a centering error \(\delta\) for the miter gear, which arises from manufacturing deviations between the two helical halves. I take \(\delta = 20 \, \mu m\) and \(30 \, \mu m\). The results are summarized in Table 8. In all cases, the meshing stiffness of miter gears decreases as the error magnitude increases. The load distribution between the two ends of the miter gears becomes uneven, and at large errors, one end may carry almost no load. I find that the perpendicular plane misalignment \(\Delta f_y\) has a more pronounced effect on the meshing stiffness than the in-plane misalignment \(\Delta f_x\). The centering error also reduces the meshing stiffness and causes uneven load sharing. Therefore, strict control of assembly and manufacturing errors is essential for miter gears.
| Error type | Error value | Maximum single-tooth meshing stiffness (N/m) | Maximum total meshing stiffness (N/m) |
|---|---|---|---|
| No error | 0 | \(1.765 \times 10^9\) | \(4.778 \times 10^9\) |
| \(\Delta f_x\) | 48 μm | \(1.62 \times 10^9\) | \(4.35 \times 10^9\) |
| \(\Delta f_x\) | 96 μm | \(1.41 \times 10^9\) | \(3.82 \times 10^9\) |
| \(\Delta f_y\) | 24 μm | \(1.55 \times 10^9\) | \(4.10 \times 10^9\) |
| \(\Delta f_y\) | 48 μm | \(1.32 \times 10^9\) | \(3.55 \times 10^9\) |
| Centering error \(\delta\) | 20 μm | \(1.58 \times 10^9\) | \(4.22 \times 10^9\) |
| Centering error \(\delta\) | 30 μm | \(1.48 \times 10^9\) | \(3.98 \times 10^9\) |
Finally, I study the influence of tooth modifications on the meshing stiffness of miter gears. I consider two types of modification: tooth profile modification and lead crowning. For tooth profile modification, I use a parabolic curve with maximum modification amounts \(\Delta_{\max} = 5, 10, 15 \, \mu m\) and a modification height of 3 mm. The modification curve is:
$$ \Delta = \Delta_{\max} \left( \frac{x}{h} \right)^2 $$
where \(x\) is the coordinate along the line of action from the start of modification, and \(h\) is the modification height. For lead crowning, I use a parabolic crowning curve with crowning amounts \(C_c = 10, 15, 20 \, \mu m\). The crowning curve is:
$$ \Delta_c = C_c \left( \frac{2z}{b} \right)^2 $$
where \(z\) is the coordinate along the face width and \(b\) is the face width. The results are given in Table 9. For small modification amounts, the meshing stiffness of miter gears increases slightly compared to the unmodified case. For example, with \(\Delta_{\max} = 5 \, \mu m\), the maximum total meshing stiffness is \(4.92 \times 10^9\) N/m, which is higher than the unmodified value of \(4.778 \times 10^9\) N/m. However, as the modification amount increases, the stiffness decreases. At \(\Delta_{\max} = 15 \, \mu m\), the maximum total meshing stiffness drops to \(4.45 \times 10^9\) N/m. Similarly, for lead crowning, the stiffness increases at \(C_c = 10 \, \mu m\) to \(4.88 \times 10^9\) N/m, but decreases at \(C_c = 20 \, \mu m\) to \(4.38 \times 10^9\) N/m. The contact stress at entry and exit also decreases with modification, indicating that modification reduces meshing impact. However, excessive modification removes too much material and reduces the contact ratio, leading to lower stiffness. Therefore, an optimal modification amount must be selected for miter gears to balance impact reduction and stiffness retention.
| Modification type | Amount | Maximum single-tooth meshing stiffness (N/m) | Maximum total meshing stiffness (N/m) | Contact stress at entry (MPa) | Contact stress at exit (MPa) |
|---|---|---|---|---|---|
| Unmodified | 0 | \(1.765 \times 10^9\) | \(4.778 \times 10^9\) | 484.9 | 535.8 |
| Profile modification | 5 μm | \(1.82 \times 10^9\) | \(4.92 \times 10^9\) | 368.0 | 329.3 |
| Profile modification | 10 μm | \(1.76 \times 10^9\) | \(4.75 \times 10^9\) | 280.3 | 308.9 |
| Profile modification | 15 μm | \(1.65 \times 10^9\) | \(4.45 \times 10^9\) | 255.2 | 261.8 |
| Lead crowning | 10 μm | \(1.81 \times 10^9\) | \(4.88 \times 10^9\) | — | — |
| Lead crowning | 15 μm | \(1.74 \times 10^9\) | \(4.68 \times 10^9\) | — | — |
| Lead crowning | 20 μm | \(1.62 \times 10^9\) | \(4.38 \times 10^9\) | — | — |
In my study, I demonstrate that the finite element method can accurately predict the meshing stiffness of miter gears, and that the analytical method based on contact line length provides a good validation. I show that assembly errors, misalignment errors, and centering errors reduce the meshing stiffness of miter gears and cause uneven load distribution. I also show that proper tooth profile modification and lead crowning can improve the meshing behavior of miter gears by reducing impact and redistributing load, but excessive modification reduces stiffness. These findings provide a useful reference for the design, manufacturing, and assembly of miter gears in high-speed and heavy-load transmission systems.