
In this study I focus on the meshing efficiency calculation and macro and micro parameter optimization of a double helical star gear system, while I also discuss how the same modeling ideas can be transferred to miter gears and other precision gear pairs operating under mixed elastohydrodynamic lubrication. The system I analyze is a geared turbofan engine transmission with one sun gear, five star gears, and one internal ring gear. Power enters through the sun gear, is split into five parallel paths through the star gears, and is collected by the ring gear. Because miter gears and double helical star gears both experience time-varying contact conditions, sliding friction, rolling friction, mesh phasing, and elastic deformation, I treat the evaluation of miter gears as a related problem in which contact line kinematics and tribological state must be resolved before efficiency can be predicted. The rated input power is 2000 kW, and the rated input speed is 7500 r/min. I use this configuration to demonstrate a complete workflow: geometry and contact ratio, time-varying contact line length, mixed EHL friction coefficient, dynamic mesh force, meshing power loss, efficiency, parameter influence analysis, and genetic algorithm optimization.
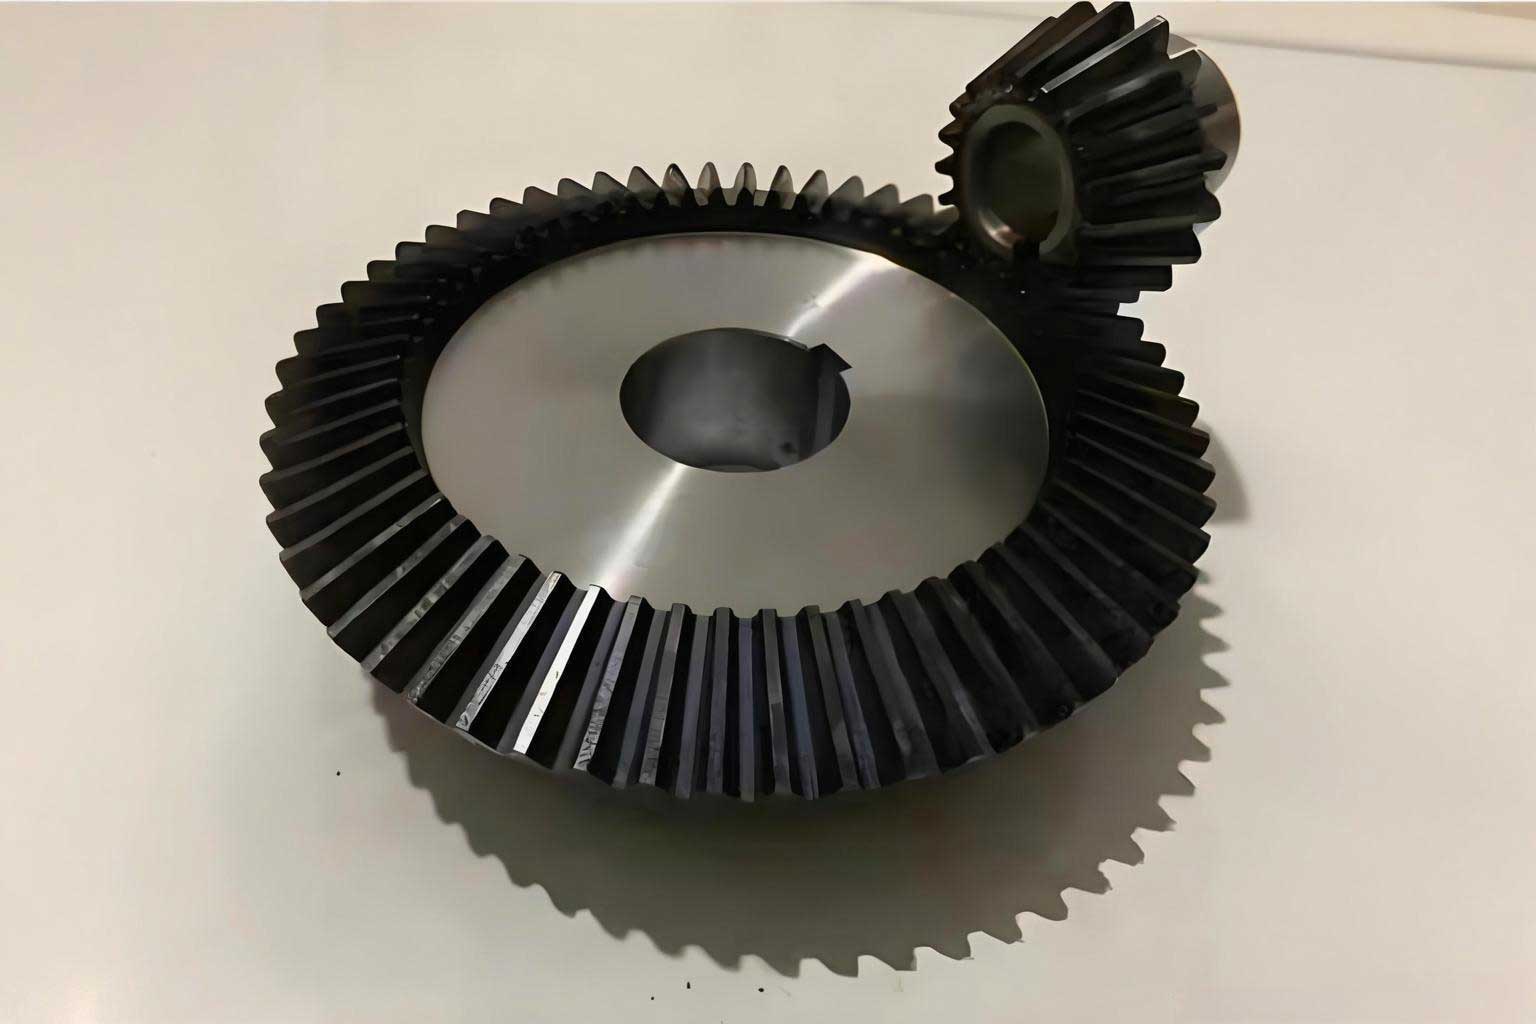
I first define the basic geometric parameters of the double helical star gear system. These parameters also provide a reference framework for miter gears when the contact geometry must be converted into equivalent curvature, entrainment velocity, and slide-to-roll ratio. Table 1 lists the main geometric and operating parameters used in my calculations.
| Parameter | Sun gear | Star gear | Ring gear |
|---|---|---|---|
| Number of teeth | 34 | 31 | 96 |
| Normal module, mm | 2 | 2 | 2 |
| Normal pressure angle, deg | 22.5 | 22.5 | 22.5 |
| Helix angle, deg | 30 | 30 | 30 |
| Total face width, mm | 58 | 58 | 58 |
| Groove width, mm | 10 | 10 | 10 |
| Normal profile shift coefficient | 0.1016 | 0.1235 | 0.3485 |
| Input power, kW | 2000 | ||
| Input speed, r/min | 7500 | ||
For miter gears and double helical star gears, the first essential step is to determine the contact ratio and the actual meshing region. I calculate the transverse contact ratio of the internal mesh as
$$
\varepsilon_{\alpha,i}=\frac{\sqrt{r_{e1}^{2}-r_{b1}^{2}}-\sqrt{r_{s2}^{2}-r_{b2}^{2}}+a\sin\alpha_{w}}{p_{bt}},
$$
and the transverse contact ratio of the external mesh as
$$
\varepsilon_{\alpha,e}=\frac{\sqrt{r_{e1}^{2}-r_{b1}^{2}}-\sqrt{r_{s2}^{2}-r_{b2}^{2}}+a\sin\alpha_{w}}{p_{bt}}.
$$
Here, r_e is the radius to the end of the modified meshing region, r_s is the radius to the start of the modified meshing region, r_b is the base radius, a is the center distance, α_w is the transverse working pressure angle, and p_bt is the transverse base pitch. For miter gears, the same contact ratio concept applies, but the plane of action and the equivalent pitch radius must be interpreted according to the miter gear axis arrangement. The overlap ratio of the double helical star gear system is
$$
\varepsilon_{\beta}=\frac{B\sin\beta}{\pi m_n},
$$
where B is the single-side face width, β is the helix angle, and m_n is the normal module. The total contact ratio is therefore
$$
\varepsilon_{\gamma}=\varepsilon_{\alpha}+\varepsilon_{\beta}.
$$
Table 2 summarizes the contact ratios I obtained. I note that miter gears with a single contact region usually show a different overlap behavior, but the same summation principle is useful when I compare miter gears with helical and double helical configurations.
| Mesh type | Transverse contact ratio εα | Overlap ratio εβ | Total contact ratio εγ |
|---|---|---|---|
| Internal mesh | 1.274 | 1.910 | 3.184 |
| External mesh | 1.228 | 1.910 | 3.138 |
After obtaining the contact ratio, I calculate the time-varying contact line length. This is important for miter gears as well, because the instantaneous friction power loss depends strongly on the loaded contact area. For a double helical star gear pair, the contact line moves uniformly over two symmetric rectangular regions separated by the groove. The total contact line length at time t is
$$
L_z(t)=\sum_{i=1}^{N}l_i(t),
$$
where N is the total number of contact lines at that instant. For the case β_b < β_0, the single-tooth contact line length can be written as
$$
l(t)=
\begin{cases}
2v_0 t\sin\beta_b, & t_0\le t<t_1,\\ $$="" &="" 0,="" 2\left(b\tan\beta_b+p_{bt}-v_0="" <p="" \dfrac{b}{\cos\beta_b},="" \end{cases}="" t<t,="" t<t_2,\\="" twhere v_0 is the linear velocity of the contact line, p_bt is the transverse base pitch, and T is the single-tooth meshing period. The same segment-based approach can be adapted to miter gears by replacing the rectangular contact region with the appropriate miter gear contact footprint. I use the segment-based method because it allows the friction coefficient and the normal load to vary along each contact line.
The geometric and kinematic parameters of the mesh include the distance from the pitch point to an arbitrary contact point, the radius of curvature, the entrainment velocity, and the relative sliding velocity. I calculate the distance PK as
$$
PK=r_{b1}\left(\tan\alpha_{t1}-\tan\alpha_t\right).
$$
The transverse radii of curvature are
$$
R_{t1}=r_{b1}\tan\alpha_{t1},
$$
$$
R_{t2}=r_{b1}\left[\tan\alpha_t(1\pm i)-\tan\alpha_{t1}\right],
$$
where the upper and lower signs correspond to external and internal meshes, respectively. The normal radii of curvature are
$$
R_{n1}=\frac{R_{t1}}{\cos\beta_b},
\qquad
R_{n2}=\frac{R_{t2}}{\cos\beta_b}.
$$
The equivalent radius of curvature is
$$
R_z=\frac{R_{n1}R_{n2}}{R_{n2}\pm R_{n1}}.
$$
The relative sliding velocity, entrainment velocity, and slide-to-roll ratio are
$$
v_s=v_{t1}-v_{t2},
$$
$$
v_e=\frac{v_{t1}+v_{t2}}{2},
$$
$$
\xi=\frac{2\left(v_{t1}-v_{t2}\right)}{v_{t1}+v_{t2}}.
$$
These quantities are essential for both miter gears and double helical star gears, because the friction coefficient in mixed EHL depends on v_e, ξ, R_z, and the contact pressure.
I now describe the mixed elastohydrodynamic lubrication model. In a high-speed and heavy-load gear transmission, the tooth surfaces are neither in full-film EHL nor in pure boundary lubrication. Instead, the load is shared by the lubricant film and the asperity contacts. For miter gears operating under severe conditions, this mixed state is also common. The minimum film thickness is calculated as
$$
h_{\min}=2.65\frac{\alpha^{0.54}\left(\upsilon_0 v_e\right)^{0.7}R_z^{0.43}}{E^{0.13}\varpi^{0.13}},
$$
where α is the pressure-viscosity coefficient, υ_0 is the dynamic viscosity, E is the equivalent elastic modulus, and ϖ is the load per unit contact line length. The film thickness ratio is
$$
\lambda=\frac{h_{\min}}{\sqrt{\sigma_1^2+\sigma_2^2}},
$$
where σ_1 and σ_2 are the surface roughness values of the two gear flanks. The oil film load-sharing ratio is
$$
\gamma=\frac{1.21\lambda^{0.64}}{1+0.37\lambda^{1.26}}.
$$
The comprehensive friction coefficient is
$$
\mu=(1-\gamma)\mu_b+\gamma\mu_e,
$$
where μ_b is the asperity contact friction coefficient, which I take as 0.12, and μ_e is the oil film friction coefficient. The oil film friction coefficient is obtained from a regression model that includes the effects of contact pressure, entrainment velocity, equivalent radius, slide-to-roll ratio, and surface roughness. I use the following generalized form for miter gears and helical gear pairs:
$$
\mu_e=e^{b_1}P_h^{b_2}|v_e|^{b_3}R_z^{b_4},
$$
when the contact pressure is in the lower range, and a more general logarithmic form when the pressure is high. The regression coefficients I employ are listed in Table 3. Table 4 lists the lubrication parameters used in my mixed EHL analysis.
| Coefficient | Value |
|---|---|
| b1 | -8.916465 |
| b2 | 1.033030 |
| b3 | 1.036077 |
| b4 | -0.354068 |
| b5 | 2.812084 |
| b6 | -0.100601 |
| b7 | 0.752755 |
| b8 | -0.390958 |
| b9 | 0.620305 |
| Parameter | Value |
|---|---|
| Pressure-viscosity coefficient, m²/N | 1.68×10⁻⁸ |
| Dynamic viscosity, Pa·s | 0.0347 |
| Equivalent elastic modulus, Pa | 2.264×10¹¹ |
| Surface roughness of gear 1, μm | 0.6 |
| Surface roughness of gear 2, μm | 0.6 |
| Asperity friction coefficient | 0.12 |
I find that the minimum film thickness and film thickness ratio increase from the root to the tip for the internal mesh, while the external mesh shows the opposite trend. The film thickness ratio remains between 1 and 3, which confirms that the gear pair is in the mixed EHL regime. This result is important for miter gears because it means that neither a pure boundary friction model nor a full-film EHL model is sufficient for efficiency prediction. The comprehensive friction coefficient is close to zero near the pitch point because the sliding velocity vanishes there. Away from the pitch point, the friction coefficient depends on the competition between asperity contact and oil film shear. For miter gears, the same pitch-point behavior is observed, but the contact line orientation and the pressure distribution can modify the location of the minimum friction coefficient.
Using the mixed EHL friction coefficient, I calculate the time-varying friction excitation. I divide each contact line into small segments of length ΔL. The normal load on one segment is
$$
F_n^{ij}(t)=F_d(t)\frac{\Delta L_{ij}(t)}{L_z(t)},
$$
where F_d is the total normal load on the gear pair. The friction force on the segment is
$$
F_f^{ij}(t)=\mu_{ij}(t)F_n^{ij}(t).
$$
The total friction force on one tooth pair is
$$
F_f^i(t)=\sum_{j=1}^{n_1}F_f^{ij}(t)-\sum_{j=1}^{n_2}F_f^{ij}(t),
$$
where the two sums correspond to the two sides of the pitch line. The total friction force of the gear pair is
$$
F_f(t)=\sum_{i=1}^{N}F_f^i(t).
$$
The friction torque on the driving and driven gears is
$$
T_{f1}(t)=\sum_{i=1}^{N}\sum_{j=1}^{n_i}\mu_{ij}(t)F_n^{ij}(t)R_{t1}^{ij}(t),
$$
$$
T_{f2}(t)=\sum_{i=1}^{N}\sum_{j=1}^{n_i}\mu_{ij}(t)F_n^{ij}(t)R_{t2}^{ij}(t).
$$
For miter gears, the moment arm must be projected onto the appropriate plane of rotation, but the segment summation rule remains the same. I observe that the internal and external meshes both produce periodic friction forces and friction torques. The internal ring gear experiences a much larger friction torque than the sun gear because its moment arm is larger. The external mesh has similar friction torques on the sun and star gears because their numbers of teeth are relatively close.
Next I develop the dynamic model of the double helical star gear system. I include time-varying mesh stiffness, tooth surface friction, mesh phasing, and mesh error. The system has five star gears, and each gear is divided into a left part and a right part because of the double helical configuration. The generalized displacement vector contains transverse, axial, and torsional displacements. I use the lumped parameter method and obtain the following matrix equation:
$$
\mathbf{M}\ddot{\mathbf{X}}+\mathbf{C}\dot{\mathbf{X}}+\mathbf{K}\mathbf{X}=\mathbf{F}.
$$
I calculate the time-varying mesh stiffness by considering the oil film stiffness. The average mesh stiffness is
$$
k_m(t)=\gamma k_e(t)+(1-\gamma)k_b,
$$
where k_e is the EHL average mesh stiffness and k_b is the boundary lubrication average mesh stiffness. The EHL stiffness is obtained from the series combination of the tooth body stiffness and the oil film stiffness:
$$
\frac{1}{k_e}=\frac{1}{k_t}+\frac{1}{k_f},
$$
where k_t is the equivalent tooth body stiffness and k_f is the oil film squeeze stiffness. The single-tooth stiffness is then distributed along the contact line:
$$
k(t)=k_m(t)L(t).
$$
The total mesh stiffness is
$$
K(t)=\sum_{i=1}^{N}k_i(t).
$$
Table 5 gives the average mesh stiffness values I obtained. I also compare my mixed EHL stiffness model with a published loaded contact analysis result and find a difference of about 5.71%, which is acceptable for engineering design.
| Mesh type | Average mesh stiffness, N/m |
|---|---|
| Star gear–ring gear internal mesh | 8.353×10⁸ |
| Sun gear–star gear external mesh | 8.220×10⁸ |
Mesh phasing is another important excitation. Because five star gears are equally spaced around the sun gear, the internal mesh, external mesh, and the interaction between internal and external meshes have different phase relationships. I use the phase relations
$$
\gamma_{ri}=\frac{2\pi z_s}{n}\psi_i,
\qquad
\gamma_{si}=\frac{2\pi z_r}{n}\psi_i,
$$
and the internal–external phase difference
$$
\gamma_{sr}=
\begin{cases}
0.5, & z_p \text{ even},\\
0, & z_p \text{ odd},
\end{cases}
$$
where ψ_i is the installation angle of the i-th star gear. For miter gears, phasing is usually less complex because the number of parallel paths is smaller, but the same phase concept is useful when multiple miter gears operate in a train.
I also include manufacturing eccentricity and profile error. The equivalent mesh error along the line of action is obtained by projecting the eccentricity of the sun gear, star gear, and ring gear onto the mesh line. For the sun gear, the eccentricity contribution is
$$
e_{Esi}=E_s\sin(\omega_s t+\delta_s+\alpha_w-\psi_i)\cos\beta_b.
$$
For the star gear, the external and internal contributions are
$$
e_{Epi}^{w}=E_{pi}\sin(\omega_p t+\delta_{pi}+\alpha_w-\psi_i)\cos\beta_b,
$$
$$
e_{Epi}^{n}=E_{pi}\sin(\omega_p t+\delta_{pi}-\alpha_n-\psi_i)\cos\beta_b.
$$
For the ring gear, the contribution is
$$
e_{Eri}=E_r\sin(\omega_r t+\delta_r-\alpha_n-\psi_i)\cos\beta_b.
$$
The profile error is represented by a harmonic function. The comprehensive mesh error on the left and right sides is obtained by superposition. This comprehensive error enters the dynamic equations and affects the dynamic mesh force. I note that miter gears are also sensitive to eccentricity and profile error, especially when the miter gears are used in precision positioning systems.
Using the relative displacement between the sun gear and star gear, I derive the dynamic mesh force. For the external mesh on the left side, the relative displacement is
$$
\delta_{spi}^{L}=(x_s^{L}-x_{pi}^{L})\sin\phi_{spi}+(y_s^{L}-y_{pi}^{L})\cos\phi_{spi}
+(z_s^{L}-z_{pi}^{L})\sin\beta_b
+r_{bs}\theta_s^{L}-r_{bpi}\theta_{pi}^{L}+e_{spi}^{L}.
$$
The corresponding dynamic mesh force is
$$
F_{spi}^{L}=k_{spi}^{L}(t)\delta_{spi}^{L}+c_{spi}\dot{\delta}_{spi}^{L}.
$$
For the internal mesh, the relative displacement is
$$
\delta_{rpi}^{L}=(x_{pi}^{L}-x_r^{L})\sin\phi_{rpi}+(y_{pi}^{L}-y_r^{L})\cos\phi_{rpi}
+(z_{pi}^{L}-z_r^{L})\sin\beta_b
+r_{br}\theta_r^{L}-r_{bpi}\theta_{pi}^{L}+e_{rpi}^{L},
$$
and the dynamic mesh force is
$$
F_{rpi}^{L}=k_{rpi}^{L}(t)\delta_{rpi}^{L}+c_{rpi}\dot{\delta}_{rpi}^{L}.
$$
The mesh damping is calculated from
$$
c_{spi}=2\xi_{spi}\sqrt{\frac{k_{spi}}{1/m_{es}+1/m_{epi}}},
$$
$$
c_{rpi}=2\xi_{rpi}\sqrt{\frac{k_{rpi}}{1/m_{er}+1/m_{epi}}},
$$
where ξ is the damping ratio, and m_es, m_epi, and m_er are the equivalent masses of the sun gear, star gear, and ring gear. I solve the dynamic equations by the Runge–Kutta method. Table 6 summarizes the dynamic mesh force statistics. I find that the left and right sides of the double helical gears have similar mesh force variation, but the internal and external meshes show phase differences. For miter gears, the dynamic mesh force is often dominated by the first mesh frequency, while for double helical star gears the mesh phasing creates a more distributed excitation pattern.
| Mesh path | Mean dynamic mesh force, kN | Fluctuation range, kN |
|---|---|---|
| Internal mesh, star 1 left | 8.35 | 5.20–10.80 |
| Internal mesh, star 1 right | 8.33 | 5.18–10.75 |
| External mesh, star 1 left | 8.12 | 6.10–10.20 |
| External mesh, star 1 right | 8.10 | 6.08–10.18 |
I investigate the influence of mesh stiffness on the dynamic mesh force. When the oil film stiffness is included, the comprehensive mesh stiffness decreases because the oil film stiffness is in series with the tooth body stiffness. The internal mesh is more sensitive to the oil film stiffness than the external mesh. When the internal mesh stiffness increases from 0.5 to 3 times its reference value, the relative range of the internal and external mesh forces increases. A similar trend is found when the external mesh stiffness increases. These results are useful for miter gears because they show that the stiffness of the lubricated contact should not be ignored when the dynamic load is used for efficiency prediction.
After the dynamic mesh force is known, I calculate the meshing power loss. The sliding friction power loss on one segment is
$$
P_s^{ij}(t)=\mu_{ij}(t)F_n^{ij}(t)v_s^{ij}(t).
$$
The total sliding power loss of one gear pair is
$$
P_s(t)=\sum_{i=1}^{N}\sum_{j=1}^{n_i}P_s^{ij}(t).
$$
For the star gear system, the total sliding power loss is the sum over five external meshes and five internal meshes:
$$
P_s^{\text{ALL}}(t)=\sum_{i=1}^{5}P_s^{w,i}(t)+\sum_{i=1}^{5}P_s^{n,i}(t).
$$
The rolling friction power loss is calculated from
$$
P_r=\frac{b v_r h}{\cos\beta_b}\varepsilon_{\gamma},
$$
where b is the face width, v_r is the average rolling velocity, and h is the average oil film thickness. In the heavy-load condition, the rolling power loss is much smaller than the sliding power loss. Table 7 compares the sliding, rolling, and total power losses with the Niemann method. The Niemann method gives a constant value because it uses an average friction coefficient, while my contact-line segmentation method gives a time-varying power loss. The average values are close, which validates my approach.
| Method | Sliding power loss, kW | Rolling power loss, kW | Total power loss, kW | Efficiency, % |
|---|---|---|---|---|
| Contact-line segmentation | 16.57 | 0.14 | 16.71 | 99.08 |
| Niemann method | 16.57 | — | 16.57 | 99.17 |
The meshing efficiency is
$$
\eta(t)=1-\frac{P_s(t)+P_r(t)}{P_{\text{in}}},
$$
and the average efficiency is
$$
\bar{\eta}=\frac{1}{T}\int_{0}^{T}\eta(t)dt.
$$
The Niemann efficiency is
$$
\eta=1-\mu_m H_v,
$$
where μ_m is the average friction coefficient and H_v is the gear loss factor. My calculated average efficiency is 99.08%, and the Niemann result is 99.17%. The small difference is caused by the fact that the mixed EHL friction coefficient is larger than the average empirical value. I also find that miter gears often show a similar efficiency range when their surface finish and lubrication are comparable, but the exact value depends on the contact pattern and the load distribution.
I then study the influence of macro parameters on meshing efficiency. Table 8 summarizes the trends. The efficiency increases with tooth number, face width, helix angle, and pressure angle, and it decreases with module and surface roughness. The profile modification amount and modification length also affect efficiency. A larger modification amount reduces the contact ratio and the relative sliding velocity, so the sliding power loss decreases and the efficiency increases. However, excessive modification can reduce the load capacity, so a balance is required. For miter gears, the same trade-off exists: a larger pressure angle can improve efficiency, but the top land thickness and bending strength must be checked.
| Parameter | Change | Effect on efficiency | Main reason |
|---|---|---|---|
| Tooth number, z | Increase | Increase | Lower mesh force and lower load per contact line |
| Module, mn | Increase | Decrease | Larger sliding velocity and longer contact line |
| Face width, Bz | Increase | Increase slightly | Lower load per unit length |
| Helix angle, β | Increase | Increase slightly | Higher total contact ratio |
| Pressure angle, αn | Increase | Increase | Lower sliding velocity and lower friction coefficient |
| Profile shift, xn | Reasonable distribution | Increase | Better balance of sliding at entry and exit |
I also study micro parameters. Table 9 lists the influence of surface roughness, profile modification amount, and profile modification length. Lower surface roughness increases the oil film load-sharing ratio and decreases the comprehensive friction coefficient. A larger modification amount and a longer modification length reduce the contact ratio and the sliding velocity, so the efficiency increases. For miter gears, the surface roughness is especially important because the contact area is often smaller and the local pressure is higher.
| Parameter | Change | Effect on efficiency | Main reason |
|---|---|---|---|
| Surface roughness, σ | Increase | Decrease | Lower oil film load ratio and higher friction coefficient |
| Profile modification amount, C | Increase | Increase | Smaller contact ratio and lower sliding velocity |
| Profile modification length, L | Increase | Increase | Smaller meshing region and lower friction coefficient |
Based on these results, I propose several methods to improve the meshing efficiency of miter gears and double helical star gears. First, I recommend using a smaller module and a larger tooth number when the bending strength permits. Second, I recommend increasing the face width and helix angle within manufacturing limits. Third, I recommend increasing the pressure angle when the top land thickness is sufficient. Fourth, I recommend distributing the profile shift coefficients carefully so that the sliding velocities at the entry and exit points are balanced. Fifth, I recommend reducing the surface roughness and using an appropriate lubrication method. For high-speed miter gears, oil jet lubrication can reduce churning loss, and a controlled oil supply can maintain the mixed EHL film without excessive drag.
I now establish the macro and micro parameter optimization model. The design variables are the sun gear tooth number, star gear tooth number, ring gear tooth number, normal module, pressure angle, profile shift coefficients, profile modification amount, and profile modification length:
$$
\mathbf{X}=[z_1,z_2,z_3,x_{n1},x_{n2},x_{n3},m_n,\alpha_n,C,L]^T.
$$
The objective functions are minimum mass, maximum meshing efficiency, and minimum static transmission error peak-to-peak value. The mass function is
$$
M=\frac{\pi}{4}\rho\left[B_z\left(d_{a1}^2+nd_{a2}^2\right)+\left(B_z-B_t\right)\left(d_{a3}^2-d_{f3}^2\right)-B_t\left(d_{t1}^2-d_{t2}^2\right)\right],
$$
where ρ is the material density, B_z is the total face width, B_t is the groove width, d_a is the addendum circle diameter, d_f is the dedendum circle diameter, and n is the number of star gears. The minimum mass objective is
$$
F_1(\mathbf{X})=\frac{M}{M_0}.
$$
The maximum efficiency objective is
$$
F_2(\mathbf{X})=\frac{\eta_0}{\eta},
$$
where η_0 is the initial efficiency. The static transmission error peak-to-peak value is
$$
E=\frac{F_z}{K\cos\beta_b},
$$
and the peak-to-peak value is
$$
P=\max(E)-\min(E).
$$
The corresponding objective is
$$
F_3(\mathbf{X})=\frac{P}{P_0}.
$$
The total objective function is
$$
\min F(\mathbf{X})=w_1F_1(\mathbf{X})+w_2\left(1-F_2(\mathbf{X})\right)+w_3F_3(\mathbf{X}),
$$
where w_1, w_2, and w_3 are weight factors. I set w_1 = 0.3, w_2 = 0.4, and w_3 = 0.3. The constraints include the assembly condition for five star gears, the transmission ratio constraint, the center distance constraint, the module standard values, the pressure angle standard values, the profile shift bounds, the non-undercut condition, and the contact and bending fatigue strength conditions. The assembly condition is
$$
z_1+z_2=5k_1,
\qquad
z_1+z_3=5k_2,
$$
where k_1 and k_2 are integers. The transmission ratio constraint is
$$
\left|\frac{i-i_0}{i_0}\right|\le 0.05.
$$
The center distance constraint is
$$
\left|\frac{a-a_0}{a_0}\right|\le 0.05.
$$
The contact fatigue strength condition is
$$
S_H=\frac{\sigma_{H\lim}Z_{NT}Z_LZ_vZ_RZ_WZ_X}{\sigma_H}\ge S_{H\min},
$$
and the bending fatigue strength condition is
$$
S_F=\frac{\sigma_{FE}Y_{NT}Y_{\delta\text{rel}T}Y_{R\text{rel}T}Y_X}{\sigma_F}\ge S_{F\min}.
$$
I solve this optimization model with a genetic algorithm. The population size is 100, the number of generations is 100, the crossover probability is 0.8, and the mutation probability is 0.2. The optimization process converges rapidly, as shown in Table 10. Table 11 lists the design variables before and after optimization. The optimized design uses a smaller module, a larger tooth number, a larger pressure angle, and a larger profile modification amount. The profile shift coefficients are redistributed to reduce the sliding power loss.
| Generation | Objective function value | Generation | Objective function value |
|---|---|---|---|
| 1 | 0.0959732 | 20 | 0.0959504 |
| 2 | 0.0959674 | 30 | 0.0959504 |
| 3 | 0.0959606 | 50 | 0.0959504 |
| 4 | 0.0959576 | 80 | 0.0959504 |
| 5 | 0.0959534 | 100 | 0.0959504 |
| Variable | Before optimization | After optimization |
|---|---|---|
| Sun gear tooth number z1 | 34 | 41 |
| Star gear tooth number z2 | 31 | 39 |
| Ring gear tooth number z3 | 96 | 119 |
| Normal module mn, mm | 2 | 1.5 |
| Pressure angle αn, deg | 22.5 | 25 |
| Sun gear profile shift xn1 | 0.1016 | 0.2243 |
| Star gear profile shift xn2 | 0.1235 | 0.2576 |
| Ring gear profile shift xn3 | 0.3485 | 0.4983 |
| Profile modification amount C, μm | 10 | 16.5146 |
| Profile modification length L, mm | 1 | 1.6887 |
Table 12 compares the objective functions before and after optimization. The total mass is reduced by 15.44%, the average meshing efficiency is increased by 0.28%, and the static transmission error peak-to-peak value is reduced by 18.86%. These results show that the optimization is effective for a low-mass, high-efficiency, and low-noise design. I also check the safety factors. The contact and bending safety factors decrease slightly after optimization, but they remain above the minimum values. Table 13 lists the safety factors. This confirms that the optimized miter gear and double helical star gear design still satisfies the strength requirements.
| Objective | Before optimization | After optimization | Improvement |
|---|---|---|---|
| Mass, kg | 11.7910 | 9.9699 | -15.44% |
| Average meshing efficiency | 0.9908 | 0.9936 | +0.28% |
| Static transmission error peak-to-peak, μm | 2.6274 | 2.1318 | -18.86% |
| Gear | Contact safety factor before | Contact safety factor after | Bending safety factor before | Bending safety factor after |
|---|---|---|---|---|
| Sun gear | 1.61 | 1.57 | 1.71 | 1.61 |
| Star gear | 1.76 | 1.69 | 1.57 | 1.49 |
| Ring gear | 1.82 | 1.75 | 2.04 | 1.92 |
My study shows that the meshing efficiency of a double helical star gear system can be predicted accurately when the contact line geometry, mixed EHL friction, and dynamic mesh force are considered together. The same framework is applicable to miter gears, provided that the contact ellipse or contact line is correctly mapped and the entrainment velocity is evaluated in the proper plane. For miter gears, the main differences are the orientation of the contact path and the three-dimensional nature of the contact; however, the friction power loss still follows the same fundamental relation, namely the product of friction coefficient, normal load, and sliding velocity. I therefore recommend that miter gears be analyzed with a mixed EHL friction model rather than a constant friction coefficient, especially when the miter gears operate at high speed and high load.
From the parameter influence study, I conclude that tooth number, module, face width, helix angle, pressure angle, and profile shift all affect the efficiency of miter gears and double helical star gears. The strongest positive effects come from a smaller module, a larger tooth number, a larger pressure angle, lower surface roughness, and reasonable profile modification. The face width and helix angle have a smaller but still beneficial effect. The profile shift coefficient does not have a simple monotonic effect; it must be distributed so that the sliding velocities at the entry and exit points are balanced. If the profile shift is poorly distributed, the efficiency can decrease even if other parameters are favorable. This finding is important for miter gears because their contact pattern is often sensitive to axial positioning and profile shift.
I also conclude that the oil film stiffness should be included in the dynamic model. The oil film stiffness reduces the comprehensive mesh stiffness and changes the dynamic mesh force. The internal mesh is more sensitive to the oil film stiffness than the external mesh. In a miter gear train, the lubricated contact stiffness can shift the natural frequencies and change the dynamic load distribution. Therefore, a tribo-dynamic coupling model is preferable when the efficiency is to be optimized. The coupling between friction and dynamics is not one-way: the dynamic mesh force changes the contact pressure, the contact pressure changes the film thickness and friction coefficient, and the friction coefficient changes the friction force and the dynamic response. I include this coupling in an iterative manner.
For the optimization, I use a genetic algorithm because the design space is mixed-integer and contains many nonlinear constraints. The objective function combines mass, efficiency, and static transmission error. The optimized design reduces mass by 15.44%, increases average efficiency by 0.28%, and reduces the static transmission error peak-to-peak value by 18.86%. The optimized design also satisfies the contact and bending fatigue strength constraints. The reduction in mass is mainly due to the smaller module and the shorter center distance. The efficiency improvement is due to the larger pressure angle, the larger tooth number, and the optimized profile modification. The transmission error reduction is due to the improved mesh stiffness and the better load distribution along the contact line.
I believe that the proposed method can be extended to other gear types, including miter gears, spiral bevel gears, and hypoid gears. The key is to obtain an accurate contact line or contact ellipse, to evaluate the mixed EHL friction coefficient at each contact point, and to couple the friction force with the dynamic model. For miter gears, the contact line is often replaced by an elliptical contact, and the entrainment velocity is computed from the rolling velocities of the two miter gears. The same segment summation or integration procedure can then be used to calculate the total friction power loss. The efficiency can be improved by optimizing the macro and micro parameters, including tooth number, module, pressure angle, profile shift, surface roughness, and profile modification.
In summary, I have developed a complete framework for the meshing efficiency calculation and macro and micro parameter optimization of a double helical star gear system, and I have discussed how the framework can be adapted to miter gears. The framework includes contact ratio calculation, time-varying contact line length, mixed EHL friction coefficient, time-varying friction force and torque, dynamic mesh force, sliding and rolling power loss, efficiency prediction, parameter influence analysis, and genetic algorithm optimization. The results show that the mixed EHL friction model provides a more realistic prediction than a constant friction coefficient, that the oil film stiffness affects the dynamic mesh force, and that the optimized design achieves a better balance among mass, efficiency, and transmission error. I recommend that future work include experimental validation of miter gears and double helical star gears under mixed EHL conditions, and that the coupling between thermal effects, surface roughness evolution, and dynamic load be investigated further.