
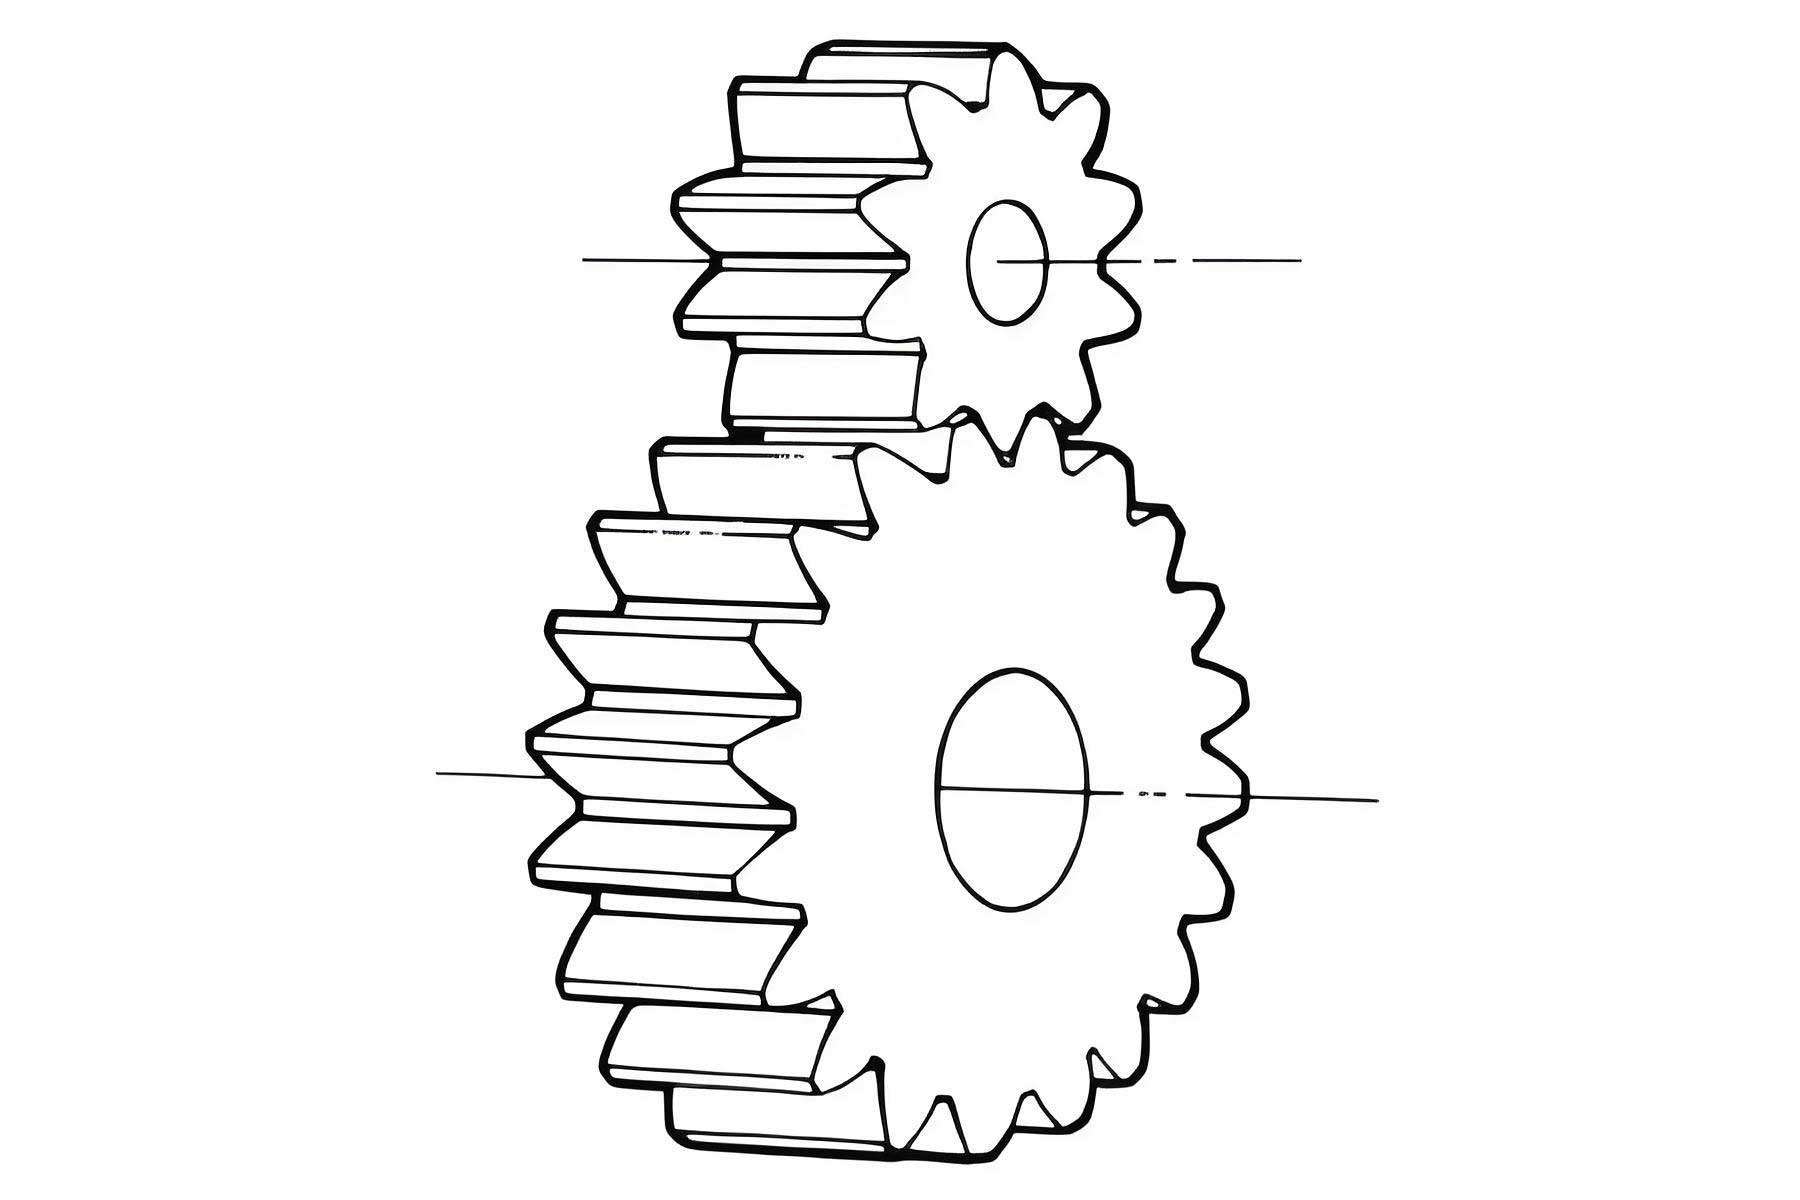
My research deals with the contact stiffness and damping of an elastohydrodynamically lubricated (EHL) spur gear pair. The need for high power density and low vibration in modern transmission systems makes accurate modeling of gear tooth contact behavior essential. The deformation of meshing teeth under load acts as one of the internal excitation sources for gear vibration. Since gears usually operate under lubricated conditions, the oil film between tooth surfaces not only deforms elastically but also dissipates energy through viscous shear during dynamic loading. This energy dissipation gives rise to the oil film damping effect. In my work I developed analytical and numerical models for evaluating the contact stiffness, the oil film stiffness, and the oil film damping of lubricated spur gear contacts. I studied how operating conditions, surface roughness, starvation degree, and gear design parameters influence these quantities.
1. Background of My Research on Spur Gears
In the field of gear transmission, a spur gear pair is widely used because of its simple geometry and high efficiency. In the meshing process, the tooth surfaces are subjected to cyclic contact stresses and relative sliding motion. To avoid direct metal-to-metal contact, a lubricating film is introduced between the tooth surfaces. Under typical operating conditions the pressure in this film is sufficiently high to cause elastic deformation of the contacting bodies, a regime known as elastohydrodynamic lubrication (EHL).
For a spur gear pair, the contact between the meshing tooth surfaces can be modeled as a two-dimensional line contact between two elastic cylinders. The oil film thickness and the pressure distribution along the contact width are governed by the Reynolds equation coupled with the elasticity equation of the contacting solids. The transient behavior of the oil film, especially during dynamic loading, is crucial for the dynamic response of the gear system. The damping caused by lubricant squeeze film effects has been identified as a key factor in suppressing gear vibration.
One of the main difficulties in gear dynamics is the evaluation of the mesh stiffness and damping values. While the structural stiffness of gear teeth (due to bending, shear, and fillet flexibility) has been studied extensively, the contribution of the oil film to the overall mesh stiffness is rarely considered. In my study I attempted to fill this gap by investigating the oil film stiffness and damping as separate yet coupled contributions for spur gears.
2. Numerical Model of Elastohydrodynamic Lubrication
My work first required a robust numerical solver for the EHL line contact problem. The classical steady-state Reynolds equation for a Newtonian fluid is written as:
$$
\frac{\partial}{\partial x}\left(\frac{\rho h^{3}}{\eta}\frac{\partial p}{\partial x}\right) – 12 u_r \frac{\partial (\rho h)}{\partial x}=0
$$
where \(x\) is the flow direction, \(\rho\) the density of the lubricant, \(h\) the film thickness, \(\eta\) the dynamic viscosity, \(p\) the pressure, and \(u_r\) the rolling speed (entrainment velocity). For the transient case, the Reynolds equation becomes:
$$
\frac{\partial}{\partial x}\left(\frac{\rho h^{3}}{\eta}\frac{\partial p}{\partial x}\right) – 12 u_r \frac{\partial (\rho h)}{\partial x} – 12 \frac{\partial (\rho h)}{\partial t}=0
$$
The film thickness equation for a smooth surface condition is given by:
$$
h(x,t) = h_0(t) + \frac{x^2}{2R} – \frac{4}{\pi E’}\int_{-\infty}^{+\infty} \ln|x-x’| p(x’,t)\, dx’
$$
where \(h_0\) is the normal approach (rigid body displacement), \(R\) the equivalent radius of curvature, and \(E’\) the effective elastic modulus defined as:
$$
\frac{1}{E’} = \frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2}
$$
with \(E_1, E_2\) and \(\nu_1, \nu_2\) being the elastic moduli and Poisson’s ratios of the two contacting bodies.
The viscosity of the lubricant was modeled using the Roelands equation:
$$
\eta(p) = \eta_0 \exp\left\{(\ln\eta_0 + 9.67)\left[\left(1+\frac{p}{p_0}\right)^z – 1\right]\right\}
$$
with \(z = 0.68\) and \(p_0 = 5.1\times10^9\) Pa. The density was described by the Dowson-Higginson relation:
$$
\rho(p) = \rho_0 \frac{0.59\times10^9 + 1.34 p}{0.59\times10^9 + p}
$$
The load balance equation requires that the integral of the pressure distribution over the contact domain equals the applied normal force per unit width:
$$
\int_{-\infty}^{+\infty} p(x,t)\, dx = F(t)
$$
where \(F(t)\) is the time-varying line load.
For numerical convenience, I used the Hertzian dimensionless variables:
$$
X = \frac{x}{b_H}, \quad P = \frac{p}{p_H}, \quad H = \frac{h R}{b_H^2}, \quad T = \frac{t u_r}{b_H}
$$
where the Hertzian half-width \(b_H\) and maximum Hertzian pressure \(p_H\) are:
$$
b_H = \sqrt{\frac{8 F R}{\pi E’}}, \quad p_H = \frac{2 F}{\pi b_H}
$$
The dimensionless Reynolds equation takes the form:
$$
\frac{\partial}{\partial X}\left(\varepsilon \frac{\partial P}{\partial X}\right) – \frac{\partial (\rho H)}{\partial X} – \frac{\partial (\rho H)}{\partial T}=0
$$
with \(\varepsilon = \frac{\rho H^3}{\eta \lambda}\) and \(\lambda = \frac{12 u_r \eta_0 R^2}{b_H^3 p_H}\).
A hybrid relaxation scheme was used to solve the discretized equations. When \(\varepsilon/\Delta X^2\) is large, a Gauss-Seidel iteration is adopted; when \(\varepsilon/\Delta X^2\) is small, a Jacobi distributive iteration is used. This mixed approach ensures fast convergence and numerical stability over a wide range of operating conditions.
I examined the mesh convergence using node numbers of 64, 256, and 1024. The results show that when the number of nodes exceeds 2000, the minimum and central film thickness values stabilize, as shown in the following table:
| Number of Nodes | Dimensionless Minimum Film Thickness | Dimensionless Central Film Thickness |
|---|---|---|
| 64 | 0.0412 | 0.0523 |
| 256 | 0.0387 | 0.0498 |
| 1024 | 0.0365 | 0.0471 |
| 2048 | 0.0352 | 0.0456 |
| 4096 | 0.0351 | 0.0455 |
I selected \(N_X = 2048\) as the optimal balance between accuracy and computational efficiency. The numerical model was validated against the Dowson-Higginson empirical formulas for minimum and central film thickness over a wide range of loads. The maximum deviation was within \(10^{-8}\) m, which confirms the accuracy of my solver.
3. Contact Stiffness of a Spur Gear Pair
Contact stiffness represents the resistance of the contacting bodies to elastic deformation. In my work I used two analytical models for the contact stiffness of a spur gear pair.
3.1 Hertz Contact Stiffness
The Hertz contact theory provides the maximum elastic deformation at the center of the contact area for a line contact configuration:
$$
\delta_{max} = \frac{R}{2} – \frac{R}{2}\sqrt{1 – \frac{b_H^2}{R^2}} \approx \frac{b_H^2}{2R}
$$
After simplification, the load-displacement relationship becomes:
$$
f = \frac{\pi E’ B}{8R}\left(2R\delta_{max} – \delta_{max}^2\right)
$$
where \(B\) is the contact length. Differentiating the load with respect to the maximum deformation gives the Hertzian contact stiffness:
$$
k_{cHertz} = \frac{df}{d\delta_{max}} = \frac{\pi E’ B}{4R}\sqrt{R – \delta_{max}}
$$
3.2 Yang-Sun Contact Stiffness
Yang and Sun proposed a linearized load-deformation relationship for gear dynamics modeling:
$$
f = \frac{\pi E’ B}{4(1-\nu^2)}\delta_{max}
$$
which directly leads to a constant contact stiffness independent of load:
$$
k_{cY-S} = \frac{\pi E’ B}{4(1-\nu^2)}
$$
My calculations show that for a typical spur gear pair with \(B=0.01\) m, \(E’=2.2\times10^{11}\) Pa, and \(R=0.01\) m, the Hertz contact stiffness varies only slightly with load, ranging from \(1.7245\times10^9\) N/m to \(1.726\times10^9\) N/m when the load changes from \(2.5\times10^4\) N/m to \(6.25\times10^5\) N/m. The Yang-Sun stiffness, though about 10% higher in magnitude, exhibits the same order of magnitude as the Hertzian result. This confirms that the linearized load-deformation assumption is reasonable for gear dynamics applications.
| Model | Expression | Load Dependence |
|---|---|---|
| Hertz | \(k_{cHertz} = \frac{\pi E’ B}{4R}\sqrt{R – \delta_{max}}\) | Weak |
| Yang-Sun | \(k_{cY-S} = \frac{\pi E’ B}{4(1-\nu^2)}\) | None |
4. Oil Film Stiffness Calculation Methods
In my study I proposed four different approaches to evaluate the oil film stiffness of an EHL lubricated spur gear pair. The oil film stiffness describes the relationship between the change in normal load and the corresponding change in oil film thickness.
4.1 Empirical Formula Methods
The Dowson-Higginson minimum film thickness empirical formula is:
$$
h_m = 2.65 U^{0.7} G^{0.54} W^{-0.13} R
$$
where \(U = \frac{\eta_0 u_r}{E’ R}\), \(G = \alpha_l E’\), and \(W = \frac{F}{E’ R}\) are the dimensionless speed, material, and load parameters respectively. Differentiating this expression yields the minimum film thickness-based oil film stiffness:
$$
k_{hm} = 7.69 B E’ R U^{0.7} G^{0.54} (2.65 h_m)^{-7.69}
$$
Similarly, the Dowson-Higginson central film thickness formula is:
$$
h_c = 3.06 U^{0.69} G^{0.56} W^{-0.10} R
$$
leading to the central film thickness-based oil film stiffness:
$$
k_{hc} = 10 B E’ R U^{0.69} G^{0.56} (3.06 h_c)^{-10}
$$
4.2 Numerical Methods
For more general conditions, such as those involving roughness or starvation, the empirical formulas are not directly applicable. I therefore proposed a global method and an average film thickness method based on my numerical EHL solver.
Global Method: This method treats the oil film as a collection of parallel small springs distributed over the contact area. The global oil film stiffness is obtained by summing the local stiffness contributions:
$$
k_{glo} = \sum_{i=n_1}^{n_2} \frac{\Delta f_i}{\Delta h_i}
$$
where \(\Delta f_i = B p_i \Delta x\) is the load increment at nodal position \(i\), and \(\Delta h_i = h_i(f) – h_i(f+\Delta f)\) is the corresponding film thickness change.
Average Film Thickness Method: This simpler approach uses the total load increment and the change in the average film thickness within the pressurized region:
$$
k_{ave} = \frac{\Delta f}{\Delta h}
$$
where \(\Delta h\) is computed by averaging the film thickness over the entire contact region before and after the load increment.
I investigated the sensitivity of the numerical oil film stiffness to the load increment \(\Delta f/f\). The results show that for a wide range of loaded cases from light load to heavy load and from low speed to high speed, the effect of \(\Delta f/f\) is negligible. I chose \(\Delta f/f = 0.0125\) for all subsequent calculations.
| Method | Symbol | Type | Basis |
|---|---|---|---|
| Hertz contact stiffness | \(k_{cHertz}\) | Analytical | Hertz deformation equation |
| Yang-Sun contact stiffness | \(k_{cY-S}\) | Analytical | Yang-Sun linearized model |
| Minimum film method | \(k_{hm}\) | Analytical | Dowson-Higginson minimum film equation |
| Central film method | \(k_{hc}\) | Analytical | Dowson-Higginson central film equation |
| Global method | \(k_{glo}\) | Numerical | Summation of local springs |
| Average film method | \(k_{ave}\) | Numerical | Average film thickness variation |
5. Effects of Operating Conditions on Oil Film Stiffness for Spur Gears
I studied the influence of load and entrainment speed on the oil film stiffness of spur gears over a wide parameter range. The load was varied from \(1\times10^5\) N/m to \(2\times10^6\) N/m, and the rolling speed from 0.1 m/s to 10 m/s. The Moes parameters \(M\) and \(L\) were used to characterize the operating conditions:
$$
M = \frac{F}{E’ R}\left(\frac{2\eta_0 u_r}{E’ R}\right)^{3/4}, \quad L = \alpha_l E’\left(\frac{2\eta_0 u_r}{E’ R}\right)^{1/4}
$$
The minimum film thickness decreases with increasing load but increases with increasing speed. I observed that the oil film stiffness increases with increasing load and decreases with increasing rolling speed, consistent with the physical interpretation: heavier loads compress the film, making further compression more difficult; higher speeds produce a thicker film, making the film easier to compress.
The four calculation methods gave very consistent results over the entire range of operating conditions.
$$
k_{oil} \approx \left(10^{11} \sim 10^{12}\right) \, \mathrm{N/m}
$$
At the same operating condition, the oil film stiffness is 2 to 3 orders of magnitude higher than the contact stiffness. This indicates that the oil film acts as a very stiff spring in the contact zone of spur gears, which should not be ignored in gear dynamic modeling.
6. Effect of Surface Roughness on the Oil Film Stiffness
Engineering gear tooth surfaces are always rough. To study this effect systematically, I introduced a regular sinusoidal roughness into the film thickness equation:
$$
rr = a \cos\left(\frac{2\pi x}{\lambda}\right)
$$
where \(a\) is the real amplitude of roughness and \(\lambda\) is the dimensionless wavelength. The normalized roughness amplitude and wavelength are defined as:
$$
Amp = \frac{a}{b_H^2/(2R)}, \quad \lambda = \frac{\Lambda}{b_H}
$$
where \(\Lambda\) is the dimensional wavelength.
I ran a series of simulations with different loads (1.5×10⁶ N/m), speeds (3 m/s and 7 m/s), roughness amplitudes (0.1 μm, 0.2 μm, 0.3 μm), and wavelengths (0.1, 0.2, 0.5, 1.0). The results show that:
- The pressure ripples and film thickness fluctuations become more pronounced as the roughness amplitude increases.
- Higher loads tend to flatten the roughness, weakening its influence on pressure and film profile.
- The oil film stiffness decreases slightly with increasing roughness amplitude.
- The oil film stiffness increases with increasing surface roughness wavelength.
This suggests that gears with smoother surfaces exhibit higher oil film stiffness under identical operating conditions. Surface finish quality is therefore important for ensuring high stiffness and stable dynamic behavior of spur gears.
7. Effects of Starvation on the Oil Film Stiffness
In many practical situations, the inlet zone of the contact may not be fully flooded with oil, leading to starved lubrication conditions. I modeled this by using the Elrod cavitation algorithm, which introduces a partial film proportion parameter \(\theta\). The modified Reynolds equation for starved conditions is:
$$
\frac{\partial}{\partial X}\left(\varepsilon \frac{\partial P}{\partial X}\right) – \frac{\partial (\theta \rho H)}{\partial X} – \frac{\partial (\theta \rho H)}{\partial T}=0
$$
with the complementary condition:
$$
P(X)[1.0 – \theta(X)] = 0.0
$$
In the pressurized region, \(P > 0\) and \(\theta = 1\), while in the cavitated region, \(P = 0\) and \(0 < \theta < 1\). The boundary value of \(\theta\) at the inlet is given by:
$$
\theta_{in} = \frac{H_{oil}}{H_{in}}
$$
where \(H_{oil}\) is the inlet oil film thickness and \(H_{in}\) is the inlet gap height.
My results show that the minimum film thickness increases with the inlet oil supply until reaching a plateau corresponding to fully flooded conditions. The oil film stiffness exhibits a more complex behavior with starvation depending on the rolling speed:
- At low rolling speed (0.1 m/s), the oil film stiffness first increases with the inlet oil supply and then remains nearly constant once full flooding is approached.
- At high rolling speed (3 m/s), the oil film stiffness decreases as the inlet oil supply increases.
These trends highlight the importance of maintaining an adequate oil supply for stable lubrication conditions in a spur gear pair, not only for film thickness consideration but also for stiffness characteristics.
8. Oil Film Damping Calculation Models
The damping of the oil film in an EHL contact is a consequence of the squeeze film effect caused by the relative normal motion of the two contacting surfaces. In my research I proposed two methods to quantify the oil film damping coefficient for spur gears.
8.1 Harmonic Vibration Method
In the harmonic excitation approach, a sinusoidal load is applied to the contact system:
$$
f(t) = f_0 + f_a \sin(\omega t)
$$
where \(f_0\) is the average load, \(f_a\) is the amplitude of the alternating load component, and \(\omega\) is the angular frequency. The dimensionless form of the motion equation is:
$$
\frac{1}{\pi}\int P(X,T)\, dX = 1 + A_f \sin(\Omega_e T)
$$
where \(A_f = f_a/f_0\) is the dimensionless load amplitude and \(\Omega_e = \omega b_H/u_r\) is the dimensionless angular frequency.
The dimensionless damping force can be written as:
$$
W_C(T) = D \dot{H}(T)
$$
where \(D\) is the dimensionless damping coefficient. The energy dissipated per cycle by the damping force is given by:
$$
E_C = \int_0^{T_e} W_C(T)\, dH(T) = -\pi \Omega_e A_f^2 D
$$
where \(T_e = 2\pi/\Omega_e\) is the dimensionless period. From this expression, the dimensionless damping coefficient \(D\) is obtained, and the dimensional damping coefficient becomes:
$$
c_{har} = \frac{D f_0 R}{B u_r b_H}
$$
8.2 Free Vibration Method
In the free vibration approach, a constant load is applied and an initial displacement away from the equilibrium position is imposed. The system then performs a damped free vibration until it reaches the steady state. The equation of motion for the equivalent single-degree-of-freedom system is:
$$
m_c \Delta \ddot{h}_0 + c_{free} \Delta \dot{h}_0 + k_o \Delta h_0 = 0
$$
where \(m_c = \pi \rho_c R^2 B\) is the equivalent mass, and \(k_o\) is the effective oil film stiffness. By integrating the energy dissipation over the entire transient response, I derived the following expression for the free vibration damping coefficient:
$$
c_{free} = \frac{k_o \left[\Delta h_0(0)\right]^2}{2\int_0^{\infty} \left[\Delta \dot{h}_0(t)\right]^2 dt}
$$
This energy-based method accounts for the entire response history, making it more robust than the traditional logarithmic decrement approach.
8.3 Validation and Comparison
I also compared my numerical results with the empirical fitting formula proposed by Ankouni et al.:
$$
D = \frac{4.3 L M^{1.2}}{1 + (3/L)^{0.85}}
$$
where \(M\) and \(L\) are the Moes parameters. The corresponding dimensional damping coefficient is:
$$
c_{M} = \frac{D f_0 R}{B u_r b_H}
$$
| Method | Symbol | Principle |
|---|---|---|
| Harmonic vibration | \(c_{har}\) | Damping hysteresis loop under sinusoidal excitation |
| Free vibration | \(c_{free}\) | Energy conservation during damped free vibration |
| Fitting formula | \(c_M\) | Empirical formula of Ankouni et al. |
9. Dynamic Characteristics of the EHL Contact System
I analyzed the dynamic response of the contact-vibration system under both harmonic excitation and free vibration conditions. The pressure profile and oil film thickness exhibit periodic oscillations at the same frequency as the applied sinusoidal load.
The phase lag between the external excitation and the system response is the source of the damping hysteresis loop. For the sinusoidal load case, the vibration system shows a modulated wave traveling through the contact region when observed at different time instants within one cycle.
I studied the influence of the excitation frequency and the load amplitude on the oil film damping coefficient. The results are summarized below:
| Parameter | Range | Effect on Oil Film Damping |
|---|---|---|
| Dimensionless frequency \(\Omega_e\) | 0.5 – 6 | Negligible |
| Dimensionless amplitude \(A_f\) | 0.1 – 0.9 | Minor (weakly nonlinear) |
| Line load \(F\) | 5×10⁵ – 9×10⁵ N/m | Damping decreases with increasing load |
| Rolling speed \(u_r\) | 0.3 – 10 m/s | Damping decreases with increasing speed |
For the free vibration case, I examined three different initial displacement perturbations: \(H_0(T=0) = 0.2\), 0.4, and 0.6. The results show that although the initial amplitude of the response scales with the magnitude of the initial perturbation, the system always reaches the same equilibrium position, which corresponds to the steady-state film thickness under the applied constant load. The damping ratio and logarithmic decrement increase with increasing load but decrease with increasing rolling speed.
10. Application to a Spur Gear Pair Dynamics
The load of a spur gear pair along the line of action (LOA) is not constant during the meshing cycle. Teeth alternate between single and double pair contact, causing abrupt load changes. The load distribution is given by:
$$
F = \frac{T_1}{R_{p1} B}
$$
where during double tooth contact the load is halved compared to the single tooth contact, and transitions follow a triangular distribution pattern along the contact path.
For a typical FZG type A gear pair with input torque \(T_1 = 300\) N·m and speed \(n_1 = 1000\) r/min, the minimum film thickness is lower in the single tooth mesh region than in the double tooth mesh region. The reason is straightforward: the load is higher when only one pair of teeth is in contact. The lowest film thickness occurs at the lowest and highest points of single tooth contact, which are therefore the critical positions for potential surface failure of spur gears.
10.1 Gear Geometry and Kinematics
I used the following geometry parameters:
| Parameter | Symbol | Value |
|---|---|---|
| Transmission ratio | \(i\) | 1.5 |
| Module | \(m\) | 0.0045 m |
| Pinion teeth number | \(z_1\) | 16 |
| Wheel teeth number | \(z_2\) | 24 |
| Addendum coefficient | \(h_a^*\) | 1 |
| Pressure angle | \(\alpha\) | 20° |
| Face width | \(B\) | 0.01 m |
The meshing geometry of the spur gear pair is described by the following equations. The pitch circle radii of the pinion and wheel are:
$$
R_{p1} = \frac{m z_1}{2}\frac{\cos\alpha}{\cos\alpha’}, \quad R_{p2} = \frac{m z_2}{2}\frac{\cos\alpha}{\cos\alpha’}
$$
The base circle radii are:
$$
R_{b1} = \frac{m z_1}{2}\cos\alpha, \quad R_{b2} = \frac{m z_2}{2}\cos\alpha
$$
The equivalent radius of curvature at the contact point is:
$$
R = \frac{R_1 R_2}{R_1 + R_2}
$$
where \(R_1 = R_{p1}\sin\alpha’ + \zeta\) and \(R_2 = R_{p2}\sin\alpha’ – \zeta\), with \(\zeta\) being the distance from the pitch point to the current contact point on the line of action.
The entrainment velocity and sliding velocity at the meshing point are:
$$
u_r = \frac{u_1 + u_2}{2}, \quad u_s = u_1 – u_2
$$
with \(u_1 = \pi n_1 R_1 / 30\) and \(u_2 = \pi n_2 R_2 / 30\). At the pitch point, \(u_1 = u_2\) so that \(u_s = 0\).
10.2 Oil Film Stiffness of the Spur Gear Pair along the Line of Action
I computed the oil film stiffness of the FZG gear pair along the line of action using the four methods described earlier. The results show that the oil film stiffness in the single tooth contact zone is larger than that in the double tooth contact zone. This can be attributed to the higher load in the single contact zone, which compresses the film more severely.
I evaluated the influence of the input torque on the oil film stiffness of the spur gear pair. Increasing the input torque from 100 N·m to 600 N·m increases the oil film stiffness substantially, and the jumps at the single/double tooth transition points become more severe.
I also investigated the influence of the input speed on the oil film stiffness of the spur gear pair. In the range from 500 r/min to 4000 r/min, the oil film stiffness decreases as the input speed increases. At lower speeds the load-induced jumps are stronger; at higher speeds the stiffness variation becomes smoother.
10.3 Oil Film Damping of the Spur Gear Pair along the Line of Action
The oil film damping of the spur gear pair was also evaluated along the line of action. In general, the damping is lower in the single tooth contact zone than in the double tooth contact zone. This implies that the energy dissipation capability is weaker in the single tooth contact zone, making it more prone to vibration-related problems.
With increasing input torque, the damping decreases; with increasing input speed, the damping also decreases across all positions of the line of action.
10.4 Effect of Profile Shift on the Oil Film Stiffness and Damping of Spur Gears
I compared a type A FZG spur gear (profile shift coefficients \(x_1 = 0.8532\) and \(x_2 = -0.5\)) with a type C FZG gear (profile shift coefficients \(x_1 = 0.1817\) and \(x_2 = -0.1715\)). The results show that the two gear types have significantly different meshing behavior. The type C gear has a longer line of action and a shorter double tooth contact zone. Its rolling speed is higher and the equivalent radius of curvature is smaller, which collectively lower the oil film stiffness and damping compared to the type A gear.
This confirms that the choice of profile shift coefficients for a spur gear pair has a direct impact on the lubrication performance and the dynamic characteristics of the oil film.
11. Summary of the Key Findings
In my research, I developed a comprehensive framework for analyzing the contact stiffness, oil film stiffness, and oil film damping of EHL lubricated spur gear pairs. Some of the principal findings are summarized below:
| Quantity | Main Observations |
|---|---|
| Contact stiffness | Load has a small influence; independent of speed; Yang-Sun and Hertz models agree in magnitude |
| Oil film stiffness | Increases with load; decreases with speed; higher than contact stiffness by 2-3 orders of magnitude |
| Effect of roughness | Stiffness decreases slightly with amplitude; increases with wavelength |
| Effect of starvation | Stiffness varies with oil supply; low speed shows plateau; high speed shows monotonic decrease |
| Oil film damping | Independent of excitation amplitude and frequency; decreases with load and speed |
| Spur gear mesh | Stiffness higher in single contact zone; damping lower in single contact zone; affected by profile shift |
These results demonstrate that the oil film exerts considerable influence on the dynamic stiffness and damping characteristics of spur gears. It is therefore necessary to consider the lubricant film effects as an integral part of the tooth interface model for accurate gear dynamics prediction.
12. Conclusions
In this study I systematically developed the calculation approaches for the oil film stiffness and damping in EHL line contacts and applied them to a spur gear pair. The following points summarize my main conclusions:
- Both the Hertzian and Yang-Sun models yield comparable contact stiffness values for spur gears, confirming that linearization of the load-deformation relationship is acceptable for dynamic simulations.
- The oil film stiffness in EHL line contacts is two to three orders of magnitude larger than the contact stiffness, which should be included in gear mesh stiffness models.
- Oil film stiffness grows with load and diminishes with rolling speed. It is also sensitive to roughness amplitude, wavelength, and starved lubrication conditions.
- The damping coefficient of the oil film can be effectively quantified using either the harmonic vibration method or the energy-based free vibration method. The results from the two methods agree reasonably well and capture the expected physical trends.
- For a spur gear pair, the film stiffness and damping vary significantly along the line of action. Input torque and input speed affect these quantities in a predictable manner. Profile shift causes additional variations in the meshing parameters and thus changes the oil film behavior.
My work provides a step toward a more complete understanding of the coupled lubrication-dynamics behavior of spur gears. The proposed models can serve as a basis for developing more advanced gear dynamics frameworks that account for the time-varying lubricated contact effects. Future work will address the three-dimensional tooth contact with profile modification and actual surface roughness, as well as the coupling of the lubricated contact model with the full gear pair dynamics model.