
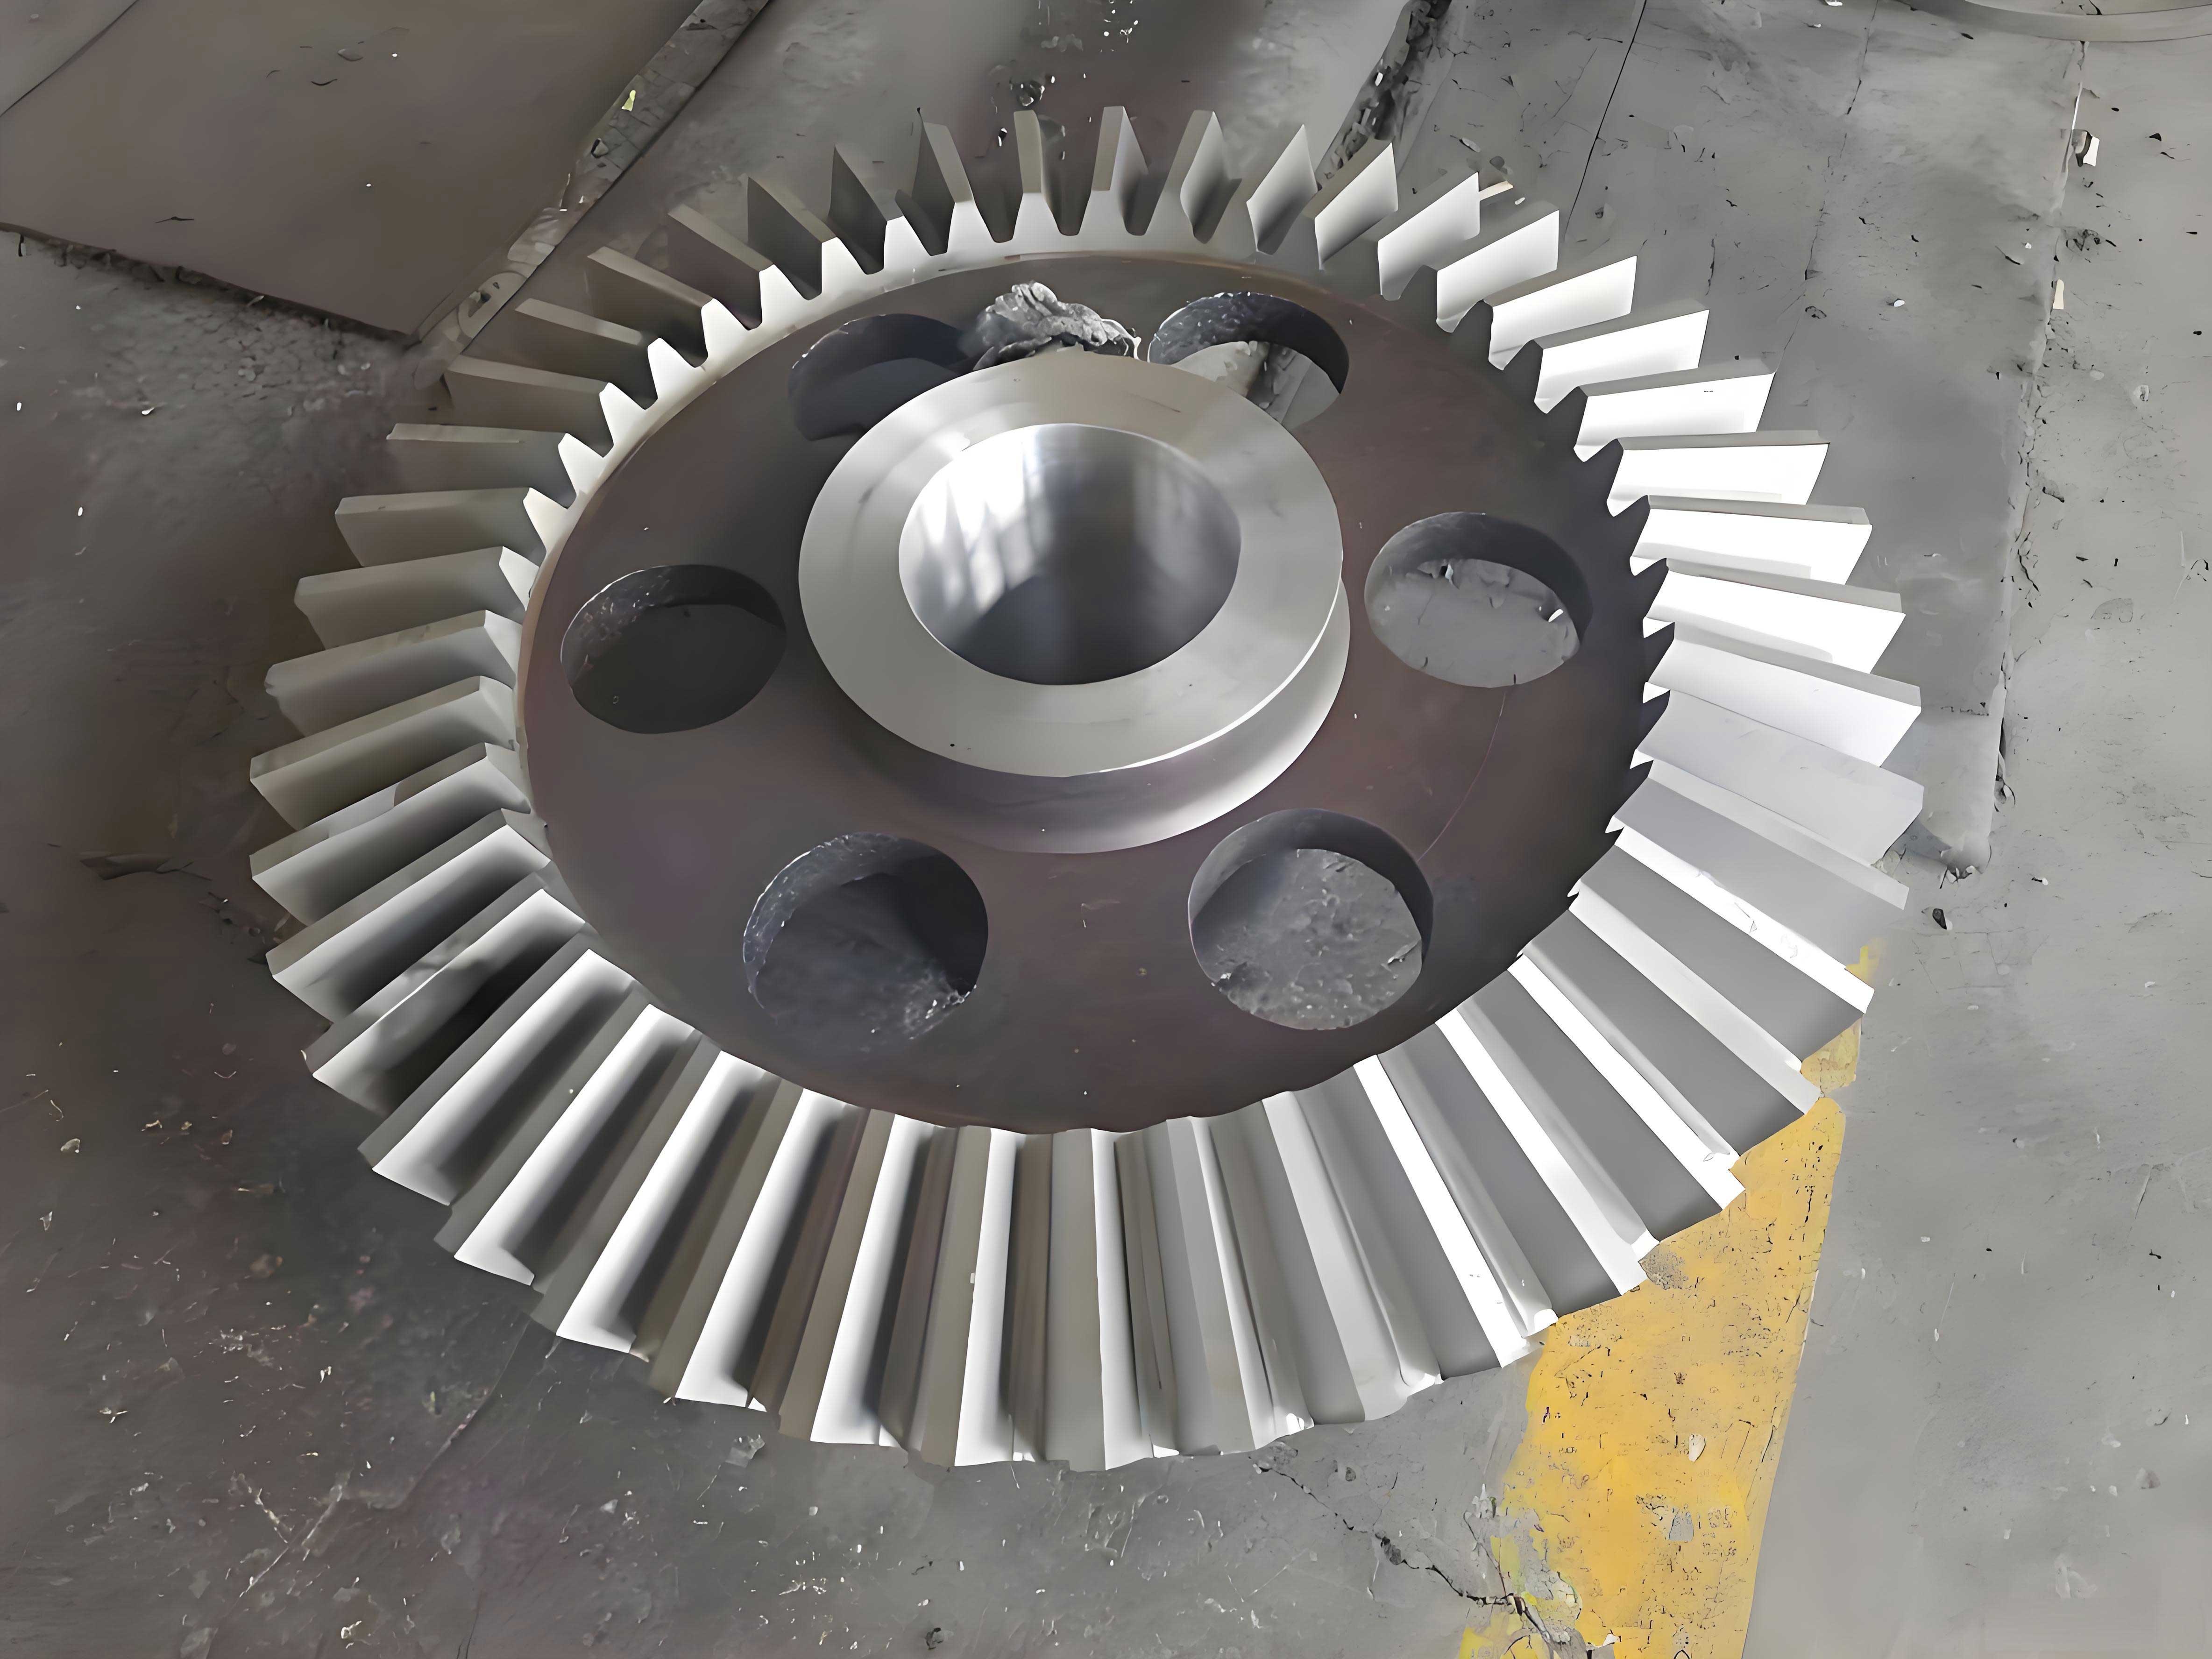
In this study, I investigate the tooth surface wear of miter gears from the perspective of irreversible process thermodynamics. Miter gears are widely used in high-speed and heavy-load transmission systems because of their high power density, smooth operation, and small axial force. However, tooth surface wear remains a critical issue that affects transmission efficiency, stability, and reliability. The wear mechanism of miter gears is complex and influenced by multiple nonlinear and strongly coupled factors, making it difficult to predict accurately using a single wear mechanism. Therefore, I develop a thermodynamic wear model for miter gears based on the degradation-entropy generation theorem, considering the effects of centering error. I validate the model through pin-on-disc wear tests and compare it with the Archard wear model. The results show that the thermodynamic wear model provides more accurate predictions under variable load and speed conditions. I further analyze the influence of surface roughness, torque, and rotational speed on the wear distribution of miter gears, and reveal the evolution of contact pressure and wear rate during the wear process.
Miter gears, especially those with a herringbone configuration, are often subjected to severe operating conditions. The wear of miter gears not only changes the tooth profile but also induces vibration and noise, accelerating fatigue failure. Understanding the wear behavior of miter gears is essential for improving their service life. Traditional wear models, such as the Archard model, are based on a single wear mechanism and do not account for the effects of contact temperature and friction coefficient variations. In contrast, irreversible process thermodynamics provides a unified framework for analyzing complex dissipative systems. The wear process of miter gears is inherently irreversible and dissipative, accompanied by entropy generation. Therefore, I adopt a thermodynamic approach to model the wear of miter gears.
1. Thermodynamic Principles of Wear
Classical thermodynamics deals with equilibrium states and reversible processes, while irreversible process thermodynamics extends to non-equilibrium and nonlinear phenomena. The wear of miter gears is a typical irreversible process involving energy dissipation and entropy production. The first law of thermodynamics for an open system can be expressed as:
$$dU = \delta Q – \delta W + \sum_i \mu_i dn_i$$
where \(dU\) is the change in internal energy, \(\delta Q\) is the heat transfer, \(\delta W\) is the work done by the system, \(\mu_i\) is the chemical potential, and \(dn_i\) is the change in mole number of component \(i\). The second law introduces entropy \(S\), which satisfies:
$$dS = d_eS + d_iS$$
Here, \(d_eS\) is the entropy exchange with the surroundings, and \(d_iS\) is the entropy generation due to irreversible processes. For a reversible process, \(d_iS = 0\); for an irreversible process, \(d_iS > 0\). The local entropy balance equation in Lagrangian form is:
$$\rho \frac{Ds}{Dt} = -\nabla \cdot \mathbf{J}_s + \dot{\chi}$$
where \(\rho\) is density, \(s\) is specific entropy, \(\mathbf{J}_s\) is entropy flux, and \(\dot{\chi}\) is the entropy generation rate per unit volume. Assuming negligible chemical potential gradients, the entropy flux is related to heat flux \(\mathbf{J}_q\) by \(\mathbf{J}_s = \mathbf{J}_q / T\). Using Fourier’s law \(\mathbf{J}_q = -\lambda \nabla T\), the entropy generation rate becomes:
$$\dot{\chi} = \frac{\lambda (\nabla T)^2}{T^2} + \frac{\boldsymbol{\sigma}_s : \dot{\boldsymbol{\varepsilon}}_p}{T} – \frac{\dot{E}_m}{T}$$
For metallic materials, the dissipation due to internal variables is small, and the dominant term is the plastic deformation work. In sliding wear, the friction work converts into heat, and the entropy generation rate can be approximated by:
$$\dot{S}_i = \frac{\mu N v}{T V}$$
where \(\mu\) is the friction coefficient, \(N\) is the normal load, \(v\) is the sliding speed, \(T\) is the contact temperature, and \(V\) is the volume. This equation links wear to irreversible entropy generation. The degradation-entropy generation theorem further relates the wear rate to entropy production through a degradation coefficient \(B\):
$$\dot{w}_v = B \dot{S}_g$$
Combining these, the wear rate for a tribo-pair is:
$$\dot{w}_v = B \frac{\mu N v}{T}$$
This thermodynamic wear model forms the basis for predicting the wear of miter gears.
2. Miter Gear Contact and Wear Model
The miter gears considered in this work have a herringbone configuration, which can be regarded as two opposite helical gear halves. The meshing process can be equivalent to the contact of two pairs of axially parallel conical rollers. The contact line length of miter gears varies dynamically during meshing. Based on the transverse contact ratio \(\varepsilon_\alpha\) and axial contact ratio \(\varepsilon_\beta\), the contact line length \(L(t)\) can be calculated as follows:
For \(\varepsilon_\alpha > \varepsilon_\beta\):
$$L(t) = \begin{cases}
\frac{p_{bt}}{\sin \beta} \frac{t}{T_m}, & 0 \leq t \leq \frac{\varepsilon_\beta T_m}{\varepsilon_\alpha} \\
\frac{b}{\cos \beta}, & \frac{\varepsilon_\beta T_m}{\varepsilon_\alpha} < t \leq \frac{\varepsilon_\alpha T_m}{\varepsilon_\alpha} \\
\frac{p_{bt}}{\sin \beta} \frac{T_m – t}{T_m}, & \frac{\varepsilon_\alpha T_m}{\varepsilon_\alpha} < t \leq T_m
\end{cases}$$
For \(\varepsilon_\alpha \leq \varepsilon_\beta\):
$$L(t) = \begin{cases}
\frac{p_{bt}}{\sin \beta} \frac{t}{T_m}, & 0 \leq t \leq \frac{\varepsilon_\alpha T_m}{\varepsilon_\beta} \\
\frac{p_{bt}}{\sin \beta}, & \frac{\varepsilon_\alpha T_m}{\varepsilon_\beta} < t \leq \frac{\varepsilon_\beta T_m}{\varepsilon_\beta} \\
\frac{p_{bt}}{\sin \beta} \frac{T_m – t}{T_m}, & \frac{\varepsilon_\beta T_m}{\varepsilon_\beta} < t \leq T_m
\end{cases}$$
where \(p_{bt}\) is the base pitch, \(b\) is the face width, \(\beta\) is the helix angle, and \(T_m\) is the meshing period. The total contact line length is the sum of all active contact lines. The load per unit length is then obtained by distributing the total normal load \(F_n\) according to the percentage of contact line length:
$$F_L(t) = \frac{F_n}{2 L_z(t)}$$
Based on Hertz contact theory, the contact half-width \(a_h\) and maximum contact pressure \(p_{\max}\) are:
$$a_h = \sqrt{\frac{4 F_L R^*}{\pi E^*}}$$
$$p_{\max} = \sqrt{\frac{F_L E^*}{\pi R^*}}$$
where \(R^*\) and \(E^*\) are the equivalent radius and equivalent elastic modulus, respectively. The average contact pressure is:
$$p_m = \frac{4}{3\pi} \frac{F_L}{a_h}$$
The sliding velocity between the miter gear teeth is calculated from the velocity components perpendicular to the line of action. For a point \(M\) on the line of action, the sliding velocity is:
$$\Delta v = \omega_1 N_1M – \omega_2 N_2M$$
The sliding distances for the pinion and gear are obtained by the single-point observation method:
$$s_p = 2 a_h \frac{v_y}{v_{1y}}, \quad s_g = 2 a_h \frac{v_{1y} – v_y}{v_{1y}}$$
The contact temperature \(T_c\) consists of the bulk temperature \(T_b\) and the flash temperature \(T_f\). The flash temperature for a rectangular heat source is calculated as:
$$T_f = \frac{2 a_h q_t}{\sqrt{\pi} \left( K_p \sqrt{1+P_{ep}} + K_g \sqrt{1+P_{eg}} \right)}$$
where \(q_t\) is the average heat flux, \(K_p\) and \(K_g\) are thermal conductivities, and \(P_{ep}\) and \(P_{eg}\) are Peclet numbers. For mixed lubrication, the asperity contact load ratio \(L_a\) is introduced, and the wear depth at a discrete point \((m,n)\) on the meshing plane is:
$$h_{m,n} = B_w \frac{\mu_{b} P_{m,n} L_a}{T_{a,m,n}} s_{m,n}$$
where \(B_w\) is the wear degradation coefficient, \(\mu_b\) is the boundary friction coefficient, \(P_{m,n}\) is the contact pressure, \(T_{a,m,n}\) is the asperity contact temperature, and \(s_{m,n}\) is the sliding distance.
Centering error is an unavoidable manufacturing error in miter gears with a relief groove. It causes one side of the gear to contact earlier than the other. The difference in contact pressure between the early-contact side and the delayed-contact side is:
$$\Delta F = k_h \Delta_c$$
where \(k_h\) is the mesh stiffness of one side and \(\Delta_c\) is the centering error. After wear occurs, the centering error changes to:
$$\Delta_c’ = \Delta_c + h_{l1} + h_{l2} – h_{r1} – h_{r2}$$
where \(h_{l1}, h_{l2}\) and \(h_{r1}, h_{r2}\) are the wear depths on the left and right sides of the pinion and gear, respectively. This coupling between wear and centering error is considered in the iterative wear calculation.
3. Experimental Validation
To validate the thermodynamic wear model, I conducted pin-on-disc wear tests using 45 steel as the material for both the pin and the disc. The test parameters are listed in Table 1.
| Test No. | Load (N) | Speed (r/min) | Time (min) | Sliding distance (m) | Wear mass (mg) |
|---|---|---|---|---|---|
| 1 | 65 | 100 | 20 | 84 | 13.45 |
| 2 | 65 | 90 | 20 | 79 | 12.60 |
| 3 | 60 | 90 | 20 | 79 | 11.74 |
The friction coefficient and contact temperature were recorded during the tests. The wear degradation coefficient \(B_w\) was calculated from the steady-state wear stage using:
$$B_w = \frac{m_v T}{\rho \mu N s}$$
where \(m_v\) is the wear mass, \(\rho\) is the density, \(s\) is the sliding distance, and \(T\) is the contact temperature. The average wear degradation coefficient for the 45 steel pair was found to be approximately \(3.02 \times 10^{-33} \, \text{m K/J}\). This value is consistent across different loads and speeds, confirming that it is a material property similar to the Archard wear coefficient.
To further validate the model, I conducted variable load and variable speed tests. The load sequence tests are summarized in Table 2, and the speed sequence tests in Table 3.
| Test No. | Load sequence (N) | Speed (r/min) | Time (min) |
|---|---|---|---|
| 1 | 60 → 70 → 80 → 100 | 100 | 14 |
| 2 | 80 → 70 → 60 → 100 | 100 | 14 |
| 3 | 80 → 60 → 70 → 100 | 100 | 14 |
| 4 | 70 → 80 → 60 → 100 | 100 | 14 |
| Test No. | Speed sequence (r/min) | Load (N) | Time (min) |
|---|---|---|---|
| 1 | 80 → 100 → 120 | 70 | 14 |
| 2 | 120 → 100 → 80 | 70 | 14 |
The experimental wear masses were compared with the predictions from the thermodynamic wear model and the Archard wear model. The results are shown in Table 4.
| Condition | Experimental (mg) | Archard model (mg) | Thermodynamic model (mg) |
|---|---|---|---|
| Load seq. 1 | 12.8 | 13.5 | 12.2 |
| Load seq. 2 | 12.5 | 13.2 | 11.9 |
| Load seq. 3 | 12.3 | 13.0 | 11.7 |
| Load seq. 4 | 12.6 | 13.3 | 12.0 |
| Speed seq. 1 | 11.9 | 12.8 | 11.4 |
| Speed seq. 2 | 12.1 | 13.1 | 11.6 |
The thermodynamic model predictions are consistently lower than the experimental values, which include the running-in wear. The Archard model tends to overestimate the wear under variable conditions because it neglects the effects of contact temperature and friction coefficient variations. The thermodynamic model, which accounts for these effects, provides more realistic predictions.
4. Wear Characteristics of Miter Gears
The geometric and working parameters of the miter gear pair used in the analysis are listed in Table 5.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth \(z\) | 37 | 95 |
| Normal module \(m_n\) (mm) | 15 | 15 |
| Normal pressure angle \(\alpha\) (°) | 20 | 20 |
| Face width per side (mm) | 170 | 170 |
| Helix angle \(\beta\) (°) | 20 | 20 |
| Input speed (r/min) | 150 | — |
| Input torque (N·mm) | 800 | — |
I first analyzed the effect of centering error on the contact characteristics. The average contact pressure, asperity contact pressure, contact temperature, and sliding distance all increase with increasing centering error. The early-contact side exhibits higher values than the delayed-contact side. For example, the maximum average contact pressure on the early-contact side is about 1.2 times that on the delayed-contact side when \(\Delta_c = 12 \, \mu\text{m}\).
Under dry friction, the wear distribution of the miter gear pair after \(1 \times 10^4\) meshing cycles is shown in Table 6. The wear depth is maximum at the engaging-in point and decreases nonlinearly toward the pitch point, then increases toward the engaging-out point. The wear distribution along the face width is non-uniform.
| Position | Early-contact side | Delayed-contact side |
|---|---|---|
| Engaging-in point | 2.85 | 2.12 |
| Pitch point | 0.45 | 0.38 |
| Engaging-out point | 1.92 | 1.48 |
Under mixed lubrication, the wear depth is significantly lower. Using the same gear pair, the wear depth after \(1 \times 10^5\) meshing cycles is shown in Table 7. The asperity contact pressure dominates the wear process, and the oil film reduces the wear by a factor of about 10 compared to dry friction.
| Position | Early-contact side | Delayed-contact side |
|---|---|---|
| Engaging-in point | 3.12 | 2.45 |
| Pitch point | 0.52 | 0.44 |
| Engaging-out point | 2.08 | 1.65 |
The surface roughness has a significant effect on the wear of miter gears. Table 8 shows the wear depth for different roughness values under mixed lubrication. As the roughness increases from 0.2 μm to 0.8 μm, the wear depth increases by more than 5 times. This is because a rougher surface reduces the film thickness ratio and increases the asperity contact load ratio.
| Roughness \(\sigma_r\) (μm) | Early-contact side | Delayed-contact side |
|---|---|---|
| 0.2 | 0.85 | 0.68 |
| 0.5 | 2.34 | 1.85 |
| 0.8 | 5.12 | 4.05 |
The input torque and rotational speed also affect the wear. Table 9 summarizes the wear depth under different torques and speeds. Increasing the torque increases the contact pressure and sliding distance, leading to higher wear. Increasing the speed, however, reduces the wear because the lubricant film is more easily formed and the asperity contact is reduced.
| Torque (N·mm) | Speed (r/min) | Early-contact side | Delayed-contact side |
|---|---|---|---|
| 600 | 150 | 1.85 | 1.42 |
| 800 | 150 | 3.12 | 2.45 |
| 1000 | 150 | 4.56 | 3.68 |
| 800 | 100 | 4.02 | 3.21 |
| 800 | 200 | 2.15 | 1.68 |
Finally, I analyzed the wear evolution process considering the coupling between wear and centering error. The wear depth and asperity contact pressure were updated every \(3 \times 10^6\) meshing cycles. The results show that the wear rate on the early-contact side decreases, while that on the delayed-contact side increases. After several updating steps, the wear rates near the engaging-in point become nearly equal on both sides, indicating that the wear process tends to compensate for the centering error. The contact pressure also tends to equalize, which is consistent with the wear evolution.
5. Conclusions
In this study, I developed a thermodynamic wear model for miter gears based on irreversible process thermodynamics and the degradation-entropy generation theorem. The main conclusions are as follows:
(1) The thermodynamic wear model provides more accurate predictions than the Archard model under variable load and speed conditions. The wear degradation coefficient is a material property that can be determined from pin-on-disc tests. For 45 steel, the average value is \(3.02 \times 10^{-33} \, \text{m K/J}\).
(2) The wear distribution of miter gears is non-uniform. Under dry friction, the maximum wear occurs at the engaging-in and engaging-out points, and the minimum wear occurs at the pitch point. Under mixed lubrication, the wear is significantly reduced, and the distribution is more affected by asperity contact.
(3) Centering error causes the early-contact side to experience higher contact pressure, temperature, sliding distance, and wear than the delayed-contact side. As the wear progresses, the difference in wear between the two sides decreases, and the wear rate tends to equalize near the engaging-in point.
(4) Surface roughness, torque, and rotational speed significantly influence the wear of miter gears. Lower roughness, lower torque, and moderate speed increase can reduce wear. The thermodynamic model can capture these effects by considering the contact temperature and friction coefficient variations.
The proposed model can serve as a theoretical tool for the anti-wear design of miter gears and for improving the accuracy of wear prediction. Future work will consider dynamic effects and the influence of wear on lubrication properties.